


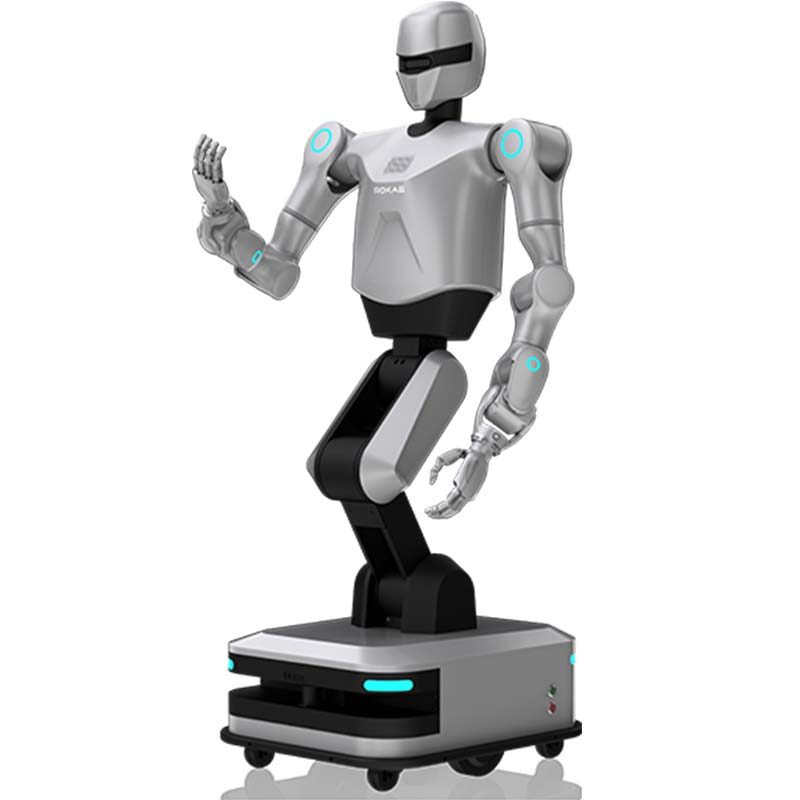
Helios, a Wheeled Dual-Arm Robot
The Helios is a humanoid or AI robot for research / reception. Key specifications: Industrial-grade motion positioning accuracy 10 mm; Arm manipulation accuracy ±0.1 mm; Full body degrees of freedom 42. Lead time is 90 days; pricing is quoted per configuration. Certifications: CE documentation on request.
- Model
- Helios
- Industrial-grade motion positioning accuracy
- 10mm;
- Arm manipulation accuracy
- ±0.1mm;
- Full body degrees of freedom
- 42;
- Multimodal fusion perception
- Pose-Vision-Force control strategy: Tactic of Pose + Vision + Force;
- Maximum payload per arm
- 5kg.
What This Platform Is For
Wheeled Dual-Arm Robot--- Helios! Industrial-grade motion positioning accuracy: 10mm; Arm manipulation accuracy: ±0.1mm; Full body degrees of freedom: 42; Multimodal fusion perception: Pose-Vision-Force control strategy: Tactic of Pose + Vision + Force; Maximum payload per arm: 5kg.
Commercial Terms
| Quotation | Priced per configuration — reply within 48 hours |
|---|---|
| Lead time | 90 days |
| MOQ | 1 unit |
| Origin | China |
| Port of loading | Shanghai, China |
| Incoterm | FOB Shanghai / CIF on request |
| Payment | 30% deposit, 70% before shipment |
| Warranty | 24 months standard, 36 months optional |
Product Details
Application notes, construction drawings and video from the TROY engineering file — the same documentation shipped with the quotation.
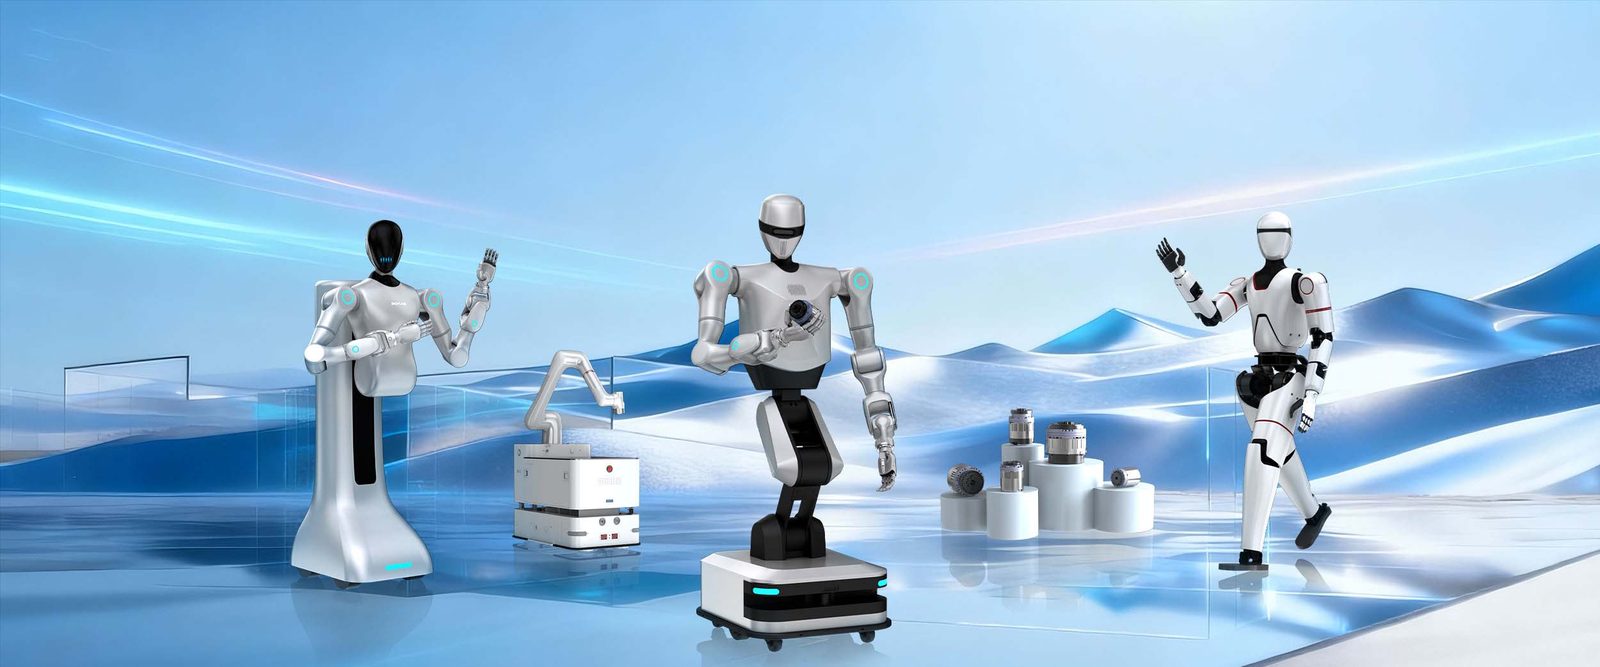
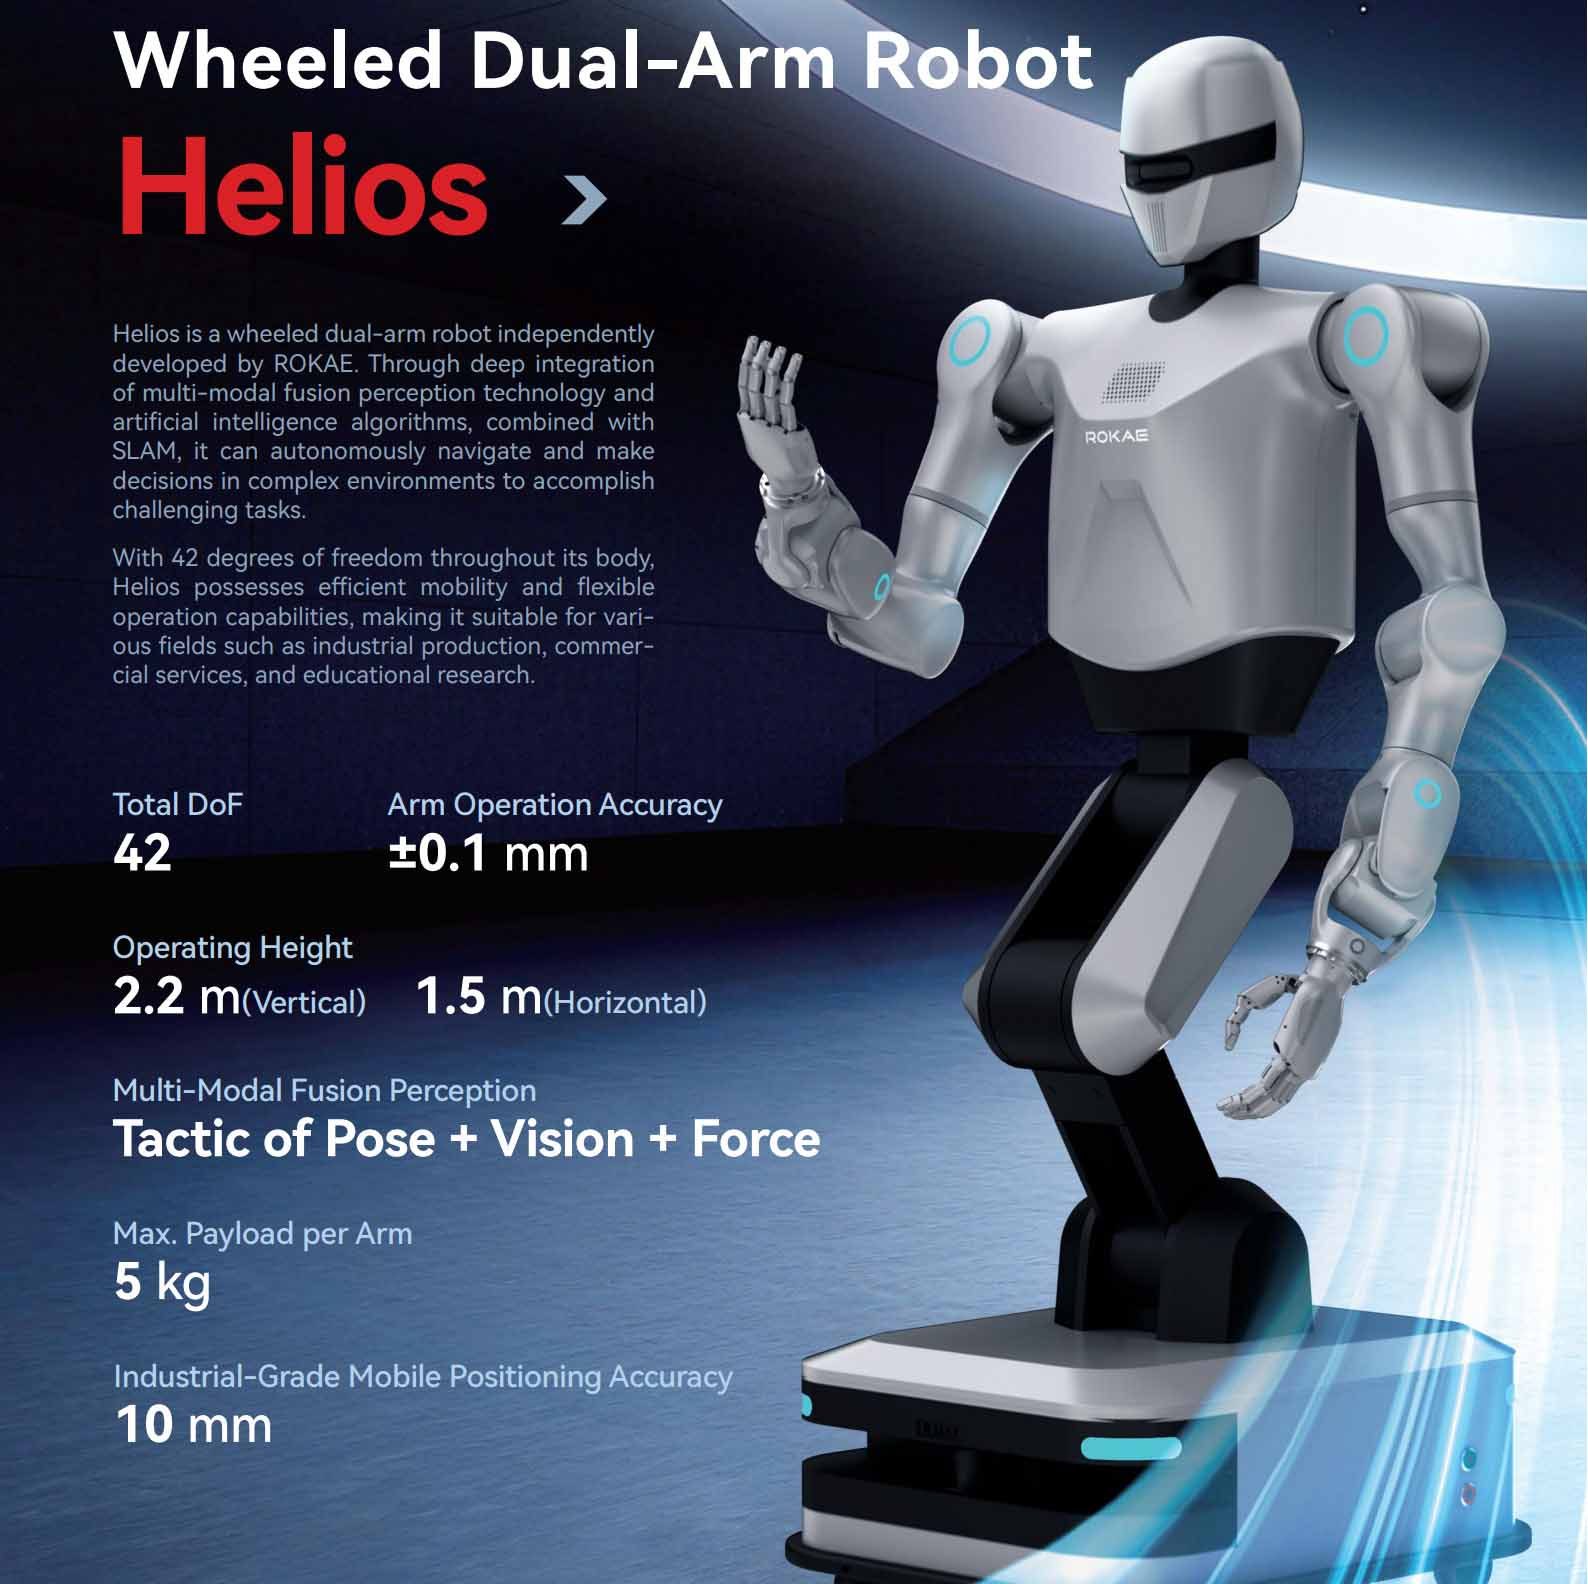
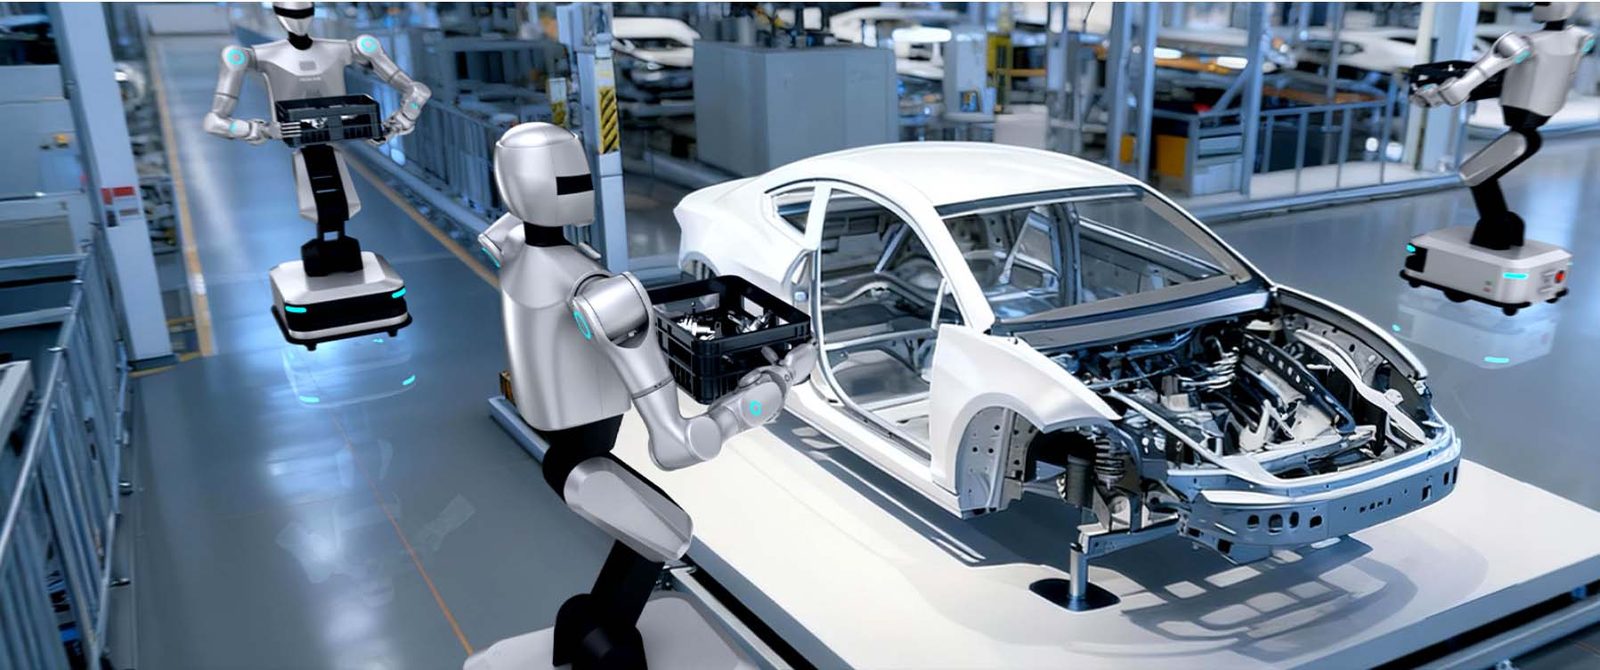
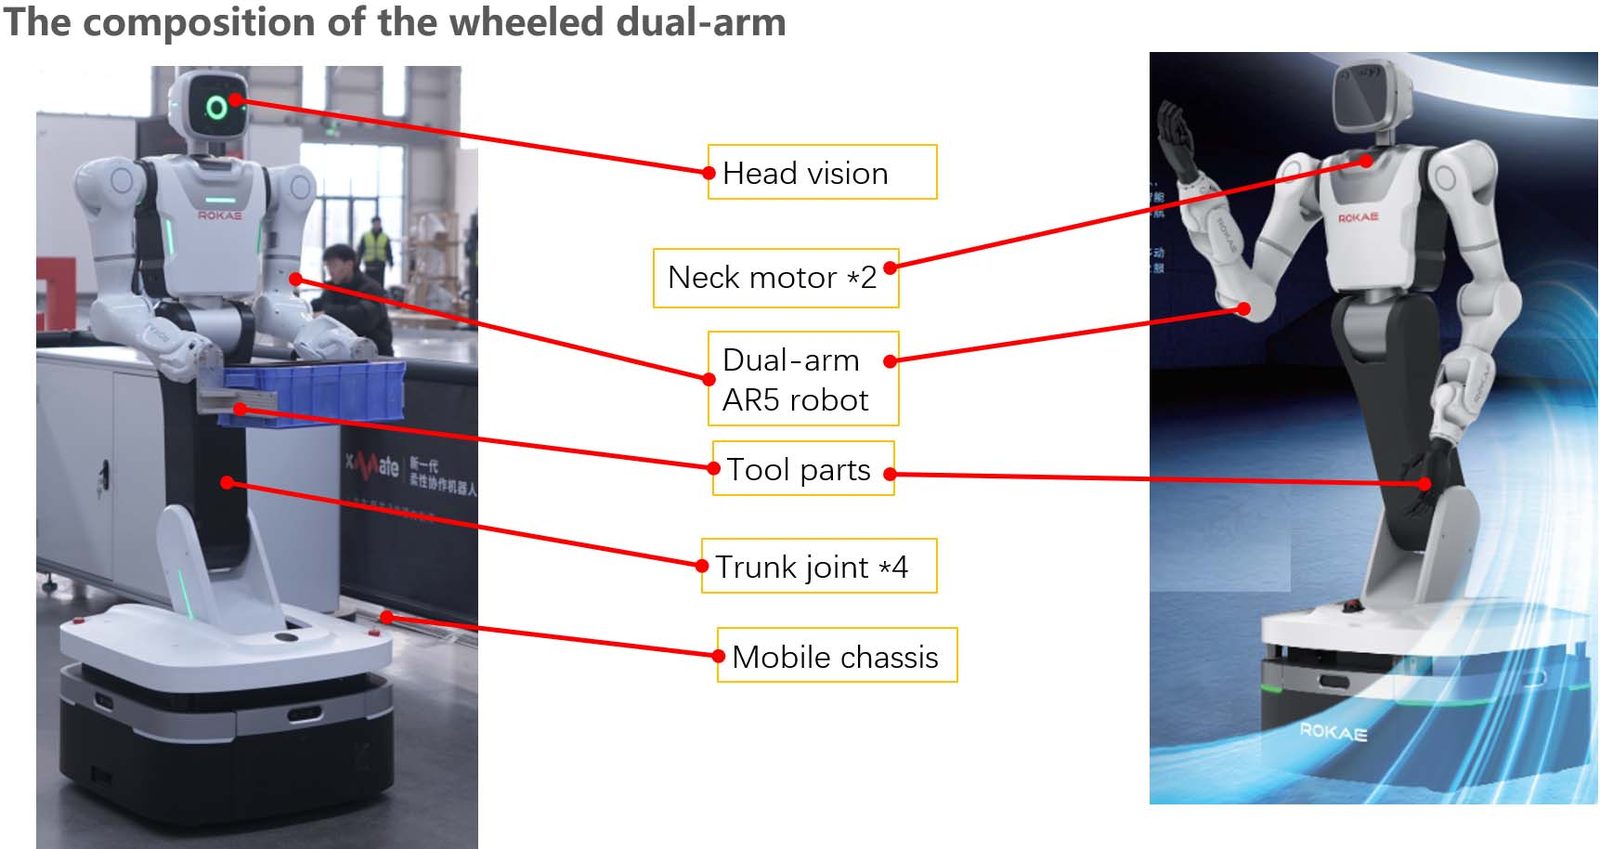
Helios is a wheeled dual-arm robot independently developed by Rokae. It achieves multimodal fusion perception through a posture-vision-force control strategy, combined with laser SLAM navigation. Without environmental modification, it can autonomously navigate and make decisions in complex scenarios, capable of handling various challenging tasks.
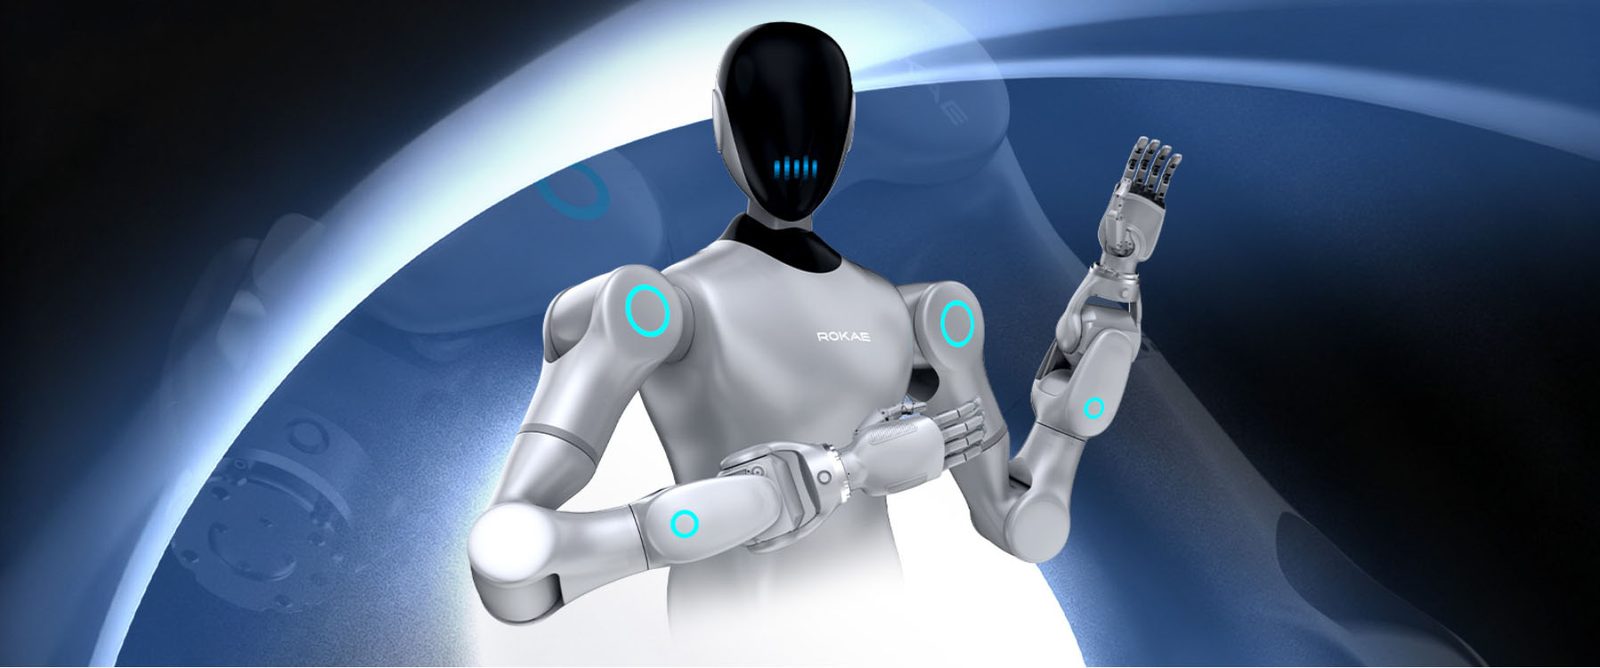
Helios boasts 42 degrees of freedom, combining efficient mobility with dexterous manipulation. Equipped with a seven-DOF, cross-wrist force-controlled arm and joint torque sensors, it achieves high-dynamic force control, making it widely applicable in industrial scenarios such as bin handling, complex material sorting, and precision assembly. Furthermore, its open underlying control architecture and flexible secondary development interfaces facilitate user customization of advanced functions to meet diverse needs in education, research, and automated process development.
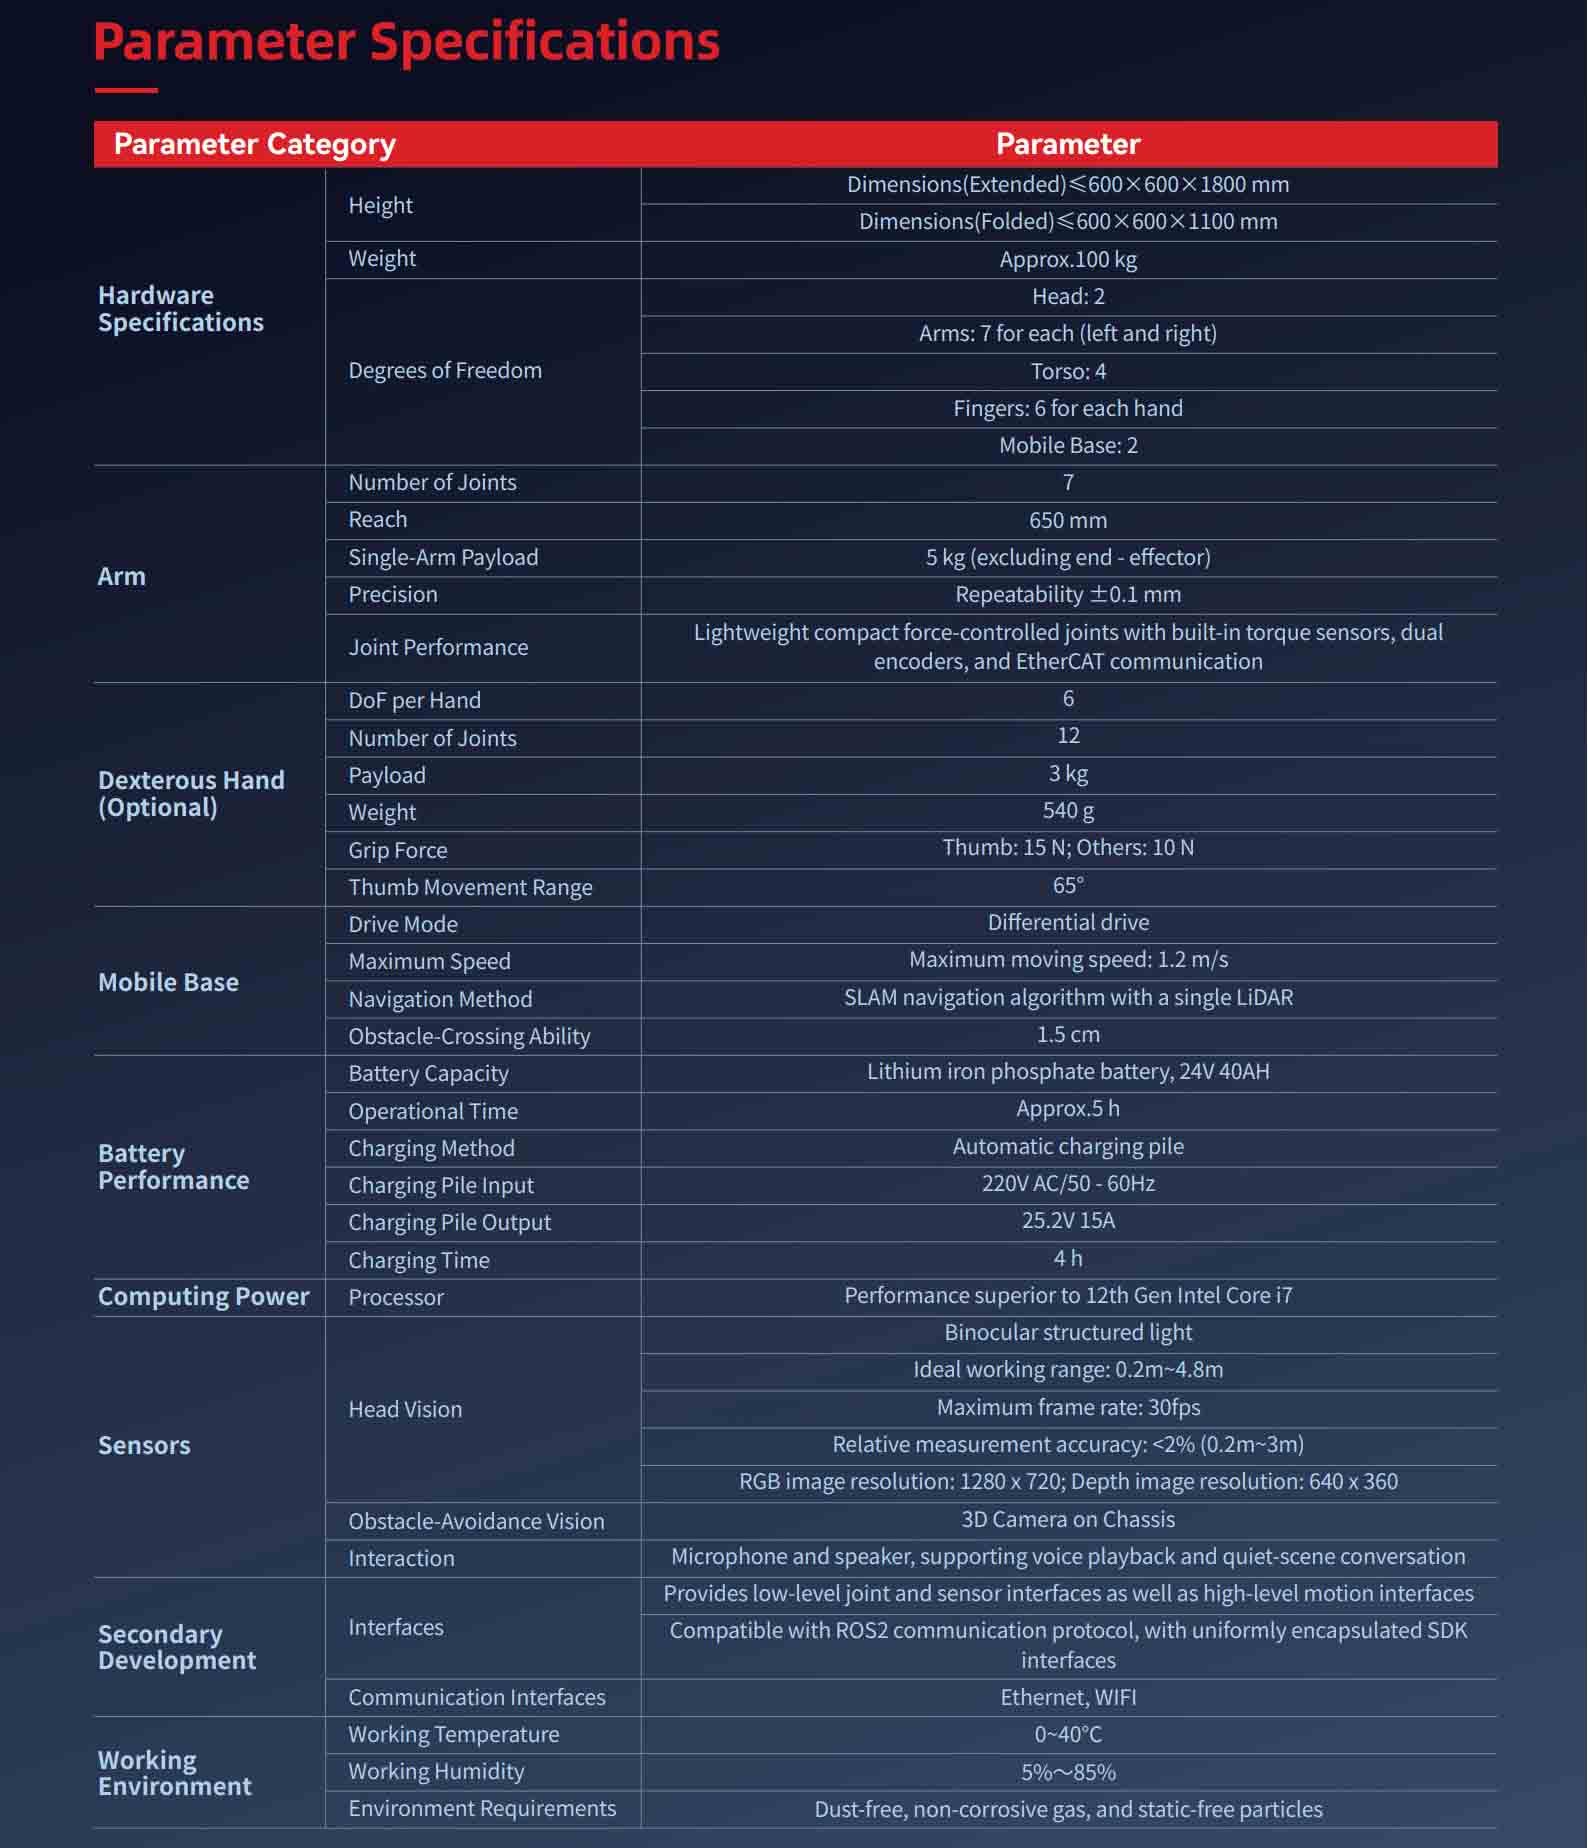
Hw Param | Height | Length, width, height (extended)≤ 680x640x1736mm |
Weight | About 90kg | |
DOF | Head:2 | |
arm | Number of joints | 7 |
Reach | 650mm | |
Single-arm rated load | 5kg (excluding end effector) | |
Accuracy | Repeated positioning accuracy is ±0.1mm | |
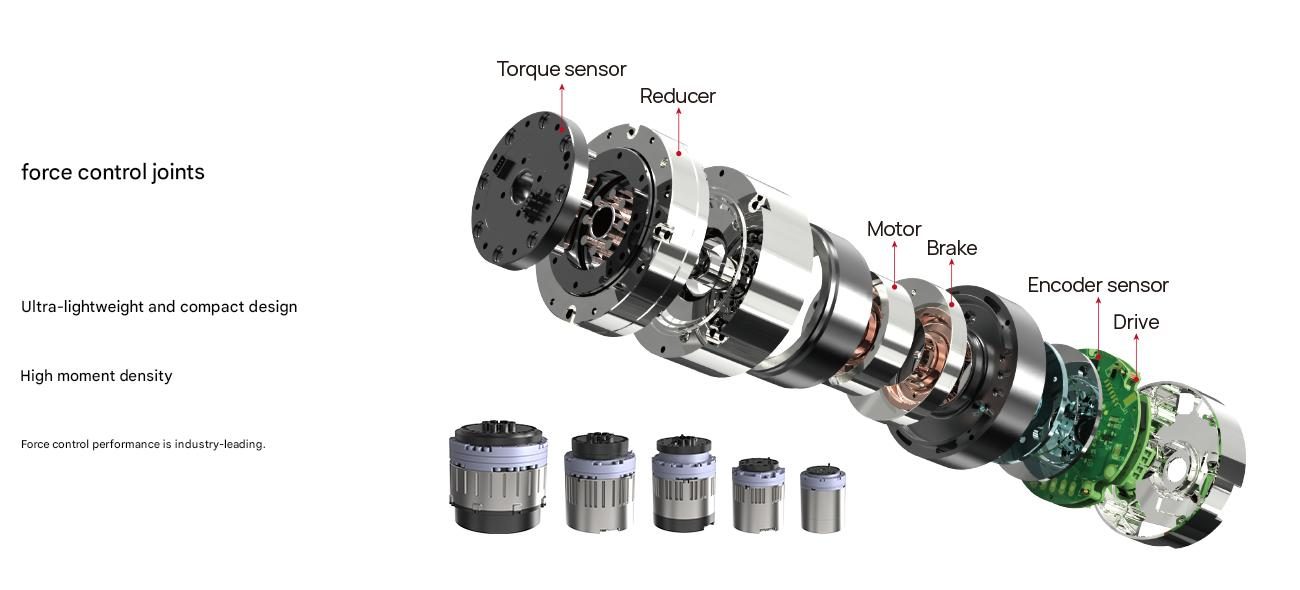
Joint performance | Lightweight and compact force-controlled joint, with built-in torque sensor, dual encoders, and EtherCAT communication | |
Dexterous hand (optional) | DOF | 10(6 active degrees of freedom) |
Number of joints | 12 | |
Load capacity | 3kg | |
Weight | 540g | |
Grasping ability | Thumb:15N;Four-fingered:10N | |
Range of the thumb | 65° | |
Mobile chassis | Move mode | Full-directional movement |
Maximum speed | Maximum moving speed:1.5 m/s | |
Navigate mode | SLAM navigation algorithm, dual laser radars | |
Obstacle climbing ability | 1.5cm | |
Cruising ability | Battery capacity | 48V 30AH |
Battery life | 6h | |
Charge mode | Manual, automatic, battery quick replacement | |
Charger input | 220V AC/50-60Hz | |
Charging time | 1.5h | |
Computing power | Processor | Intel i7-1195G7 ;16GB of RAM, 256GB solid-state drive |
Sensor | Head vision | Orbbec Gemini 335L |
Obstacle avoidance vision | 4 sets of 3D visual obstacle avoidance for chassis (optional) | |
Interaction | Microphone, speaker | |
Secondary development | Interface | It provides low-level joint and sensor interfaces as well as high-level motion interfaces |
Compatible with the ROS2 communication protocol and uniformly encapsulating the SDK interface | ||
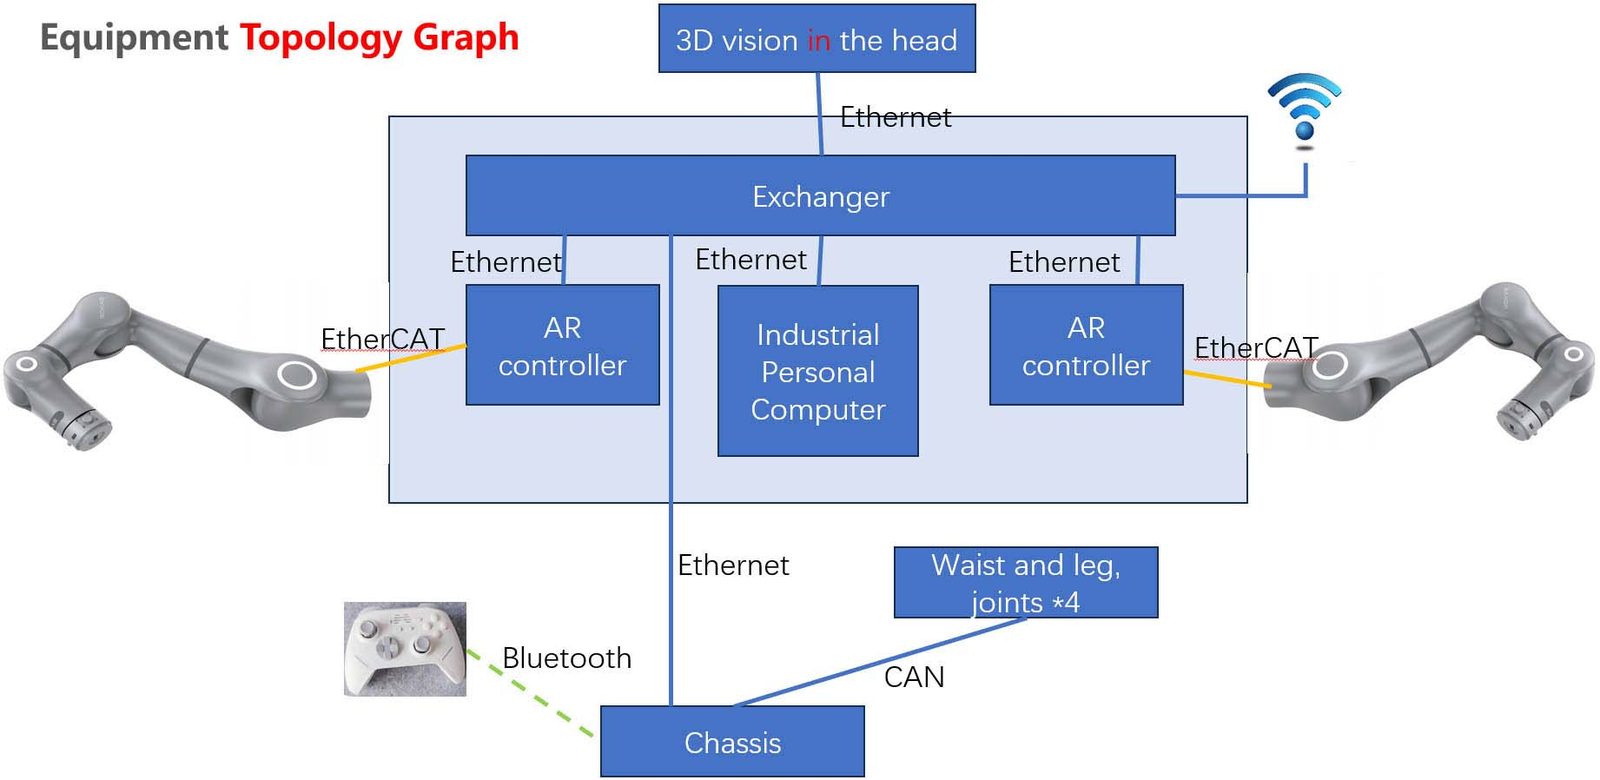
Communication interface | Ethernet, WIFI | |
Working environment | Working Temperature | 0~40℃ |
Working Humidity | 5%~95% | |
Environment | No dust, no corrosive gas, no static particles, no flammable or explosive substances |
Full Technical Data
| Model | Helios |
|---|---|
| Industrial-grade motion positioning accuracy | 10mm; |
| Arm manipulation accuracy | ±0.1mm; |
| Full body degrees of freedom | 42; |
| Multimodal fusion perception | Pose-Vision-Force control strategy: Tactic of Pose + Vision + Force; |
| Maximum payload per arm | 5kg. |
| Payload | 5 kg |
| Tolerance | ±0.1 mm |
| Category | AI & Humanoid Robots |
| Lead time | 90 days |
Values are nominal at 20 °C. Download the datasheet for cad models, torque curves and controller I/O maps.
Where It Runs
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Buyer Questions
What are the key specifications?
Model: Helios, Industrial-grade motion positioning accuracy: 10mm;, Arm manipulation accuracy: ±0.1mm;.
What is the lead time?
90 days for the standard configuration; confirmed at quotation.
Can it be customised?
Yes — OEM/ODM options, voltage, tooling and branding can be adapted. Send the application and target output for a proposal.
Get a Priced Proposal for Helios
Include the part, target rate and destination port. An engineer — not a chatbot — replies within 48 hours.
Same Category

Wheeled Dual-Arm Humanoid Robot

Dual-Arm Humanoid Robot

Biomimetic Panda Service Robot
Reviewed by TROY Engineering · . Specifications are re-checked against the supplier datasheet at every quotation.