


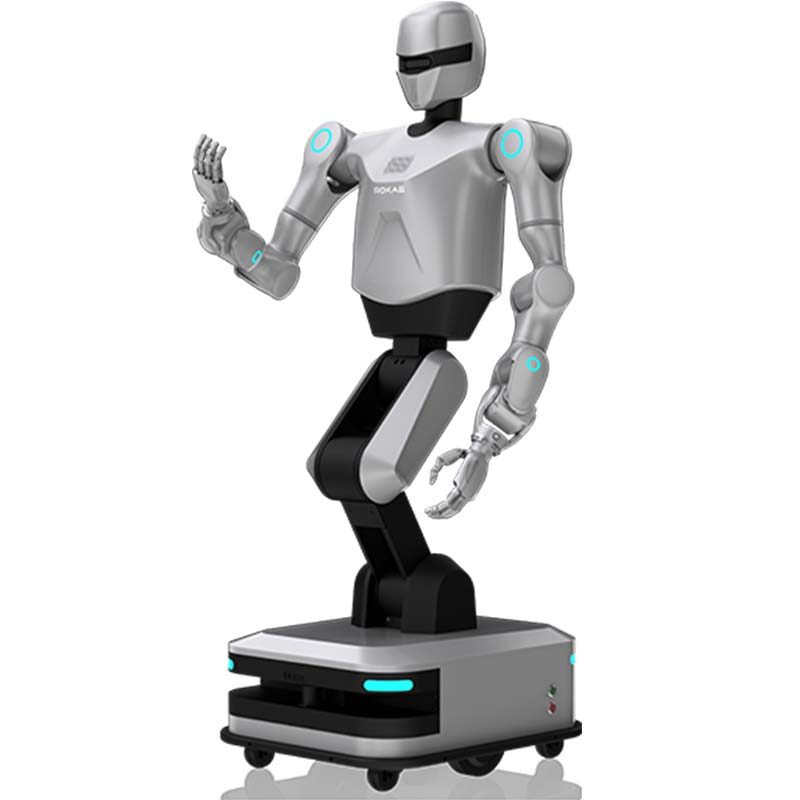
Helios, ein zweiarmiger Roboter mit Rädern
The Helios is a humanoid or AI robot for research / reception. Key specifications: Industrial-grade motion positioning accuracy 10 mm; Arm manipulation accuracy ±0.1 mm; Full body degrees of freedom 42. Lead time is 90 days; pricing is quoted per configuration. Certifications: CE documentation on request.
- Modell
- Helios
- Genauigkeit der Bewegungspositionierung in Industriequalität
- 10mm;
- Genauigkeit der Armmanipulation
- ±0.1mm;
- Volle Freiheitsgrade des Körpers
- 42;
- Multimodale Fusionswahrnehmung
- Pose-Vision-Force control strategy: Tactic of Pose + Vision + Force;
- Maximale Nutzlast pro Arm
- 5kg.
Wofür diese Plattform gedacht ist
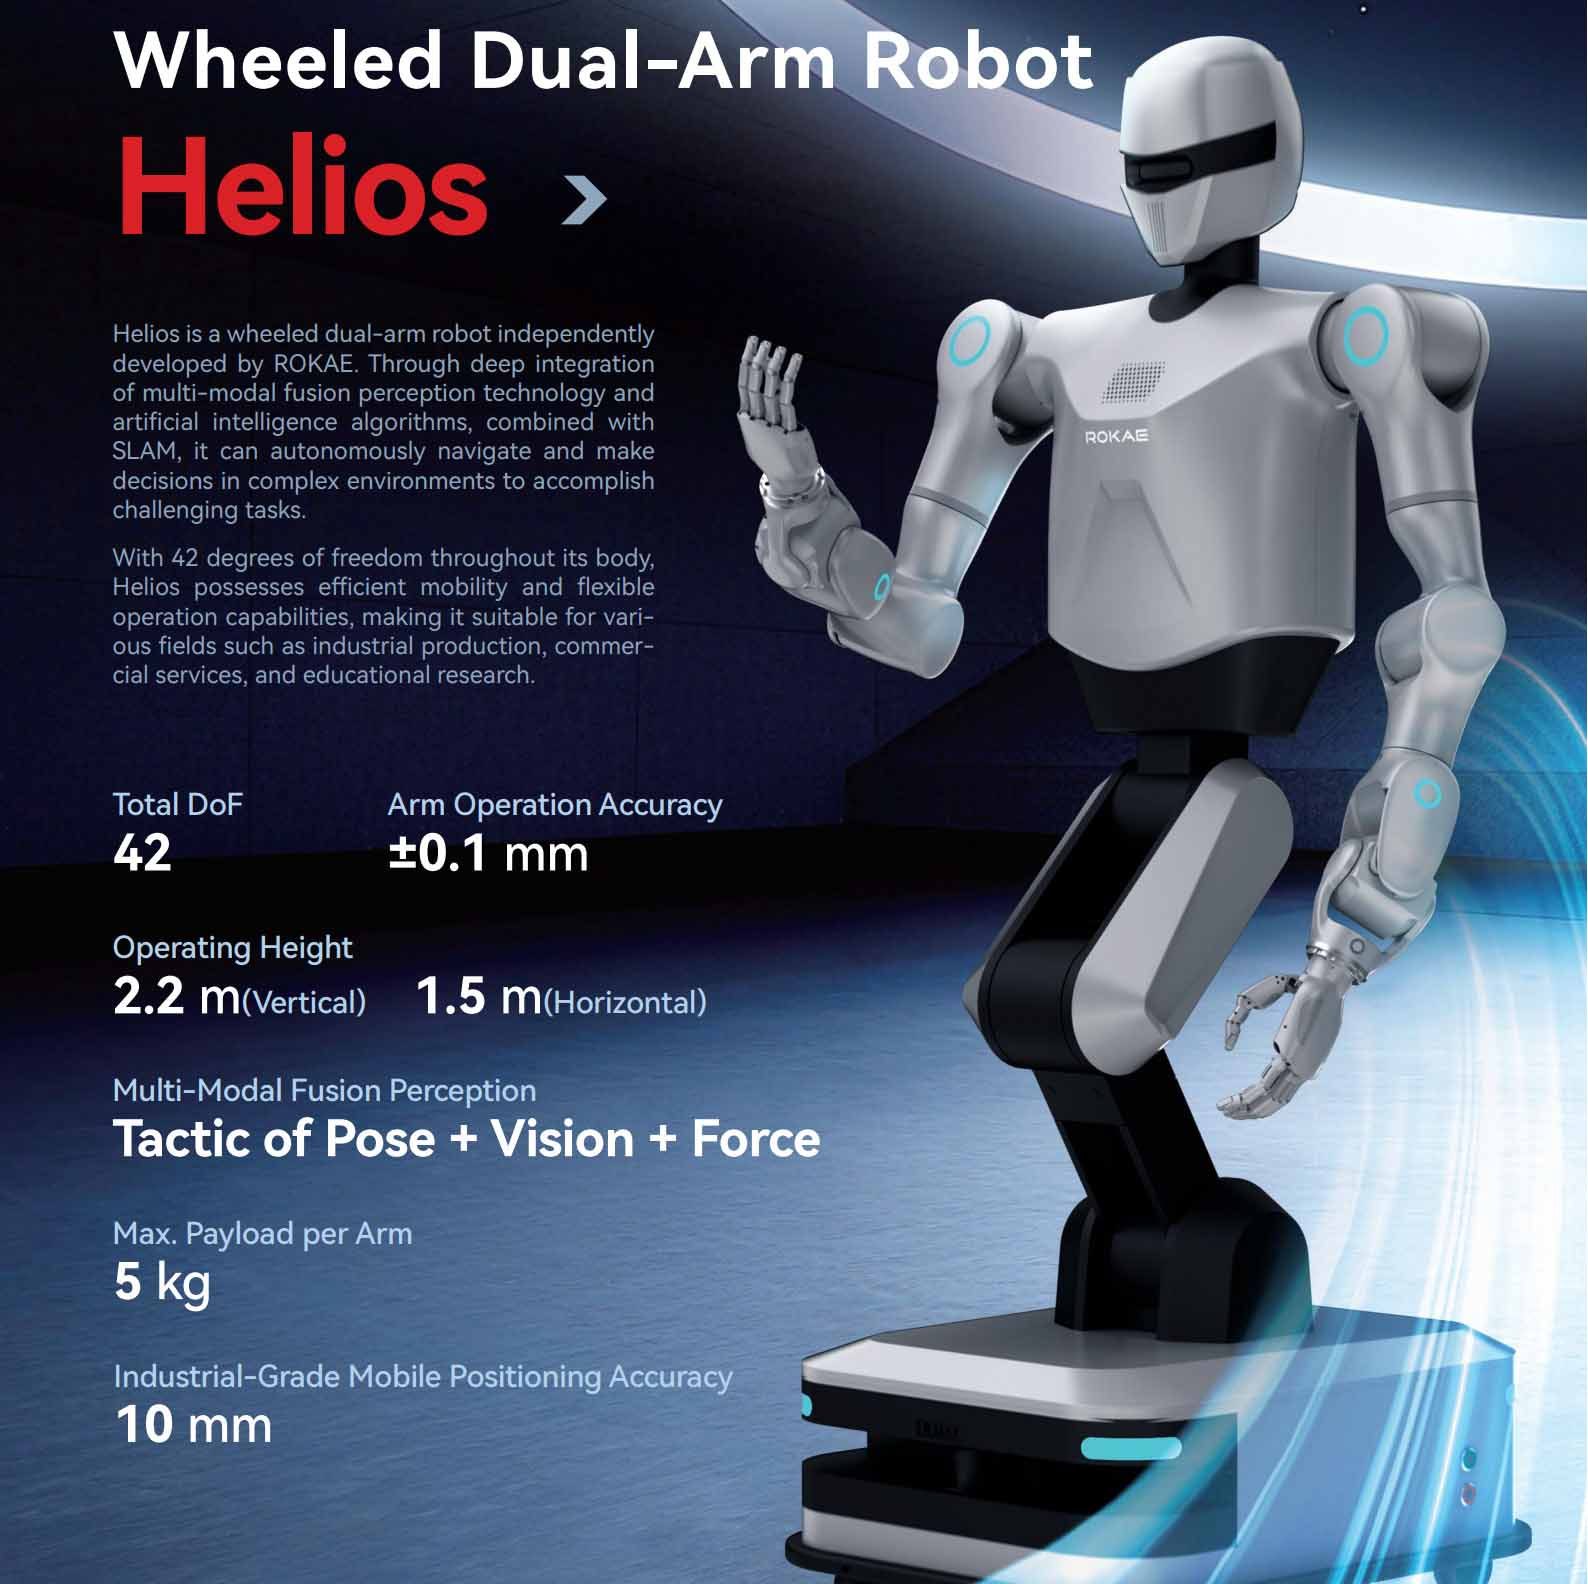
Zweiarmiger Roboter mit Rädern – Helios! Genauigkeit der Bewegungspositionierung in Industriequalität: 10 mm; Genauigkeit der Armmanipulation: ±0,1 mm; Ganzkörper-Freiheitsgrade: 42; Multimodale Fusionswahrnehmung: Pose-Vision-Kraft-Kontrollstrategie: Taktik von Pose + Vision + Kraft; Maximale Nutzlast pro Arm: 5 kg.
Handelsbedingungen
| Angebot | Preis pro Konfiguration – Antwort innerhalb von 48 Stunden |
|---|---|
| Vorlaufzeit | 90 Tage |
| Mindestbestellmenge | 1 Einheit |
| Herkunft | China |
| Verladehafen | Shanghai, China |
| Incoterm | FOB Shanghai / CIF on request |
| Zahlung | 30 % Anzahlung, 70 % vor Versand |
| Garantie | 24 Monate Standard, 36 Monate optional |
Produktdetails
Anwendungshinweise, Konstruktionszeichnungen und Videos aus der TROY-Konstruktionsdatei – dieselbe Dokumentation, die mit dem Angebot geliefert wurde.
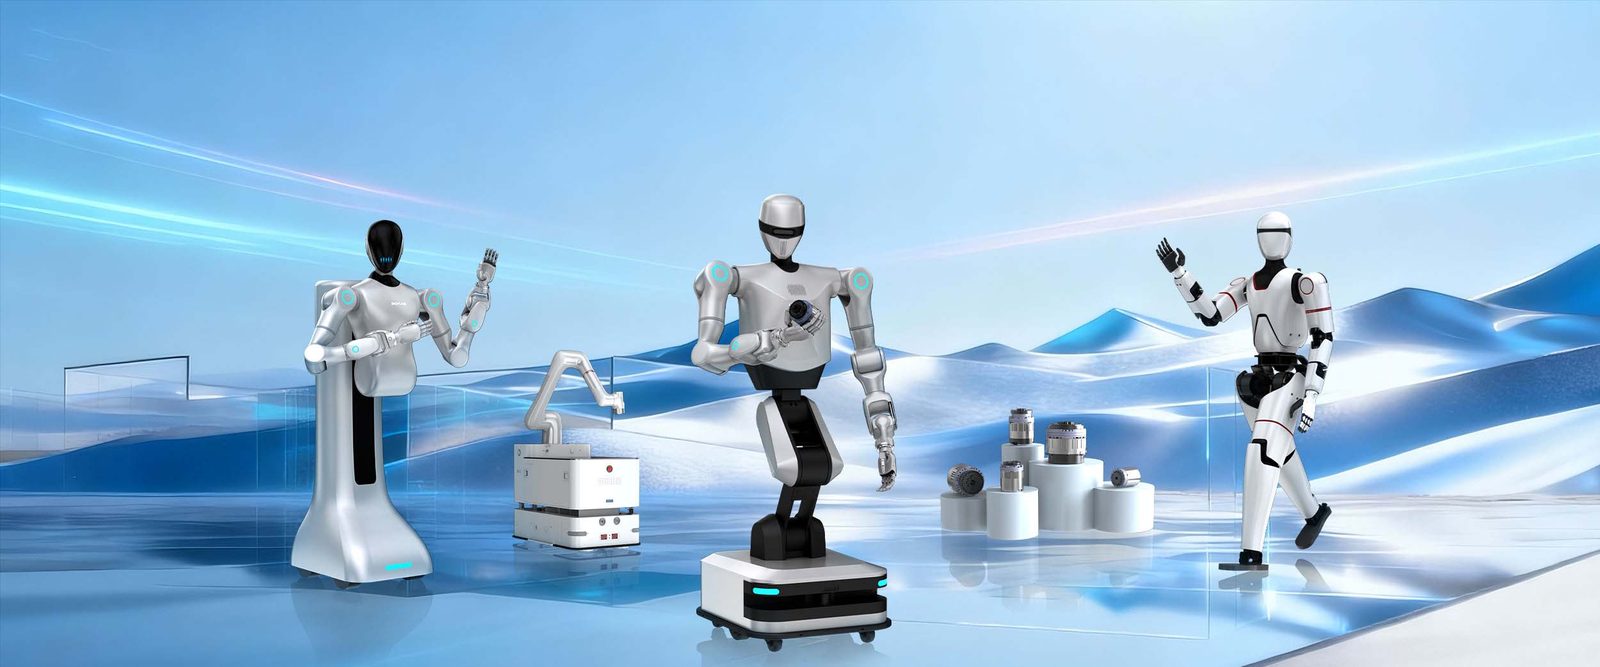
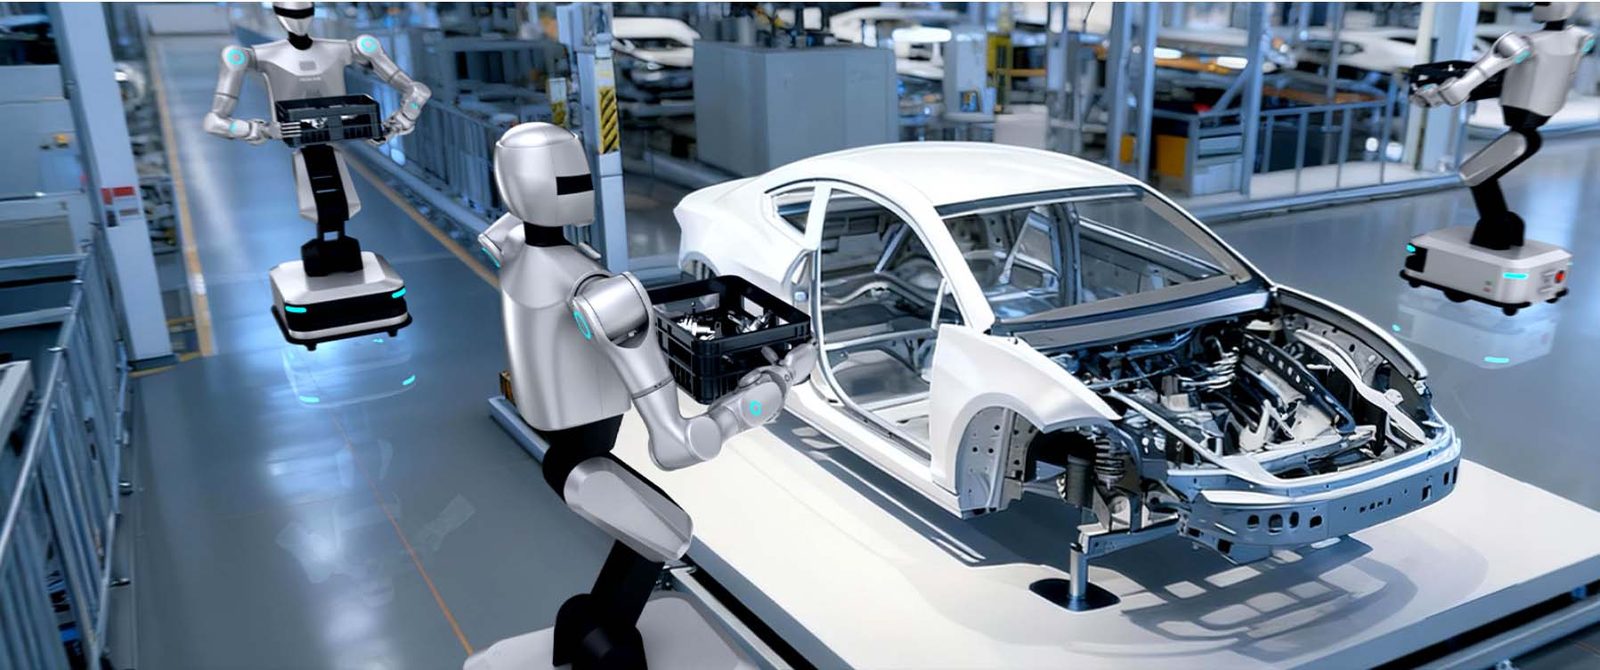
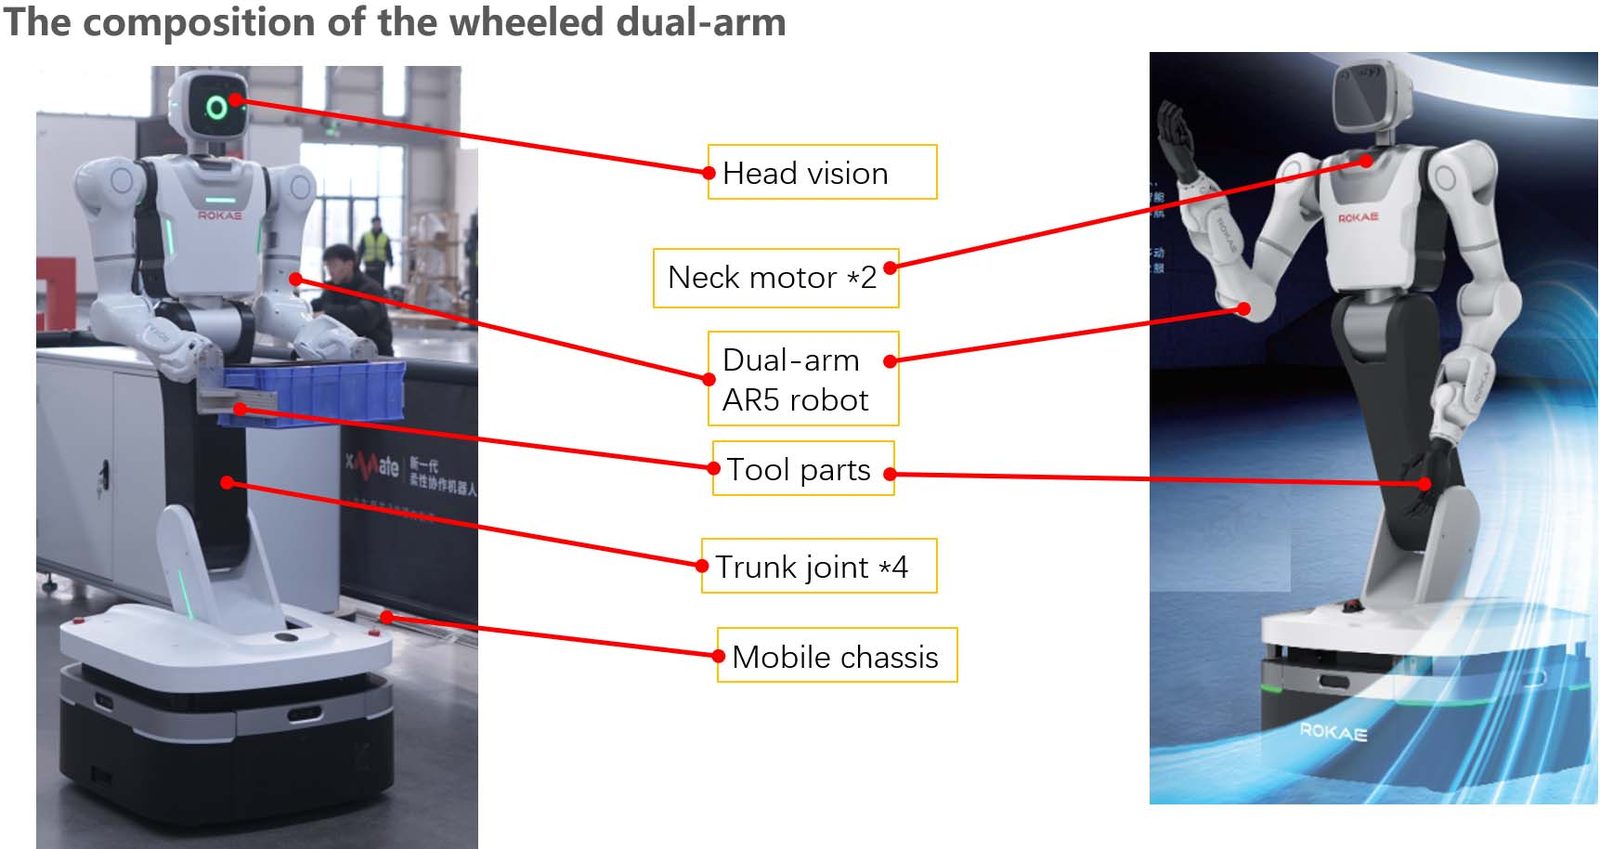
Helios is a wheeled dual-arm robot independently developed by Rokae. It achieves multimodal fusion perception through a posture-vision-force control strategy, combined with laser SLAM navigation. Without environmental modification, it can autonomously navigate and make decisions in complex scenarios, capable of handling various challenging tasks.
Helios boasts 42 degrees of freedom, combining efficient mobility with dexterous manipulation. Equipped with a seven-DOF, cross-wrist force-controlled arm and joint torque sensors, it achieves high-dynamic force control, making it widely applicable in industrial scenarios such as bin handling, complex material sorting, and precision assembly. Furthermore, its open underlying control architecture and flexible secondary development interfaces facilitate user customization of advanced functions to meet diverse needs in education, research, and automated process development.
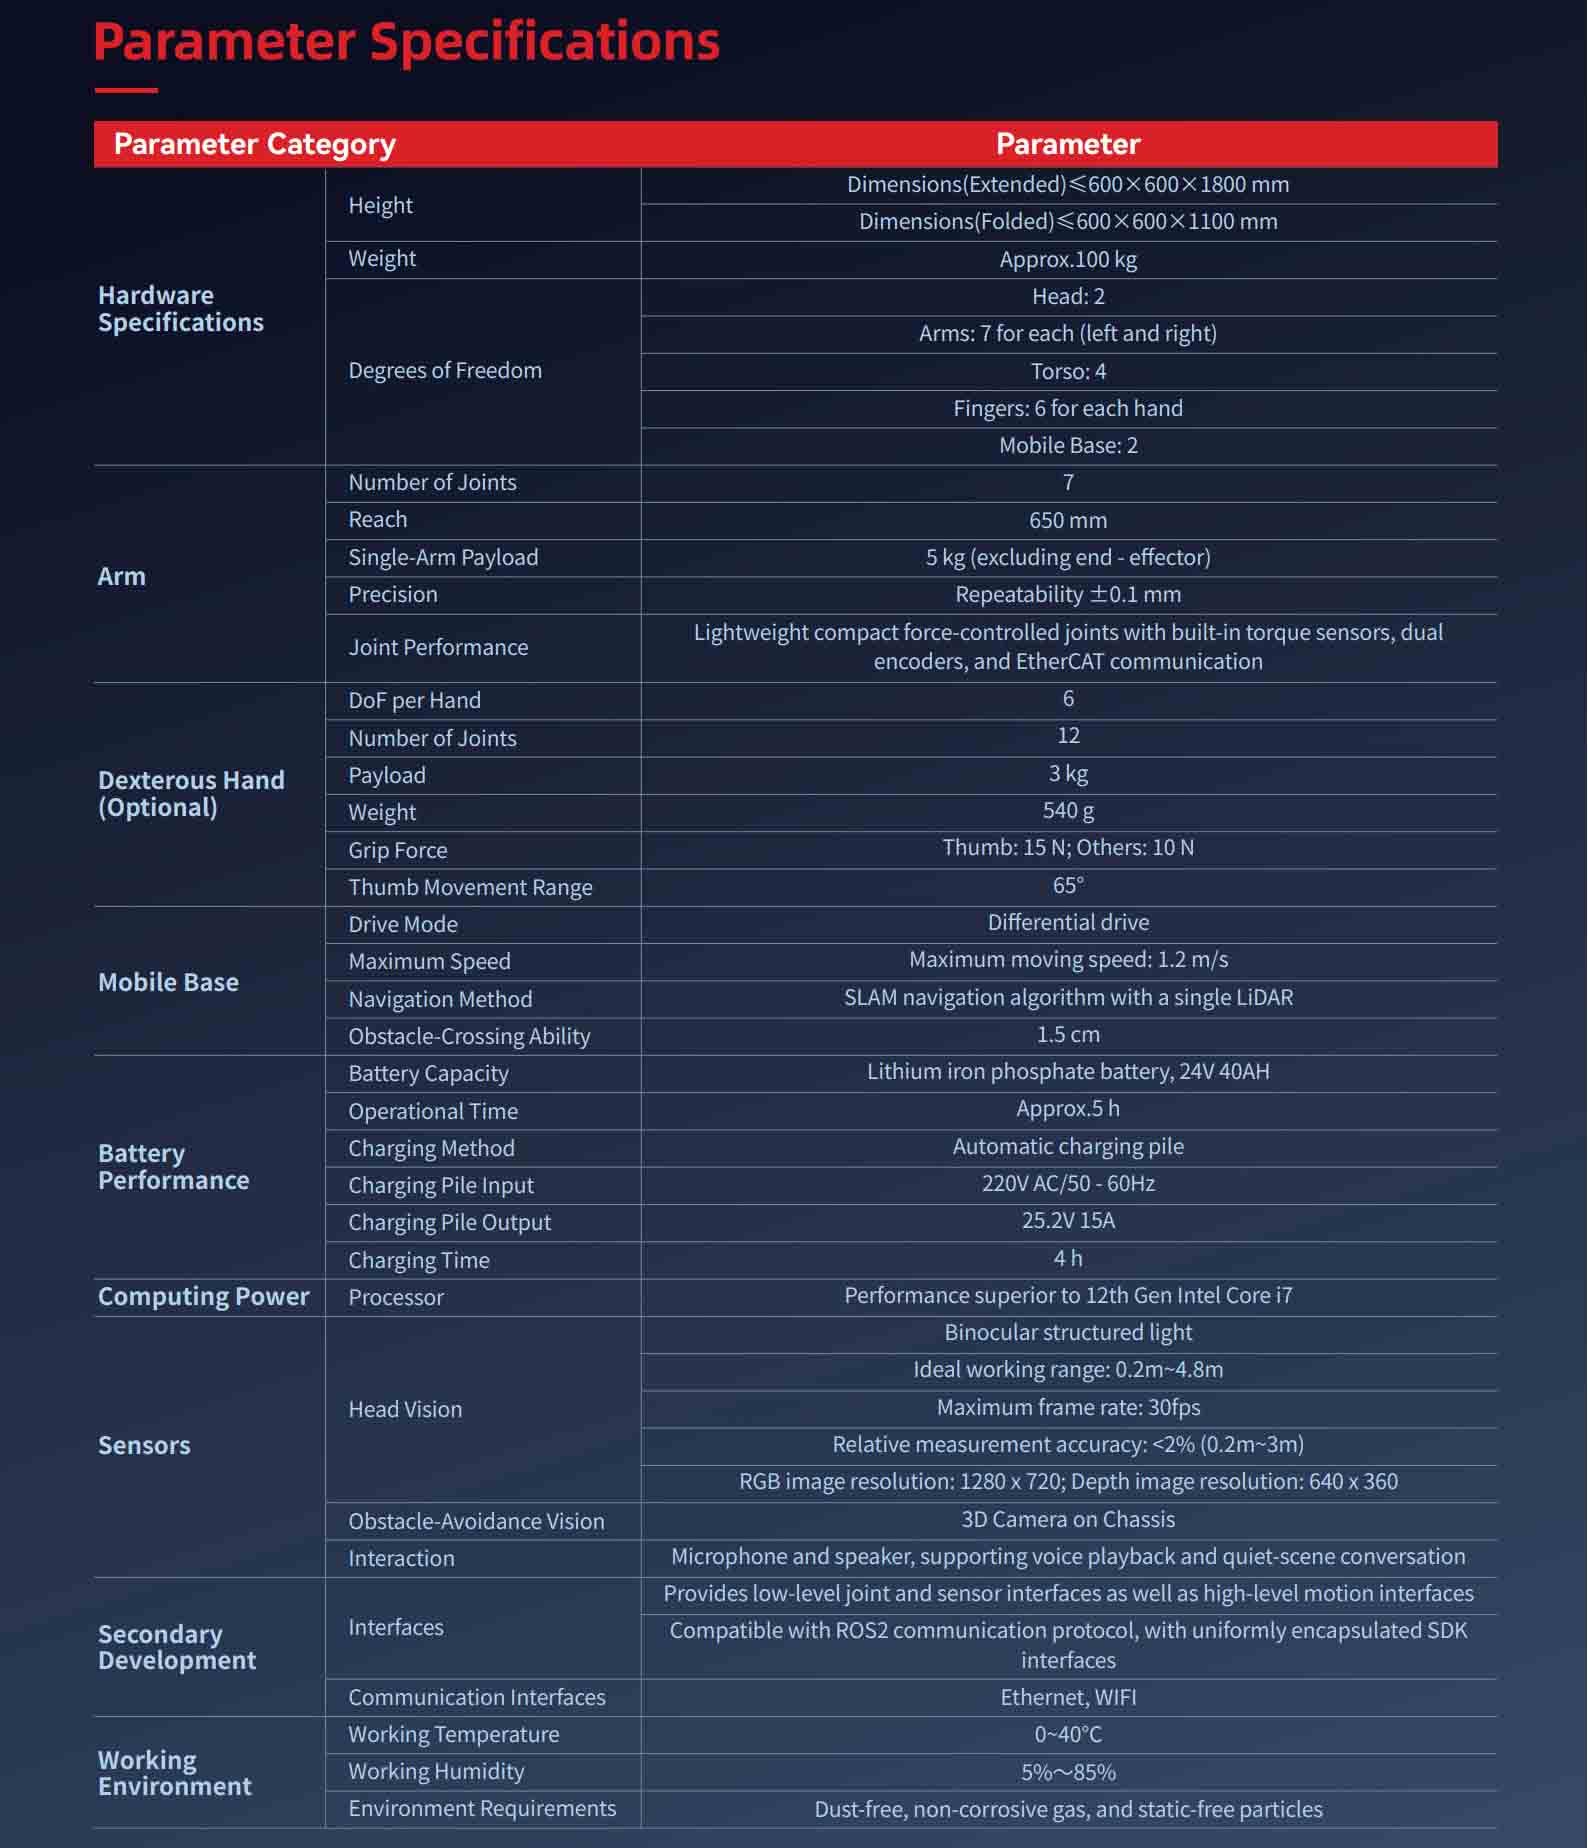
Hw Param | Höhe | Length, width, height (extended)≤ 680x640x1736mm |
Gewicht | About 90kg | |
DOF | Head:2 | |
Arm | Number of joints | 7 |
Reichweite | 650mm | |
Single-arm rated load | 5kg (excluding end effector) | |
Genauigkeit | Repeated positioning accuracy is ±0.1mm | |
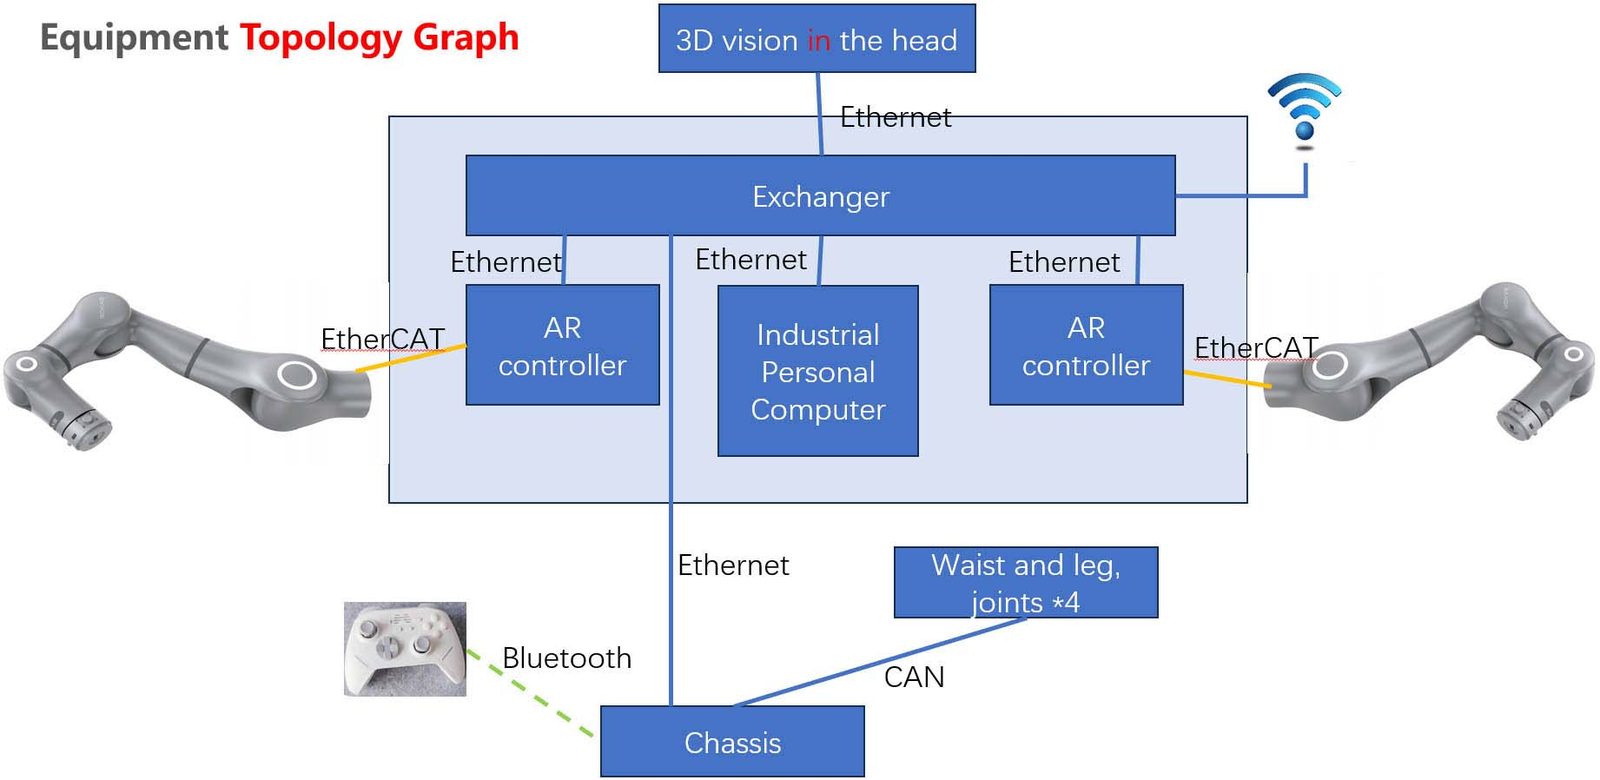
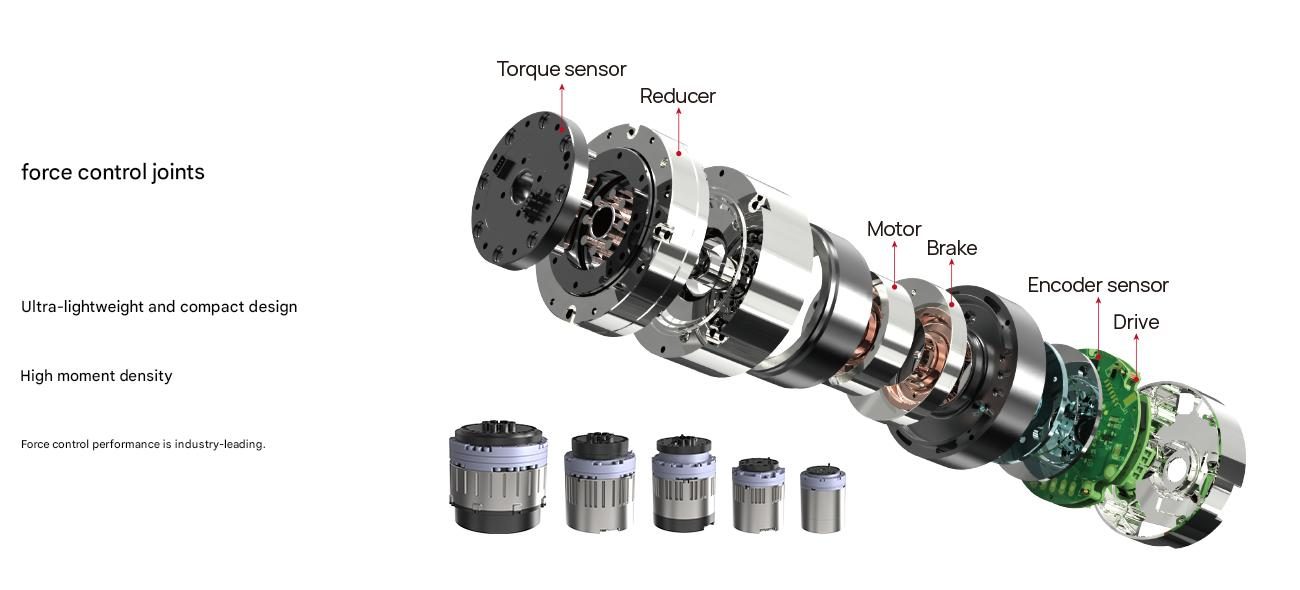
Joint performance | Leicht und kompakt Kraftgesteuertes Gelenk mit integriertem Drehmomentsensor, zwei Encodern und EtherCAT-Kommunikation | |
Dexterous hand (optional) | DOF | 10(6 active degrees of freedom) |
Number of joints | 12 | |
Tragfähigkeit | 3kg | |
Gewicht | 540g | |
Grasping ability | Thumb:15N;Four-fingered:10N | |
Range of the thumb | 65° | |
Mobile chassis | Move mode | Full-directional movement |
Maximum speed | Maximum moving speed:1.5 m/s | |
Navigate mode | SLAM navigation algorithm, dual laser radars | |
Obstacle climbing ability | 1.5cm | |
Cruising ability | Batteriekapazität | 48V 30AH |
Akkulaufzeit | 6h | |
Charge mode | Manual, automatic, battery quick replacement | |
Charger input | 220V AC/50-60Hz | |
Ladezeit | 1.5h | |
Computing power | Processor | Intel i7-1195G7 ;16GB of RAM, 256GB solid-state drive |
Sensor | Head vision | Orbbec Gemini 335L |
Obstacle avoidance vision | 4 Sätze visueller 3D-Hindernisse Ausweichung für Fahrwerk (optional) | |
Interaction | Microphone, speaker | |
Secondary development | Schnittstelle | Es bietet Gelenke auf niedrigem Niveau und Sensorschnittstellen sowie High-Level-Motion-Schnittstellen |
Kompatibel mit dem ROS2-Kommunikationsprotokoll und einheitliche Kapselung der SDK-Schnittstelle | ||
Kommunikationsschnittstelle | Ethernet, WIFI | |
Working environment | Working Temperature | 0~40℃ |
Working Humidity | 5%~95% | |
Environment | No dust, no corrosive gas, no static particles, no flammable or explosive substances |
Vollständige technische Daten
| Modell | Helios |
|---|---|
| Genauigkeit der Bewegungspositionierung in Industriequalität | 10mm; |
| Genauigkeit der Armmanipulation | ±0.1mm; |
| Volle Freiheitsgrade des Körpers | 42; |
| Multimodale Fusionswahrnehmung | Pose-Vision-Force control strategy: Tactic of Pose + Vision + Force; |
| Maximale Nutzlast pro Arm | 5kg. |
| Nutzlast | 5 kg |
| Toleranz | ±0.1 mm |
| Kategorie | KI und humanoide Roboter |
| Vorlaufzeit | 90 Tage |
Die Werte sind Nominalwerte bei 20 °C. Laden Sie das Datenblatt für CAD-Modelle, Drehmomentkurven und Controller-I/O-Karten herunter.
Wo es läuft
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Fragen des Käufers
Was sind die wichtigsten Spezifikationen?
Modell: Helios, Bewegungspositionierungsgenauigkeit in Industriequalität: 10 mm, Armmanipulationsgenauigkeit: ± 0,1 mm.
Was ist die Vorlaufzeit?
90 Tage für die Standardkonfiguration; im Angebot bestätigt.
Kann es individuell angepasst werden?
Ja – OEM/ODM-Optionen, Spannung, Werkzeuge und Branding können angepasst werden. Senden Sie den Antrag und zielen Sie auf die Ausgabe eines Angebots ab.
Holen Sie sich ein Preisangebot für Helios
Geben Sie das Teil, die Zielrate und den Zielport an. Ein Techniker – kein Chatbot – antwortet innerhalb von 48 Stunden.
Gleiche Kategorie

Humanoider Roboter mit zwei Armen auf Rädern

Zweiarmiger humanoider Roboter

Biomimetischer Panda-Serviceroboter
Bewertet von TROY Engineering ·. Bei jedem Angebot werden die Spezifikationen erneut anhand des Datenblatts des Lieferanten überprüft.