


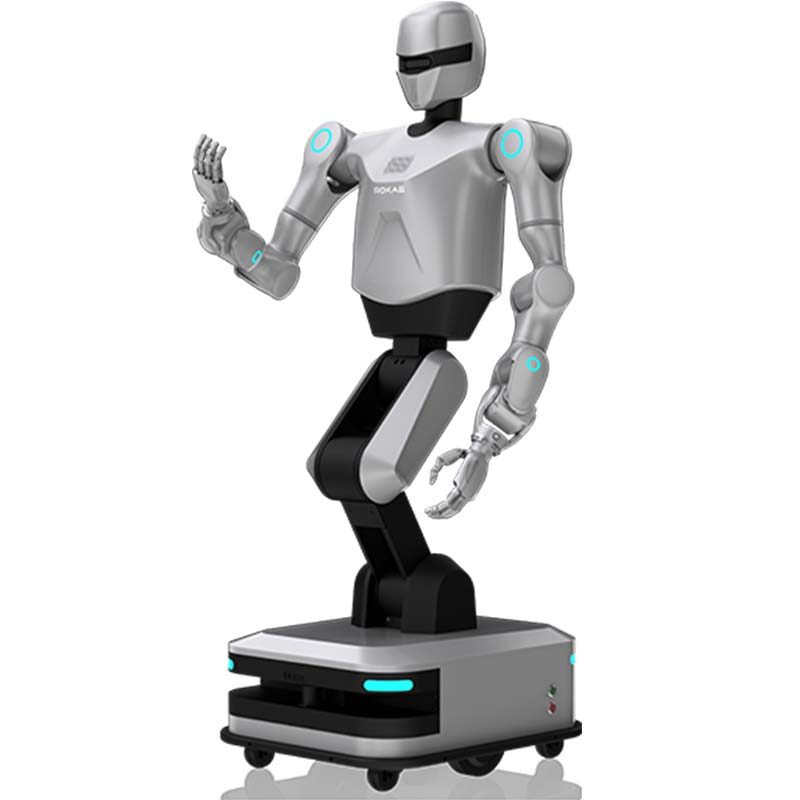
Helios, een robot met twee armen op wielen
The Helios is a humanoid or AI robot for research / reception. Key specifications: Industrial-grade motion positioning accuracy 10 mm; Arm manipulation accuracy ±0.1 mm; Full body degrees of freedom 42. Lead time is 90 days; pricing is quoted per configuration. Certifications: CE documentation on request.
- Model
- Helios
- Nauwkeurigheid bij bewegingspositionering van industriële kwaliteit
- 10mm;
- Nauwkeurigheid van armmanipulatie
- ±0.1mm;
- Vrijheidsgraden voor het hele lichaam
- 42;
- Multimodale fusieperceptie
- Pose-Vision-Force control strategy: Tactic of Pose + Vision + Force;
- Maximaal laadvermogen per arm
- 5 kg.
Waar dit platform voor is
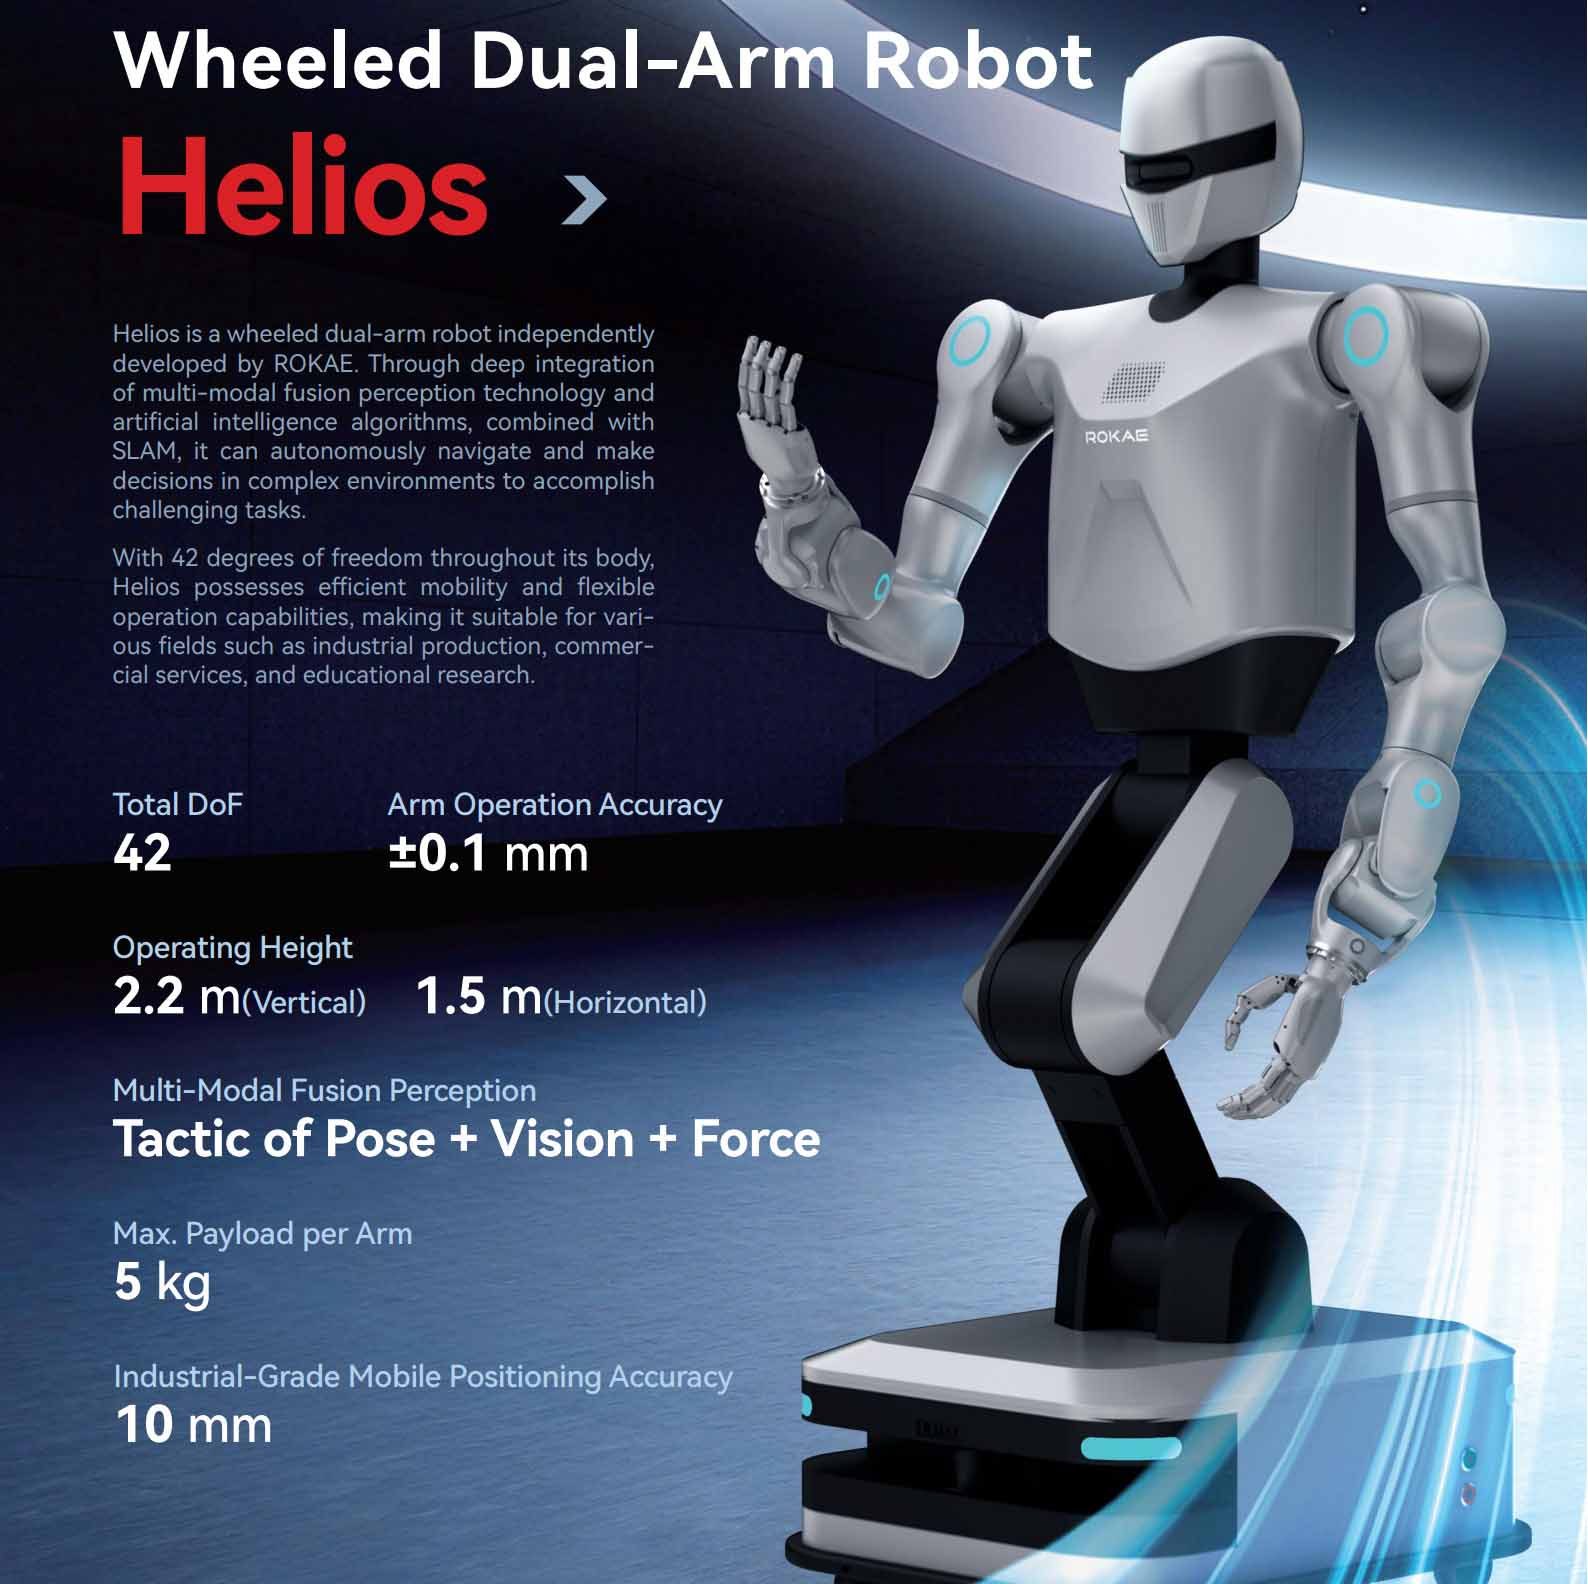
Robot met twee armen op wielen --- Helios! Nauwkeurigheid van bewegingspositionering van industriële kwaliteit: 10 mm; Nauwkeurigheid armmanipulatie: ±0,1 mm; Vrijheidsgraden voor het hele lichaam: 42; Multimodale fusieperceptie: Pose-Vision-Force-controlestrategie: Tactiek van Pose + Vision + Force; Maximaal laadvermogen per arm: 5kg.
Commerciële voorwaarden
| Offerte | Geprijsd per configuratie - antwoord binnen 48 uur |
|---|---|
| Doorlooptijd | 90 dagen |
| MOQ | 1 eenheid |
| Oorsprong | China |
| Haven van laden | Shanghai, China |
| Incoterm | FOB Shanghai / CIF on request |
| Betaling | 30% aanbetaling, 70% vóór verzending |
| Garantie | 24 maanden standaard, 36 maanden optioneel |
Productdetails
Applicatienota's, constructietekeningen en video uit het TROY-engineeringbestand: dezelfde documentatie die bij de offerte wordt geleverd.
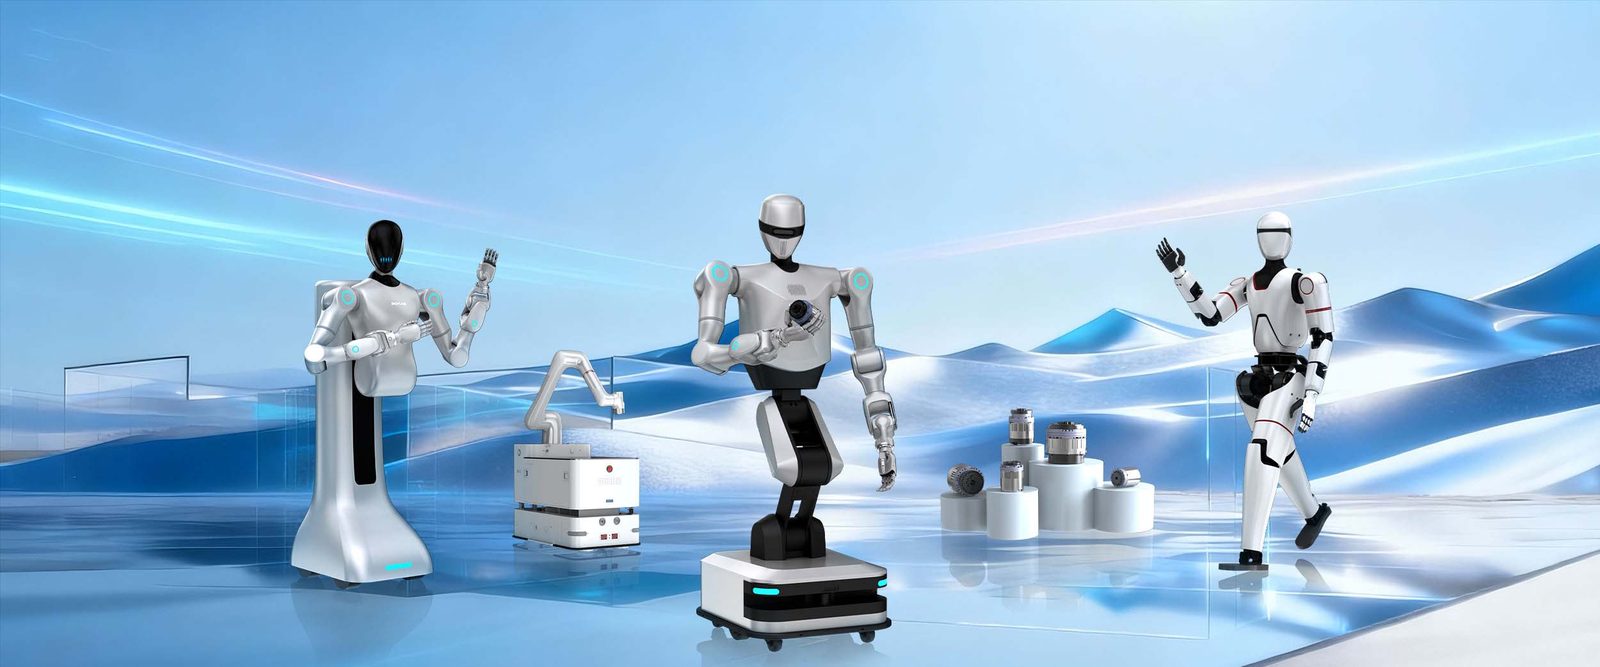
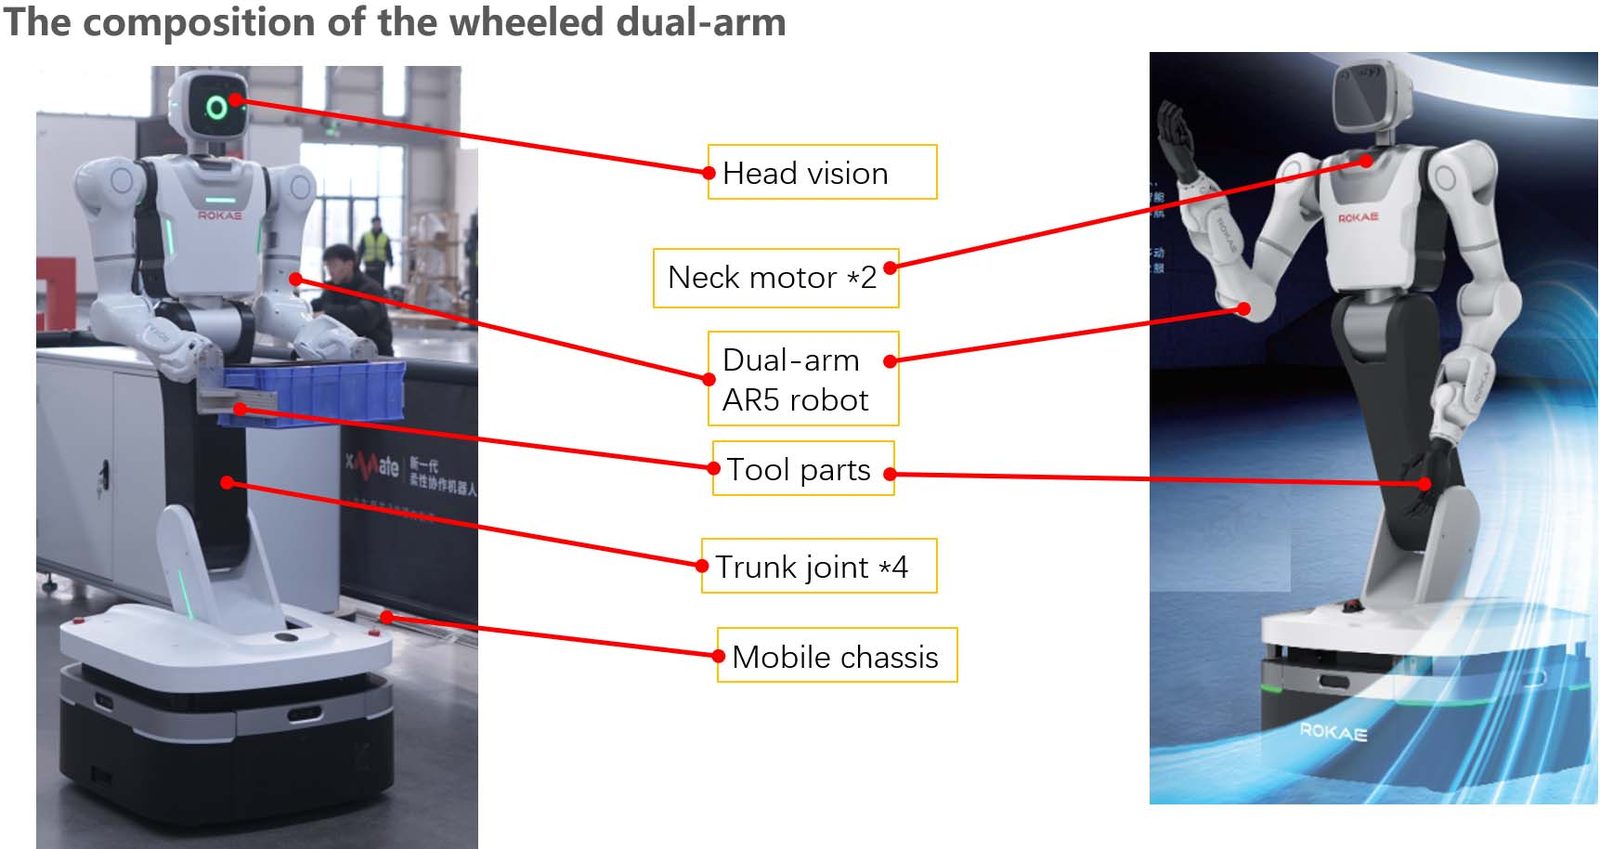
Helios is a wheeled dual-arm robot independently developed by Rokae. It achieves multimodal fusion perception through a posture-vision-force control strategy, combined with laser SLAM navigation. Without environmental modification, it can autonomously navigate and make decisions in complex scenarios, capable of handling various challenging tasks.
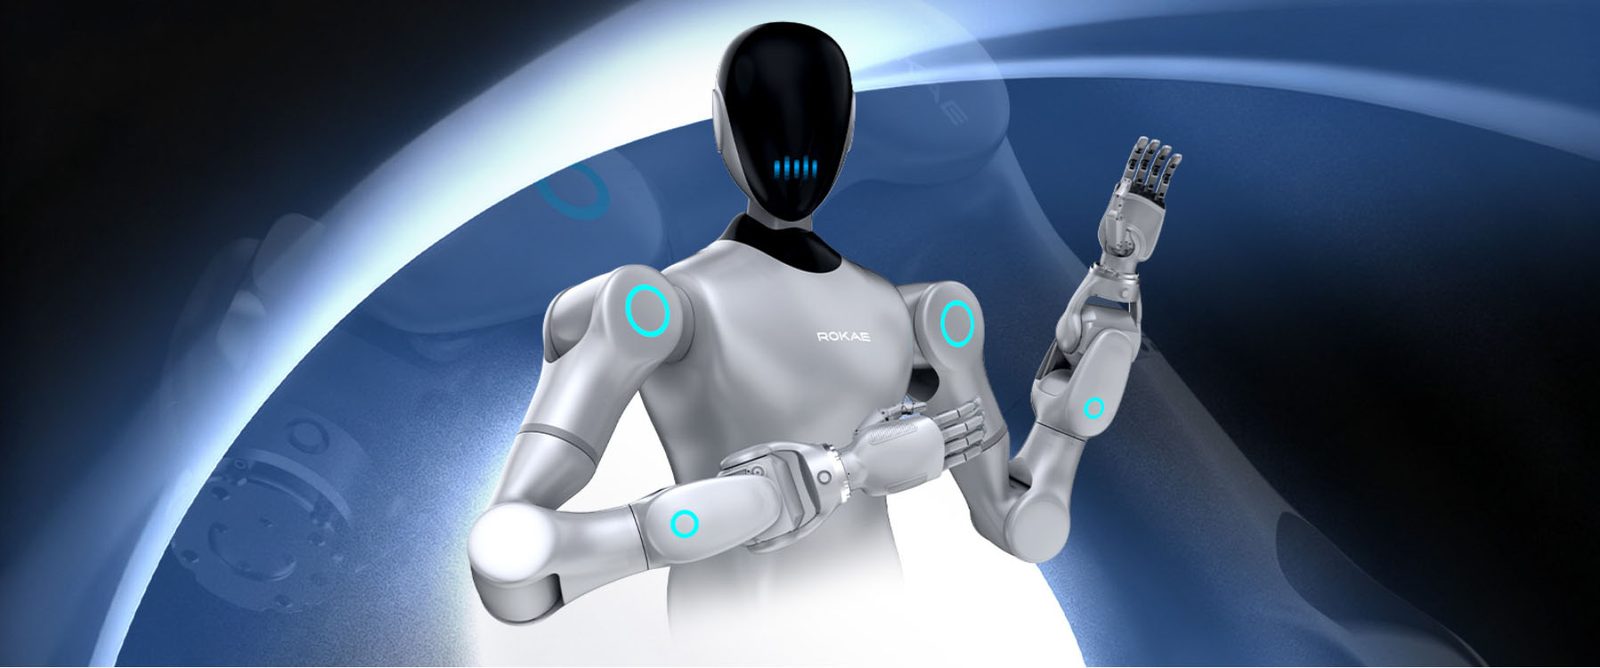
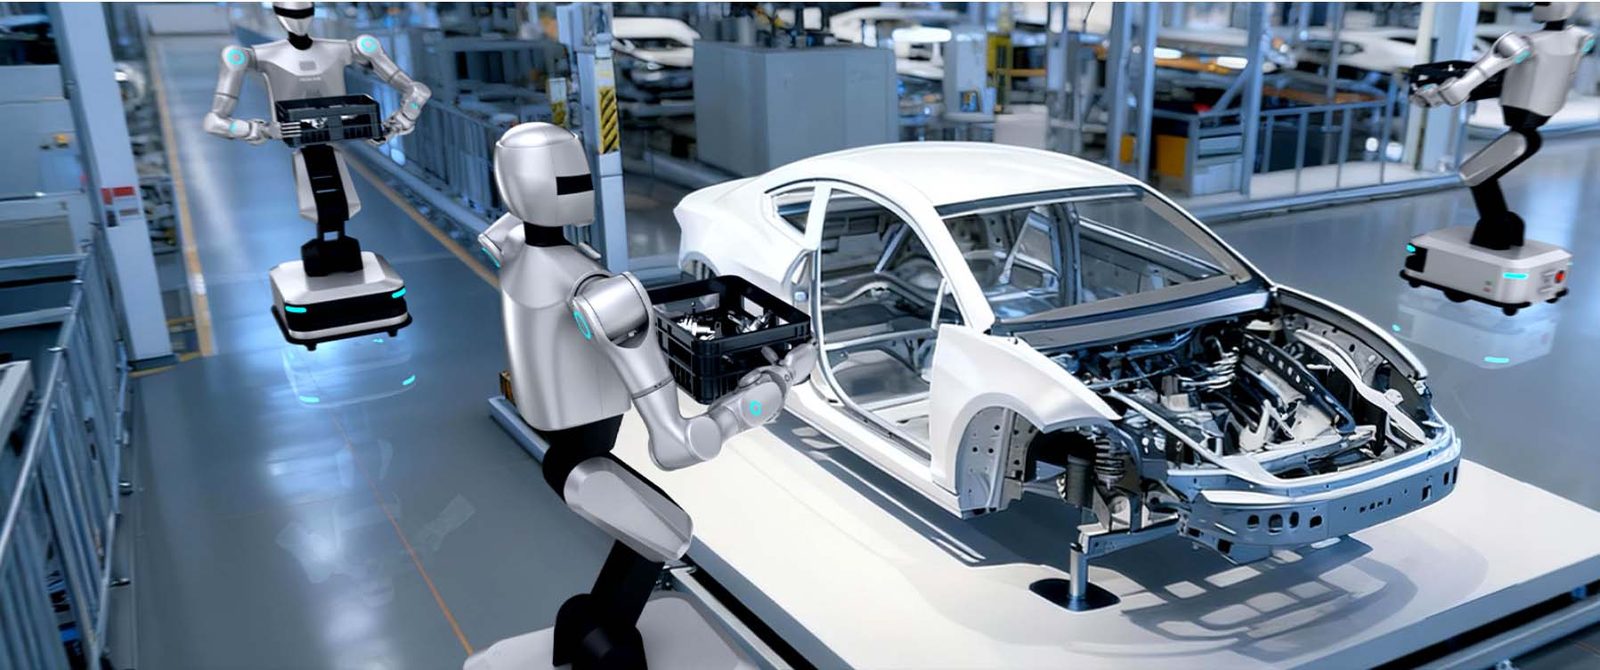
Helios boasts 42 degrees of freedom, combining efficient mobility with dexterous manipulation. Equipped with a seven-DOF, cross-wrist force-controlled arm and joint torque sensors, it achieves high-dynamic force control, making it widely applicable in industrial scenarios such as bin handling, complex material sorting, and precision assembly. Furthermore, its open underlying control architecture and flexible secondary development interfaces facilitate user customization of advanced functions to meet diverse needs in education, research, and automated process development.
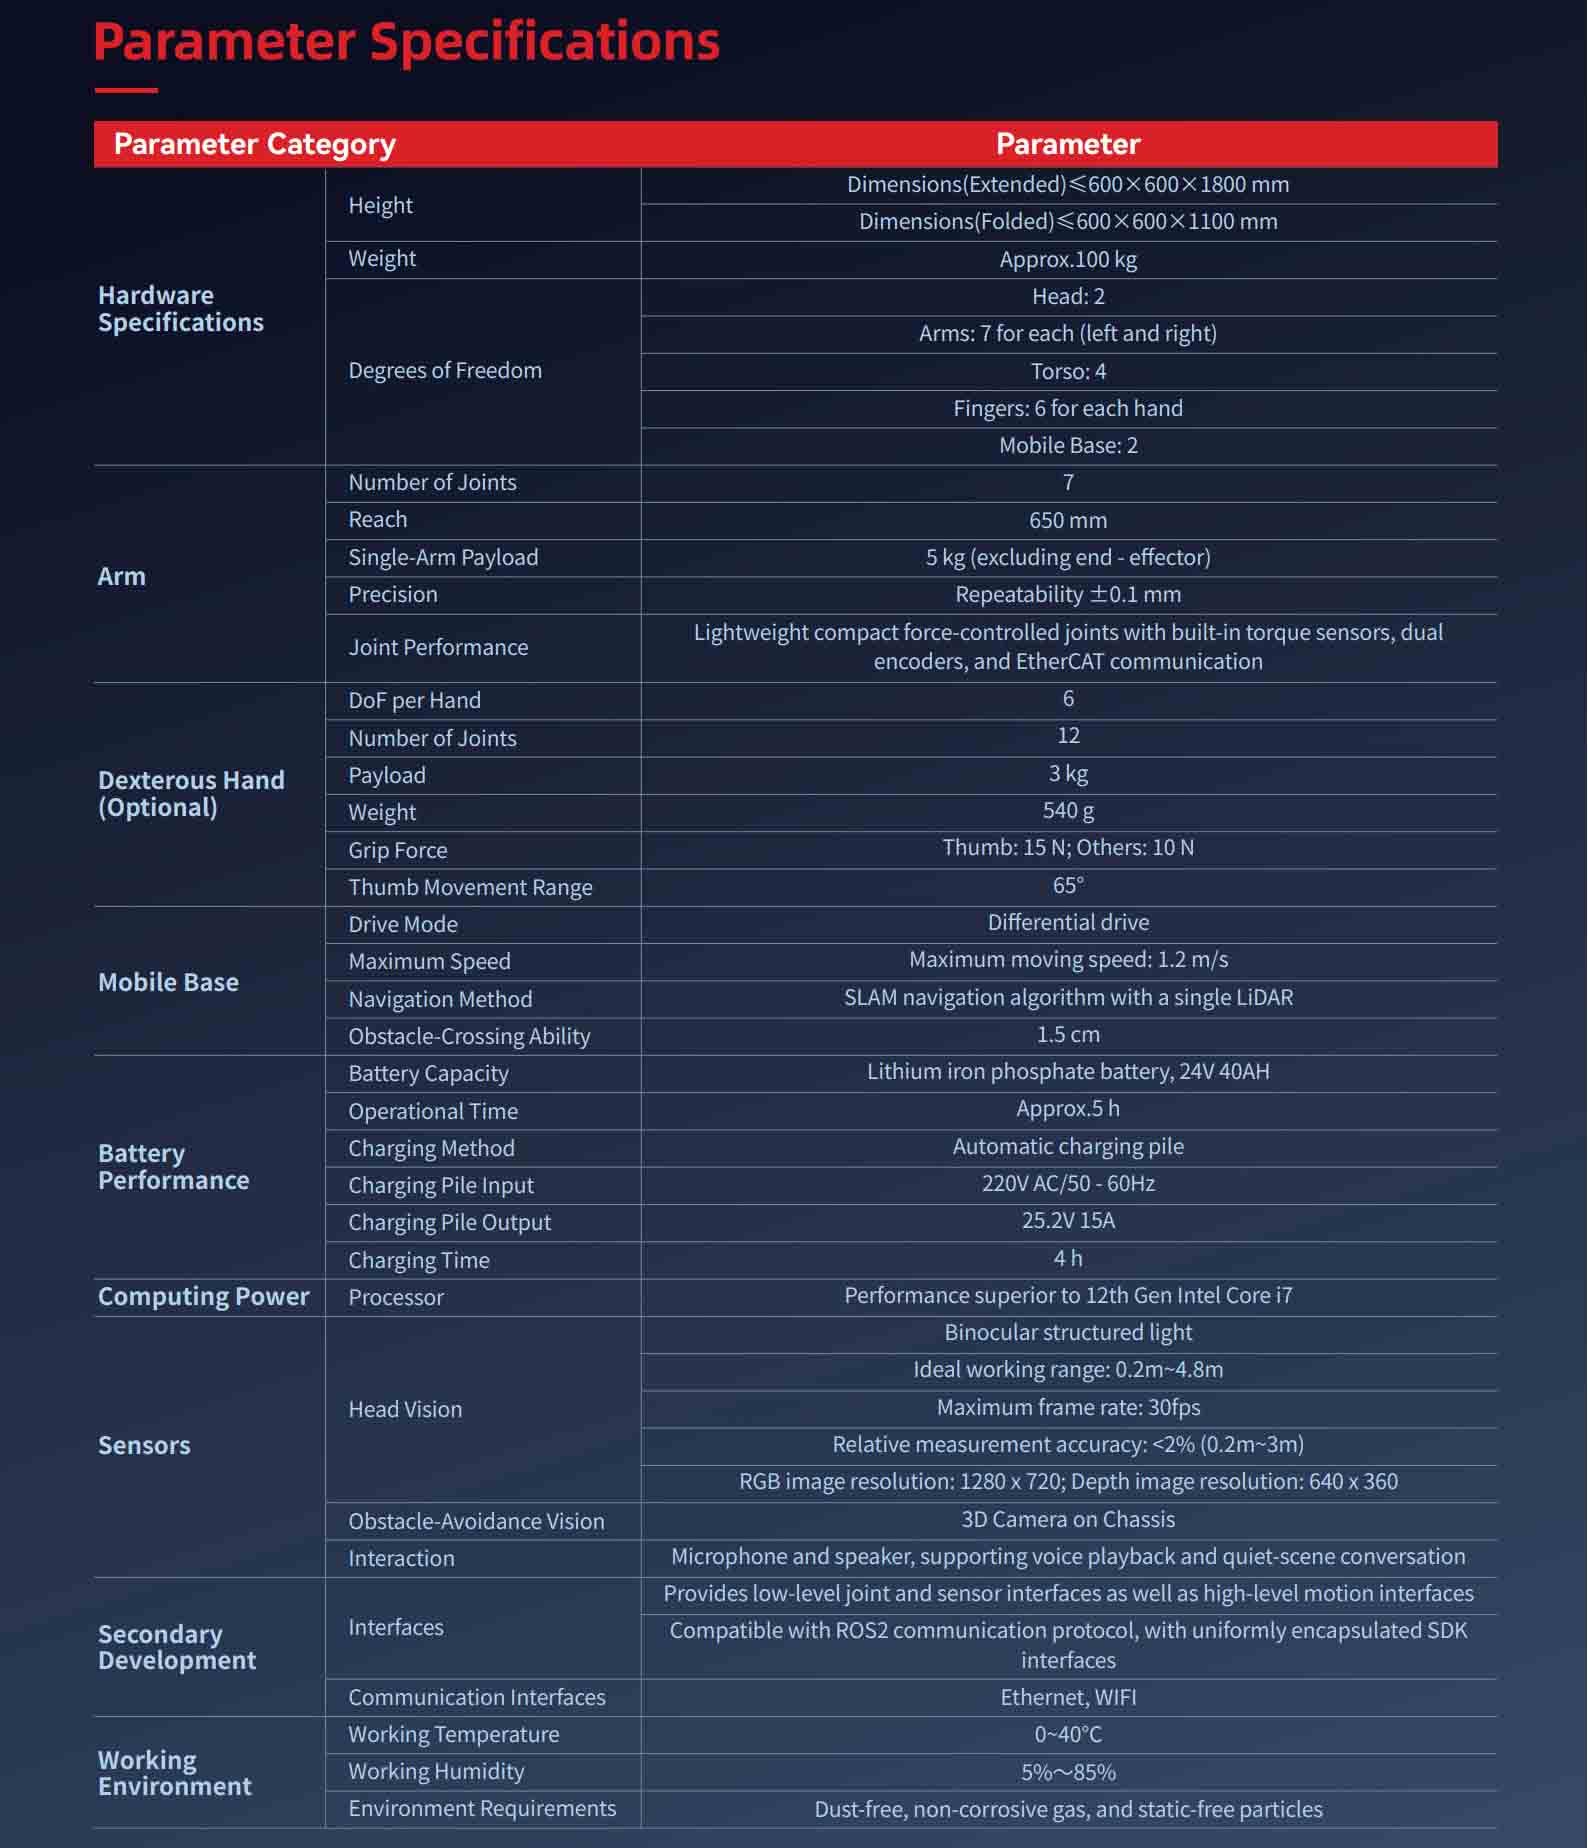
Hw Param | Hoogte | Length, width, height (extended)≤ 680x640x1736mm |
Gewicht | About 90kg | |
DOF | Head:2 | |
arm | Number of joints | 7 |
Bereik | 650mm | |
Single-arm rated load | 5kg (excluding end effector) | |
Nauwkeurigheid | Repeated positioning accuracy is ±0.1mm | |
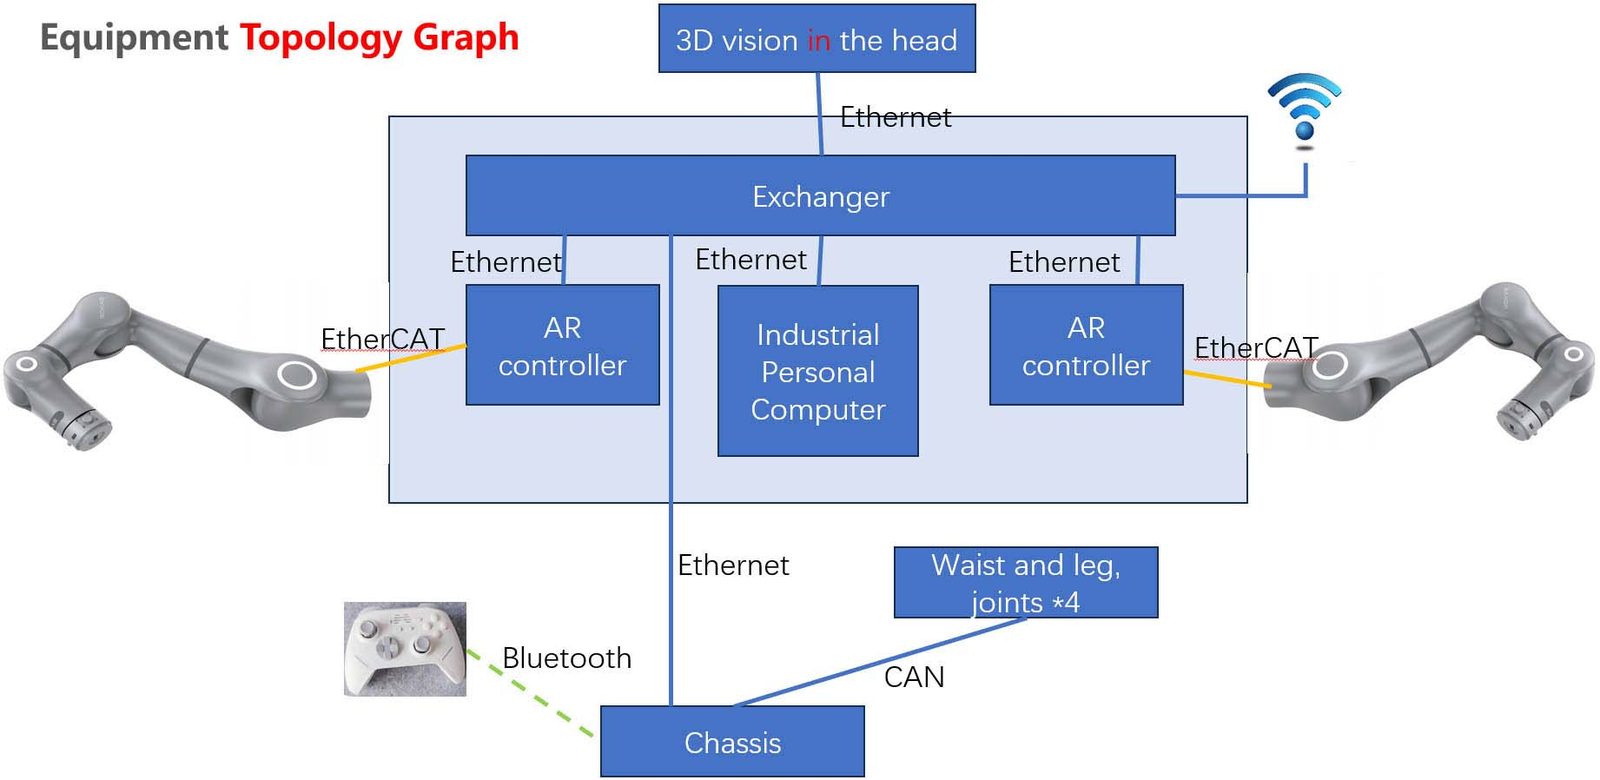
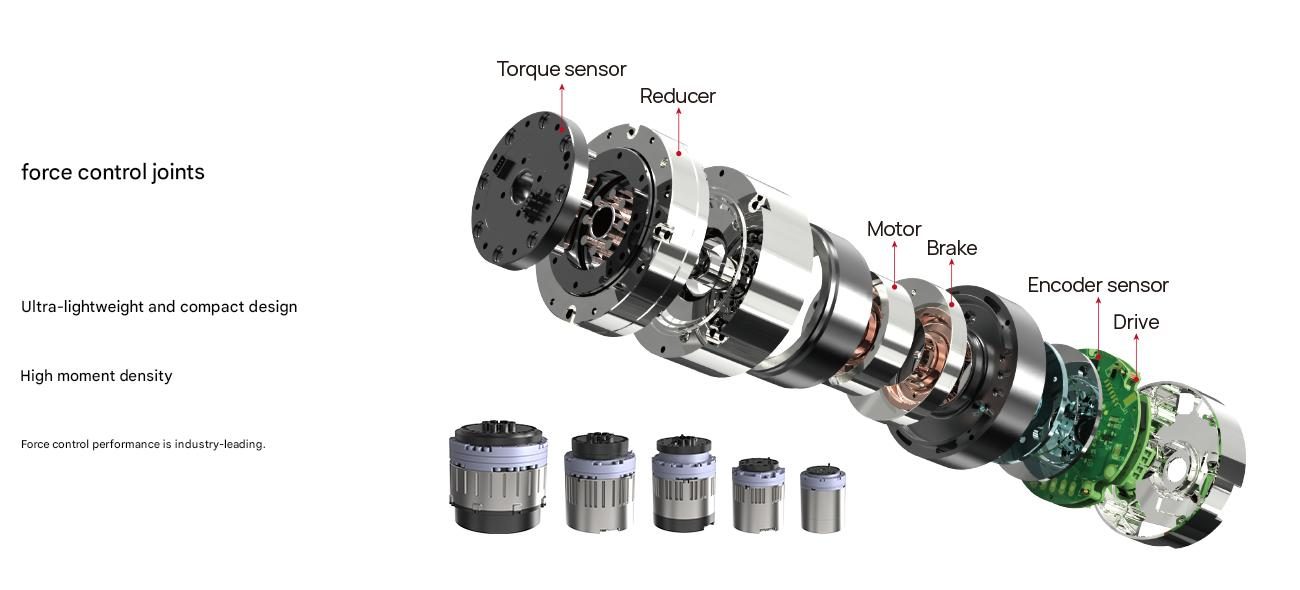
Joint performance | Lichtgewicht en compact krachtgestuurde verbinding, met ingebouwde koppelsensor, dubbele encoders en EtherCAT-communicatie | |
Dexterous hand (optional) | DOF | 10(6 active degrees of freedom) |
Number of joints | 12 | |
Laadvermogen | 3kg | |
Gewicht | 540g | |
Grasping ability | Thumb:15N;Four-fingered:10N | |
Range of the thumb | 65° | |
Mobile chassis | Move mode | Full-directional movement |
Maximum speed | Maximum moving speed:1.5 m/s | |
Navigate mode | SLAM navigation algorithm, dual laser radars | |
Obstacle climbing ability | 1.5cm | |
Cruising ability | Batterijcapaciteit | 48V 30AH |
Levensduur van de batterij | 6h | |
Charge mode | Manual, automatic, battery quick replacement | |
Charger input | 220V AC/50-60Hz | |
Oplaadtijd | 1.5h | |
Computing power | Processor | Intel i7-1195G7 ;16GB of RAM, 256GB solid-state drive |
Sensor | Head vision | Orbbec Gemini 335L |
Obstacle avoidance vision | 4 sets visuele 3D-hindernissen ontwijking voor chassis (optioneel) | |
Interaction | Microphone, speaker | |
Secondary development | Interface | Het biedt verbindingen op laag niveau en sensorinterfaces en bewegingsinterfaces op hoog niveau |
Compatibel met het ROS2-communicatieprotocol en het uniform inkapselen van de SDK-interface | ||
Communicatie-interface | Ethernet, WIFI | |
Working environment | Working Temperature | 0~40℃ |
Working Humidity | 5%~95% | |
Environment | No dust, no corrosive gas, no static particles, no flammable or explosive substances |
Volledige technische gegevens
| Model | Helios |
|---|---|
| Nauwkeurigheid bij bewegingspositionering van industriële kwaliteit | 10mm; |
| Nauwkeurigheid van armmanipulatie | ±0.1mm; |
| Vrijheidsgraden voor het hele lichaam | 42; |
| Multimodale fusieperceptie | Pose-Vision-Force control strategy: Tactic of Pose + Vision + Force; |
| Maximaal laadvermogen per arm | 5 kg. |
| Laadvermogen | 5 kg |
| Tolerantie | ±0.1 mm |
| Categorie | AI en humanoïde robots |
| Doorlooptijd | 90 dagen |
Waarden zijn nominaal bij 20 °C. Download de datasheet voor CAD-modellen, koppelcurven en I/O-kaarten van de controller.
Waar het draait
Op maat gemaakt en in opdracht gemaakt door TROY-ingenieurs.
Op maat gemaakt en in opdracht gemaakt door TROY-ingenieurs.
Op maat gemaakt en in opdracht gemaakt door TROY-ingenieurs.
Op maat gemaakt en in opdracht gemaakt door TROY-ingenieurs.
Vragen van kopers
Wat zijn de belangrijkste specificaties?
Model: Helios, nauwkeurigheid van bewegingspositionering van industriële kwaliteit: 10 mm;, nauwkeurigheid van armmanipulatie: ± 0,1 mm;.
Wat is de doorlooptijd?
90 dagen voor de standaardconfiguratie; bevestigd bij offerte.
Kan het worden aangepast?
Ja – OEM/ODM-opties, spanning, tooling en branding kunnen worden aangepast. Verzend de aanvraag en doeloutput voor een voorstel.
Ontvang een scherp geprijsd voorstel voor Helios
Vermeld het onderdeel, het doeltarief en de bestemmingshaven. Een engineer – geen chatbot – antwoordt binnen 48 uur.
Zelfde categorie

Humanoïde robot met twee armen op wielen

Tweearmige humanoïde robot

Biomimetische Panda-servicerobot
Beoordeeld door TROY Engineering ·. Bij iedere offerte worden de specificaties opnieuw getoetst aan de leveranciersdatasheet.