


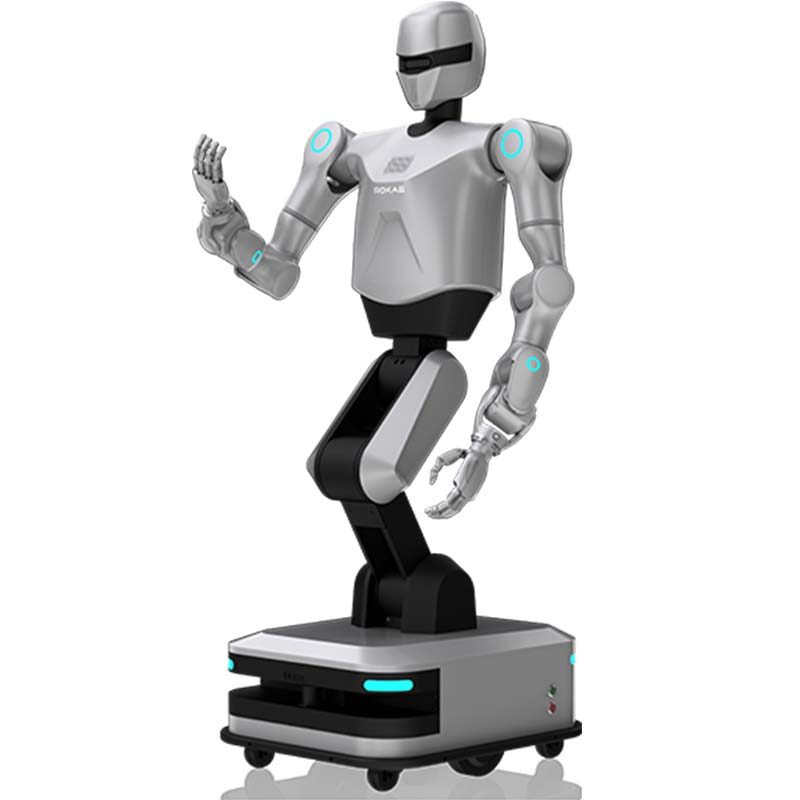
Helios, Robot beroda dua lengan
The Helios is a humanoid or AI robot for research / reception. Key specifications: Industrial-grade motion positioning accuracy 10 mm; Arm manipulation accuracy ±0.1 mm; Full body degrees of freedom 42. Lead time is 90 days; pricing is quoted per configuration. Certifications: CE documentation on request.
- Model
- Helios
- Akurasi posisi gerakan tingkat industri
- 10mm;
- Akurasi manipulasi lengan
- ±0.1mm;
- Derajat kebebasan seluruh tubuh
- 42;
- Persepsi fusi multimodal
- Pose-Vision-Force control strategy: Tactic of Pose + Vision + Force;
- Muatan maksimum per lengan
- 5kg.
Untuk apa platform ini
Robot Berlengan Ganda Beroda--- Helios! Akurasi posisi gerak tingkat industri: 10mm; Akurasi manipulasi lengan: ±0,1mm; Derajat kebebasan seluruh tubuh: 42; Persepsi fusi multimodal: Strategi pengendalian Pose-Vision-Force: Taktik Pose + Vision + Force; Muatan maksimum per lengan: 5kg.
istilah komersial
| Kutipan | Harga per konfigurasi — balas dalam 48 jam |
|---|---|
| Waktu memimpin | 90 hari |
| MOQ | 1 buah |
| Asal | Cina |
| Pelabuhan pemuatan | Shanghai, China |
| Incoterm | FOB Shanghai / CIF on request |
| Pembayaran | Deposit 30%, 70% sebelum pengiriman |
| Jaminan | Standar 24 bulan, 36 bulan opsional |
Detail produk
Catatan aplikasi, gambar konstruksi, dan video dari file teknik TROY — dokumentasi yang sama dikirimkan bersama kutipan.
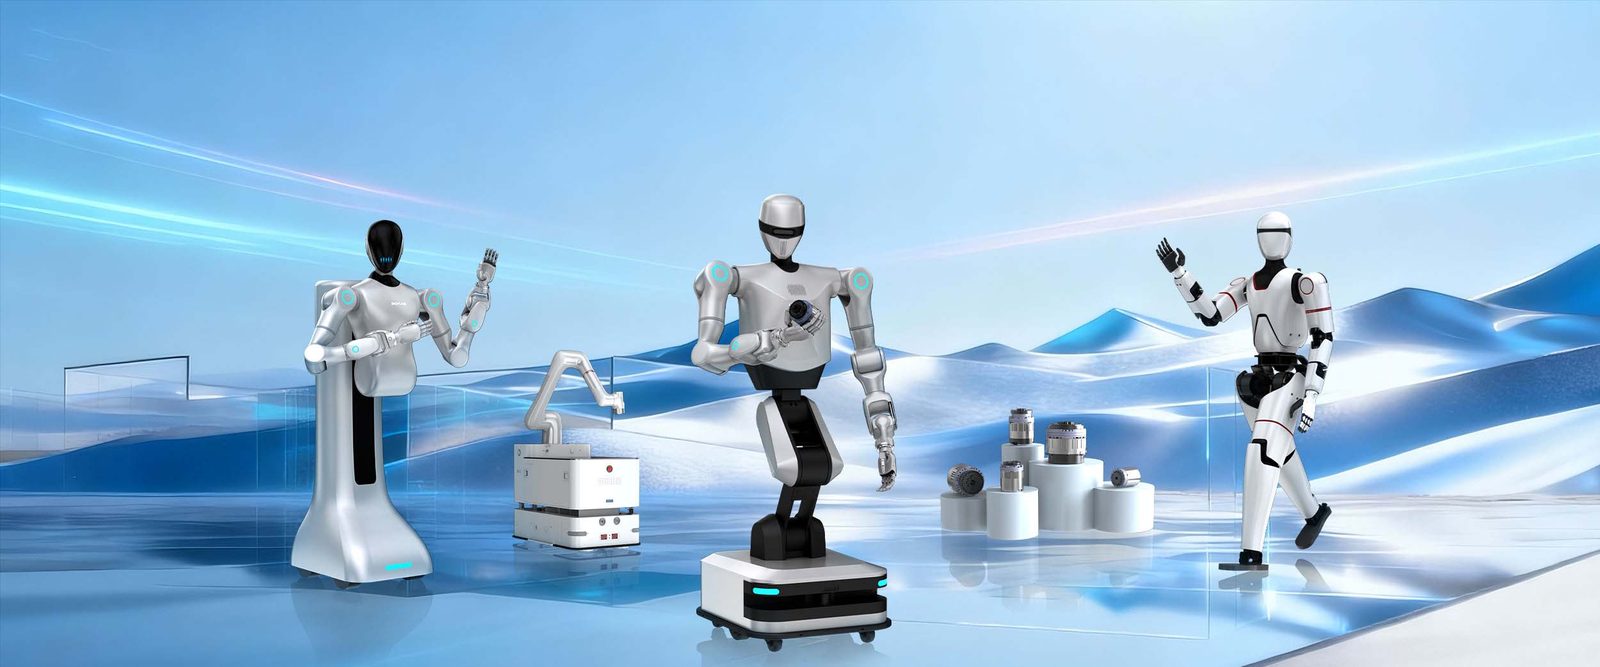
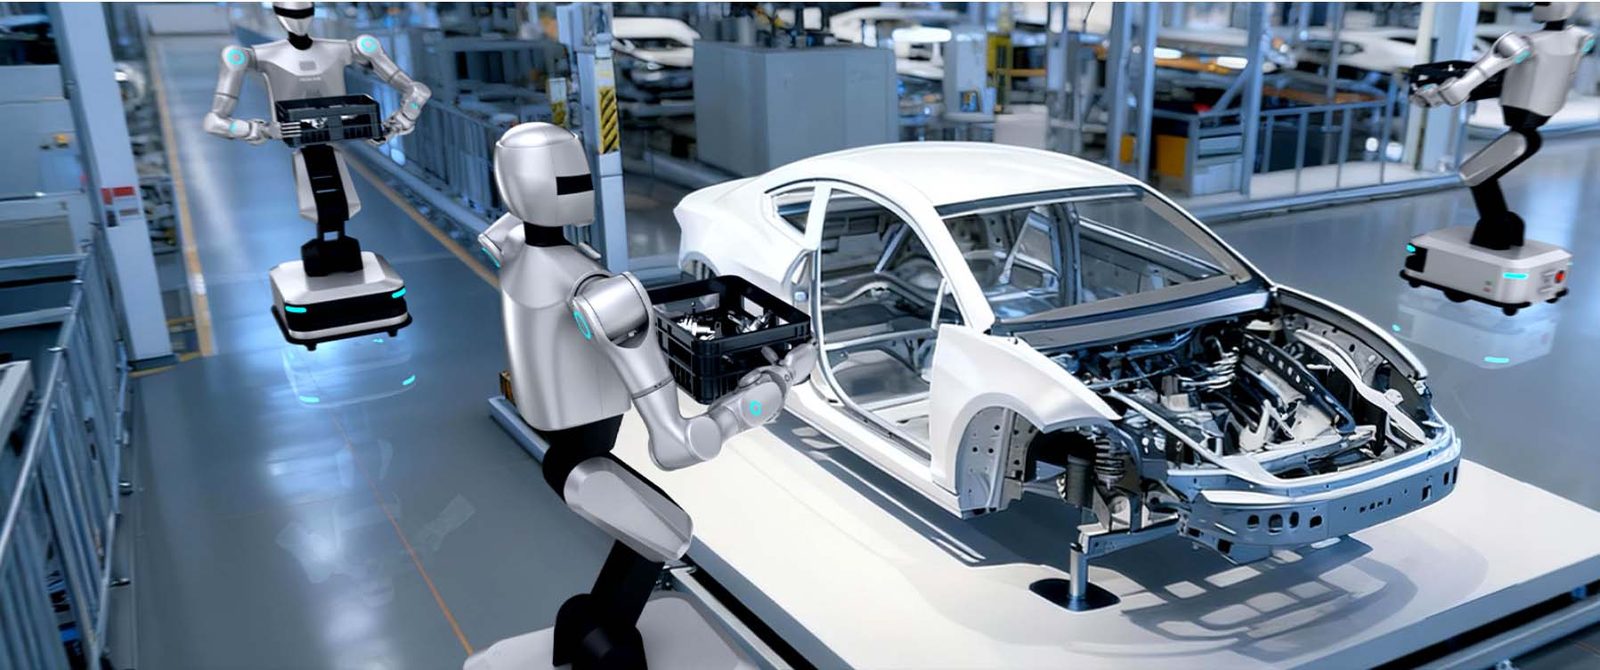
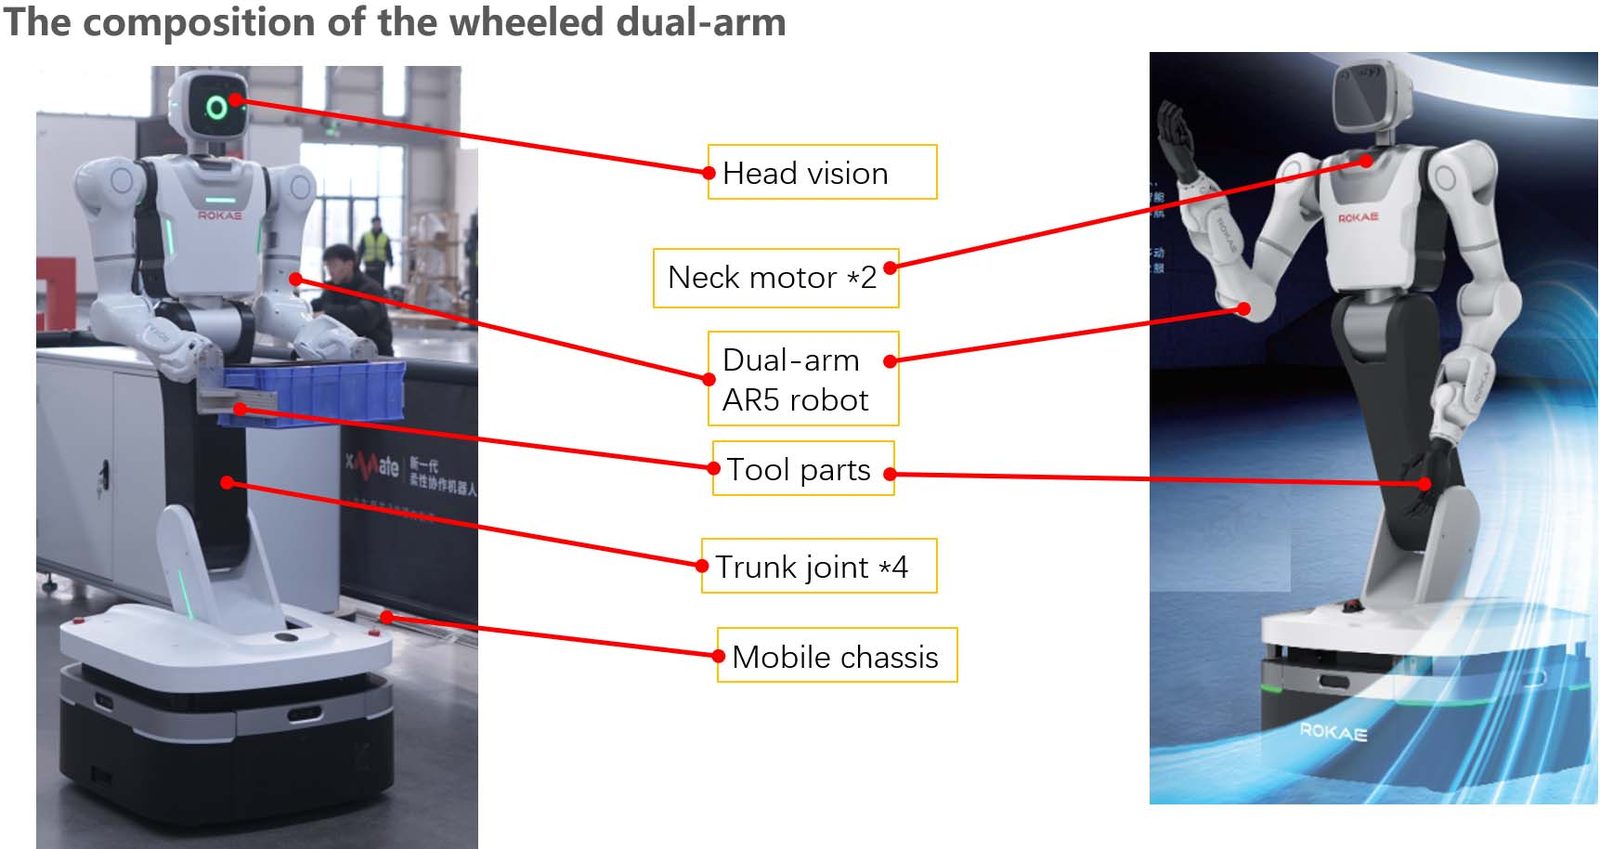
Helios is a wheeled dual-arm robot independently developed by Rokae. It achieves multimodal fusion perception through a posture-vision-force control strategy, combined with laser SLAM navigation. Without environmental modification, it can autonomously navigate and make decisions in complex scenarios, capable of handling various challenging tasks.
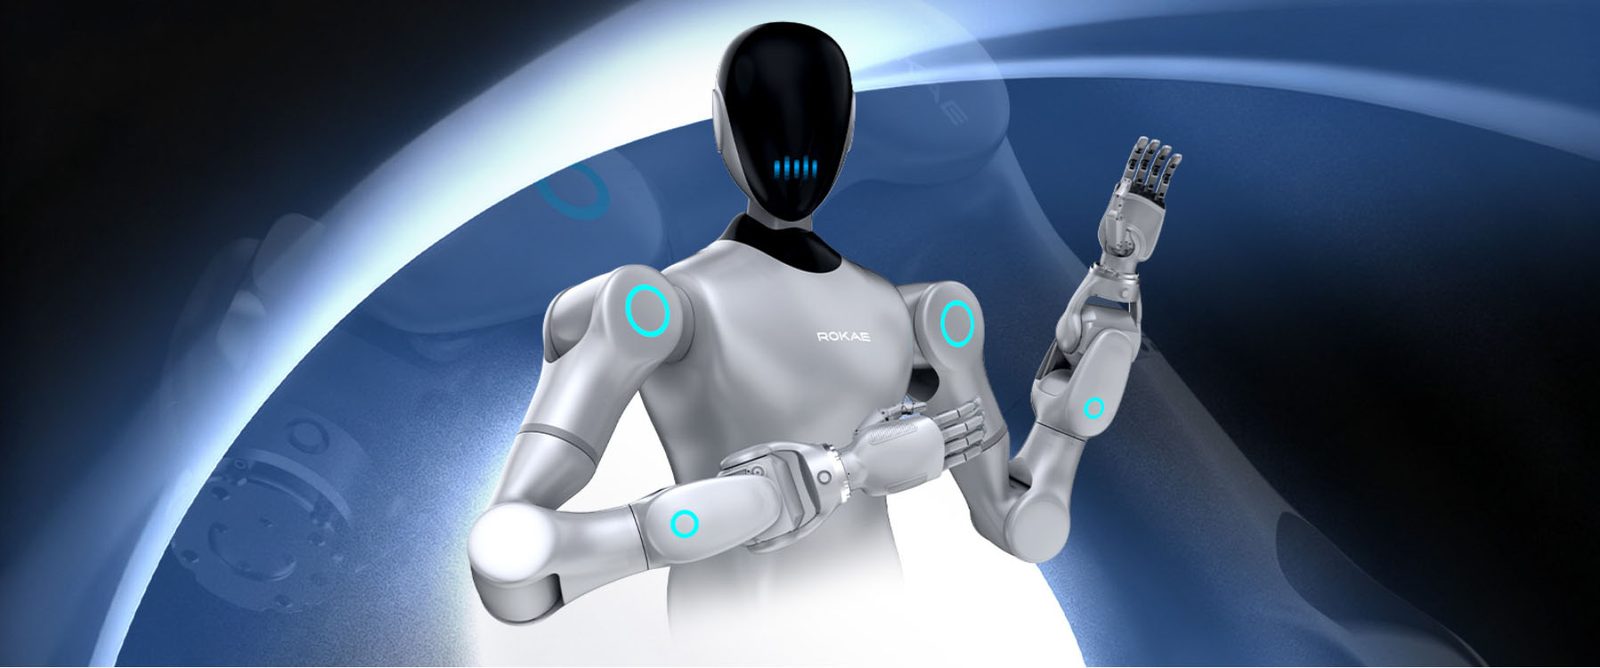
Helios boasts 42 degrees of freedom, combining efficient mobility with dexterous manipulation. Equipped with a seven-DOF, cross-wrist force-controlled arm and joint torque sensors, it achieves high-dynamic force control, making it widely applicable in industrial scenarios such as bin handling, complex material sorting, and precision assembly. Furthermore, its open underlying control architecture and flexible secondary development interfaces facilitate user customization of advanced functions to meet diverse needs in education, research, and automated process development.
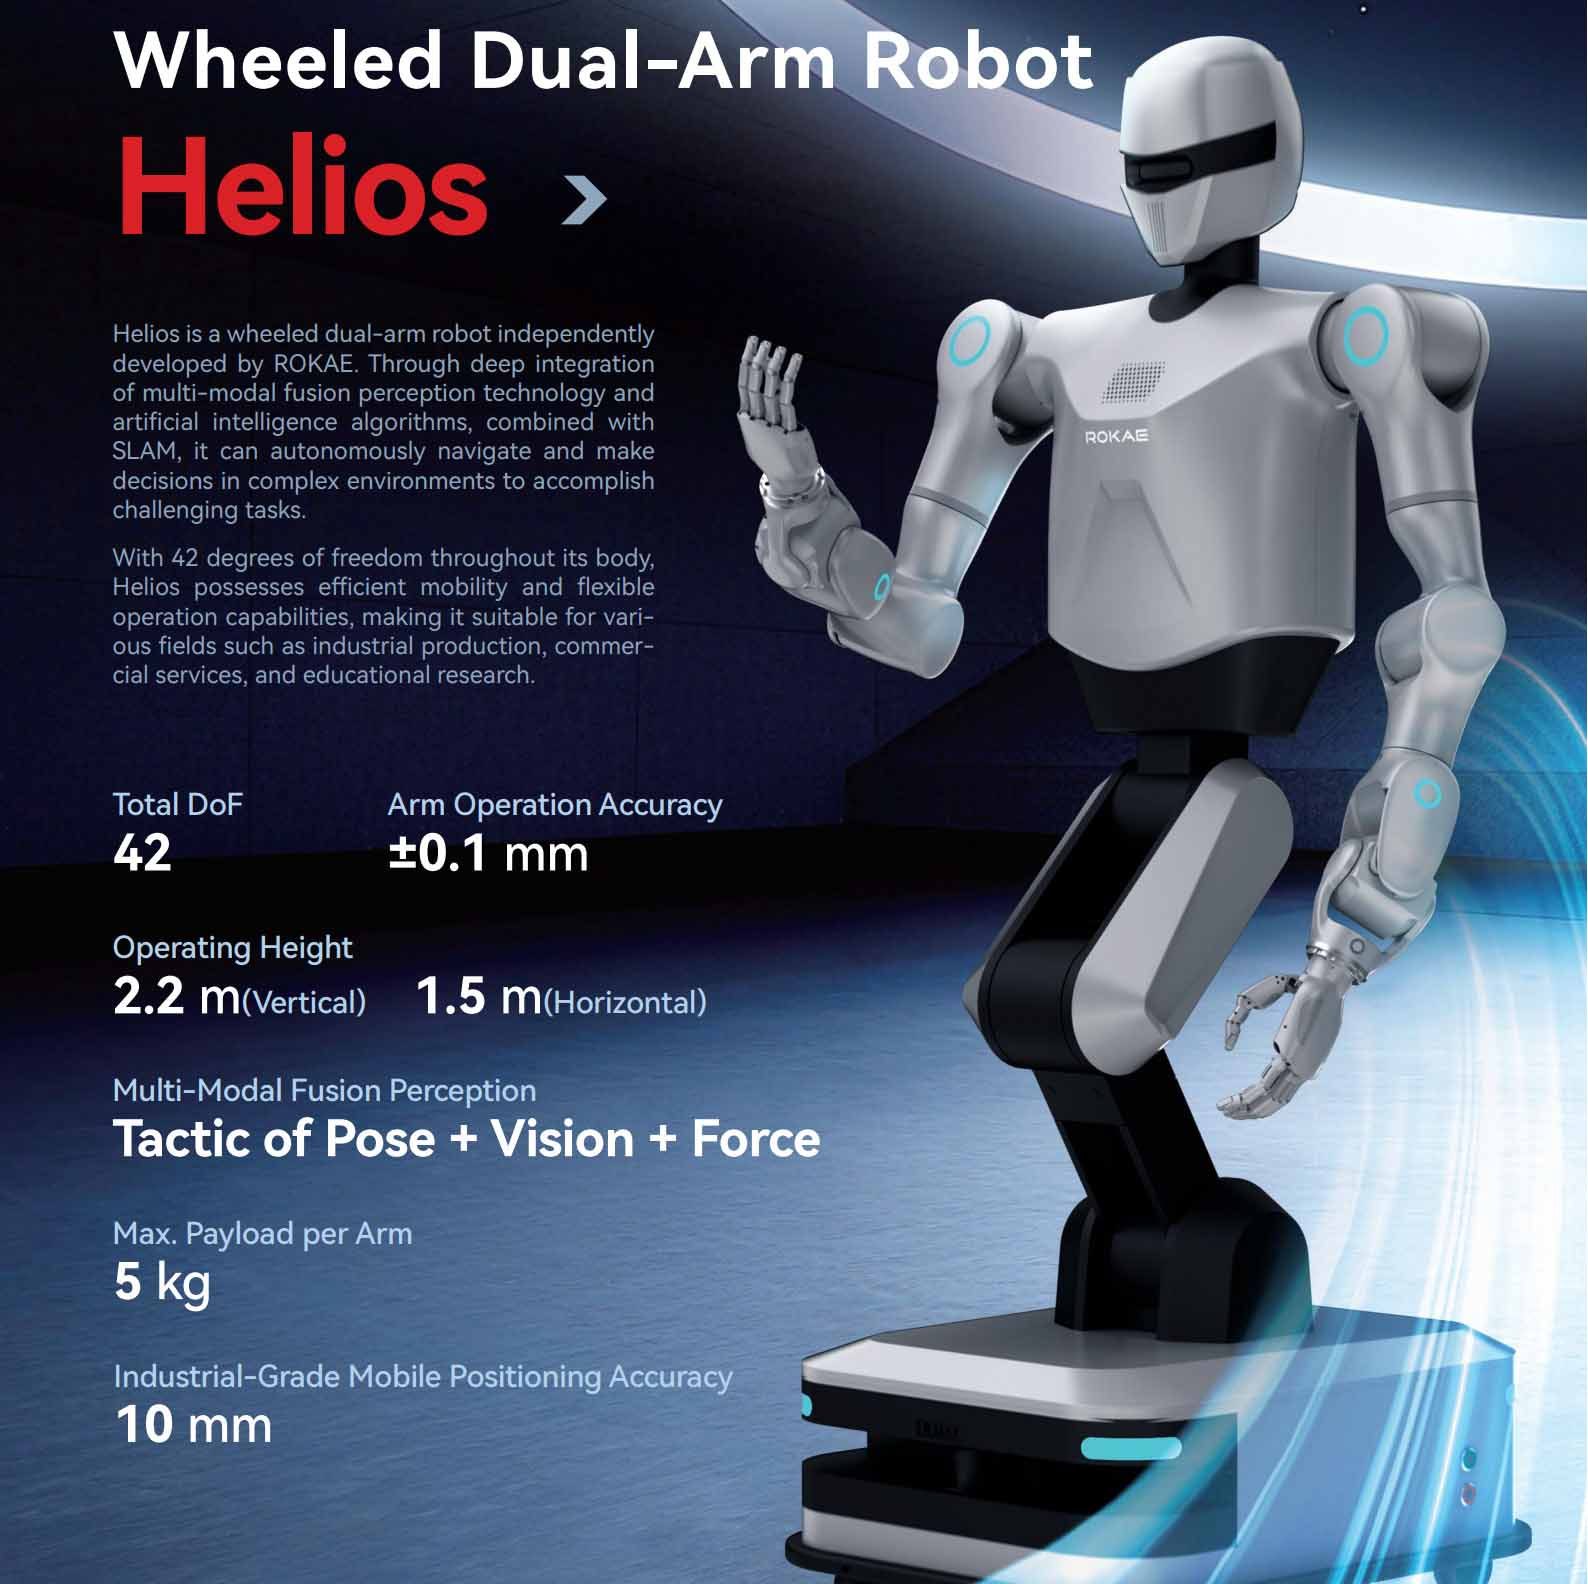
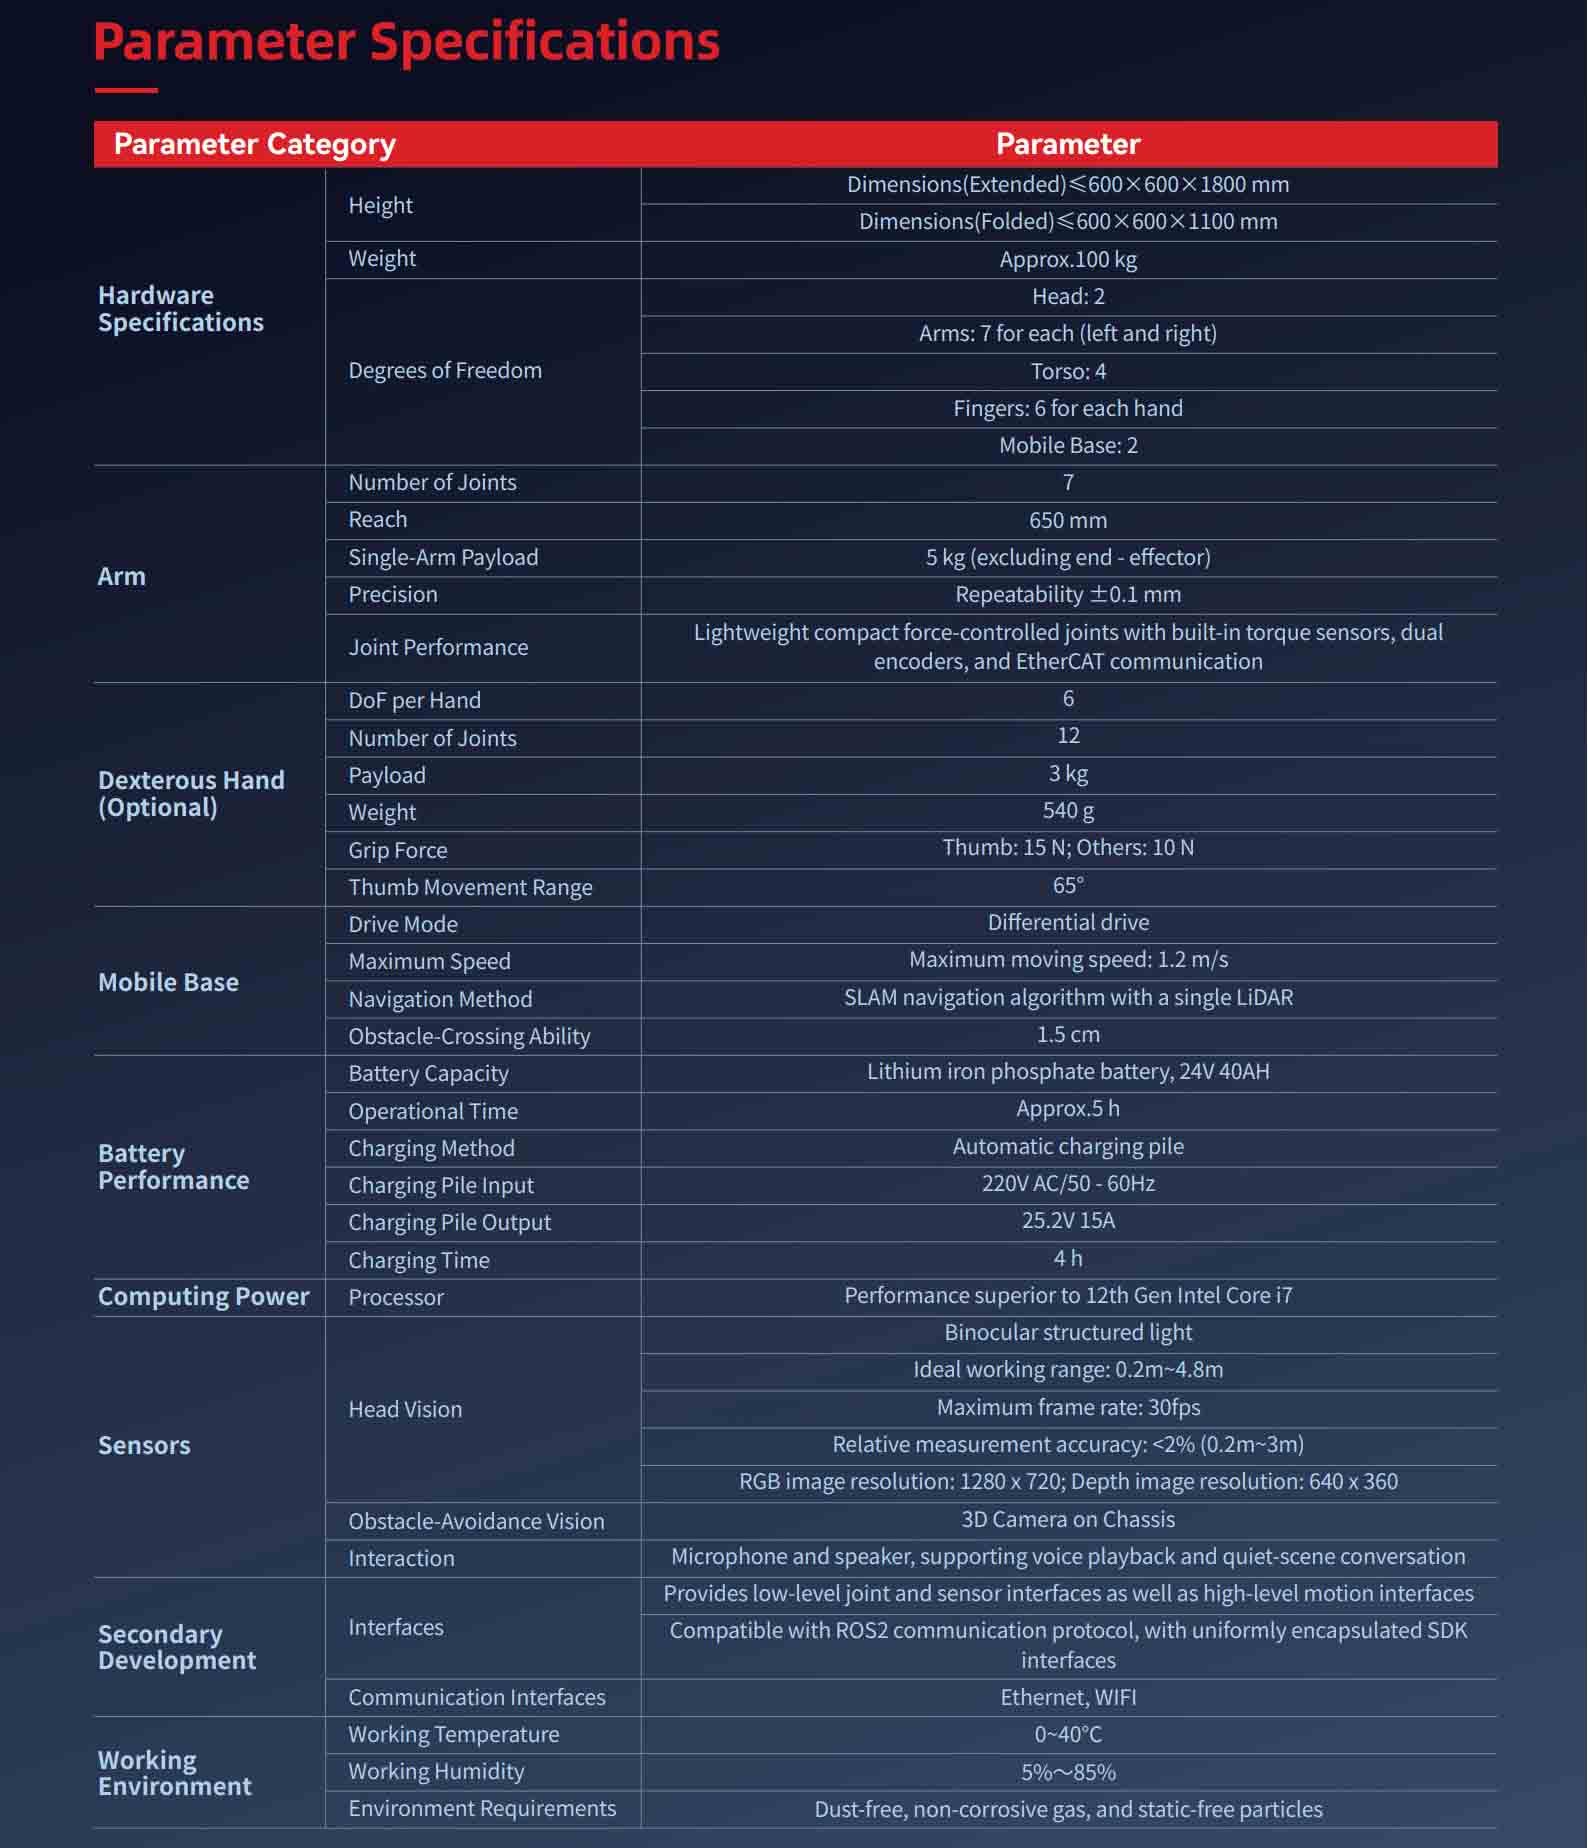
Hw Param | Tinggi | Length, width, height (extended)≤ 680x640x1736mm |
Berat | About 90kg | |
DOF | Head:2 | |
lengan | Number of joints | 7 |
Mencapai | 650mm | |
Single-arm rated load | 5kg (excluding end effector) | |
Ketepatan | Repeated positioning accuracy is ±0.1mm | |
Joint performance | Ringan dan kompak sambungan yang dikontrol gaya, dengan sensor torsi internal, encoder ganda, dan komunikasi EtherCAT | |
Dexterous hand (optional) | DOF | 10(6 active degrees of freedom) |
Number of joints | 12 | |
Kapasitas beban | 3kg | |
Berat | 540g | |
Grasping ability | Thumb:15N;Four-fingered:10N | |
Range of the thumb | 65° | |
Mobile chassis | Move mode | Full-directional movement |
Maximum speed | Maximum moving speed:1.5 m/s | |
Navigate mode | SLAM navigation algorithm, dual laser radars | |
Obstacle climbing ability | 1.5cm | |
Cruising ability | Kapasitas baterai | 48V 30AH |
Daya tahan baterai | 6h | |
Charge mode | Manual, automatic, battery quick replacement | |
Charger input | 220V AC/50-60Hz | |
Waktu pengisian daya | 1.5h | |
Computing power | Processor | Intel i7-1195G7 ;16GB of RAM, 256GB solid-state drive |
Sensor | Head vision | Orbbec Gemini 335L |
Obstacle avoidance vision | 4 set rintangan visual 3D penghindaran untuk sasis (opsional) | |
Interaction | Microphone, speaker | |
Secondary development | Antarmuka | Ini menyediakan sambungan tingkat rendah dan antarmuka sensor serta antarmuka gerak tingkat tinggi |
Kompatibel dengan protokol komunikasi ROS2 dan merangkum antarmuka SDK secara seragam | ||
Antarmuka komunikasi | Ethernet, WIFI | |
Working environment | Working Temperature | 0~40℃ |
Working Humidity | 5%~95% | |
Environment | No dust, no corrosive gas, no static particles, no flammable or explosive substances |
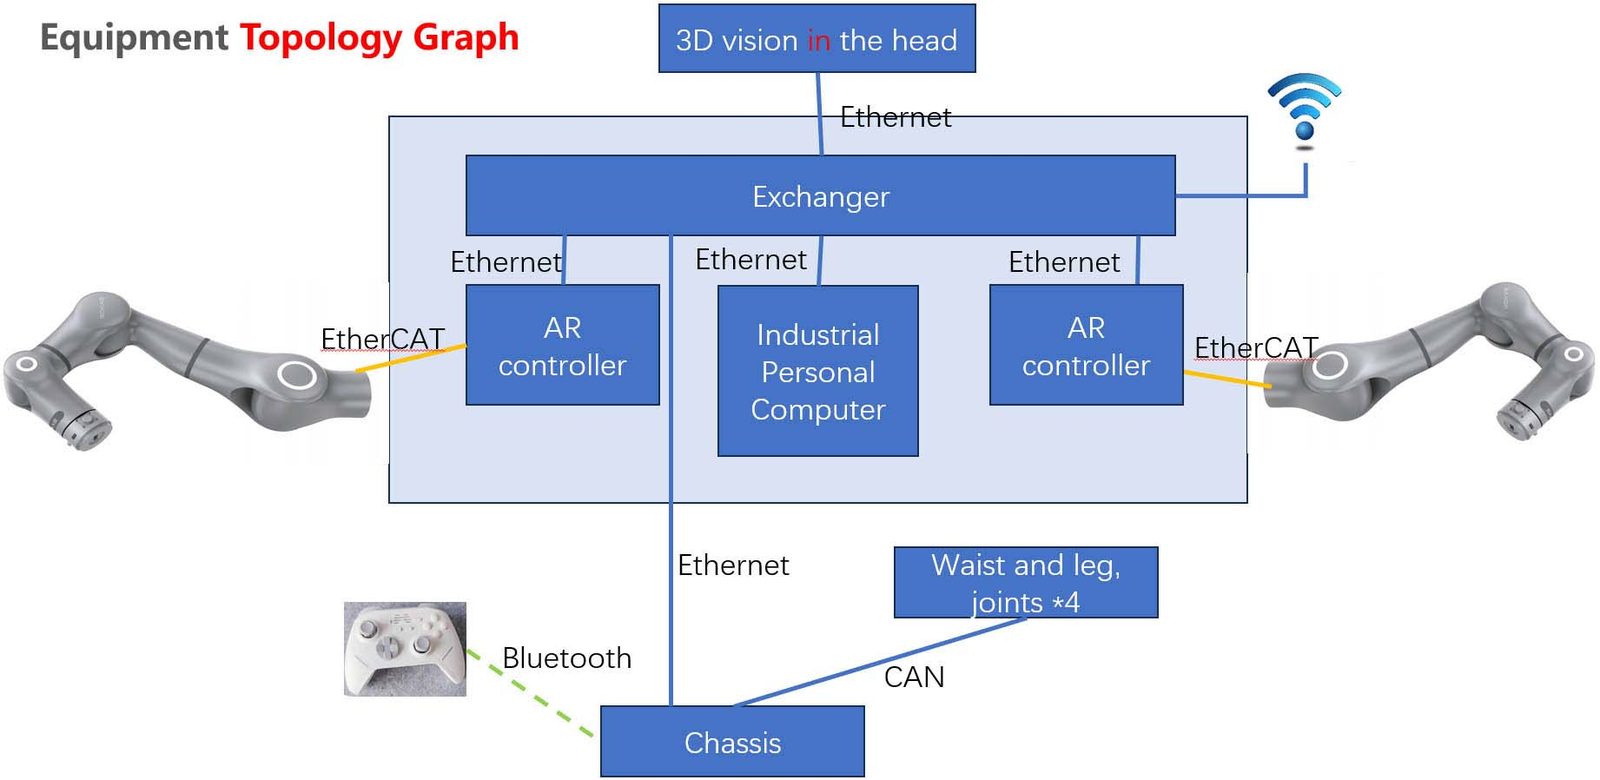
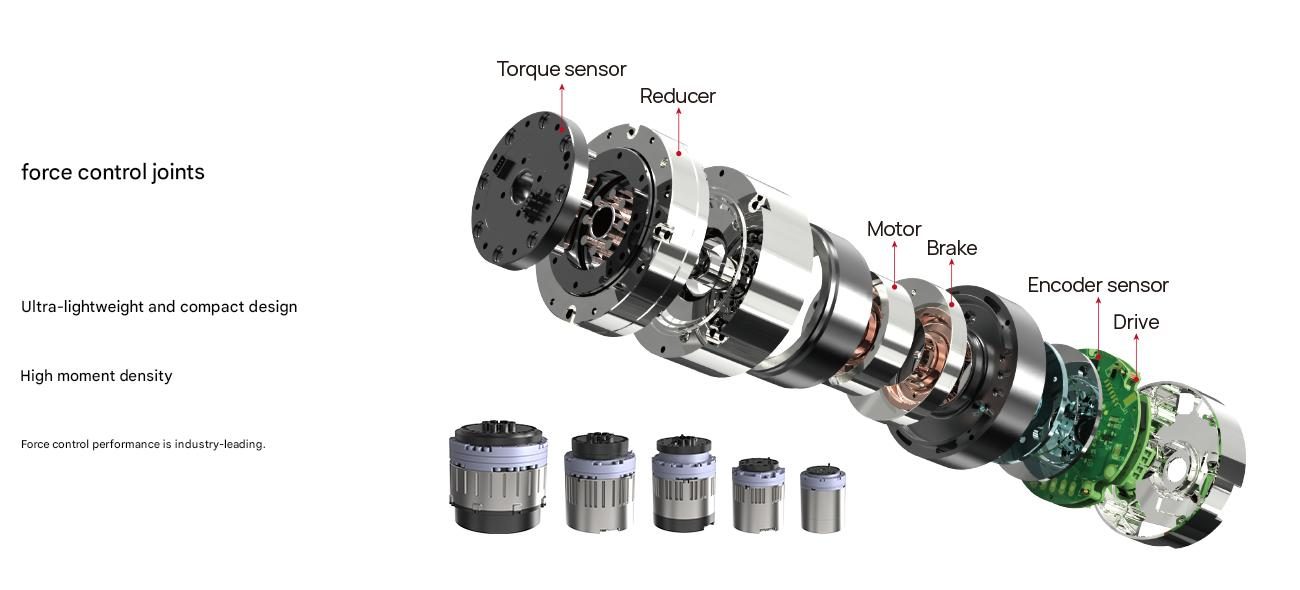
Data teknis lengkap
| Model | Helios |
|---|---|
| Akurasi posisi gerakan tingkat industri | 10mm; |
| Akurasi manipulasi lengan | ±0.1mm; |
| Derajat kebebasan seluruh tubuh | 42; |
| Persepsi fusi multimodal | Pose-Vision-Force control strategy: Tactic of Pose + Vision + Force; |
| Muatan maksimum per lengan | 5kg. |
| Muatan | 5 kg |
| Toleransi | ±0.1 mm |
| Kategori | Robot AI & Humanoid |
| Waktu memimpin | 90 hari |
Nilainya nominal pada 20 °C. Unduh lembar data untuk model cad, kurva torsi, dan peta I/O pengontrol.
Di mana ia berjalan
Diukur dan ditugaskan oleh para insinyur TROY.
Diukur dan ditugaskan oleh para insinyur TROY.
Diukur dan ditugaskan oleh para insinyur TROY.
Diukur dan ditugaskan oleh para insinyur TROY.
Pertanyaan pembeli
Apa spesifikasi utamanya?
Model: Helios, Akurasi posisi gerakan tingkat industri: 10mm;, Akurasi manipulasi lengan: ±0,1mm;.
Apa waktu tunggunya?
90 hari untuk konfigurasi standar; dikonfirmasi pada kutipan.
Bisakah itu disesuaikan?
Ya — Opsi OEM/ODM, voltase, perkakas, dan merek dapat disesuaikan. Kirim lamaran dan target keluaran proposal.
Dapatkan proposal harga untuk Helios
Sertakan bagian, target rate dan port tujuan. Seorang insinyur — bukan chatbot — membalas dalam waktu 48 jam.
Kategori yang sama

Robot Humanoid Lengan Ganda Beroda

Robot Humanoid Lengan Ganda

Robot Layanan Panda Biomimetik
Ditinjau oleh TROY Teknik ·. Spesifikasi diperiksa ulang berdasarkan lembar data pemasok di setiap penawaran.