


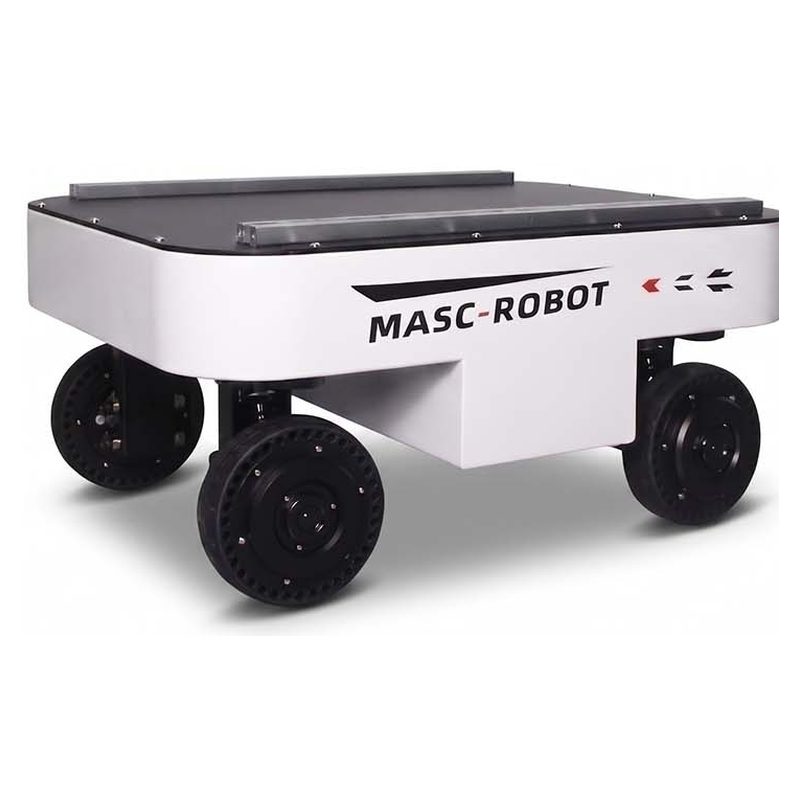
4WD 4WS Off-Road Mobile Robot Chassis TRLU-S4-100K
The TRLU-S4-100K is a mobile robot for internal logistics / warehouse transport. Key specifications: Payload 100 kg; Dimensions 718 x 560 x 340 mm; Vehicle weight 50 kg. Lead time is 15-30 days; pricing is quoted per configuration. Certifications: CE documentation on request.
- Model
- TRLU-S4-100K
- Payload
- 100 kg
- Dimensions
- 718 x 560 x 340 mm
- Vehicle weight
- 50 kg
- Drive
- 4 drive + 4 steering servo motors (8 axes)
- Six motion modes
- 4W4S, Ackermann, crabbing, diagonal, spin, parking
What This Platform Is For
TRLU-S4-100K is a 100 kg payload 4WD 4WS drive-by-wire robot chassis with 8 independent servo motors, six motion modes, 0 mm turning radius, 30 degree gradeability and IP55 protection. CAN bus and RC control, ready for LiDAR, RTK and SLAM development.
Commercial Terms
| Quotation | Priced per configuration — reply within 48 hours |
|---|---|
| Lead time | 15-30 days |
| MOQ | 1 unit |
| Origin | China |
| Port of loading | Shenzhen, China |
| Incoterm | FOB Shenzhen / CIF on request |
| Payment | 30% deposit, 70% before shipment |
| Warranty | 24 months standard, 36 months optional |
Product Details
Application notes, construction drawings and video from the TROY engineering file — the same documentation shipped with the quotation.
Compact 4WD 4WS Drive-By-Wire Chassis for Off-Road AMR Development
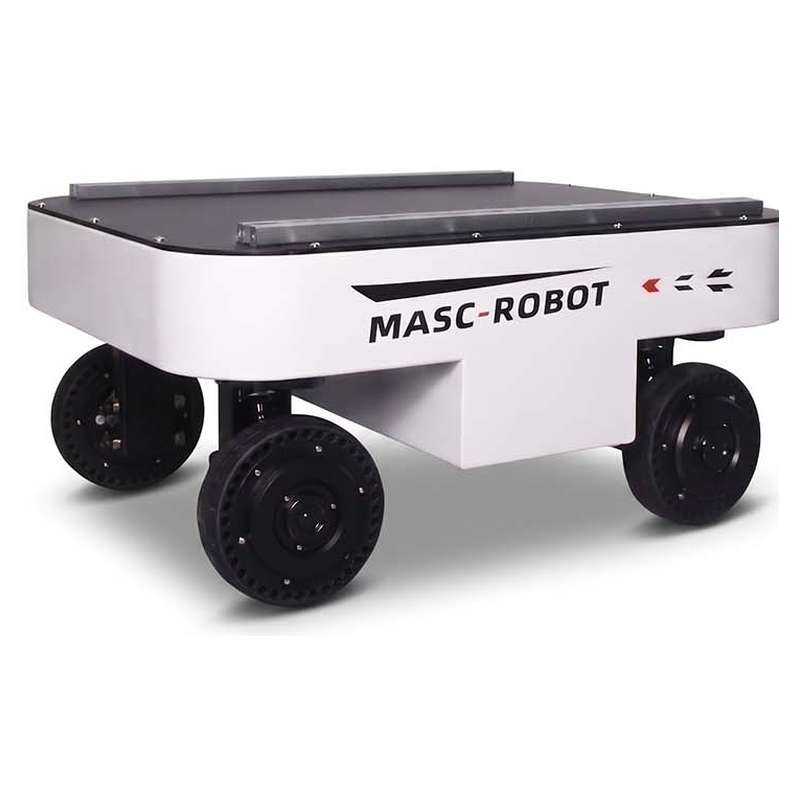
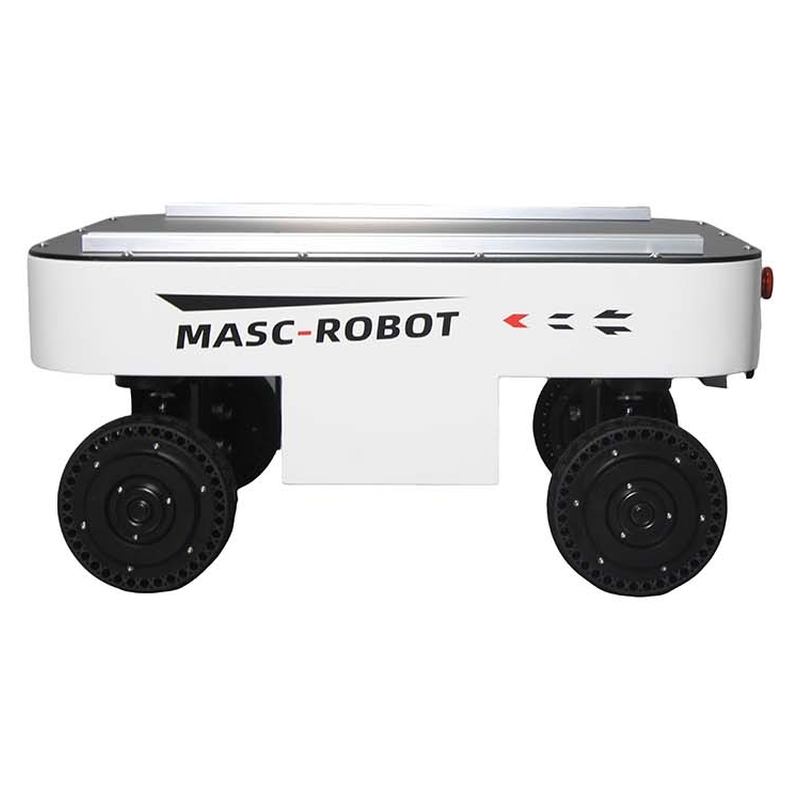
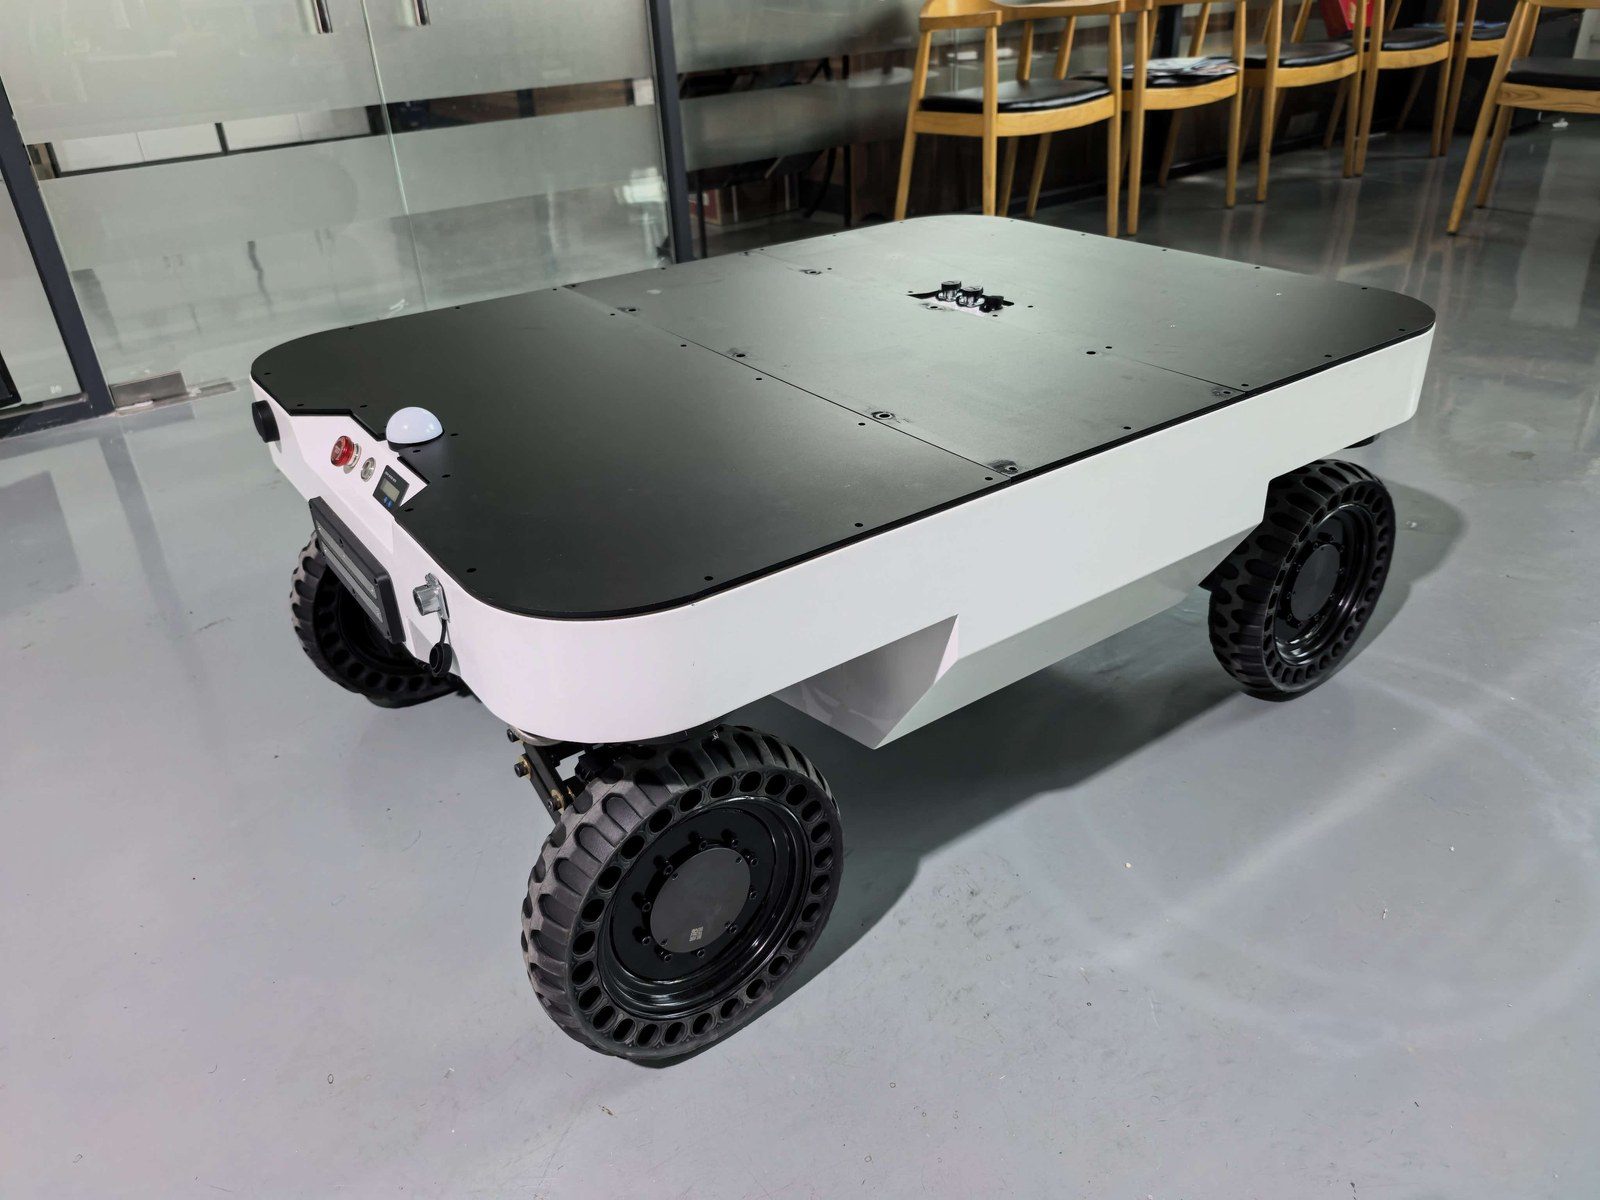
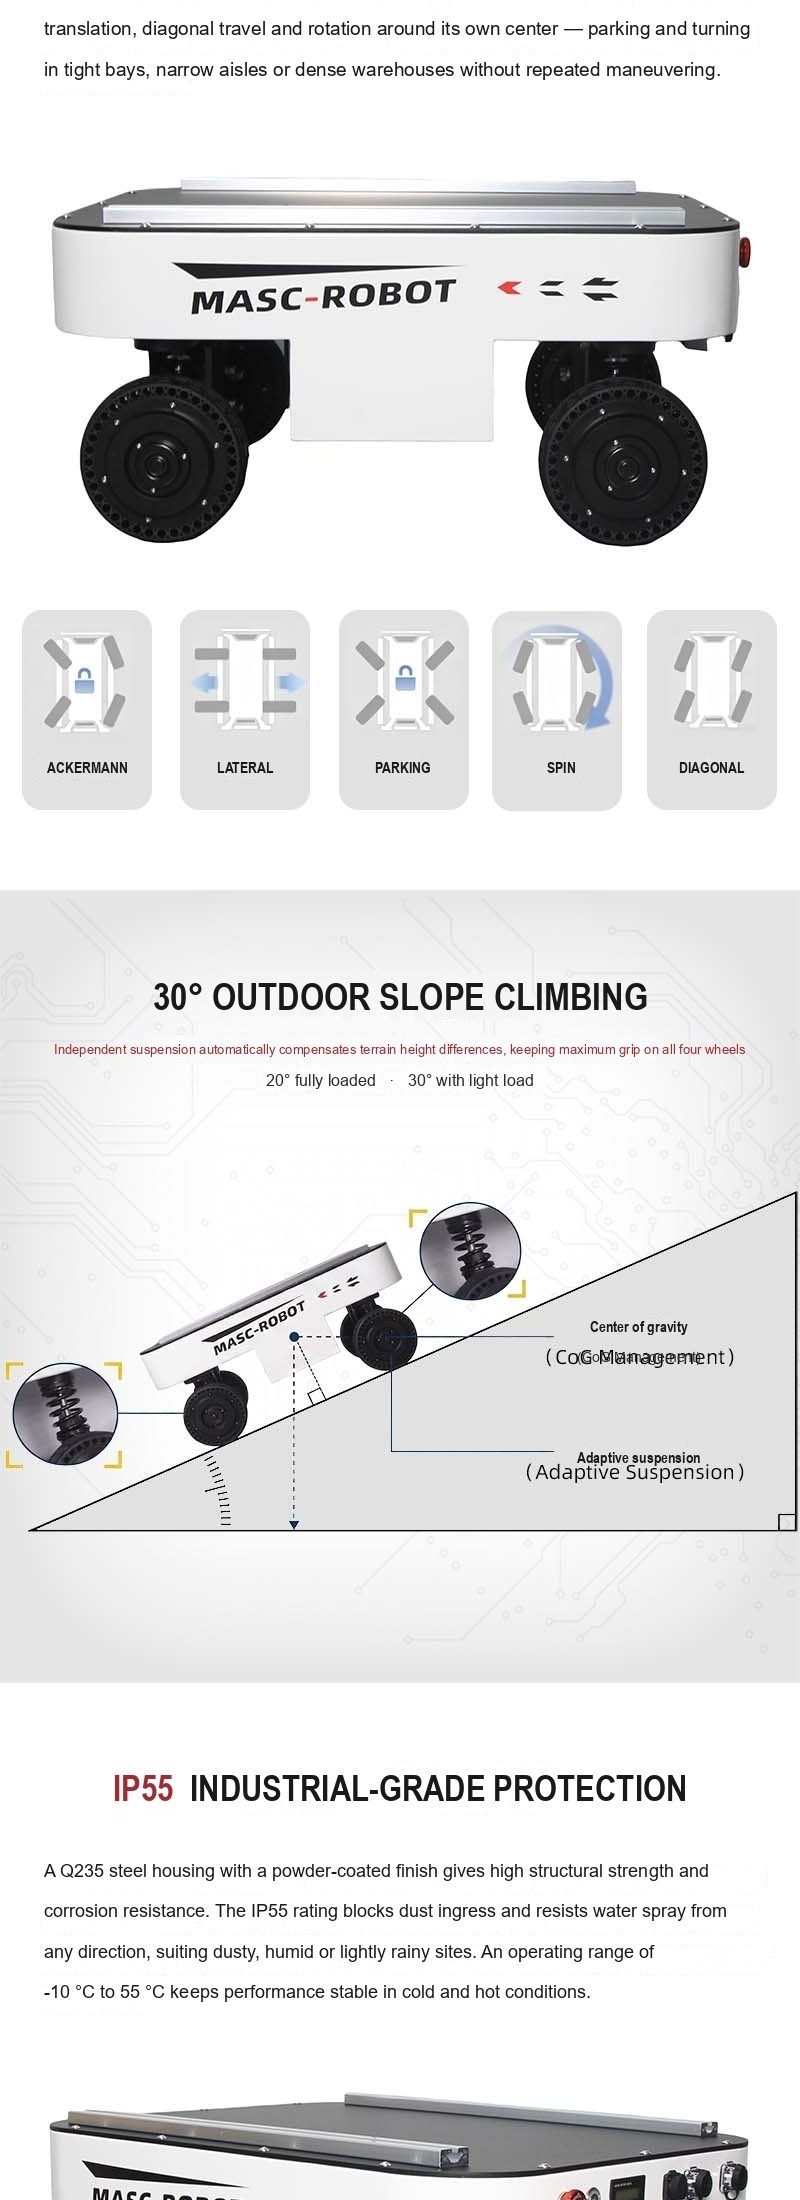
The TRLU-S4-100K is a compact four-wheel-drive, four-wheel-steering mobile robot chassis built for developers who need a reliable moving platform. Each of its four wheels carries its own drive motor and steering motor, giving eight independent servo axes: the chassis can travel forward, sideways and diagonally, and rotate on the spot around its own centre. With a 100 kg payload, a 718 x 560 x 340 mm footprint and 58.5 mm of suspension clearance, it works as comfortably in narrow corridors and pipe racks as it does on uneven outdoor ground.
Mount a LiDAR, depth camera, RTK module, IMU or industrial PC on the two pre-installed 40-series European aluminium profiles and the TRLU-S4-100K becomes an unmanned inspection robot, a research and teaching platform, or an outdoor logistics carrier. Control it with the supplied FlySky remote controller, or drive it from your own host computer through the Type-C CAN bus and the documented little-endian protocol.
Key Features
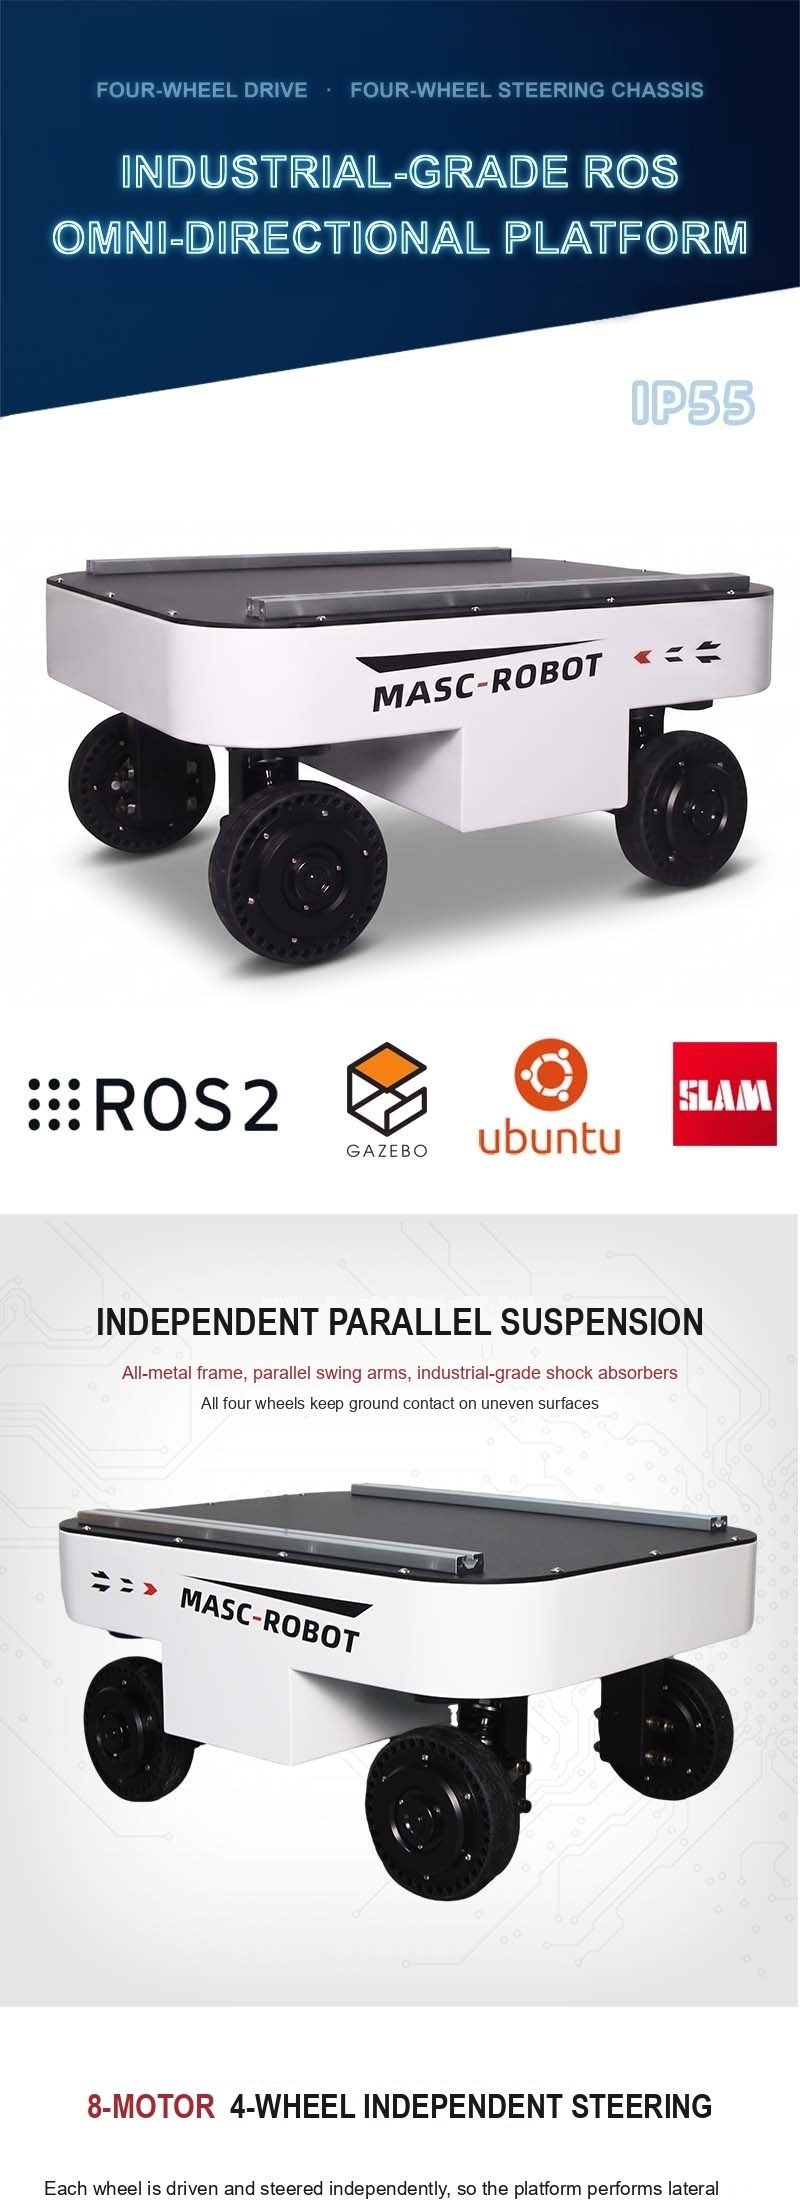
- 8-motor 4WD 4WS layout: 4 drive motors + 4 steering servo motors, independently controlled per wheel
- Six motion modes: 4W4S, front/rear Ackermann, crabbing (lateral), diagonal, spin and parking
- 0 mm minimum turning radius and 420 mm rotation radius - turns inside its own footprint
- 100 kg payload with a 50 kg vehicle weight and widened 421 mm track
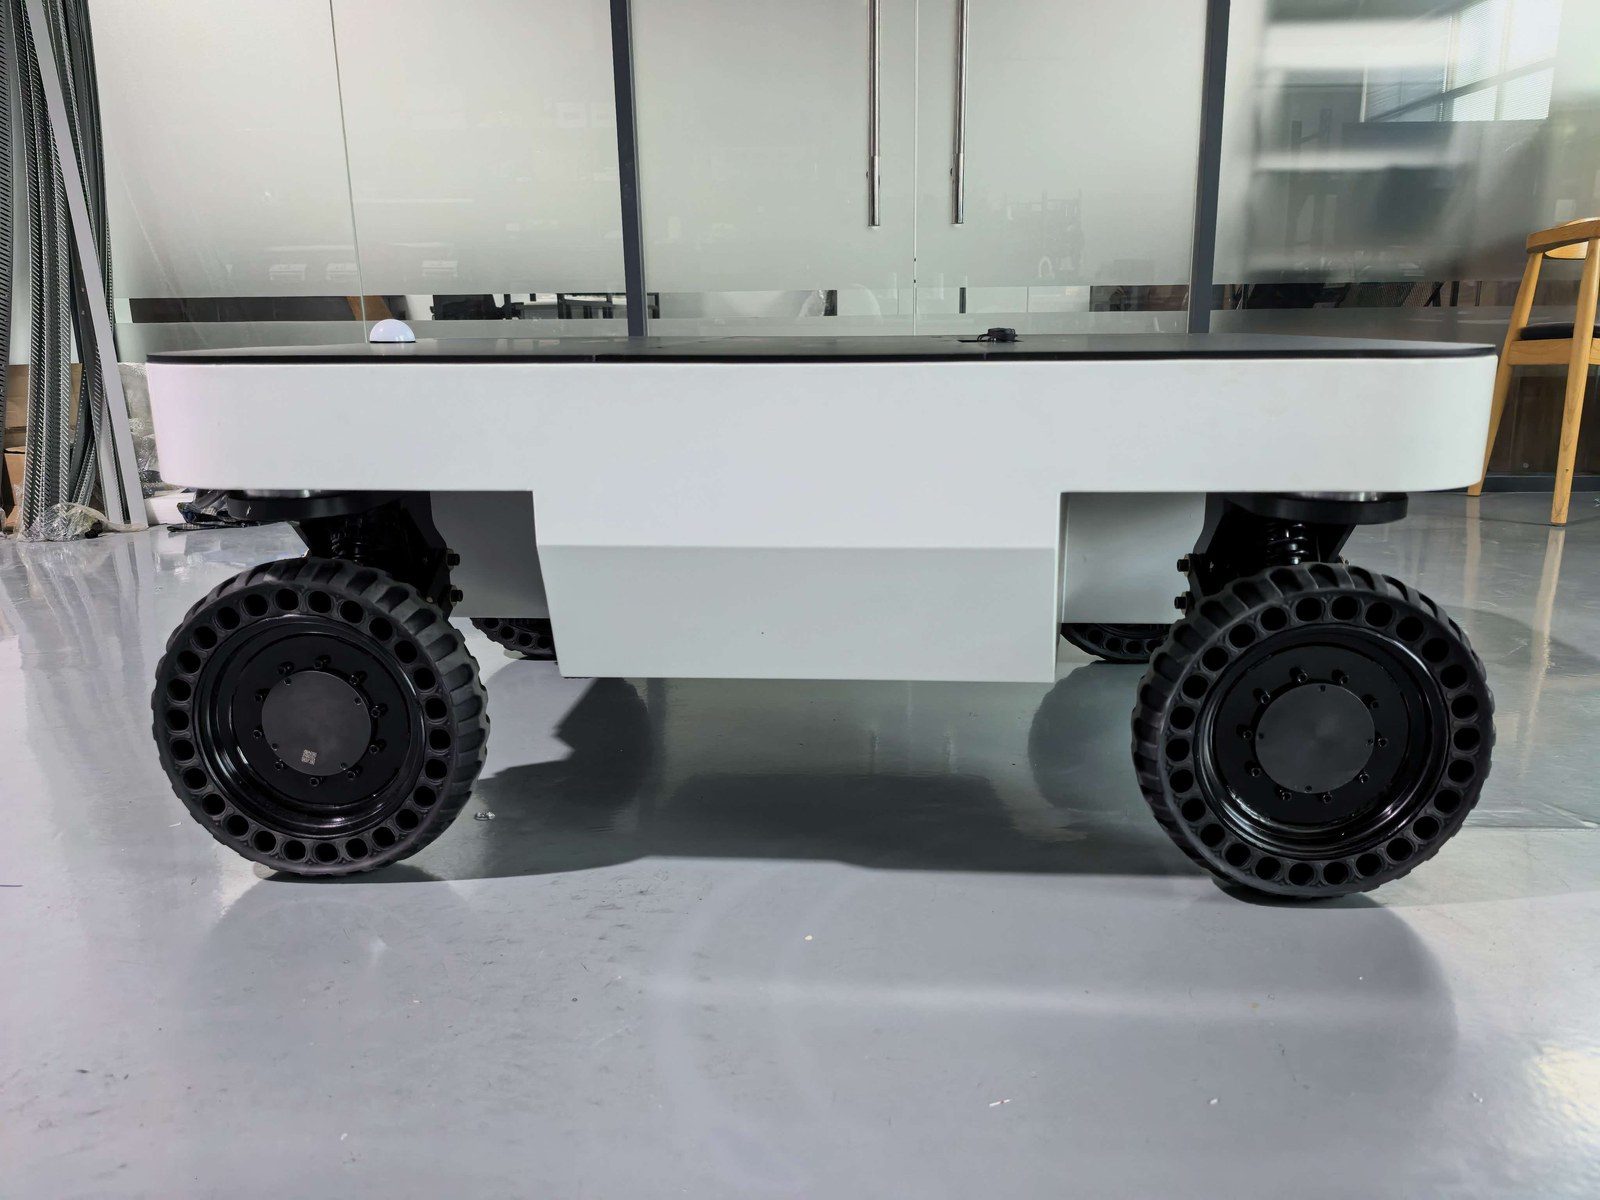
- Parallel independent suspension on all four wheels; 30 degrees gradeability without load, 20 degrees fully loaded
- IP55 protection and -10 C to 55 C operating range for dusty, humid and lightly rainy sites
- 2.0 m/s maximum speed (no load), 4 h battery life, 4 h charging
- CAN bus drive-by-wire plus FlySky RC remote control; Type-C communication interface
- 1 x 48 V 10 A (480 W) and 1 x 24 V 10 A (240 W) external power outputs for sensors and payloads
- 40-series aluminium profiles, emergency stop, battery level indicator and automatic charging electrodes
Six Motion Modes - One Chassis
| Mode | How the chassis moves | Typical use |
| 4W4S (default) | All four wheels drive and steer independently; the chassis translates in any direction without changing heading | Precise docking, narrow working areas |
| Ackermann | Front and rear wheels steer in a car-like pattern | Fast straight-line travel in long corridors |
| Crabbing | Wheels turn 90 degrees and the chassis moves sideways | Sliding into racks or pallets without turning |
| Diagonal | Wheels set at 45 degrees, motion along the diagonal vector | Quick repositioning and aisle entry |
| Spin | Wheels rotate around the chassis centre | Turning in place, 0 mm turning radius |
| Parking | Wheels locked in a braked posture | Stable standing on slopes, safe load transfer |
The motion mode is selected over CAN (command 0x110) or from the remote controller, and the chassis reports the active mode back on 0x220, so a host computer always knows which kinematic model is running.
Independent Parallel Suspension and 30 Degree Gradeability
An all-metal parallel wishbone layout with industrial shock absorbers keeps all four wheels in contact with the ground. On uneven terrain or on a slope, the suspension absorbs height differences so that each wheel keeps maximum traction, while the low centre of gravity and the 421 mm track keep the platform stable under the full 100 kg payload. The TRLU-S4-100K climbs 30 degrees without load and 20 degrees fully loaded, with a 118 mm chassis clearance for obstacles and rough ground.
Technical Specifications
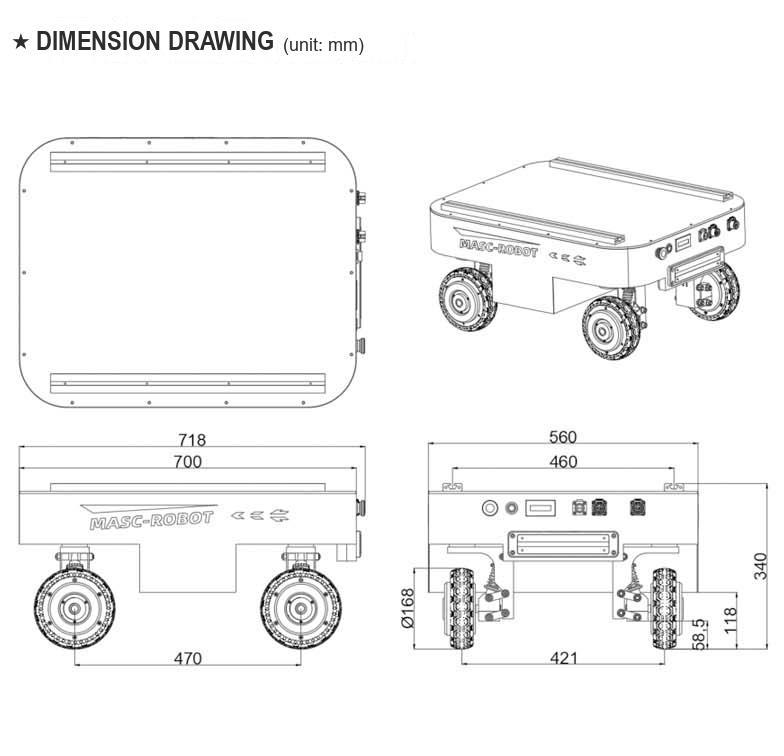
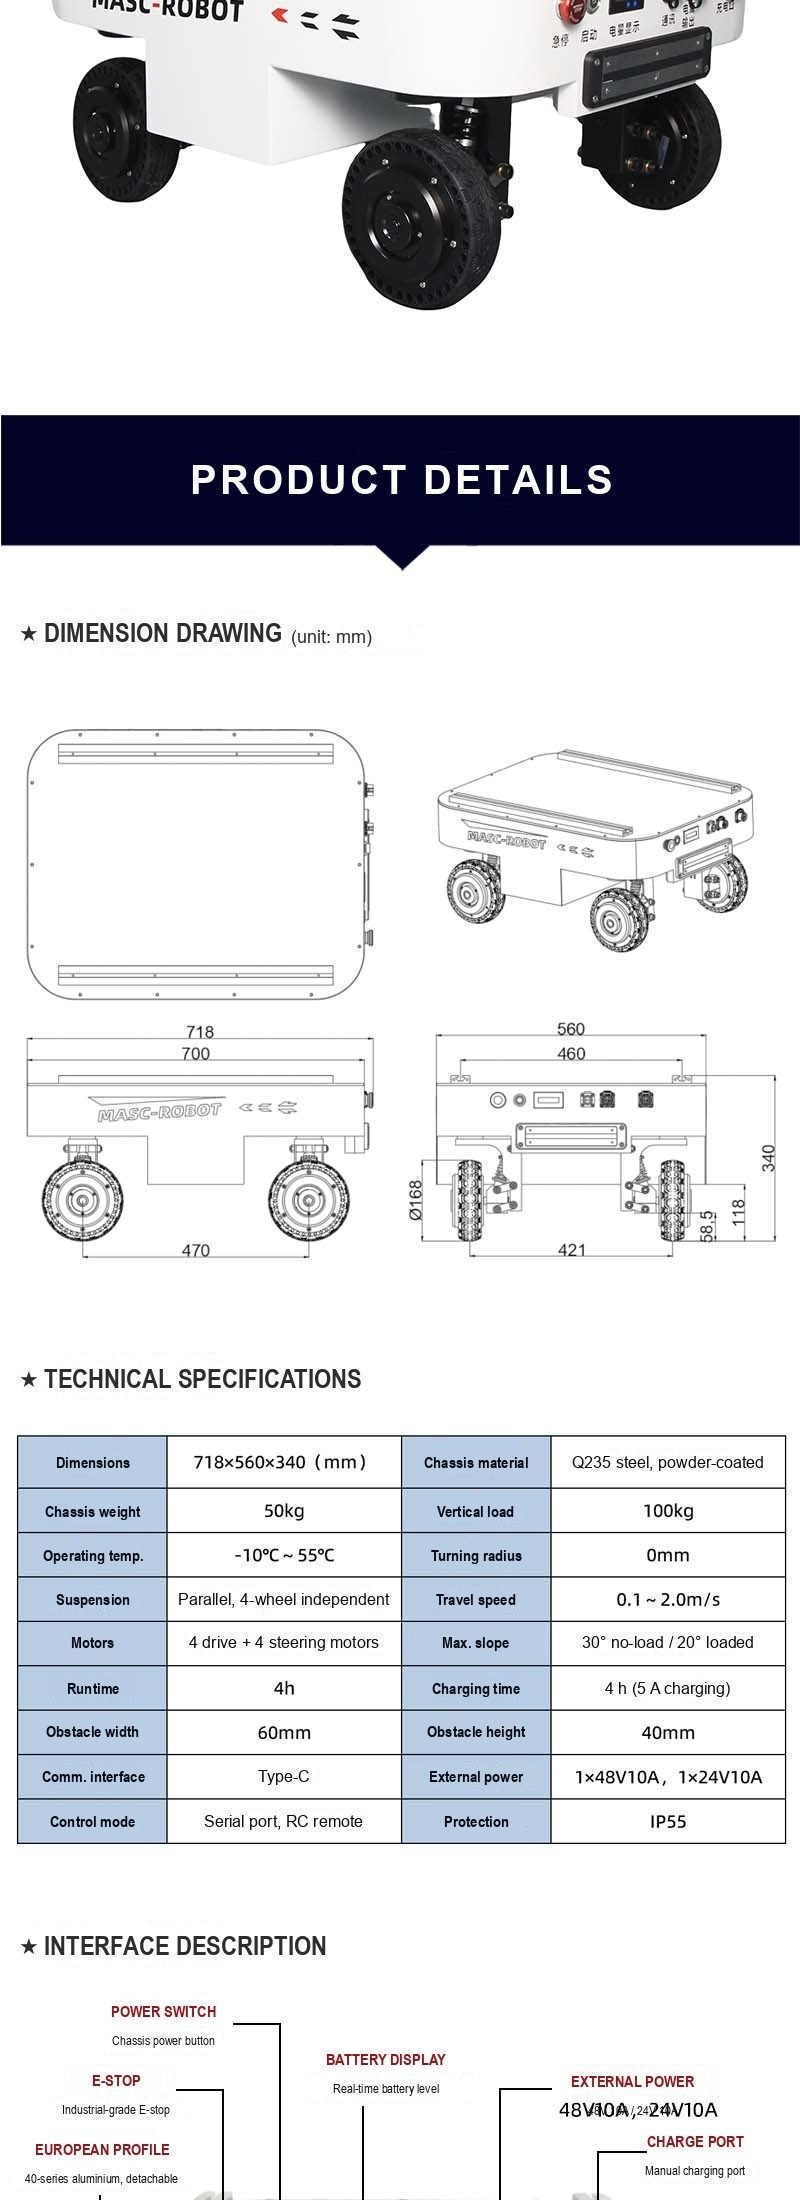
| External dimensions (L x W x H) | 718 x 560 x 340 mm |
| Track width | 421 mm |
| Wheelbase | 470 mm |
| Maximum payload | 100 kg |
| Vehicle weight | 50 kg |
| Drive type | 4-wheel drive, 4-wheel steering (4W4S) |
| Motors | 4 drive + 4 steering servo motors (8 axes) |
| Suspension | Parallel suspension, 4-wheel independent |
| Maximum speed (no load) | 2.0 m/s |
| Minimum turning radius | 0 mm |
| Rotation radius | 420 mm |
| Ground clearance | Suspension 58.5 mm / chassis 118 mm |
| Maximum gradeability | 30 degrees (no load) / 20 degrees (full load) |
| Battery life | 4 h |
| Charging time | 4 h (5 A charger) |
| Protection rating | IP55 |
| Operating temperature | -10 C to 55 C |
| Control mode | FlySky RC remote / CAN bus drive-by-wire |
| Communication | CAN bus (Little-Endian) via Type-C port |
| External power output | 1 x 48 V 10 A (480 W), 1 x 24 V 10 A (240 W) |
| Charging | Manual charger AC 220 V / automatic charging station (optional) |
| Motion modes | 4W4S, Ackermann, crabbing, diagonal, spin, parking |
Dimensions (Unit: mm)
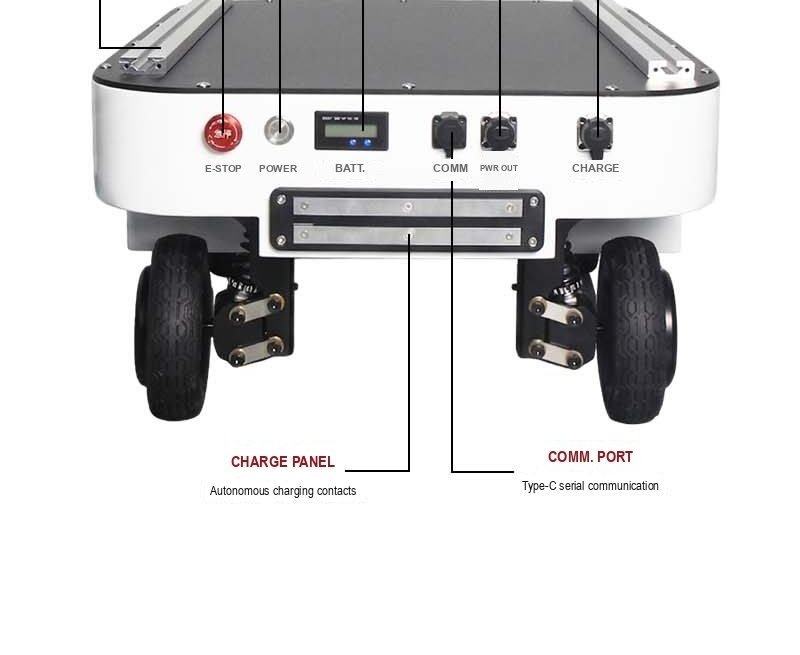
Interfaces and On-Board Power
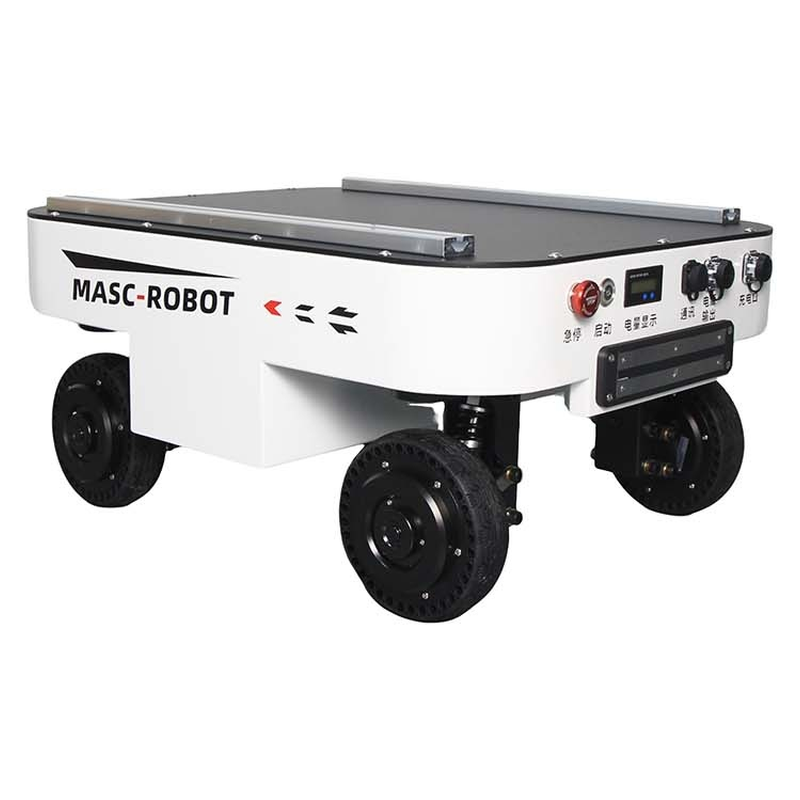
- Emergency stop switch - cuts motor output, industrial-grade push button
- Start switch - chassis main power
- Battery level indicator - real-time state of charge
- Automatic charging electrodes - work with the optional charging station
- Type-C interface - CAN communication and secondary development
- External power output - 1 x 48 V 10 A (480 W), 1 x 24 V 10 A (240 W)
- Manual charging port - AC 220 V dedicated lithium battery charger
CAN Bus Development
The firmware speaks a documented Little-Endian CAN protocol: motion control frame 0x100 at 20 ms (X/Y linear velocity, Z angular velocity, target steering angle), motion feedback 0x200, motion-mode switch 0x110 with feedback on 0x220, system status 0x204, BMS data on 0x206 and 0x207, drive-wheel feedback 0x251-0x258, steering servo feedback 0x271-0x278, IMU 0x300 and RC channels 0x301. A 500 ms receive timeout brings the chassis to a controlled stop, so a host controller only has to publish commands periodically.
What Is in the Box
- 1 x TRLU-S4-100K 4WD 4WS drive-by-wire chassis
- 1 x manual battery charger (AC 220 V)
- 1 x FlySky wireless remote controller
- 1 x automatic charging station (optional)
Application Scenarios
Unmanned inspection in substations, pipe galleries and factory halls; research and teaching platforms for SLAM, navigation and multi-robot collaboration; outdoor material transfer and logistics in energy, construction, agriculture and industrial sites; mobile base for robotic arms and mobile manipulators. The chassis is delivered as a development platform: mounting holes, aluminium profiles, CAN protocol and power outputs are ready for your own sensors and payloads.
Full Specification Sheet
Warranty: 12 months overseas warranty (excluding consumables such as batteries and tyres).
Full Technical Data
| Model | TRLU-S4-100K |
|---|---|
| Payload | 100 kg |
| Dimensions | 718 x 560 x 340 mm |
| Vehicle weight | 50 kg |
| Drive | 4 drive + 4 steering servo motors (8 axes) |
| Six motion modes | 4W4S, Ackermann, crabbing, diagonal, spin, parking |
| Max. speed | 2.0 m/s |
| Turning radius | 0 mm |
| Gradeability | 30 degrees (no load) / 20 degrees (full load) |
| Protection | IP55 |
| Category | Mobile Robots & AMR |
| Lead time | 15-30 days |
Values are nominal at 20 °C. Download the datasheet for cad models, torque curves and controller I/O maps.
Where It Runs
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Buyer Questions
What are the key specifications?
Model: TRLU-S4-100K, Payload: 100 kg, Dimensions: 718 x 560 x 340 mm.
What is the lead time?
15-30 days for the standard configuration; confirmed at quotation.
Can it be customised?
Yes — OEM/ODM options, voltage, tooling and branding can be adapted. Send the application and target output for a proposal.
Get a Priced Proposal for TRLU-S4-100K
Include the part, target rate and destination port. An engineer — not a chatbot — replies within 48 hours.
Same Category
300 kg CTU Mobile Robot for Rack Handling
30 T Heavy-Load AMR Platform
2 T Autonomous Forklift AMR
Reviewed by TROY Engineering · . Specifications are re-checked against the supplier datasheet at every quotation.