


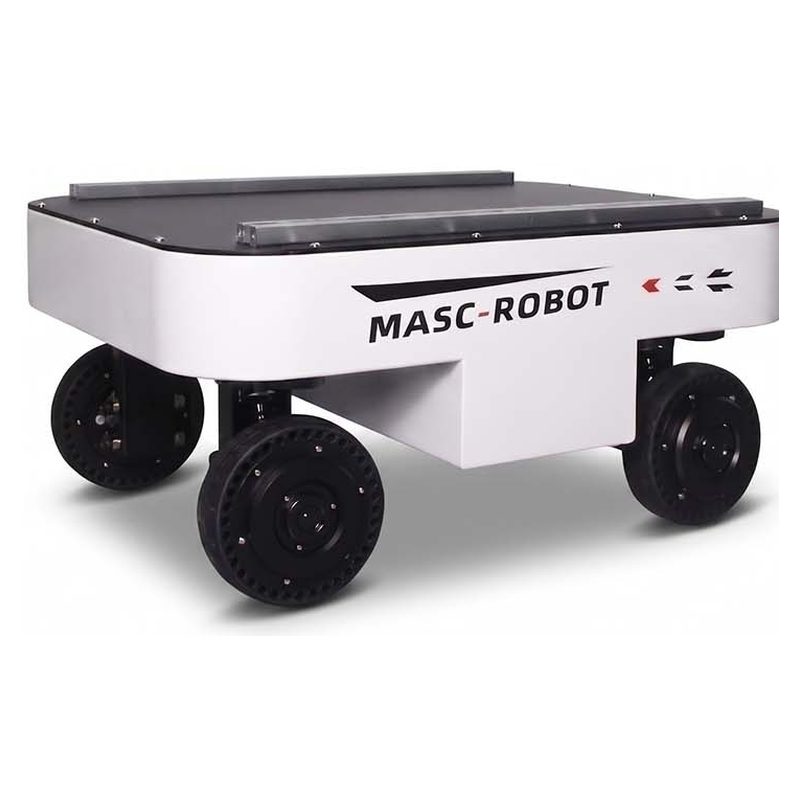
4WD 4WS 오프로드 모바일 로봇 섀시 TRLU-S4-100K
TRLU-S4-100K는 내부물류/창고운송을 위한 이동로봇입니다. 주요 사양: 탑재량 100kg; 크기 718 x 560 x 340mm; 차량 중량 50kg. 리드타임은 15-30일입니다. 가격은 구성별로 제시됩니다. 인증: 요청 시 CE 문서.
- 모델
- TRLU-S4-100K
- 유효 탑재량
- 100 kg
- 치수
- 718 x 560 x 340 mm
- 차량 중량
- 50 kg
- 운전하다
- 드라이브 4개 + 조향 서보 모터 4개(8축)
- 6가지 모션 모드
- 4W4S, Ackermann, 크랩빙, 대각선, 스핀, 주차
이 플랫폼의 용도
TRLU-S4-100K는 8개의 독립적인 서보 모터, 6개의 모션 모드, 0mm 회전 반경, 30도 등판 능력 및 IP55 보호 기능을 갖춘 100kg 페이로드 4WD 4WS 드라이브 바이 와이어 로봇 섀시입니다. LiDAR, RTK 및 SLAM 개발을 위한 CAN 버스 및 RC 제어가 가능합니다.
상업적 용어
| 인용 | 구성당 가격 책정 — 48시간 이내에 답변 |
|---|---|
| 리드타임 | 15-30 days |
| MOQ | 1개 단위 |
| 기원 | 중국 |
| 선적항 | 중국 선전 |
| 인코텀즈 | 요청 시 FOB 심천/CIF |
| 지불 | 보증금 30%, 배송 전 70% |
| 보증 | 24개월은 기본, 36개월은 선택 가능 |
제품 세부정보
TROY 엔지니어링 파일의 애플리케이션 노트, 시공 도면 및 비디오 — 견적과 함께 제공되는 동일한 문서입니다.
Compact 4WD 4WS Drive-by-Wire Chassis for Off-Road AMR Development
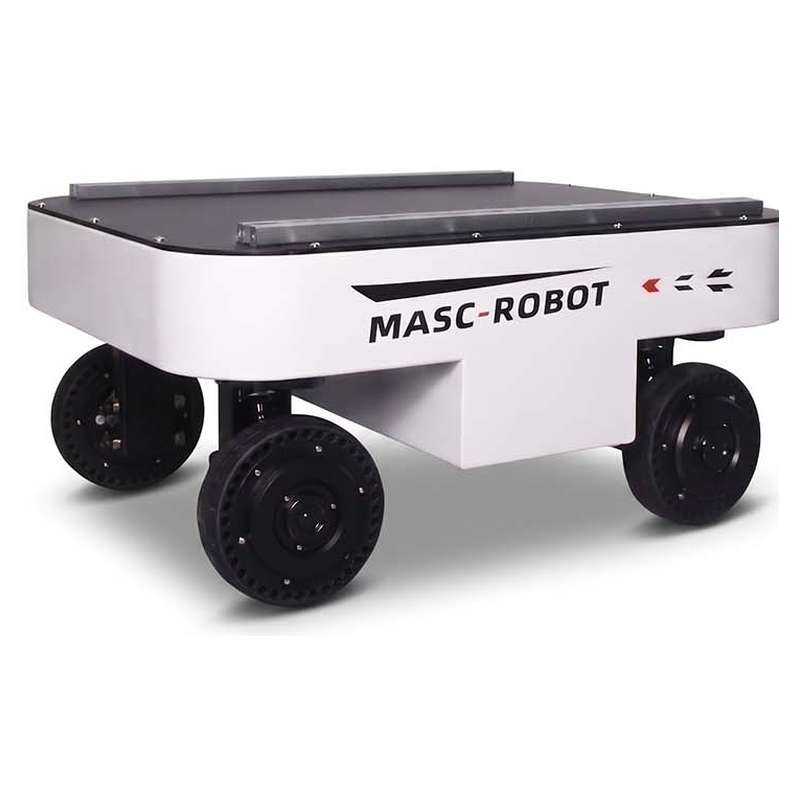
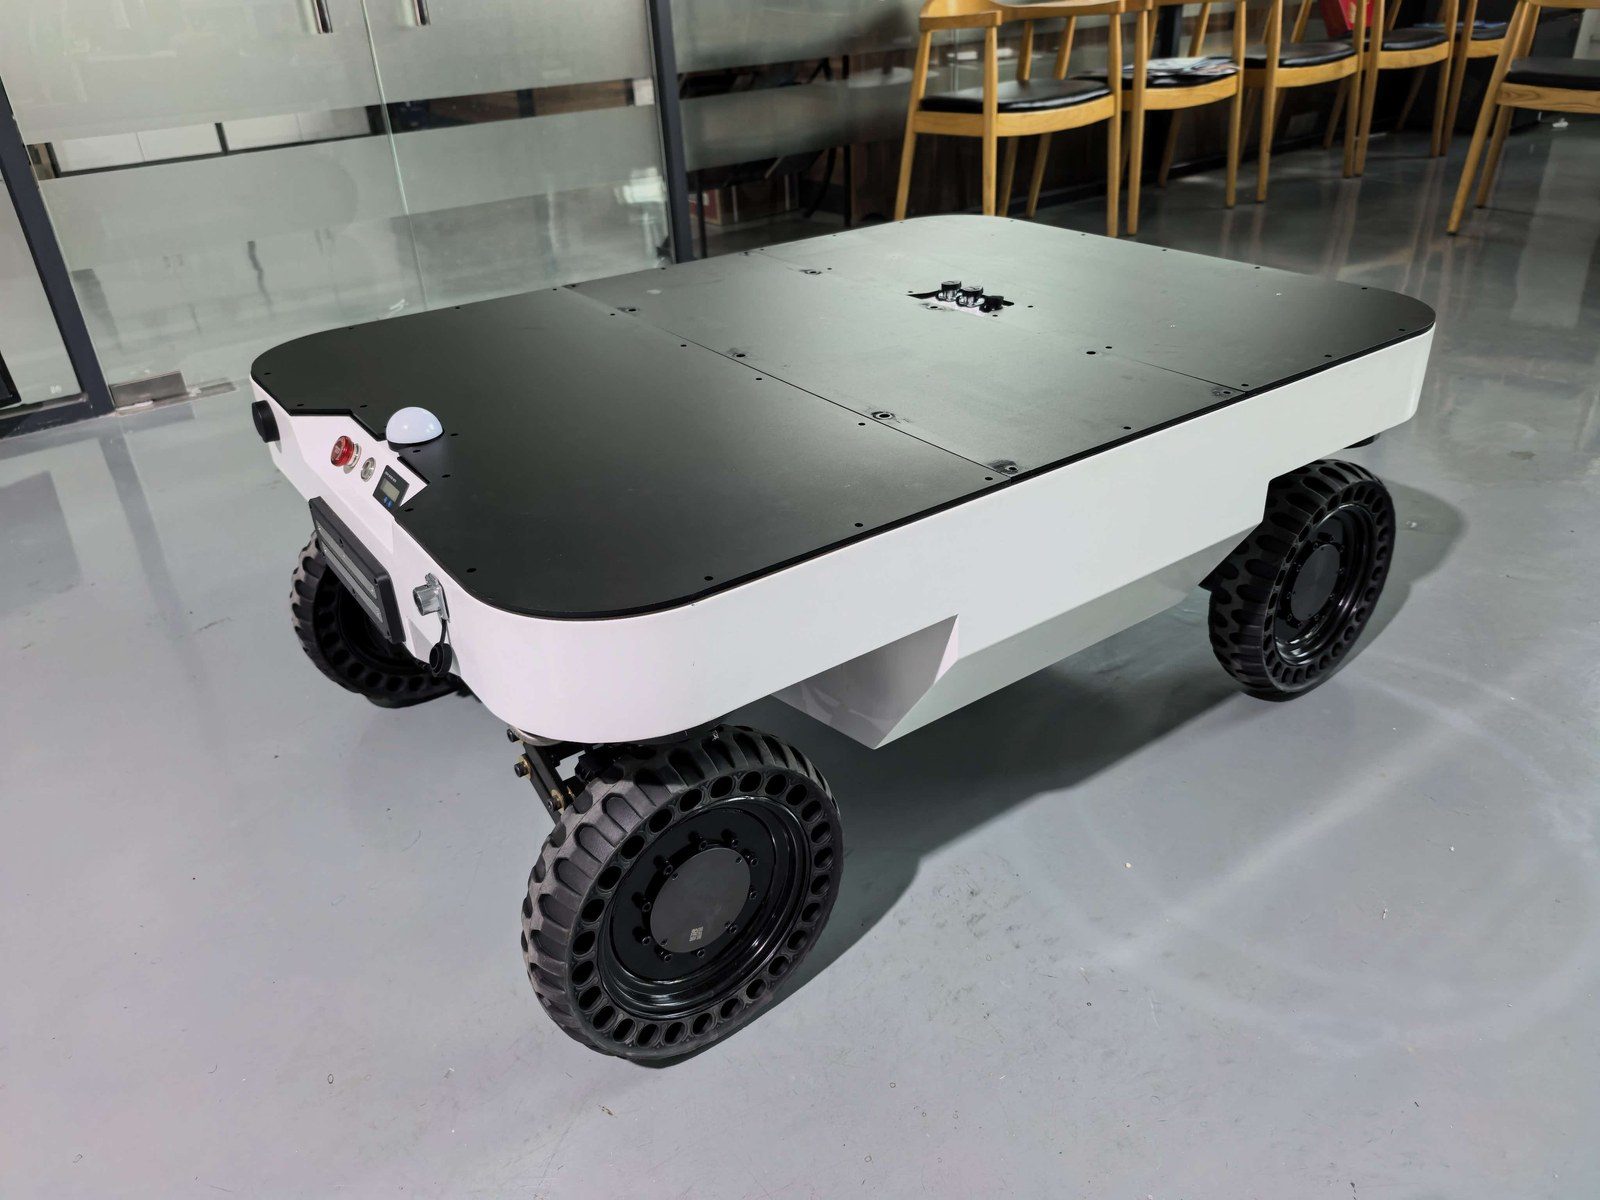
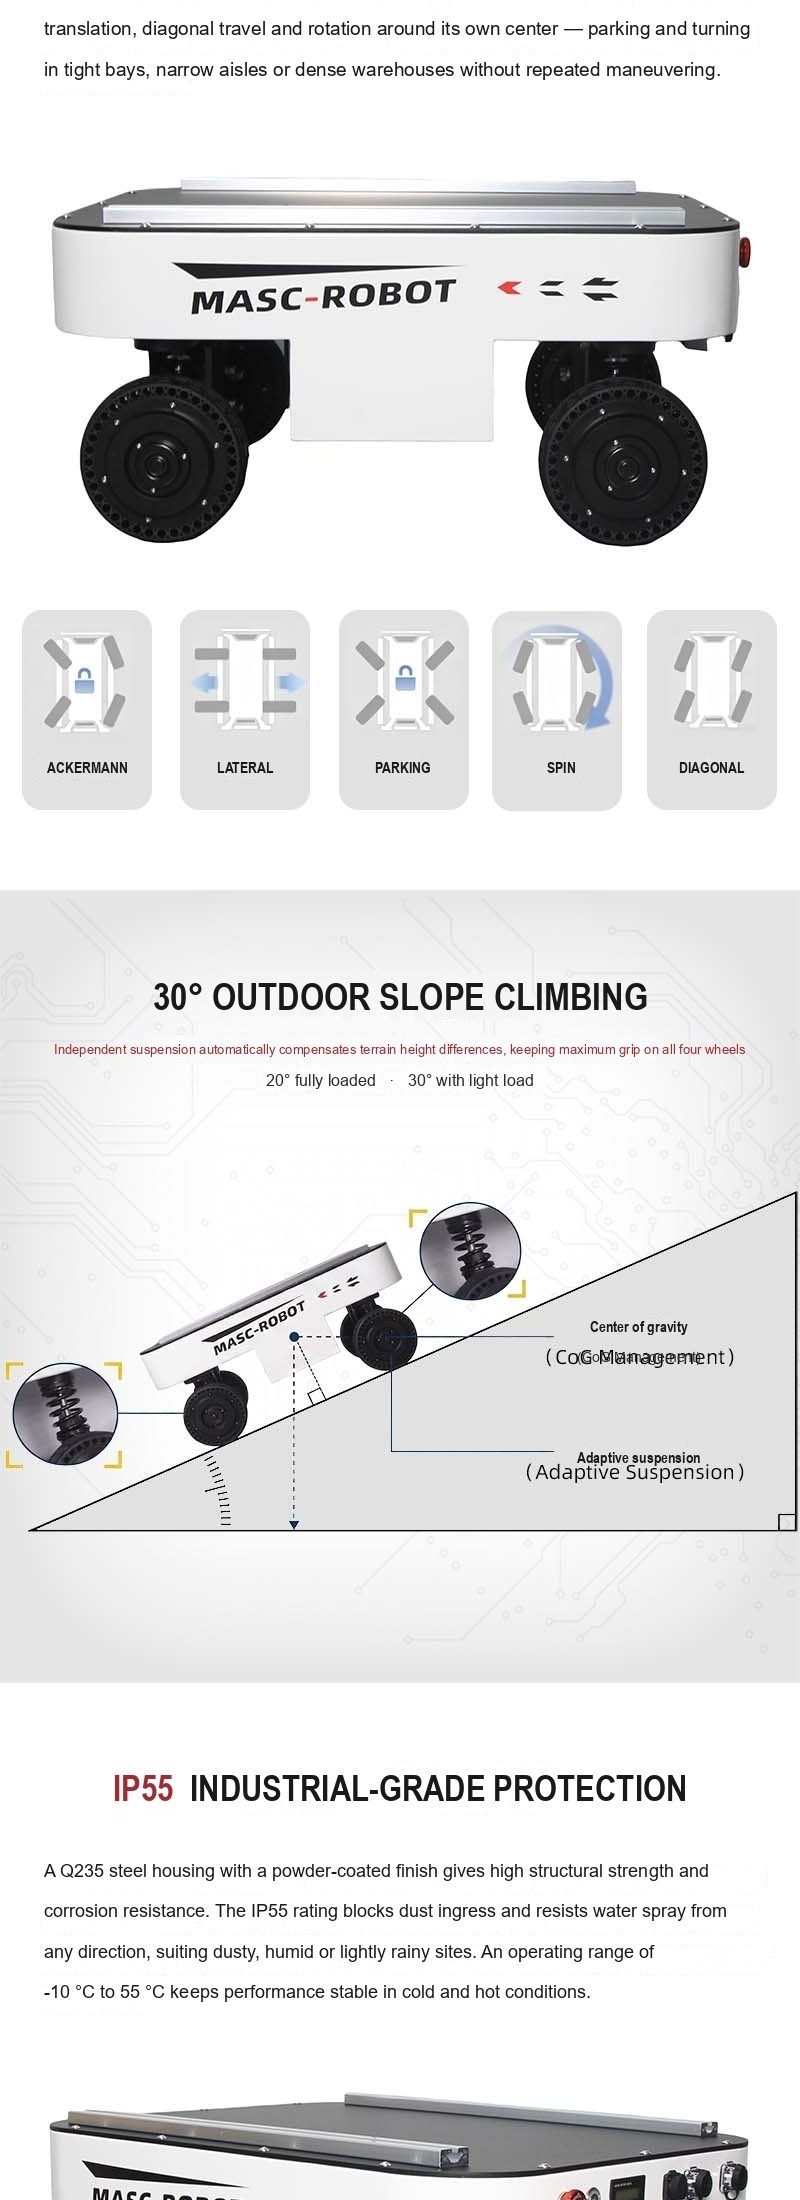
The TRLU-S4-100K is a compact four-wheel-drive, four-wheel-steering mobile robot chassis built for developers who need a reliable moving platform. Each of its four wheels carries its own drive motor and steering motor, giving eight independent servo axes: the chassis can travel forward, sideways and diagonally, and rotate on the spot around its own centre. With a 100 kg payload, a 718 x 560 x 340 mm footprint and 58.5 mm of suspension clearance, it works as comfortably in narrow corridors and pipe racks as it does on uneven outdoor ground.
Mount a LiDAR, depth camera, RTK module, IMU or industrial PC on the two pre-installed 40-series European aluminium profiles and the TRLU-S4-100K becomes an unmanned inspection robot, a research and teaching platform, or an outdoor logistics carrier. Control it with the supplied FlySky remote controller, or drive it from your own host computer through the Type-C CAN bus and the documented little-endian protocol.
Key Features
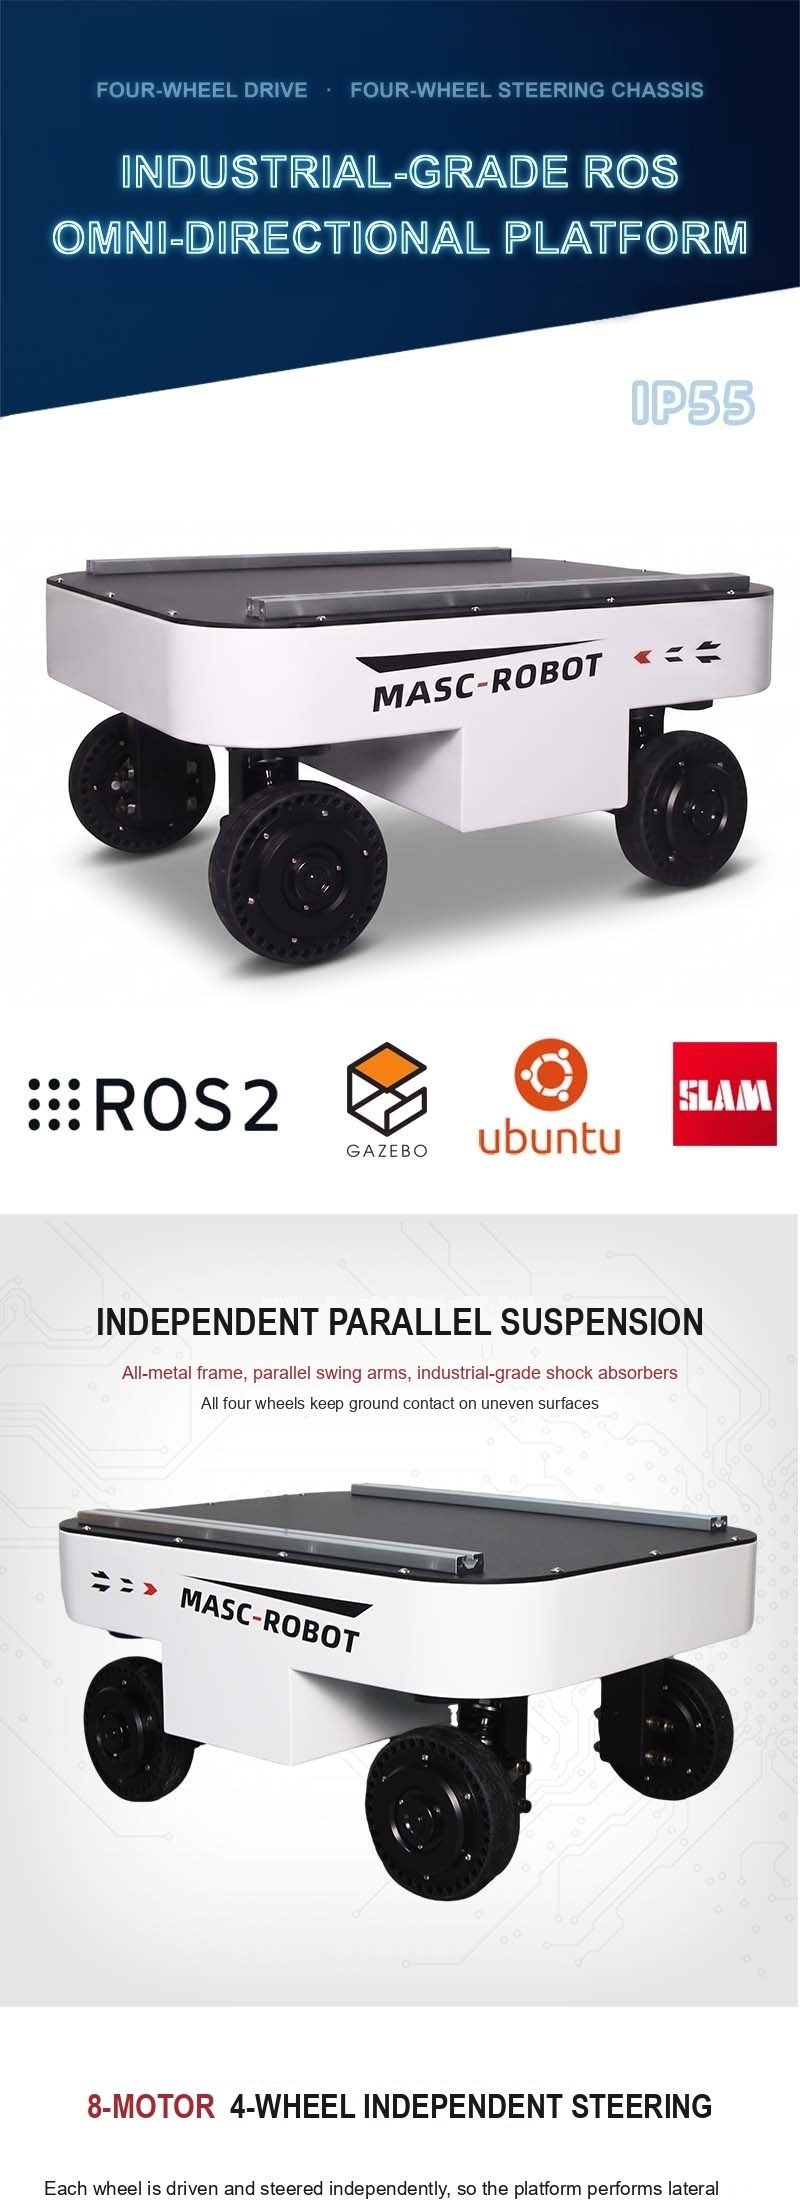
- 8-motor 4WD 4WS layout: 4 drive motors + 4 steering servo motors, independently controlled per wheel
- Six motion modes: 4W4S, front/rear Ackermann, crabbing (lateral), diagonal, spin and parking
- 0mm 최소 회전 반경 및 420mm 회전 반경 - 자체 설치 공간 내에서 회전
- 차량 중량 50kg에 탑재량 100kg, 트랙이 421mm 넓어짐
- Parallel independent suspension on all four wheels; 30 degrees gradeability without load, 20 degrees fully loaded
- IP55 보호 및 -10C~55C 작동 범위 - 먼지가 많고 습하며 약간 비가 오는 장소
- 2.0 m/s maximum speed (no load), 4 h battery life, 4 h charging
- CAN 버스 드라이브 바이 와이어 및 FlySky RC 원격 제어; Type-C 통신 인터페이스
- 센서 및 페이로드용 48V 10A(480W) 1개 및 24V 10A(240W) 외부 전원 출력 1개
- 40-series aluminium profiles, emergency stop, battery level indicator and automatic charging electrodes
Six Motion Modes - One Chassis
| Mode | How the chassis moves | Typical use |
| 4W4S (default) | 네 바퀴 모두 독립적으로 구동 및 조향됩니다. 섀시는 방향을 바꾸지 않고 어떤 방향으로든 이동합니다. | Precise docking, narrow working areas |
| Ackermann | 앞바퀴와 뒷바퀴가 자동차와 같은 패턴으로 조종됩니다. | Fast straight-line travel in long corridors |
| Crabbing | 바퀴가 90도 회전하고 섀시가 옆으로 움직입니다. | Sliding into racks or pallets without turning |
| Diagonal | 45도로 설정된 바퀴, 대각선 벡터를 따라 움직이는 바퀴 | Quick repositioning and aisle entry |
| Spin | Wheels rotate around the chassis centre | Turning in place, 0 mm turning radius |
| Parking | 브레이크가 걸린 상태에서 바퀴가 잠김 | Stable standing on slopes, safe load transfer |
모션 모드는 CAN(명령 0x110) 또는 조종기에서 선택되며 섀시는 0x220에서 활성 모드를 다시 보고하므로 호스트 컴퓨터는 항상 어떤 운동 모델이 실행되고 있는지 알 수 있습니다.
Independent Parallel Suspension and 30 Degree Gradeability
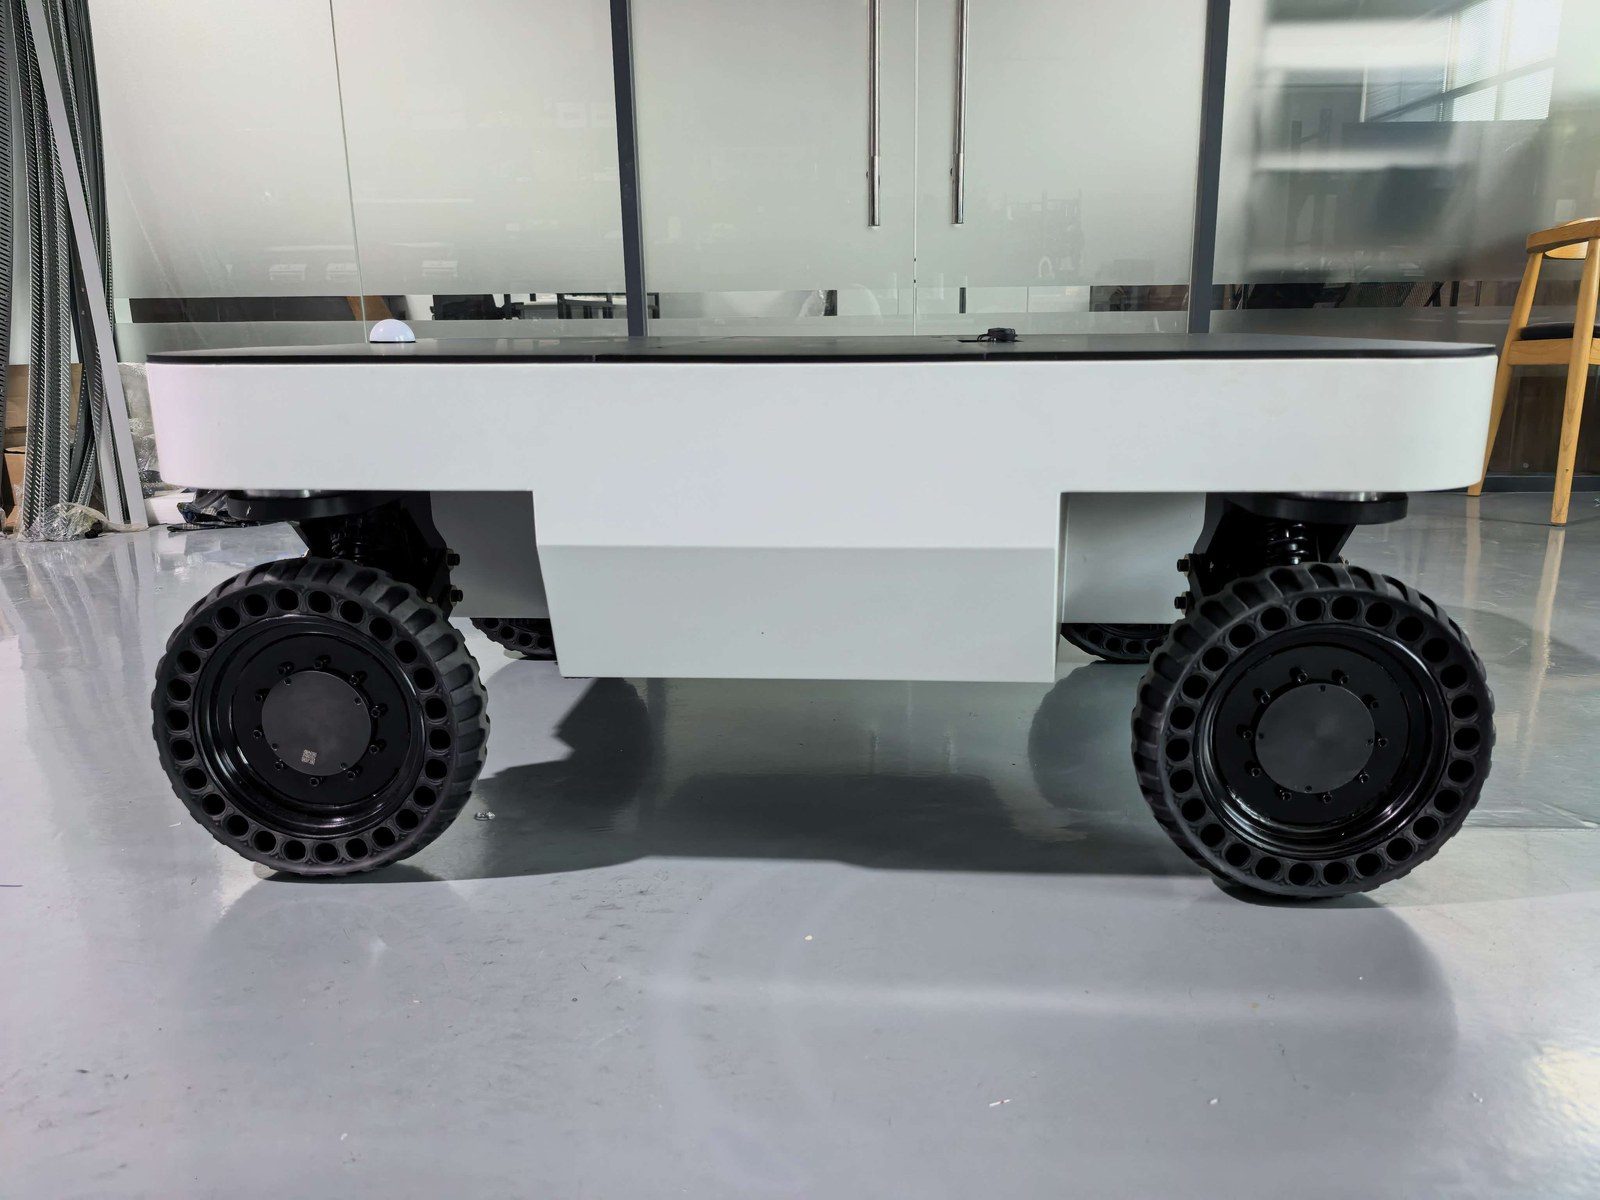
An all-metal parallel wishbone layout with industrial shock absorbers keeps all four wheels in contact with the ground. On uneven terrain or on a slope, the suspension absorbs height differences so that each wheel keeps maximum traction, while the low centre of gravity and the 421 mm track keep the platform stable under the full 100 kg payload. The TRLU-S4-100K climbs 30 degrees without load and 20 degrees fully loaded, with a 118 mm chassis clearance for obstacles and rough ground.
Technical Specifications
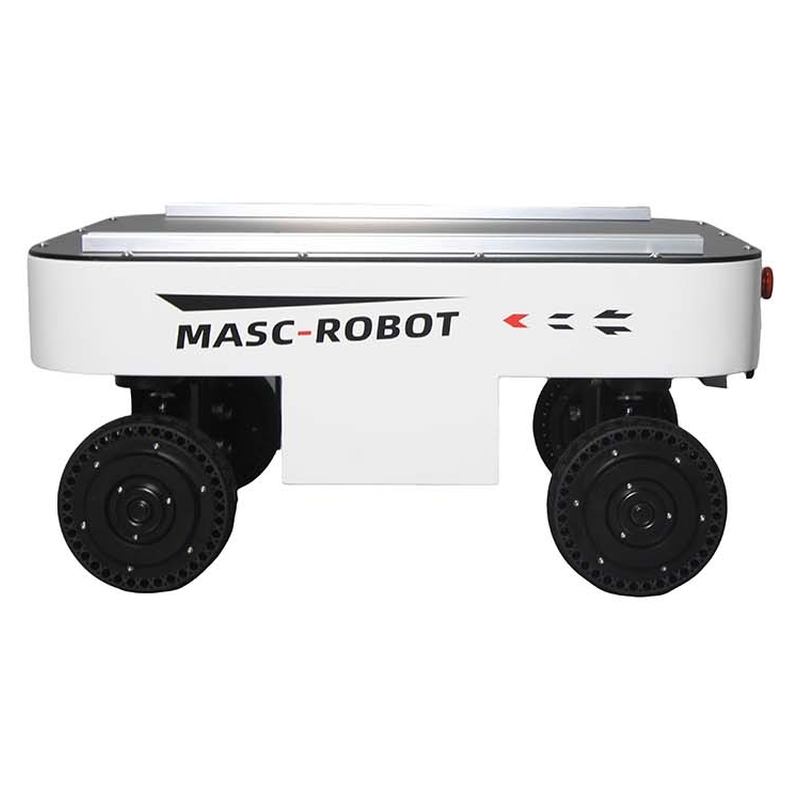
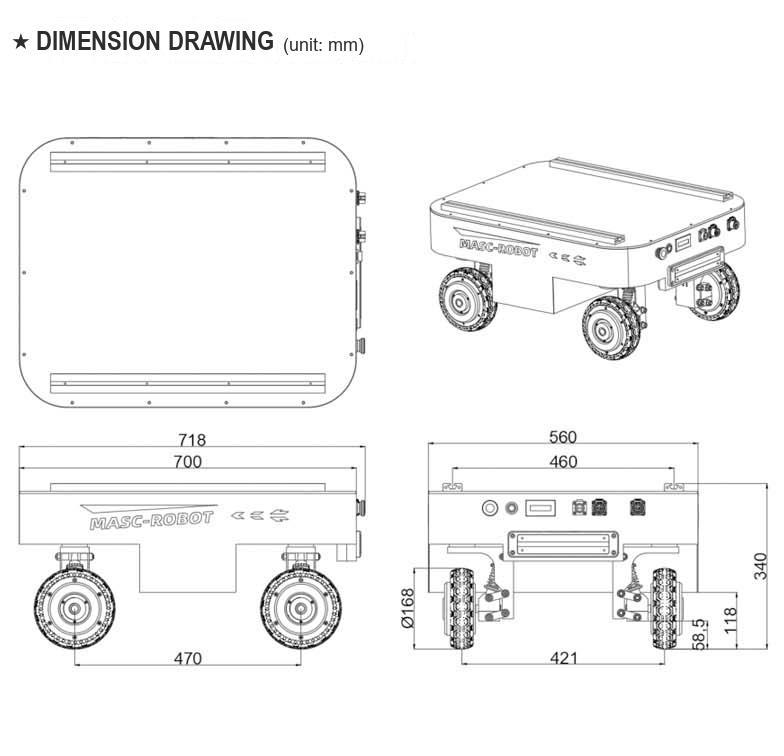
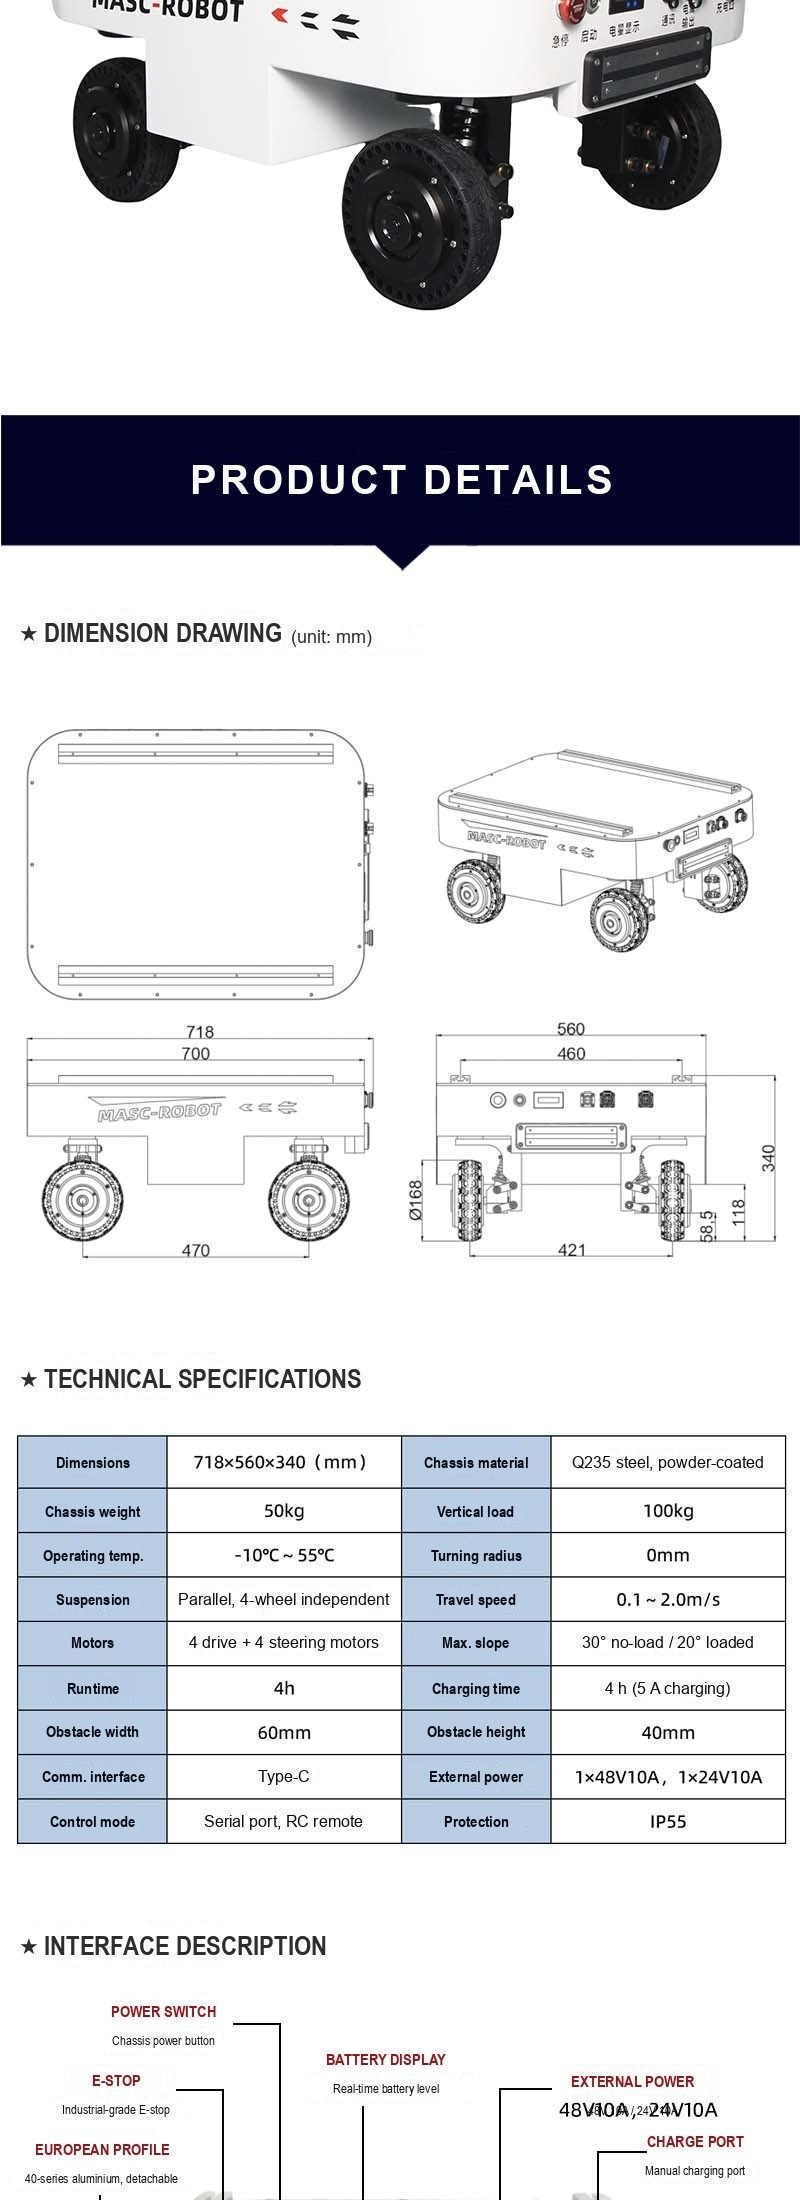
| External dimensions (L x W x H) | 718 x 560 x 340 mm |
| Track width | 421 mm |
| Wheelbase | 470 mm |
| Maximum payload | 100 kg |
| 차량 중량 | 50 kg |
| Drive type | 4-wheel drive, 4-wheel steering (4W4S) |
| Motors | 드라이브 4개 + 조향 서보 모터 4개(8축) |
| 보류 | Parallel suspension, 4-wheel independent |
| Maximum speed (no load) | 2.0 m/s |
| Minimum turning radius | 0 mm |
| Rotation radius | 420 mm |
| Ground clearance | Suspension 58.5 mm / chassis 118 mm |
| Maximum gradeability | 30도(무부하시) / 20도(풀로드) |
| 배터리 수명 | 4 h |
| 충전시간 | 4 h (5 A charger) |
| Protection rating | IP55 |
| 작동 온도 | -10 C to 55 C |
| Control mode | FlySky RC 원격/CAN 버스 드라이브 바이 와이어 |
| Communication | CAN bus (Little-Endian) via Type-C port |
| External power output | 48V 10A(480W) 1개, 24V 10A(240W) 1개 |
| 충전 중 | Manual charger AC 220 V / automatic charging station (optional) |
| Motion modes | 4W4S, Ackermann, 크랩빙, 대각선, 스핀, 주차 |
Dimensions (unit: mm)
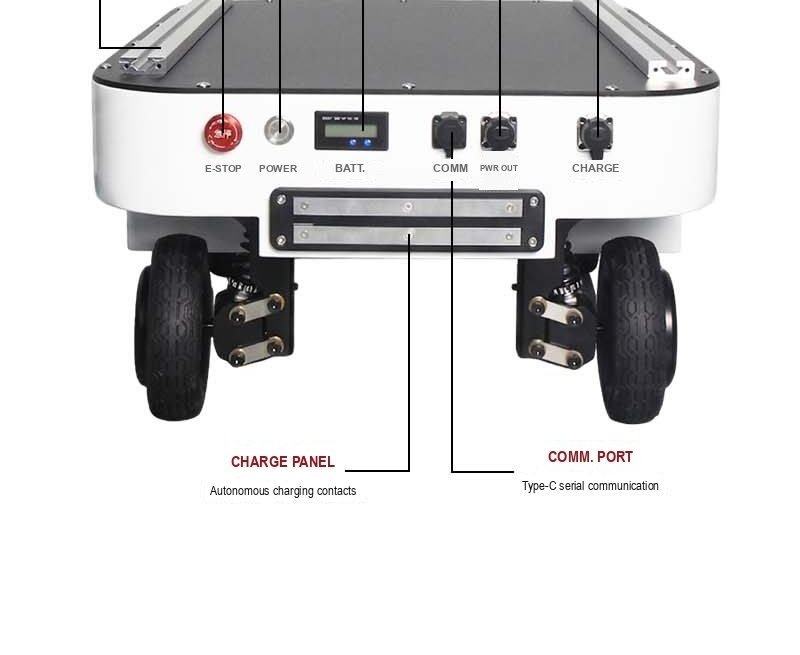
인터페이스 및 온보드 전원
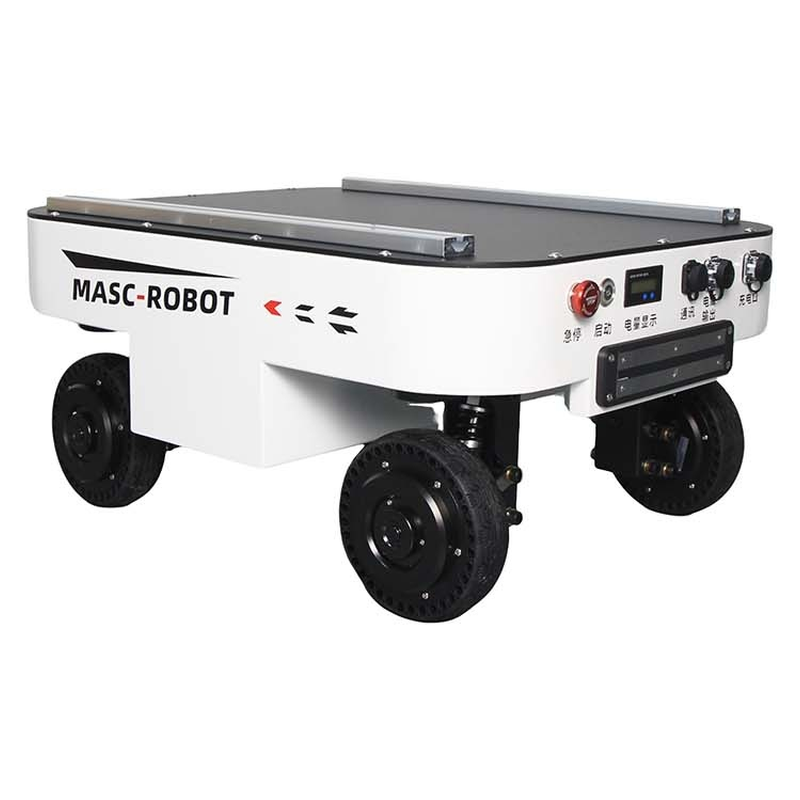
- Emergency stop switch - cuts motor output, industrial-grade push button
- Start switch - chassis main power
- Battery level indicator - real-time state of charge
- 자동 충전 전극 - 옵션 충전 스테이션과 함께 작동
- Type-C 인터페이스 - CAN 통신 및 2차 개발
- 외부 전원 출력 - 1 x 48V 10A(480W), 1 x 24V 10A(240W)
- Manual charging port - AC 220 V dedicated lithium battery charger
CAN Bus Development
The firmware speaks a documented Little-Endian CAN protocol: motion control frame 0x100 at 20 ms (X/Y linear velocity, Z angular velocity, target steering angle), motion feedback 0x200, motion-mode switch 0x110 with feedback on 0x220, system status 0x204, BMS data on 0x206 and 0x207, drive-wheel feedback 0x251-0x258, steering servo feedback 0x271-0x278, IMU 0x300 and RC channels 0x301. A 500 ms receive timeout brings the chassis to a controlled stop, so a host controller only has to publish commands periodically.
What is in the Box
- 1 x TRLU-S4-100K 4WD 4WS drive-by-wire chassis
- 1 x manual battery charger (AC 220 V)
- 1 x FlySky wireless remote controller
- 1 x automatic charging station (optional)
Application Scenarios
Unmanned inspection in substations, pipe galleries and factory halls; research and teaching platforms for SLAM, navigation and multi-robot collaboration; outdoor material transfer and logistics in energy, construction, agriculture and industrial sites; mobile base for robotic arms and mobile manipulators. The chassis is delivered as a development platform: mounting holes, aluminium profiles, CAN protocol and power outputs are ready for your own sensors and payloads.
Full Specification Sheet
보증기간 : 12개월 해외보증 (배터리, 타이어 등 소모품 제외)
전체 기술 데이터
| 모델 | TRLU-S4-100K |
|---|---|
| 유효 탑재량 | 100 kg |
| 치수 | 718 x 560 x 340 mm |
| 차량 중량 | 50 kg |
| 운전하다 | 드라이브 4개 + 조향 서보 모터 4개(8축) |
| 6가지 모션 모드 | 4W4S, Ackermann, 크랩빙, 대각선, 스핀, 주차 |
| 최대. 속도 | 2.0 m/s |
| 회전 반경 | 0 mm |
| 등판 능력 | 30도(무부하시) / 20도(풀로드) |
| 보호 | IP55 |
| 범주 | 모바일 로봇 및 AMR |
| 리드타임 | 15-30 days |
값은 20°C에서의 공칭값입니다. CAD 모델, 토크 곡선 및 컨트롤러 I/O 맵에 대한 데이터시트를 다운로드하세요.
실행되는 곳
TROY 엔지니어가 크기를 조정하고 의뢰했습니다.
TROY 엔지니어가 크기를 조정하고 의뢰했습니다.
TROY 엔지니어가 크기를 조정하고 의뢰했습니다.
TROY 엔지니어가 크기를 조정하고 의뢰했습니다.
구매자 질문
주요 사양은 무엇입니까?
모델: TRLU-S4-100K, 탑재량: 100kg, 크기: 718 x 560 x 340mm.
리드타임은 무엇입니까?
표준 구성의 경우 15-30일; 견적으로 확인되었습니다.
맞춤 설정할 수 있나요?
예 - OEM/ODM 옵션, 전압, 툴링 및 브랜딩을 조정할 수 있습니다. 제안서에 대한 응용 프로그램 및 대상 출력을 보냅니다.
TRLU-S4-100K에 대한 가격 제안 받기
부품, 목표 속도 및 대상 포트를 포함합니다. 챗봇이 아닌 엔지니어가 48시간 이내에 답변합니다.
같은 카테고리
검토자: TROY 엔지니어링 ·. 사양은 견적이 나올 때마다 공급업체 데이터시트를 기준으로 다시 확인됩니다.