


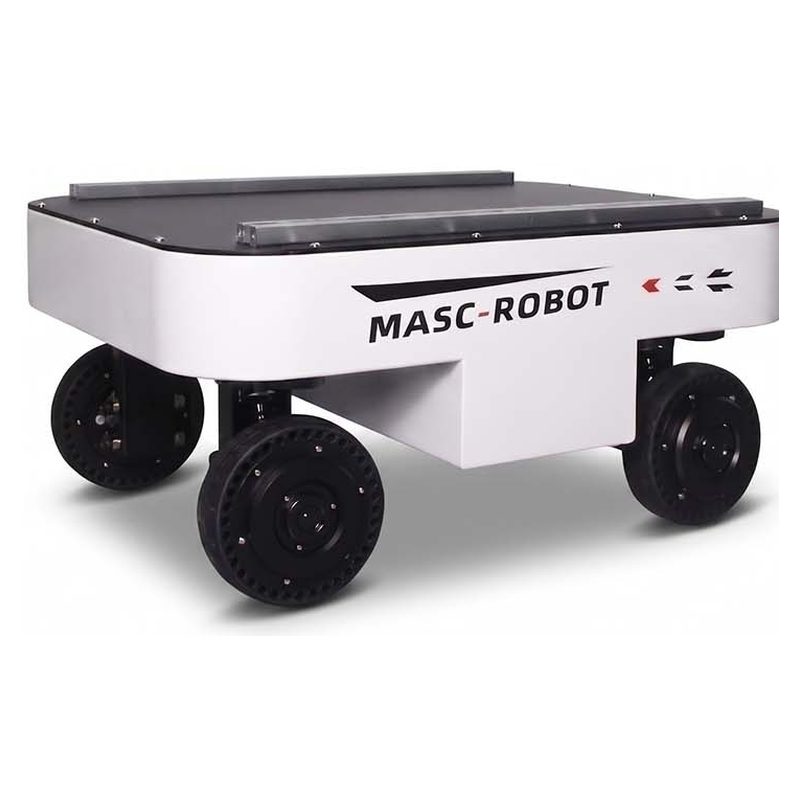
4WD 4WS Offroad-Mobilroboter-Chassis TRLU-S4-100K
Der TRLU-S4-100K ist ein mobiler Roboter für die innerbetriebliche Logistik / Lagertransporte. Wichtige Spezifikationen: Nutzlast 100 kg; Abmessungen 718 x 560 x 340 mm; Fahrzeuggewicht 50 kg. Die Vorlaufzeit beträgt 15–30 Tage; Die Preise werden pro Konfiguration angegeben. Zertifizierungen: CE-Dokumentation auf Anfrage.
- Modell
- TRLU-S4-100K
- Nutzlast
- 100 kg
- Abmessungen
- 718 x 560 x 340 mm
- Fahrzeuggewicht
- 50 kg
- Fahren
- 4 Antriebs- + 4 Lenkservomotoren (8 Achsen)
- Sechs Bewegungsmodi
- 4W4S, Ackermann, Krabbeln, Diagonalfahren, Drehen, Parken
Wofür diese Plattform gedacht ist
TRLU-S4-100K ist ein 100 kg Nutzlast 4WD 4WS Drive-by-Wire-Roboterchassis mit 8 unabhängigen Servomotoren, sechs Bewegungsmodi, 0 mm Wenderadius, 30 Grad Steigfähigkeit und IP55-Schutz. CAN-Bus- und RC-Steuerung, bereit für die LiDAR-, RTK- und SLAM-Entwicklung.
Handelsbedingungen
| Angebot | Preis pro Konfiguration – Antwort innerhalb von 48 Stunden |
|---|---|
| Vorlaufzeit | 15-30 days |
| Mindestbestellmenge | 1 Einheit |
| Herkunft | China |
| Verladehafen | Shenzhen, China |
| Incoterm | FOB Shenzhen / CIF auf Anfrage |
| Zahlung | 30 % Anzahlung, 70 % vor Versand |
| Garantie | 24 Monate Standard, 36 Monate optional |
Produktdetails
Anwendungshinweise, Konstruktionszeichnungen und Videos aus der TROY-Konstruktionsdatei – dieselbe Dokumentation, die mit dem Angebot geliefert wurde.
Compact 4WD 4WS Drive-by-Wire Chassis for Off-Road AMR Development
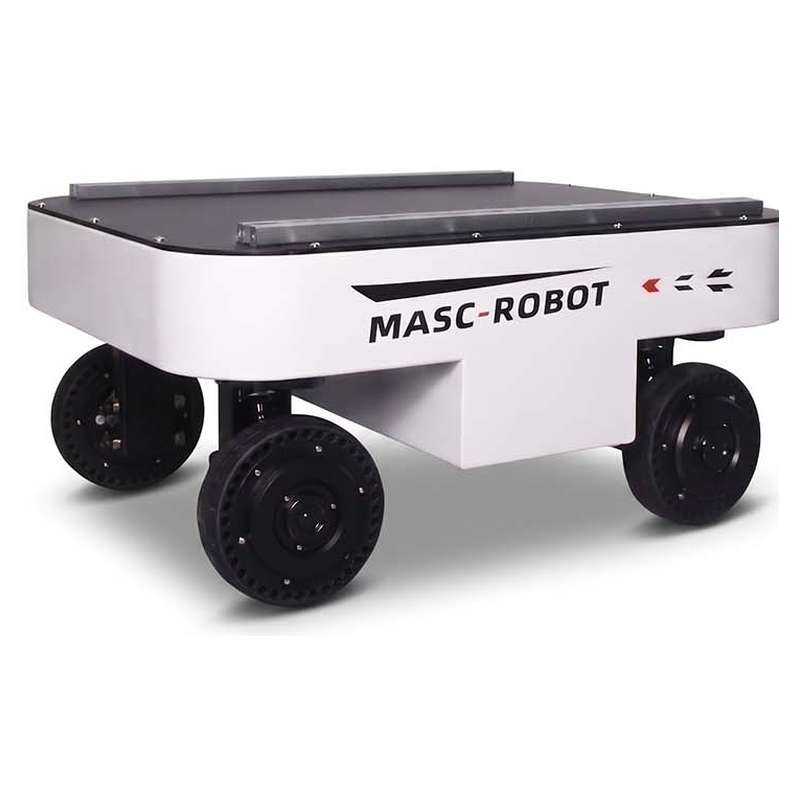
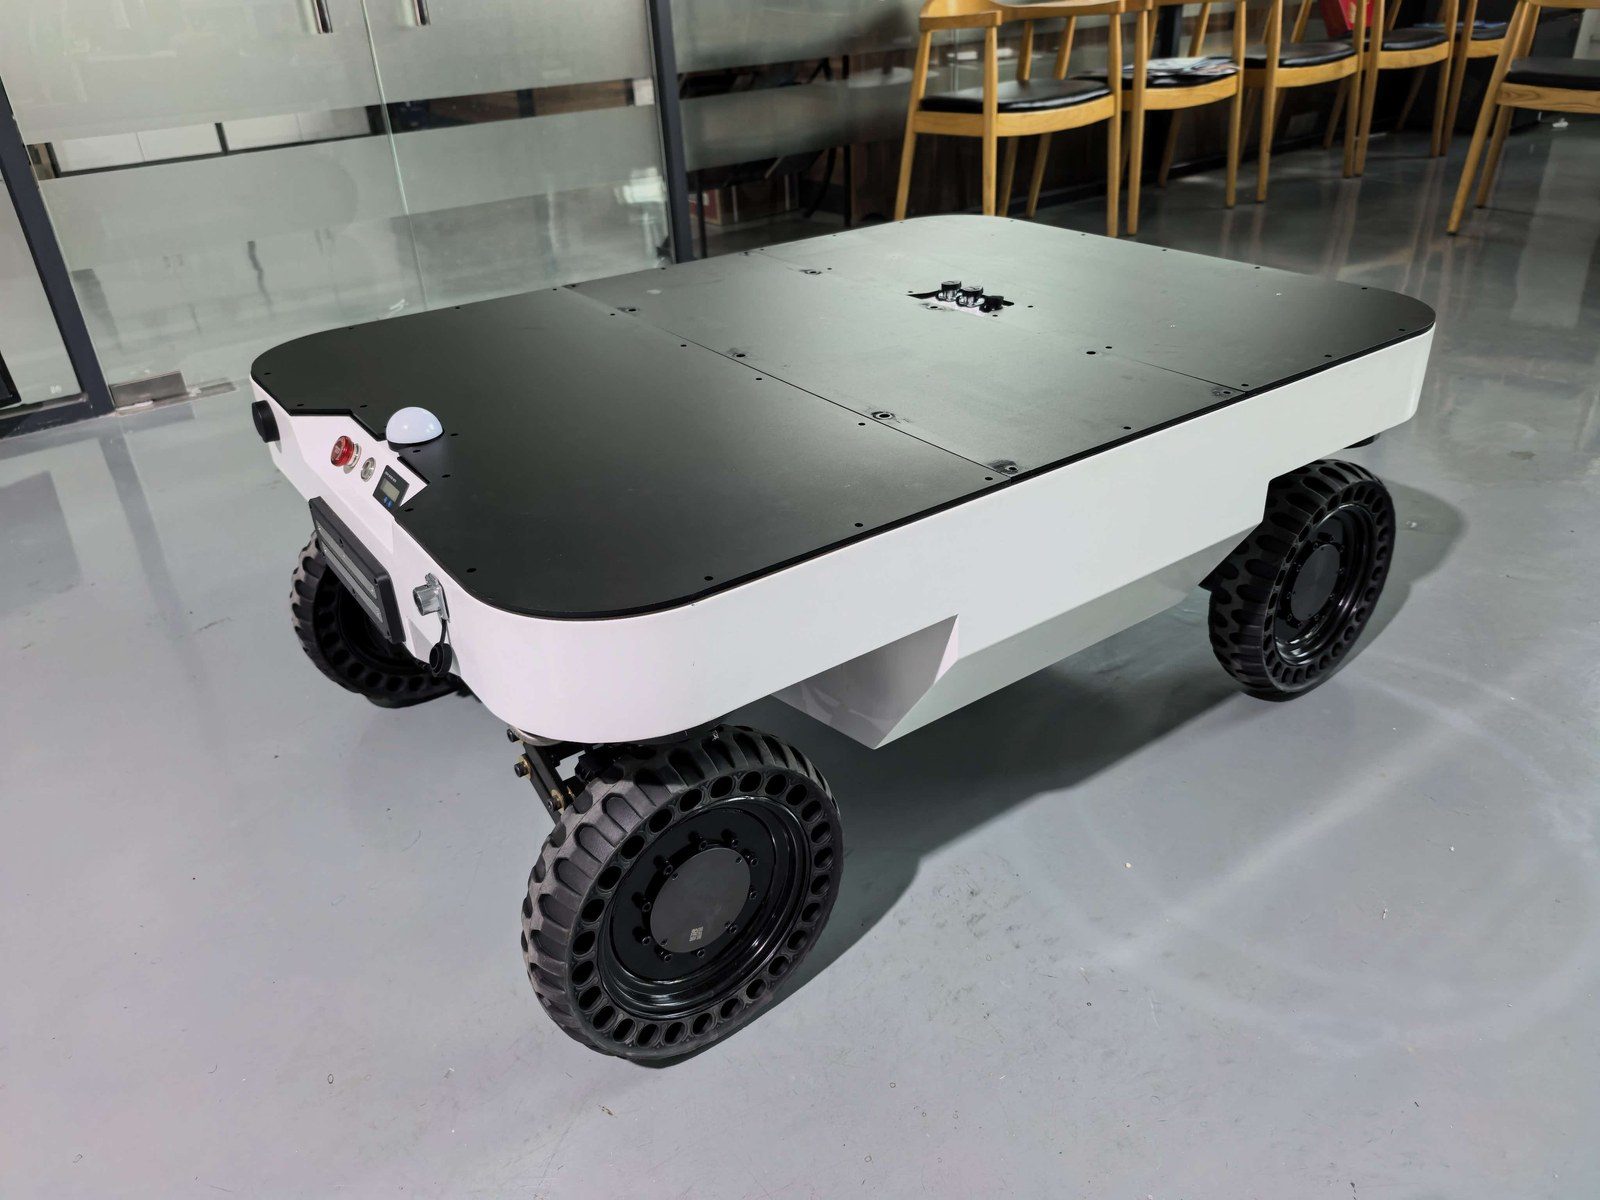
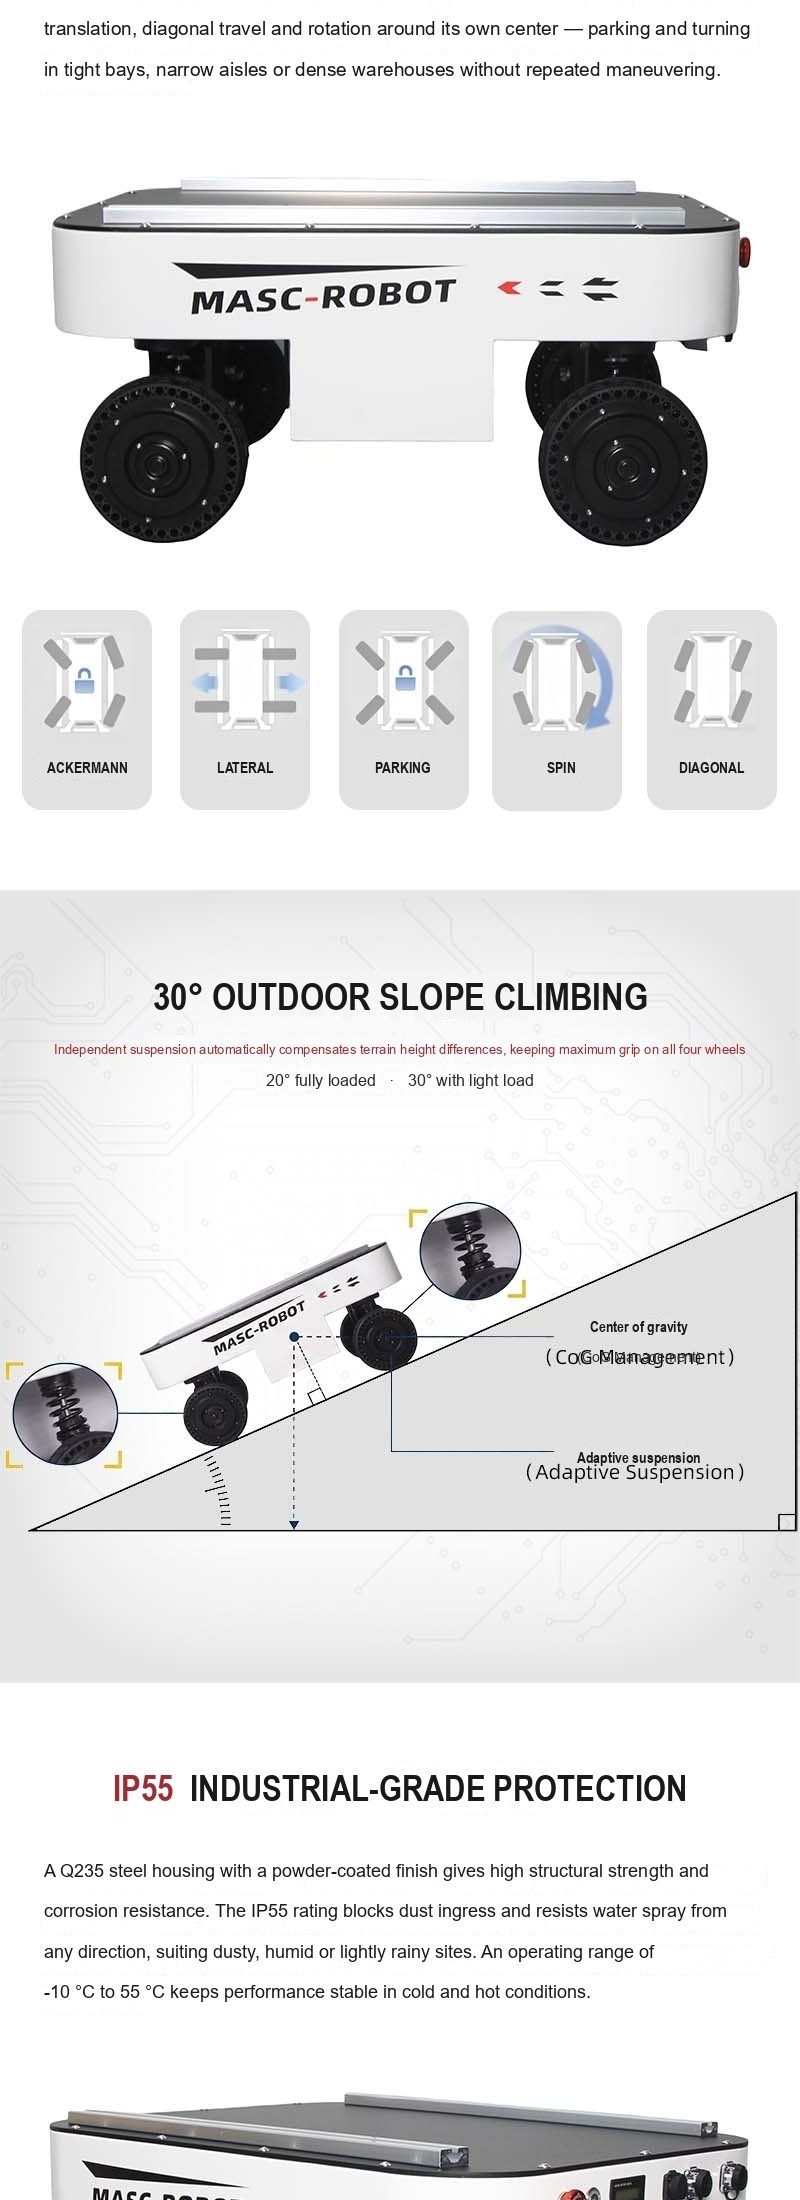
The TRLU-S4-100K is a compact four-wheel-drive, four-wheel-steering mobile robot chassis built for developers who need a reliable moving platform. Each of its four wheels carries its own drive motor and steering motor, giving eight independent servo axes: the chassis can travel forward, sideways and diagonally, and rotate on the spot around its own centre. With a 100 kg payload, a 718 x 560 x 340 mm footprint and 58.5 mm of suspension clearance, it works as comfortably in narrow corridors and pipe racks as it does on uneven outdoor ground.
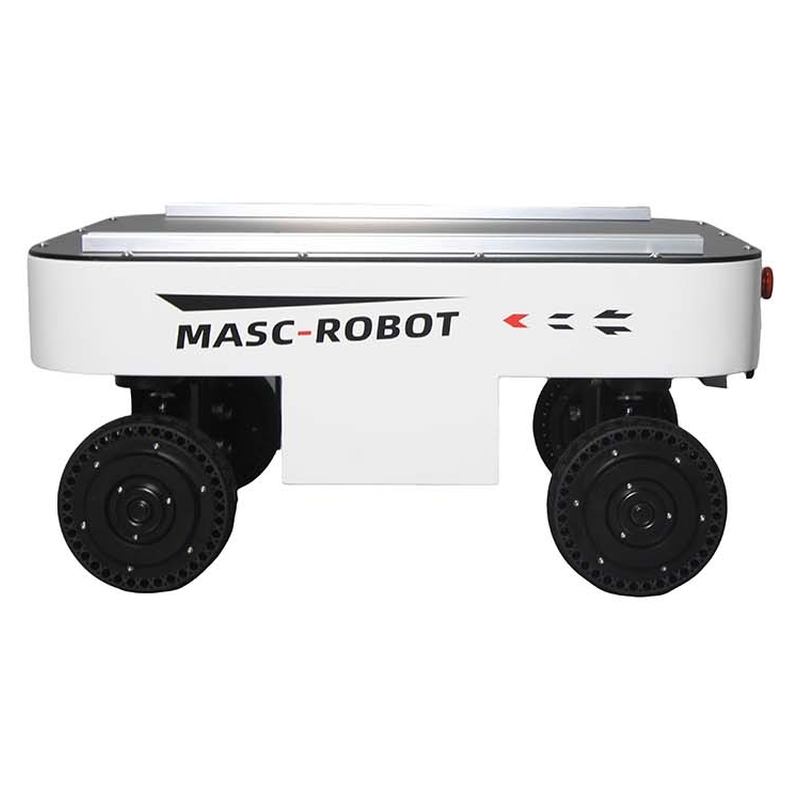
Mount a LiDAR, depth camera, RTK module, IMU or industrial PC on the two pre-installed 40-series European aluminium profiles and the TRLU-S4-100K becomes an unmanned inspection robot, a research and teaching platform, or an outdoor logistics carrier. Control it with the supplied FlySky remote controller, or drive it from your own host computer through the Type-C CAN bus and the documented little-endian protocol.
Key Features
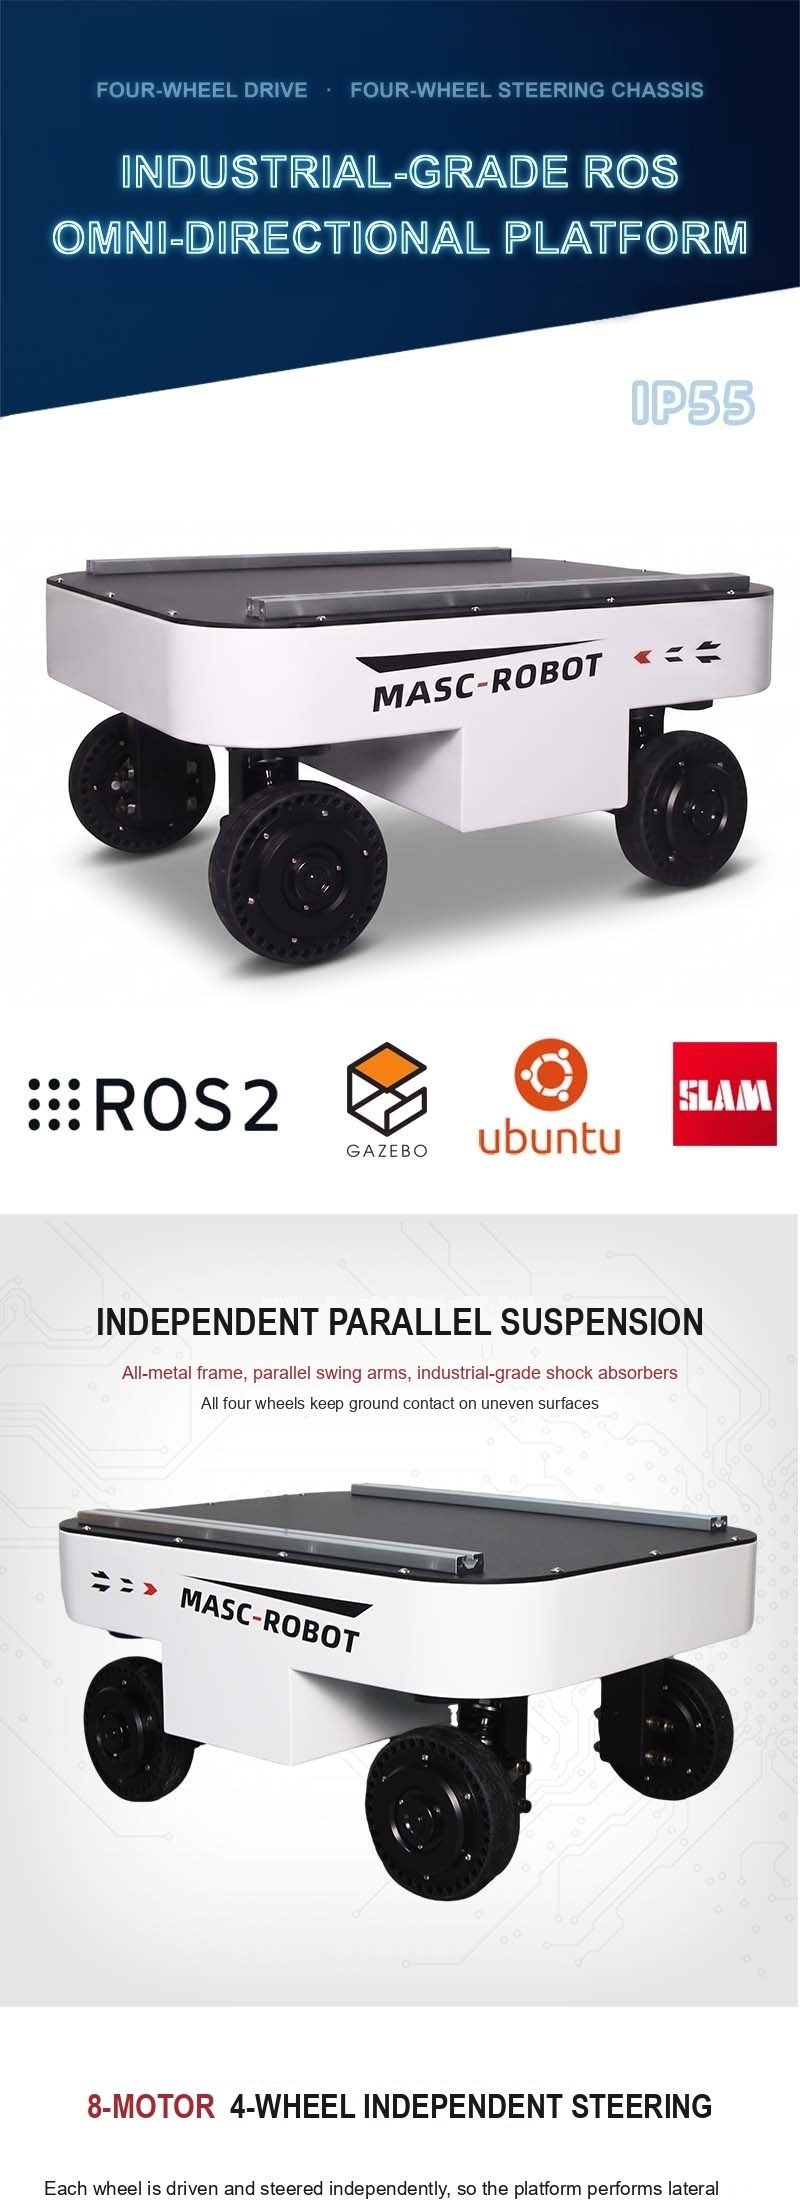
- 8-motor 4WD 4WS layout: 4 drive motors + 4 steering servo motors, independently controlled per wheel
- Six motion modes: 4W4S, front/rear Ackermann, crabbing (lateral), diagonal, spin and parking
- 0 mm minimaler Drehradius und 420 mm Drehradius – dreht sich innerhalb seiner eigenen Stellfläche
- 100 kg Nutzlast bei 50 kg Fahrzeuggewicht und verbreiterter 421 mm Spur
- Parallel independent suspension on all four wheels; 30 degrees gradeability without load, 20 degrees fully loaded
- IP55-Schutz und -10 °C bis 55 °C Betriebsbereich für staubige, feuchte und leicht regnerische Standorte
- 2.0 m/s maximum speed (no load), 4 h battery life, 4 h charging
- CAN-Bus Drive-by-Wire plus FlySky RC-Fernbedienung; Typ-C-Kommunikationsschnittstelle
- 1 x 48 V 10 A (480 W) und 1 x 24 V 10 A (240 W) externe Stromausgänge für Sensoren und Nutzlasten
- 40-series aluminium profiles, emergency stop, battery level indicator and automatic charging electrodes
Six Motion Modes - One Chassis
| Mode | How the chassis moves | Typical use |
| 4W4S (default) | Alle vier Räder fahren und lenken unabhängig voneinander; Das Chassis bewegt sich in jede Richtung, ohne die Richtung zu ändern | Precise docking, narrow working areas |
| Ackermann | Vorder- und Hinterräder lenken in einem autoähnlichen Muster | Fast straight-line travel in long corridors |
| Crabbing | Die Räder drehen sich um 90 Grad und das Fahrgestell bewegt sich seitwärts | Sliding into racks or pallets without turning |
| Diagonal | Räder auf 45 Grad eingestellt, Bewegung entlang des Diagonalvektors | Quick repositioning and aisle entry |
| Spin | Wheels rotate around the chassis centre | Turning in place, 0 mm turning radius |
| Parking | Räder blockierten in gebremster Stellung | Stable standing on slopes, safe load transfer |
Der Bewegungsmodus wird über CAN (Befehl 0x110) oder von der Fernbedienung ausgewählt und das Chassis meldet den aktiven Modus auf 0x220 zurück, sodass ein Host-Computer immer weiß, welches Kinematikmodell läuft.
Independent Parallel Suspension and 30 Degree Gradeability
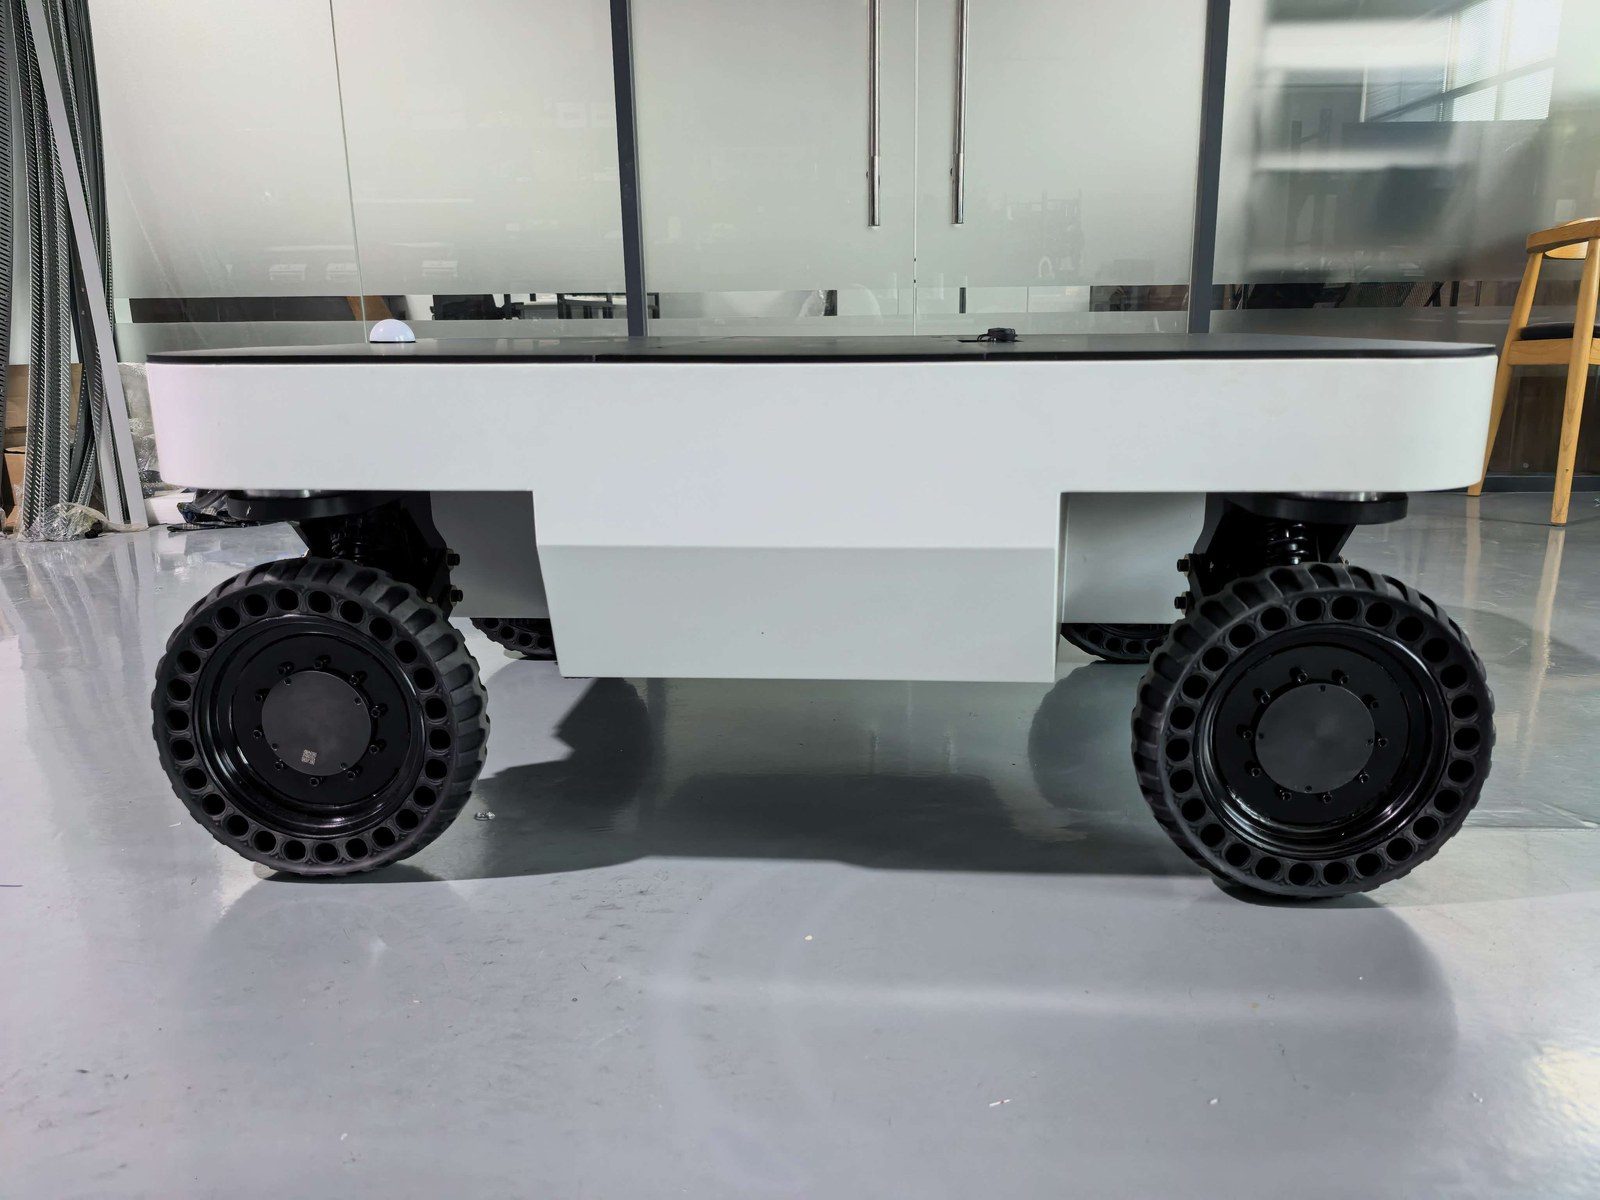
An all-metal parallel wishbone layout with industrial shock absorbers keeps all four wheels in contact with the ground. On uneven terrain or on a slope, the suspension absorbs height differences so that each wheel keeps maximum traction, while the low centre of gravity and the 421 mm track keep the platform stable under the full 100 kg payload. The TRLU-S4-100K climbs 30 degrees without load and 20 degrees fully loaded, with a 118 mm chassis clearance for obstacles and rough ground.
Technical Specifications
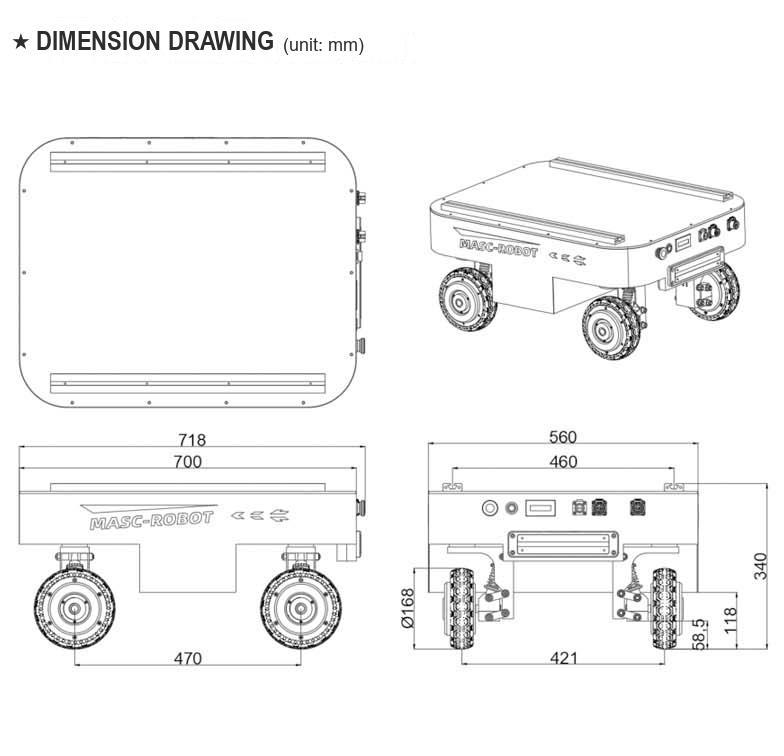
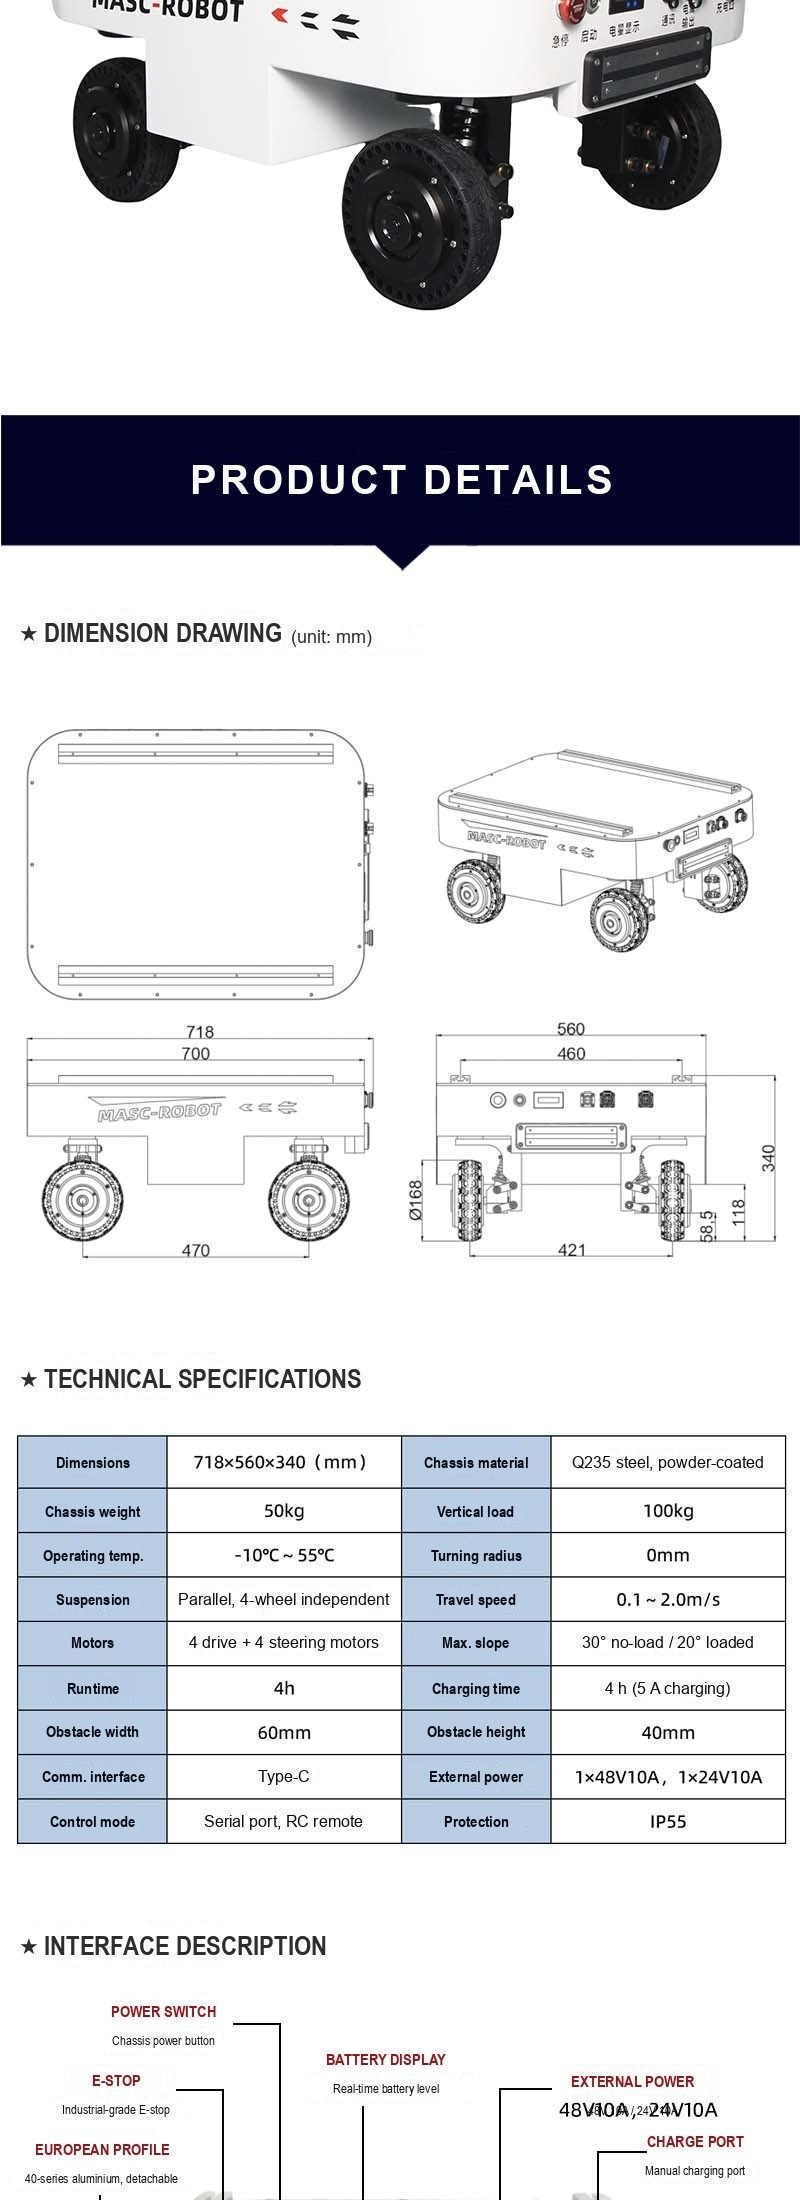
| External dimensions (L x W x H) | 718 x 560 x 340 mm |
| Track width | 421 mm |
| Wheelbase | 470 mm |
| Maximum payload | 100 kg |
| Fahrzeuggewicht | 50 kg |
| Drive type | 4-wheel drive, 4-wheel steering (4W4S) |
| Motors | 4 Antriebs- + 4 Lenkservomotoren (8 Achsen) |
| Suspension | Parallel suspension, 4-wheel independent |
| Maximum speed (no load) | 2.0 m/s |
| Minimum turning radius | 0 mm |
| Rotation radius | 420 mm |
| Ground clearance | Suspension 58.5 mm / chassis 118 mm |
| Maximum gradeability | 30 Grad (keine Last) / 20 Grad (Volllast) |
| Akkulaufzeit | 4 h |
| Ladezeit | 4 h (5 A charger) |
| Protection rating | IP55 |
| Betriebstemperatur | -10 C to 55 C |
| Control mode | FlySky RC-Fernbedienung / CAN-Bus Drive-by-Wire |
| Communication | CAN bus (Little-Endian) via Type-C port |
| External power output | 1 x 48 V 10 A (480 W), 1 x 24 V 10 A (240 W) |
| Aufladen | Manual charger AC 220 V / automatic charging station (optional) |
| Motion modes | 4W4S, Ackermann, Krabbeln, Diagonalfahren, Drehen, Parken |
Dimensions (unit: mm)
Schnittstellen und Bordnetz
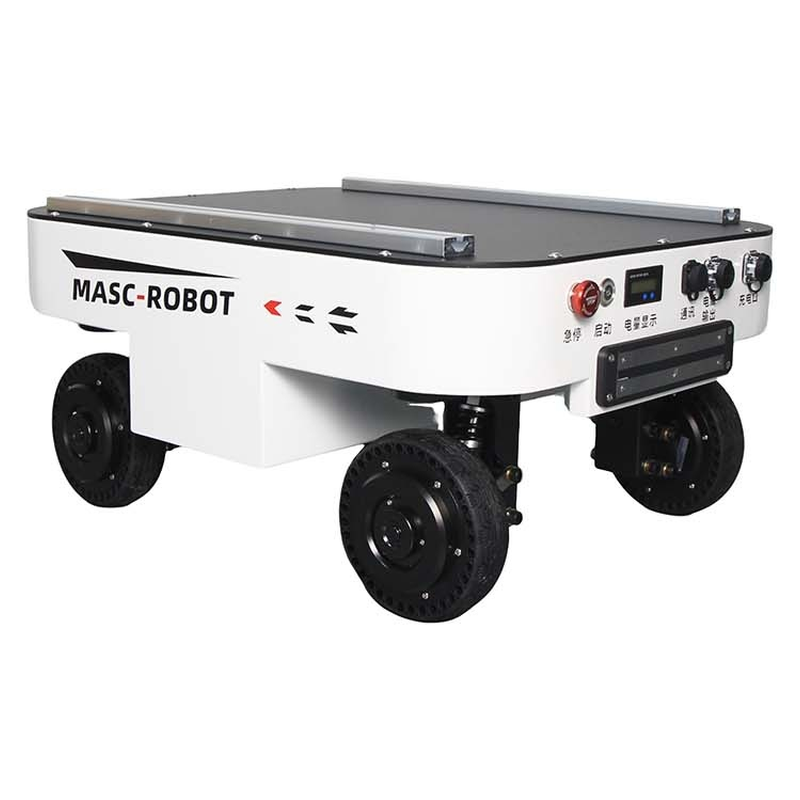
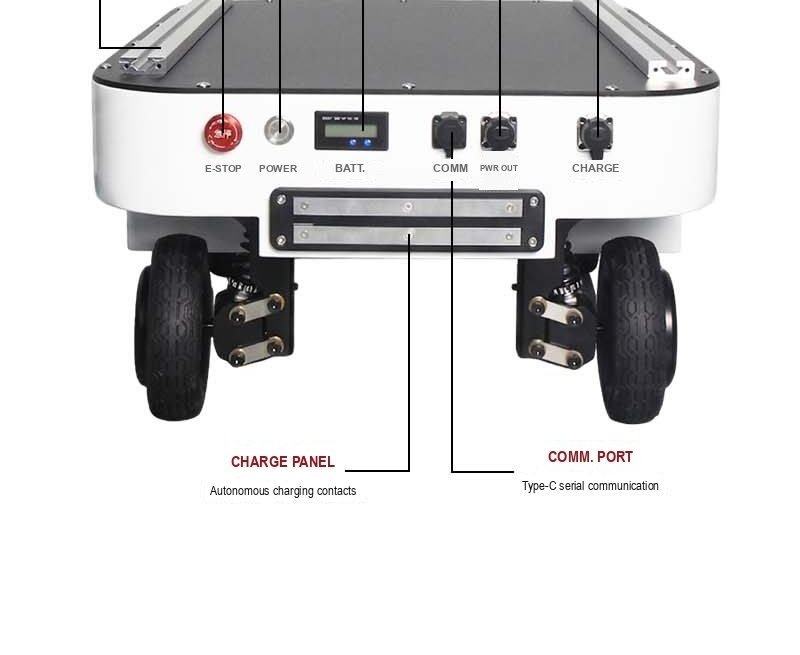
- Emergency stop switch - cuts motor output, industrial-grade push button
- Start switch - chassis main power
- Battery level indicator - real-time state of charge
- Automatische Ladeelektroden – funktionieren mit der optionalen Ladestation
- Typ-C-Schnittstelle – CAN-Kommunikation und Sekundärentwicklung
- Externer Stromausgang – 1 x 48 V 10 A (480 W), 1 x 24 V 10 A (240 W)
- Manual charging port - AC 220 V dedicated lithium battery charger
CAN Bus Development
The firmware speaks a documented Little-Endian CAN protocol: motion control frame 0x100 at 20 ms (X/Y linear velocity, Z angular velocity, target steering angle), motion feedback 0x200, motion-mode switch 0x110 with feedback on 0x220, system status 0x204, BMS data on 0x206 and 0x207, drive-wheel feedback 0x251-0x258, steering servo feedback 0x271-0x278, IMU 0x300 and RC channels 0x301. A 500 ms receive timeout brings the chassis to a controlled stop, so a host controller only has to publish commands periodically.
What is in the Box
- 1 x TRLU-S4-100K 4WD 4WS drive-by-wire chassis
- 1 x manual battery charger (AC 220 V)
- 1 x FlySky wireless remote controller
- 1 x automatic charging station (optional)
Application Scenarios
Unmanned inspection in substations, pipe galleries and factory halls; research and teaching platforms for SLAM, navigation and multi-robot collaboration; outdoor material transfer and logistics in energy, construction, agriculture and industrial sites; mobile base for robotic arms and mobile manipulators. The chassis is delivered as a development platform: mounting holes, aluminium profiles, CAN protocol and power outputs are ready for your own sensors and payloads.
Full Specification Sheet
Garantie: 12 Monate Auslandsgarantie (ausgenommen Verbrauchsmaterialien wie Batterien und Reifen).
Vollständige technische Daten
| Modell | TRLU-S4-100K |
|---|---|
| Nutzlast | 100 kg |
| Abmessungen | 718 x 560 x 340 mm |
| Fahrzeuggewicht | 50 kg |
| Fahren | 4 Antriebs- + 4 Lenkservomotoren (8 Achsen) |
| Sechs Bewegungsmodi | 4W4S, Ackermann, Krabbeln, Diagonalfahren, Drehen, Parken |
| Max. Geschwindigkeit | 2.0 m/s |
| Wenderadius | 0 mm |
| Steigfähigkeit | 30 Grad (keine Last) / 20 Grad (Volllast) |
| Schutz | IP55 |
| Kategorie | Mobile Roboter und AMR |
| Vorlaufzeit | 15-30 days |
Die Werte sind Nominalwerte bei 20 °C. Laden Sie das Datenblatt für CAD-Modelle, Drehmomentkurven und Controller-I/O-Karten herunter.
Wo es läuft
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Fragen des Käufers
Was sind die wichtigsten Spezifikationen?
Modell: TRLU-S4-100K, Nutzlast: 100 kg, Abmessungen: 718 x 560 x 340 mm.
Was ist die Vorlaufzeit?
15–30 Tage für die Standardkonfiguration; im Angebot bestätigt.
Kann es individuell angepasst werden?
Ja – OEM/ODM-Optionen, Spannung, Werkzeuge und Branding können angepasst werden. Senden Sie den Antrag und zielen Sie auf die Ausgabe eines Angebots ab.
Holen Sie sich ein Preisangebot für TRLU-S4-100K
Geben Sie das Teil, die Zielrate und den Zielport an. Ein Techniker – kein Chatbot – antwortet innerhalb von 48 Stunden.
Gleiche Kategorie
300 kg schwerer mobiler CTU-Roboter für die Regalhandhabung
30 t Schwerlast-AMR-Plattform
2 t autonomer Gabelstapler AMR
Bewertet von TROY Engineering ·. Bei jedem Angebot werden die Spezifikationen erneut anhand des Datenblatts des Lieferanten überprüft.