


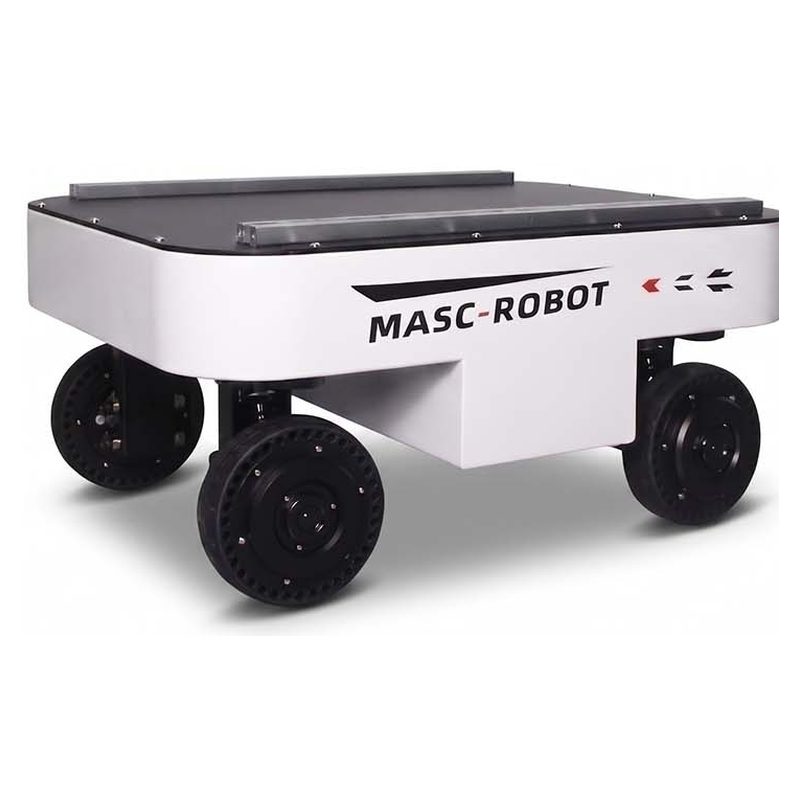
4WD 4WS オフロードモバイルロボットシャーシ TRLU-S4-100K
TRLU-S4-100Kは、社内物流・倉庫搬送用の移動ロボットです。主な仕様: ペイロード 100 kg。寸法 718 x 560 x 340 mm;車両重量50kg。リードタイムは15〜30日です。価格は構成ごとに見積もられます。認証: ご要望に応じて CE ドキュメントをご提供します。
- モデル
- TRLU-S4-100K
- ペイロード
- 100 kg
- 寸法
- 718 x 560 x 340 mm
- 車両重量
- 50 kg
- ドライブ
- 4ドライブ+4ステアリングサーボモーター(8軸)
- 6つのモーションモード
- 4W4S、アッカーマン、クラビング、ダイアゴナル、スピン、パーキング
このプラットフォームの目的
TRLU-S4-100K は、8 つの独立したサーボモーター、6 つの動作モード、回転半径 0 mm、30 度の登坂性、および IP55 保護を備えた、ペイロード 100 kg の 4WD 4WS ドライブバイワイヤロボットシャーシです。 CAN バスと RC 制御、LiDAR、RTK、SLAM 開発に対応。
商業条件
| 引用 | 構成ごとの価格 - 48 時間以内にご返信ください |
|---|---|
| リードタイム | 15-30 days |
| MOQ | 1台 |
| 起源 | 中国 |
| 積地港 | 深セン、中国 |
| インコタームズ | FOB 深セン / CIF (ご要望に応じて) |
| 支払い | 30% のデポジット、出荷前に 70% |
| 保証 | 標準は 24 か月、オプションは 36 か月 |
製品詳細
TROY エンジニアリング ファイルからのアプリケーション ノート、構造図、およびビデオ — 見積書に同梱される同じ文書。
Compact 4WD 4WS Drive-by-Wire Chassis for Off-Road AMR Development
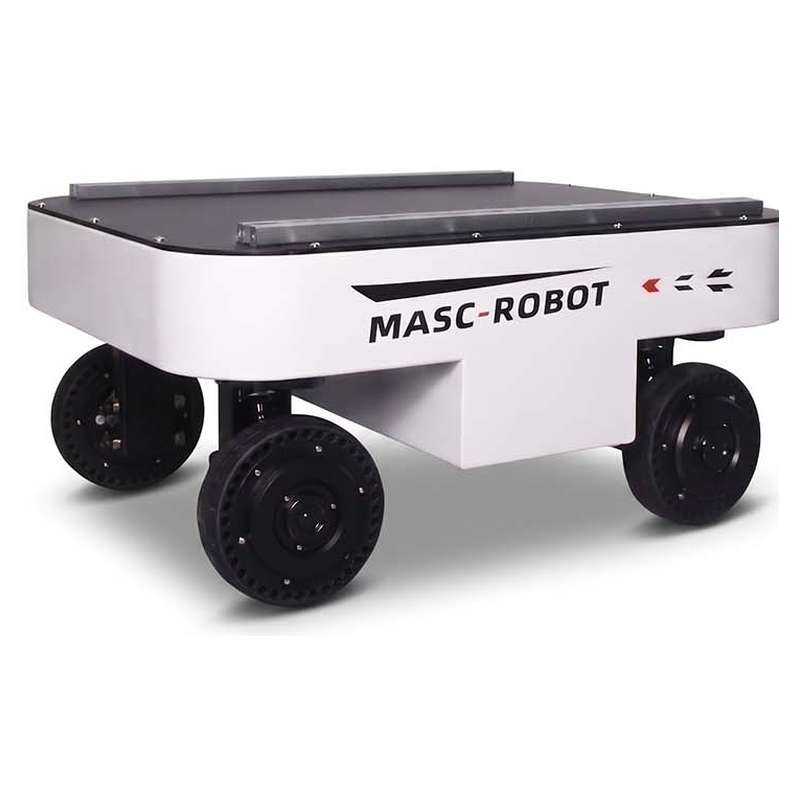
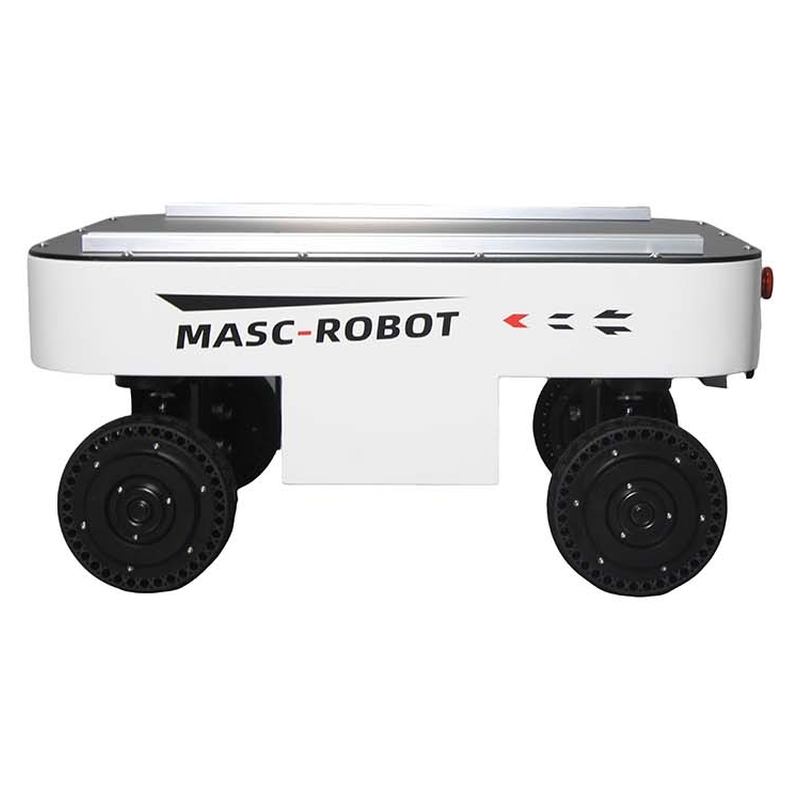
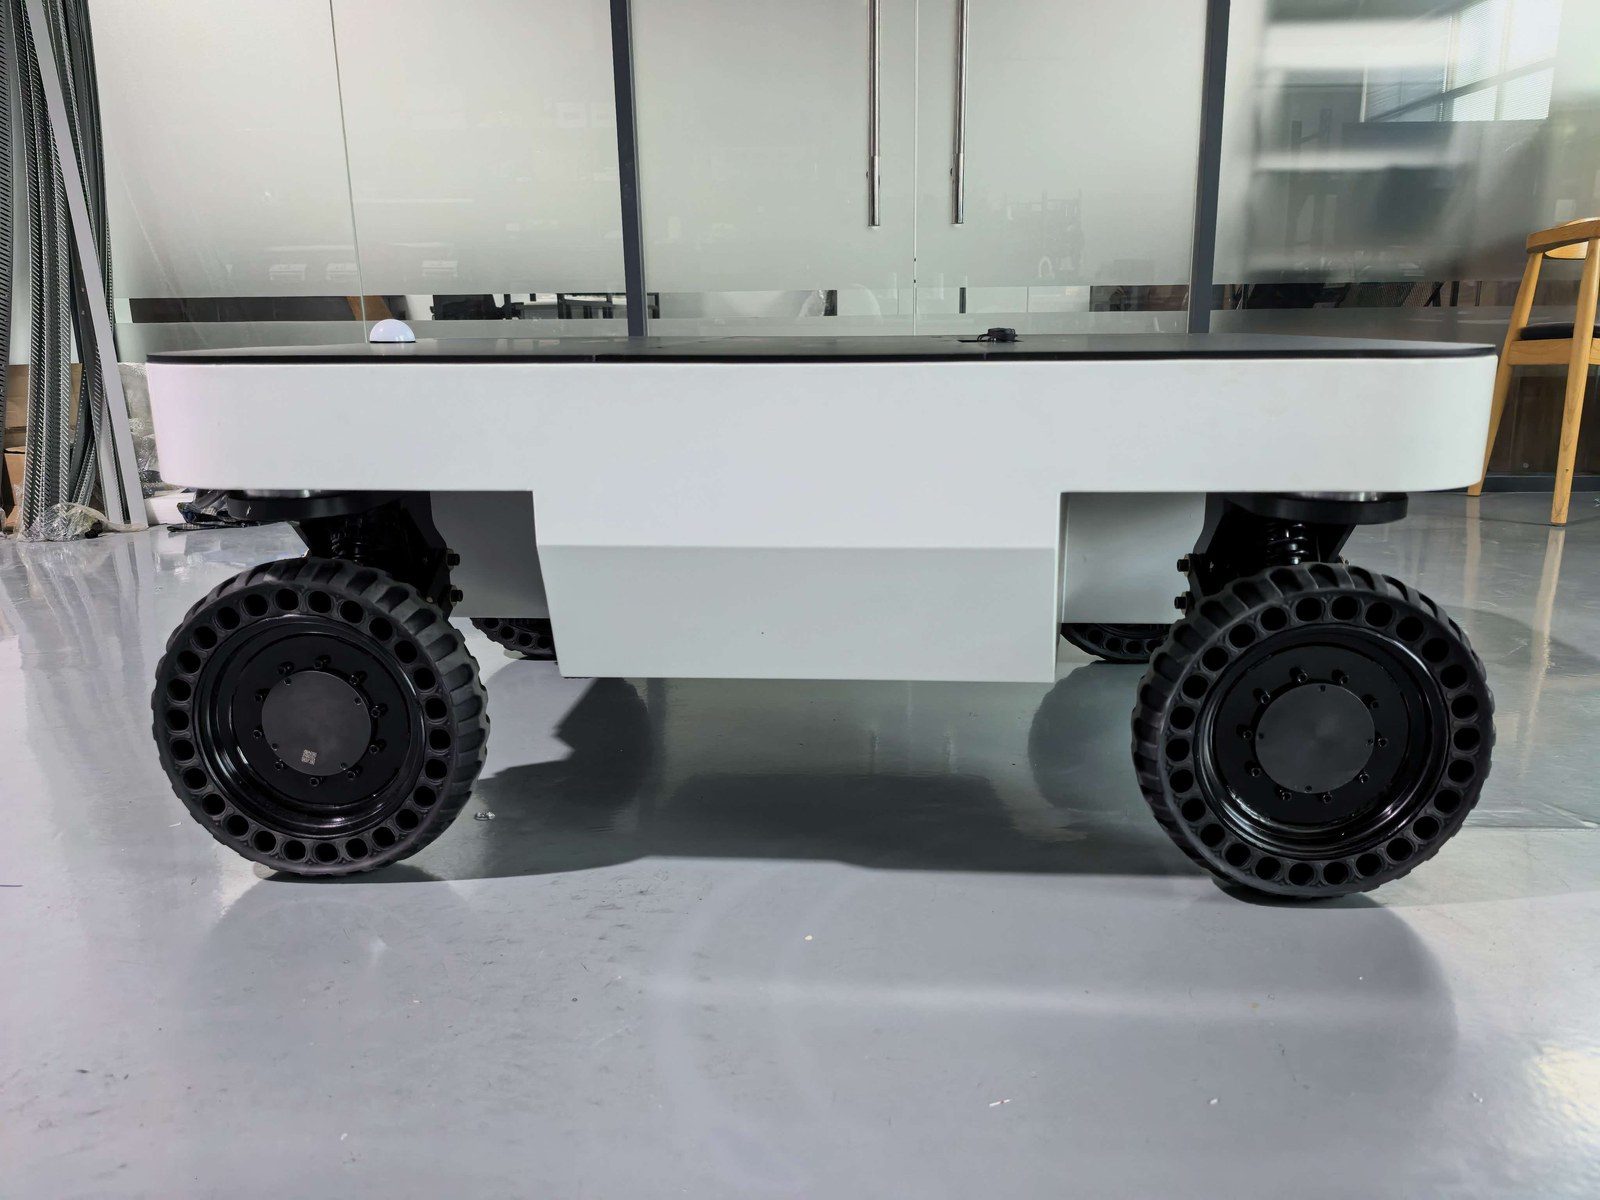
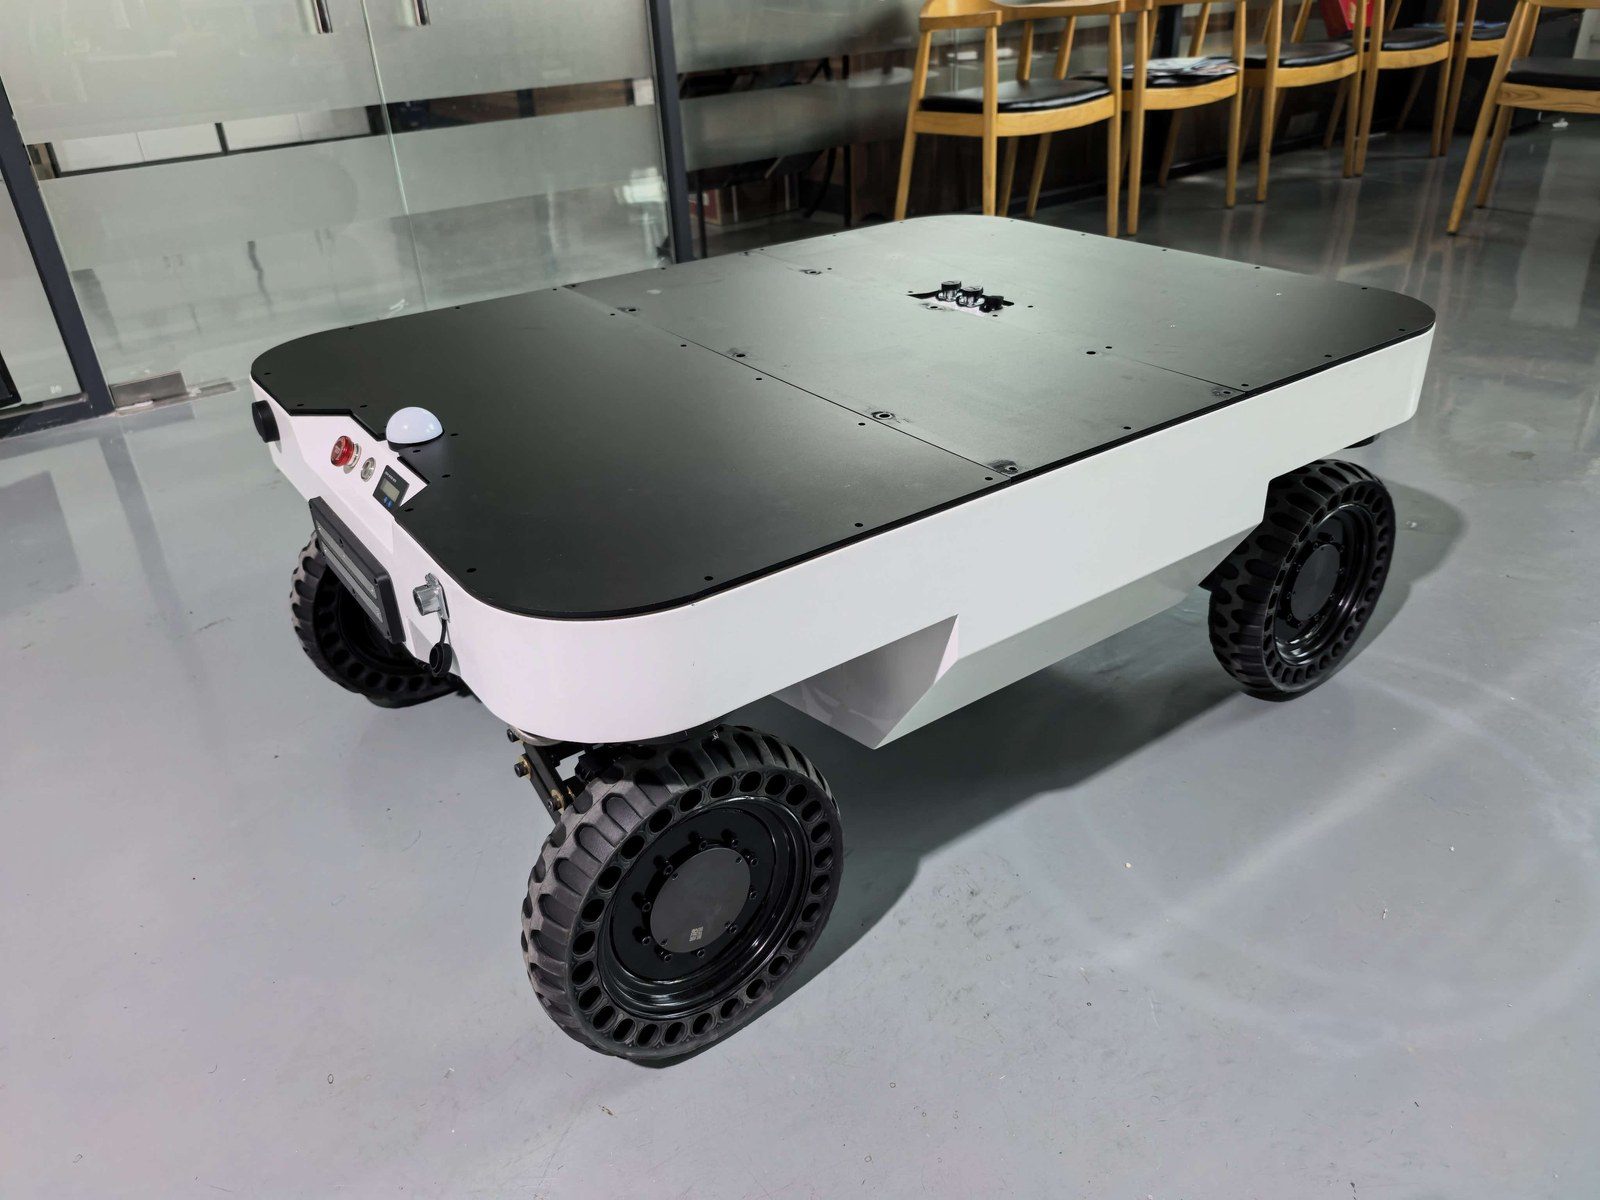
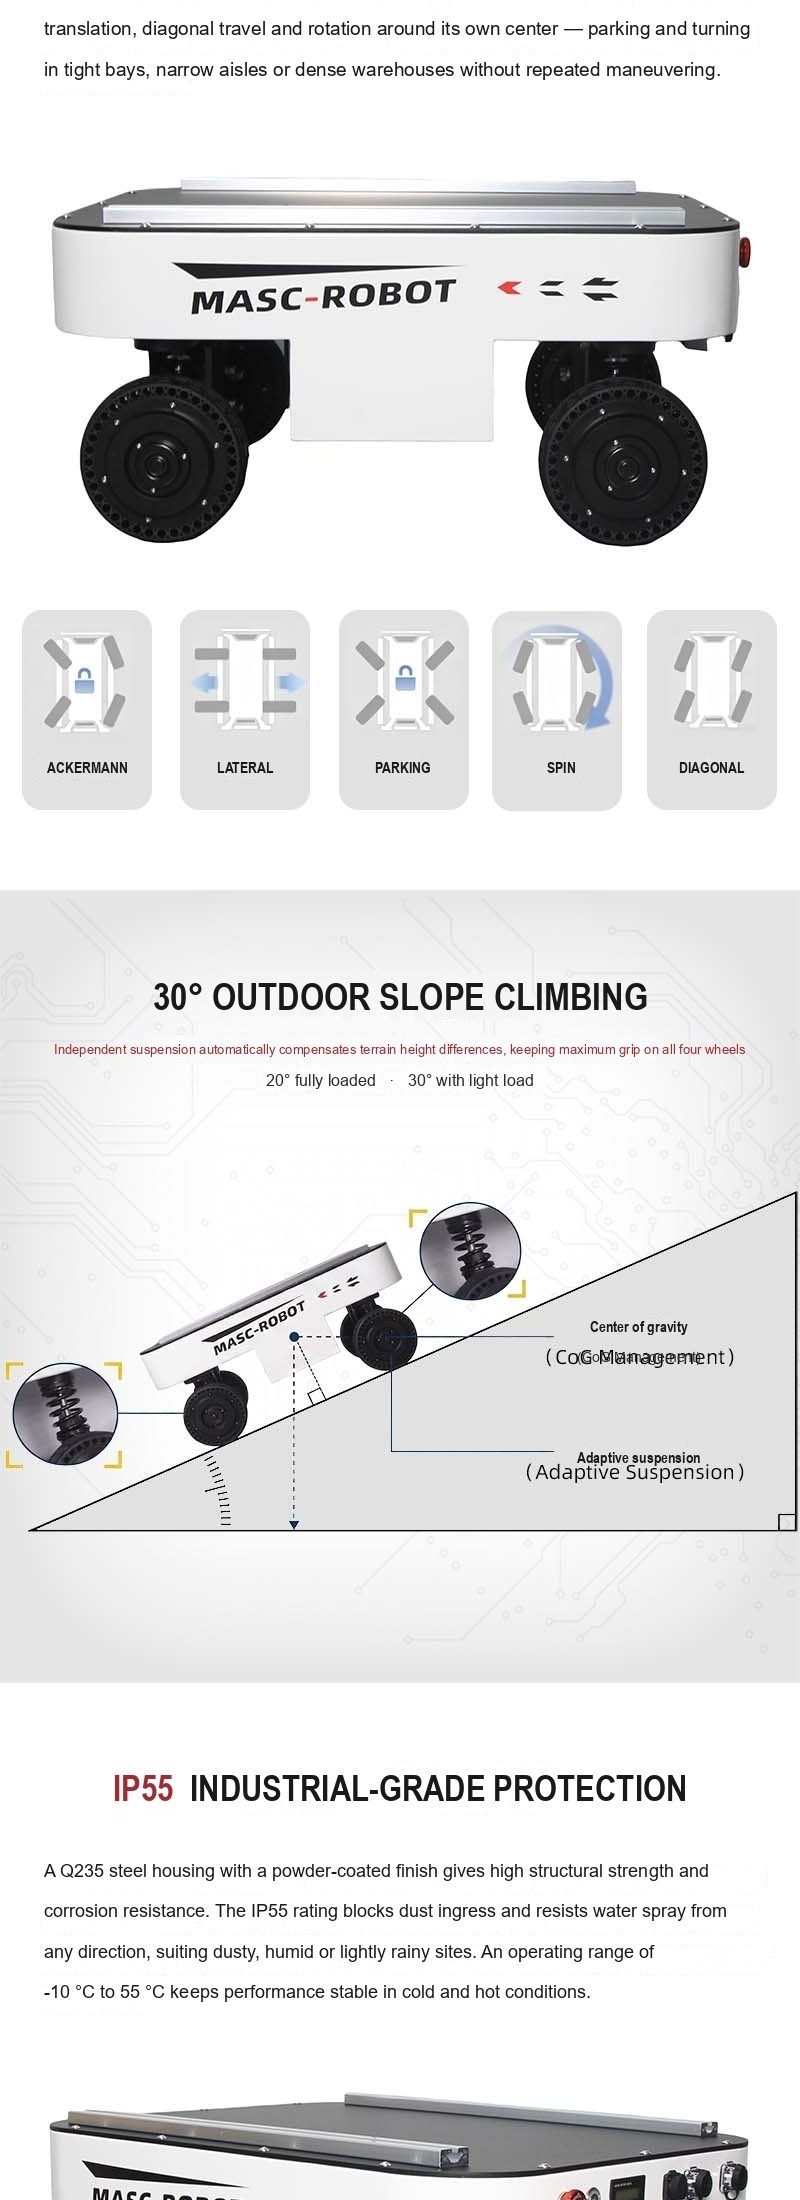
The TRLU-S4-100K is a compact four-wheel-drive, four-wheel-steering mobile robot chassis built for developers who need a reliable moving platform. Each of its four wheels carries its own drive motor and steering motor, giving eight independent servo axes: the chassis can travel forward, sideways and diagonally, and rotate on the spot around its own centre. With a 100 kg payload, a 718 x 560 x 340 mm footprint and 58.5 mm of suspension clearance, it works as comfortably in narrow corridors and pipe racks as it does on uneven outdoor ground.
Mount a LiDAR, depth camera, RTK module, IMU or industrial PC on the two pre-installed 40-series European aluminium profiles and the TRLU-S4-100K becomes an unmanned inspection robot, a research and teaching platform, or an outdoor logistics carrier. Control it with the supplied FlySky remote controller, or drive it from your own host computer through the Type-C CAN bus and the documented little-endian protocol.
Key Features
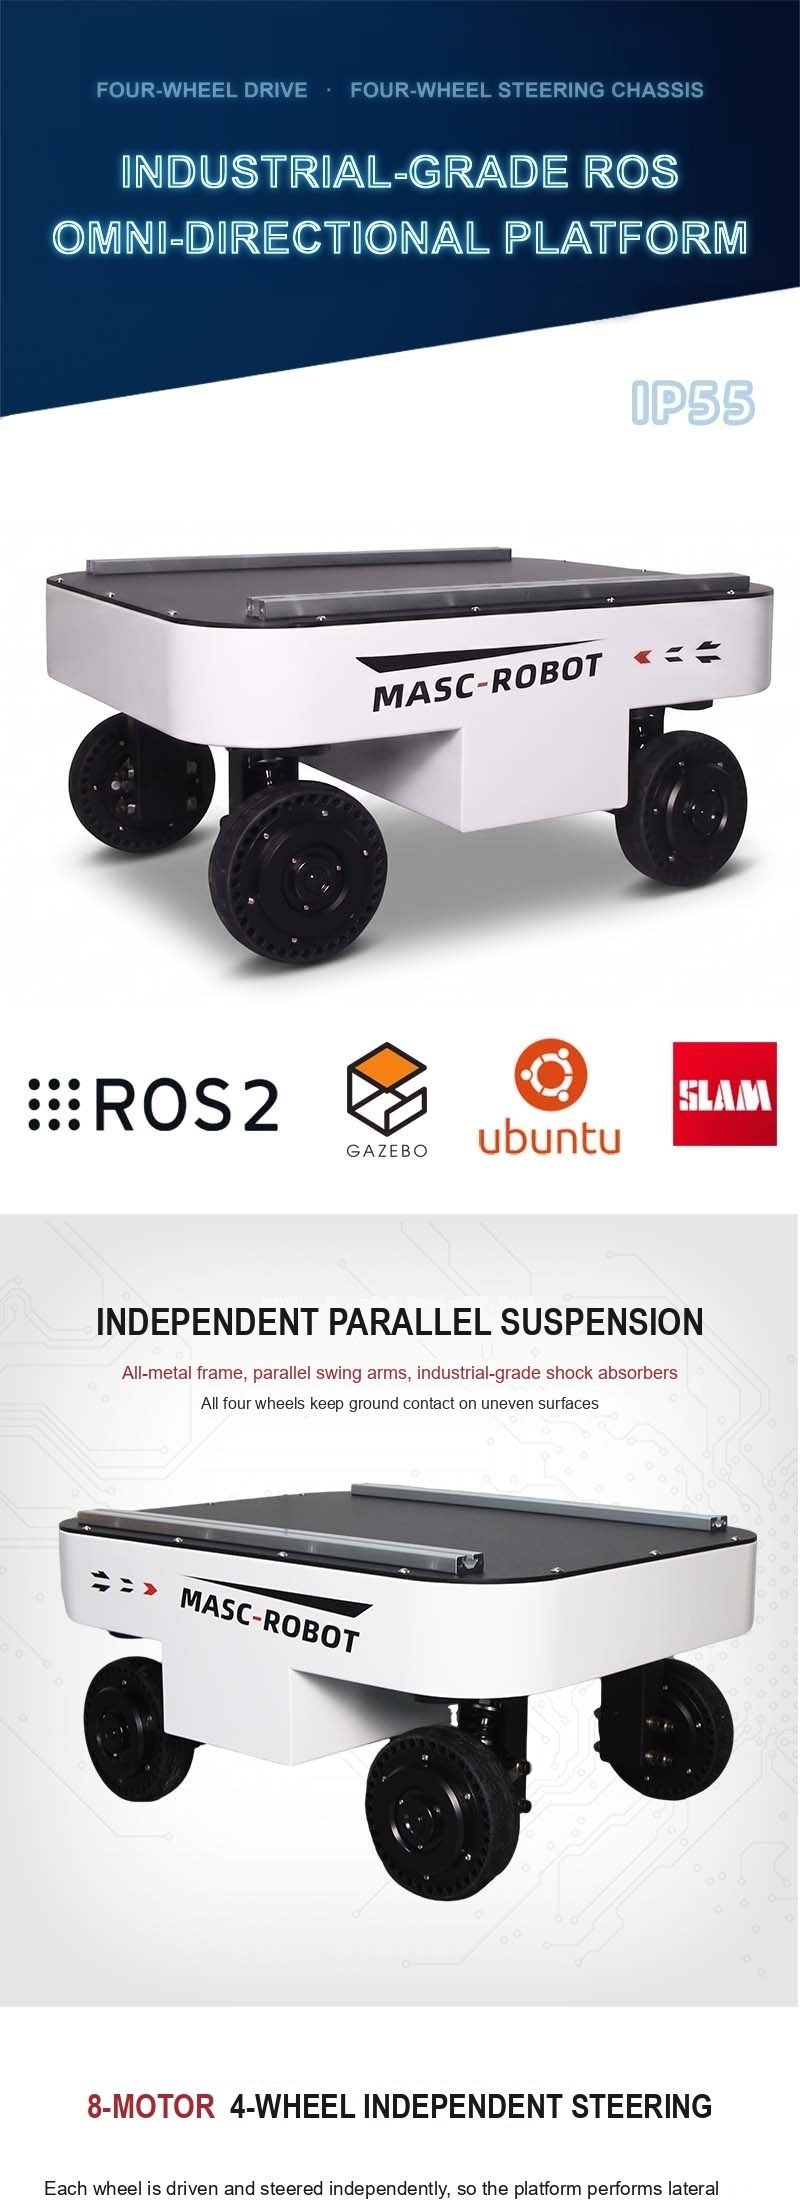
- 8-motor 4WD 4WS layout: 4 drive motors + 4 steering servo motors, independently controlled per wheel
- Six motion modes: 4W4S, front/rear Ackermann, crabbing (lateral), diagonal, spin and parking
- 最小回転半径 0 mm および回転半径 420 mm - 独自の設置面積内で回転します
- 50 kgの車両重量と421 mmの幅広トラックで100 kgの積載量
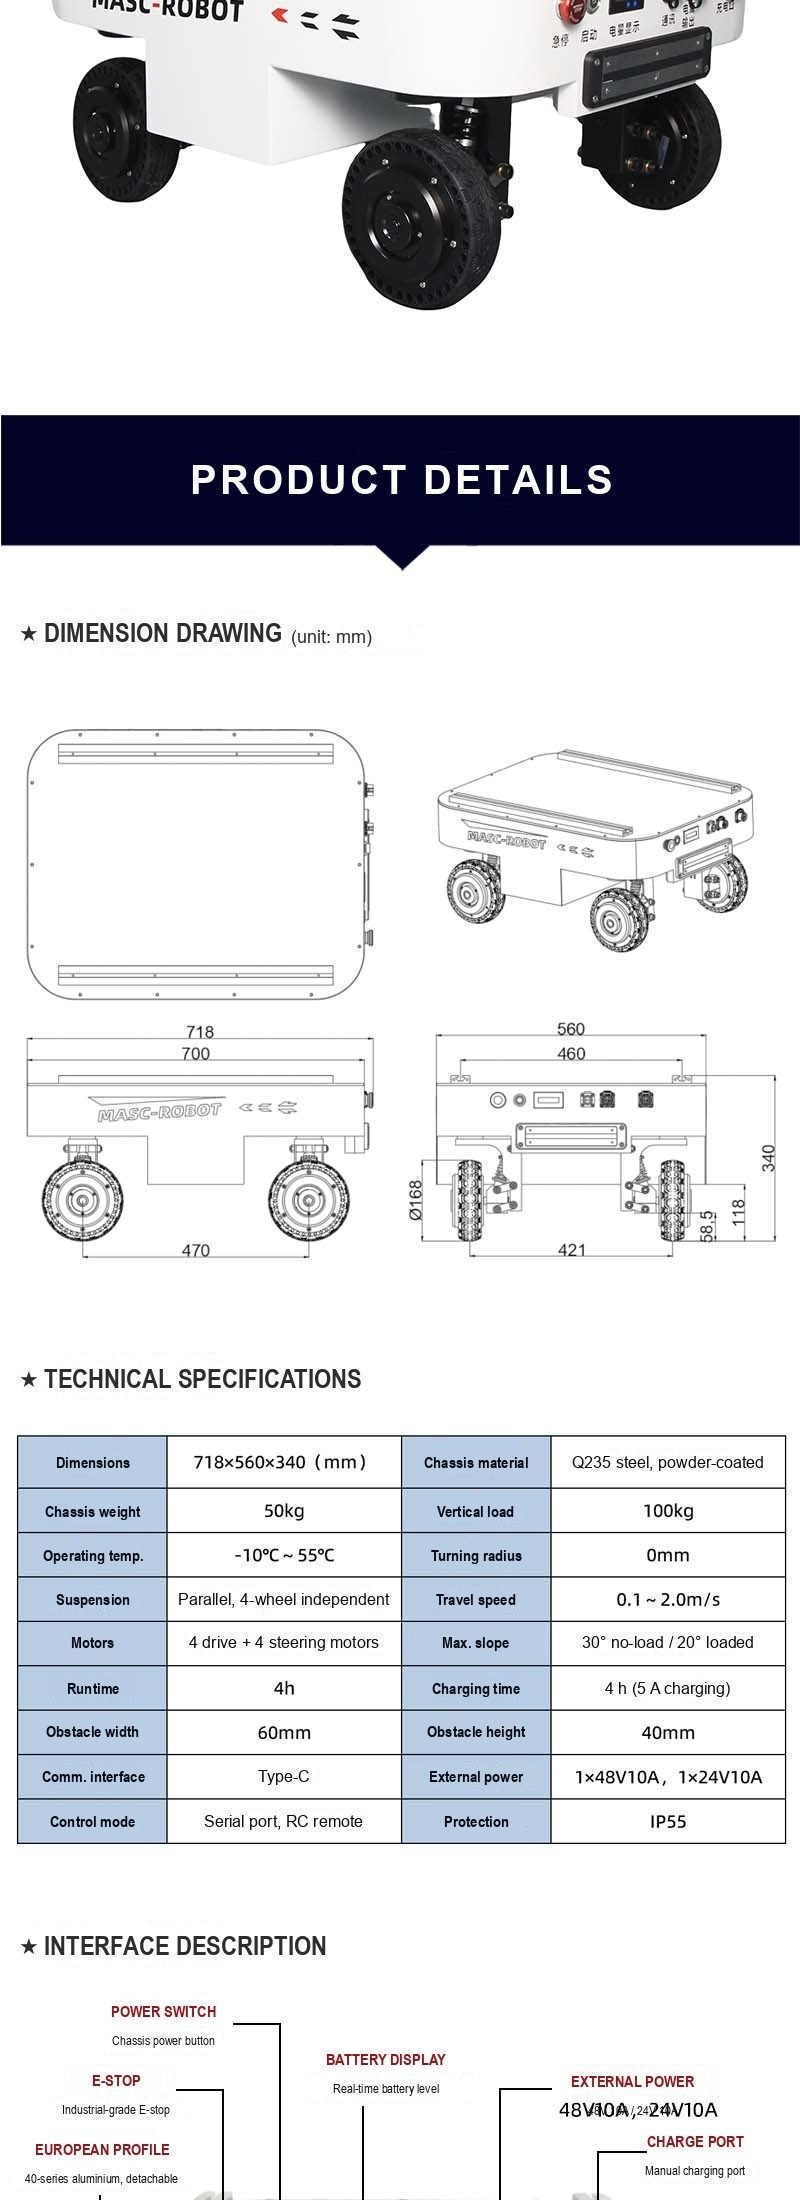
- Parallel independent suspension on all four wheels; 30 degrees gradeability without load, 20 degrees fully loaded
- IP55 保護および -10 C ~ 55 C の動作範囲で、ほこりの多い、湿気の多い、小雨の現場に対応
- 2.0 m/s maximum speed (no load), 4 h battery life, 4 h charging
- CANバスドライブバイワイヤとFlySky RCリモートコントロール。 Type-C通信インターフェース
- センサーおよびペイロード用の 1 x 48 V 10 A (480 W) および 1 x 24 V 10 A (240 W) 外部電源出力
- 40-series aluminium profiles, emergency stop, battery level indicator and automatic charging electrodes
Six Motion Modes - One Chassis
| Mode | How the chassis moves | Typical use |
| 4W4S (default) | 4 つの車輪すべてが独立して駆動し、操縦します。シャーシは方向を変えることなく任意の方向に移動します | Precise docking, narrow working areas |
| Ackermann | 前輪と後輪が車のようなパターンで操縦します | Fast straight-line travel in long corridors |
| Crabbing | 車輪が 90 度回転し、シャーシが横に動きます | Sliding into racks or pallets without turning |
| Diagonal | ホイールは 45 度に設定、対角ベクトルに沿った動き | Quick repositioning and aisle entry |
| Spin | Wheels rotate around the chassis centre | Turning in place, 0 mm turning radius |
| Parking | ブレーキをかけた姿勢で車輪がロックされる | Stable standing on slopes, safe load transfer |
モーション モードは CAN (コマンド 0x110) またはリモート コントローラーから選択され、シャーシはアクティブ モードを 0x220 に報告するため、ホスト コンピューターはどの運動学モデルが実行されているかを常に認識します。
Independent Parallel Suspension and 30 Degree Gradeability
An all-metal parallel wishbone layout with industrial shock absorbers keeps all four wheels in contact with the ground. On uneven terrain or on a slope, the suspension absorbs height differences so that each wheel keeps maximum traction, while the low centre of gravity and the 421 mm track keep the platform stable under the full 100 kg payload. The TRLU-S4-100K climbs 30 degrees without load and 20 degrees fully loaded, with a 118 mm chassis clearance for obstacles and rough ground.
Technical Specifications
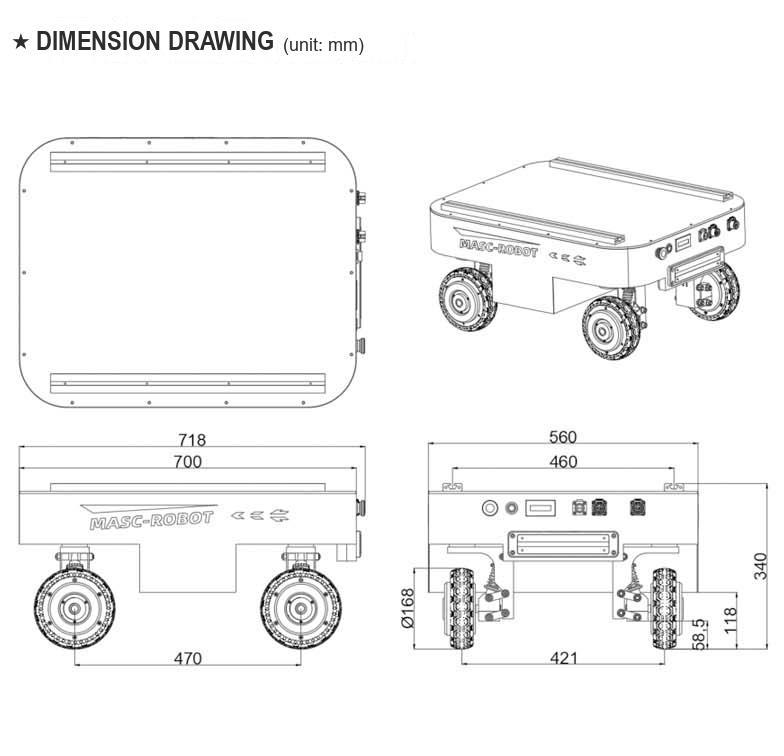
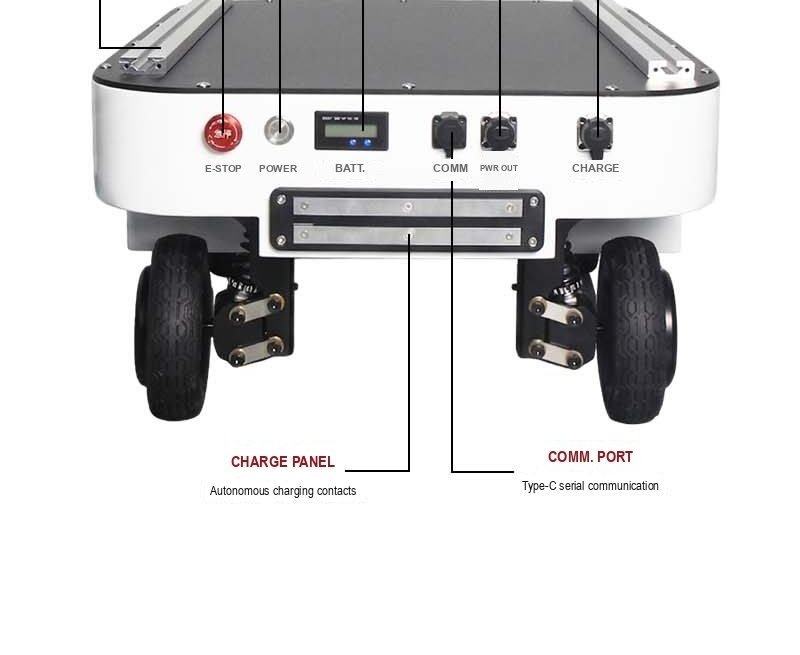
| External dimensions (L x W x H) | 718 x 560 x 340 mm |
| Track width | 421 mm |
| Wheelbase | 470 mm |
| Maximum payload | 100 kg |
| 車両重量 | 50 kg |
| Drive type | 4-wheel drive, 4-wheel steering (4W4S) |
| Motors | 4ドライブ+4ステアリングサーボモーター(8軸) |
| サスペンション | Parallel suspension, 4-wheel independent |
| Maximum speed (no load) | 2.0 m/s |
| Minimum turning radius | 0 mm |
| Rotation radius | 420 mm |
| Ground clearance | Suspension 58.5 mm / chassis 118 mm |
| Maximum gradeability | 30度(無負荷)/20度(全負荷) |
| バッテリー寿命 | 4 h |
| 充電時間 | 4 h (5 A charger) |
| Protection rating | IP55 |
| 動作温度 | -10 C to 55 C |
| Control mode | FlySky RC リモート / CAN バス ドライブバイワイヤ |
| Communication | CAN bus (Little-Endian) via Type-C port |
| External power output | 1×48V 10A(480W)、1×24V 10A(240W) |
| 充電 | Manual charger AC 220 V / automatic charging station (optional) |
| Motion modes | 4W4S、アッカーマン、クラビング、ダイアゴナル、スピン、パーキング |
Dimensions (unit: mm)
インターフェースとオンボード電源
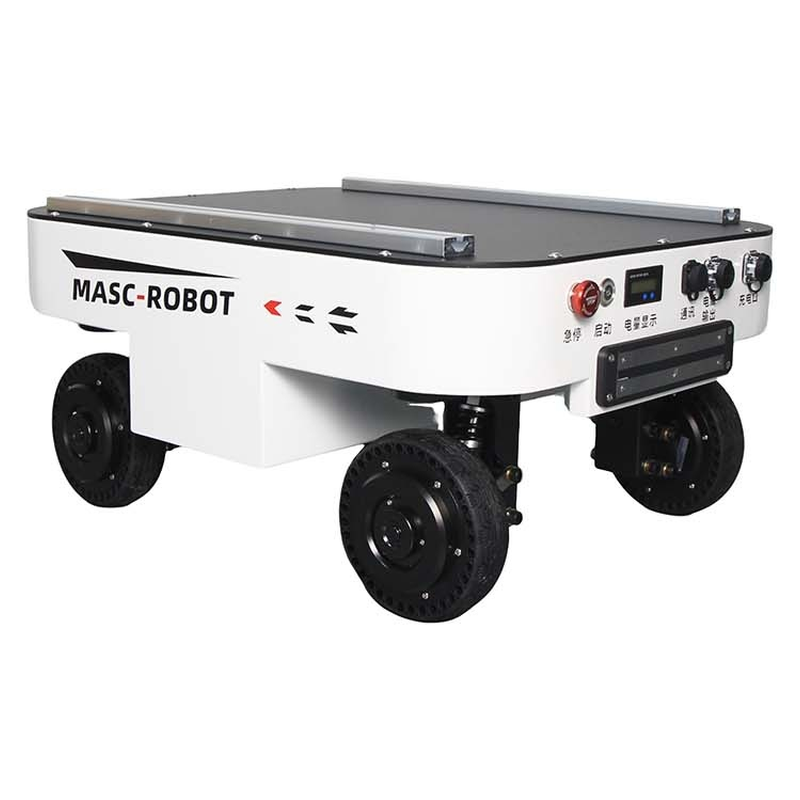
- Emergency stop switch - cuts motor output, industrial-grade push button
- Start switch - chassis main power
- Battery level indicator - real-time state of charge
- 自動充電電極 - オプションの充電ステーションと連携します。
- Type-C インターフェース - CAN 通信と二次開発
- 外部電源出力 - 1 x 48 V 10 A (480 W)、1 x 24 V 10 A (240 W)
- Manual charging port - AC 220 V dedicated lithium battery charger
CAN Bus Development
The firmware speaks a documented Little-Endian CAN protocol: motion control frame 0x100 at 20 ms (X/Y linear velocity, Z angular velocity, target steering angle), motion feedback 0x200, motion-mode switch 0x110 with feedback on 0x220, system status 0x204, BMS data on 0x206 and 0x207, drive-wheel feedback 0x251-0x258, steering servo feedback 0x271-0x278, IMU 0x300 and RC channels 0x301. A 500 ms receive timeout brings the chassis to a controlled stop, so a host controller only has to publish commands periodically.
What is in the Box
- 1 x TRLU-S4-100K 4WD 4WS drive-by-wire chassis
- 1 x manual battery charger (AC 220 V)
- 1 x FlySky wireless remote controller
- 1 x automatic charging station (optional)
Application Scenarios
Unmanned inspection in substations, pipe galleries and factory halls; research and teaching platforms for SLAM, navigation and multi-robot collaboration; outdoor material transfer and logistics in energy, construction, agriculture and industrial sites; mobile base for robotic arms and mobile manipulators. The chassis is delivered as a development platform: mounting holes, aluminium profiles, CAN protocol and power outputs are ready for your own sensors and payloads.
Full Specification Sheet
保証:海外12ヶ月保証(バッテリーやタイヤなどの消耗品を除く)。
完全な技術データ
| モデル | TRLU-S4-100K |
|---|---|
| ペイロード | 100 kg |
| 寸法 | 718 x 560 x 340 mm |
| 車両重量 | 50 kg |
| ドライブ | 4ドライブ+4ステアリングサーボモーター(8軸) |
| 6つのモーションモード | 4W4S、アッカーマン、クラビング、ダイアゴナル、スピン、パーキング |
| 最大。スピード | 2.0 m/s |
| 回転半径 | 0 mm |
| 昇級性 | 30度(無負荷)/20度(全負荷) |
| 保護 | IP55 |
| カテゴリ | モバイルロボットとAMR |
| リードタイム | 15-30 days |
値は 20 °C における公称値です。 CAD モデル、トルク曲線、コントローラー I/O マップのデータシートをダウンロードしてください。
どこで実行されるか
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
購入者の質問
主な仕様は何ですか?
モデル: TRLU-S4-100K、ペイロード: 100 kg、寸法: 718 x 560 x 340 mm。
リードタイムはどれくらいですか?
標準構成の場合は 15 ~ 30 日。引用時に確認されました。
カスタマイズできますか?
はい - OEM/ODM オプション、電圧、ツール、ブランドを適応させることができます。アプリケーションと提案のターゲット出力を送信します。
TRLU-S4-100K の価格提案を取得する
パート、ターゲット レート、宛先ポートを含めます。チャットボットではなくエンジニアが 48 時間以内に返信します。
同じカテゴリ
TROY エンジニアリングによるレビュー ·。仕様は見積ごとにサプライヤーのデータシートと照合して再チェックされます。