


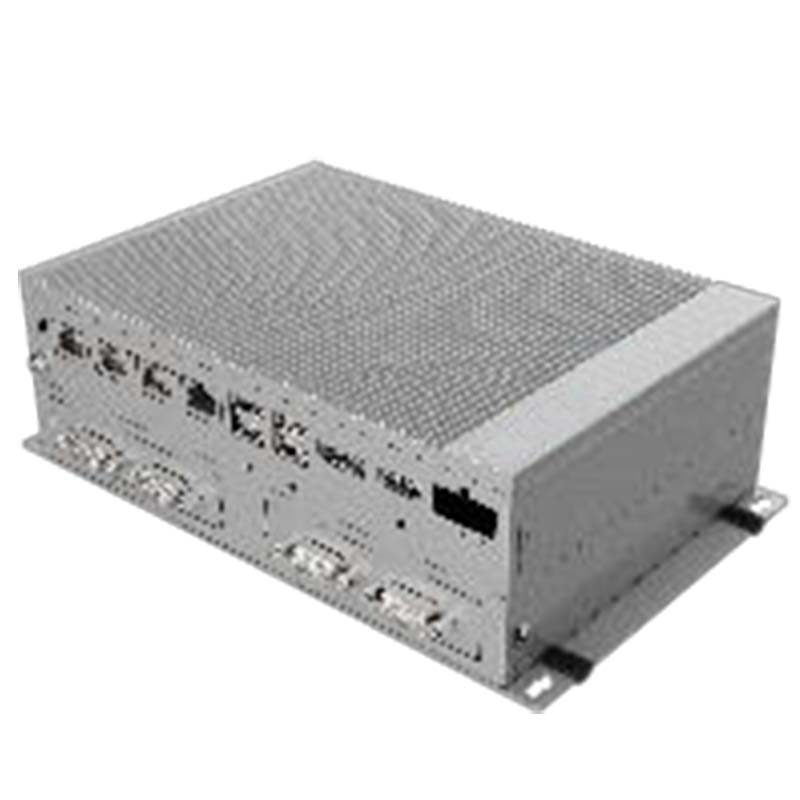
RPNS Control System
The TR-PNS_G01 is a CNC and motion product for CNC machining / motion control. Lead time is 15 days; pricing is quoted per configuration. Certifications: CE documentation on request.
- Model
- TR-PNS_G01
- Lead time
- 15 days
- Category
- CNC & Motion Control
What This Platform Is For
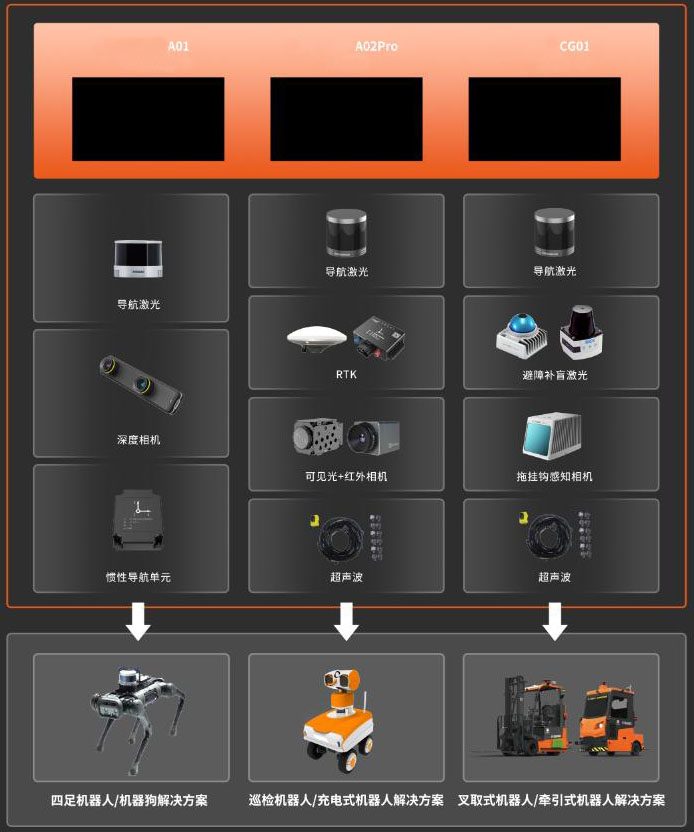
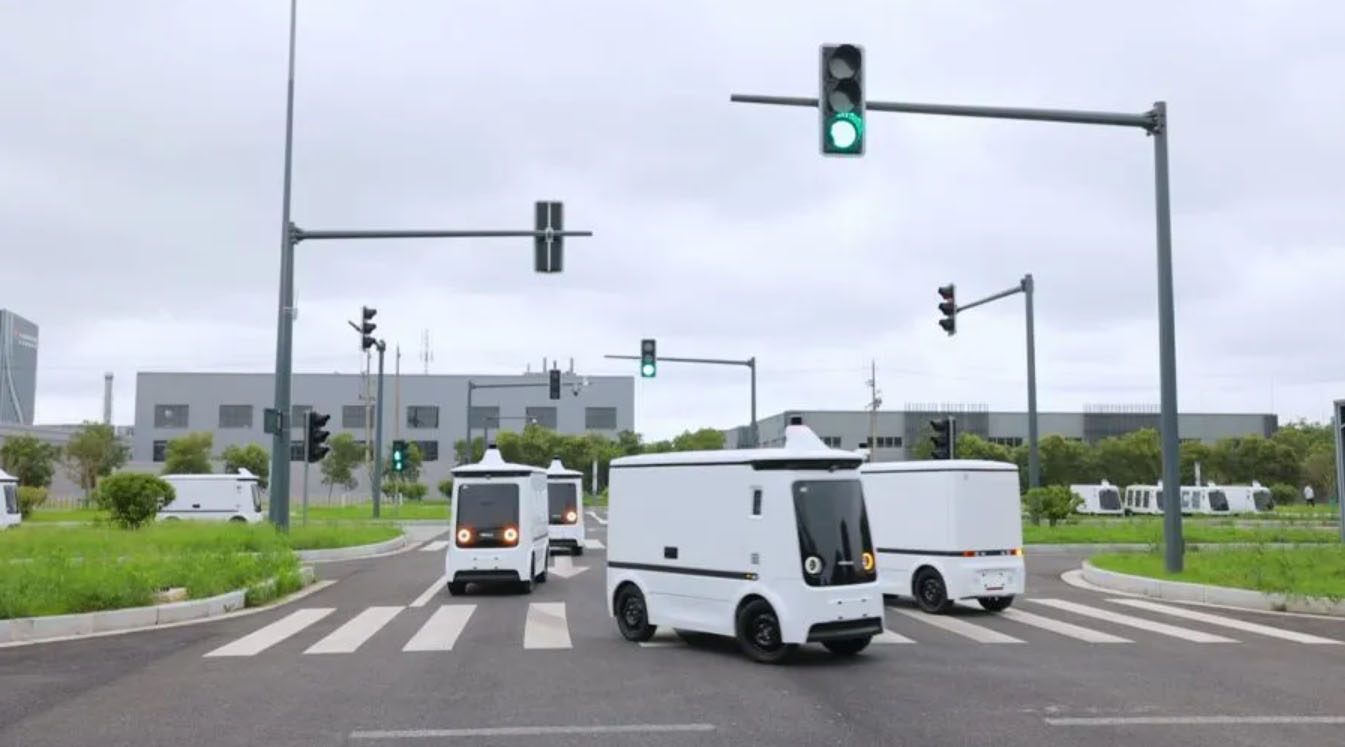
The RPNS control system (ROBOT POSITIONING NAVIGATION SYSTEM) has functions such as measurement, perception, navigation, positioning, and control. It adopts an open technical architecture and can be adapted to mainstream robot ECU\VCU, supporting manufacturers to complete secondary development on their own. The system supports seamless access to various downstream terminals.
Commercial Terms
| Quotation | Priced per configuration — reply within 48 hours |
|---|---|
| Lead time | 15 days |
| MOQ | 20 units |
| Origin | China |
| Port of loading | Shenzhen, China |
| Incoterm | FOB Shenzhen / CIF on request |
| Payment | 30% deposit, 70% before shipment |
| Warranty | 24 months standard, 36 months optional |
Product Details
Application notes, construction drawings and video from the TROY engineering file — the same documentation shipped with the quotation.
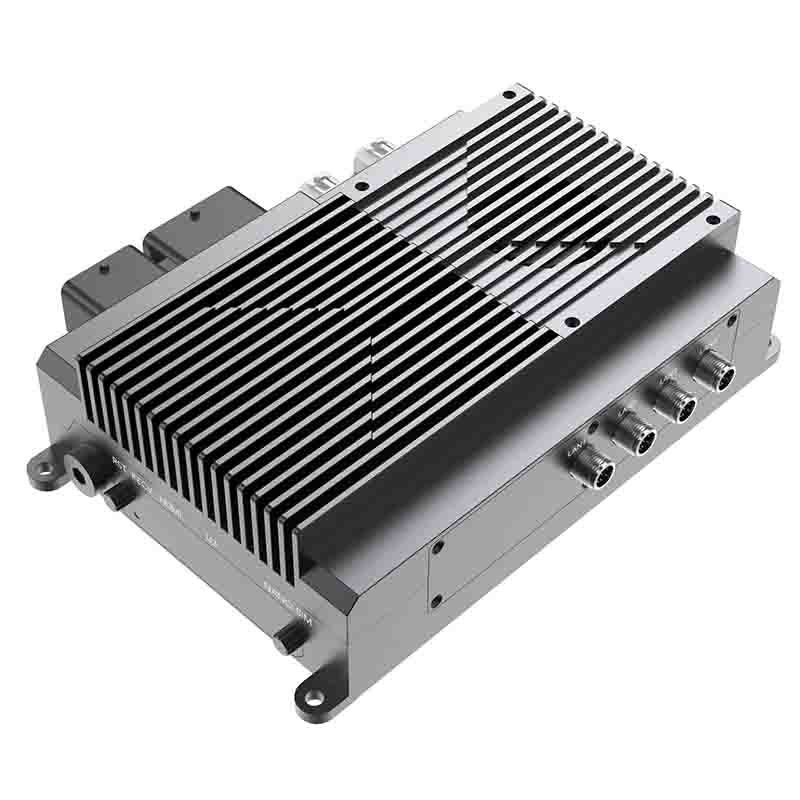
RPNS control system Details:
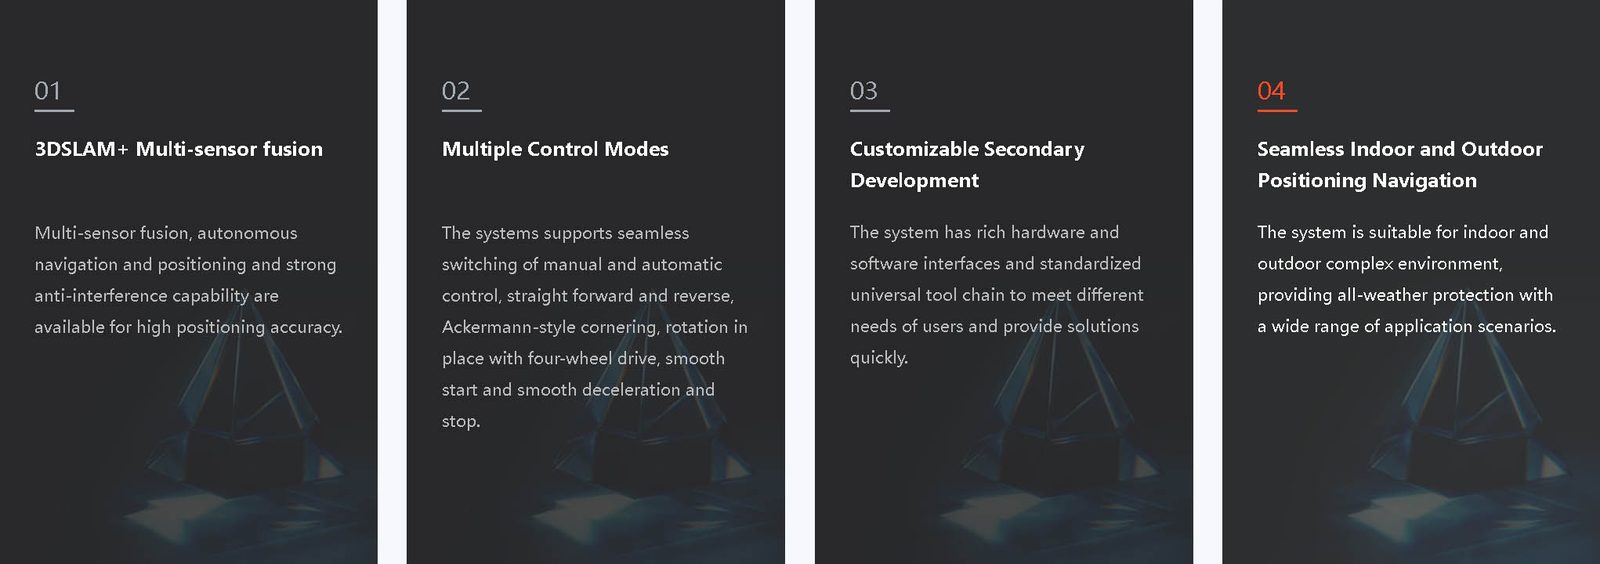
The upgraded Robot Movement System (RMS) introduces more advanced sensor fusion technology and enhanced 3DSLAM algorithm, which significantly improves the robot's perception ability and navigation accuracy in complex dynamic environments. The newly added autonomous learning module optimizes the navigation route through deep learning, enabling the robot to intelligently adapt to the walking path of different scenarios and achieve more efficient obstacle avoidance strategies.
The system is compatible with more types of chassis and supports more complex motion modes. At the same time, it integrates AI-driven environmental perception functions, and the robot can analyze and respond to environmental changes in real time to achieve smooth unmanned driving operations. The upgraded version is particularly suitable for all-weather, multi-scenario application requirements, whether it is logistics, security, or detection and rescue missions in extreme environments, it can provide intelligent and automated solutions.
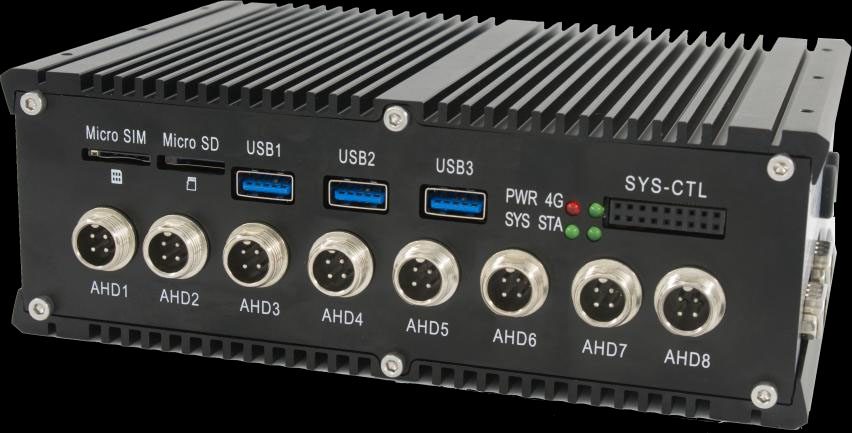
Multi-sensor fusion positioning (3DSLAM+RTK+IMU)
The built-in multi-sensor fusion autonomous positioning and navigation algorithm is suitable for various complex environments. It supports positioning and navigation in complex road conditions such as grass, sand, stone slabs and steel plates, and the positioning accuracy reaches centimeter level.
Quickly build high-precision maps
Supports fast mapping methods, can realize fully automatic three-dimensional high-precision navigation map drawing and three-dimensional scene modeling, the mapping operation is simple and easy, builds color three-dimensional point clouds, and has the ability to update maps autonomously.
Auto path planning and road network planning
Supports the optimal route sorting of random task points, can output global path planning and local path planning routes according to task points, supports free navigation between any points within the mapping range, and various planning methods such as tracking.
Perception and obstacle avoidance
Enable the robot to have autonomous perception capabilities, automatically avoid or bypass obstacles when encountering obstacles, autonomously update local path planning and find passable paths.
Portable remote control
It can be customized according to the protocol of the existing master control end, and can be adjusted and optimized according to needs, and portable information interaction with the master control end can be realized.
Supports the development of multiple chassis communication protocols
Customized development can be carried out according to the user's existing chassis protocol, and adjustments and optimizations can be made as needed to achieve real-time feedback and transmission of chassis and robot-related information.
Multiple control modes
Supports seamless switching between manual and automatic control; supports straight forward/reverse, Ackerman-style turning, and four-wheel eight-wheel drive rotation in situ; supports smooth starting, smooth deceleration and parking.
Automatic recovery of power-off memory
Data is uploaded to the robot supervision platform for unified storage, and supports historical playback.
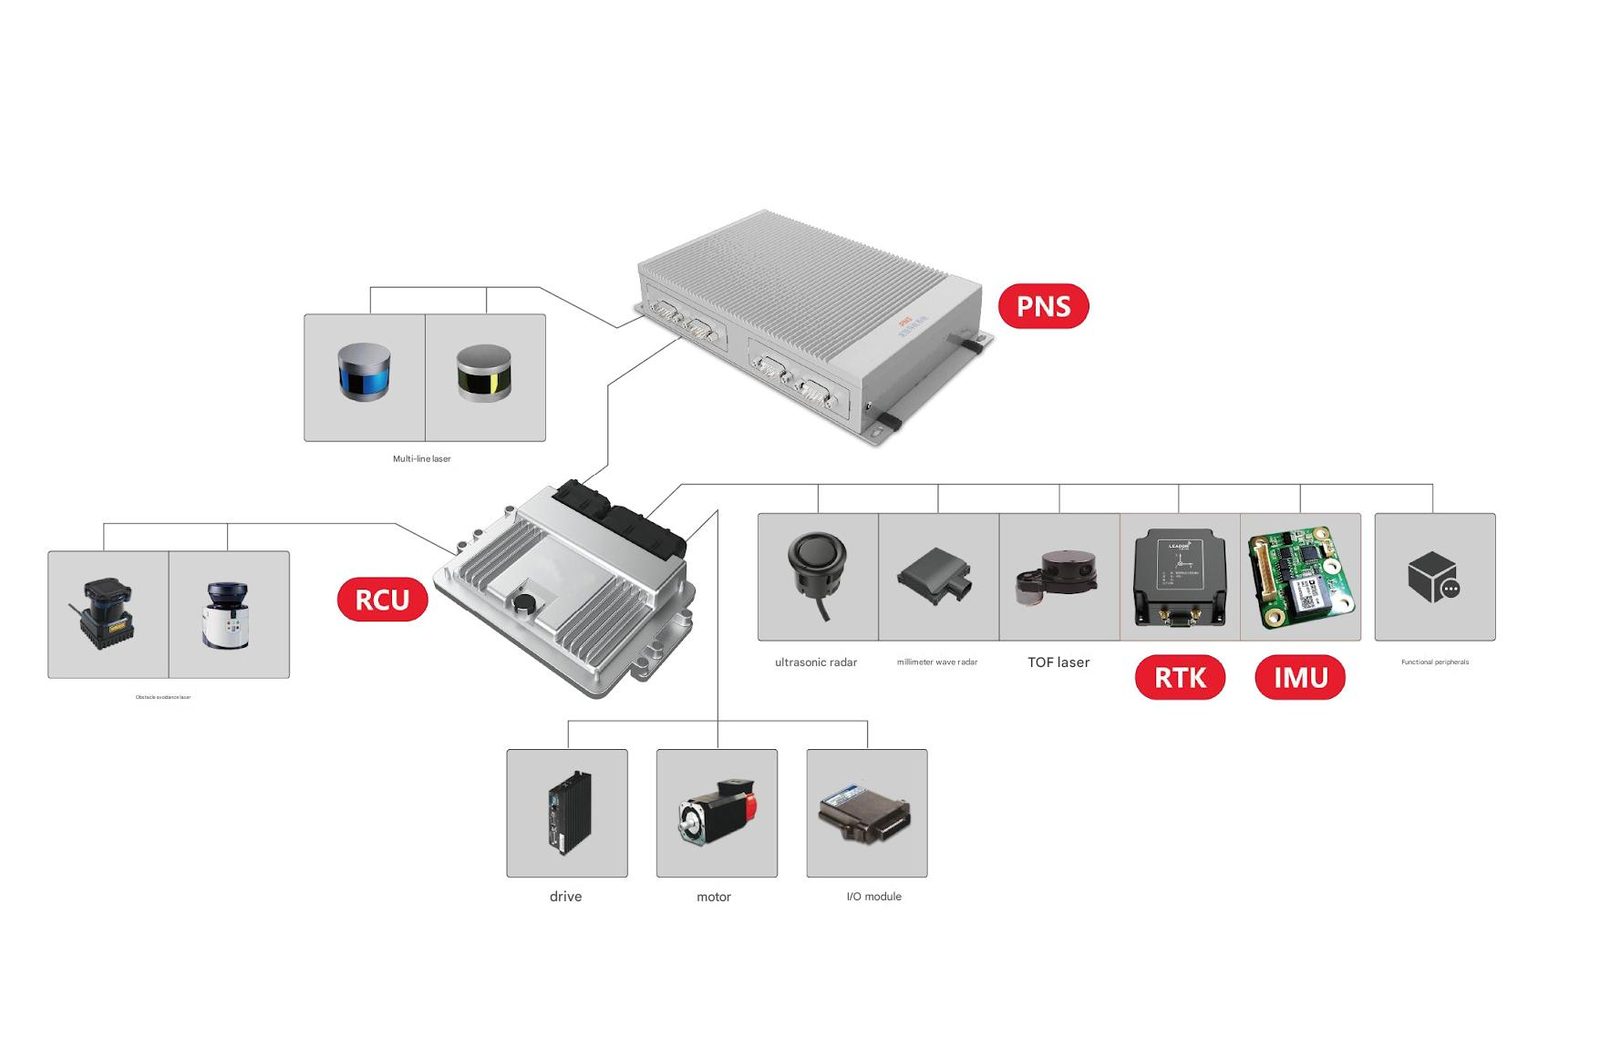
PNS Controller Basic performance:
Equipment model LD-PNS-A01
CPUI7-7600U, main frequency ≥2.5GHz
RCUIO output x 16/ IO input x 16/ CAN x 4/ RS232 * 11/ RS485 x 4
Navigation mode Multi-source fusion positioning (3D-SLAM/laser + inertial navigation + RTK, etc.)
Matching laser RS-LIDAR-16. VLP-16, LMS141. UTM-30, etc.
Applicable chassis Ackerman wheel, four-wheel differential, McDonnell wheel, four-wheel drive four-steering wheel, crawler chassis
Mapping range 500,000㎡
Visual range 100m
Navigation accuracy ± 10cm
Stop accuracy ≤±3cm
Positioning frequency ≤100Hz.
Full Technical Data
| Model | TR-PNS_G01 |
|---|---|
| Lead time | 15 days |
| Category | CNC & Motion Control |
Values are nominal at 20 °C. Download the datasheet for cad models, torque curves and controller I/O maps.
Where It Runs
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Buyer Questions
What are the key specifications of the TR-PNS_G01?
Model TR-PNS_G01. A full datasheet is available on request.
What is the lead time and MOQ for the TR-PNS_G01?
Lead time is 15 days; MOQ is 20 units.
How is the TR-PNS_G01 priced?
Pricing is quoted per configuration, including tooling and freight where applicable.
Get a Priced Proposal for TR-PNS_G01
Include the part, target rate and destination port. An engineer — not a chatbot — replies within 48 hours.
Same Category
Medium-Speed of Wire EDM Machine TR-RT80
AMR Controller SRC-880
Frameless Motors
Reviewed by TROY Engineering · . Specifications are re-checked against the supplier datasheet at every quotation.