


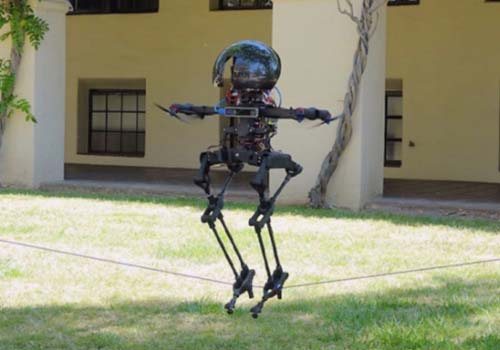
9 Ekim'de Kaliforniya Teknoloji Enstitüsü'nden araştırmacılar, iki ayaklı yürüme ve uçma hareketlerini birleştiren, onu son derece esnek hale getiren ve kayma gibi karmaşık hareketleri gerçekleştirebilen iki ayaklı bir robot geliştirdiler. Kaykay, ip yürüyüşü vb.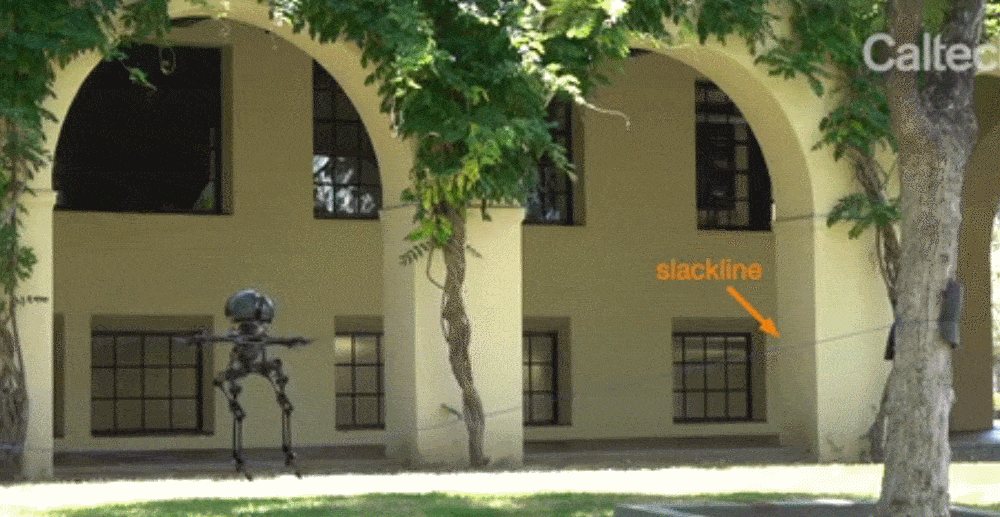
▲LEO walks along the rope tied between the treesThe design of this robot is inspired by the various behaviors of birds between walking and flying. The researchers named it LEONARDO (legs on the "legsonboarddrone" drone, or LEO for short). LEO can achieve fine control of its own balance through multi-articulated legs and propeller-based propellers.
The researchers stated in the research paper that LEO can perform various tasks that are difficult for humans and traditional robots to perform thanks to its hybrid motion capabilities. High-altitude operations will be one of the most suitable applications for LEO, such as the maintenance of high-voltage lines, and spray paint on high-altitude bridges.
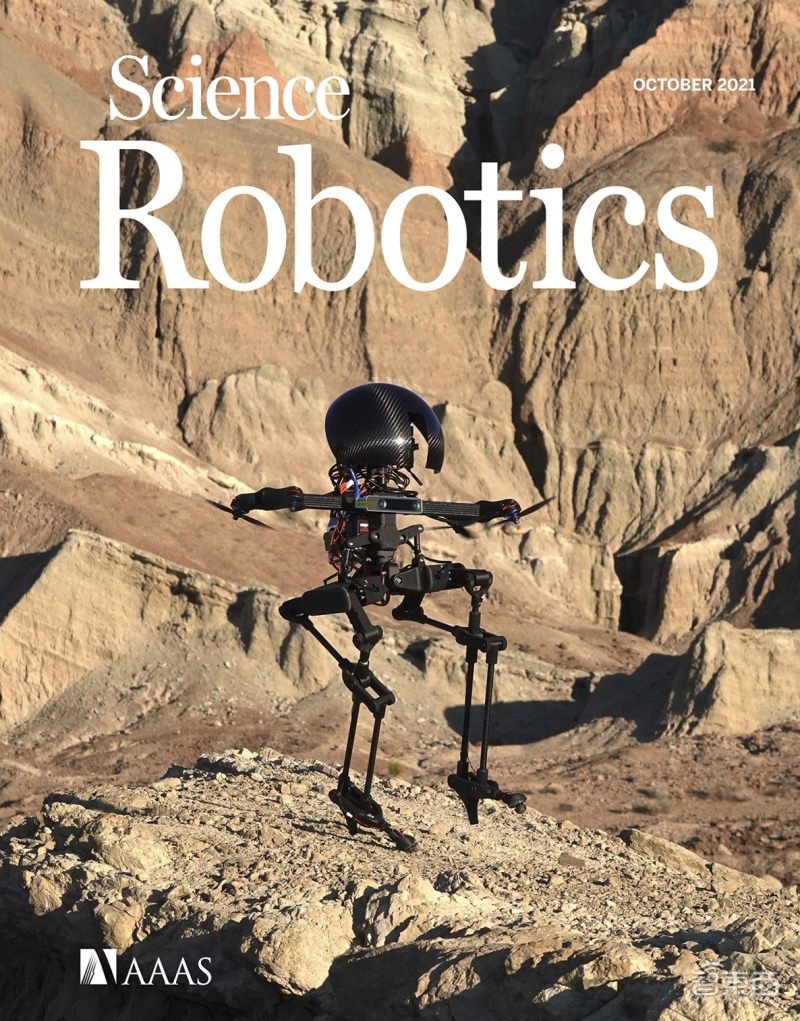
Araştırma bu çarşamba günü Science'ın alt dergisi Science Robotics'te yayınlandı ve bu ay derginin kapağında yer aldı. Tezin başlığı “Uçabilen, gevşek halatta hareket edebilen ve kaykay yapabilen iki ayaklı yürüyen robot (uçabilen, ipte yürüyebilen ve kaykay yapabilen iki ayaklı yürüyen robot)”.
 Birinci. Robotun koşup uçabilmesi için geleneksel hareket biçimini değiştirin
Mevcut robotların çoğu yerde veya havada hareket edebiliyor ancak bu iki hareket moduna sahip robot neredeyse yok. Ayrıca mevcut robotlar nadiren karmaşık görevleri yerine getirme yeteneğine sahiptir.
Ground robots have legged, wheeled, crawling and other forms. Among them, biped robots have attracted much attention because they have the appearance of humans and can walk, run, and jump like humans. However, the movement of ground robots is easily restricted by rugged terrain, and its application range is also limited to near the ground, making it difficult to work at heights.
Flying robots can ignore all kinds of rugged terrain and engage in aerial work such as remote sensing, delivery, search and rescue, and inspection. But its own shortcomings are also very obvious, such as high energy consumption, short flight time, and limited load capacity. In addition, because aerial robots need to take care of their own stability when working in the air, it is more difficult to physically interact with objects than ground robots.
Araştırmacılar bu iki robotun avantajlarını birleştirerek LEO'nun karışık hareket için yürüme ve uçma hareket modlarını birleştirmesine ve farklı hareket modları arasında geçiş yaparak çeşitli engebeli arazilere uyum sağlamasına olanak tanıdı.
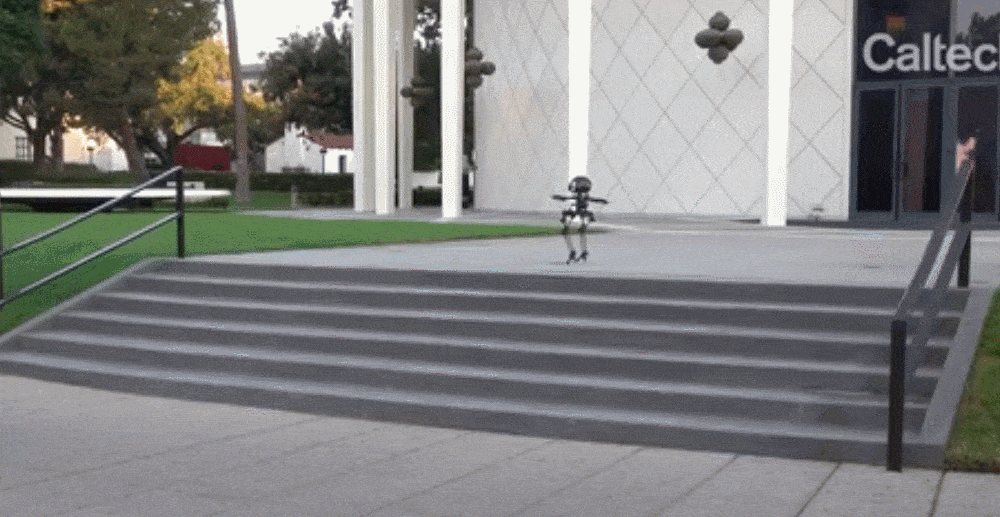
▲LEO merdivenlerin önüne doğru yürüdü ve merdivenlerden aşağı uçtuSaniye. 75 cm yüksekliği sadece 5 kg ve ağırlığı 4 pervanedir.
LEO'nun ağırlığı 2,58 kg ve yürürken toplam boyu 75 cm'dir. Temel olarak bir gövde, bir pervane tahrik sistemi ve sivri topuklu iki bacaktan oluşur.
In order to make it light enough, LEO’s leg structure uses carbon fiber tubes and 3D printed carbon fiber reinforced nylon joints to support ball bearings. Its two legs are symmetrical. Each leg has 3 servo motors. One is located at the pelvis and the other two are located at the front and back of the hip. The three servo motors jointly control the movement of the legs.
LEO'nun omuzları, yürüme ve uçuş hareketlerini stabilize etmek ve kontrol etmek için simetrik olarak yerleştirilmiş 4 pervane ile donatılmıştır.
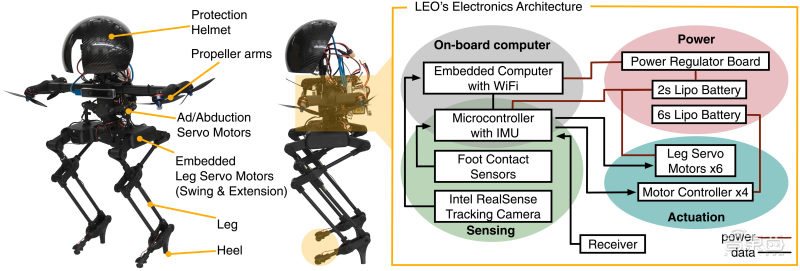
▲LEO'nun elektronik ve mekanik parçalarıLEO, yerleşik bilgisayarı ve sensör paketi aracılığıyla tamamen otonom olarak çalışabilir. Aşılması gereken engelin türüne bağlı olarak, yürümeyi veya uçmayı kullanmayı veya gerektiğinde ikisini karıştırmayı tercih edebilir.
Yürüme sırasında LEO'nun pervaneleri, yürürken dik durmasını sağlar ve bacak aktüatörleri, yürümeyi sağlamak için bacakların konumunu değiştirerek robotun ağırlık merkezini ileri doğru hareket ettirir. LEO, uçuş sırasında pervaneleri tek başına kullanabiliyor ve drone gibi uçabiliyor.Üçüncüsü, kayak yapmak, ipte yürümek, yüksek irtifa operasyonu en büyük uygulama yönüdür
Araştırmacılar, sporları birleştirme yeteneği sayesinde, ip üzerinde yürümek ve kaykay üzerinde kaymak gibi geleneksel robotlar için zor olan bazı eylemleri tamamlayabildiğini buldu. Ayrıca çok yüksek bir anti-parazit kabiliyetine sahiptir ve 3,8 m/s'ye varan rüzgar hızlarında bile stabil kalabilir.
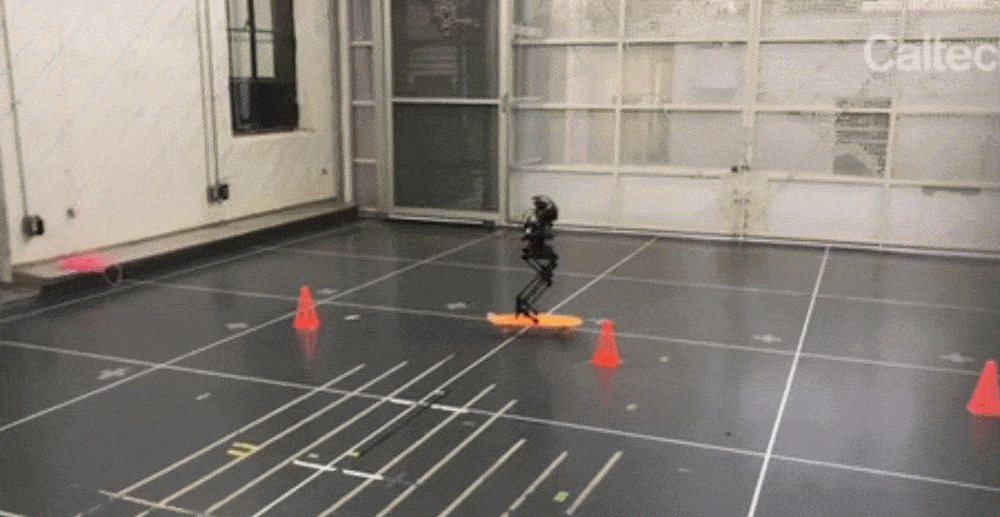
▲LEO kaykayı engelleri aşmak içinAraştırmacılar makalede şunları söyledi: "LEO için belki de en uygun uygulamalar yüksek irtifa operasyonlarını içeren uygulamalardır. Bu görevler genellikle insanlar için tehlikelidir ve bunların yerini robotların alması gerekir."
For example, the current high-voltage line inspection is done by professionals, who not only have to remotely inspect the line, but also go on the line for inspection and maintenance. Using LEO, there is no need to send personnel to climb up the wires, and only use the robot to fly onto high-voltage lines and walk along the wires for maintenance work. This will reduce maintenance costs and reduce the possibility of falling casualties.
In addition to these effects, the technology designed for LEO can also promote the development of adaptive landing gear systems. The research team envisions that future Martian rotorcraft can be equipped with legged landing gear so that they can maintain their balance when landing on sloping or uneven terrain, thereby reducing the risk of landing failure.
Next, the team plans to improve the performance of LEO by improving the leg design to make it stronger to support heavier robots and increase the thrust of the propeller. In addition, they also hope that LEO can be more autonomous, so that when the robot is walking on rugged terrain, it can understand how much weight the legs support and how much thrust is required by the propeller.
The researchers also plan to equip LEO with a newly developed control algorithm that uses a deep neural network to control the landing of the drone, allowing the robot to better understand the environment and decide on its own the best combination of walking, flying or mixed motion. The safest and least energy-consuming way to move from one place to another.
Çözüm:Robot Leo Koşabilir ve uçabilir, böylece iki ayaklı robotların uygulama alanı daha geniş olur
İnsan görünümü nedeniyle iki ayaklı robotlar, çeşitli görevleri tamamlamak için insanları taklit edebilir. Ancak çevre ve arazi koşulları nedeniyle birçok durumda iki ayaklı robotların hareketi kısıtlanacaktır.
LEO, iki ayaklı robotların koşup uçmasına olanak sağlamak için yürümeyi ve uçmayı birleştirerek arazideki engelleri aşıyor ve daha yaygın kullanılmasını sağlıyor. İnsansı Robot; Yapay Zeka Hizmet Robotu; Mobil cobot


