


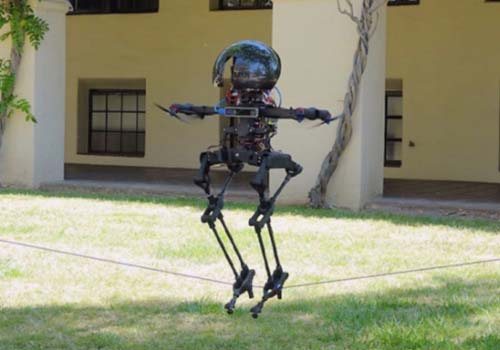
เมื่อวันที่ 9 ตุลาคม นักวิจัยจากสถาบันเทคโนโลยีแคลิฟอร์เนียได้พัฒนาหุ่นยนต์สองเท้าที่รวมการเคลื่อนไหวด้วยการเดินและการบินเข้าด้วยกัน ทำให้หุ่นยนต์มีความยืดหยุ่นอย่างมากและสามารถเคลื่อนไหวที่ซับซ้อนได้ เช่น การเลื่อน สเก็ตบอร์ด เดินไต่เชือก ฯลฯ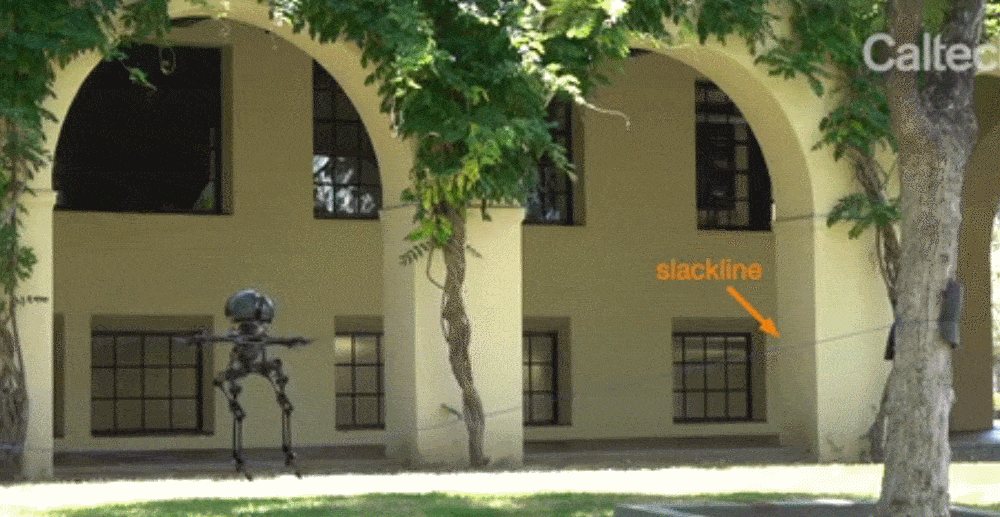
▲LEO walks along the rope tied between the treesThe design of this robot is inspired by the various behaviors of birds between walking and flying. The researchers named it LEONARDO (legs on the "legsonboarddrone" drone, or LEO for short). LEO can achieve fine control of its own balance through multi-articulated legs and propeller-based propellers.
The researchers stated in the research paper that LEO can perform various tasks that are difficult for humans and traditional robots to perform thanks to its hybrid motion capabilities. High-altitude operations will be one of the most suitable applications for LEO, such as the maintenance of high-voltage lines, and spray paint on high-altitude bridges.
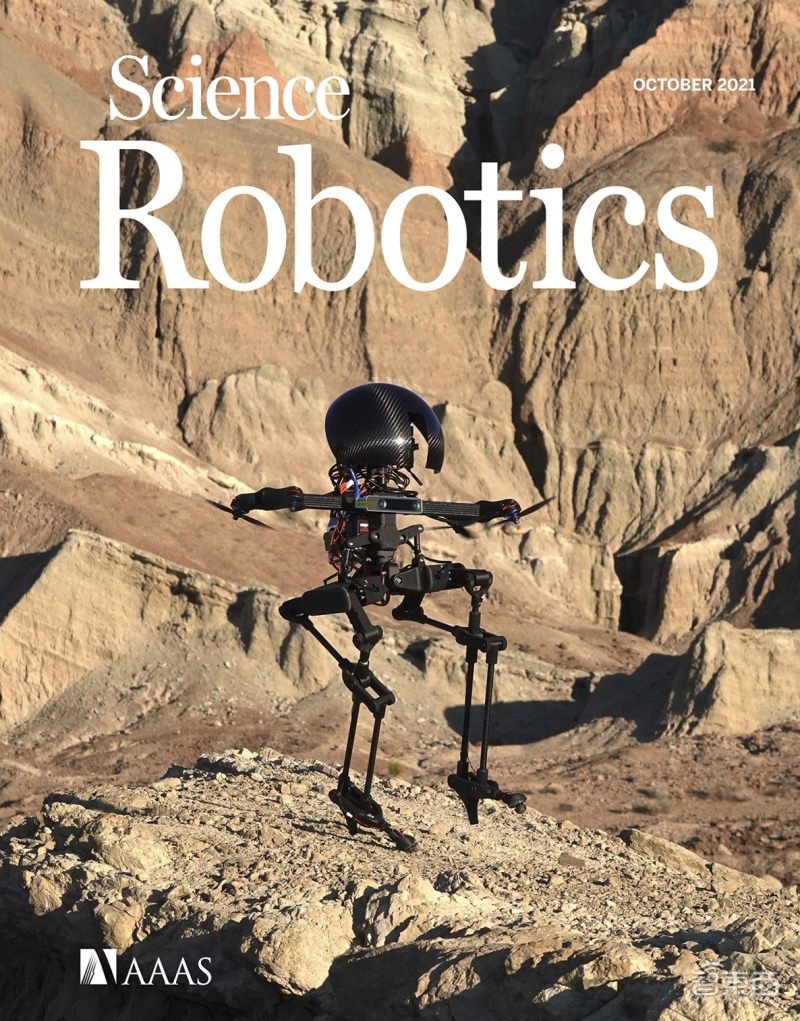
งานวิจัยนี้ตีพิมพ์ในวารสาร Science Robotics ซึ่งเป็นวารสารย่อยของ Science เมื่อวันพุธนี้ และปรากฏบนหน้าปกวารสารในเดือนนี้ วิทยานิพนธ์ชื่อ “Abipedalwalkingrobotthatcanfly, slackline, andskateboard (หุ่นยนต์เดินสองเท้าที่บินได้ เดินไต่เชือก และเล่นสเก็ตบอร์ดได้)”
 อันดับแรก. เปลี่ยนวิธีการเคลื่อนไหวแบบเดิมเพื่อให้หุ่นยนต์สามารถวิ่งและบินได้
หุ่นยนต์ที่มีอยู่ส่วนใหญ่สามารถเคลื่อนที่บนพื้นหรือในอากาศได้ แต่แทบไม่มีหุ่นยนต์ที่มีโหมดการเคลื่อนที่ทั้งสองแบบนี้เลย นอกจากนี้ หุ่นยนต์ที่มีอยู่แทบจะไม่สามารถทำงานที่ซับซ้อนได้
Ground robots have legged, wheeled, crawling and other forms. Among them, biped robots have attracted much attention because they have the appearance of humans and can walk, run, and jump like humans. However, the movement of ground robots is easily restricted by rugged terrain, and its application range is also limited to near the ground, making it difficult to work at heights.
Flying robots can ignore all kinds of rugged terrain and engage in aerial work such as remote sensing, delivery, search and rescue, and inspection. But its own shortcomings are also very obvious, such as high energy consumption, short flight time, and limited load capacity. In addition, because aerial robots need to take care of their own stability when working in the air, it is more difficult to physically interact with objects than ground robots.
นักวิจัยได้รวมข้อดีของหุ่นยนต์ทั้งสองเข้าด้วยกัน ทำให้ LEO สามารถรวมโหมดการเคลื่อนไหวแบบเดินและการบินสำหรับการเคลื่อนไหวแบบผสม และปรับให้เข้ากับภูมิประเทศที่ขรุขระต่างๆ โดยการสลับระหว่างโหมดการเคลื่อนไหวต่างๆ
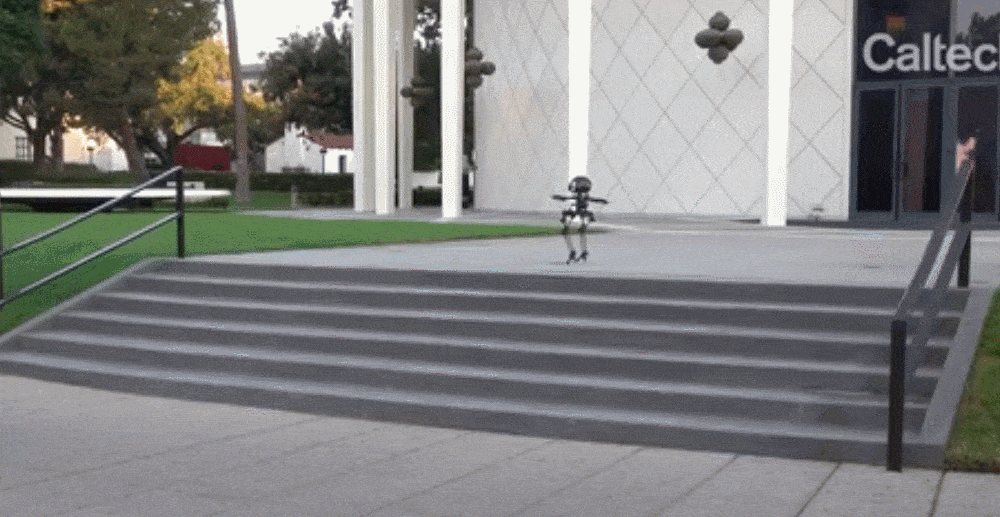
▲LEO เดินไปที่หน้าบันไดแล้วบินลงบันไดที่สอง. ส่วนสูง 75 ซม. หนักเพียง 5 กก. และน้ำหนัก 4 ใบพัด
น้ำหนักของ LEO คือ 2.58 กก. และความสูงโดยรวมเมื่อเดินคือ 75 ซม. โดยส่วนใหญ่ประกอบด้วยลำตัว ระบบขับเคลื่อนด้วยใบพัด และขา 2 ข้างที่มีส้นเท้าแหลม
In order to make it light enough, LEO’s leg structure uses carbon fiber tubes and 3D printed carbon fiber reinforced nylon joints to support ball bearings. Its two legs are symmetrical. Each leg has 3 servo motors. One is located at the pelvis and the other two are located at the front and back of the hip. The three servo motors jointly control the movement of the legs.
ไหล่ของ LEO ติดตั้งใบพัด 4 ใบที่วางเรียงกันอย่างสมมาตรเพื่อรักษาเสถียรภาพและควบคุมการเคลื่อนที่ของการเดินและการบิน
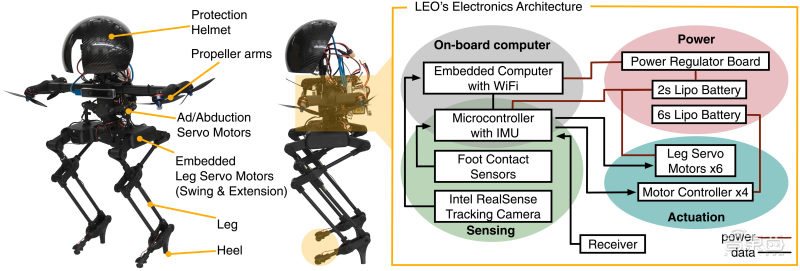
▲ชิ้นส่วนอิเล็กทรอนิกส์และกลไกของ LEOLEO สามารถทำงานโดยอัตโนมัติอย่างสมบูรณ์ผ่านคอมพิวเตอร์ออนบอร์ดและชุดเซ็นเซอร์ ขึ้นอยู่กับประเภทของสิ่งกีดขวางที่ต้องข้าม สามารถเลือกใช้ เดิน หรือ บิน หรือผสมทั้งสองได้ตามต้องการ
ในระหว่างการเดิน ใบพัดของ LEO ช่วยให้แน่ใจว่าหุ่นยนต์สามารถตั้งตรงขณะเดินได้ และตัวกระตุ้นที่ขาจะเคลื่อนจุดศูนย์ถ่วงของหุ่นยนต์ไปข้างหน้าโดยการเปลี่ยนตำแหน่งของขาเพื่อให้สามารถเดินได้ ในการบิน LEO สามารถใช้ใบพัดเพียงอย่างเดียวและบินได้เหมือนโดรนประการที่สาม การเล่นสกี การเดินไต่เชือก การทำงานบนที่สูงเป็นทิศทางการใช้งานที่ใหญ่ที่สุด
ด้วยความสามารถในการผสมผสานกีฬา นักวิจัยพบว่าสามารถดำเนินการบางอย่างที่ยากสำหรับหุ่นยนต์ทั่วไป เช่น การเดินบนเชือกและการเลื่อนบนสเก็ตบอร์ด และยังมีความสามารถในการป้องกันการรบกวนที่สูงมาก และยังสามารถรักษาเสถียรภาพได้แม้ที่ความเร็วลมสูงถึง 3.8 เมตร/วินาที
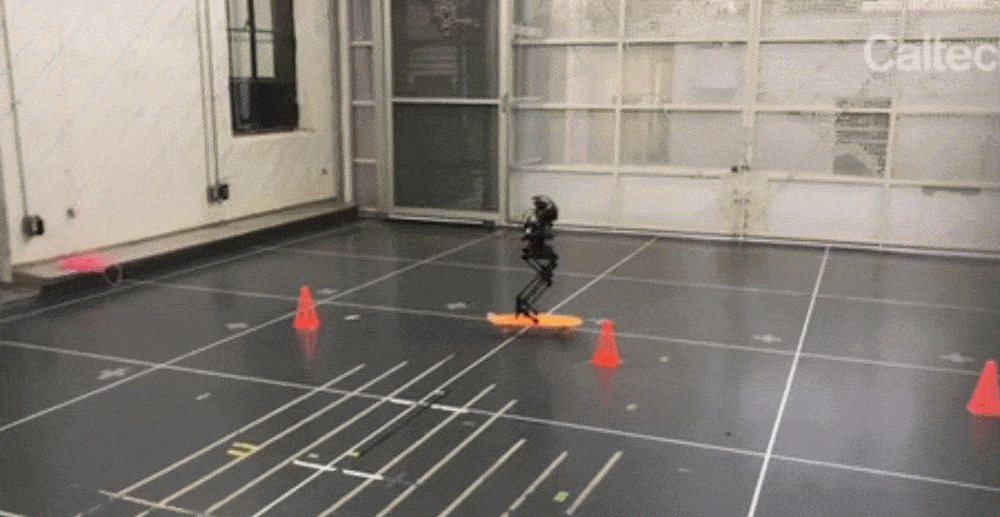
▲LEO สเก็ตบอร์ดเพื่อหลีกเลี่ยงอุปสรรคนักวิจัยกล่าวในรายงาน: "บางทีการใช้งานที่เหมาะสมที่สุดสำหรับ LEO อาจเป็นการใช้งานที่เกี่ยวข้องกับปฏิบัติการในที่สูง งานเหล่านี้มักจะเป็นอันตรายต่อมนุษย์และต้องใช้หุ่นยนต์มาแทนที่"
For example, the current high-voltage line inspection is done by professionals, who not only have to remotely inspect the line, but also go on the line for inspection and maintenance. Using LEO, there is no need to send personnel to climb up the wires, and only use the robot to fly onto high-voltage lines and walk along the wires for maintenance work. This will reduce maintenance costs and reduce the possibility of falling casualties.
In addition to these effects, the technology designed for LEO can also promote the development of adaptive landing gear systems. The research team envisions that future Martian rotorcraft can be equipped with legged landing gear so that they can maintain their balance when landing on sloping or uneven terrain, thereby reducing the risk of landing failure.
Next, the team plans to improve the performance of LEO by improving the leg design to make it stronger to support heavier robots and increase the thrust of the propeller. In addition, they also hope that LEO can be more autonomous, so that when the robot is walking on rugged terrain, it can understand how much weight the legs support and how much thrust is required by the propeller.
The researchers also plan to equip LEO with a newly developed control algorithm that uses a deep neural network to control the landing of the drone, allowing the robot to better understand the environment and decide on its own the best combination of walking, flying or mixed motion. The safest and least energy-consuming way to move from one place to another.
บทสรุป:Robot Leo สามารถวิ่งและบินได้ เพื่อให้พื้นที่การใช้งานของหุ่นยนต์สองเท้ากว้างขึ้น
เนื่องจากรูปร่างหน้าตาของมนุษย์ หุ่นยนต์สองเท้าจึงสามารถเลียนแบบมนุษย์เพื่อทำงานต่างๆ ได้สำเร็จ อย่างไรก็ตาม เนื่องจากสภาพแวดล้อมและภูมิประเทศ การเคลื่อนไหวของหุ่นยนต์สองเท้าจะถูกจำกัดในหลายกรณี
LEO ผสมผสานการเดินและการบินเพื่อให้หุ่นยนต์สองขาวิ่งและบินได้ ทำลายอุปสรรคของภูมิประเทศและทำให้มีการใช้กันอย่างแพร่หลายมากขึ้น หุ่นยนต์ฮิวแมนนอยด์ หุ่นยนต์บริการ AI โคบอทเคลื่อนที่


