


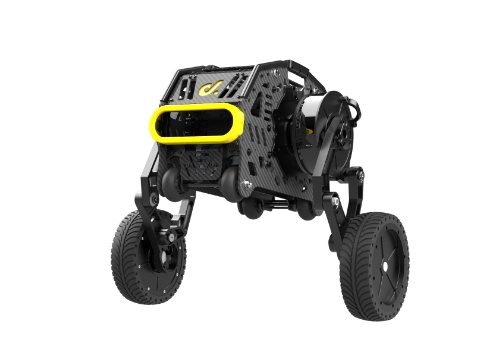
이륜족 로봇은 전통적인 바퀴형 AGV와 다족형 로봇의 특성을 결합해 안정성과 균형감이 탁월하게 융합된 로봇이다.
이륜 다리 로봇 헤드의 안정적인 작동은 주로 다리의 4바 구조에 기반합니다. Xingtian 로봇의 다리는 서로 독립적이며 별도로 펴거나 구부릴 수 있으므로 매우 펑크한 다리 흔들기 동작을 수행할 수 있습니다.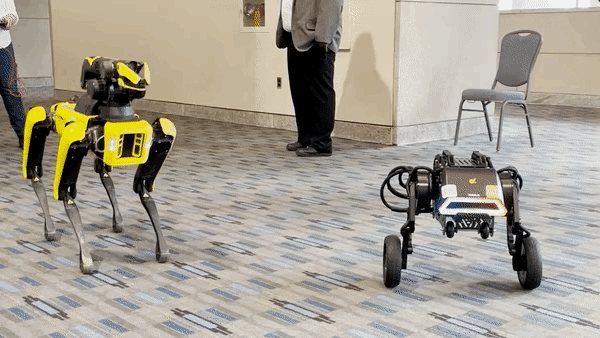 성능 측면에서 Xingtian 로봇은 바퀴와 다리의 조합으로 인해 강력한 조작성과 유연성을 갖춘 매우 컴팩트한 로봇이 되었습니다.
The Xingtian robot can use wheels to cross flat terrain at high speed, and can also use two-degree-of-freedom mechanical legs to cross some obstacles. This form of the Xingtian robot not only fully utilizes the speed advantage of wheeled AGVs, but also maintains the mobility and obstacle-crossing advantage of foot-type robots. The overall movement is flexible and the jump is more agile.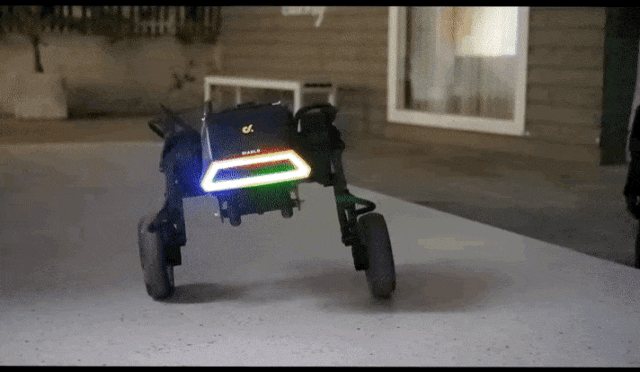 일부 제품 테스트에 따르면 Xingtian 로봇의 최대 측면 점프 높이는 8cm, 제자리 최대 점프 높이는 14cm이며, 5cm 장애물을 원활하게 횡단할 수 있고, 한 발로 10cm 장애물을 횡단할 수 있습니다.
그만큼이륜발 로봇has excellent jumping performance, so it can perform better in a wider range of indoor and outdoor scenes. For example, when inspecting indoors and outdoors, it can move quickly on flat ground with wheels, and can jump over obstacles on stairs and other terrains, greatly improving terrain adaptability.


