


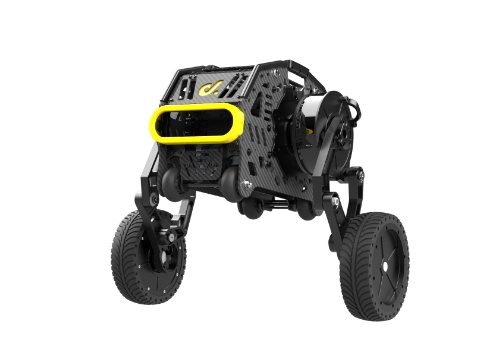
दो-पहिया पैरों वाला रोबोट पारंपरिक पहिए वाले एजीवी और बहु-पैर वाले रोबोट की विशेषताओं को जोड़ता है, और इसमें स्थिरता और संतुलन का उत्कृष्ट मिश्रण है।
दो-पहिया पैरों वाले रोबोट के सिर का स्थिर संचालन काफी हद तक पैरों की चार-बार संरचना पर आधारित है। ज़िंगटियन रोबोट के पैर एक-दूसरे से स्वतंत्र हैं और इन्हें अलग-अलग सीधा या मोड़ा जा सकता है, इसलिए यह बहुत ही पंक लेग शेकिंग मूवमेंट कर सकता है।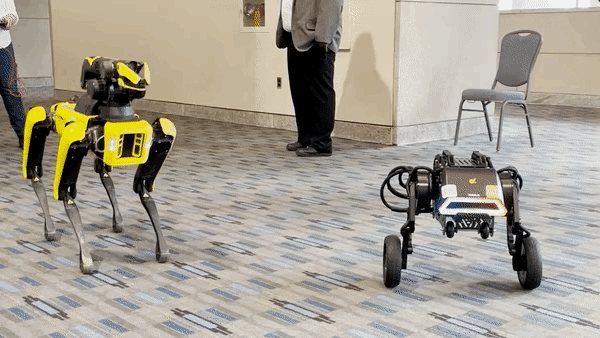 प्रदर्शन के संदर्भ में, पहियों और पैरों का संयोजन जिंगटियन रोबोट को मजबूत निष्क्रियता और लचीलेपन के साथ बहुत कॉम्पैक्ट बनाता है।
The Xingtian robot can use wheels to cross flat terrain at high speed, and can also use two-degree-of-freedom mechanical legs to cross some obstacles. This form of the Xingtian robot not only fully utilizes the speed advantage of wheeled AGVs, but also maintains the mobility and obstacle-crossing advantage of foot-type robots. The overall movement is flexible and the jump is more agile.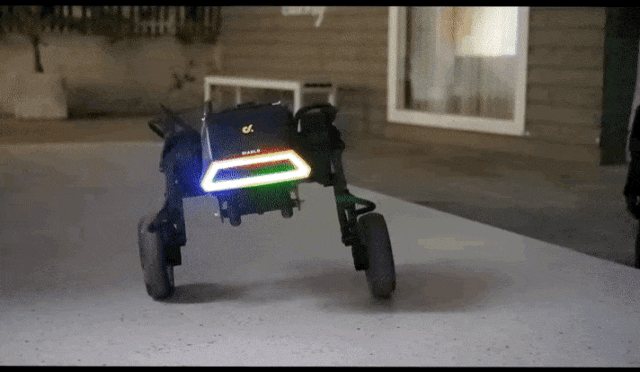 कुछ उत्पाद परीक्षणों के अनुसार, जिंगटियन रोबोट की अधिकतम पार्श्व कूद ऊंचाई 8 सेमी है, जगह में अधिकतम कूद ऊंचाई 14 सेमी है, यह 5 सेमी बाधा को आसानी से पार कर सकता है, और एक पैर के साथ 10 सेमी बाधा को पार कर सकता है।
The दोपहिया पैर वाला रोबोटhas excellent jumping performance, so it can perform better in a wider range of indoor and outdoor scenes. For example, when inspecting indoors and outdoors, it can move quickly on flat ground with wheels, and can jump over obstacles on stairs and other terrains, greatly improving terrain adaptability.


