


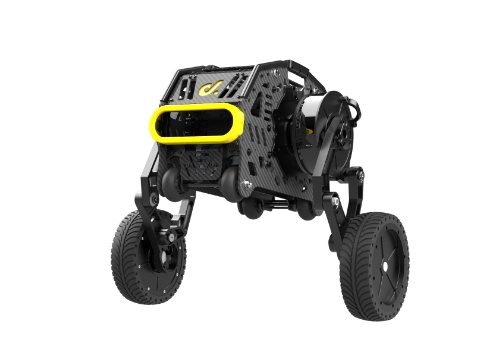
يجمع الروبوت ذو العجلتين بين خصائص AGV التقليدية ذات العجلات والروبوت متعدد الأرجل، ويتميز بمزيج ممتاز من الاستقرار والتوازن.
يعتمد التشغيل المستقر لرأس الروبوت ذو الأرجل ذات العجلتين إلى حد كبير على هيكل الأرجل ذو الأربعة أشرطة. أرجل الروبوت Xingtian مستقلة عن بعضها البعض ويمكن تقويمها أو ثنيها بشكل منفصل، حتى تتمكن من أداء حركات اهتزاز الساق.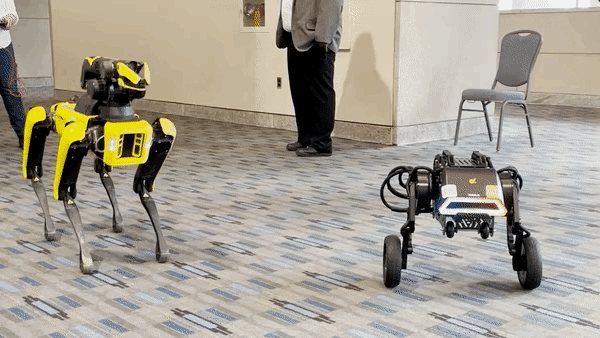 من حيث الأداء، فإن الجمع بين العجلات والأرجل يجعل روبوت Xingtian مضغوطًا للغاية، مع قدرة قوية على المرور والمرونة.
The Xingtian robot can use wheels to cross flat terrain at high speed, and can also use two-degree-of-freedom mechanical legs to cross some obstacles. This form of the Xingtian robot not only fully utilizes the speed advantage of wheeled AGVs, but also maintains the mobility and obstacle-crossing advantage of foot-type robots. The overall movement is flexible and the jump is more agile.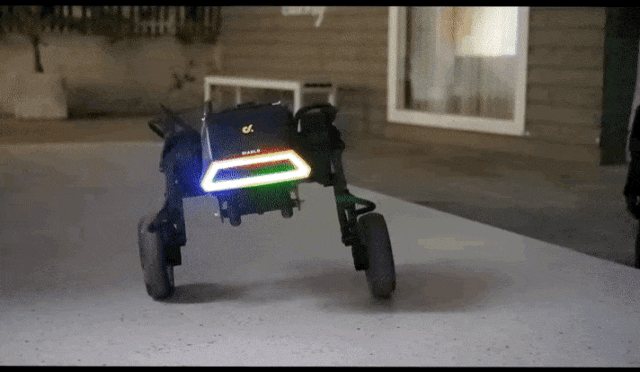 وفقًا لبعض اختبارات المنتج، فإن الحد الأقصى لارتفاع القفز الجانبي لروبوت Xingtian هو 8 سم، والحد الأقصى لارتفاع القفز في مكانه هو 14 سم، ويمكنه عبور عائق 5 سم بسلاسة، ويمكنه عبور عائق 10 سم بقدم واحدة.
الروبوت قدم ذو عجلتينhas excellent jumping performance, so it can perform better in a wider range of indoor and outdoor scenes. For example, when inspecting indoors and outdoors, it can move quickly on flat ground with wheels, and can jump over obstacles on stairs and other terrains, greatly improving terrain adaptability.


