


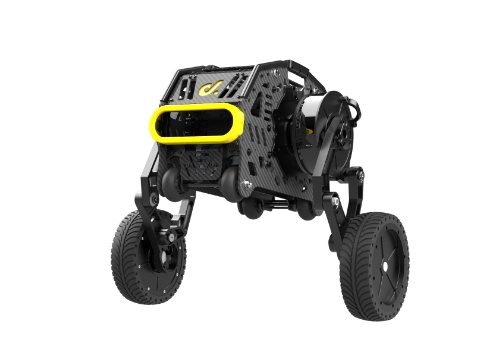
従来の車輪型AGVと多脚ロボットの特徴を併せ持ち、安定性とバランス性を優れた融合した二輪脚ロボットです。
二輪脚型ロボットヘッドの安定動作は、脚部の4本棒構造が大きく貢献しています。 Xingtian ロボットの脚はそれぞれ独立しており、別々に伸ばしたり曲げたりできるため、非常にパンクな脚振り動作を実行できます。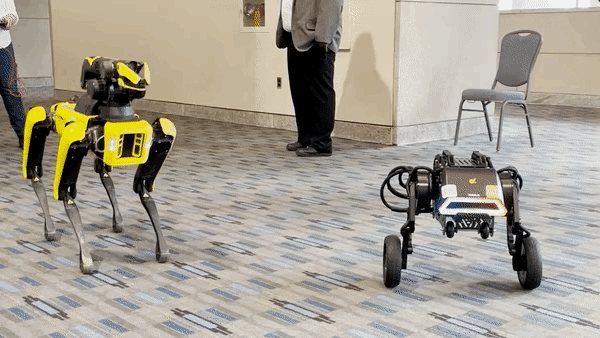 性能の面では、車輪と脚の組み合わせにより、Xingtian ロボットは非常にコンパクトになり、強力な通過性と柔軟性を備えています。
The Xingtian robot can use wheels to cross flat terrain at high speed, and can also use two-degree-of-freedom mechanical legs to cross some obstacles. This form of the Xingtian robot not only fully utilizes the speed advantage of wheeled AGVs, but also maintains the mobility and obstacle-crossing advantage of foot-type robots. The overall movement is flexible and the jump is more agile.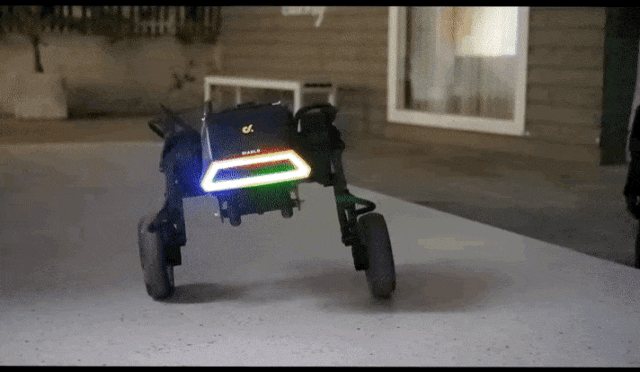 いくつかの製品テストによると、Xingtianロボットの最大横ジャンプ高さは8cm、その場での最大ジャンプ高さは14cm、片足で5cmの障害物をスムーズに越えることができ、10cmの障害物を越えることができます。
の二輪足ロボットhas excellent jumping performance, so it can perform better in a wider range of indoor and outdoor scenes. For example, when inspecting indoors and outdoors, it can move quickly on flat ground with wheels, and can jump over obstacles on stairs and other terrains, greatly improving terrain adaptability.


