


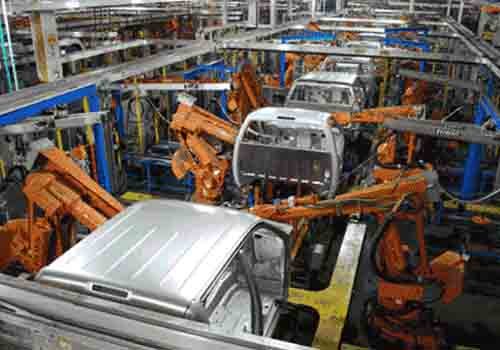
Robots industriels are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology. Le premier robot industriel conforme à la norme ISO a été produit par Bill Griffith Taylor en 1937 et publié dans le magazine Meccano en mars 1938.
Ce robot industriel en forme de grue est composé de pièces Meccano et alimenté par un seul moteur électrique. Ce robot industriel peut empiler des blocs de bois de manière préprogrammée. Le milieu du XXe siècle a été une période critique pour la recherche et le développement de robots industriels.
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
En 1959, le premier robot industriel d'Unimation est né aux États-Unis, ouvrant ainsi une nouvelle ère dans le développement des robots.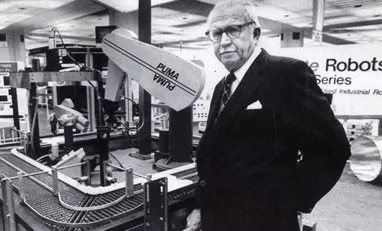 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
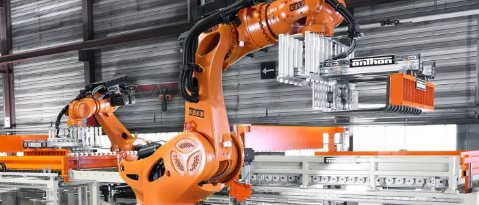
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
Le contrôleur informatique peut saisir et stocker divers programmes pour déterminer la connexion et la relation de la séquence de travail. Capteurs : le robot utilise des capteurs pour reconnaître et évaluer les changements de position, les différences de style et les obstacles ou dysfonctionnements des systèmes externes. Système de rétroaction : Le dispositif de rétroaction du robot industriel peut mesurer la position, la vitesse de déplacement et l'accélération de chaque axe.
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——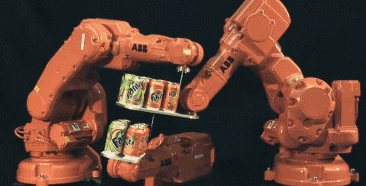
▲ Le robot industriel ABB a relevé le défi « Fanta Tank » Configuration articulée : Le bras articulé est le bras robot le plus courant, très similaire à un bras humain. Généralement des machines à six axes, elles offrent une redondance et se déplacent plus facilement.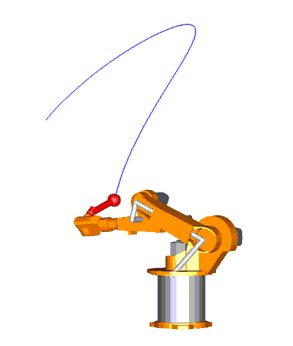 ▲ Configuration articulaire articulée
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.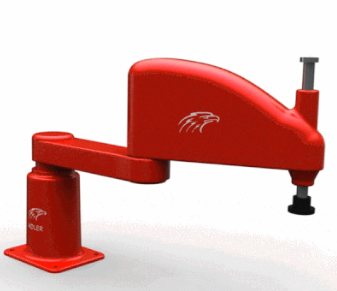
▲ Configuration conjointe de configuration SCARA
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple robots à trois axesqui contiennent uniquement des entraînements linéaires à trois broches.
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——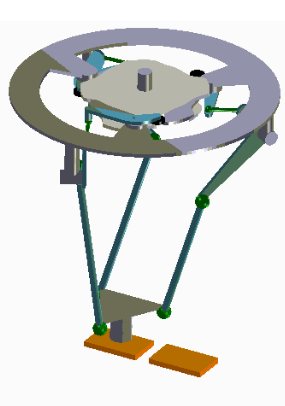
▲ Robot industriel parallèleUn mécanisme parallèle peut être défini comme un mécanisme en boucle fermée dans lequel la plate-forme mobile et la plate-forme fixe sont reliées par au moins deux chaînes cinématiques indépendantes, le mécanisme a deux degrés de liberté ou plus et est entraîné en parallèle.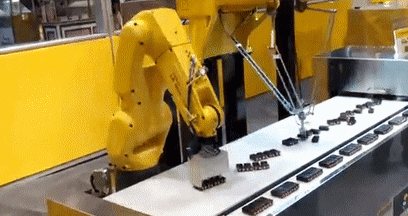 Les applications typiques des robots industriels comprennent le soudage, la peinture, l'assemblage, la collecte et le placement (comme l'emballage, la palettisation et le SMT), l'inspection et les tests de produits, etc. ; toutes les tâches sont accomplies avec une efficacité, une durabilité, une rapidité et une précision élevées.
 Afin d'effectuer les tâches de travail avec plus de précision, les robots industriels incluent généralement des sous-systèmes de vision industrielle comme capteurs de vision, connectés à de puissants ordinateurs ou contrôleurs.
For modern industrial robots, robots d'intelligence artificiellesont devenus des équipements de plus en plus importants.


