


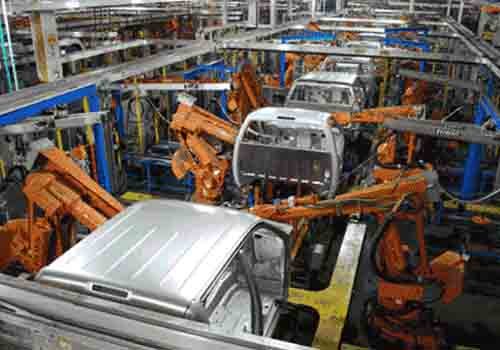
Endüstriyel robotlar are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology.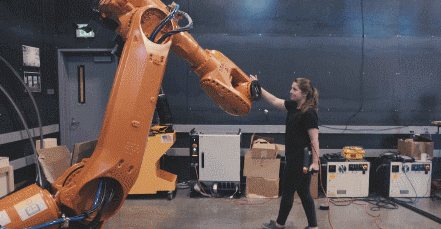 ISO standardına uygun ilk endüstriyel robot, 1937 yılında Bill Griffith Taylor tarafından üretilmiş ve Mart 1938'de Meccano dergisinde yayınlanmıştır.
Vinç benzeri bu endüstriyel robot, Meccano parçalarından yapılmış ve tek bir elektrik motoruyla çalışıyor. Bu endüstriyel robot, ahşap blokları önceden programlanmış bir şekilde istifleyebilir.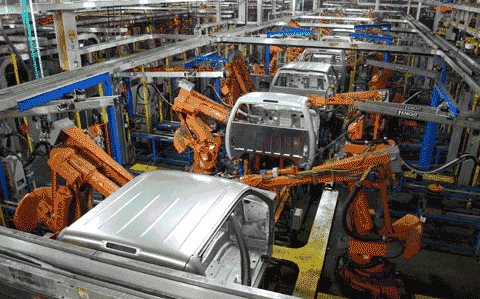 20. yüzyılın ortaları endüstriyel robotların araştırılması ve geliştirilmesi açısından kritik bir dönemdi.
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
1959'da Unimation'un ilk endüstriyel robotu Amerika Birleşik Devletleri'nde doğdu ve robot geliştirmede yeni bir çağ açtı.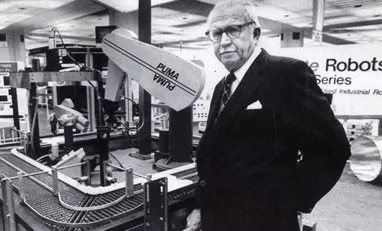 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
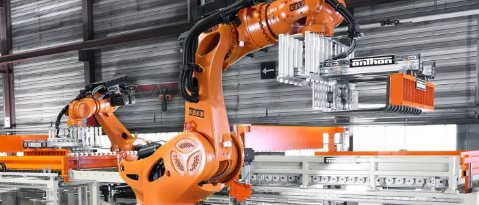
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
Bilgisayar denetleyicisi, iş sırasının bağlantısını ve ilişkisini belirlemek için çeşitli programları girebilir ve saklayabilir. Sensörler: Robot, konum değişikliklerini, stil farklılıklarını ve harici sistemlerdeki engelleri veya arızaları tanımak ve değerlendirmek için sensörleri kullanır.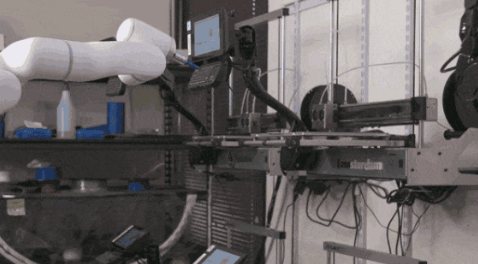 Geri bildirim sistemi: Endüstriyel robotun geri bildirim cihazı, her eksenin konumunu, hareket hızını ve ivmesini ölçebilir.
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——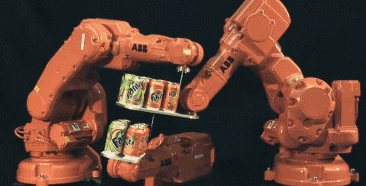
▲ ABB endüstriyel robotu "Fanta Tank" görevini tamamladı Mafsallı konfigürasyon: Mafsallı kol, insan koluna çok benzeyen en yaygın robot koludur. Genellikle altı eksenli makineler yedeklilik sağlar ve daha düzgün hareket ederler.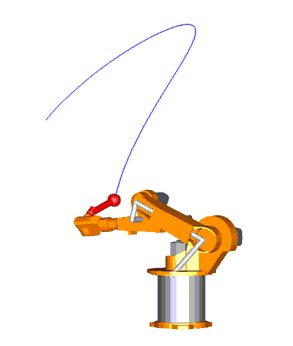 ▲ Mafsallı bağlantı konfigürasyonu
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.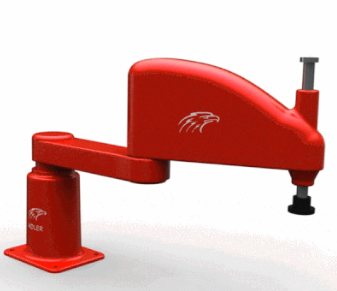
▲ SCARA konfigürasyonu ortak konfigürasyonu
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple üç eksenli robotlaryalnızca üç iş miline sahip doğrusal tahrikler içerir.
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——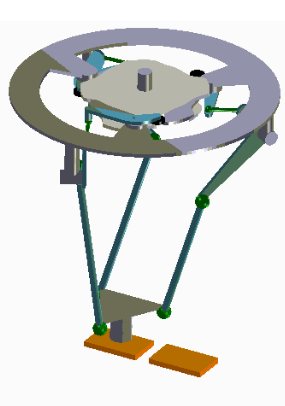
▲ Paralel endüstriyel robotParalel mekanizma, hareketli platform ile sabit platformun en az iki bağımsız kinematik zincirle bağlandığı, mekanizmanın iki veya daha fazla serbestlik derecesine sahip olduğu ve paralel olarak tahrik edildiği kapalı döngü mekanizması olarak tanımlanabilir.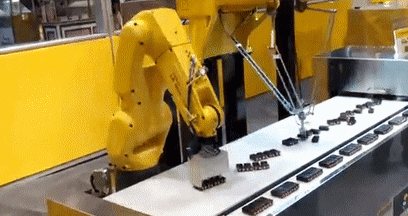 Endüstriyel robotların tipik uygulamaları arasında kaynak, boyama, montaj, toplama ve yerleştirme (paketleme, paletleme ve SMT gibi), ürün denetimi ve testi vb.; tüm görevler yüksek verimlilik, dayanıklılık, hız ve doğrulukla tamamlanır.
 Endüstriyel robotlar, iş görevlerini daha doğru bir şekilde gerçekleştirmek için genellikle güçlü bilgisayarlara veya kontrolörlere bağlı görüntü sensörleri olarak makine görüşü alt sistemlerini içerir.
For modern industrial robots, yapay zeka robotlarıgiderek daha önemli bir ekipman haline geldi.


