


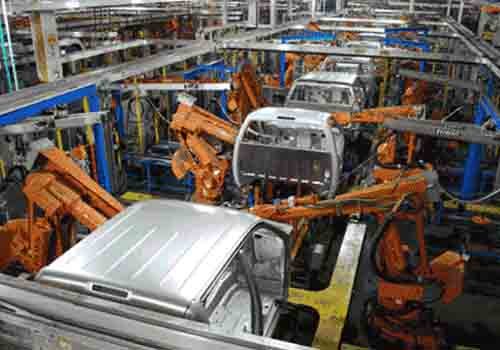
الروبوتات الصناعية are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology.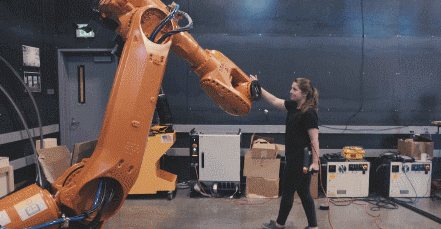 تم إنتاج أول روبوت صناعي مطابق لمعايير ISO بواسطة بيل جريفيث تايلور في عام 1937 ونشر في مجلة ميكانو في مارس 1938.
هذا الروبوت الصناعي الذي يشبه الرافعة مصنوع من أجزاء ميكانو ويعمل بمحرك كهربائي واحد. يستطيع هذا الروبوت الصناعي تكديس الكتل الخشبية بطريقة مبرمجة مسبقًا. كان منتصف القرن العشرين فترة حرجة لأبحاث وتطوير الروبوتات الصناعية.
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
في عام 1959، وُلد أول روبوت صناعي لشركة Unimation في الولايات المتحدة، فاتحًا حقبة جديدة من تطوير الروبوت.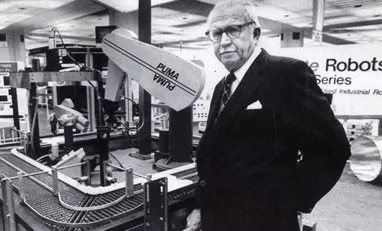 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
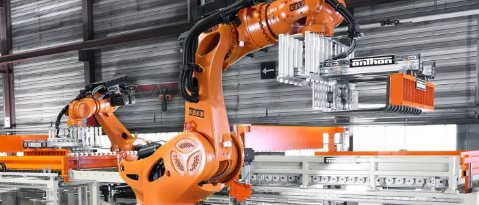
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
يمكن لوحدة التحكم في الكمبيوتر إدخال وتخزين برامج مختلفة لتحديد الاتصال والعلاقة بين تسلسل العمل. أجهزة الاستشعار: يستخدم الروبوت أجهزة استشعار للتعرف على وتقييم تغيرات الموضع، واختلافات الأسلوب، والعقبات أو الأعطال في الأنظمة الخارجية. نظام التغذية الراجعة: يمكن لجهاز التغذية الراجعة الخاص بالروبوت الصناعي قياس موضع وسرعة الحركة والتسارع لكل محور.
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——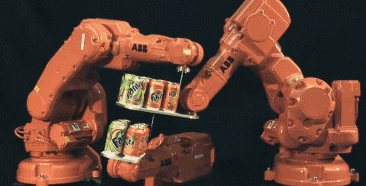
▲ أكمل الروبوت الصناعي ABB تحدي "Fanta Tank" التكوين المفصلي: الذراع المفصلية هي ذراع الروبوت الأكثر شيوعًا، وهي تشبه إلى حد كبير الذراع البشرية. عادةً ما تكون الآلات ذات ستة محاور توفر التكرار وتتحرك بشكل أكثر سلاسة.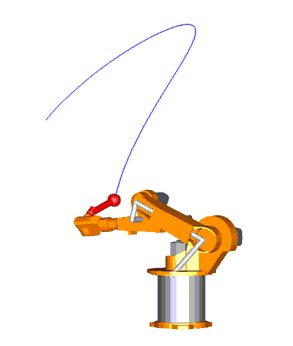 ▲ تكوين مشترك مفصلي
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.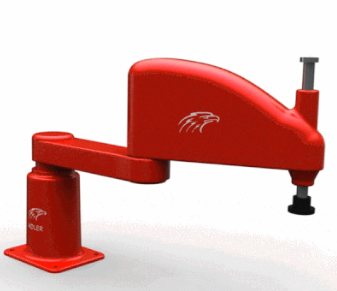
▲ التكوين المشترك لتكوين SCARA
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple روبوتات ثلاثية المحاورالتي تحتوي فقط على محركات خطية بثلاثة مغازل.
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——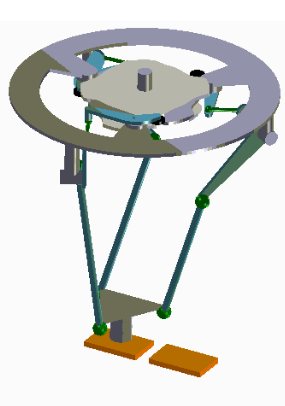
▲ الروبوت الصناعي المتوازي يمكن تعريف الآلية المتوازية على أنها آلية حلقة مغلقة يتم فيها توصيل المنصة المتحركة والمنصة الثابتة بواسطة سلسلتين حركيتين مستقلتين على الأقل، وتتمتع الآلية بدرجتين أو أكثر من الحرية، ويتم دفعها بالتوازي.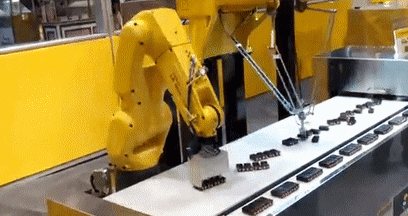 تشمل التطبيقات النموذجية للروبوتات الصناعية اللحام، والطلاء، والتجميع، والجمع والوضع (مثل التعبئة والتغليف، ومنصات النقل، وSMT)، وفحص المنتج واختباره، وما إلى ذلك؛ ويتم إنجاز جميع المهام بكفاءة عالية ومتانة وسرعة ودقة.
 من أجل أداء مهام العمل بشكل أكثر دقة، تتضمن الروبوتات الصناعية عادةً أنظمة فرعية للرؤية الآلية كأجهزة استشعار للرؤية، متصلة بأجهزة كمبيوتر أو وحدات تحكم قوية.
For modern industrial robots, روبوتات الذكاء الاصطناعيأصبحت المعدات ذات أهمية متزايدة.


