


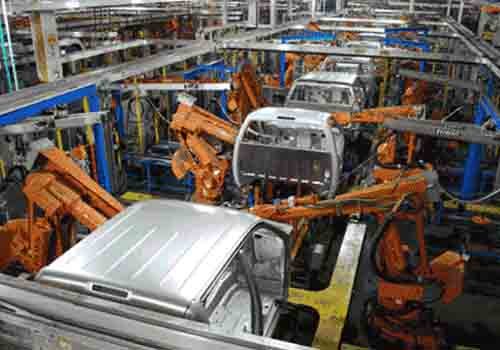
robots industriales are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology.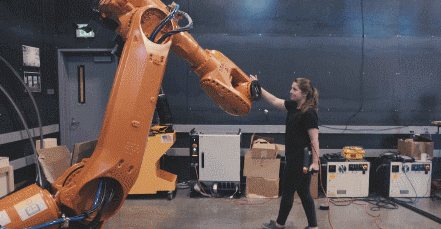 El primer robot industrial conforme a la norma ISO fue producido por Bill Griffith Taylor en 1937 y publicado en la revista Meccano en marzo de 1938.
Este robot industrial con forma de grúa está fabricado con piezas de Meccano y propulsado por un único motor eléctrico. Este robot industrial puede apilar bloques de madera de forma preprogramada. La mitad del siglo XX fue un período crítico para la investigación y el desarrollo de robots industriales.
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
En 1959, nació el primer robot industrial de Unimation en los Estados Unidos, abriendo una nueva era en el desarrollo de robots.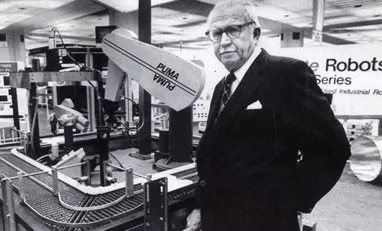 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
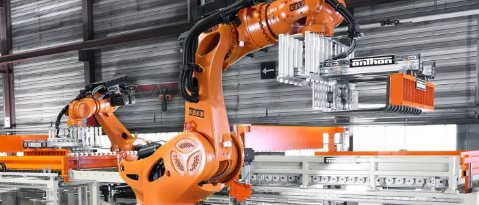
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
El controlador de la computadora puede ingresar y almacenar varios programas para determinar la conexión y relación de la secuencia de trabajo. Sensores: el robot utiliza sensores para reconocer y evaluar cambios de posición, diferencias de estilo y obstáculos o mal funcionamiento de sistemas externos.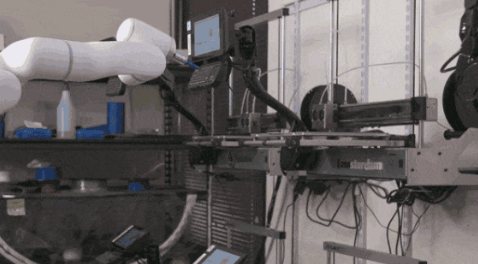 Sistema de retroalimentación: El dispositivo de retroalimentación del robot industrial puede medir la posición, velocidad de movimiento y aceleración de cada eje.
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——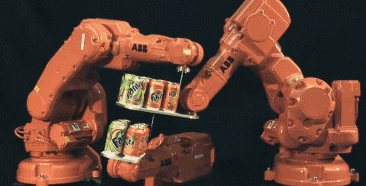
▲ El robot industrial ABB completó el desafío "Fanta Tank"Configuración articulada: el brazo articulado es el brazo robótico más común, muy similar al brazo humano. Generalmente máquinas de seis ejes, brindan redundancia y se mueven con mayor suavidad.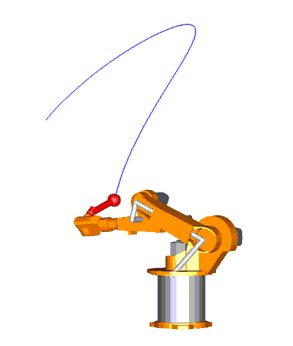 ▲ Configuración de junta articulada
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.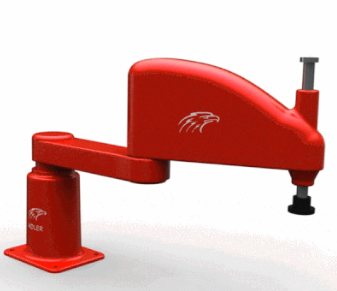
▲ Configuración conjunta de configuración SCARA
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple robots de tres ejesque sólo contienen actuadores lineales con tres husillos.
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——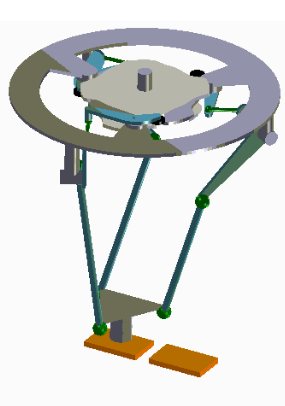
▲ Robot industrial paralelo Un mecanismo paralelo se puede definir como un mecanismo de circuito cerrado en el que la plataforma móvil y la plataforma fija están conectadas por al menos dos cadenas cinemáticas independientes, el mecanismo tiene dos o más grados de libertad y se acciona en paralelo.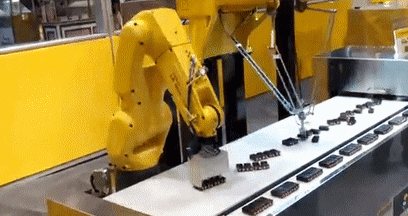 Las aplicaciones típicas de los robots industriales incluyen soldadura, pintura, montaje, recogida y colocación (como embalaje, paletizado y SMT), inspección y prueba de productos, etc.; todas las tareas se completan con alta eficiencia, durabilidad, velocidad y precisión.
 Para realizar las tareas laborales con mayor precisión, los robots industriales suelen incluir subsistemas de visión artificial como sensores de visión, conectados a potentes ordenadores o controladores.
For modern industrial robots, robots de inteligencia artificialse han convertido en equipos cada vez más importantes.


