


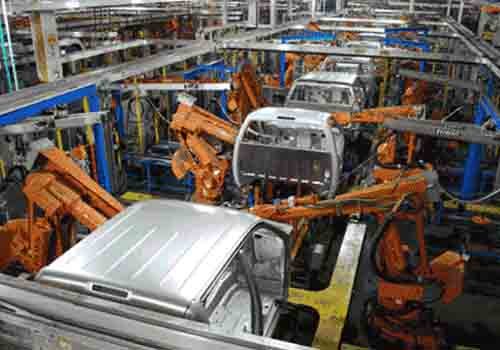
औद्योगिक रोबोट are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology. आईएसओ मानक के अनुरूप पहला औद्योगिक रोबोट 1937 में बिल ग्रिफ़िथ टेलर द्वारा निर्मित किया गया था और मार्च 1938 में मेकानो पत्रिका में प्रकाशित हुआ था।
यह क्रेन जैसा औद्योगिक रोबोट मेकानो भागों से बना है और एक एकल इलेक्ट्रिक मोटर द्वारा संचालित है। यह औद्योगिक रोबोट लकड़ी के ब्लॉकों को पूर्व-क्रमादेशित तरीके से ढेर कर सकता है। 20वीं सदी का मध्य औद्योगिक रोबोटों के अनुसंधान और विकास के लिए एक महत्वपूर्ण अवधि थी।
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
1959 में, यूनिमेशन का पहला औद्योगिक रोबोट संयुक्त राज्य अमेरिका में पैदा हुआ, जिसने रोबोट विकास के एक नए युग की शुरुआत की।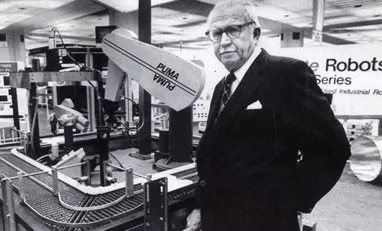 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
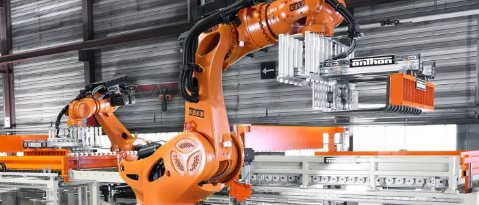
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
कंप्यूटर नियंत्रक कार्य अनुक्रम के कनेक्शन और संबंध को निर्धारित करने के लिए विभिन्न कार्यक्रमों को इनपुट और स्टोर कर सकता है। सेंसर: रोबोट स्थिति परिवर्तन, शैली अंतर और बाहरी प्रणालियों की बाधाओं या खराबी को पहचानने और मूल्यांकन करने के लिए सेंसर का उपयोग करता है। फीडबैक प्रणाली: औद्योगिक रोबोट का फीडबैक उपकरण प्रत्येक अक्ष की स्थिति, गति और त्वरण को माप सकता है।
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——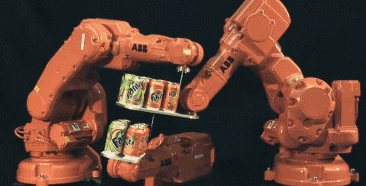
▲ एबीबी औद्योगिक रोबोट ने "फैंटा टैंक" चुनौती को पूरा किया। आर्टिकुलेटेड कॉन्फ़िगरेशन: आर्टिकुलेटेड आर्म सबसे आम रोबोट आर्म है, जो मानव बांह के समान है। आमतौर पर छह-अक्ष मशीनें, वे अतिरेक प्रदान करती हैं और आसानी से चलती हैं।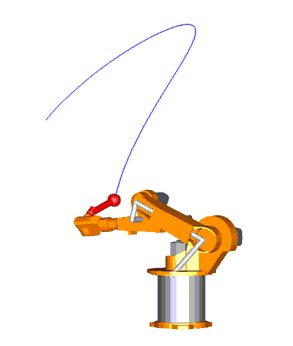 ▲ व्यक्त संयुक्त विन्यास
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.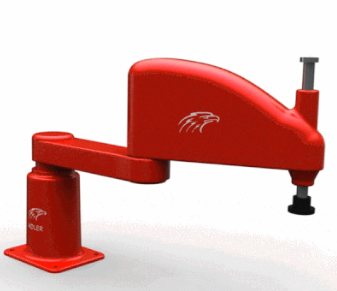
▲ SCARA कॉन्फ़िगरेशन संयुक्त कॉन्फ़िगरेशन
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple तीन अक्ष रोबोटजिसमें केवल तीन स्पिंडल वाली रैखिक ड्राइव होती हैं।
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——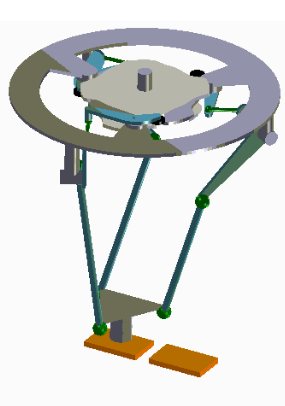
▲ समानांतर औद्योगिक रोबोट एक समानांतर तंत्र को एक बंद-लूप तंत्र के रूप में परिभाषित किया जा सकता है जिसमें चलती प्लेटफ़ॉर्म और निश्चित प्लेटफ़ॉर्म कम से कम दो स्वतंत्र गतिज श्रृंखलाओं से जुड़े होते हैं, तंत्र में दो या अधिक स्वतंत्रता की डिग्री होती है, और समानांतर में संचालित होती है।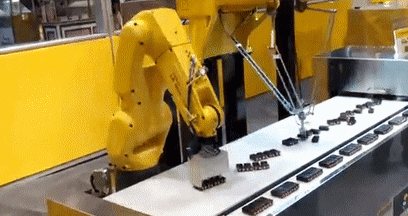 औद्योगिक रोबोट के विशिष्ट अनुप्रयोगों में वेल्डिंग, पेंटिंग, असेंबली, संग्रह और प्लेसमेंट (जैसे पैकेजिंग, पैलेटाइजिंग और एसएमटी), उत्पाद निरीक्षण और परीक्षण आदि शामिल हैं; सभी कार्य उच्च दक्षता, स्थायित्व, गति और सटीकता के साथ पूरे होते हैं।
 कार्य कार्यों को अधिक सटीकता से करने के लिए, औद्योगिक रोबोटों में आमतौर पर मशीन विज़न सबसिस्टम को उनके विज़न सेंसर के रूप में शामिल किया जाता है, जो शक्तिशाली कंप्यूटर या नियंत्रकों से जुड़ा होता है।
For modern industrial robots, कृत्रिम बुद्धि रोबोटतेजी से महत्वपूर्ण उपकरण बन गए हैं।


