


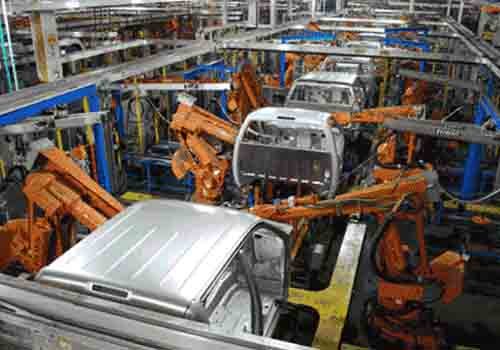
Robot industriali are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology.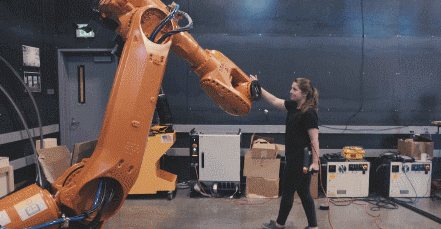 Il primo robot industriale conforme allo standard ISO fu prodotto da Bill Griffith Taylor nel 1937 e pubblicato sulla rivista Meccano nel marzo 1938.
Questo robot industriale simile a una gru è costituito da parti del Meccano e alimentato da un unico motore elettrico. Questo robot industriale può impilare blocchi di legno in modo preprogrammato.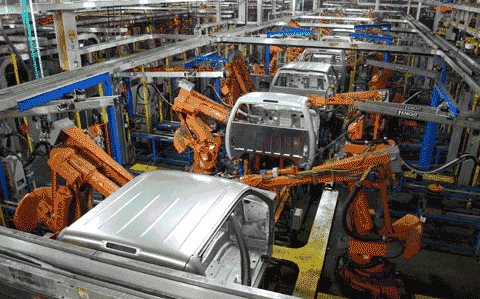 La metà del XX secolo è stata un periodo critico per la ricerca e lo sviluppo dei robot industriali.
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
Nel 1959, negli Stati Uniti, nacque il primo robot industriale di Unimation, aprendo una nuova era nello sviluppo dei robot.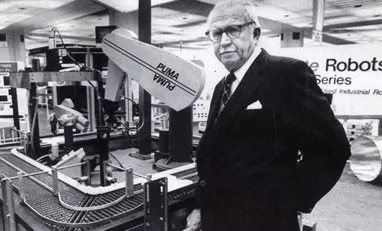 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
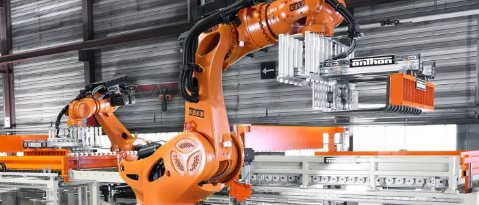
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
Il controller del computer può inserire e memorizzare vari programmi per determinare la connessione e la relazione della sequenza di lavoro. Sensori: il robot utilizza sensori per riconoscere e valutare cambiamenti di posizione, differenze di stile e ostacoli o malfunzionamenti di sistemi esterni. Sistema di feedback: il dispositivo di feedback del robot industriale può misurare la posizione, la velocità di movimento e l'accelerazione di ciascun asse.
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——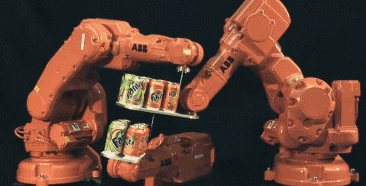
▲ Il robot industriale ABB ha completato la sfida "Fanta Tank"Configurazione articolata: il braccio articolato è il braccio robotico più comune, molto simile a un braccio umano. Solitamente macchine a sei assi, forniscono ridondanza e si muovono in modo più fluido.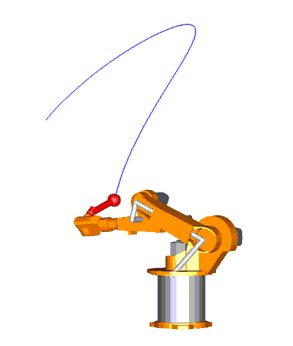 ▲ Configurazione giunto snodato
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.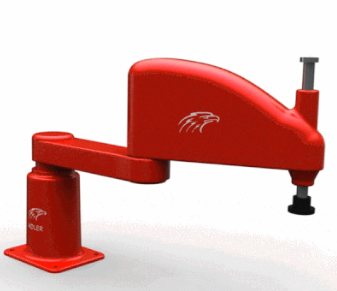
▲ Configurazione SCARA configurazione congiunta
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple robot a tre assiche contengono solo attuatori lineari con tre mandrini.
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——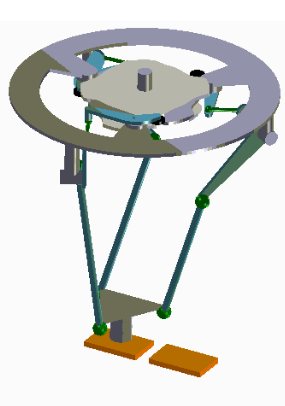
▲ Robot industriale paralleloUn meccanismo parallelo può essere definito come un meccanismo a circuito chiuso in cui la piattaforma mobile e la piattaforma fissa sono collegate da almeno due catene cinematiche indipendenti, il meccanismo ha due o più gradi di libertà ed è azionato in parallelo.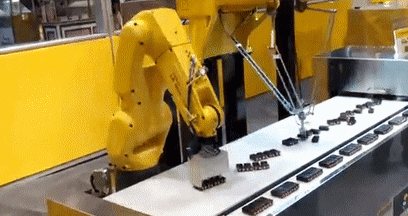 Le applicazioni tipiche dei robot industriali includono saldatura, verniciatura, assemblaggio, raccolta e posizionamento (come imballaggio, pallettizzazione e SMT), ispezione e test del prodotto, ecc.; tutte le attività vengono completate con elevata efficienza, durata, velocità e precisione.
 Per eseguire le attività lavorative in modo più accurato, i robot industriali solitamente includono sottosistemi di visione artificiale come sensori di visione, collegati a potenti computer o controller.
For modern industrial robots, robot di intelligenza artificialesono diventate apparecchiature sempre più importanti.


