


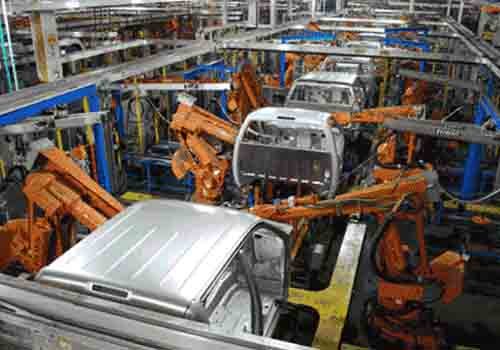
Průmyslové roboty are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology.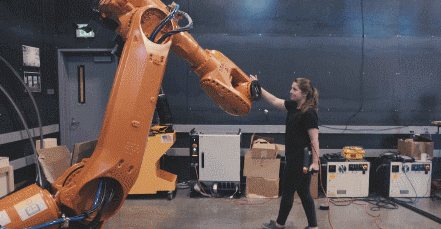 První průmyslový robot vyhovující normě ISO vyrobil Bill Griffith Taylor v roce 1937 a v březnu 1938 jej publikoval časopis Meccano.
Tento průmyslový robot podobný jeřábu je vyroben z dílů Meccano a je poháněn jediným elektromotorem. Tento průmyslový robot může skládat dřevěné kostky předem naprogramovaným způsobem. Polovina 20. století byla kritickým obdobím pro výzkum a vývoj průmyslových robotů.
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
V roce 1959 se ve Spojených státech zrodil první průmyslový robot společnosti Unimation, který otevřel novou éru vývoje robotů.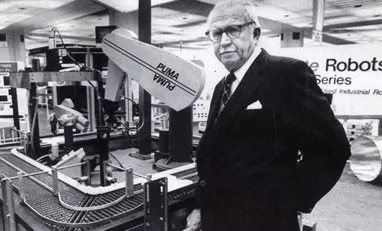 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
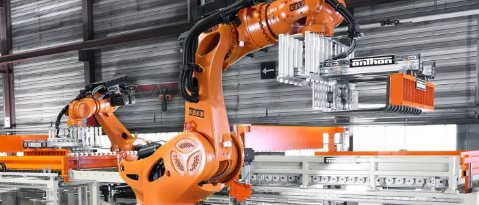
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
Počítačový kontrolér může vkládat a ukládat různé programy k určení spojení a vztahu pracovní sekvence. Senzory: Robot používá senzory k rozpoznání a vyhodnocení změn polohy, stylových rozdílů a překážek nebo poruch externích systémů. Systém zpětné vazby: Zařízení zpětné vazby průmyslového robota může měřit polohu, rychlost pohybu a zrychlení každé osy.
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——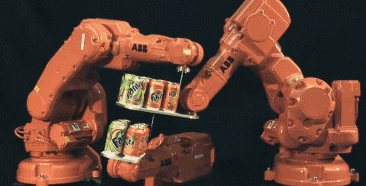
▲ Průmyslový robot ABB dokončil výzvu „Fanta Tank“ Kloubová konfigurace: Kloubové rameno je nejběžnější robotické rameno, velmi podobné lidské paži. Obvykle šestiosé stroje poskytují redundanci a pohyb plynulejší.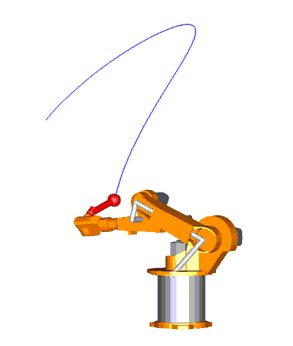 ▲ Konfigurace kloubového kloubu
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.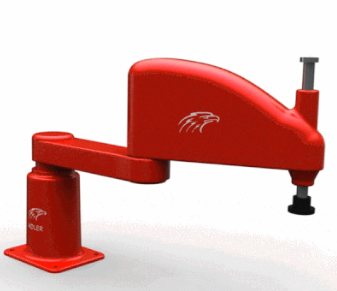
▲ Konfigurace kloubu konfigurace SCARA
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple tříosé robotykteré obsahují pouze lineární pohony se třemi vřeteny.
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——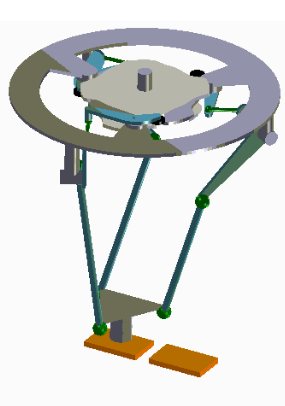
▲ Paralelní průmyslový robotParalelní mechanismus lze definovat jako mechanismus s uzavřenou smyčkou, ve kterém jsou pohyblivá plošina a pevná plošina spojeny alespoň dvěma nezávislými kinematickými řetězci, mechanismus má dva nebo více stupňů volnosti a je poháněn paralelně.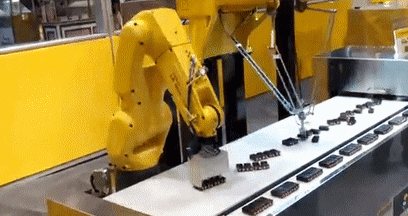 Mezi typické aplikace průmyslových robotů patří svařování, lakování, montáž, sběr a umístění (jako je balení, paletizace a SMT), kontrola a testování výrobků atd.; všechny úkoly jsou dokončeny s vysokou účinností, odolností, rychlostí a přesností.
 Aby průmyslové roboty vykonávaly pracovní úkoly přesněji, obvykle obsahují jako své zrakové senzory podsystémy strojového vidění, které jsou připojeny k výkonným počítačům nebo řídicím systémům.
For modern industrial robots, roboty s umělou inteligencíse staly stále důležitějším vybavením.


