


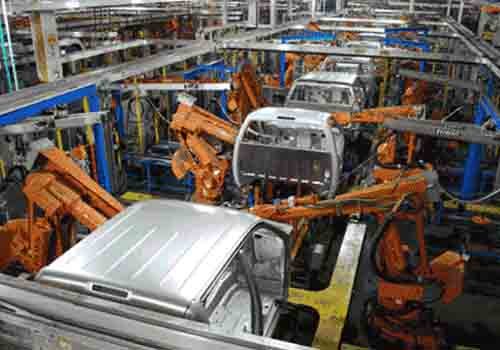
産業用ロボット are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology.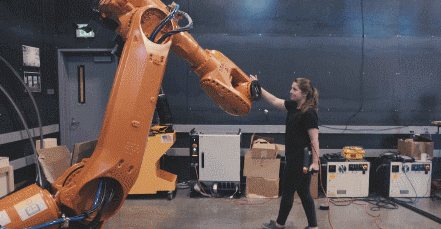 ISO 規格に準拠した最初の産業用ロボットは 1937 年にビル グリフィス テイラーによって製造され、1938 年 3 月にメカノ誌に掲載されました。
このクレーンのような産業用ロボットは Meccano の部品で作られており、単一の電気モーターで駆動されます。この産業用ロボットは、事前にプログラムされた方法で木のブロックを積み重ねることができます。 20世紀半ばは産業用ロボットの研究開発にとって重要な時期でした。
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
1959 年にユニメーション初の産業用ロボットが米国で誕生し、ロボット開発の新時代を切り開きました。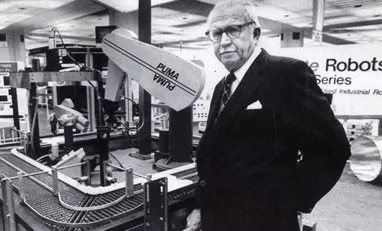 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
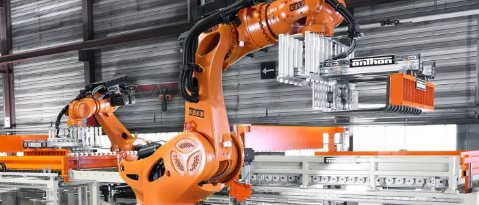
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
コンピュータコントローラは、作業シーケンスの接続と関係を決定するために、さまざまなプログラムを入力および保存できます。 センサー:ロボットはセンサーを使用して、位置の変化、スタイルの違い、および外部システムの障害物や誤動作を認識および評価します。 フィードバックシステム:産業用ロボットのフィードバック装置は、各軸の位置、移動速度、加速度を測定できます。
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——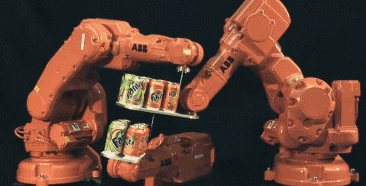
▲ ABB 産業用ロボットが「ファンタ タンク」の課題を達成 多関節構成: 多関節アームは最も一般的なロボット アームで、人間のアームに非常に似ています。通常は 6 軸マシンで、冗長性が提供され、よりスムーズに動作します。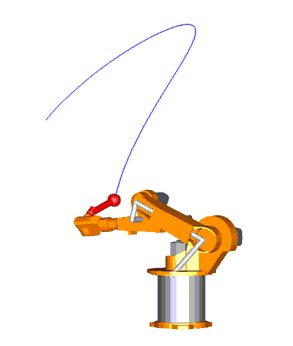 ▲ 多関節ジョイントの構成
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.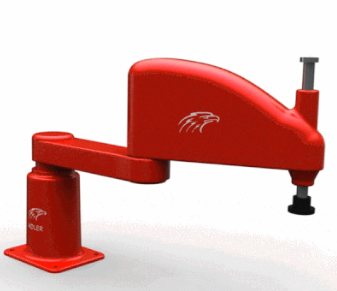
▲スカラ構成 ジョイント構成
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple 3軸ロボット3 つのスピンドルを備えたリニア ドライブのみが含まれています。
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——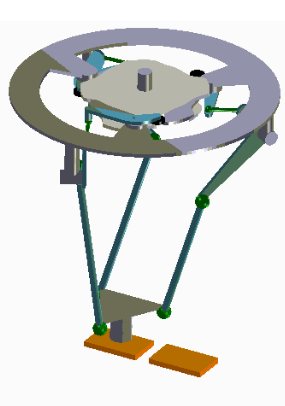
▲ 並列産業用ロボット並列機構は、移動プラットフォームと固定プラットフォームが少なくとも 2 つの独立した運動連鎖によって接続され、機構が 2 つ以上の自由度を持ち、並列に駆動される閉ループ機構として定義できます。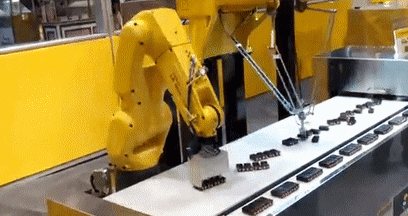 産業用ロボットの一般的な用途には、溶接、塗装、組み立て、収集と配置 (梱包、パレタイジング、SMT など)、製品の検査とテストなどが含まれます。すべてのタスクは高い効率、耐久性、スピード、正確さで完了します。
 作業タスクをより正確に実行するために、産業用ロボットには通常、ビジョン センサーとしてマシン ビジョン サブシステムが組み込まれており、強力なコンピューターまたはコントローラーに接続されています。
For modern industrial robots, 人工知能ロボットますます重要な装備となっています。


