


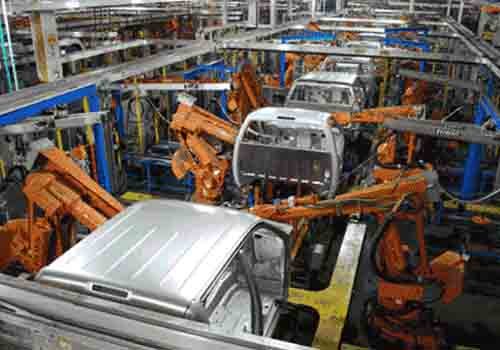
Industrieroboter are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology.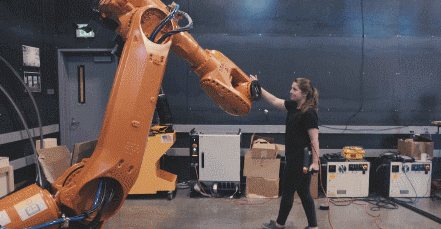 Der erste Industrieroboter, der der ISO-Norm entspricht, wurde 1937 von Bill Griffith Taylor hergestellt und im März 1938 in der Zeitschrift Meccano veröffentlicht.
Dieser kranähnliche Industrieroboter besteht aus Meccano-Teilen und wird von einem einzigen Elektromotor angetrieben. Dieser Industrieroboter kann Holzklötze auf vorprogrammierte Weise stapeln. Die Mitte des 20. Jahrhunderts war eine kritische Zeit für die Forschung und Entwicklung von Industrierobotern.
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
1959 wurde in den USA der erste Industrieroboter von Unimation geboren und leitete damit eine neue Ära der Roboterentwicklung ein.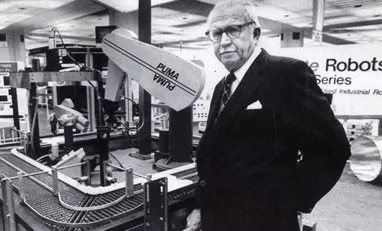 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
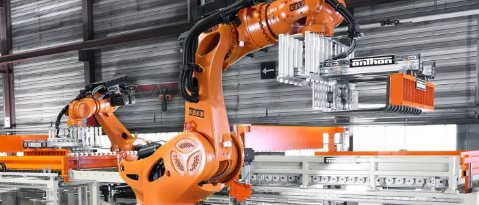
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
Die Computersteuerung kann verschiedene Programme eingeben und speichern, um den Zusammenhang und die Zusammenhänge des Arbeitsablaufs zu bestimmen.Sensoren: Der Roboter erkennt und bewertet mithilfe von Sensoren Positionsänderungen, Stilunterschiede sowie Hindernisse oder Fehlfunktionen externer Systeme. Feedback-System: Das Feedback-Gerät des Industrieroboters kann die Position, Bewegungsgeschwindigkeit und Beschleunigung jeder Achse messen.
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——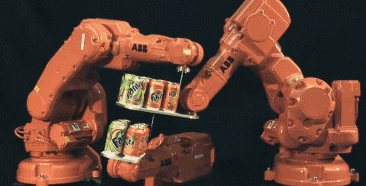
▲ ABB-Industrieroboter haben die „Fanta Tank“-Herausforderung abgeschlossenGelenkkonfiguration: Der Gelenkarm ist der häufigste Roboterarm, der einem menschlichen Arm sehr ähnlich ist. In der Regel handelt es sich bei Maschinen um sechsachsige Maschinen, die Redundanz bieten und eine reibungslosere Bewegung ermöglichen.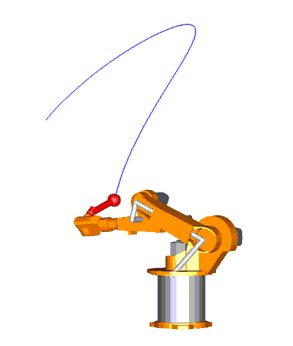 ▲ Gelenkverbindungskonfiguration
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.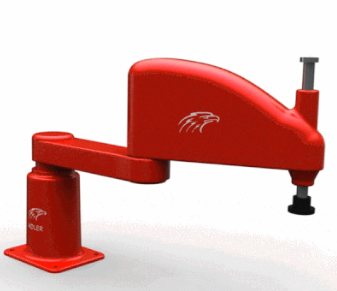
▲ SCARA-Konfigurationsgelenkkonfiguration
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple dreiachsige Roboterdie ausschließlich Linearantriebe mit drei Spindeln enthalten.
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——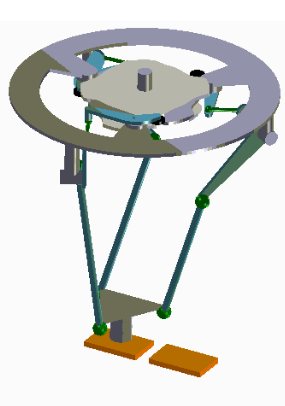
▲ Paralleler IndustrieroboterEin Parallelmechanismus kann als geschlossener Mechanismus definiert werden, bei dem die bewegliche Plattform und die feste Plattform durch mindestens zwei unabhängige kinematische Ketten verbunden sind, der Mechanismus zwei oder mehr Freiheitsgrade aufweist und parallel angetrieben wird.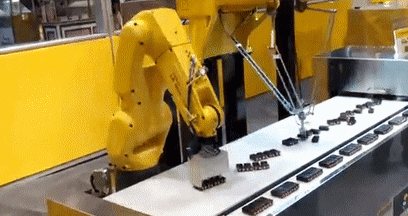 Zu den typischen Anwendungen von Industrierobotern gehören Schweißen, Lackieren, Montage, Sammlung und Platzierung (z. B. Verpackung, Palettierung und SMT), Produktinspektion und -prüfung usw.; Alle Aufgaben werden mit hoher Effizienz, Haltbarkeit, Geschwindigkeit und Genauigkeit erledigt.
 Um Arbeitsaufgaben genauer ausführen zu können, verfügen Industrieroboter in der Regel über Bildverarbeitungssubsysteme als Bildverarbeitungssensoren, die mit leistungsstarken Computern oder Steuerungen verbunden sind.
For modern industrial robots, Roboter mit künstlicher Intelligenzsind zu immer wichtigeren Geräten geworden.


