


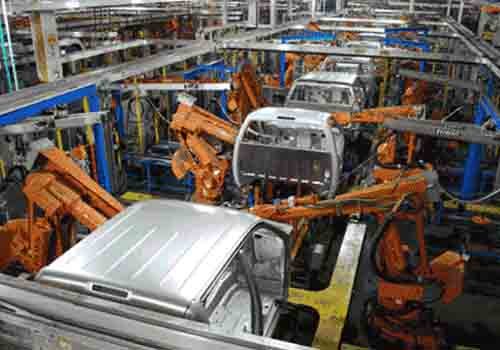
산업용 로봇 are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology.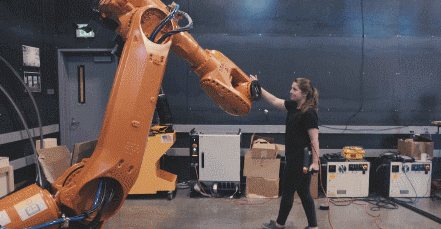 ISO 표준을 준수하는 최초의 산업용 로봇은 1937년 Bill Griffith Taylor에 의해 생산되었으며 1938년 3월 Meccano 잡지에 게재되었습니다.
이 크레인 모양의 산업용 로봇은 메카노 부품으로 만들어졌으며 단일 전기 모터로 구동됩니다. 이 산업용 로봇은 사전 프로그래밍된 방식으로 나무 블록을 쌓을 수 있습니다. 20세기 중반은 산업용 로봇의 연구개발에 있어서 중요한 시기였습니다.
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
1959년 유니메이션의 첫 번째 산업용 로봇이 미국에서 탄생하며 로봇 개발의 새로운 시대를 열었습니다.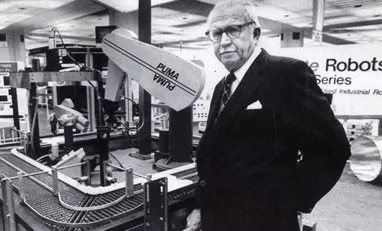 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
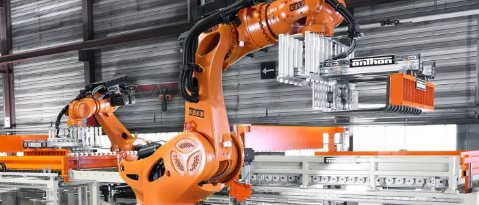
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
컴퓨터 컨트롤러는 작업 순서의 연결과 관계를 결정하기 위해 다양한 프로그램을 입력하고 저장할 수 있습니다. 센서: 로봇은 센서를 사용하여 위치 변화, 스타일 차이, 외부 시스템의 장애물이나 오작동을 인식하고 평가합니다. 피드백 시스템: 산업용 로봇의 피드백 장치는 각 축의 위치, 이동 속도 및 가속도를 측정할 수 있습니다.
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——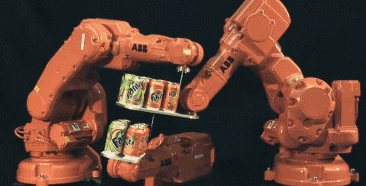
▲ ABB 산업용 로봇이 '판타 탱크' 챌린지를 완료했습니다. 관절 구성: 관절 팔은 가장 일반적인 로봇 팔로 인간 팔과 매우 유사합니다. 일반적으로 6축 기계는 중복성을 제공하고 더 부드럽게 움직입니다.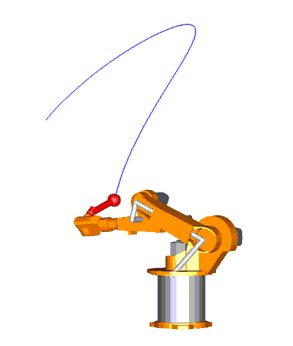 ▲ 관절형 조인트 구성
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.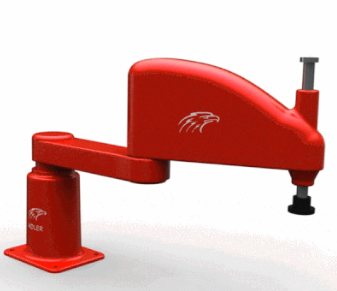
▲ SCARA 구성 조인트 구성
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple 3축 로봇3개의 스핀들이 있는 선형 드라이브만 포함되어 있습니다.
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——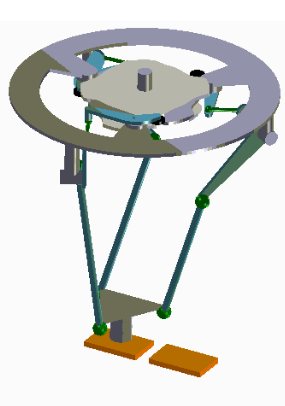
▲ 병렬형 산업용 로봇병렬 메커니즘은 움직이는 플랫폼과 고정 플랫폼이 적어도 2개의 독립적인 운동 체인으로 연결되고, 메커니즘이 2개 이상의 자유도를 가지며 병렬로 구동되는 폐쇄 루프 메커니즘으로 정의할 수 있습니다.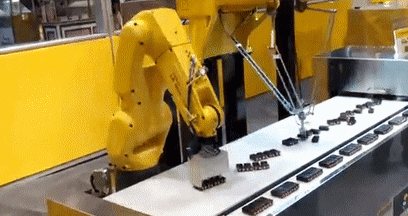 산업용 로봇의 일반적인 응용 분야에는 용접, 도장, 조립, 수집 및 배치(예: 포장, 팔레타이징 및 SMT), 제품 검사 및 테스트 등이 포함됩니다. 모든 작업은 높은 효율성, 내구성, 속도 및 정확성으로 완료됩니다.
 작업 작업을 보다 정확하게 수행하기 위해 산업용 로봇에는 일반적으로 강력한 컴퓨터나 컨트롤러에 연결된 비전 센서로 머신 비전 하위 시스템이 포함됩니다.
For modern industrial robots, 인공지능 로봇점점 더 중요한 장비가 되었습니다.


