


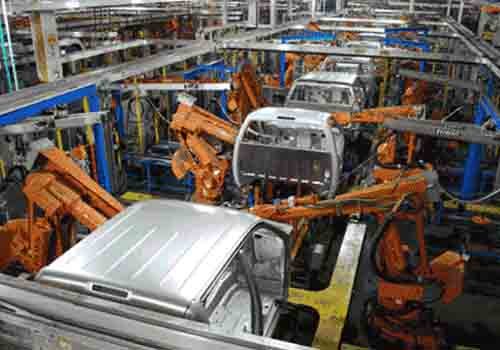
Robot industri are important equipment in the upgrading of advanced manufacturing, and they are also an important indicator of the technological level of a country's manufacturing industry. The robot industry with industrial robots as the main body is an important way to solve the problems of rising industrial costs and environmental constraints in my country. An industrial robot is a multi-joint manipulator or a multi-degree-of-freedom machine device oriented to the industrial field.
It can automatically perform work and is a machine that relies on its own power and control capabilities to achieve various functions. It can be commanded by humans, and it can also be run in accordance with pre-arranged programs. Modern industrial robots can also perform tasks in accordance with principles and guidelines established by artificial intelligence technology. Robot industri pertama yang memenuhi standar ISO diproduksi oleh Bill Griffith Taylor pada tahun 1937 dan diterbitkan di majalah Meccano pada bulan Maret 1938.
Robot industri mirip derek ini terbuat dari suku cadang Meccano dan ditenagai oleh satu motor listrik. Robot industri ini dapat menumpuk balok kayu dengan cara yang telah diprogram sebelumnya. Pertengahan abad ke-20 merupakan masa kritis bagi penelitian dan pengembangan robot industri.
Especially in the industrial environment, the work of repetitive motion and lifting heavy objects made the machine a great help to humans. Most industrial robots are used in work environments that are too dirty, tiring, or dangerous for humans.George Devol first proposed the concept of industrial robots, and applied for a patent in 1954 (patent approved in 1961). In 1956, Davor and Joseph Engelberg jointly established Unimation based on Davor's original patent.
Pada tahun 1959, robot industri pertama Unimation lahir di Amerika Serikat, membuka era baru dalam pengembangan robot.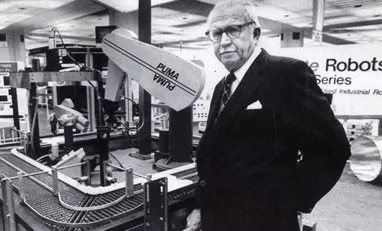 ▲ George DavorRobotics is a multidisciplinary field that combines the fields of mechanics, electronics, computer science, control, artificial intelligence, physics and mathematics. Industrial robots are composed of six basic components: dynamic units, end-of-arm machines, digital computer controllers, actuators, input devices and detectors.
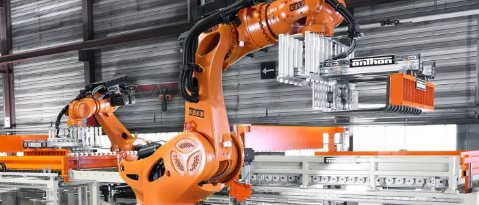
Industrial robot actuator: The actuator controls each axis and maintains the direction of movement. Since the robot needs to handle the weight of various components, its motion varies greatly. Send commands about the direction of movement from the robot computer and constantly check the feedback to ensure that the moving parts follow the correct route. This process requires high-speed equipment to send commands and read the movement of the system at a reasonable speed.Digital computer controller: For the robot, it controls the normal operation of each component.
Pengontrol komputer dapat memasukkan dan menyimpan berbagai program untuk menentukan koneksi dan hubungan urutan kerja. Sensor: Robot menggunakan sensor untuk mengenali dan mengevaluasi perubahan posisi, perbedaan gaya, dan hambatan atau malfungsi sistem eksternal. Sistem umpan balik: Perangkat umpan balik robot industri dapat mengukur posisi, kecepatan gerakan, dan percepatan setiap sumbu.
The axis must set any point to zero as a reference point in order to achieve relatively linear motion.Dynamic system: the motion part of the robot system including the industrial robot arm. The structure of the dynamic system is realized by connecting many rotation or linear motion joints.The motion provided by industrial robot joints can place the robot structure or robot arm in a specific position. The different types of joint configurations are listed below——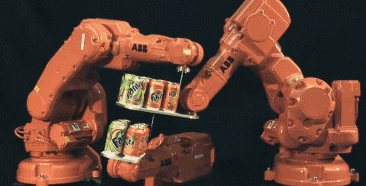
▲ Robot industri ABB menyelesaikan tantangan "Fanta Tank" Konfigurasi artikulasi: Lengan artikulasi adalah lengan robot yang paling umum, sangat mirip dengan lengan manusia. Biasanya mesin enam sumbu, mereka memberikan redundansi dan pergerakan lebih mulus.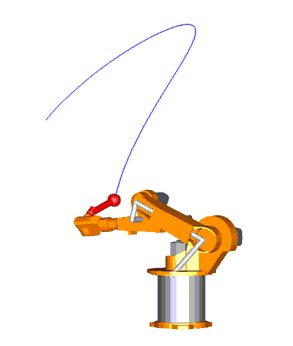 ▲ Konfigurasi sambungan artikulasi
There are six rotary joints in the articulated configuration system, and each rotary joint is placed on the previous joint. They have a variety of configurations to reach a point within the working envelope or the ability to place equipment anywhere.SCARA configuration: This four-axis arm mainly performs assembly tasks. They are small in size, but have the greatest carrying capacity.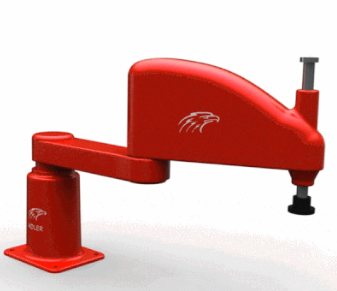
▲ Konfigurasi gabungan konfigurasi SCARA
The four-axis arm of the SCARA configuration is composed of basic rotation, linear vertical movement and two rotational movements. The linear vertical movement is in the same vertical plane. The four-axis arm of the SCARA configuration is very rigid in the vertical direction and can be ensured to be consistent with the horizontal plane.Cartesian configuration: Cartesian robots are simple robot tiga sumbuyang hanya berisi penggerak linier dengan tiga spindel.
Usually used for picking and placing, handling, palletizing, plastic molding, assembly and machine maintenance.Parallel configuration: One of the new design developments is the parallel or incremental robot configuration, as shown in the figure below——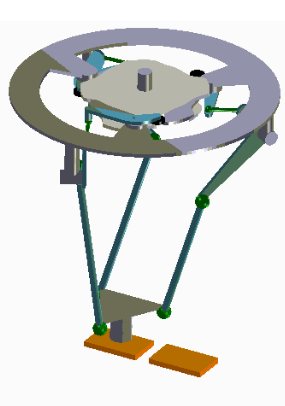
▲ Robot industri paralelMekanisme paralel dapat didefinisikan sebagai mekanisme loop tertutup di mana platform bergerak dan platform tetap dihubungkan oleh setidaknya dua rantai kinematik independen, mekanisme tersebut memiliki dua atau lebih derajat kebebasan, dan digerakkan secara paralel.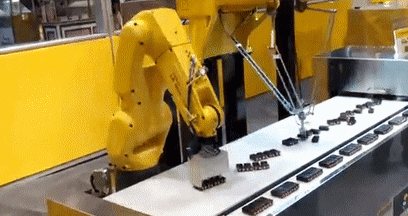 Aplikasi umum robot industri meliputi pengelasan, pengecatan, perakitan, pengumpulan dan penempatan (seperti pengemasan, pembuatan palet, dan SMT), inspeksi dan pengujian produk, dll.; semua tugas diselesaikan dengan efisiensi tinggi, daya tahan, kecepatan dan akurasi.
 Untuk melakukan tugas kerja dengan lebih akurat, robot industri biasanya menyertakan subsistem visi mesin sebagai sensor penglihatannya, yang terhubung ke komputer atau pengontrol yang kuat.
For modern industrial robots, robot kecerdasan buatantelah menjadi peralatan yang semakin penting.


