


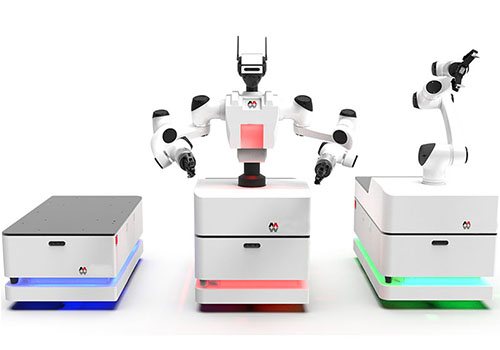
"Made in China 2025" plans the strategic goal of my country's manufacturing power, and intelligent manufacturing has become the top priority of industrial manufacturing transformation. Under the general trend of intelligence, the downstream application fields of intelligent equipment are accelerating the expansion, and the development of robôs industriaispode ser esperado.
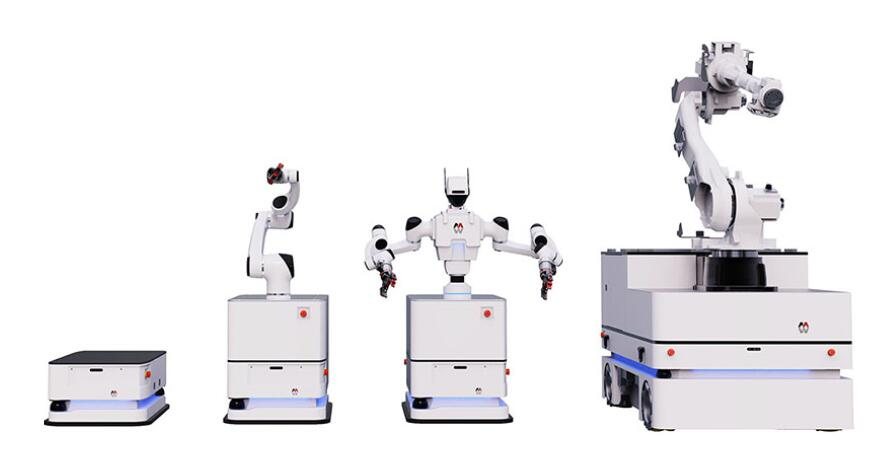
Industrial robots refer to multi-joint manipulators or multi-degree-of-freedom mechanical devices that can work intelligently under human control and can perfectly replace humans working on the production line. Compared with manpower, industrial robots have the characteristics of low cost, high efficiency and 24-hour work. In recent years, as domestic labor costs continue to rise, the labor advantage of my country's manufacturing industry is not obvious, the manufacturing industry urgently needs to transform to intelligence, and industrial robots are showing a strong development trend.
my country is a big consumer of industrial robots. Since 2013, it has become the world's largest consumer market for industrial robots for two consecutive years. There are often industrial robots in the fields of automobile manufacturing, electronics, rubber and plastics, military industry, aviation manufacturing, food industry, medical equipment and metal products. Among them, the automotive industry has the most applications, accounting for 38%.
Guangdong, Jiangsu, Xangai, Pequim e outros lugares são as principais áreas concentradas da indústria de robôs industriais do meu país, e o número de robôs industriais de propriedade representa metade do mercado nacional de robôs industriais.
However, due to the lack of core technology, the consumption of industrial robots in my country is heavily dependent on foreign companies, especially in core components such as reducers, servo motors, and controllers. Domestic robot companies in my country are restricted by others and can only purchase expensive foreign equipment, which requires domestic industries. Robot manufacturers continue to improve their technology, increase R&D level, and get rid of the control of China's industrial robot consumer market by foreign robot brands as soon as possible.
Considering that the current density of industrial robots in the global manufacturing industry is 55, while the density of China's industrial robots is only 21, which is much lower than that of developed countries such as Japan, South Korea, Germany and the United States, and in the context of intelligent manufacturing, the policy of "machine substitution" continues to be implemented. There is still a lot of room for growth. Related concept companies such as Inovance Technology, Robotics, Zhiyun Co., Ltd., Keyuan Co., Ltd., and Qinchuan Machine Tool will achieve better development under the robot dividend.
A fase de desenvolvimento de robôs industriais
O desenvolvimento de robôs industriais geralmente pode ser dividido em três gerações:
1. Primeira geração de robôs industriais:
Usually refers to the “programmable industrial robots” that are currently commercialized and used internationally, also known as “teaching and reproducing industrial robots”, that is, in order for the industrial robot to complete a certain task, the operator will first complete the task. All kinds of knowledge (such as motion trajectory, operating conditions, operating sequence and operating time, etc.) of industrial robots can be "teached" through direct or indirect means.
After the industrial robots memorize this knowledge, they can "reproduce" Instructions, within a certain accuracy range, faithfully reproduce various taught actions repeatedly. In 1962, the first Unimate industrial robot of Universal Automation of the United States was put into use in General Motors of the United States, marking the birth of the first generation of industrial robots.
2, Segunda geração de robôs industriais:
usually refers to an "intelligent robot" with some kind of intelligence (such as touch, force, vision, etc.). That is, after the sensors receive information such as touch, force and vision, the computer controls the robot's operating machine to complete the corresponding appropriate operations. In 1982, General Motors in the United States equipped the industrial robot with a vision system on the assembly line, thus announcing the advent of a new generation of intelligent industrial robots.
3, Terceira geração de robôs industriais:
is the so-called "only-type industrial robot". It not only has a perception function, but also has certain decision-making and planning capabilities. The first generation of industrial robots is still in the laboratory research stage. After the birth-growth-maturity period, industrial robots have become indispensable core equipment in the manufacturing industry. There are about 750,000 industrial robots in the world fighting side by side with workers and friends on all production lines.
As a rising star of the robot family, special robots have a tendency to come from behind due to their wide range of uses. Special robots for various purposes such as humanoid robots, agricultural robots, robôs de serviço, surgiram robôs subaquáticos, robôs médicos, robôs militares e robôs de entretenimento, e estão avançando em direção à praticidade em um ritmo rápido.Classificação de robôs industriais
Os robôs industriais podem ser divididos nos seguintes tipos de acordo com diferentes métodos
1. Os robôs industriais são divididos nas seguintes categorias de acordo com a forma de coordenadas do manipulador: (A forma de coordenadas refere-se à forma do sistema de coordenadas de referência tomada pelo braço do manipulador quando ele está em movimento.)
(1) Robô industrial de coordenadas cartesianas
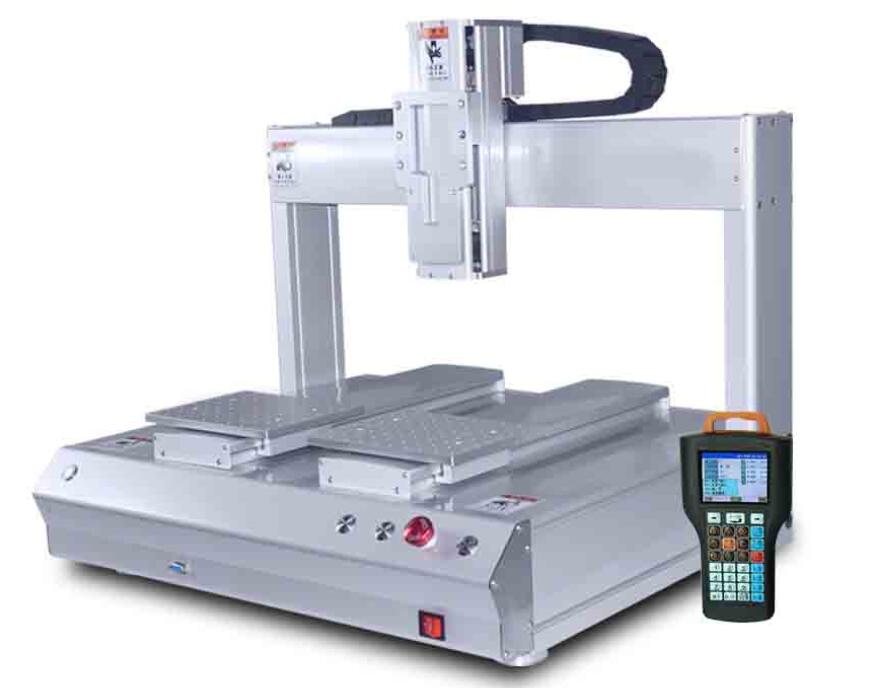
Its movement part is composed of three mutually perpendicular linear movements (namely PPP), and its working space is rectangular. Its moving distance in each axis can be read directly on each coordinate axis. It is intuitive, easy to program and calculate the position and posture, has high positioning accuracy, no coupling control, simple structure, but the body occupies a large space. The motion range is small, the flexibility is poor, and it is difficult to coordinate with other industrial robots.
(2) Robô industrial de coordenadas cilíndricas
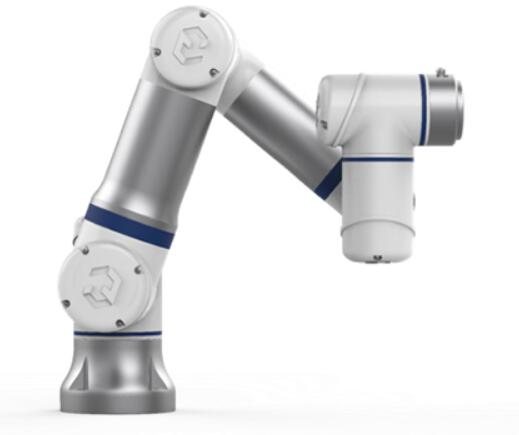
Its motion form is realized by a motion system composed of one rotation and two movements. Its working space is cylindrical. Compared with the rectangular coordinate industrial robot, under the same working space conditions, the body occupies a small volume. The range of motion is large, and its position accuracy is second only to Cartesian coordinate robots, and it is difficult to coordinate with other industrial robots.
(3) Robô industrial de coordenadas esféricas
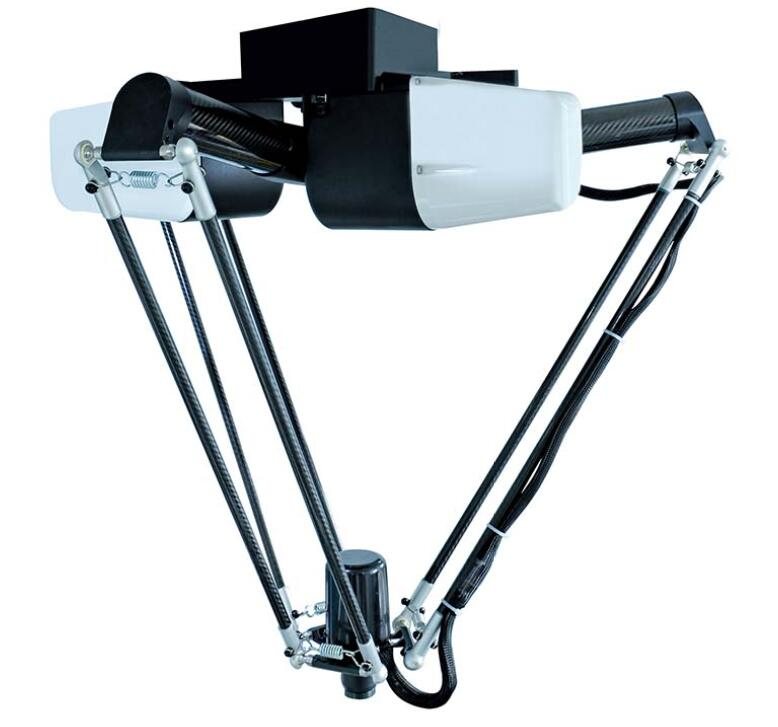
Also known as polar coordinate industrial robot, its arm movement consists of two rotations and one linear movement (ie RRP, one rotation, one pitching and one telescopic movement). Its working space is a sphere, which can make up and down pitching movements. And it can grasp the coordinated workpiece on the ground or teach low position, its position accuracy is high, and the position error is proportional to the arm length.
(4) Robô industrial multiarticular
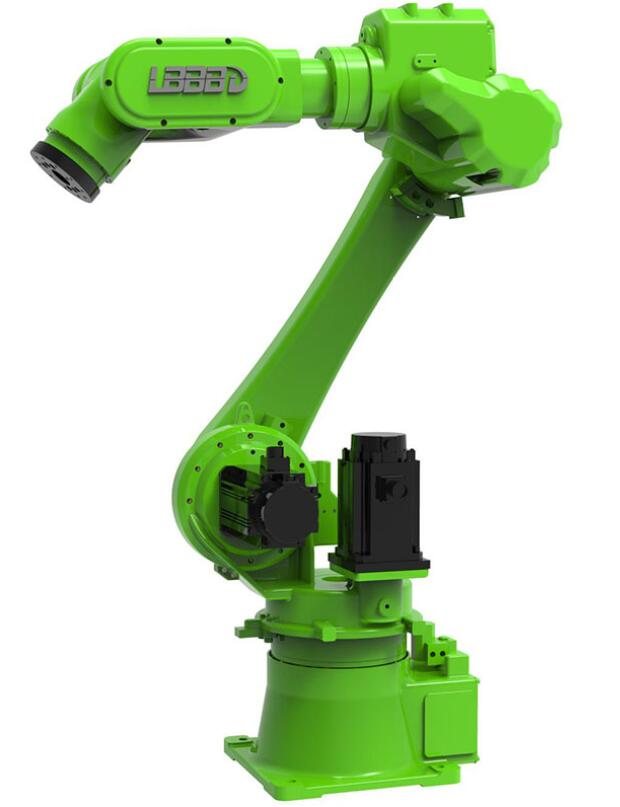
Also known as a rotary coordinate industrial robot. The arm of this industrial robot is similar to the upper limb of a human body. Its first three joints are the revolving joint (RRR). The industrial robot is generally composed of a column and a large and small arm. The column and the big arm are formed An elbow joint is formed between the shoulder joint, the upper arm and the forearm, which can make the upper arm rotate and pitch and swing, and the lower arm can make pitch swing.
Sua estrutura é a mais compacta, flexível e ocupa o menor espaço. Ele pode trabalhar em coordenação com outros robôs industriais, mas apresenta baixa precisão de posição, problemas de equilíbrio e acoplamento de controle. Este tipo de robô industrial é cada vez mais utilizado.
(5) Robô industrial tipo junta plana
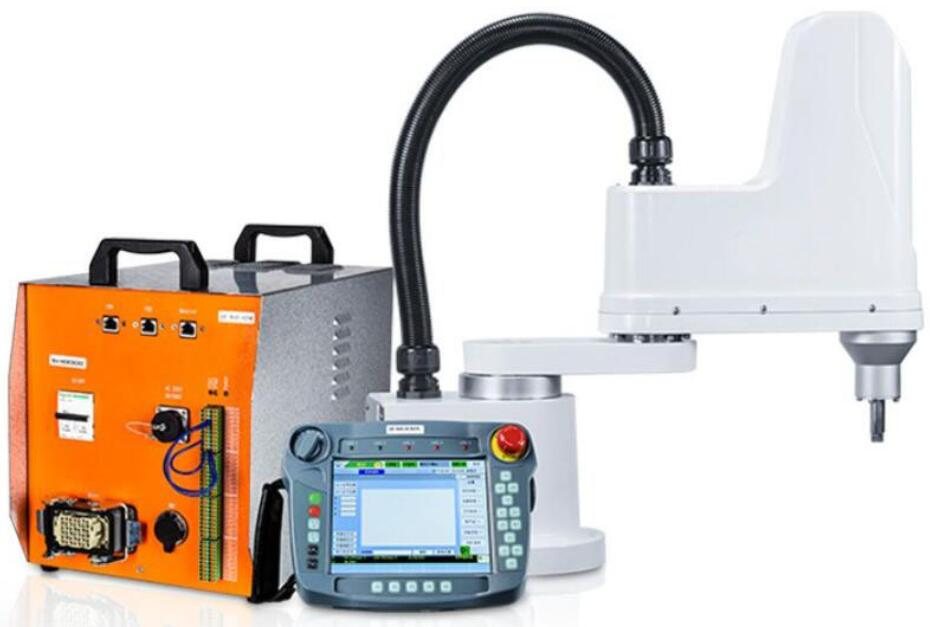
It uses a mobile joint and two rotary joints (PRR), the mobile joint realizes up and down movement, and the two rotary joints control the front and back, left and right movements. This form of industrial robot is also known as (SCARA (Seletive Compliance Assembly Robot Arm) assembly robot. It is flexible in the horizontal direction, and has great rigidity in the vertical direction. It has a simple structure and flexible movements, and is mostly used for assembly operations.
É especialmente adequado para montagem plug-in de peças de pequeno porte, como plug-in e montagem na indústria eletrônica.2. Os robôs industriais são divididos nas seguintes categorias de acordo com o modo de condução:
(1) Robô industrial pneumático
This type of industrial robot uses compressed air to drive the manipulator. Its advantages are convenient air source, rapid action, simple structure, low cost, and no pollution. The disadvantage is that the air is compressible, resulting in poor working speed stability. The source pressure is generally only about 6kPa, so the snatch force of this type of industrial robot is small, generally only tens of Newtons, and the maximum is more than 100 Newtons.
(2) Robô industrial hidráulico
The hydraulic pressure is much higher than the air pressure, generally about 70kPa, so the hydraulic transmission industrial robot has a large snatch capacity, which can reach thousands of newtons. This type of industrial robot has compact structure, smooth transmission, and sensitive action, but it has high requirements for sealing and is not suitable for working in high or low temperature environments.
(3) Robô industrial elétrico
This is the most used type of industrial robot, not only because of the large variety of electric motors, it provides a variety of options for industrial robot design, but also because they can use a variety of flexible control methods. In the early days, stepper motors were used to drive, and then DC servo drive units were developed. At present, AC servo drive units are also developing rapidly. These drive units either directly drive the manipulator, or are driven after deceleration through a device such as a harmonic reducer. The structure is very compact and simple.
Sistema de controle de robô industrial
A estrutura do sistema robótico consiste na parte do mecanismo do robô, grupo de sensores, parte de controle e parte de processamento de informações. O sistema de controle é uma parte central da indústria de robôs.1. Funções a serem alcançadas pelo sistema de controle do robô industrial
O sistema de controle do robô é usado para controlar o manipulador para completar tarefas específicas. Suas funções básicas são as seguintes:
(1) Função de memória:
Armazene sequência de trabalho, trajetória de movimento, modo de movimento, velocidade de movimento e informações relacionadas ao processo de produção.
(2) Função de ensino:
Programação offline, ensino online, ensino indireto. O ensino online inclui caixa de ensino e ensino guiado.
(3) Função de contato com equipamentos periféricos:
Interface de entrada e saída, interface de comunicação, interface de rede, interface de sincronização.
(4) Função de configuração de coordenadas:
Existem quatro sistemas de coordenadas: conjunta, absoluta, ferramenta e definida pelo usuário.
(5) Interface homem-máquina:
Caixa de ensino, painel de operação, tela de exibição.
(6) Interface do sensor:
Detecção de posição, visão, toque, força, etc.
(7) Função servo de posição:
Articulação multieixo do robô, controle de movimento, controle de velocidade e aceleração, compensação dinâmica, etc.
(8) Função de proteção de segurança para diagnóstico de falhas:
Monitoramento do status do sistema durante a operação, proteção de segurança em condições de falha e autodiagnóstico de falhas.
2. Composição do sistema de controle de robôs industriais
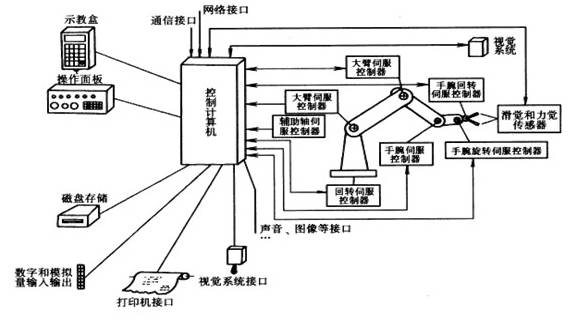 O diagrama de blocos do sistema de controle do robô (1) Computador de controle:
A organização de despacho e comando do sistema de controle. Geralmente, microcomputadores e microprocessadores são de 32 bits, 64 bits, etc., como CPUs da série Pentium e outros tipos de CPUs.
(2) Caixa de ensino:
Ensine a trajetória de trabalho e as configurações de parâmetros do robô, bem como a interação humano-computador, tenha sua própria CPU e unidade de armazenamento independentes e realize a interação de informações com o computador host por meio de comunicação serial.
(3) Painel de operação:
é composto por vários botões de operação e indicadores de status e completa apenas operações funcionais básicas.
(4) Armazenamento em disco rígido e disquete:
Memória periférica para armazenamento de programas de trabalho do robô.
(5) Entrada e saída digital e analógica:
Entrada ou saída de vários comandos de status e controle.
(6) Interface da impressora:
Registre várias informações que precisam ser produzidas.
(7) Interface do sensor:
é usado para a detecção automática de informações para realizar o controle compatível do robô, geralmente sensores de força, toque e visão.
(8) controlador de eixo:
Complete a posição articular do robô, controle de velocidade e aceleração.
(9) Controle de equipamentos auxiliares:
é utilizado para controlar equipamentos auxiliares que cooperam com o robô, como posicionador de pinça, etc.
(10) Interface de comunicação:
Realize a troca de informações entre robôs e outros dispositivos, geralmente interfaces seriais, interfaces paralelas, etc.
(11) interface de rede
1) Ethernet interface: Direct PC communication of several or single robots can be realized through Ethernet, the data transmission rate is up to 10Mbit/s, and the application program can be programmed directly on the PC with windows library functions, and the TCP/IP communication protocol can be supported , Load data and programs into each robot controller through the Ethernet interface.
2) Interface Fieldbus: suporta uma variedade de especificações populares de fieldbus, como Device net, AB Remote I/O, Interbus-s, profibus-DP, M-NET, etc.
3. Classificação de sistemas de controle de robôs industriais
(1) Sistema de controle do programa:
Aplique uma certa função de controle regular a cada grau de liberdade e o robô poderá realizar a trajetória espacial necessária.
(2) Sistema de controle adaptativo:
When the external conditions change, in order to ensure the required quality or to improve the control quality with the accumulation of experience, the process is based on the observation of the state of the operating machine and the servo error, and then adjust the parameters of the nonlinear model until the error Until it disappears. The structure and parameters of this system can change automatically with time and conditions.
(3) Sistema de Inteligência Artificial:
É impossível compilar programas de movimento antecipadamente, mas requer a determinação em tempo real do efeito de controle com base nas informações obtidas do estado circundante durante o movimento.
Modo de acionamento: consulte sistema de acionamento de robô industrial.
Método de exercício:
(4) Tipo de ponto:
requires the robot to accurately control the pose of the end effector, regardless of the path;
(5) Tipo de trilha:
requer que o robô se mova de acordo com a trajetória e velocidade ensinadas.
(6) Barramento de controle:
Sistema de controle de ônibus de padrão internacional. Use o barramento de padrão internacional como barramento de controle do sistema de controle, como VME, barramento MULTI, barramento STD, barramento PC.
(7) Sistema de controle de barramento personalizado:
O barramento definido e utilizado pelo próprio fabricante é utilizado como barramento do sistema de controle.
(8) Método de programação:
Sistema de programação de configuração física. O operador define uma chave fim de curso fixa para realizar a operação do programa de partida e parada, que só pode ser usada para operações simples de coleta e colocação.
(9) Programação on-line:
O método de programação do processo de memória para operar informações é concluído por meio do ensino humano, incluindo ensino direto (ou seja, ensino corpo a corpo), ensino de simulação e ensino de caixa de ensino.
(10) Programação off-line:
Não ensine diretamente para o robô real, mas separado do ambiente de trabalho real, gere um programa de ensino e gere a trajetória do robô remotamente off-line usando robôs e linguagens de programação de alto nível.
4. Estrutura do sistema de controle do robô
Os sistemas de controle de robôs podem ser divididos em três categorias de acordo com seus métodos de controle.
(1) Sistema de Controle Centralizado (Sistema de Controle Centralizado):
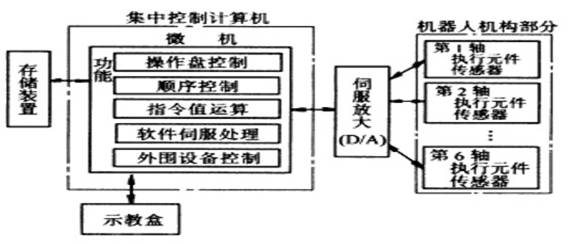 Diagrama de blocos do sistema de controle centralizado
Um computador é usado para realizar todas as funções de controle. A estrutura é simples e o custo baixo, mas o desempenho em tempo real é ruim e difícil de expandir. Essa estrutura é frequentemente usada nos primeiros robôs. O diagrama de blocos é mostrado na figura.
O sistema de controle centralizado baseado em PC aproveita ao máximo a abertura dos recursos do PC e pode alcançar uma boa abertura: uma variedade de placas de controle, dispositivos sensores, etc. podem ser integrados ao controle por meio de slots PCI padrão ou por meio de portas seriais padrão e portas paralelas. Sistema.
The advantages of centralized control systems are: low hardware costs, easy information collection and analysis, easy to achieve optimal control of the system, better integrity and coordination, and more convenient PC-based system hardware expansion. Its shortcomings are also obvious: the system control lacks flexibility, and the control danger is easy to concentrate. Once a failure occurs, its impact is wide and the consequences are serious; because the real-time requirements of industrial robots are very high, when the system performs a large amount of data calculation, it will reduce the real-time performance , The system’s responsiveness to multitasking will also conflict with the system’s real-time performance; in addition, the system’s complex wiring will reduce the system’s reliability.
(2) Sistema de controle mestre-escravo:
Using master and slave two-level processors to realize all control functions of the system. The main CPU realizes management, coordinate transformation, trajectory generation and system self-diagnosis, etc.; the slave CPU realizes the motion control of all joints. Its composition block diagram, as shown in the figure.
O sistema de controle mestre-escravo tem bom desempenho em tempo real e é adequado para controle de alta precisão e alta velocidade, mas a escalabilidade do sistema é baixa e a manutenção é difícil.
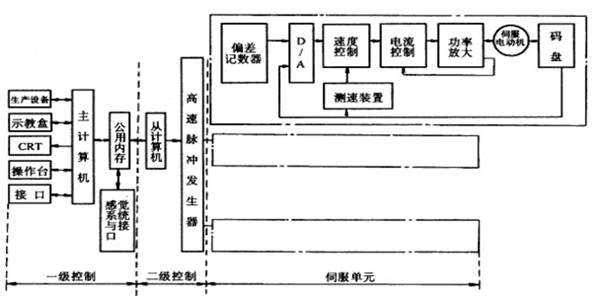 Diagrama de blocos do sistema de controle mestre e escravo
(3) Distribuir Sistema de Controle:
De acordo com a natureza e método do sistema, o controle do sistema é dividido em vários módulos. Cada módulo possui diferentes tarefas de controle e estratégias de controle. Cada modo pode ser um relacionamento mestre-escravo ou um relacionamento igual.
Este método tem bom desempenho em tempo real, é fácil de realizar controle de alta velocidade e alta precisão, é fácil de expandir e pode realizar controle inteligente. É um método popular atualmente.
The main idea is "decentralized control, centralized management", that is, the system can comprehensively coordinate and allocate its overall goals and tasks, and complete the control tasks through the coordination of subsystems. The entire system is functional, logical, and physical. It is decentralized, so the DCS system is also called a distributed control system or a distributed control system.
In this structure, the subsystem is composed of a controller and different controlled objects or devices, and each subsystem communicates with each other through a network. The distributed control structure provides an open, real-time and accurate robot control system. Two-level control methods are often used in distributed systems.
Two-level distributed control system, usually composed of upper computer, lower computer and network. The upper computer can carry out different trajectory planning and control algorithms, and the lower computer can carry out the research and realization of interpolation and subdivision and control optimization. The upper computer and the lower computer work in coordination with each other through the communication bus. The communication bus here can be in the form of RS-232, RS-485, EEE-488 and USB bus.
Now, the development of Ethernet and fieldbus technology provides robots with faster, stable and effective communication services. Especially the field bus, which is applied to the production site to realize two-way multi-node digital communication between microcomputerized measurement and control equipment, thus forming a new type of network integrated fully distributed control system-field bus control system FCS (Filed bus Control System) ).
In the factory production network, the devices that can be connected via fieldbus are collectively referred to as "field devices/instruments". From the perspective of system theory, industrial robots, as one of the production equipment of the factory, can also be summarized as field equipment. After the introduction of fieldbus technology in the robot system, it is more conducive to the integration of robots in the industrial production environment.
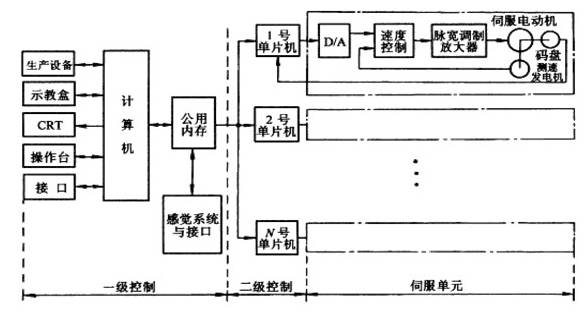 Block diagram of distributed control systemThe advantages of the distributed control system are: system flexibility is good, the risk of the control system is reduced, the use of multi-processor distributed control is conducive to the parallel execution of system functions, the processing efficiency of the system is improved, and the response time is shortened.
For industrial robots with multiple degrees of freedom, centralized control handles the coupling relationship between each control axis very well, and can be easily compensated. However, when the number of axes increases to make the control algorithm very complicated, its control performance will deteriorate. Moreover, when the number of axes in the system or the control algorithm becomes very complicated, it may lead to the redesign of the system.
Em contrapartida, cada eixo de movimento da estrutura distribuída é processado por um controlador, o que significa que o sistema possui menos acoplamento entre os eixos e maior reconfiguração do sistema.
"Industry 4.0" refers to the fourth industrial revolution after steam engine, electrification and automation. It combines traditional industry with digital information technology and realizes intelligent production with the help of technologies such as big data and cloud computing. In China, "Industry 4.0" means the upgrading of the country's manufacturing industry. For this reason, China has specifically put forward the development goal of "Made in China 2025". The goal is to move from a major manufacturing country to a strong manufacturing country by 2025.


