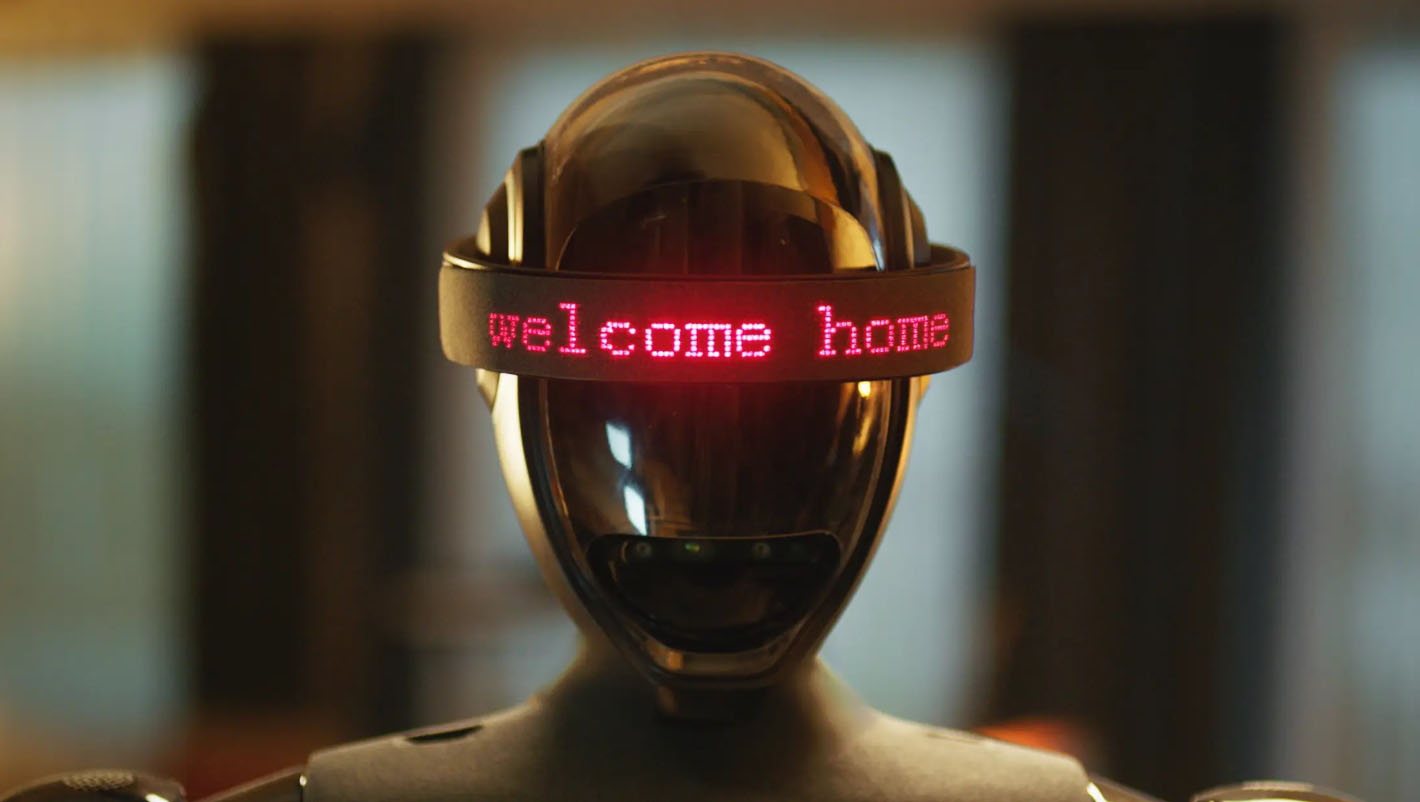
On November 13, 2024, the humanoid robot brand CASBOT officially released its first full-size bipedal humanoid robot "CASBOT 01", a general-purpose brain-like intelligent robot for multiple scenarios. This is a brilliant answer from CASBOT in less than a year since its establishment, and it also marks the arrival of a new entrant in the humanoid robot track with rapid commercialization capabilities.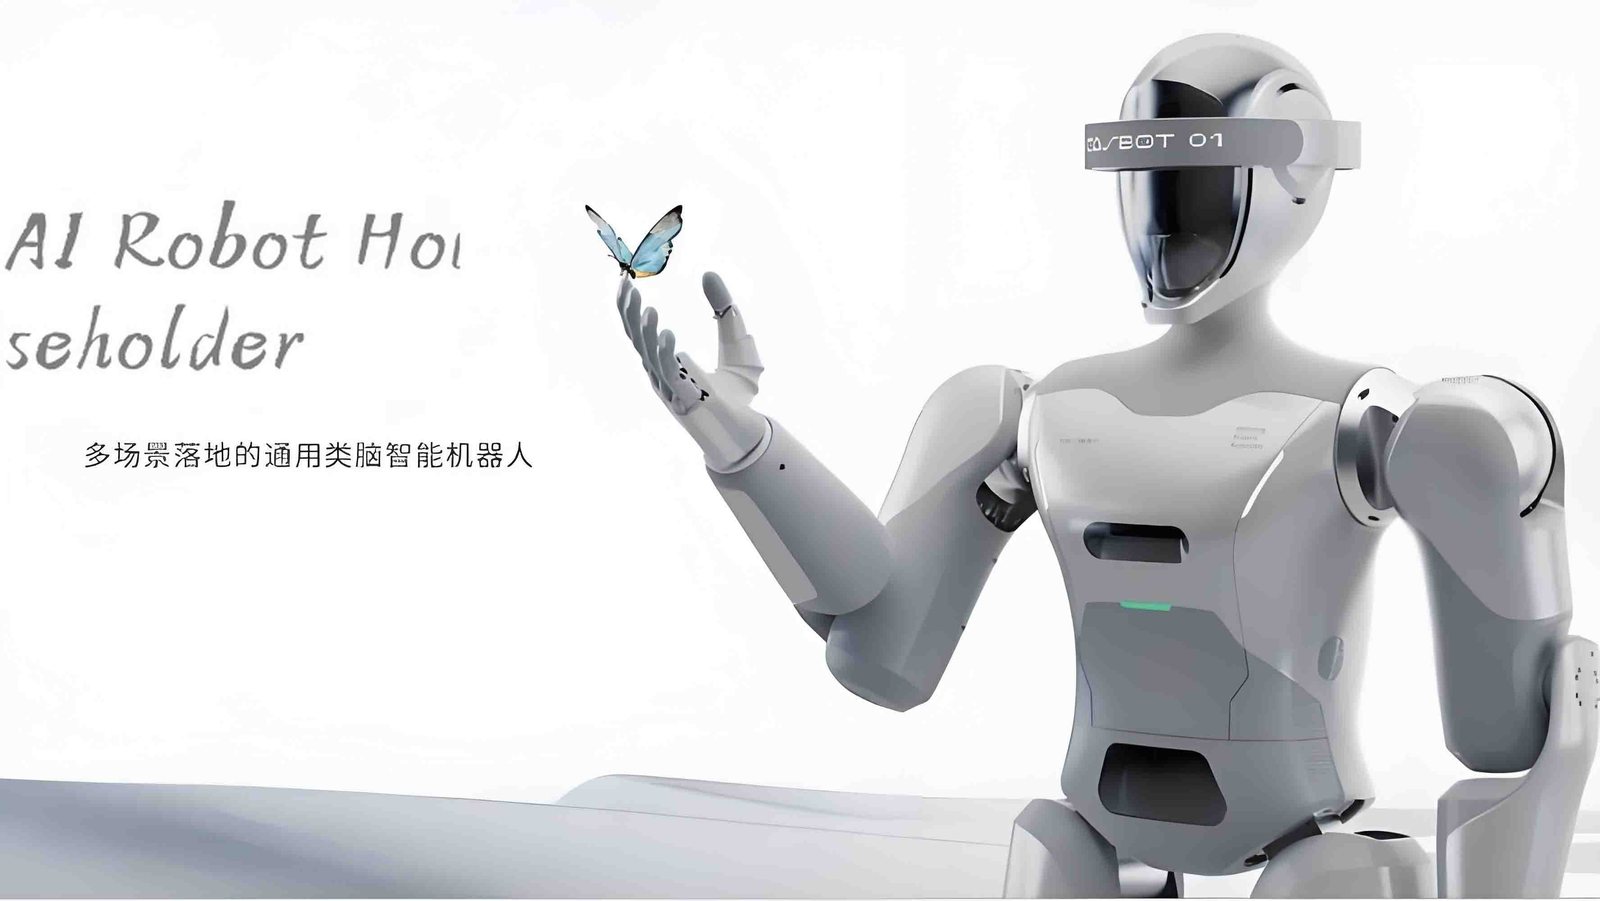 Desde a sua criação, a CASBOT acumulou muitos parceiros em navegação aeroespacial, resgate de emergência, operações subterrâneas, fabricação industrial e serviços comerciais, e explorou novos cenários para aplicações empresariais inteligentes incorporadas.
Graças aos grandes empreendimentos de projetos anteriores e à experiência prática de implementação, a CASBOT aperfeiçoou uma rota de desenvolvimento orientada a cenários que impulsiona a iteração tecnológica.
Comece com o fim em mente, nascido como humano
No campo da inteligência incorporada, não há consenso no debate sobre a forma última.
In the view of CASBOT team, the world is "measured by people". In the physical world, most environments, objects and tools are designed according to the scale of "people". Therefore, robots that are close to human form can better adapt to the complex physical world. For example, using vision instead of "eyes" to process physical world data, the robot's understanding will not be distorted, and the versatility of humanoid robots will be maximized, and they will truly integrate into the work and living environment of "people".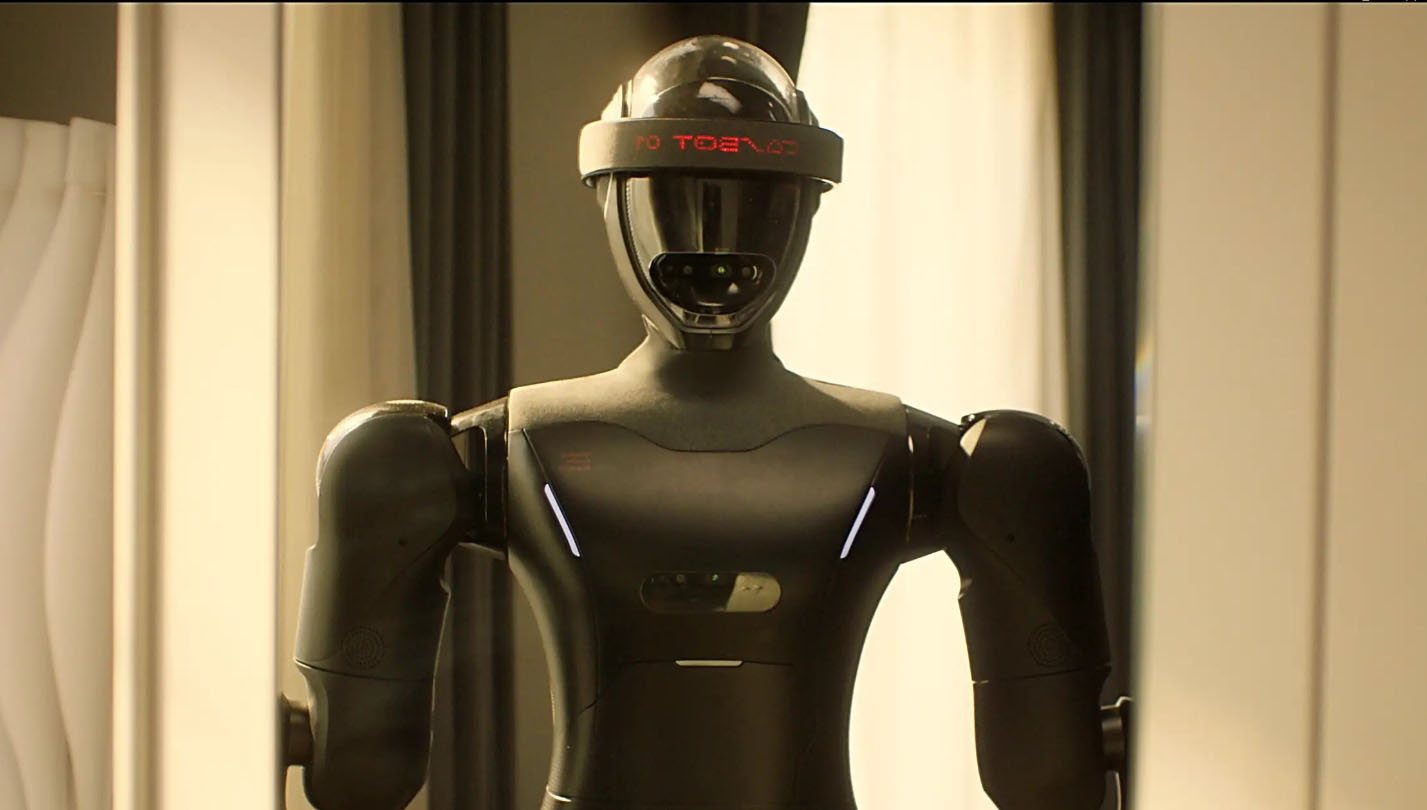 Design estético, biônica universal
“CASBOT 01” is 179cm tall and weighs 60kg. It has 52 degrees of freedom, a computing power of 550T, and a battery life of more than 4 hours. It also has a more memorable nickname called “Wednesday”, which makes it more approachable through its friendly appearance design. From the product film released, we can see that “Wednesday” can not only stand on two feet and walk steadily, but also organize clothes, assemble desk lamps, replace light bulbs, and even screw in screws.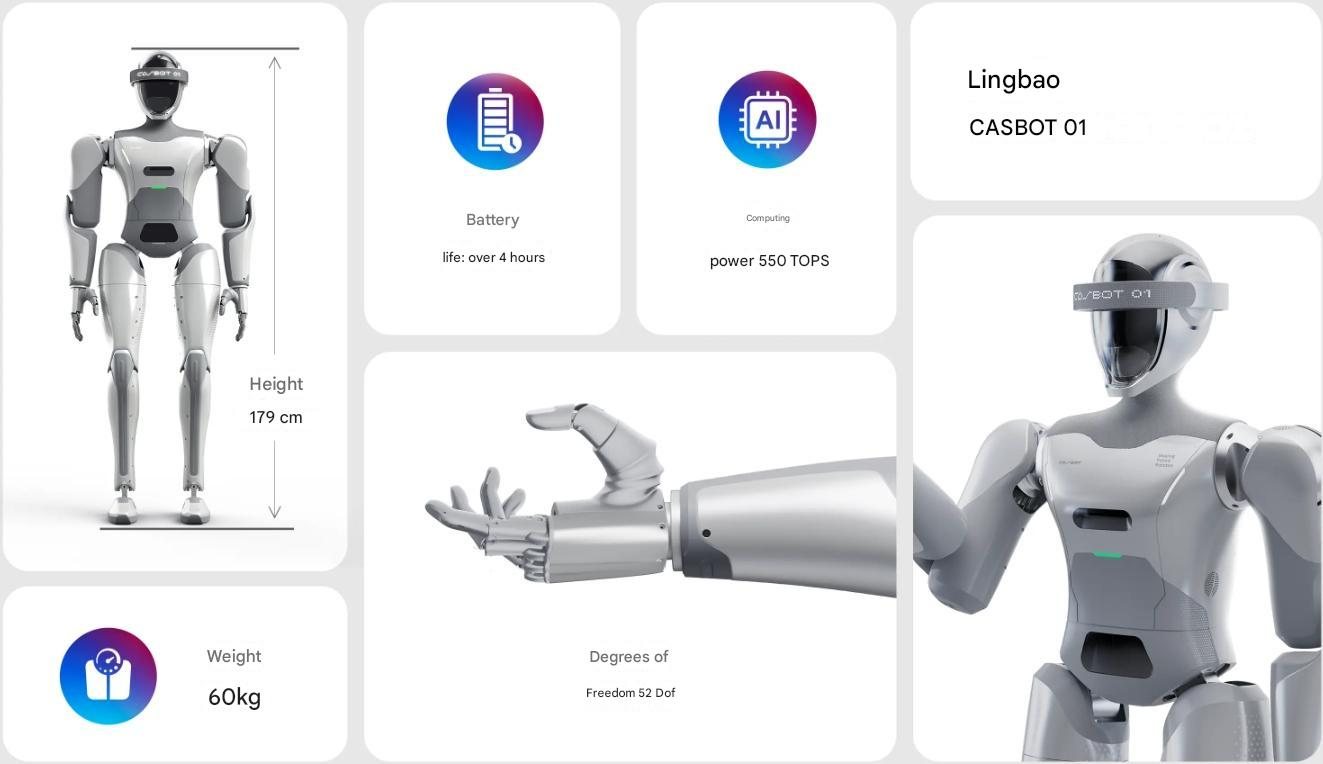 Em termos de design de identificação, o CASBOT 01 consegue uma fusão perfeita entre engenharia mecânica e estética orgânica através da decomposição visual e generalização abstrata das proporções dos músculos humanos.
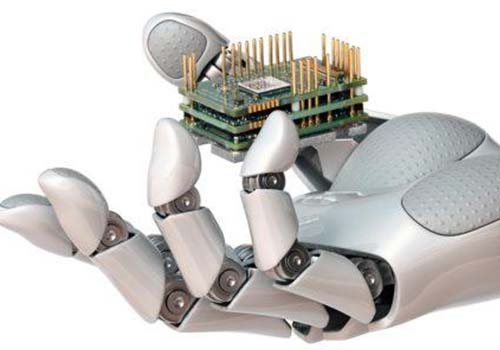
As the end effector for fine operations, CASBOT 01's five-finger bionic dexterous hand weighs 800g per hand and has a rated load of 5kg. It adopts a highly compact overall configuration and a bionic design that integrates drive-sensor-sensing-control systems, as well as a multi-source perception system design of touch-force-vision. By optimizing control algorithms and motion planning, it imitates the flexibility of human hands in operations, faces fine operation scenarios, and strives to solve the difficulties of "dexterity" and "operation".
Com o forte suporte de software e hardware, são realizadas operações hábeis de longo prazo que podem ser rapidamente aprendidas e generalizadas.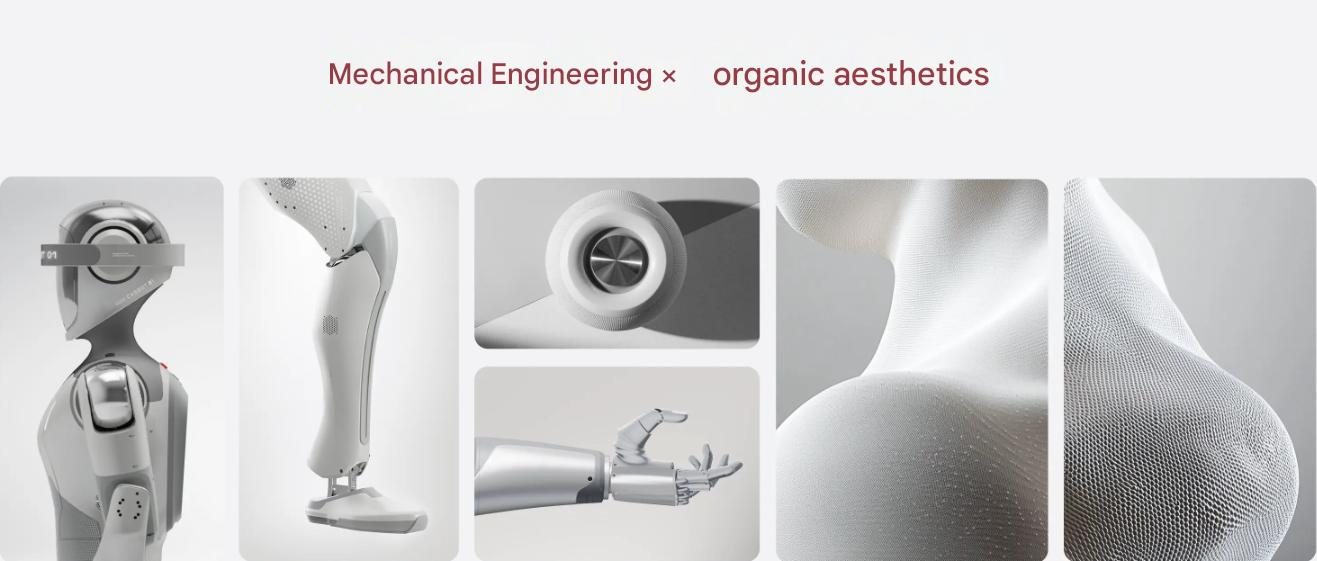 Tecnologia full stack para criar produtos em nível de aplicação
In the mechanical structure design part, after multiple optimizations, CASBOT has balanced the range of motion and aesthetics. While the whole machine is extremely light, high-strength metal materials are used to process complex curved surfaces to form an ultra-thin hollow cavity with intermediate reinforcement, ensuring the stability and impact resistance of the structure.
CASBOT independently developed three series of integrated joints including planetary, harmonic, and linear joints, with a peak torque density of up to 207Nm/kg and joint efficiency exceeding 80%. The joint uses a force control optimization strategy based on current or sensors, supplemented by model tracking control, and adopts vibration suppression, inertia identification, friction compensation and "gain self-tuning" technologies to achieve high-precision "torque loop" control effects, inertia matching according to the overall needs of operation and control, and improves the dynamic response frequency of a single joint: efficient and stable communication to meet the bandwidth requirements of high dynamic force control: energy management strategies are optimized through impact conditions, combined with servo, single leg and whole machine overcurrent protection measures, and nearly a thousand hours of life testing have been completed to ensure long-term stable operation of the joint.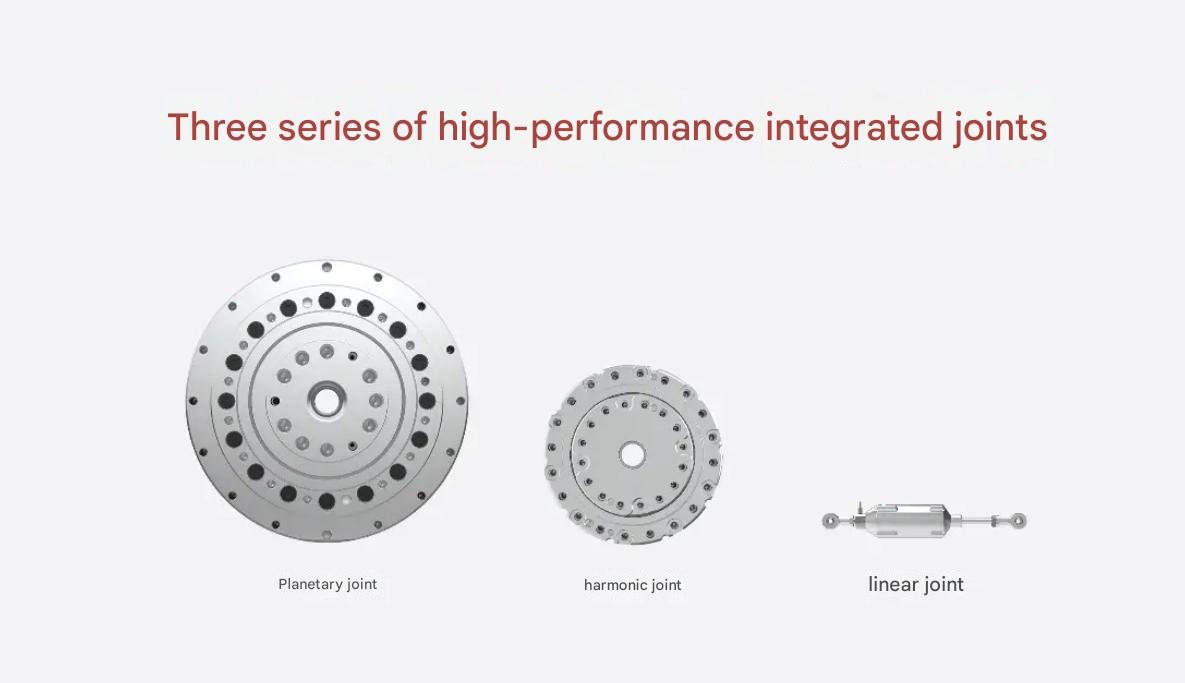 O excelente desempenho estrutural do corpo fornece uma base sólida para o treinamento de controle de movimento do robô.
The overall motion control framework of CASBOT 01 combines adversarial motion priors and whole body control (WBC) to achieve integrated motion control. Through this framework, the robot can robustly perform whole-body tasks in complex dynamic environments. On the basis of the traditional reinforcement learning training framework, Lingbao CASBOT simultaneously trained the generative adversarial imitation learning network, the generator and the discriminator to continuously play games, so that the model will generate highly anthropomorphic motion control strategies.
Graças ao banco de dados rico e completo, ele pode mostrar uma variedade de diferentes capacidades de movimento de acordo com o conteúdo da tarefa, como caminhar, correr, pular, etc., de forma a completar com eficiência as tarefas especificadas, melhorando muito a versatilidade do modelo.
At the "brain" level, after evaluating the industry's mainstream "end-to-end embodied large model, segmented decision model, and teaching imitation training skill model", Lingbao CASBOT chose the hierarchical end-to-end model technology route, which can combine the advantages of various routes while avoiding their shortcomings.
Em termos de treinamento de modelo, o Lingbao CASBOT adota uma rota tecnológica inovadora do real para o virtual, síntese de dados, treinamento híbrido e depois do virtual para o real. Através de modelos ponta a ponta em camadas e tecnologia de treinamento híbrida, os robôs podem se tornar mais inteligentes, flexíveis e autônomos.
Quando o “corpo” e o “cérebro” trabalham juntos, o robô ganha a capacidade de cognição, compreensão e planejamento de tomada de decisão de alto nível.
The head of CASBOT 01 has two degrees of freedom and is equipped with multiple RGBD cameras, lidars, IMUs and other sensors, which can perform dual visual and auditory interactions. Under the operation framework, through end-to-end multimodal dexterous operation large models, distillation and quantization technologies, the robot hand successfully realizes the generalization and adaptability of "environment, object, task".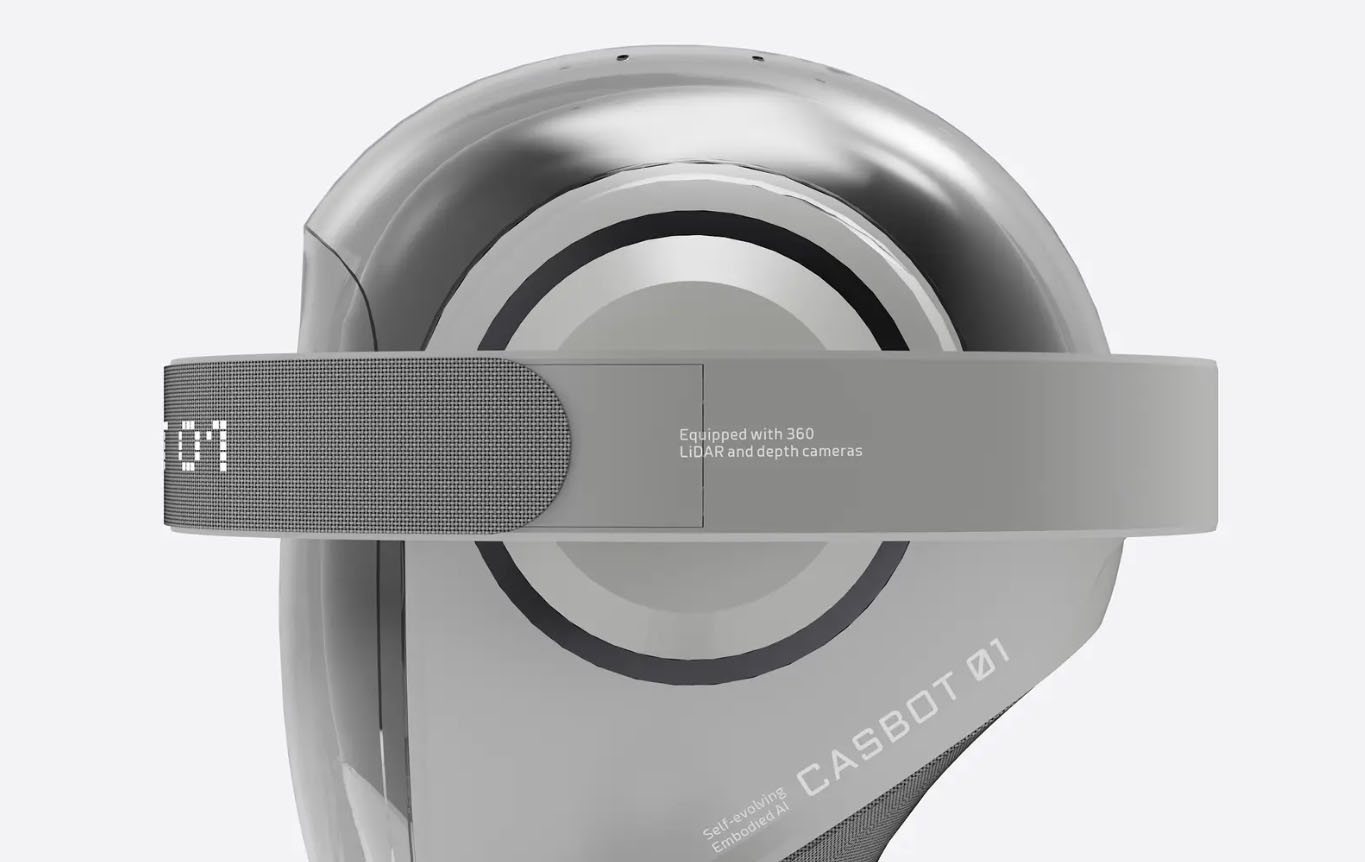 Cenários retroalimentam a tecnologia, explorando um mercado de 100 bilhões
2024 is considered the "first year of commercialization of humanoid robots". A recent report released by the China Humanoid Robot Industry Conference shows that the scale of the Chinese humanoid robot market will reach 2.76 billion yuan in 2024, and is expected to grow into a 100 billion yuan market in 2030.
Behind the data are two sides of the development of the humanoid robot industry: on the one hand, thanks to its strong industrial penetration and industrial integration capabilities, it has become an important force for "new quality productivity" and a new pillar for promoting the high-quality development of China's economy; on the other hand, with a market scale of 100 billion, commercialization has become a "must-answer question" for the humanoid robot industry.
In September 2024, Lingbao CASBOT and Lenovo Manufacturing as a Service signed a strategic cooperation agreement and became the first batch of core cooperative enterprises of Lenovo's "Spark Plan". The two parties have created a new paradigm of "two-way empowerment" cooperation, laying the foundation for the commercialization and application of Lingbao CASBOT's humanoid robot products.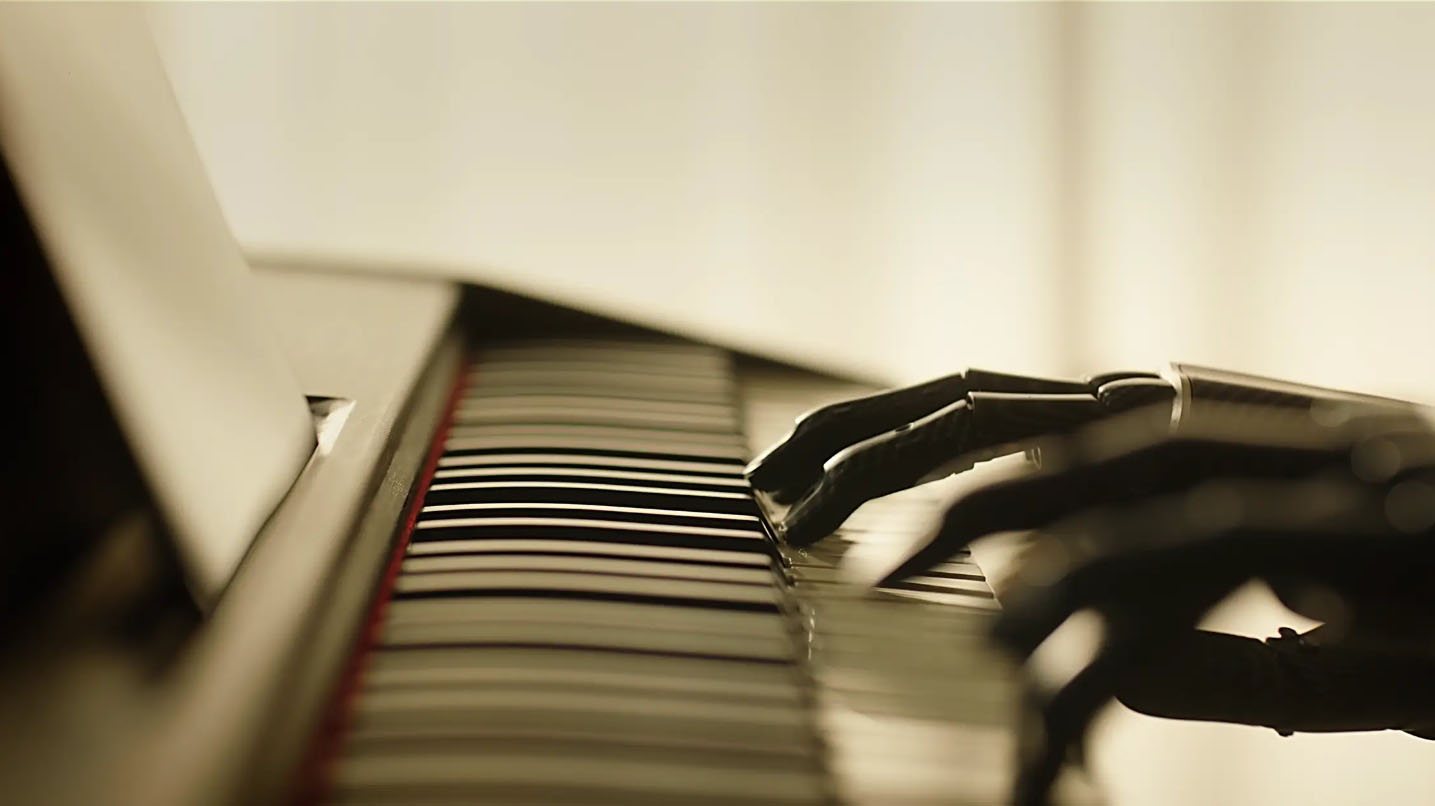 For Lenovo, the introduction of Lingbao CASBOT's technological innovations in flexible force control and precision operation in Lenovo's intelligent manufacturing factory can not only improve the automation level of the production line and reduce production costs, but also directly inject new vitality into Lenovo's intelligent manufacturing factory and bring breakthrough assistance to Lenovo's intelligent manufacturing upgrade.
Para Lingbao CASBOT, cenários comerciais reais podem permitir a iteração de tecnologia, e o cultivo profundo de cenários de aplicação o ajudará a ficar à vontade em cenários diversificados no futuro, alcançando assim as demandas "universais" da indústria.
In order to better serve the market and meet the diversified needs of different industries, Lingbao CASBOT will also open the basic skills library of humanoid robots to all industry partners to jointly build a more refined professional skills library, and look forward to better understanding the needs of different industries, so that humanoid robots and embodied intelligent technologies can serve various scenarios and ultimately serve people.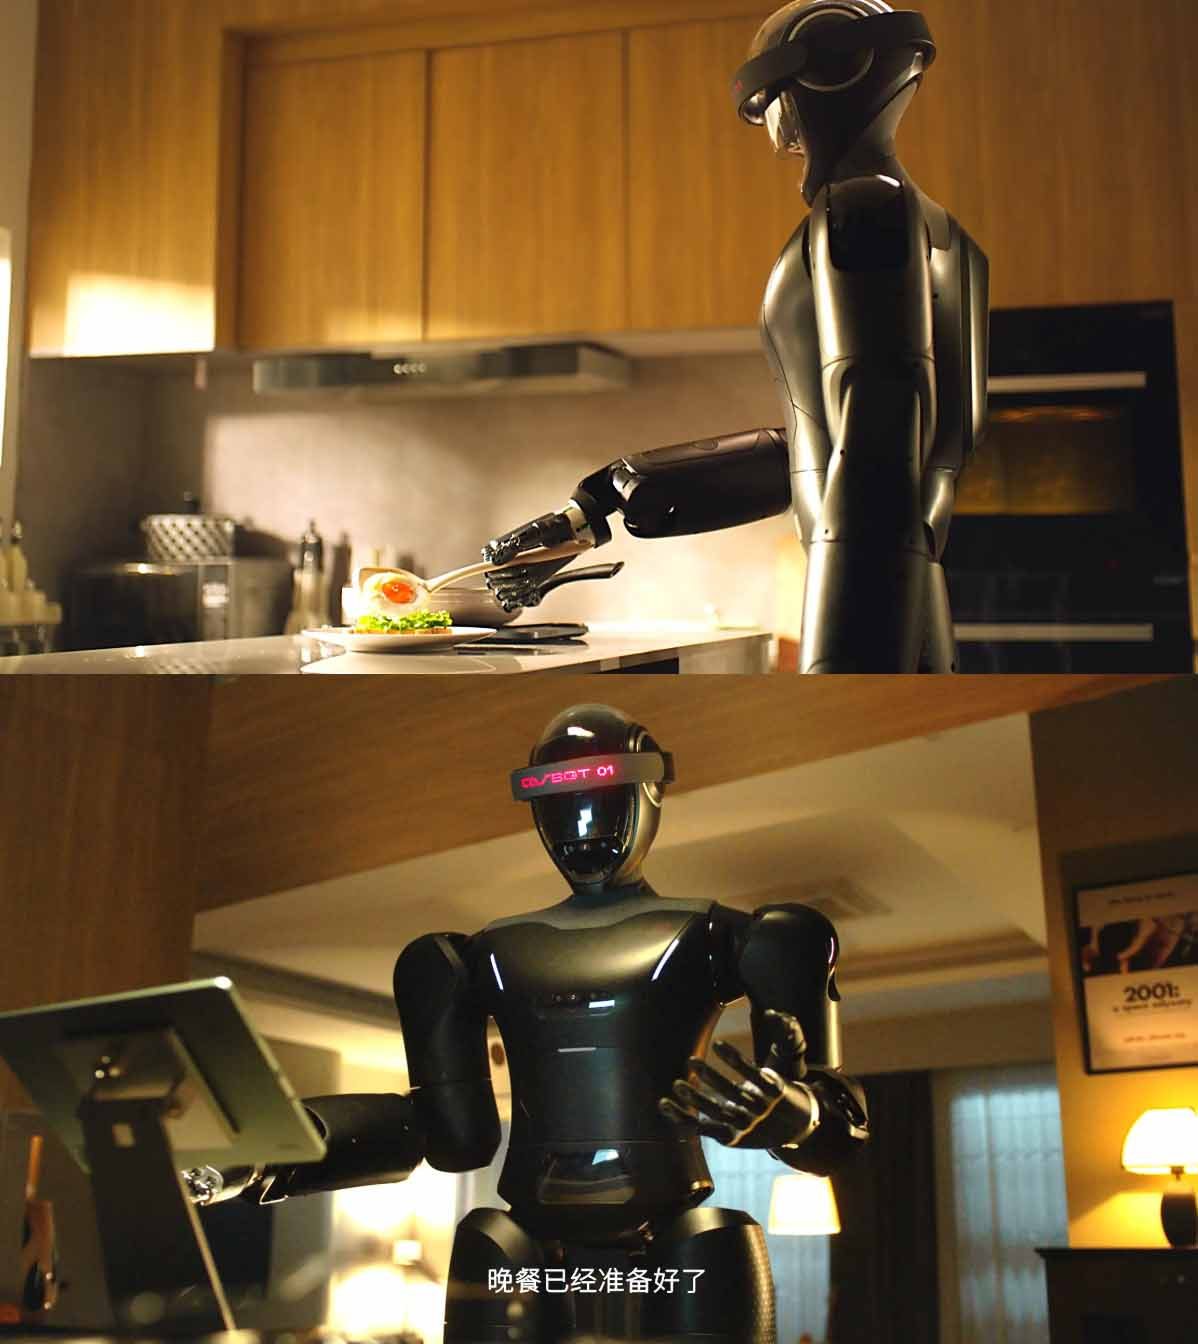 Iteração contínua, simbiose inteligente
Assim como o tema da conferência CASBOT é “Nascido para a Humanidade” – esta é a visão da CASBOT, libertar o potencial humano com tecnologia inteligente.
At the conference, CASBOT 01 also released "ONE MORE THING" - "CASBOT NEXT GEN" on behalf of the host. As an upgraded version of CASBOT 01, it will be equipped with Embodied Brain 2.0, Visual Basic Large Model 2.0, and an upgraded version of the universal motion prior controller, and a dexterous operation large model, which can complete the whole body motion posture following control and human operation video data mixed training, and achieve two-way improvement of motion operation.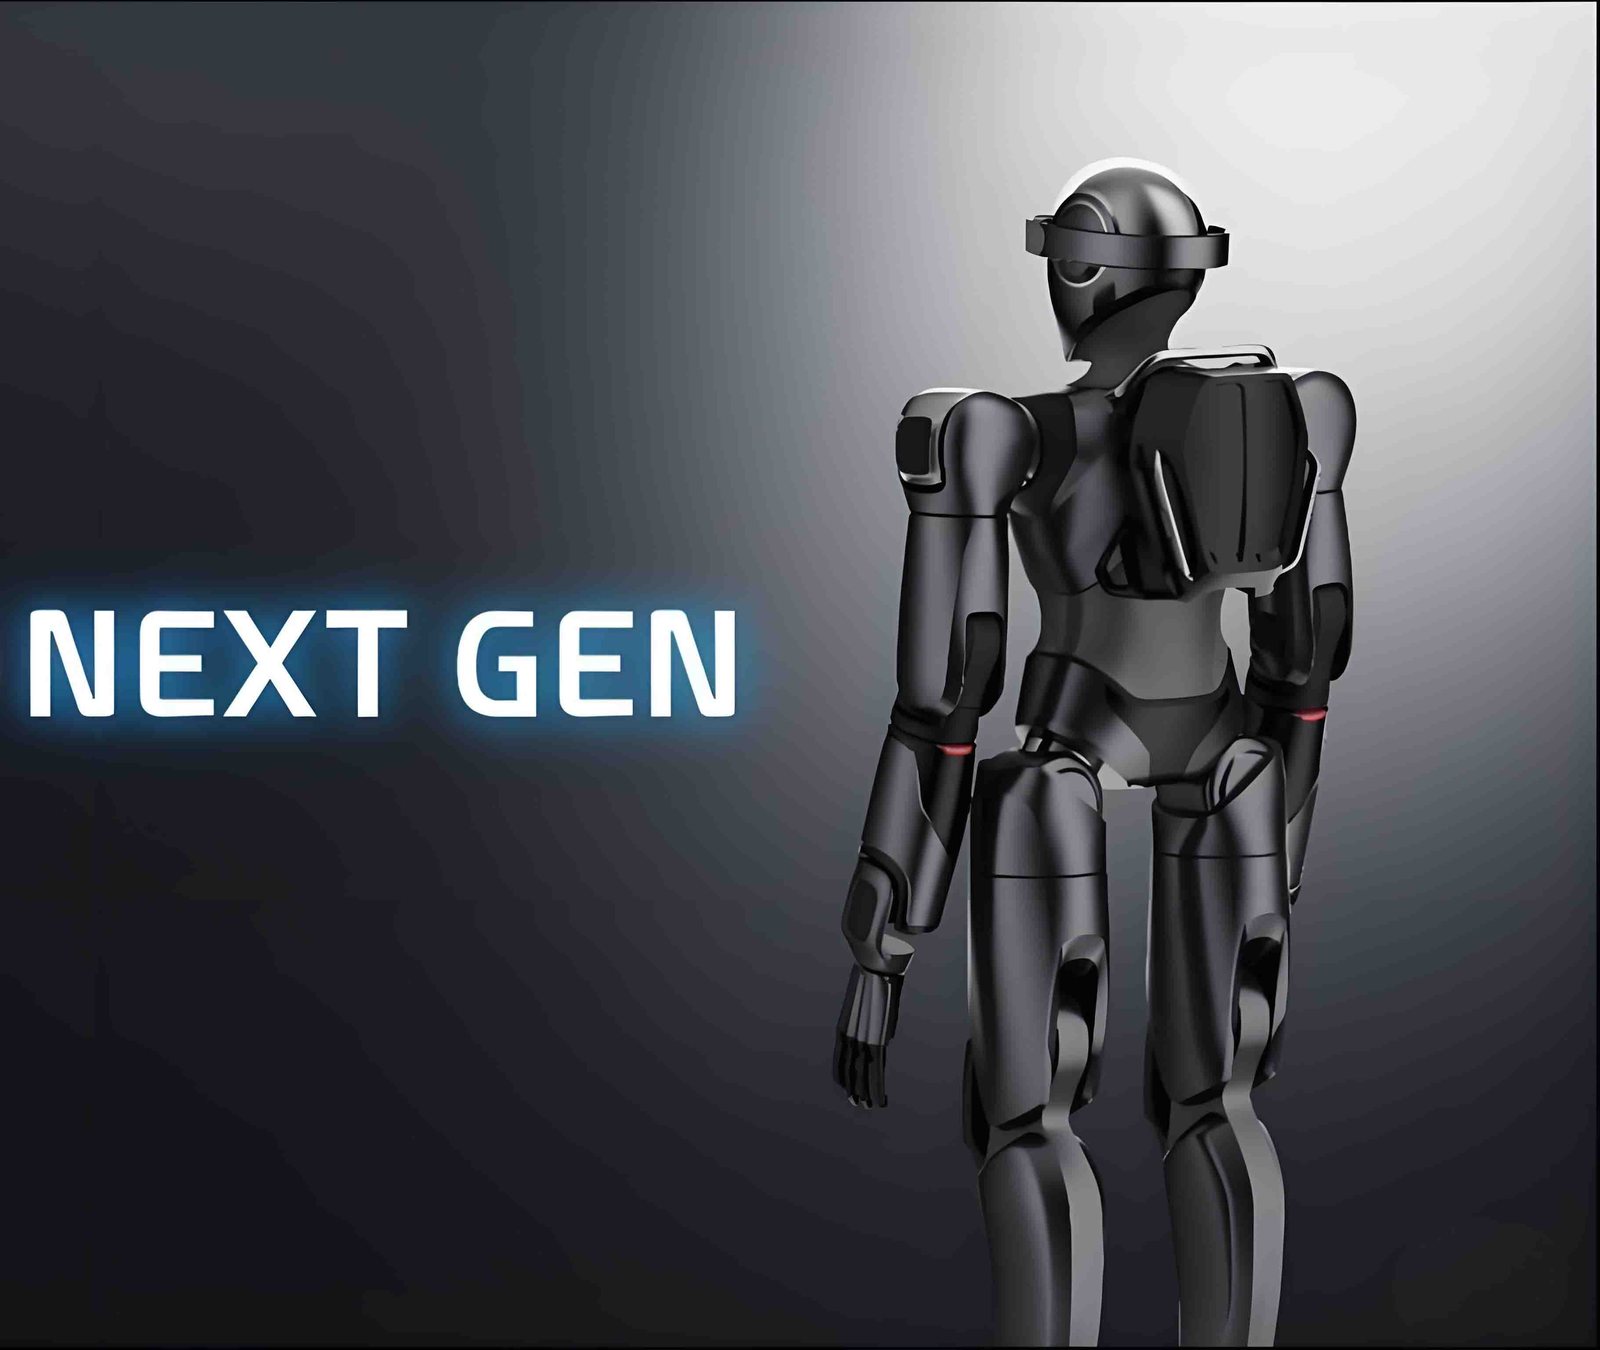 É previsível que a CASBOT continuará a estar na vanguarda da inovação tecnológica e dos cenários de implementação comercial e, através do cultivo contínuo no mercado B-end, estabelecerá uma base sólida para a "competição final" no futuro mercado C-end.
Com a evolução tecnológica passo a passo e a verificação do produto, acredito que, no futuro, a CASBOT acabará por concretizar a visão futura de "criar uma espécie de inovação inteligente e moldar um novo mundo de simbiose inteligente".