


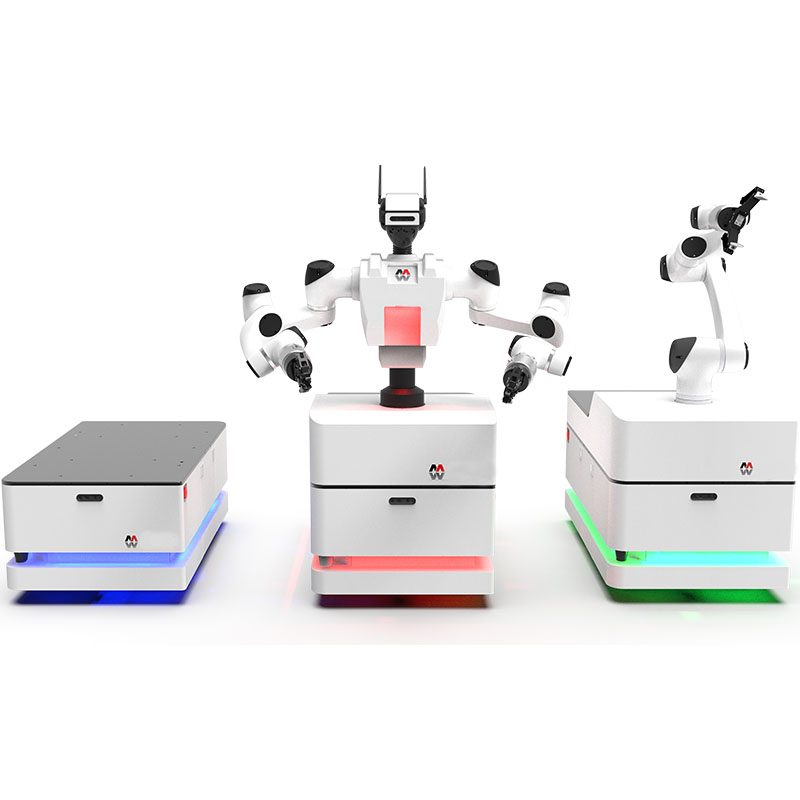
AMR Solutions with Dual-Arm Collaborative Mobile Robots
The MOD AMR solutions with dual-arm collaborative is a collaborative robot for assembly / pick and place. Lead time is 15 days; pricing is quoted per configuration. Certifications: CE documentation on request.
- Model
- MOD
- Lead time
- 15 days
- Category
- Collaborative Robots
What This Platform Is For
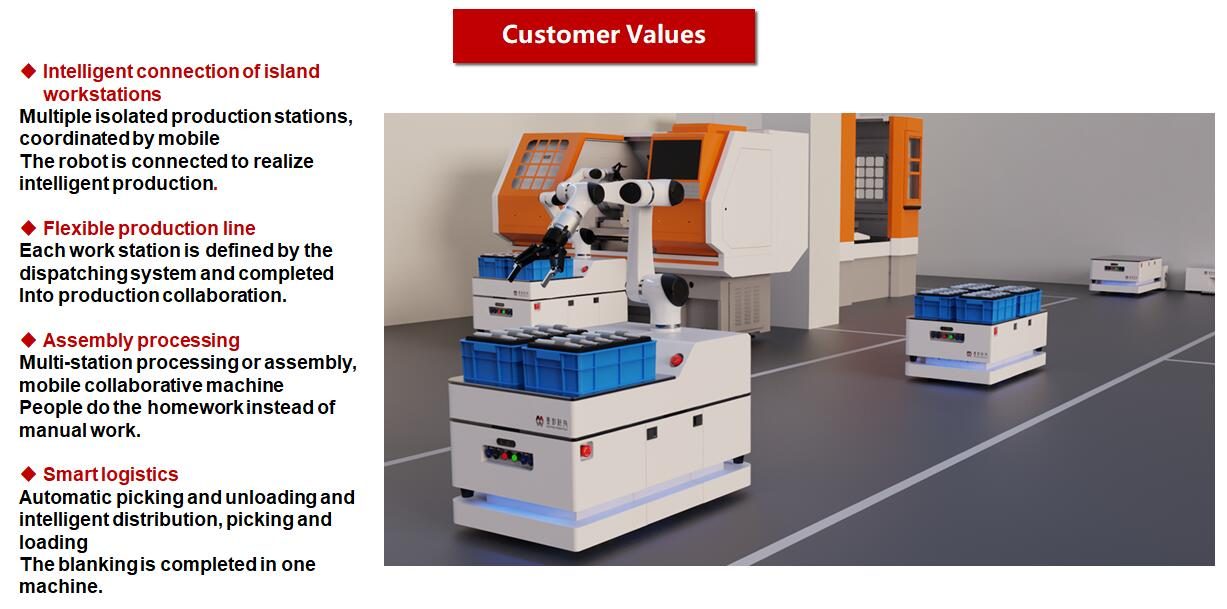
The MOD mobile collaborative robot itself is an operator that can move autonomously. Timely complete the tasks of multiple different stations in the production line. Using Mecanum wheel drive mode.
Commercial Terms
| Quotation | Priced per configuration — reply within 48 hours |
|---|---|
| Lead time | 15 days |
| MOQ | 1 unit |
| Origin | China |
| Port of loading | Shenzhen, China |
| Incoterm | FOB Shenzhen / CIF on request |
| Payment | 30% deposit, 70% before shipment |
| Warranty | 24 months standard, 36 months optional |
Product Details
Application notes, construction drawings and video from the TROY engineering file — the same documentation shipped with the quotation.
Product series
| MDN series differential mobile robot MDN-0300, MDN-0600, MDN-1200 MON series omnidirectional mobile robot MON-0300, MON-0600, MON-1500, MON-6000 MDS series differential single arm mobile collaborative robot MDS-0300, MDS-0600, MDS-1200 MDD series differential dual-arm mobile collaborative robot MDD-0600, MDD-1200 MOS series omnidirectional single-arm mobile collaborative robot MOS-0300, MOS-0600, MOS-1500 MOD series omnidirectional dual-arm mobile collaborative robot MOD-0300, MOD-0600, MOD-1500 300 6000kg chassis load 3-35kg arm wrist load ±1mm chassis repeat positioning accuracy ±0.05mm Repeated positioning accuracy of robotic arm Up to 21-axis redundant system to easily complete complex tasks | 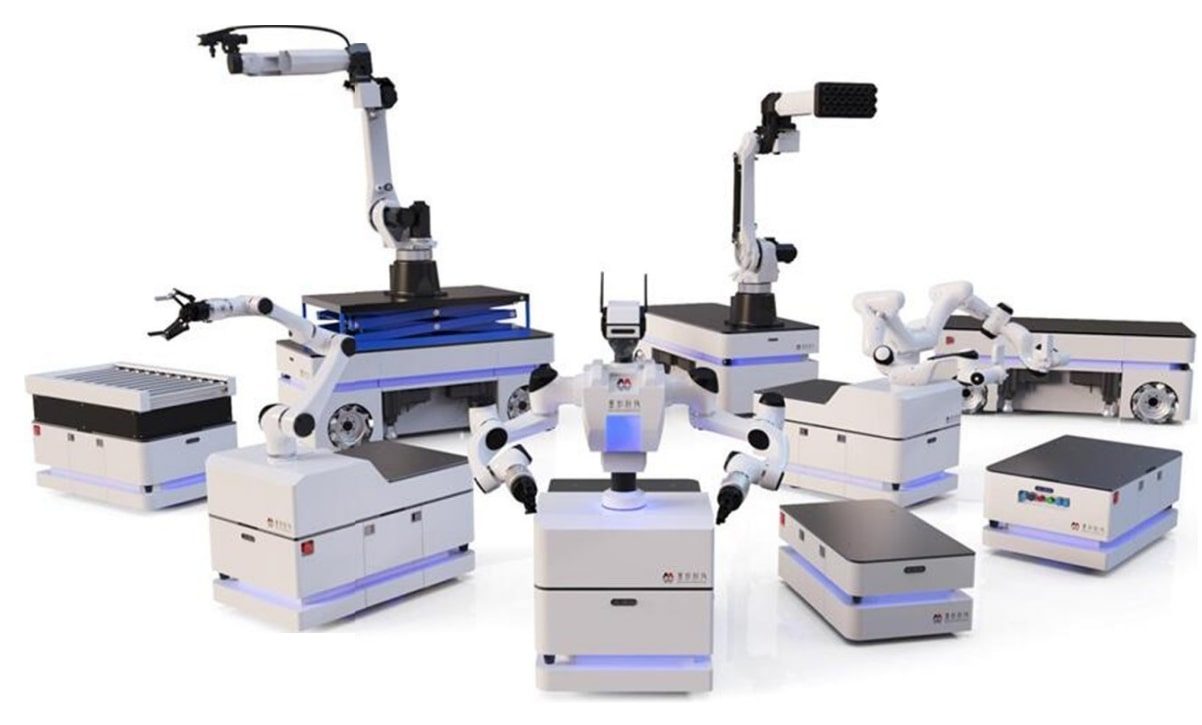 |
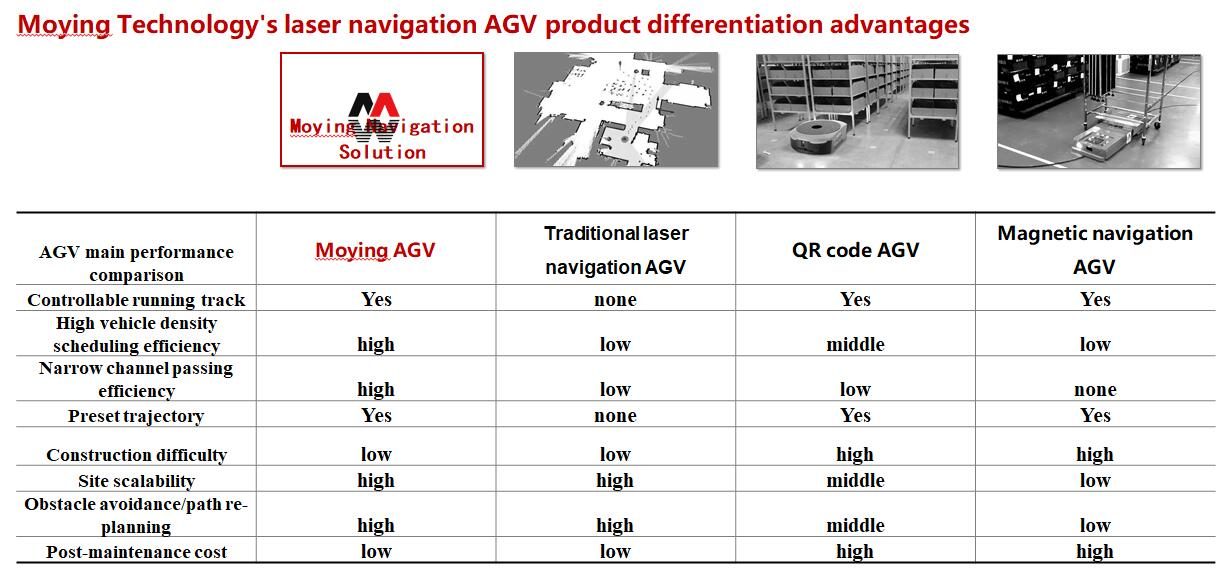
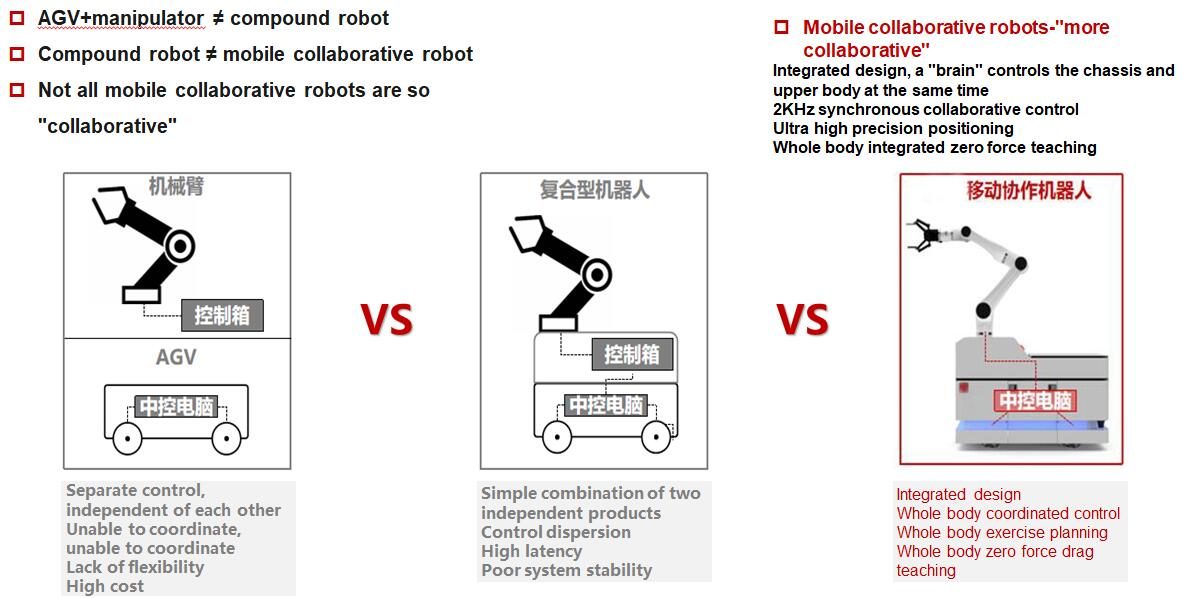
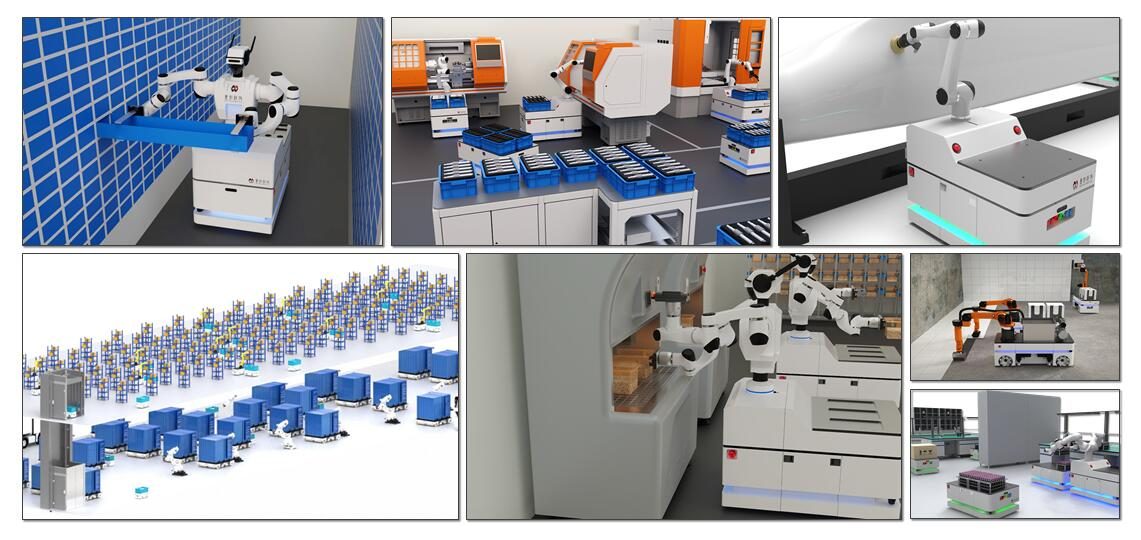
MOD series Omnidirectional dual-arm mobile collaborative robot | Robot Introduction: MOD (Moying Omnidirectional Dual-arm Collaborative Robot) The MOD mobile collaborative robot itself is an operator who can move autonomously, and can complete tasks at multiple different stations in the production line at the same time. The Mecanum wheel drive mode is adopted to realize 360° movement in any direction, which can work flexibly in a small working space and effectively improve the utilization rate of the site and the production efficiency. By collocation with a wealth of end fixtures and visual recognition equipment, it can realize the functions of grasping, assembly, sorting, loading and unloading, moving, handling, and visual inspection, and it is more accurate, stable and efficient. The dual-arm bionic design is closer to human operation, and is suitable for a variety of typical work stations that require both hands at the same time. | ||
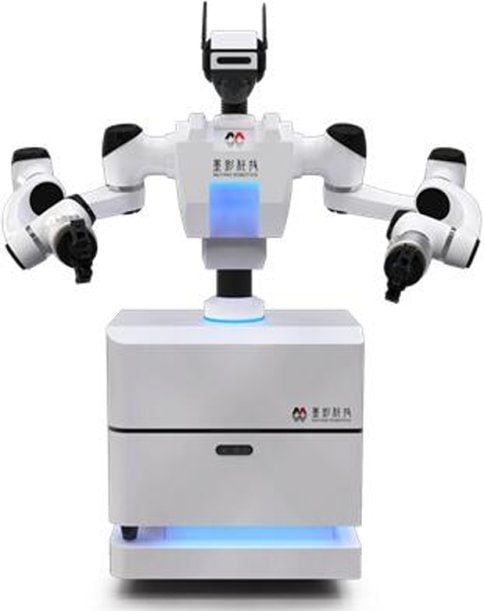 | Cost-effective Human-like design directly replaces manual operation, and can be deployed quickly without modifying the existing production line, greatly reducing the cost of transformation. | Flexible intelligence Any combination of production processes, around an isolated work platform, constitutes a flexible intelligent production line on demand. | High versatility One MOD mobile collaborative robot can realize application scenarios that require the cooperation of multiple people or multiple fixed robotic arms and AG Vs. |
Automatic tools quick change The end fixture of the robotic arm can be automatically replaced online to adapt to a variety of tasks and greatly reduce deployment costs. | Safe collaboration The high-precision collaborative robotic arm, through sensitive force control feedback, does not need to install guardrails, and can also ensure the safety of personnel. | Flexible force control Through the sensitive feedback and calculation of the joint torque, and the advanced variable impedance control algorithm, the assembly action with high precision can be safely and effectively realized | |
MOD series Omnidirectional dual-arm mobile collaborative robot | Robot Features: / Predictable navigation path planning / Intelligent obstacle avoidance Easy operation | Up to 21 degrees o f freedom overall positioning Automatic global positioning at boot Automatic recharg e & online battery quick change Remote emergency stop | |
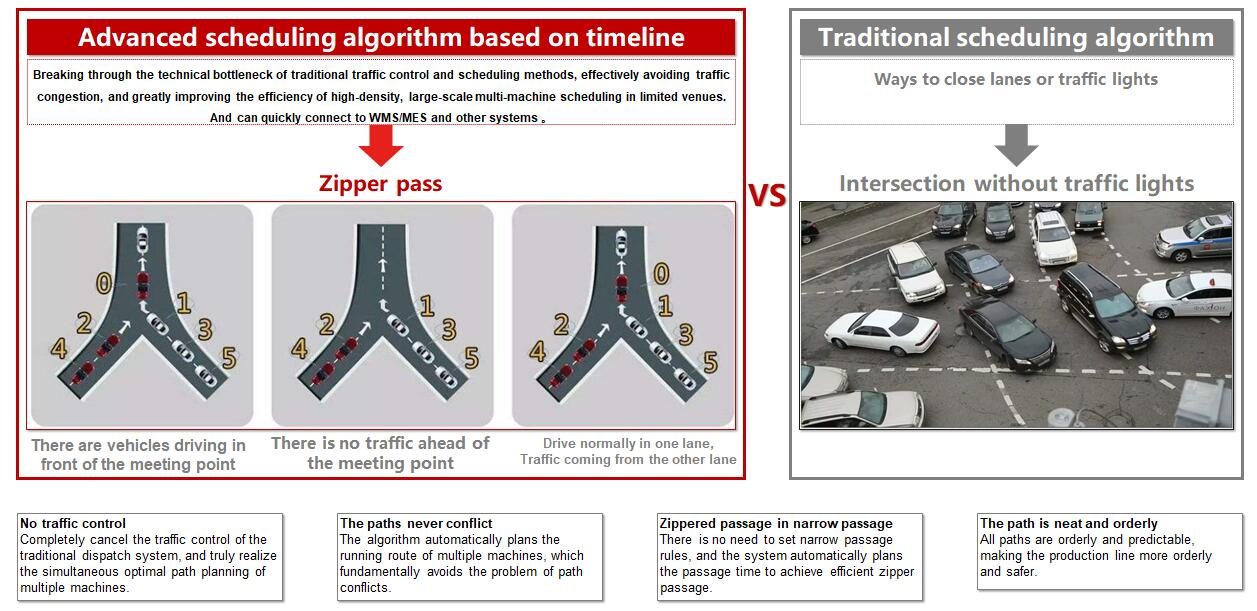
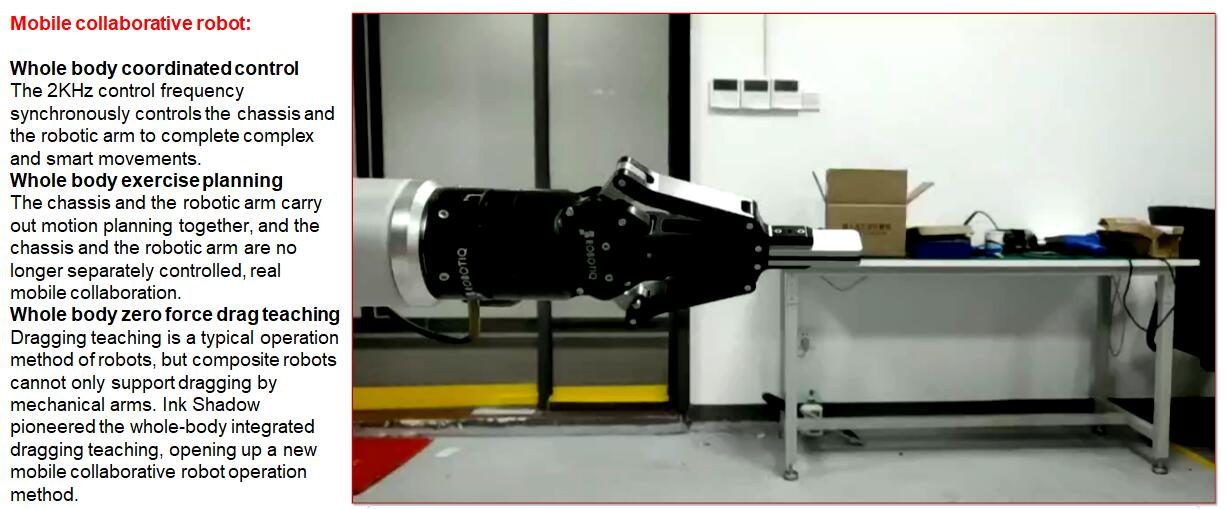
 | Ultra high control frequency The whole body of the robot supports a control frequency of up to 2KHz. and with advanced control algorithms, it can easily handle flexible and complex tasks. | Overall coordination Through the advanced control algorithm of Ink Shadow Technology, real-time coordinated control of the mobile chassis. dual robotic arms and fixtures enables complex mobile operations. | Multi-machine multi form scheduling system The original multi-machine multi-form scheduling algorithm simultaneously controls various forms of robots such as AGVs, robotic arms, and mobile collaborative robots to achieve large-scale collaboration between machines. |
Omnidirectional movement 4 Mecanum wheel drive. 360° moving in any direction, can work flexibly in a small working space, effectively improving site utilization and production efficiency. | Bionic The dual-cooperative robotic arm design that can lift and rotate is closer to human operation, and is equipped with a variety of typical work stations that require both hands to work at the same time. | High redundancy With up to 21 degrees of freedom, even in complex environments, it can accurately complete complex grasping, assembly, loading and unloading and other actions. |
PParameter Type | MOD-0300 Parameters | Configuration | |
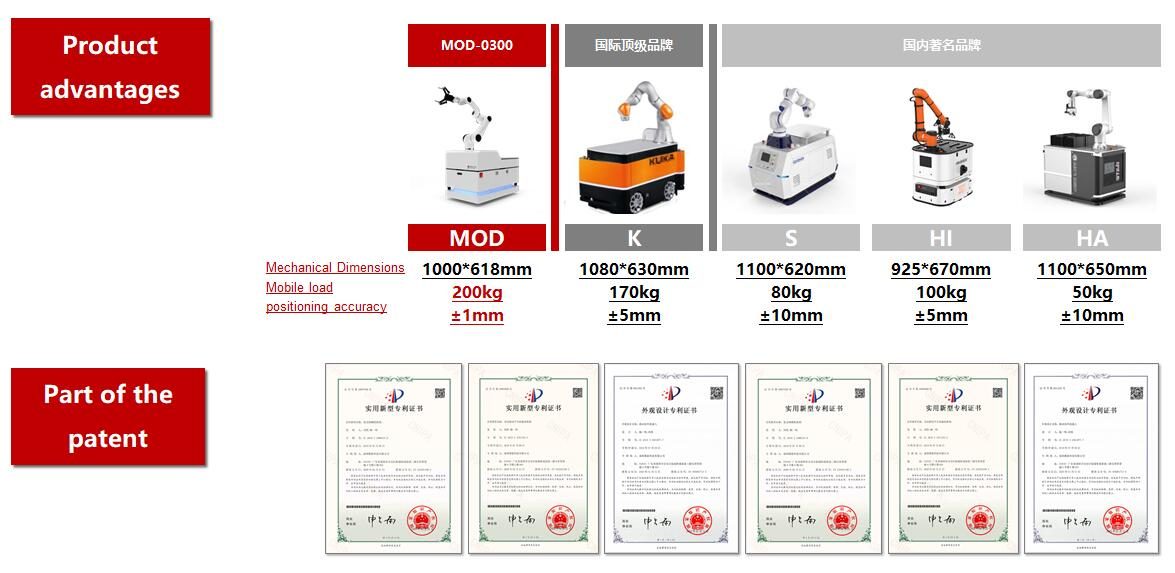
Basic parameters of the chassis | Dimensions (length x width x height) | 1000x618x425 mm | Customizable |
Ground clearance | 30mm | Standard | |
Net, weight | ≤160 kg | Customizable | |
Load surface size (length x width) | 900x580 mm | Customizable | |
Max payload | 300 kg | Customizable | |
Motion performance | Driving mode | Omnidirectional | Standard |
Top driving speed | 1.0 m/s | Standard | |
Top traverse speed | 0.56 m/s | Standard | |
Top diagonal speed | 0.56 m/s | Standard | |
Maximum linear acceleration | 0.5 m/s² | Standard | |
Grade ability | ≤ 3° | Standard | |
Maximum obstacle height | 10 mm | Standard | |
Repeat accuracy | ± 1 mm | Standard | |
Navigation | Lidar X2 | Optional by brand | |
Vision assistant | Customizable | ||
Manipulator parameters | Degree of freedom of single manipulator | 6 | Standard |
payload of single arm | 3/5 kg | Customizable | |
Single robotic arm working range | 590/800 mm | Varies due to options | |
Repeat accuracy of robotic arm | ± 0.05 mm | Varies due to options | |
Maximum speed at the end | 1 m/s | Varies due to options | |
Number of robotic arms | 2 | Standard | |
Robotic arm brand and specifications | Customizable | ||
Robot torso & head parameters | Trunk lift | Customizable | |
Torso rotation | Customizable | ||
Head freedom | Customizable | ||
Head camera (1-2) | Customizable | ||
Overall parameters | Machine size | 1000x618x1000 mm | Customizable |
Overall size | ≤250 kg | Customizable | |
Machine loading surface size (Length x width) | 580x500 mm | Customizable | |
Platform load of the whole machine | 100 kg | Varies due to options | |
Parameter Type | MOD-0300 Specifications | Configuration | |
Battery life/ battery performance | Nominal battery voltage | DC 48 V | Standard |
battery capacity | 60 Ah | Customizable | |
Charging time | 2.0 h | Customizable fast charging scheme | |
Typical operating time | 8 h | Customizable | |
Capacity lossless charge and discharge times | 1500 fully charged and discharged (Afterwards the battery capacity drops to 80%) | Standard | |
Use environment | scenes to be used | For indoor use on flat floors only | Standard |
Operating temperature | +5℃ ~ 50 ℃ | Standard | |
Environment humidity | 10% ~ 95% No condensation | Standard | |
IP Class | IP 20 | Standard | |
Noisy | <65 dB(Rated working speed) | Standard | |
Internal communication | EtherCAT(Control frequency 2KHz) | Customizable CANOpen (control frequency 500Hz) | |
reserved port | RJ45x1 / USBx2 / HDMIx1 | 4口Customizable | |
End effector & sensor | End effector (gripper, vacuum suction cup, etc.) (optional) | optional | |
Robotic arm visual positioning (optional) | optional | ||
Six-dimensional force sensor | Optional | ||
Security configuration | Lidar x2 | Standard (optional by brand) | |
Depth camera x1 | Standard | ||
Remote control emergency stop (effective range of 15 kilometers) (optional) | optional | ||
Emergency stop button 2 | Standard | ||
Multi-mode sound alert | Standard | ||
Multi-mode light warning | Standard | ||
Safety bumper (optional) | optional | ||
Full Technical Data
| Model | MOD |
|---|---|
| Lead time | 15 days |
| Category | Collaborative Robots |
Values are nominal at 20 °C. Download the datasheet for cad models, torque curves and controller I/O maps.
Where It Runs
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Buyer Questions
What are the key specifications of the MOD?
Model MOD. A full datasheet is available on request.
What is the lead time and MOQ for the MOD?
Lead time is 15 days; MOQ is 1 unit.
How is the MOD priced?
Pricing is quoted per configuration, including tooling and freight where applicable.
Get a Priced Proposal for MOD
Include the part, target rate and destination port. An engineer — not a chatbot — replies within 48 hours.
Same Category
ROKAE SR5 Collaborative Robot - 5kg 6-Axis Compact Cobot (919mm)
ROKAE SR3C xMate Collaborative Robot - 3kg 6-Axis Compact Cobot (705mm)
ROKAE CR35-35C xMate Collaborative Robot - 35kg 6-Axis Heavy-Duty Cobot (2246mm)
Reviewed by TROY Engineering · . Specifications are re-checked against the supplier datasheet at every quotation.