


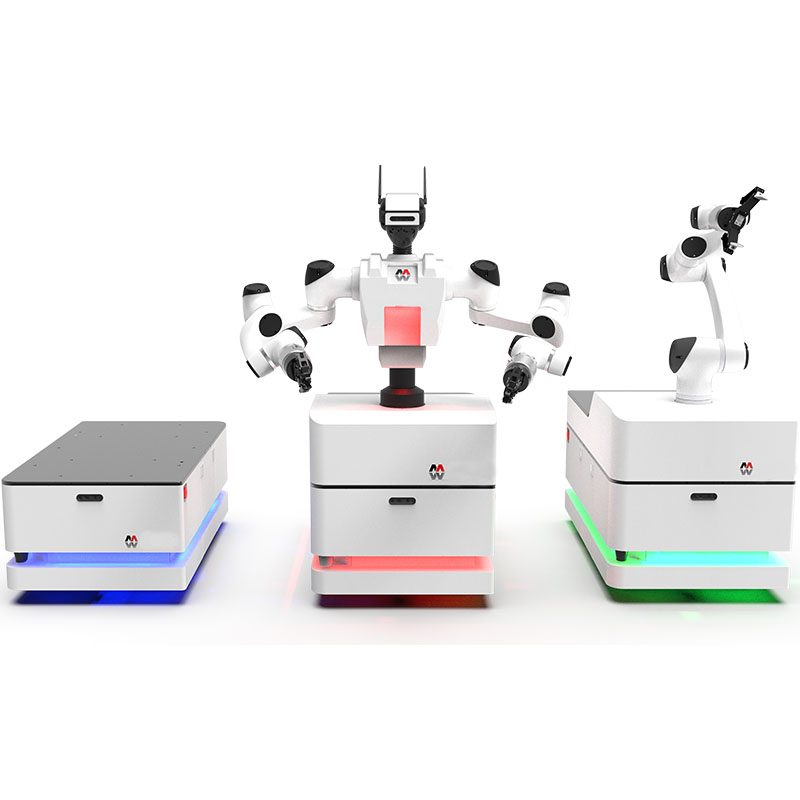
双腕協働移動ロボットによる AMR ソリューション
双腕協働を備えた MOD AMR ソリューションは、組み立て/ピック アンド プレース用の協働ロボットです。リードタイムは15日です。価格は構成ごとに見積もられます。認証: ご要望に応じて CE ドキュメントをご提供します。
- モデル
- MOD
- リードタイム
- 15日
- カテゴリ
- 協働ロボット
このプラットフォームの目的
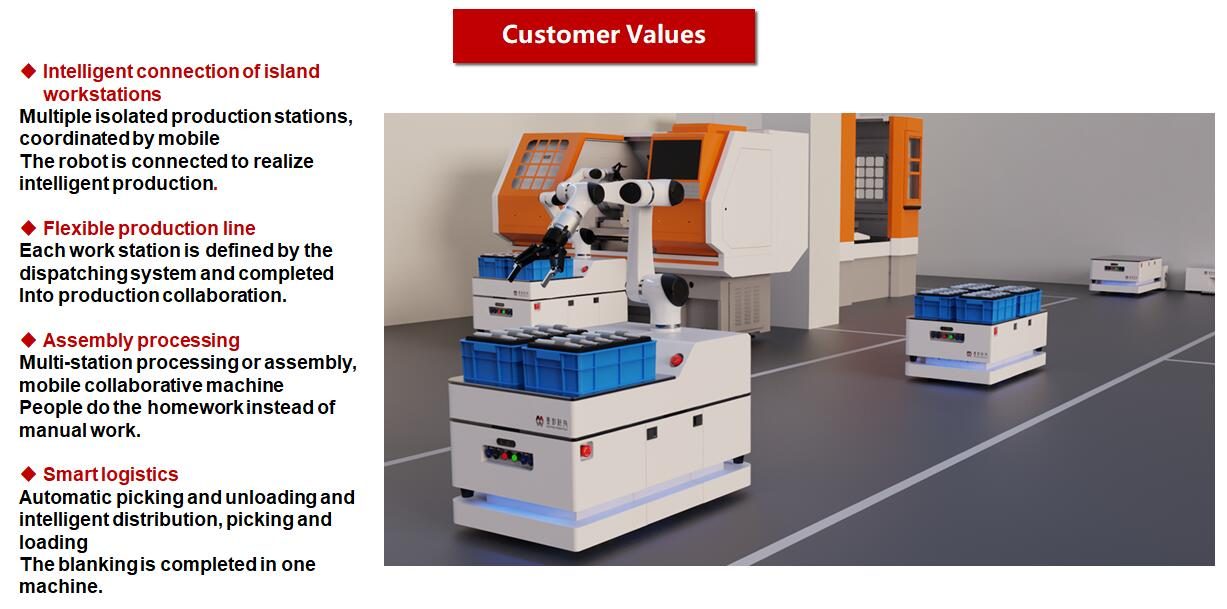
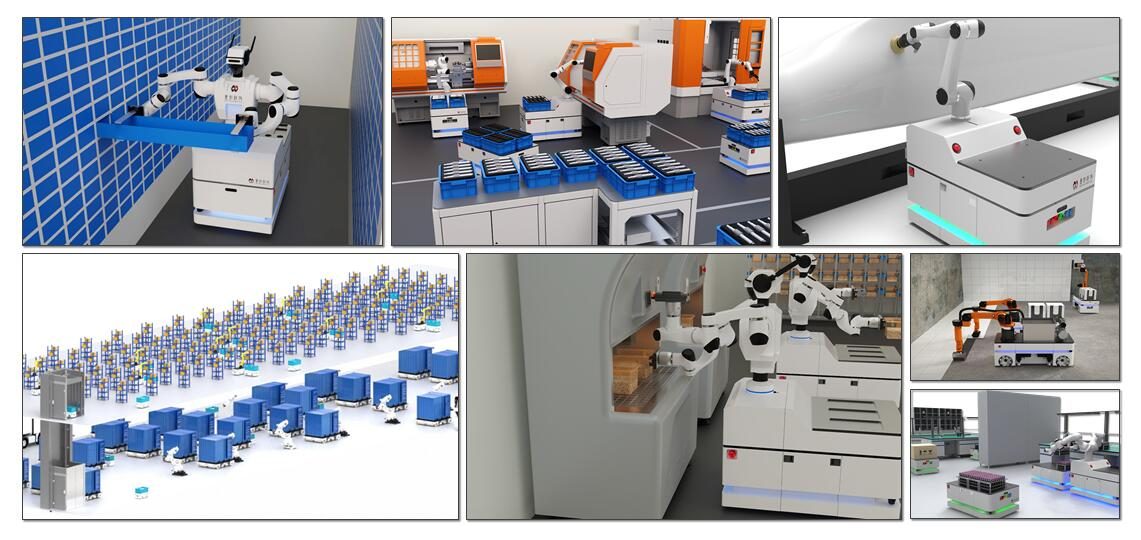
MOD の移動協働ロボット自体は自律的に移動できるオペレーターです。生産ライン内の複数の異なるステーションのタスクをタイムリーに完了します。メカナムホイールドライブモードを使用します。
商業条件
| 引用 | 構成ごとの価格 - 48 時間以内にご返信ください |
|---|---|
| リードタイム | 15日 |
| MOQ | 1台 |
| 起源 | 中国 |
| 積地港 | 深セン、中国 |
| インコタームズ | FOB 深セン / CIF (ご要望に応じて) |
| 支払い | 30% のデポジット、出荷前に 70% |
| 保証 | 標準は 24 か月、オプションは 36 か月 |
製品詳細
TROY エンジニアリング ファイルからのアプリケーション ノート、構造図、およびビデオ — 見積書に同梱される同じ文書。
Product series
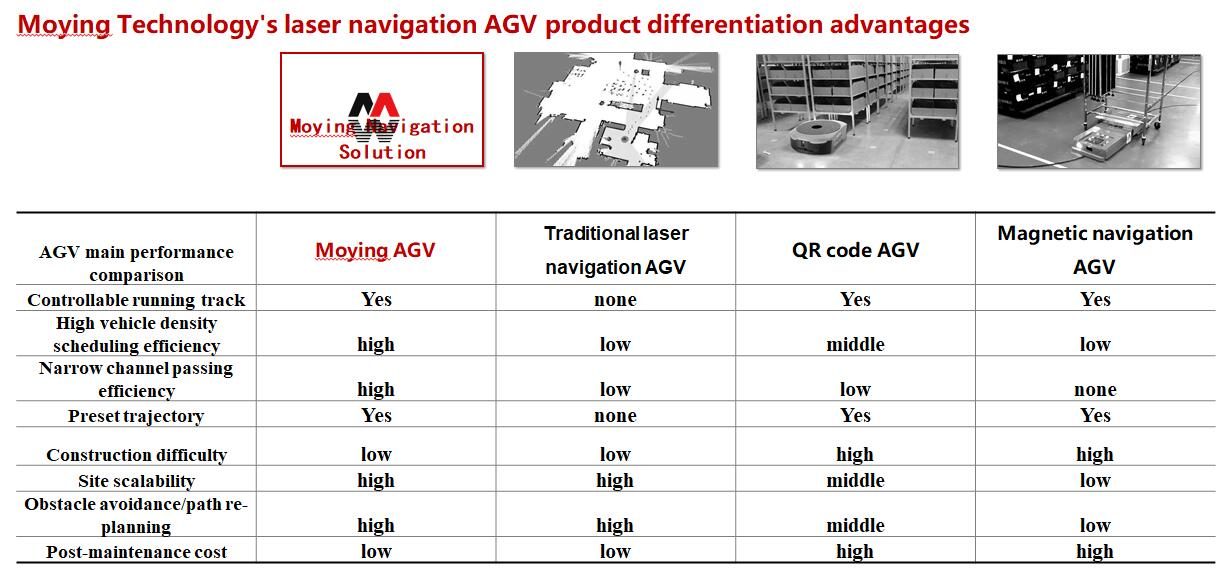
| MDN series differential mobile robot MDN-0300, MDN-0600, MDN-1200 MON series omnidirectional mobile robot MON-0300, MON-0600, MON-1500, MON-6000 MDS series differential single arm mobile collaborative robot MDS-0300, MDS-0600, MDS-1200 MDD series differential dual-arm mobile collaborative robot MDD-0600, MDD-1200 MOS series omnidirectional single-arm mobile collaborative robot MOS-0300, MOS-0600, MOS-1500 MOD series omnidirectional dual-arm mobile collaborative robot MOD-0300, MOD-0600, MOD-1500 300 6000kg chassis load 3-35kg arm wrist load ±1mm chassis repeat positioning accuracy ±0.05mm Repeated positioning accuracy of robotic arm 複雑なタスクを簡単に完了する最大 21 軸の冗長システム | 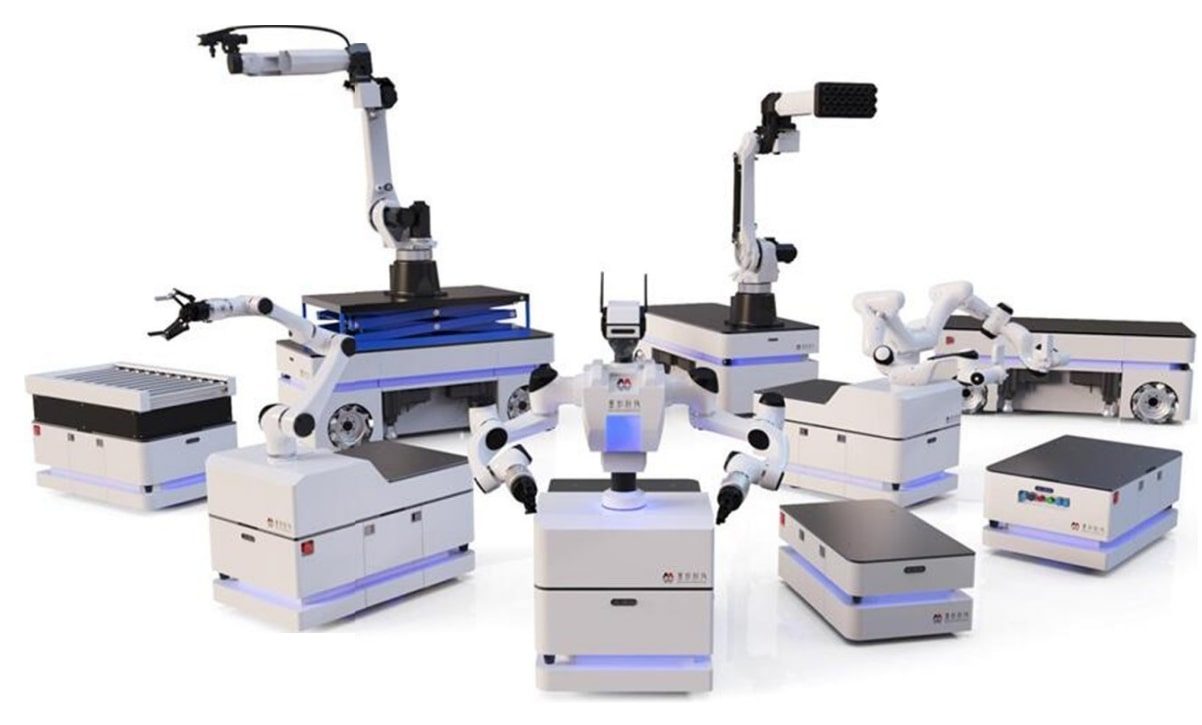 |
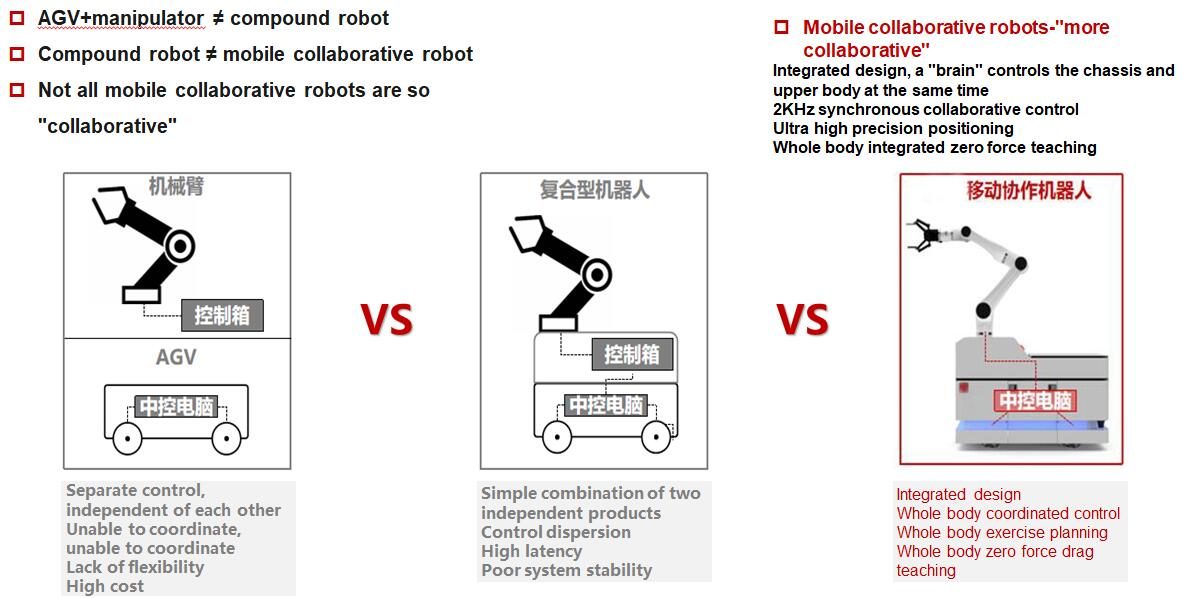
MOD series Omnidirectional dual-arm mobile collaborative robot | Robot Introduction: MOD (Moying Omnidirectional Dual-arm Collaborative Robot) The MOD mobile collaborative robot itself is an operator who can move autonomously, and can complete tasks at multiple different stations in the production line at the same time. The Mecanum wheel drive mode is adopted to realize 360° movement in any direction, which can work flexibly in a small working space and effectively improve the utilization rate of the site and the production efficiency. By collocation with a wealth of end fixtures and visual recognition equipment, it can realize the functions of grasping, assembly, sorting, loading and unloading, moving, handling, and visual inspection, and it is more accurate, stable and efficient. The dual-arm bionic design is closer to human operation, and is suitable for a variety of typical work stations that require both hands at the same time. | ||
 | Cost-effective 人間のような設計は手動操作を直接置き換え、既存の生産ラインを変更することなく迅速に導入できるため、変革コストが大幅に削減されます。 | Flexible intelligence 独立した作業プラットフォームを中心とした生産プロセスの任意の組み合わせにより、オンデマンドで柔軟なインテリジェントな生産ラインが構成されます。 | High versatility 1 台の MOD 移動協働ロボットで、複数人または複数の固定ロボット アームと AG V の協力を必要とするアプリケーション シナリオを実現できます。 |
自動ツールのクイックチェンジ ロボットアームのエンドフィクスチャはオンラインで自動的に交換できるため、さまざまなタスクに適応し、導入コストを大幅に削減できます。 | Safe collaboration 高精度の協働ロボット アームは、高感度の力制御フィードバックにより、ガードレールを設置する必要がなく、作業員の安全も確保できます。 | Flexible force control 関節トルクの高感度なフィードバックと計算、および高度な可変インピーダンス制御アルゴリズムにより、高精度の組み立て動作を安全かつ効果的に実現できます。 | |
MOD series Omnidirectional dual-arm mobile collaborative robot | Robot Features: / Predictable navigation path planning / Intelligent obstacle avoidance 簡単操作 | Up to 21 degrees o f freedom overall positioning Automatic global positioning at boot Automatic recharg e & online battery quick change Remote emergency stop | |
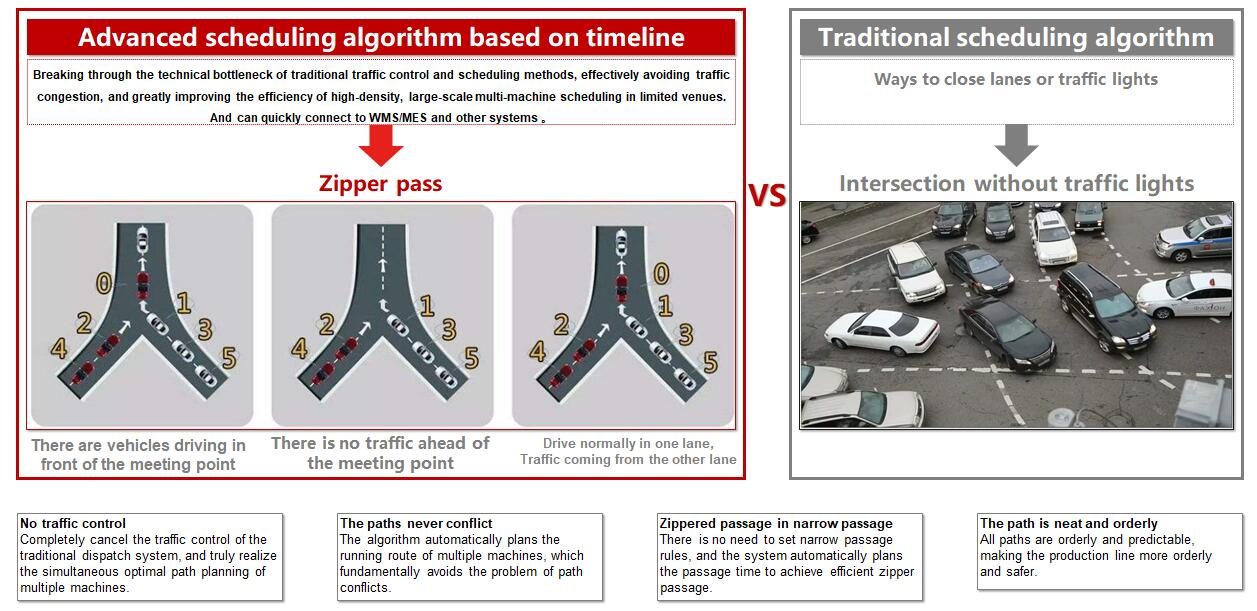
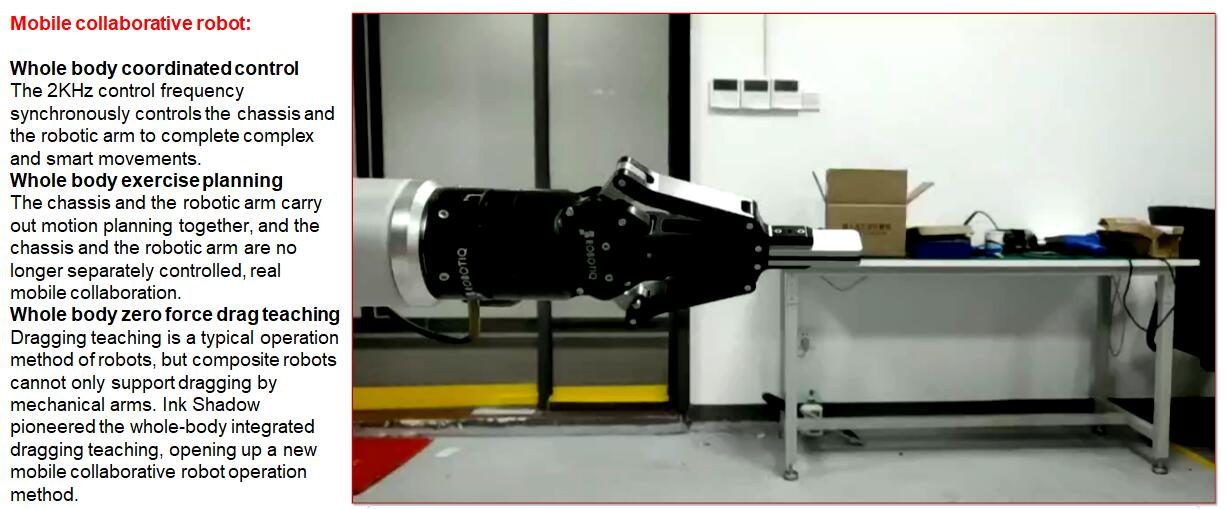
 | 超高制御周波数 ロボット本体全体で最大 2KHz の制御周波数をサポートします。高度な制御アルゴリズムにより、柔軟で複雑なタスクを簡単に処理できます。 | Overall coordination Ink Shadow Technology の高度な制御アルゴリズムにより、モバイル シャーシをリアルタイムに調整します。デュアルロボットアームと固定具により、複雑な移動操作が可能になります。 | Multi-machine multi form scheduling system 独自のマルチマシン・マルチフォームスケジューリングアルゴリズムにより、AGV、ロボットアーム、移動協働ロボットなどのさまざまな形態のロボットを同時制御し、マシン間の大規模な連携を実現します。 |
Omnidirectional movement 4メカナムホイールドライブ。 360°どの方向にも動くため、狭い作業スペースでも柔軟に作業でき、現場の利用率と生産効率を効果的に向上させます。 | Bionic 持ち上げと回転が可能な二重協調ロボット アーム設計は人間の操作に近く、両手で同時に作業する必要があるさまざまな一般的なワークステーションが装備されています。 | High redundancy 最大 21 の自由度により、複雑な環境でも、複雑な把握、組み立て、積み降ろしなどの動作を正確に実行できます。 |
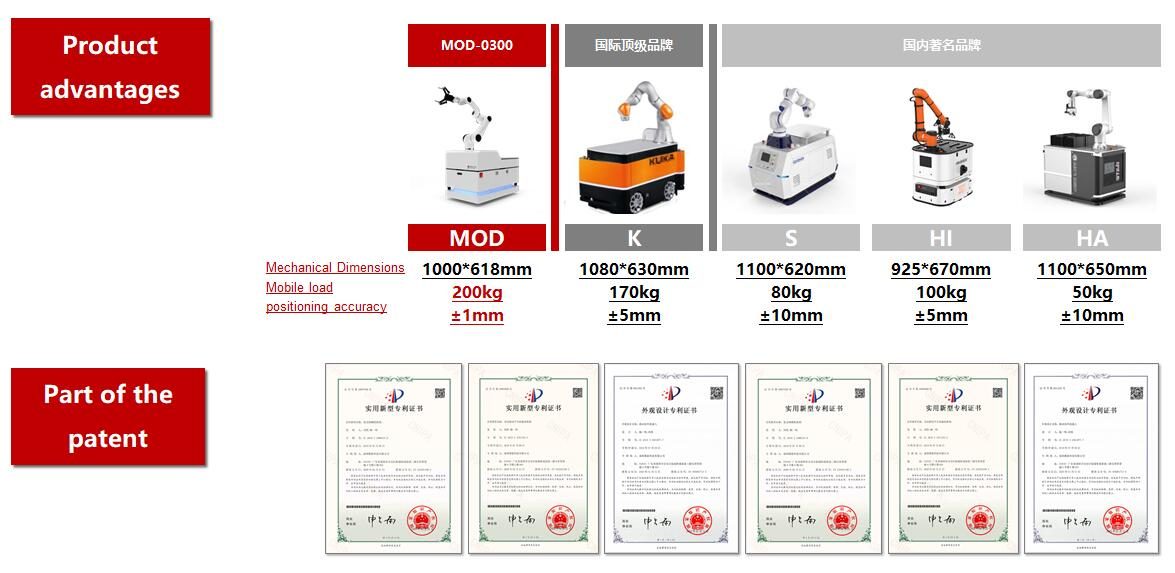
PParameter Type | MOD-0300 Parameters | Configuration | |
基本 シャーシのパラメータ | Dimensions (length x width x height) | 1000x618x425 mm | Customizable |
Ground clearance | 30mm | Standard | |
Net, weight | ≤160 kg | Customizable | |
Load surface size (length x width) | 900x580 mm | Customizable | |
最大積載量 | 300 kg | Customizable | |
Motion performance | Driving mode | Omnidirectional | Standard |
Top driving speed | 1.0 m/s | Standard | |
Top traverse speed | 0.56 m/s | Standard | |
Top diagonal speed | 0.56 m/s | Standard | |
Maximum linear acceleration | 0.5 m/s² | Standard | |
Grade ability | ≤ 3° | Standard | |
Maximum obstacle height | 10 mm | Standard | |
繰り返し精度 | ± 1 mm | Standard | |
ナビゲーション | Lidar X2 | Optional by brand | |
Vision assistant | Customizable | ||
Manipulator parameters | 学位 単一のマニピュレータの自由度 | 6 | Standard |
payload of single arm | 3/5 kg | Customizable | |
Single robotic arm working range | 590/800 mm | Varies due to options | |
Repeat accuracy of robotic arm | ± 0.05 mm | Varies due to options | |
最大値 終わりのスピード | 1 m/s | Varies due to options | |
Number of robotic arms | 2 | Standard | |
Robotic arm brand and specifications | Customizable | ||
Robot torso & head parameters | Trunk lift | Customizable | |
Torso rotation | Customizable | ||
Head freedom | Customizable | ||
Head camera (1-2) | Customizable | ||
Overall parameters | 機械サイズ | 1000x618x1000 mm | Customizable |
Overall size | ≤250 kg | Customizable | |
Machine loading surface size (Length x width) | 580x500 mm | Customizable | |
マシン全体のプラットフォーム負荷 | 100 kg | Varies due to options | |
Parameter Type | MOD-0300 Specifications | Configuration | |
Battery life/ battery performance | Nominal battery voltage | DC 48 V | Standard |
battery capacity | 60 Ah | Customizable | |
充電時間 | 2.0 h | Customizable fast charging scheme | |
Typical operating time | 8 h | Customizable | |
Capacity lossless charge and discharge times | 1500 fully charged and discharged (その後バッテリー容量が低下します) 80%まで) | Standard | |
Use environment | scenes to be used | 屋内の平らな床でのみ使用できます | Standard |
動作温度 | +5℃ ~ 50 ℃ | Standard | |
Environment humidity | 10% ~ 95% No condensation | Standard | |
IPクラス | IP 20 | Standard | |
Noisy | <65 dB(Rated working speed) | Standard | |
Internal communication | EtherCAT(Control frequency 2KHz) | Customizable CANOpen (control frequency 500Hz) | |
reserved port | RJ45x1 / USBx2 / HDMIx1 | 4口Customizable | |
End effector & sensor | End effector (gripper, vacuum suction cup, etc.) (optional) | optional | |
Robotic arm visual positioning (optional) | optional | ||
Six-dimensional force sensor | Optional | ||
Security configuration | Lidar x2 | Standard (optional by brand) | |
Depth camera x1 | Standard | ||
Remote control emergency stop (effective range of 15 kilometers) (optional) | optional | ||
Emergency stop button 2 | Standard | ||
Multi-mode sound alert | Standard | ||
Multi-mode light warning | Standard | ||
Safety bumper (optional) | optional | ||
完全な技術データ
| モデル | MOD |
|---|---|
| リードタイム | 15日 |
| カテゴリ | 協働ロボット |
値は 20 °C における公称値です。 CAD モデル、トルク曲線、コントローラー I/O マップのデータシートをダウンロードしてください。
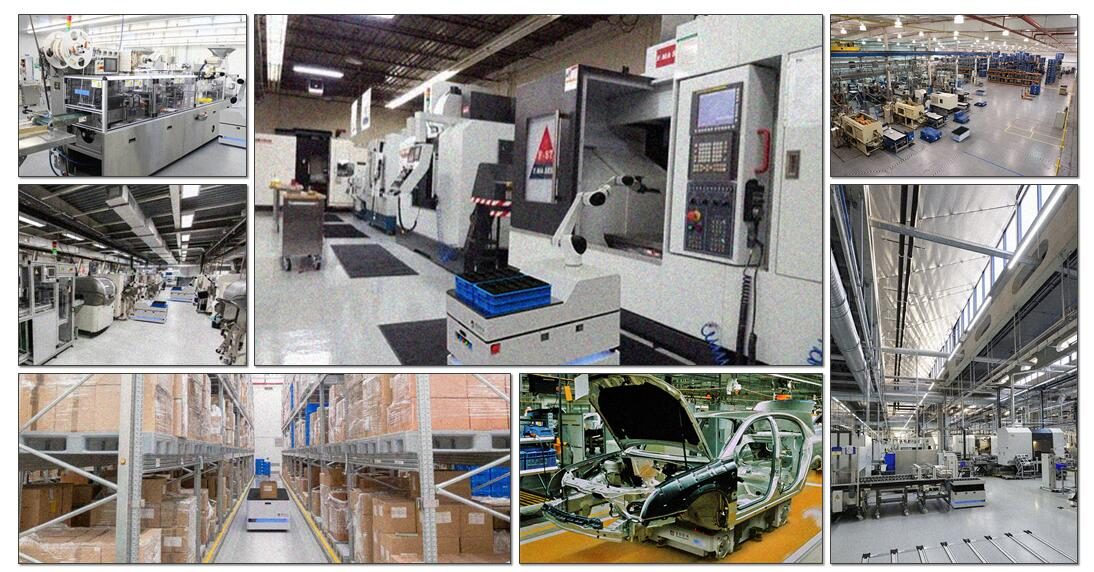
どこで実行されるか
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
購入者の質問
MODの主な仕様は何ですか?
モデルMOD。リクエストに応じて完全なデータシートを入手できます。
MODのリードタイムとMOQはどれくらいですか?
リードタイムは15日です。 MOQは1ユニットです。
MODの価格はどうなっていますか?
価格は構成ごとに見積もられており、該当する場合は工具や輸送費も含まれます。
MOD の価格提案を取得する
パート、ターゲット レート、宛先ポートを含めます。チャットボットではなくエンジニアが 48 時間以内に返信します。
同じカテゴリ
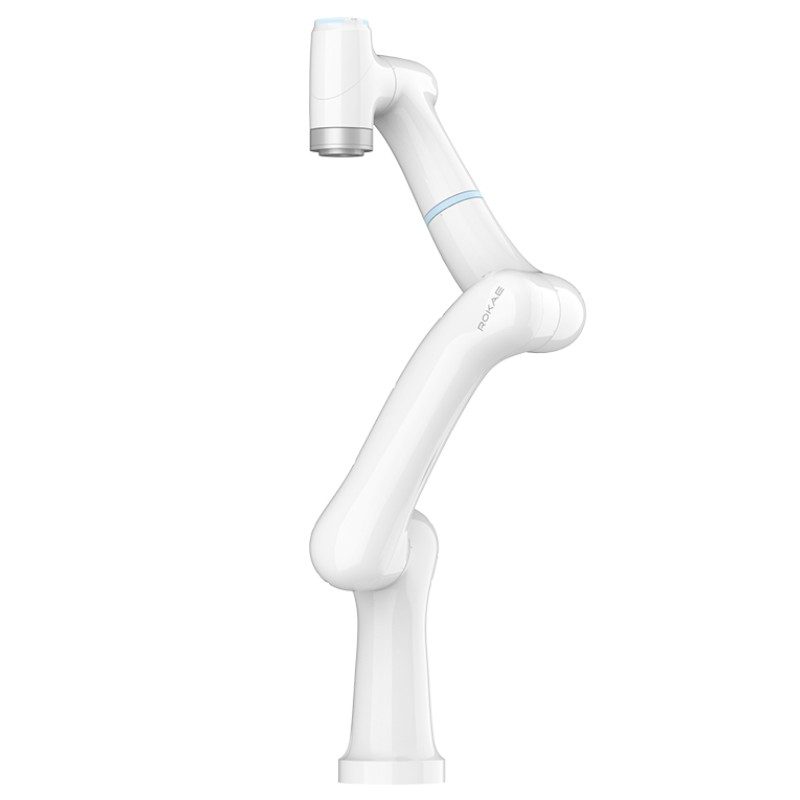
ROKAE SR5 協働ロボット - 5kg 6 軸コンパクトコボット (919mm)
ROKAE SR3C xMate 協働ロボット - 3kg 6 軸コンパクトコボット (705mm)
ROKAE CR35-35C xMate 協働ロボット - 35kg 6 軸高耐久コボット (2246mm)
TROY エンジニアリングによるレビュー ·。仕様は見積ごとにサプライヤーのデータシートと照合して再チェックされます。