


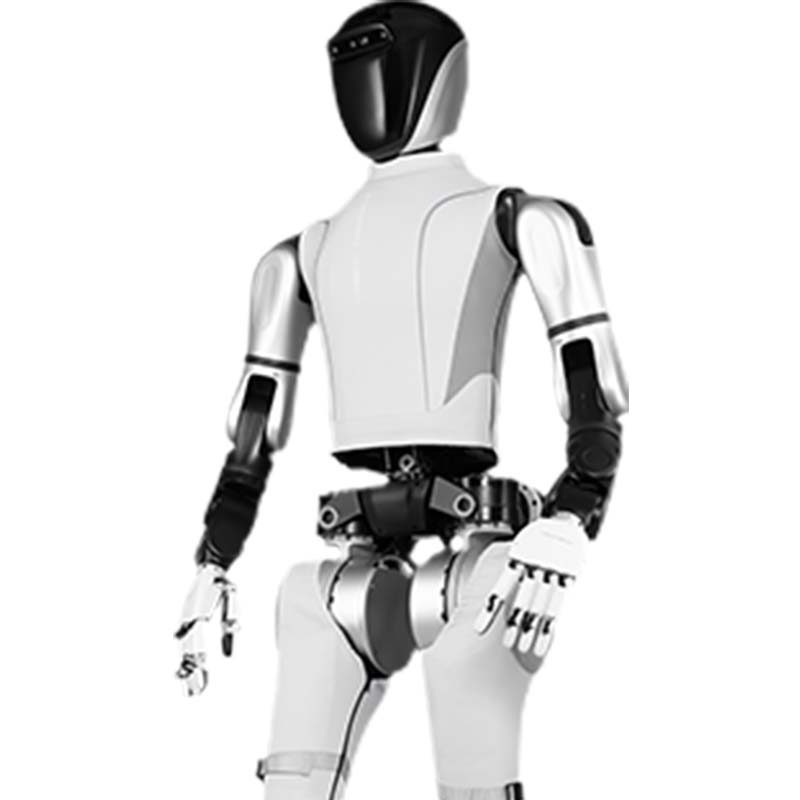
AGI Humanoid Robot TR-Star 1
The TR-Star is a humanoid robot for research / reception. Key specifications: Degrees of freedom 55; Maximum joint speed 25 rad/s; Height/weight 171 cm/63 Kg. Lead time is 60 days; pricing is quoted per configuration. Certifications: CE documentation on request.
- Model
- TR-Star
- Degrees of freedom
- 55
- Maximum joint speed
- 25 rad/s
- Height/weight
- 171 cm/63 Kg
- Total machine load
- 160 Kg+
- Maximum joint torque
- 400 Nm
What This Platform Is For
High-performance AGI Humanoid Robot TR-Star 1: *Degrees of freedom: 55 *Maximum joint speed: 25 rad/s *Height/weight: 171 cm/63 Kg *Total machine load: 160 Kg+ *Maximum joint torque: 400 Nm *5 Fingers Hand: fully self-propelled joints / 12 independent degrees of freedom.
Commercial Terms
| Quotation | Priced per configuration — reply within 48 hours |
|---|---|
| Lead time | 60 days |
| MOQ | 1 unit |
| Origin | China |
| Port of loading | Qingdao, China |
| Incoterm | FOB Qingdao / CIF on request |
| Payment | 30% deposit, 70% before shipment |
| Warranty | 24 months standard, 36 months optional |
Product Details
Application notes, construction drawings and video from the TROY engineering file — the same documentation shipped with the quotation.
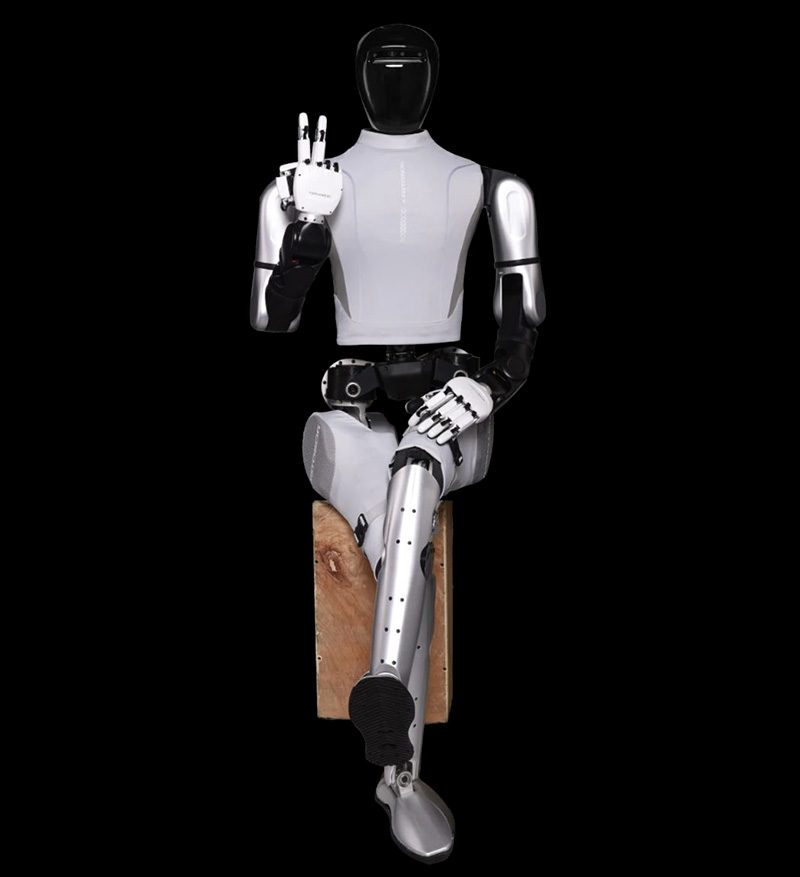
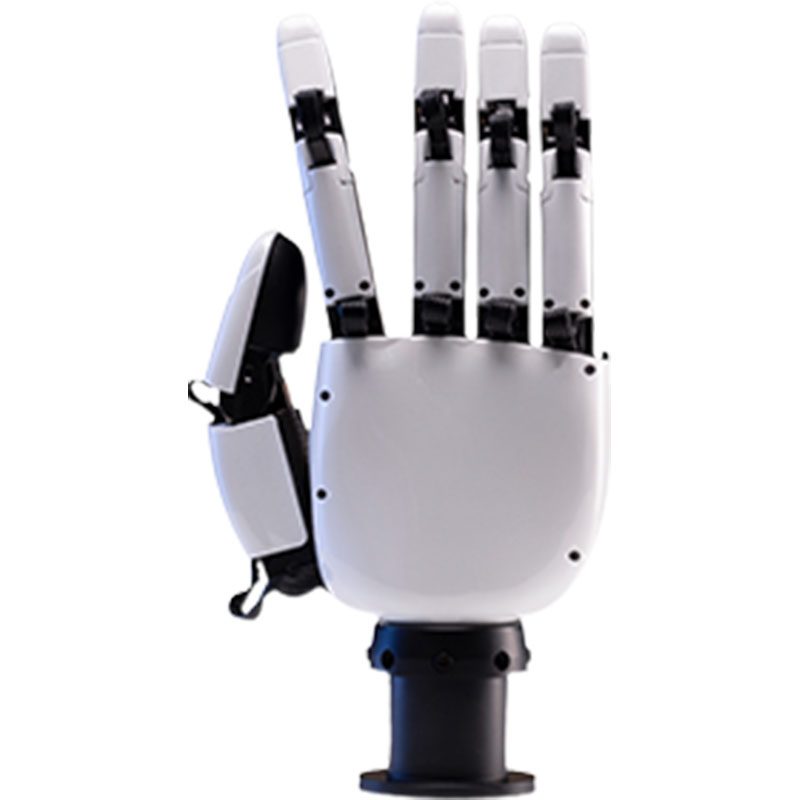
TR-STAR 1's upper limbs include a self-developed high-precision bionic robotic arm with 7 degrees of freedom, and the high-performance dexterous hand XHAND1 with 12 fully active and self-driven degrees of freedom, enabling TR-STAR 1 to have industry-leading actuators in the field of fine manipulation tasks and adapt to the application needs of various scenarios.
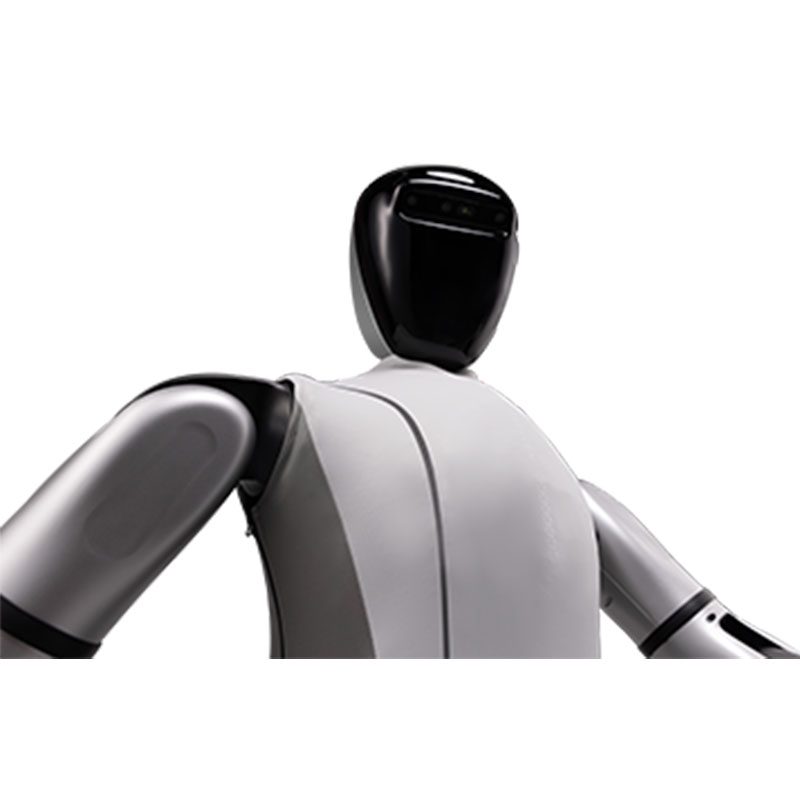
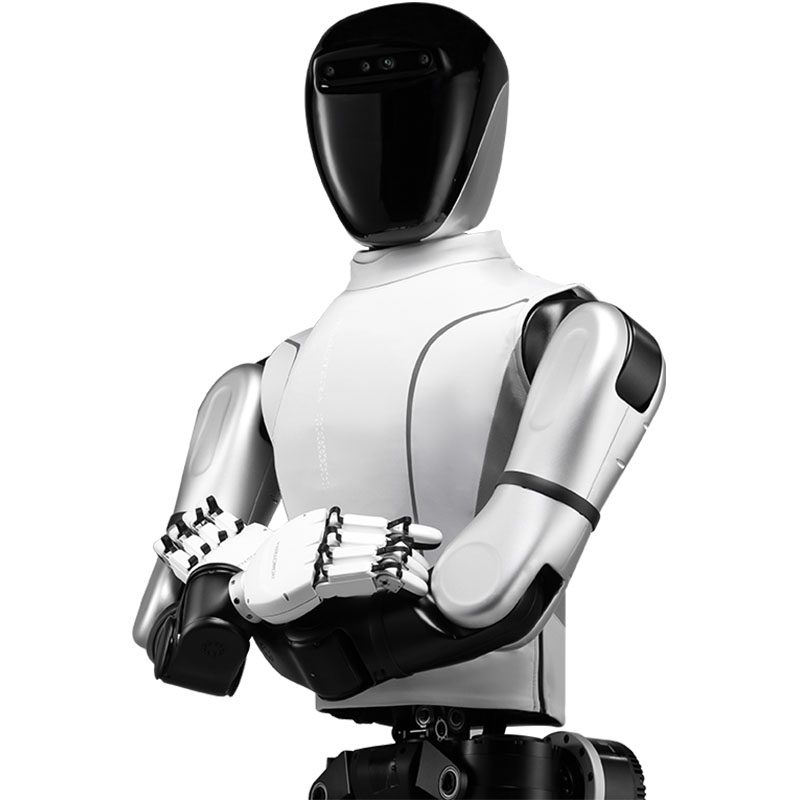
TR-STAR 1 is the first domestically produced high-performance AGI Humanoid Robot with 55 degrees of freedom. The maximum joint torque is 400Nm and the maximum speed is 25rad/s. This makes the Star-Moving STAR1 have the industry's advanced dynamic performance. The running speed in real outdoor scenes reaches 3.6m/s. With the three degrees of freedom of the waist, it can easily complete complex movements such as stable walking, running, jumping, etc. in a natural gait.
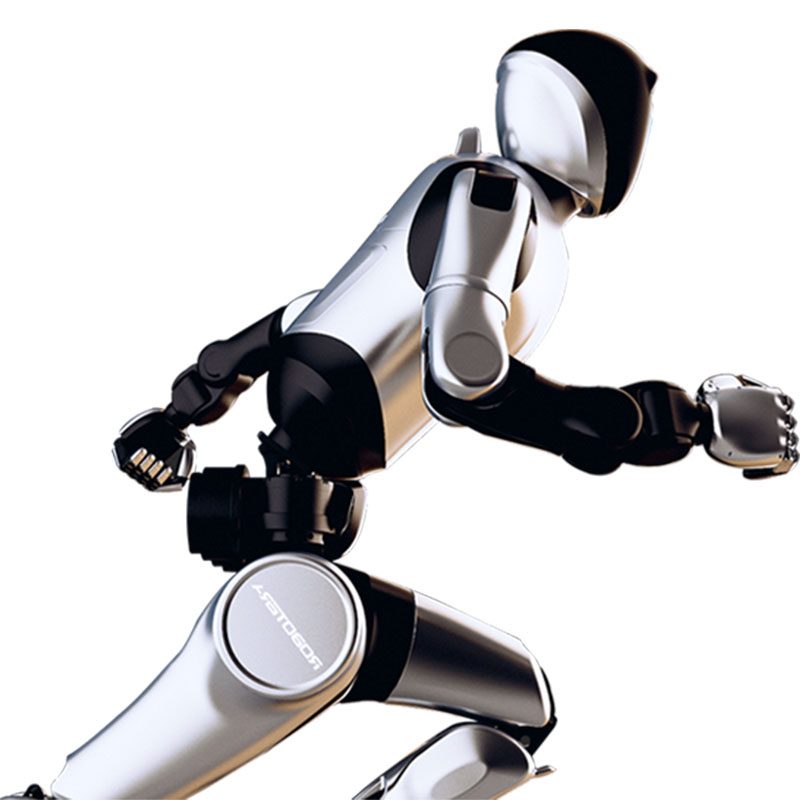
TR-STAR 1 integrates Intel high-performance processors and Nvidia Orin's powerful computing resources, providing excellent computing support for humanoid robots in reinforcement learning, imitation learning, and end-to-end large model research. The robot is also equipped with a variety of peripherals such as fingertip array tactile sensors, deep vision cameras, microphone arrays, and facial interactive screens, as well as complete software and teleoperation systems, which facilitate efficient training and highly autonomous operation.
TR-STAR 1 is an outstanding representative of the deep integration of artificial intelligence and robotic hardware. It is designed to meet the challenges of current and future scientific research and has excellent performance and flexibility.
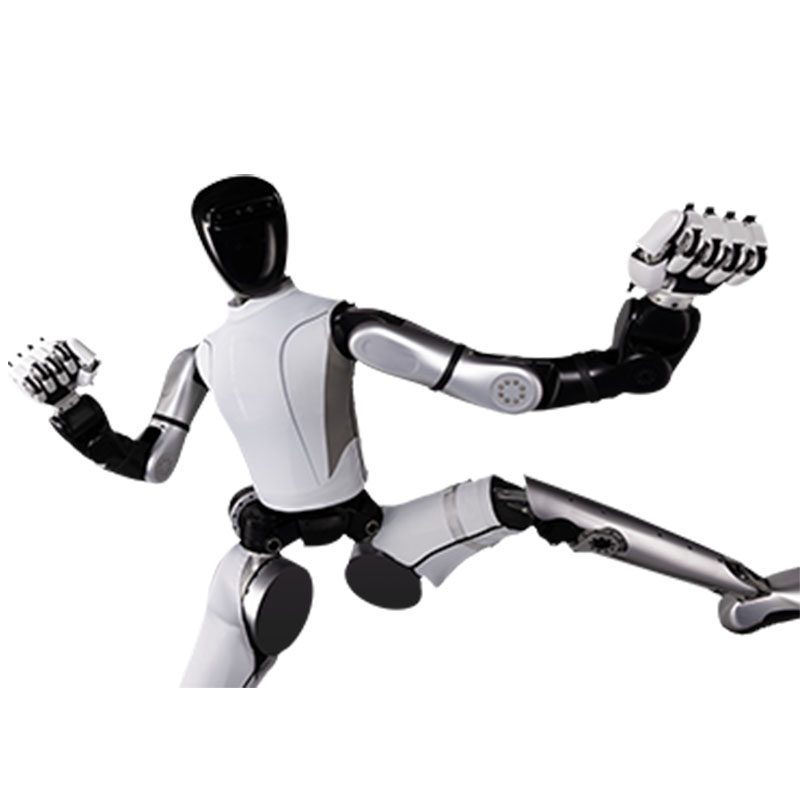
High versatility and autonomous adaptability
TR-STAR 1 has autonomous adaptability in a variety of unmodeled environments, and can perform a variety of tasks such as picking up objects and pouring water, trimming flowers and plants, and walking and running on complex roads.
Rapid iteration capability
Relying on the native robot large model and the hardware platform defined for AI, Star Era has rapidly iterated 6 generations of robots in 1 year.
World-class performance
The running speed in outdoor real scenes reaches 3.6m/s, and it can walk and run stably in complex terrain and environments.
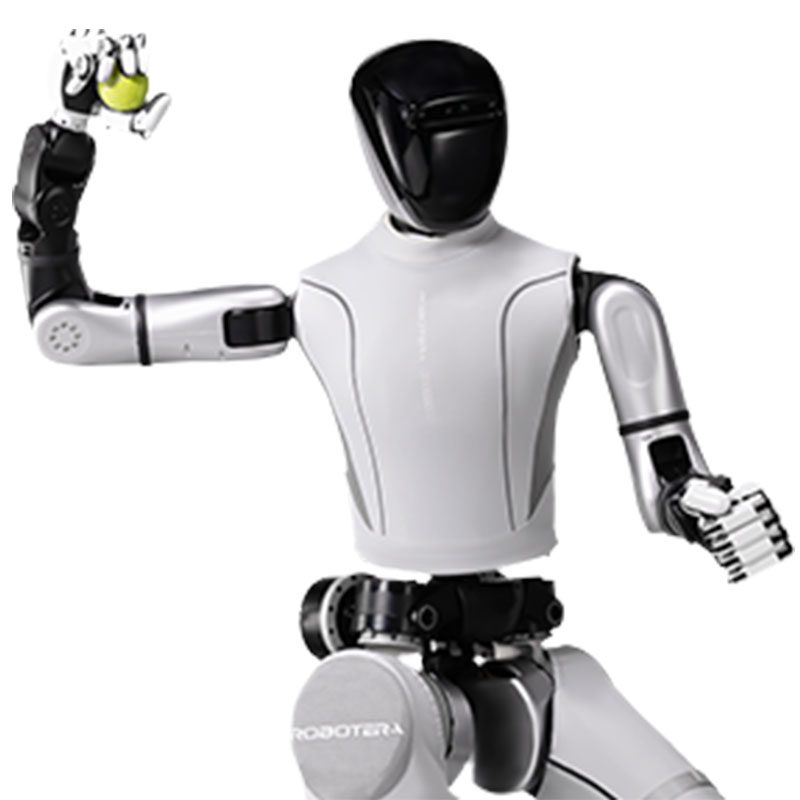
Integrated joint module:
In view of the application characteristics of humanoid robots, the self-developed integrated series joints integrate frameless torque motors, precision planetary reducers, high-precision encoders, and drivers. They have EtherCAT high-speed communication, high-precision force-position mixed control mode, compact structure, high positioning accuracy, high response frequency, and high torque density, and are suitable for robot applications with dynamic variable loads.
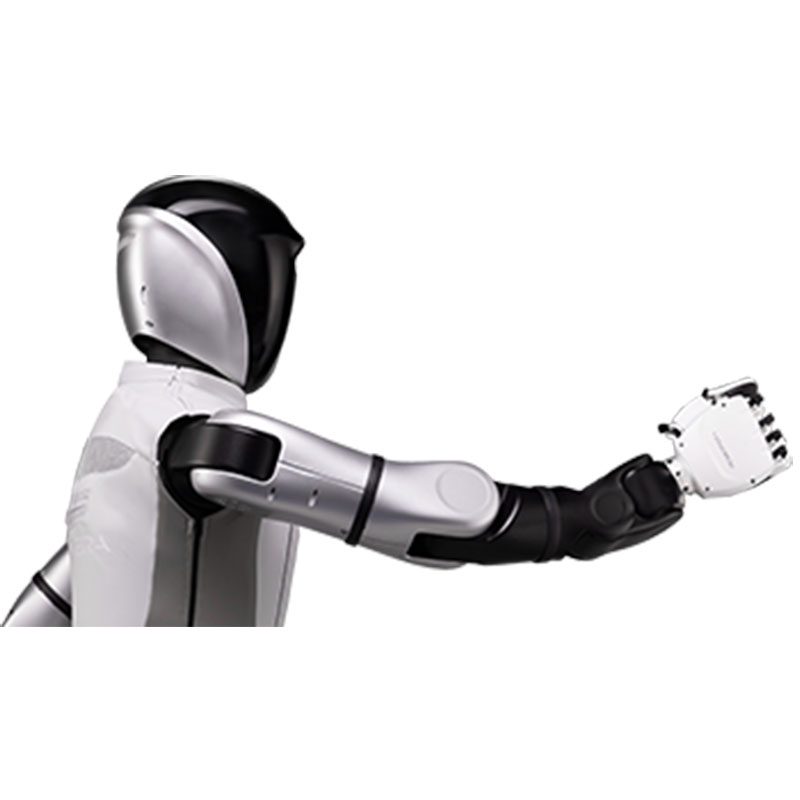
High-performance AGI Humanoid Robot model: TR-STARs1:
Height: 171 cm
Weight: 63 Kg
Degrees of freedom: 55
Computing power: 275 TOPS
Dexterous hand: 12 active degrees of freedom for one hand, full coverage of tactile array fingertips
Sensor: tactile sensor, camera, depth camera
Movement: Running speed up to 3.6 m/s in outdoor real scene
Arm: Load>20 Kg, 7 degrees of freedom high-precision bionic robotic arm
Dexterous hand: Can swing sideways, large range of finger movement, single-handed grasping>25 Kg
Joint: Maximum torque 400 Nm, maximum speed 25 rad/s
Waist and neck: 3 waist degrees of freedom, 2 neck degrees of freedom, elegant gait, friendly interaction
Total machine load: 160 Kg.
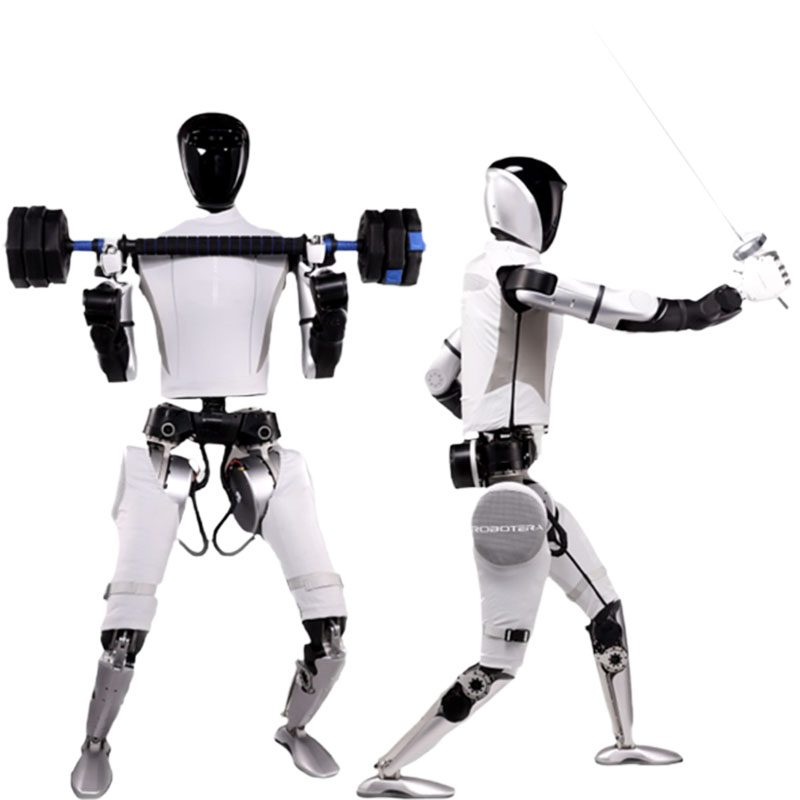
Fully self-driving, truly free degrees:
XHAND1 is the first domestically produced robot dexterous hand, with advantages such as high degree of freedom, high performance, and high intelligence.
5 finger joints fully self-driving, 12 independent degrees of freedom;
High-resolution 3D tactile sensor;
Maximum single-hand load of 80N and 25Kg.
The use of native robot large models is a new AI-native learning paradigm that is both universal and simple, and has the ability to fully scale up. Its algorithm processes sensory information such as vision, hearing, and touch through full-modal input fusion, reproducing the most fundamental way of interaction between organisms and the physical world.
Hardware platform defined for AGI:
The interaction of intelligent bodies relies on physical carriers, and the human form is currently the best example of general intelligence. Based on this, a new humanoid robot hardware architecture that integrates hardware and software and is tailored for AI is designed. From the underlying motor to the bipedal system and dexterous hands, all components are AI-friendly. Ensure that the algorithm can be quickly verified on the hardware, greatly improve the efficiency of Sim2Real, and achieve the co-evolution of software and hardware.
Full Technical Data
| Model | TR-Star |
|---|---|
| Degrees of freedom | 55 |
| Maximum joint speed | 25 rad/s |
| Height/weight | 171 cm/63 Kg |
| Total machine load | 160 Kg+ |
| Maximum joint torque | 400 Nm |
| Category | AI & Humanoid Robots |
| Lead time | 60 days |
Values are nominal at 20 °C. Download the datasheet for cad models, torque curves and controller I/O maps.
Where It Runs
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Buyer Questions
What are the key specifications?
Model: TR-Star, Degrees of freedom: 55, Maximum joint speed: 25 rad/s.
What is the lead time?
60 days for the standard configuration; confirmed at quotation.
Can it be customised?
Yes — OEM/ODM options, voltage, tooling and branding can be adapted. Send the application and target output for a proposal.
Get a Priced Proposal for TR-Star
Include the part, target rate and destination port. An engineer — not a chatbot — replies within 48 hours.
Same Category

Wheeled Dual-Arm Humanoid Robot

Dual-Arm Humanoid Robot

Biomimetic Panda Service Robot
Reviewed by TROY Engineering · . Specifications are re-checked against the supplier datasheet at every quotation.