


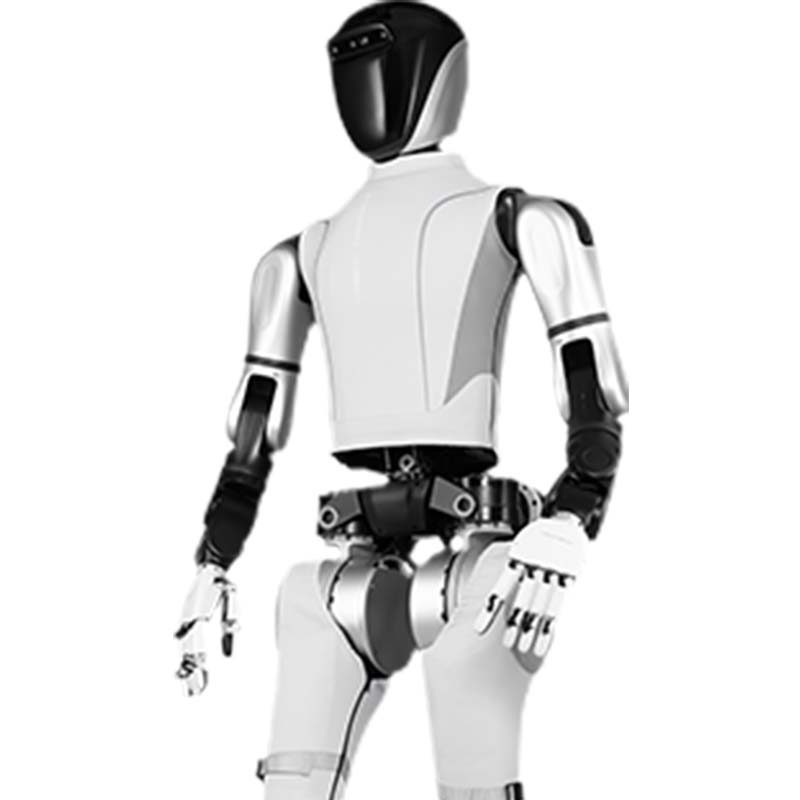
AGI Humanoider Roboter TR-Star 1
Der TR-Star ist ein humanoider Roboter für Forschung/Empfang. Wesentliche Spezifikationen: Freiheitsgrade 55; Maximale Gelenkgeschwindigkeit 25 rad/s; Größe/Gewicht 171 cm/63 kg. Die Vorlaufzeit beträgt 60 Tage; Die Preise werden pro Konfiguration angegeben. Zertifizierungen: CE-Dokumentation auf Anfrage.
- Modell
- TR-Stern
- Freiheitsgrade
- 55
- Maximale Gelenkgeschwindigkeit
- 25 rad/s
- Größe/Gewicht
- 171 cm/63 Kg
- Gesamtmaschinenlast
- 160 Kg+
- Maximales Gelenkdrehmoment
- 400 Nm
Wofür diese Plattform gedacht ist
Hochleistungsfähiger humanoider AGI-Roboter TR-Star 1: *Freiheitsgrade: 55 *Maximale Gelenkgeschwindigkeit: 25 rad/s *Höhe/Gewicht: 171 cm/63 kg *Gesamtmaschinenlast: 160 kg+ *Maximales Gelenkdrehmoment: 400 Nm *5 Finger Hand: vollständig selbstfahrende Gelenke / 12 unabhängige Freiheitsgrade.
Handelsbedingungen
| Angebot | Preis pro Konfiguration – Antwort innerhalb von 48 Stunden |
|---|---|
| Vorlaufzeit | 60 Tage |
| Mindestbestellmenge | 1 Einheit |
| Herkunft | China |
| Verladehafen | Qingdao, China |
| Incoterm | FOB Qingdao / CIF on request |
| Zahlung | 30 % Anzahlung, 70 % vor Versand |
| Garantie | 24 Monate Standard, 36 Monate optional |
Produktdetails
Anwendungshinweise, Konstruktionszeichnungen und Videos aus der TROY-Konstruktionsdatei – dieselbe Dokumentation, die mit dem Angebot geliefert wurde.
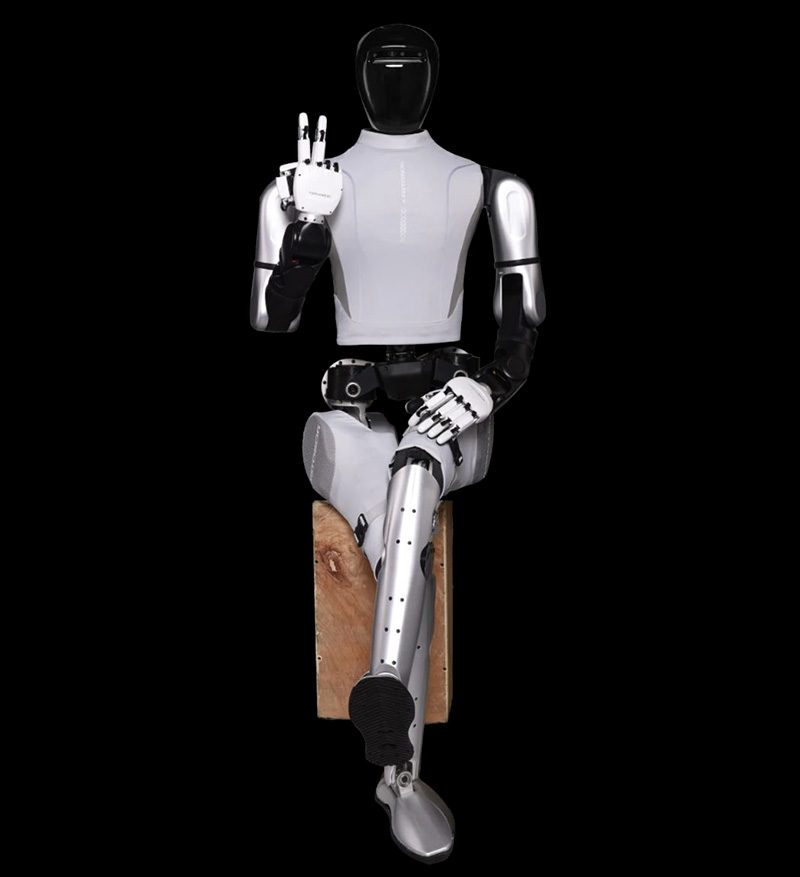
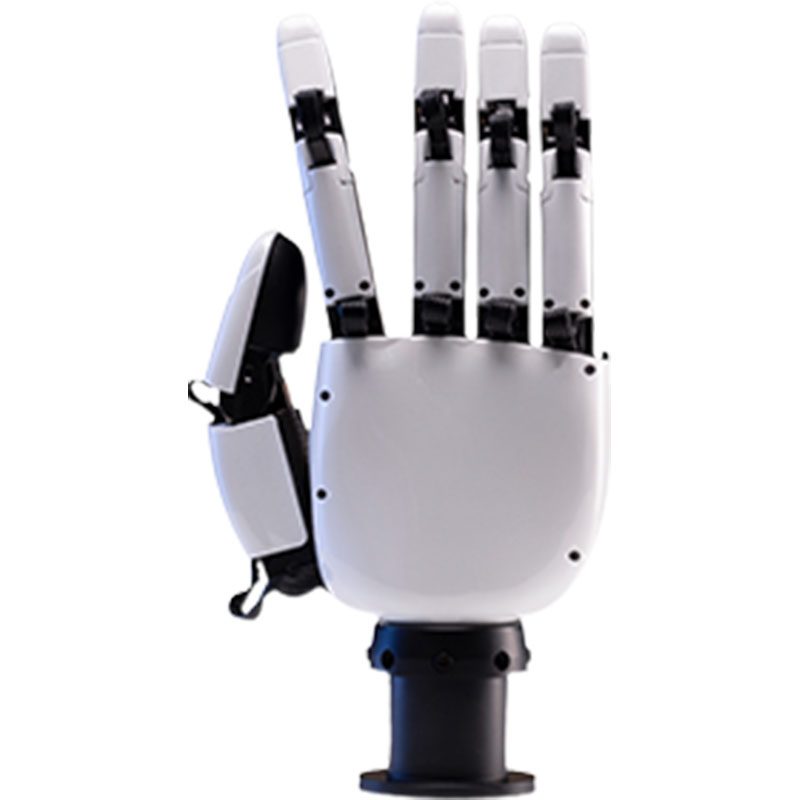
TR-STAR 1's upper limbs include a self-developed high-precision bionic robotic arm with 7 degrees of freedom, and the high-performance dexterous hand XHAND1 with 12 fully active and self-driven degrees of freedom, enabling TR-STAR 1 to have industry-leading actuators in the field of fine manipulation tasks and adapt to the application needs of various scenarios.
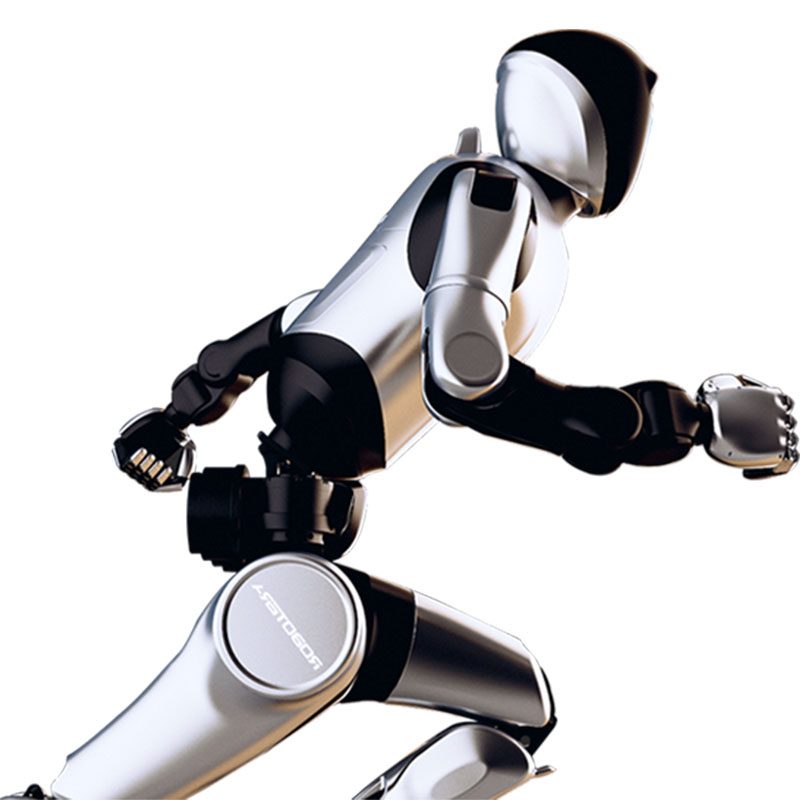
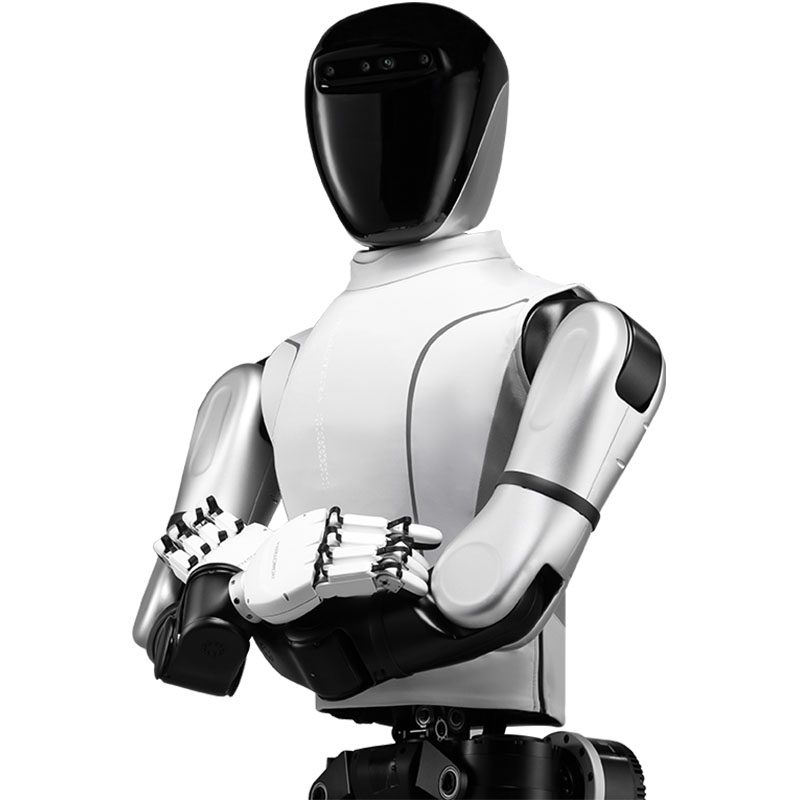
TR-STAR 1 is the first domestically produced high-performance AGI Humanoid Robot with 55 degrees of freedom. The maximum joint torque is 400Nm and the maximum speed is 25rad/s. This makes the Star-Moving STAR1 have the industry's advanced dynamic performance. The running speed in real outdoor scenes reaches 3.6m/s. With the three degrees of freedom of the waist, it can easily complete complex movements such as stable walking, running, jumping, etc. in a natural gait.
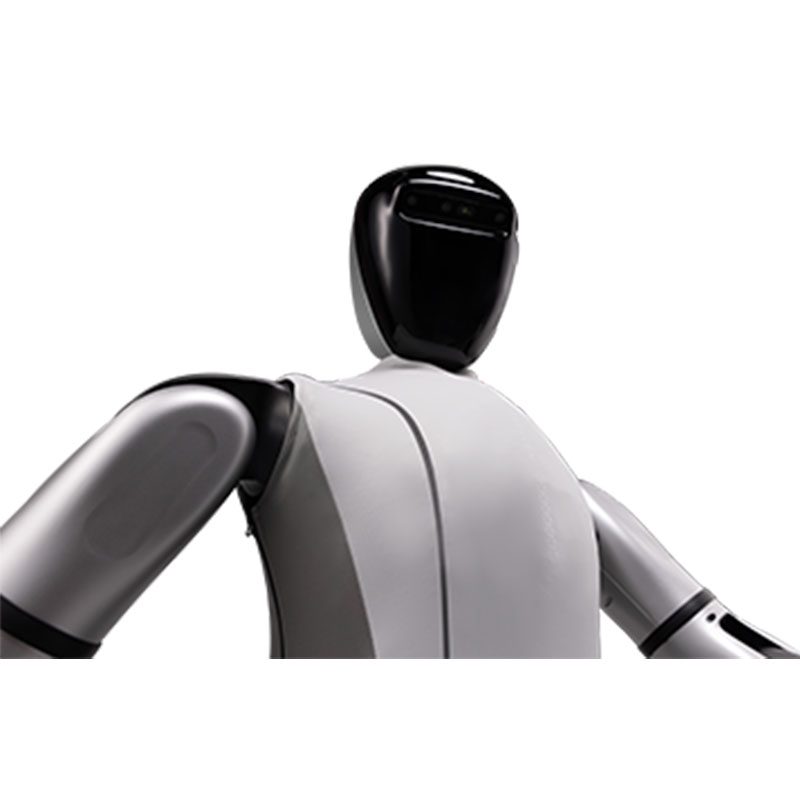
TR-STAR 1 integrates Intel high-performance processors and Nvidia Orin's powerful computing resources, providing excellent computing support for humanoid robots in reinforcement learning, imitation learning, and end-to-end large model research. The robot is also equipped with a variety of peripherals such as fingertip array tactile sensors, deep vision cameras, microphone arrays, and facial interactive screens, as well as complete software and teleoperation systems, which facilitate efficient training and highly autonomous operation.
TR-STAR 1 ist ein herausragender Vertreter der tiefen Integration von künstlicher Intelligenz und Roboterhardware. Es ist darauf ausgelegt, den Herausforderungen der aktuellen und zukünftigen wissenschaftlichen Forschung gerecht zu werden und zeichnet sich durch hervorragende Leistung und Flexibilität aus.
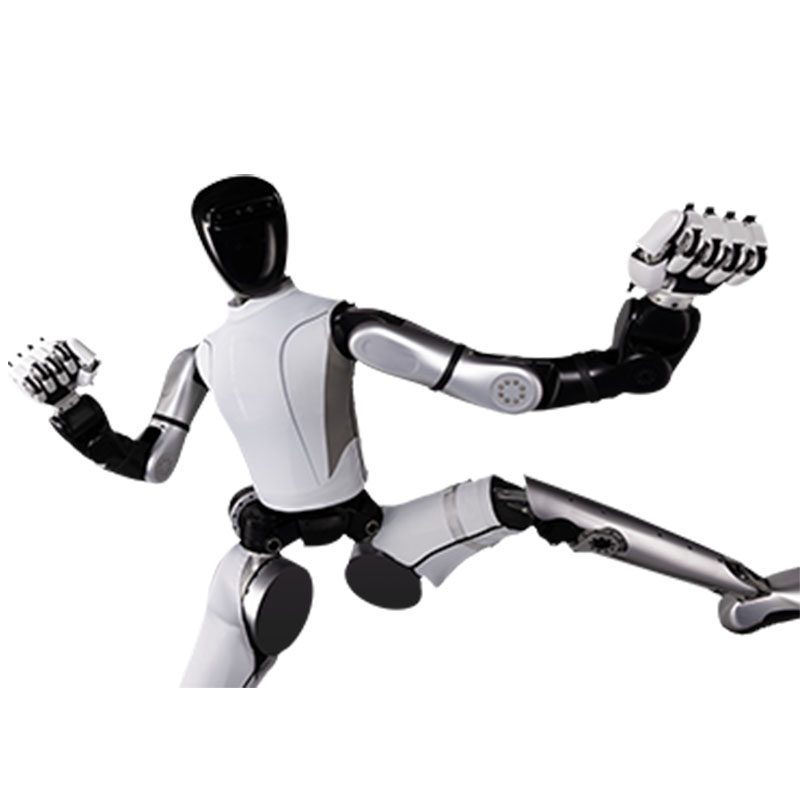
High versatility and autonomous adaptability
TR-STAR 1 verfügt über eine autonome Anpassungsfähigkeit in einer Vielzahl nicht modellierter Umgebungen und kann eine Vielzahl von Aufgaben ausführen, wie z. B. das Aufnehmen von Gegenständen und das Ausgießen von Wasser, das Beschneiden von Blumen und Pflanzen sowie das Gehen und Laufen auf komplexen Straßen.
Rapid iteration capability
Basierend auf dem nativen Roboter-Großmodell und der für KI definierten Hardwareplattform hat Star Era in einem Jahr schnell sechs Generationen von Robotern entwickelt.
World-class performance
Die Laufgeschwindigkeit in realen Szenen im Freien erreicht 3,6 m/s und es kann in komplexem Gelände und in komplexen Umgebungen stabil gehen und laufen.
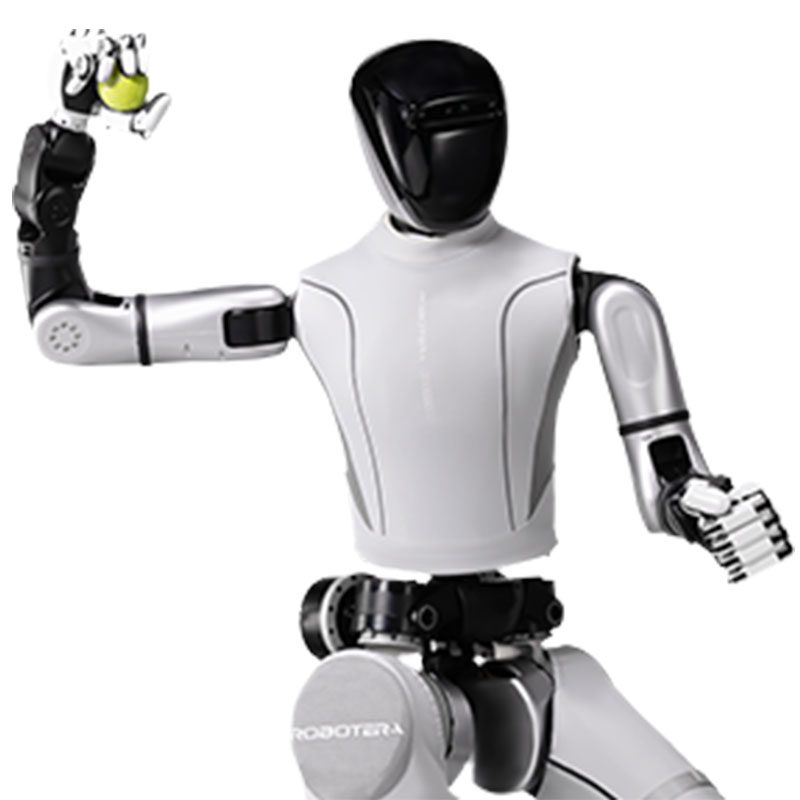
Integrated joint module:
In view of the application characteristics of humanoid robots, the self-developed integrated series joints integrate frameless torque motors, precision planetary reducers, high-precision encoders, and drivers. They have EtherCAT high-speed communication, high-precision force-position mixed control mode, compact structure, high positioning accuracy, high response frequency, and high torque density, and are suitable for robot applications with dynamic variable loads.
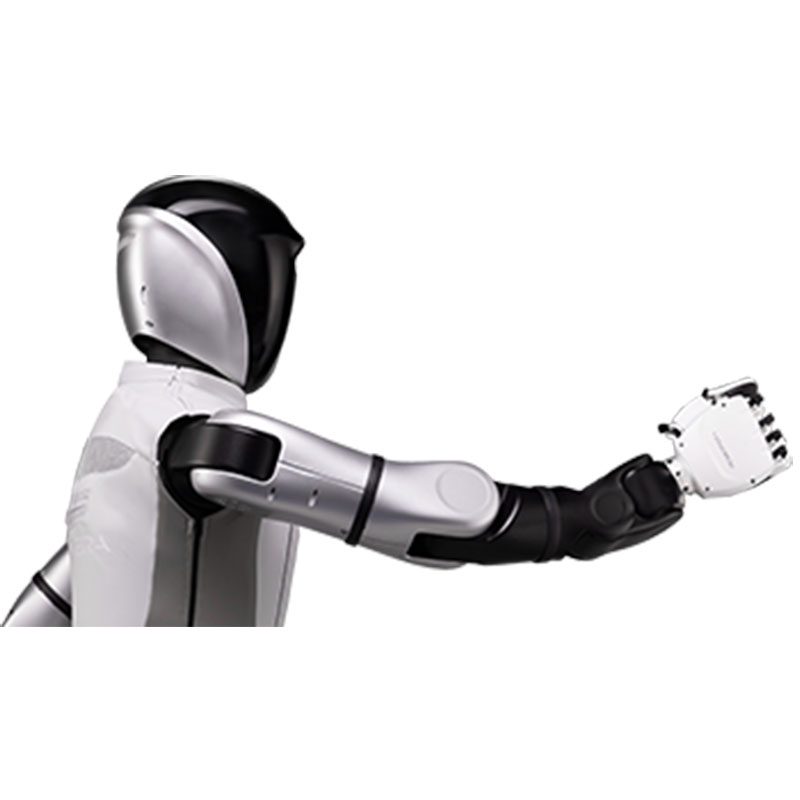
High-performance AGI Humanoid Robot model: TR-STARs1:
Height: 171 cm
Weight: 63 Kg
Degrees of freedom: 55
Computing power: 275 TOPS
Geschickte Hand: 12 aktive Freiheitsgrade für eine Hand, vollständige Abdeckung der taktilen Fingerspitzen
Sensor: tactile sensor, camera, depth camera
Bewegung: Laufgeschwindigkeit bis zu 3,6 m/s in realen Outdoor-Szenen
Arm: Load>20 Kg, 7 degrees of freedom high-precision bionic robotic arm
Geschickte Hand: Kann seitwärts schwingen, großer Fingerbewegungsbereich, einhändiges Greifen >25 kg
Joint: Maximum torque 400 Nm, maximum speed 25 rad/s
Taille und Hals: 3 Freiheitsgrade der Taille, 2 Freiheitsgrade des Halses, eleganter Gang, freundliche Interaktion
Total machine load: 160 Kg.
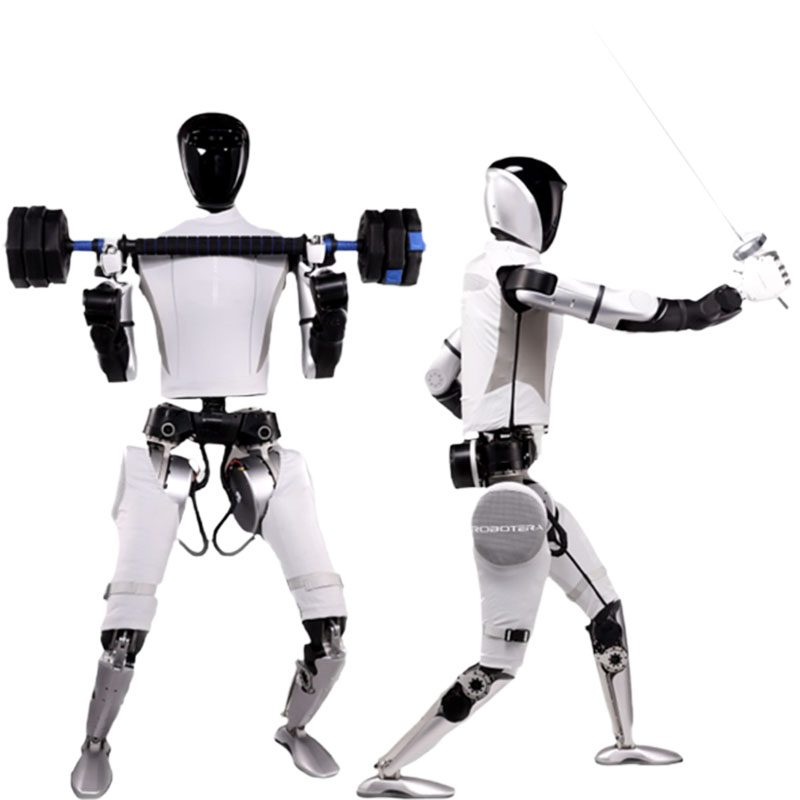
Fully self-driving, truly free degrees:
XHAND1 ist die erste im Inland hergestellte geschickte Roboterhand mit Vorteilen wie hohem Freiheitsgrad, hoher Leistung und hoher Intelligenz.
5 finger joints fully self-driving, 12 independent degrees of freedom;
High-resolution 3D tactile sensor;
Maximale Einhandlast von 80 N und 25 kg.
The use of native robot large models is a new AI-native learning paradigm that is both universal and simple, and has the ability to fully scale up. Its algorithm processes sensory information such as vision, hearing, and touch through full-modal input fusion, reproducing the most fundamental way of interaction between organisms and the physical world.
Hardware platform defined for AGI:
The interaction of intelligent bodies relies on physical carriers, and the human form is currently the best example of general intelligence. Based on this, a new humanoid robot hardware architecture that integrates hardware and software and is tailored for AI is designed. From the underlying motor to the bipedal system and dexterous hands, all components are AI-friendly. Ensure that the algorithm can be quickly verified on the hardware, greatly improve the efficiency of Sim2Real, and achieve the co-evolution of software and hardware.
Vollständige technische Daten
| Modell | TR-Stern |
|---|---|
| Freiheitsgrade | 55 |
| Maximale Gelenkgeschwindigkeit | 25 rad/s |
| Größe/Gewicht | 171 cm/63 Kg |
| Gesamtmaschinenlast | 160 Kg+ |
| Maximales Gelenkdrehmoment | 400 Nm |
| Kategorie | KI und humanoide Roboter |
| Vorlaufzeit | 60 Tage |
Die Werte sind Nominalwerte bei 20 °C. Laden Sie das Datenblatt für CAD-Modelle, Drehmomentkurven und Controller-I/O-Karten herunter.
Wo es läuft
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Dimensionierung und Inbetriebnahme durch TROY-Ingenieure.
Fragen des Käufers
Was sind die wichtigsten Spezifikationen?
Modell: TR-Star, Freiheitsgrade: 55, Maximale Gelenkgeschwindigkeit: 25 rad/s.
Was ist die Vorlaufzeit?
60 Tage für die Standardkonfiguration; im Angebot bestätigt.
Kann es individuell angepasst werden?
Ja – OEM/ODM-Optionen, Spannung, Werkzeuge und Branding können angepasst werden. Senden Sie den Antrag und zielen Sie auf die Ausgabe eines Angebots ab.
Holen Sie sich ein Preisangebot für TR-Star
Geben Sie das Teil, die Zielrate und den Zielport an. Ein Techniker – kein Chatbot – antwortet innerhalb von 48 Stunden.
Gleiche Kategorie

Humanoider Roboter mit zwei Armen auf Rädern

Zweiarmiger humanoider Roboter

Biomimetischer Panda-Serviceroboter
Bewertet von TROY Engineering ·. Bei jedem Angebot werden die Spezifikationen erneut anhand des Datenblatts des Lieferanten überprüft.