


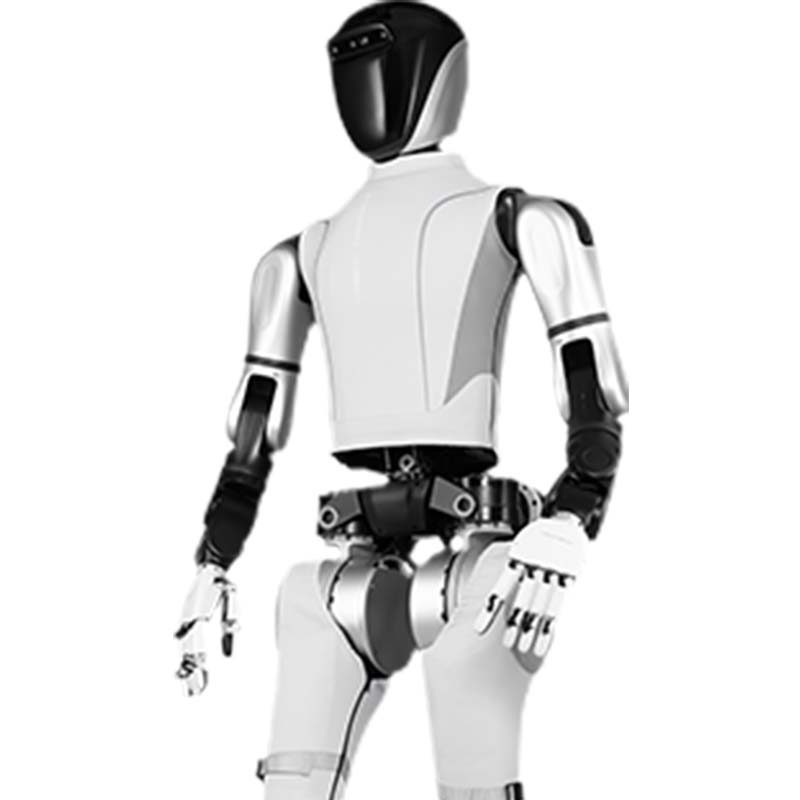
Robot umanoide AGI TR-Star 1
Il TR-Star è un robot umanoide di ricerca/ricezione. Specifiche chiave: Gradi di libertà 55; Velocità massima del giunto 25 rad/s; Altezza/peso 171 cm/63 Kg. Il tempo di consegna è di 60 giorni; il prezzo è indicato per configurazione. Certificazioni: documentazione CE su richiesta.
- Modello
- TR-Stella
- Gradi di libertà
- 55
- Velocità massima del giunto
- 25 rad/s
- Altezza/peso
- 171 cm/63 Kg
- Carico totale della macchina
- 160 Kg+
- Coppia massima del giunto
- 400 Nm
A cosa serve questa piattaforma
Robot umanoide AGI TR-Star 1 ad alte prestazioni: *Gradi di libertà: 55 *Velocità massima del giunto: 25 rad/s *Altezza/peso: 171 cm/63 Kg *Carico totale della macchina: 160 Kg+ *Coppia massima del giunto: 400 Nm *5 dita della mano: giunti completamente semoventi / 12 gradi di libertà indipendenti.
Termini commerciali
| Preventivo | Prezzo per configurazione: risposta entro 48 ore |
|---|---|
| Tempi di consegna | 60 giorni |
| MOQ | 1 unità |
| Origine | Cina |
| Porto di carico | Qingdao, China |
| Incoterm | FOB Qingdao / CIF on request |
| Pagamento | Deposito del 30%, 70% prima della spedizione |
| Garanzia | 24 mesi standard, 36 mesi facoltativi |
Dettagli del prodotto
Note applicative, disegni costruttivi e video dal file di progettazione TROY: la stessa documentazione fornita con il preventivo.
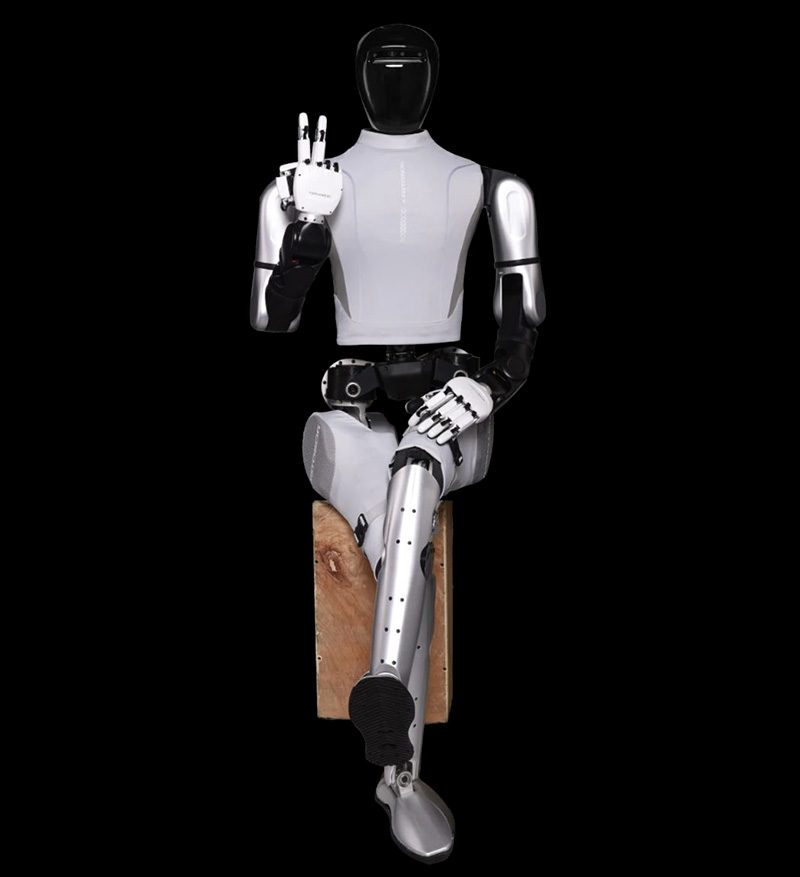
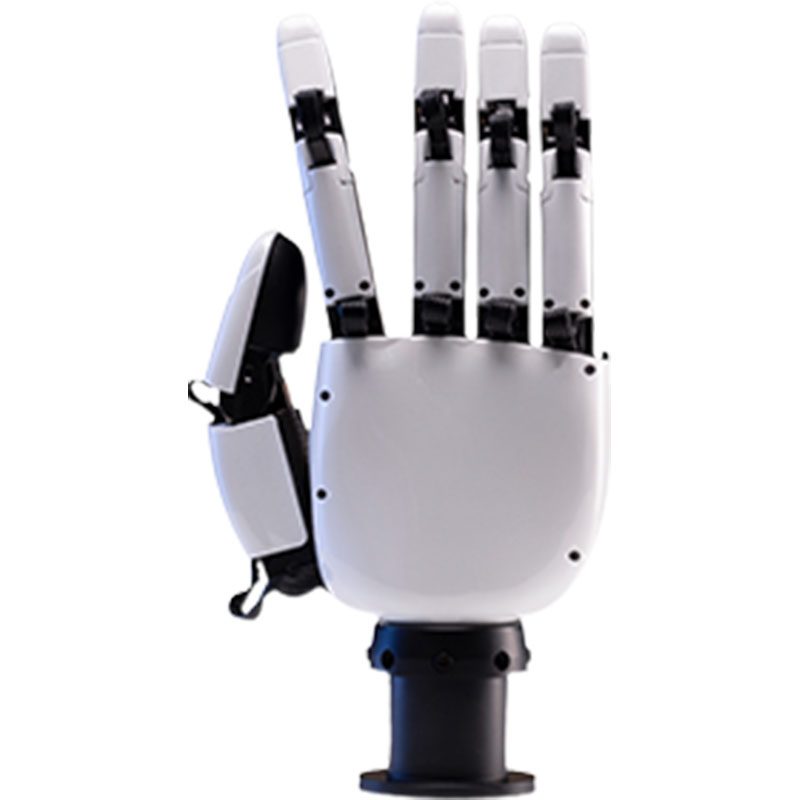
TR-STAR 1's upper limbs include a self-developed high-precision bionic robotic arm with 7 degrees of freedom, and the high-performance dexterous hand XHAND1 with 12 fully active and self-driven degrees of freedom, enabling TR-STAR 1 to have industry-leading actuators in the field of fine manipulation tasks and adapt to the application needs of various scenarios.
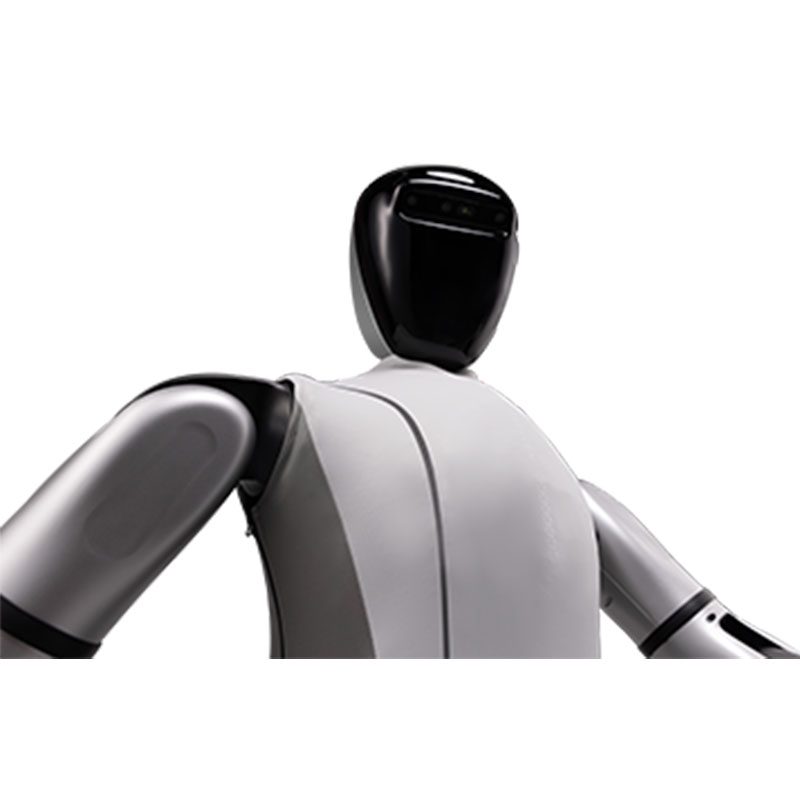
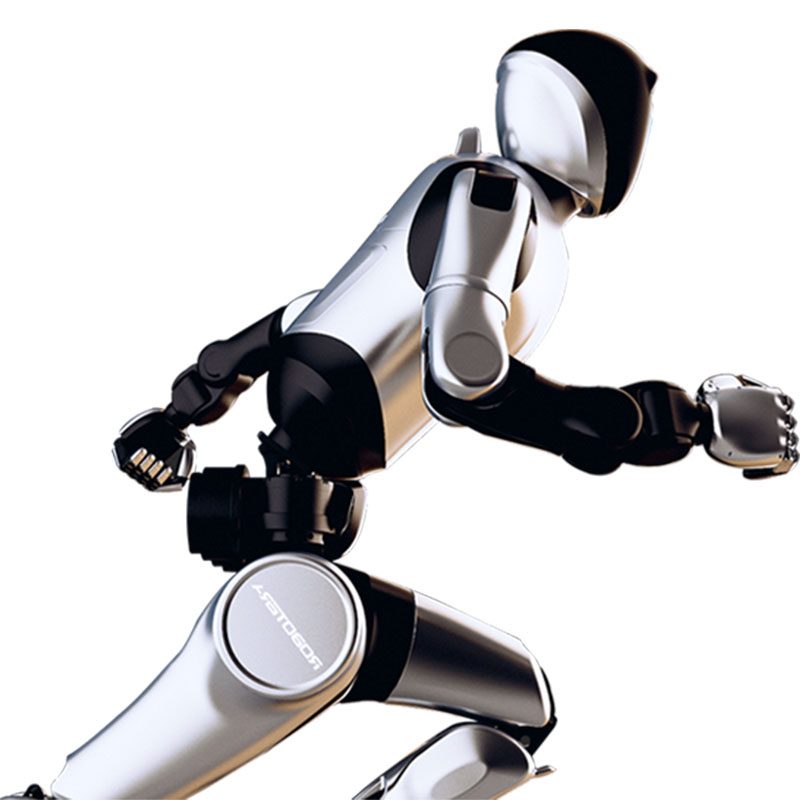
TR-STAR 1 is the first domestically produced high-performance AGI Humanoid Robot with 55 degrees of freedom. The maximum joint torque is 400Nm and the maximum speed is 25rad/s. This makes the Star-Moving STAR1 have the industry's advanced dynamic performance. The running speed in real outdoor scenes reaches 3.6m/s. With the three degrees of freedom of the waist, it can easily complete complex movements such as stable walking, running, jumping, etc. in a natural gait.
TR-STAR 1 integrates Intel high-performance processors and Nvidia Orin's powerful computing resources, providing excellent computing support for humanoid robots in reinforcement learning, imitation learning, and end-to-end large model research. The robot is also equipped with a variety of peripherals such as fingertip array tactile sensors, deep vision cameras, microphone arrays, and facial interactive screens, as well as complete software and teleoperation systems, which facilitate efficient training and highly autonomous operation.
TR-STAR 1 è un eccezionale rappresentante della profonda integrazione tra intelligenza artificiale e hardware robotico. È progettato per affrontare le sfide della ricerca scientifica attuale e futura e offre prestazioni e flessibilità eccellenti.
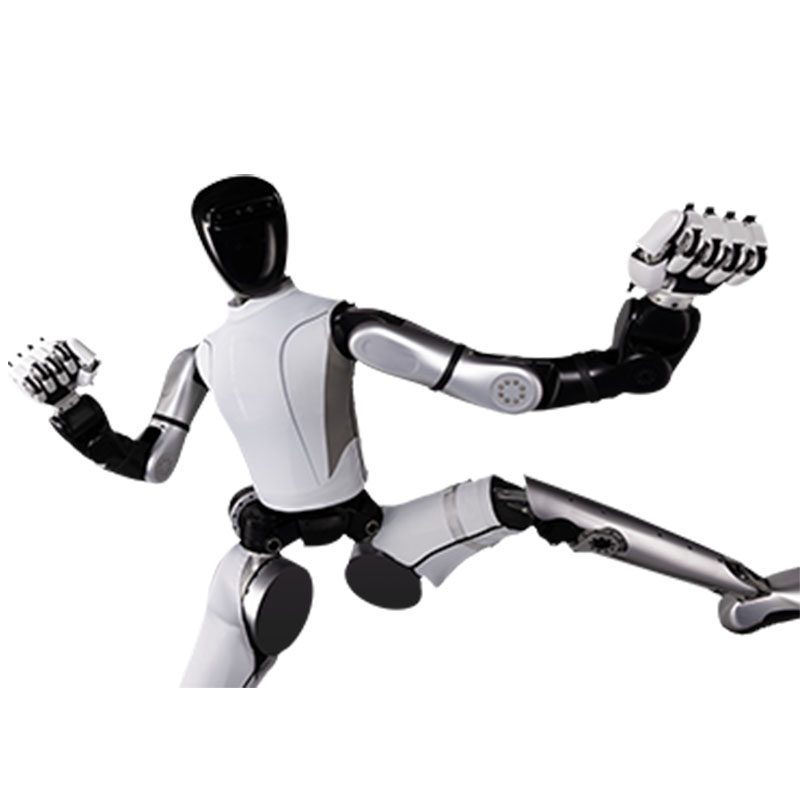
High versatility and autonomous adaptability
TR-STAR 1 ha un'adattabilità autonoma in una varietà di ambienti non modellati e può eseguire una varietà di compiti come raccogliere oggetti e versare acqua, tagliare fiori e piante e camminare e correre su strade complesse.
Rapid iteration capability
Basandosi sul modello di robot nativo di grandi dimensioni e sulla piattaforma hardware definita per l'intelligenza artificiale, Star Era ha rapidamente ripetuto 6 generazioni di robot in 1 anno.
World-class performance
La velocità di corsa nelle scene reali all'aperto raggiunge i 3,6 m/s e può camminare e correre stabilmente su terreni e ambienti complessi.
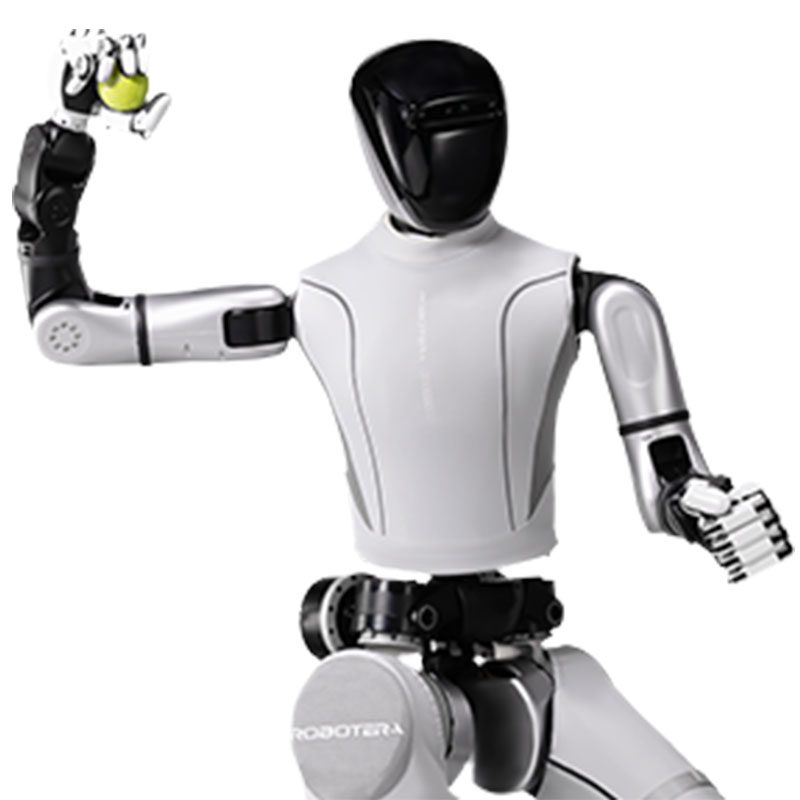
Integrated joint module:
In view of the application characteristics of humanoid robots, the self-developed integrated series joints integrate frameless torque motors, precision planetary reducers, high-precision encoders, and drivers. They have EtherCAT high-speed communication, high-precision force-position mixed control mode, compact structure, high positioning accuracy, high response frequency, and high torque density, and are suitable for robot applications with dynamic variable loads.
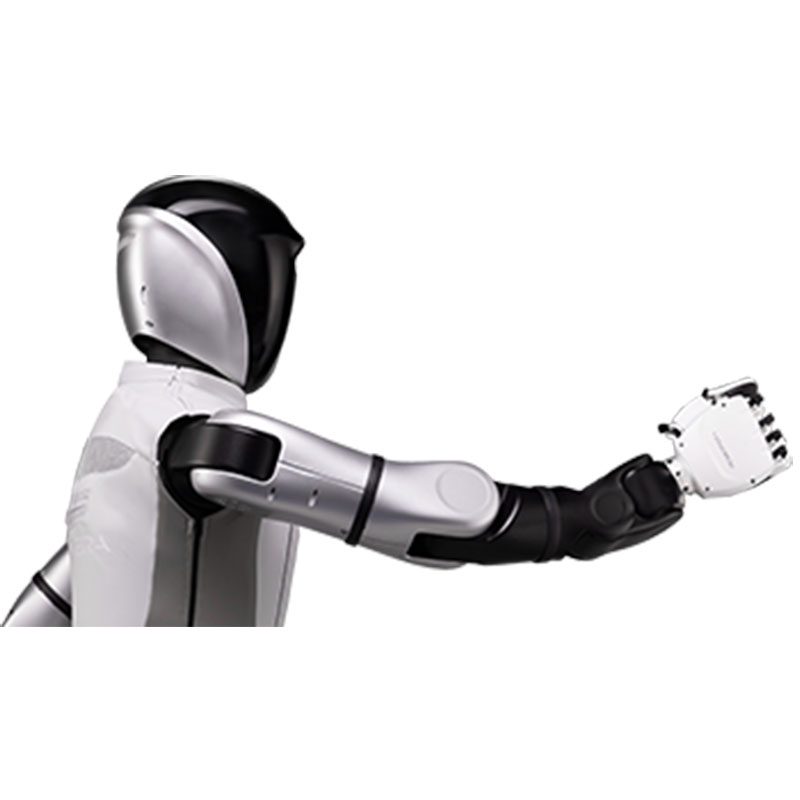
High-performance AGI Humanoid Robot model: TR-STARs1:
Height: 171 cm
Weight: 63 Kg
Degrees of freedom: 55
Computing power: 275 TOPS
Mano abile: 12 gradi di libertà attivi per una mano, copertura completa della punta delle dita tattili
Sensor: tactile sensor, camera, depth camera
Movimento: velocità di corsa fino a 3,6 m/s in una scena reale all'aperto
Arm: Load>20 Kg, 7 degrees of freedom high-precision bionic robotic arm
Mano abile: può oscillare lateralmente, ampia gamma di movimenti delle dita, presa con una sola mano> 25 Kg
Joint: Maximum torque 400 Nm, maximum speed 25 rad/s
Vita e collo: 3 gradi di libertà della vita, 2 gradi di libertà del collo, andatura elegante, interazione amichevole
Total machine load: 160 Kg.
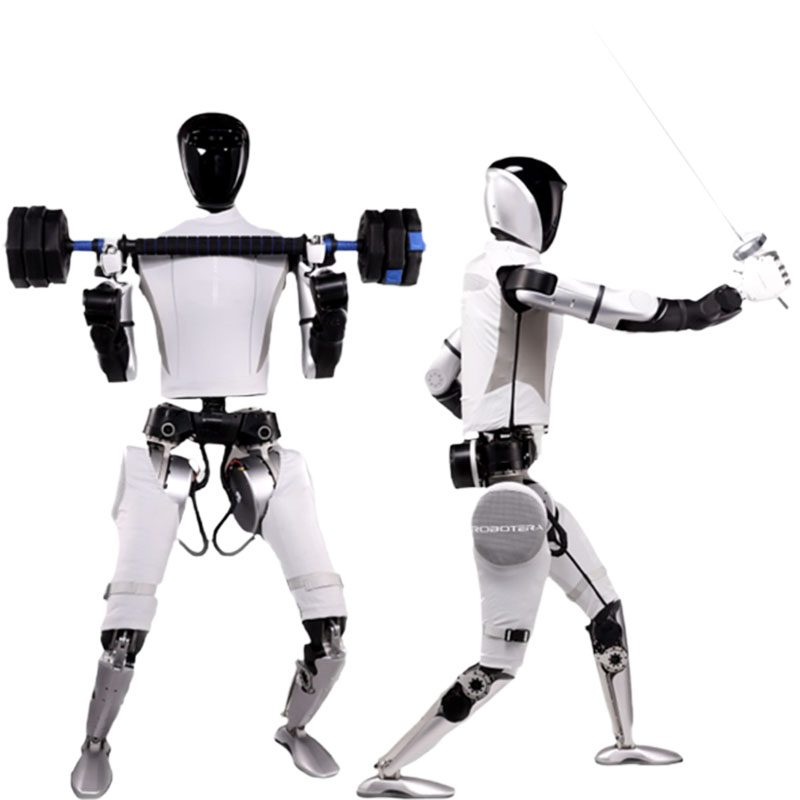
Fully self-driving, truly free degrees:
XHAND1 è la prima mano abile del robot prodotto a livello nazionale, con vantaggi quali elevato grado di libertà, alte prestazioni e alta intelligenza.
5 finger joints fully self-driving, 12 independent degrees of freedom;
High-resolution 3D tactile sensor;
Carico massimo con una sola mano di 80 N e 25 Kg.
The use of native robot large models is a new AI-native learning paradigm that is both universal and simple, and has the ability to fully scale up. Its algorithm processes sensory information such as vision, hearing, and touch through full-modal input fusion, reproducing the most fundamental way of interaction between organisms and the physical world.
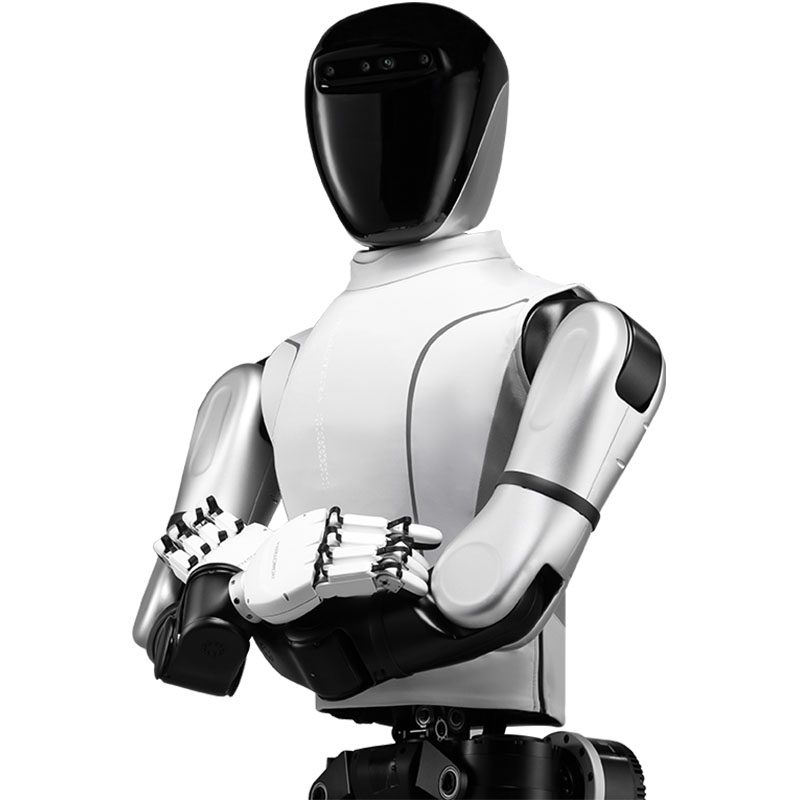
Hardware platform defined for AGI:
The interaction of intelligent bodies relies on physical carriers, and the human form is currently the best example of general intelligence. Based on this, a new humanoid robot hardware architecture that integrates hardware and software and is tailored for AI is designed. From the underlying motor to the bipedal system and dexterous hands, all components are AI-friendly. Ensure that the algorithm can be quickly verified on the hardware, greatly improve the efficiency of Sim2Real, and achieve the co-evolution of software and hardware.
Dati tecnici completi
| Modello | TR-Stella |
|---|---|
| Gradi di libertà | 55 |
| Velocità massima del giunto | 25 rad/s |
| Altezza/peso | 171 cm/63 Kg |
| Carico totale della macchina | 160 Kg+ |
| Coppia massima del giunto | 400 Nm |
| Categoria | Robot IA e umanoidi |
| Tempi di consegna | 60 giorni |
I valori sono nominali a 20 °C. Scarica la scheda tecnica per i modelli cad, le curve di coppia e le mappe I/O del controller.
Dove corre
Dimensionato e commissionato dagli ingegneri TROY.
Dimensionato e commissionato dagli ingegneri TROY.
Dimensionato e commissionato dagli ingegneri TROY.
Dimensionato e commissionato dagli ingegneri TROY.
Domande dell'acquirente
Quali sono le specifiche principali?
Modello: TR-Star, Gradi di libertà: 55, Velocità massima del giunto: 25 rad/s.
Qual è il tempo di consegna?
60 giorni per la configurazione standard; confermato a preventivo.
Può essere personalizzato?
Sì: è possibile adattare opzioni OEM/ODM, voltaggio, attrezzature e marchio. Invia l'applicazione e l'output di destinazione per una proposta.
Ottieni una proposta di prezzo per TR-Star
Includere la parte, la tariffa target e il porto di destinazione. Un ingegnere, non un chatbot, risponde entro 48 ore.
Stessa categoria

Robot umanoide a doppio braccio con ruote

Robot umanoide a doppio braccio

Robot di servizio Panda biomimetico
Recensito da TROY Engineering ·. Le specifiche vengono ricontrollate rispetto alla scheda tecnica del fornitore ad ogni preventivo.