


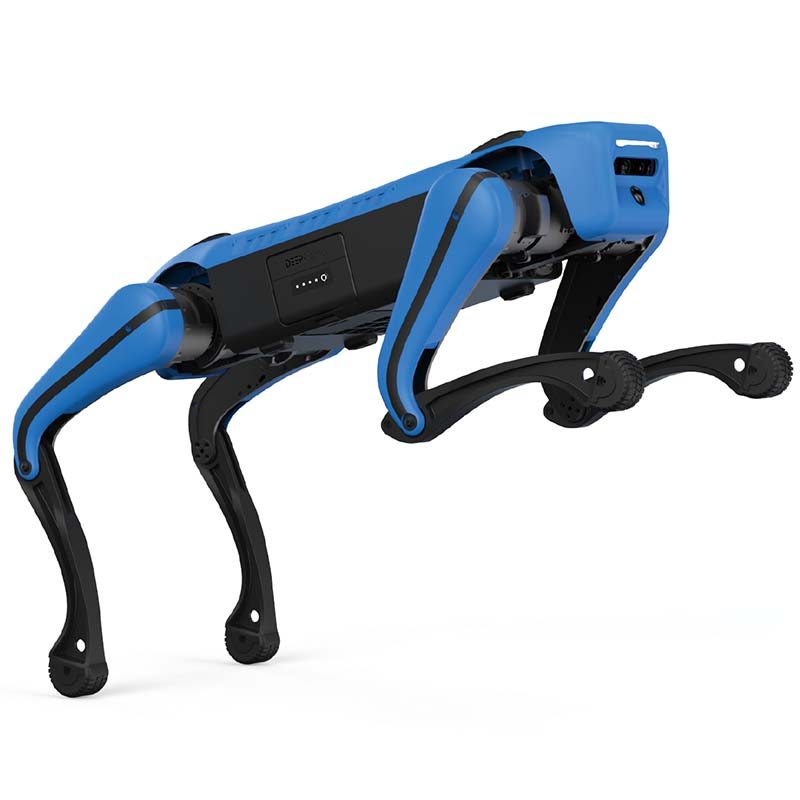
Inspection Four-Legged Mini Robot Dog
The TR-4RDM is a service robot for hospitality / cleaning. Lead time is 15 days; pricing is quoted per configuration. Certifications: CE documentation on request.
- Model
- TR-4RDM
- Lead time
- 15 days
- Category
- Service Robots
What This Platform Is For
Inspection four-legged robot dog applications: Facing the application requirements in complex and dangerous environments, it provides intelligent solutions for application scenarios such as firefighting and rescue, anti-terrorism, and anti-explosion.
Commercial Terms
| Quotation | Priced per configuration — reply within 48 hours |
|---|---|
| Lead time | 15 days |
| MOQ | 1 unit |
| Origin | China |
| Port of loading | Shenzhen, China |
| Incoterm | FOB Shenzhen / CIF on request |
| Payment | 30% deposit, 70% before shipment |
| Warranty | 24 months standard, 36 months optional |
Product Details
Application notes, construction drawings and video from the TROY engineering file — the same documentation shipped with the quotation.
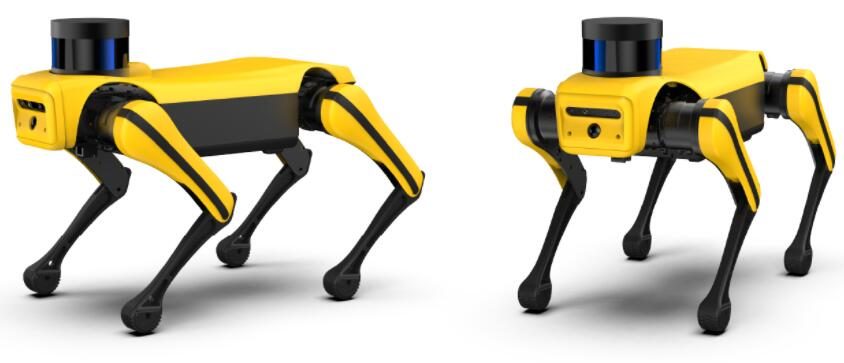
Robotic Dog is an intelligent quadruped robot independently developed by DeepRobotics. Based on advanced control algorithms, it has multiple motion modes such as walking, sliding, jumping, running, and back somersault. It has freely superimposed intelligent modules, capable of autonomous positioning and navigation, real-time obstacle avoidance, and visual recognition. It has a user-oriented design concept, with new functions such as voice interaction, sound source positioning, and safety and collision avoidance, giving users a better interactive experience and safety assurance.
Robotic Dog is open control and perception protocol is an intelligent robot system platform that can be re-developed.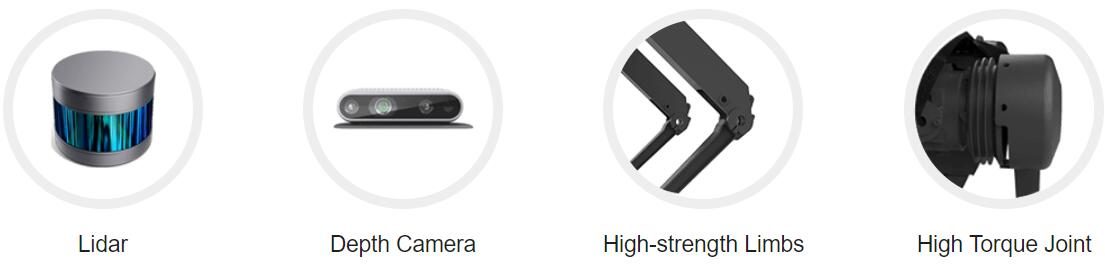
Complex Terrain Based on the accurate terrain perceiving technology and the high distinction in capability of expeditious recovery after missing steps, robot dog succeeds to adapt unstructured terrains e.g. stairs, gravel, ramp, grass etc. and even terrain with obstacles. Technical reliability is guaranteed in omnidirectional intelligent agile mobility during working on the complicated terrains.
Mobility The unprecedented dynamic gait planning and motion control technology allow robot dog to realize various gait type e.g. walk, flying-trot, galloping, pronk etc. even working on the complicated terrains e.g. stairs, ramp, obstacles, gravel, and lawn.
Balancing Robustness is assured based on the high-frequent real-time control system and the algorithm of dynamical balancing. robot dog can recover to balance state under all-directional perturbation. Even under the situation of missing step, the rapid recovering to stability is guaranteed.
High Dynamic Mobility
Robot dog achieves to perform high dynamical gaited motion e.g. Flying-Trot, Bound, Gallop, Pronk and so on due to the powerful performance in joint drive as well as the high dynamical gait planning and control technique.
Interactive Mode
Based on adequate I/O interfaces and the well-behaved perceptual interactive technology, robot dog can access to diverse interactive patterns e.g. Remoter, Touch , Vision, Gesture, and Voice control offering users a better interactive experience.
Jumping
By virtue of morphology of bucolical legs design and the powerful joint drive, the new robot dog is able to jump over 40cm obstacles. The jumping height reaches 70cm and 1.5m range of long jump are available.
Auto-recharging
The localization of auto-recharging utilizes the feedback of visual information. Under the assistance of vision system, the robot is lead to the charging zone operating in low speed locomotion. When specified region are arrived, the connection to the charging pile is triggered. With the help of the precise visual locomotion information, the robot will keep calibrating until the ‘done’ state is detected.
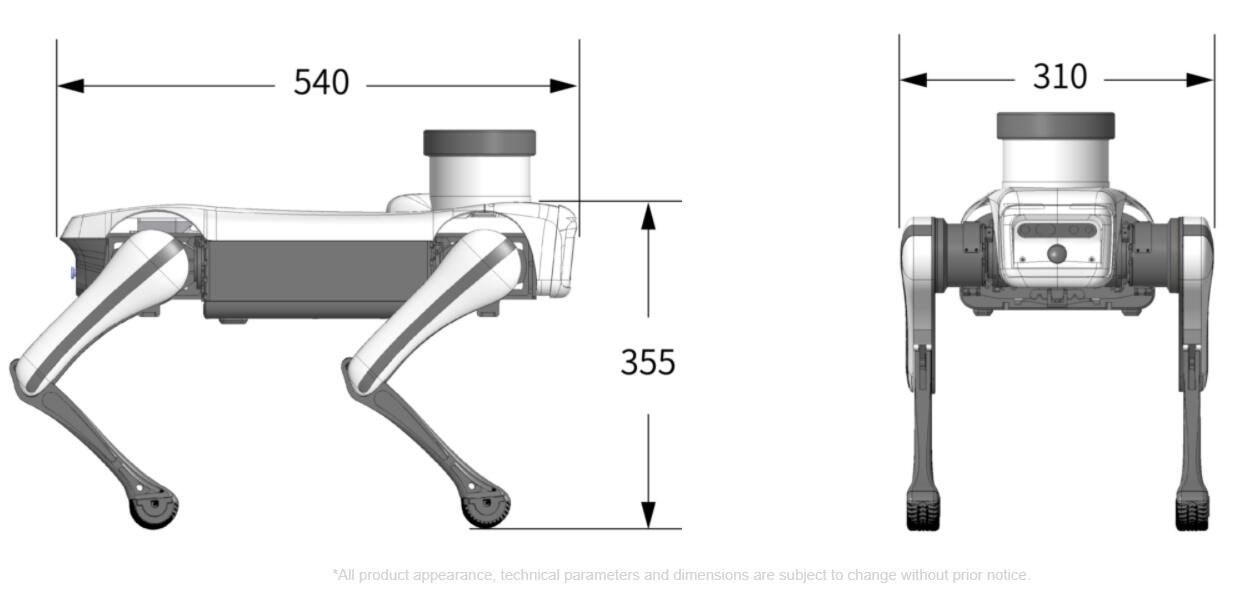
Robotic Dog mini Technical Parameters
· Gross Weight: 9kg
· Maximum Load: 5kg
· Standing Dimension (L* W * H): 540mmx310mmx355mm
· Joint DOF: 12
· Maximum Speed: 3.5m/s
· Average Runtime: 1.5-3h
· Processor: Intel Processor
· Operating System: Ubuntu
· Programming Language: C/C++, Python
· Communication Bus: CAN
· Maximum Slope: 25°
· Developing-Supported Gaits: 1. Trot
2. Flying-Trot
3. Pace
4. Pronk
5. Bound
6.Gallop
7.Backflip
8. Support other high-performance gait developing
· Developing-Supported Locomotions
1.Balancing under external force disturbance
2.Autonomous stand up after fall down
3.Crawl、Head up、Body twist,etc.
· Communication Interface: Ethernet, USB, WIFI, HDMI
· Depth Camera: Intel Realsense D435i
· Perception Processor: Intel Processor
· GPU Processor(optional): NVIDIA Jetson Xavier NX
· Visual Perception Function: Depth Camera for Collision avoidance
· Adds-On: HD Wide-Angle Camera, Ultrasound Radar, Multi-lines Lidar
Full Technical Data
| Model | TR-4RDM |
|---|---|
| Lead time | 15 days |
| Category | Service Robots |
Values are nominal at 20 °C. Download the datasheet for cad models, torque curves and controller I/O maps.
Where It Runs
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Buyer Questions
What are the key specifications of the TR-4RDM?
Model TR-4RDM. A full datasheet is available on request.
What is the lead time and MOQ for the TR-4RDM?
Lead time is 15 days; MOQ is 1 unit.
How is the TR-4RDM priced?
Pricing is quoted per configuration, including tooling and freight where applicable.
Get a Priced Proposal for TR-4RDM
Include the part, target rate and destination port. An engineer — not a chatbot — replies within 48 hours.
Same Category

Pipeline Inspection Robot with 4K Camera

Garden Robot Mower

Pipeline Network Cutting and Maintenance Robot TR-PCCRIII
Reviewed by TROY Engineering · . Specifications are re-checked against the supplier datasheet at every quotation.