


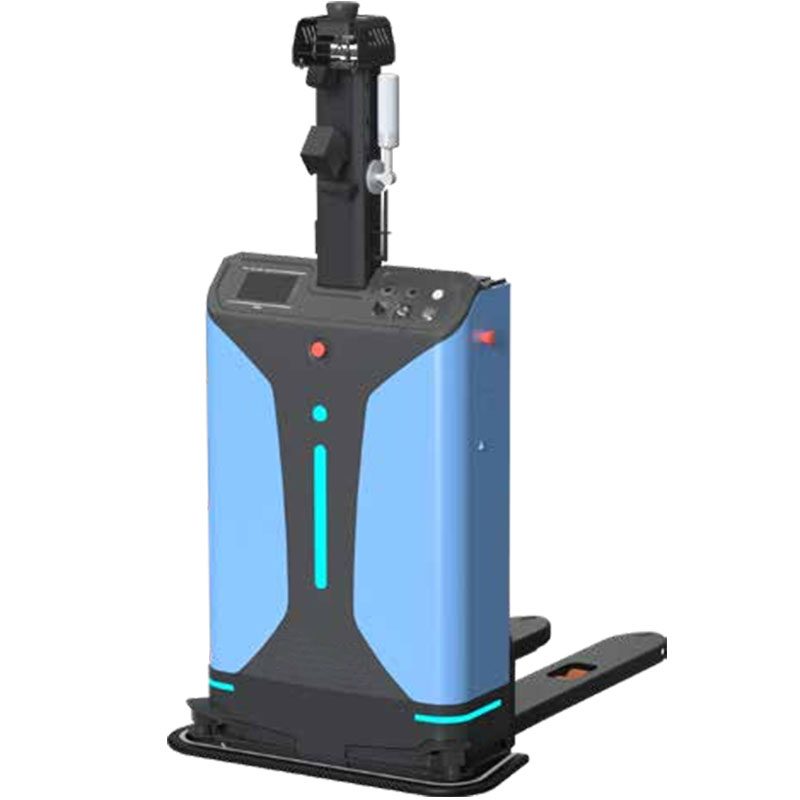
AMR Forklift TR-CDD14
The TR-CDD14 is a mobile robot for internal logistics / warehouse transport. Lead time is 20 days; pricing is quoted per configuration. Certifications: CE documentation on request.
- Model
- TR-CDD14
- Lead time
- 20 days
- Category
- Mobile Robots & AMR
What This Platform Is For
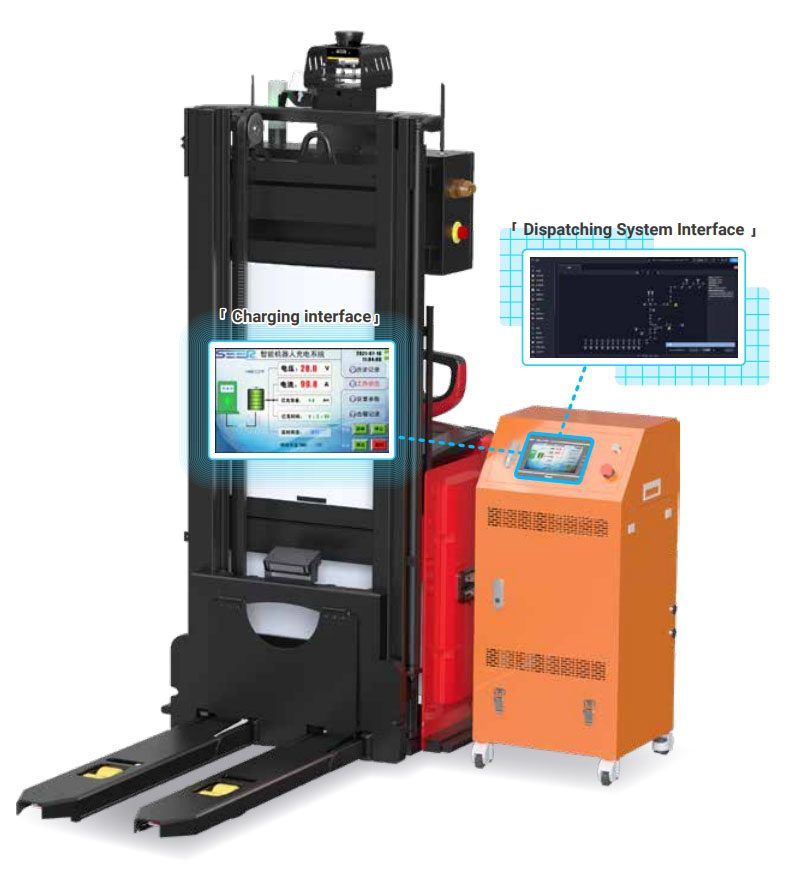
Laser SLAM Small Stacker Automatic Forklift TR-CDD14: SRC-based laser SLAM small stacker automatic forklift, equipped with SRC series core controller inside; using laser SLAM navigation, no reflector, easy to deploy; pallet identification, accurate forklift; flexible scheduling, can be seamlessly connected to the scheduling system ; Slim body, small turning radius, suitable.
Commercial Terms
| Quotation | Priced per configuration — reply within 48 hours |
|---|---|
| Lead time | 20 days |
| MOQ | 1 unit |
| Origin | China |
| Port of loading | Shanghai, China |
| Incoterm | FOB Shanghai / CIF on request |
| Payment | 30% deposit, 70% before shipment |
| Warranty | 24 months standard, 36 months optional |
Product Details
Application notes, construction drawings and video from the TROY engineering file — the same documentation shipped with the quotation.
Hot selling of Unmanned Forklift agv
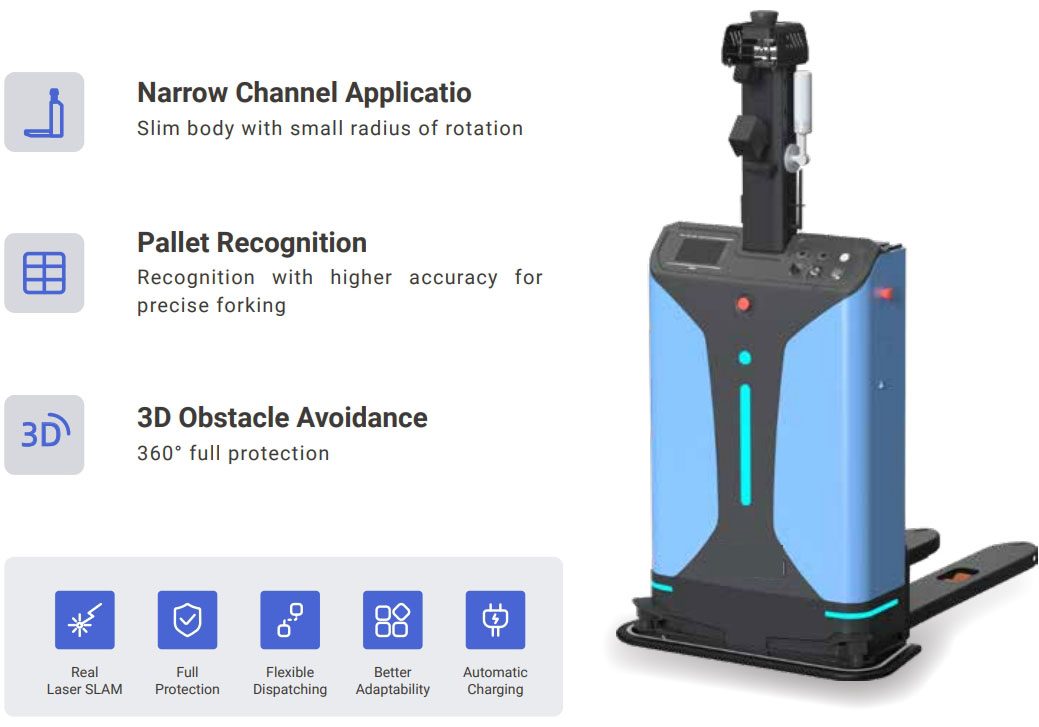
Core advantages
narrow track applications
Slim body Small radius of gyration for narrow aisle applications.
True Laser SLAM
Laser SLAM navigation, no reflector, easy to deploy.
Comprehensive protection
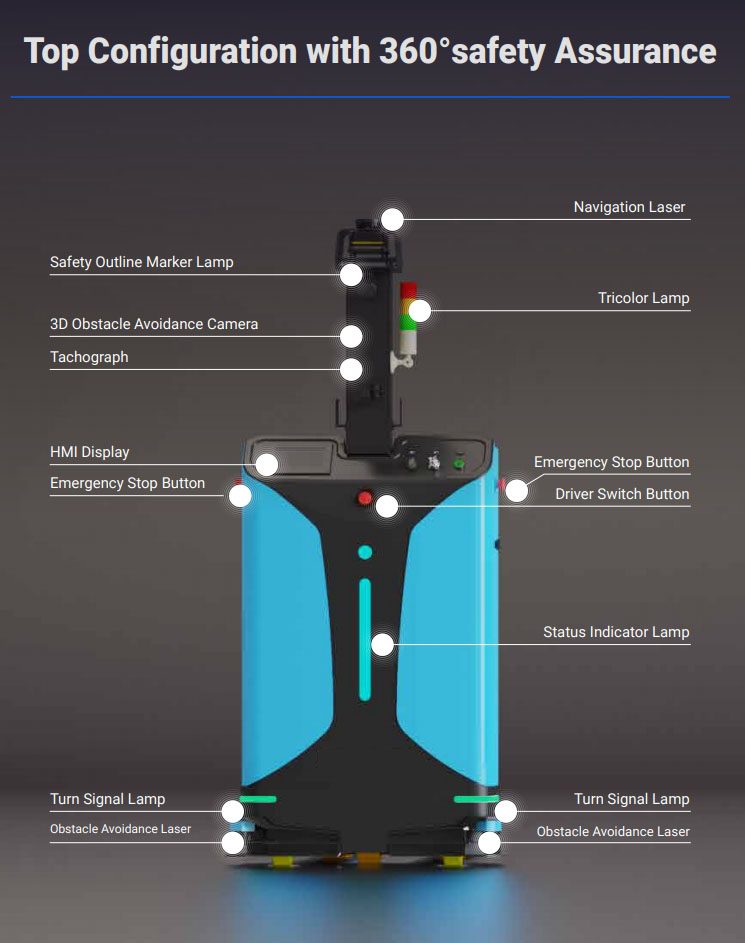
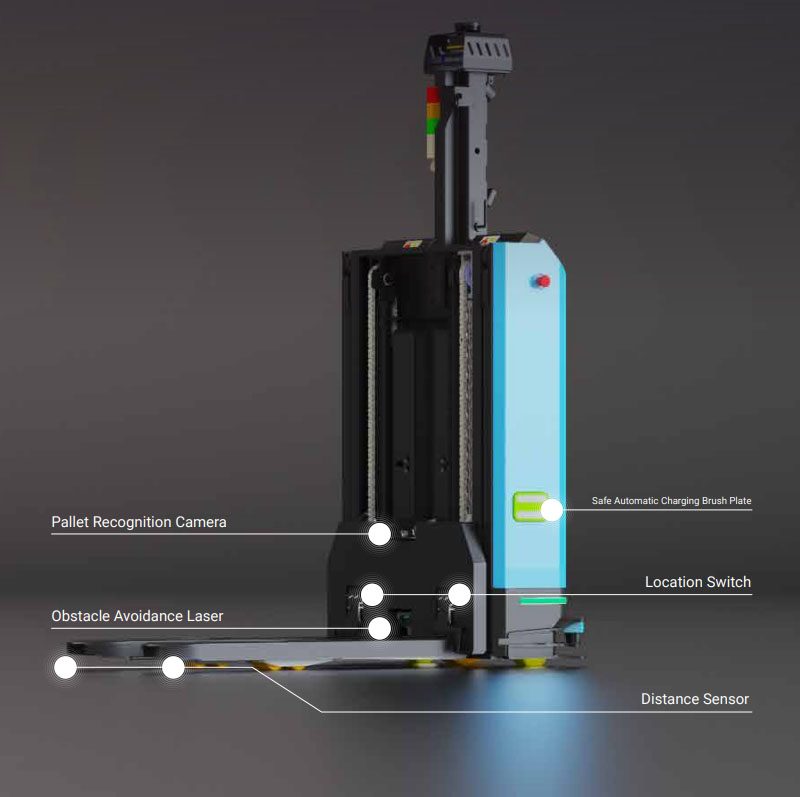
Obstacle avoidance laser + anti-collision bar + distance sensor + 3D obstacle avoidance camera, 360° comprehensive protection.
High precision
Pallet identification, accurate fork goods.
Strong applicability
It can climb slopes, pass over hurdles, pass through elevators, can be transported, and can be stacked.
Flexible scheduling
Seamless access to the scheduling system.
Technical parameters | |
Product model | TR-FL140 |
Product name | Laser SLAM small stacker automatic forklift |
Dynamic form | Electric |
Driving mode | Automatic navigation, handheld driving |
Navigation type | Laser SLAM |
Tray type | 3-stringer pallet |
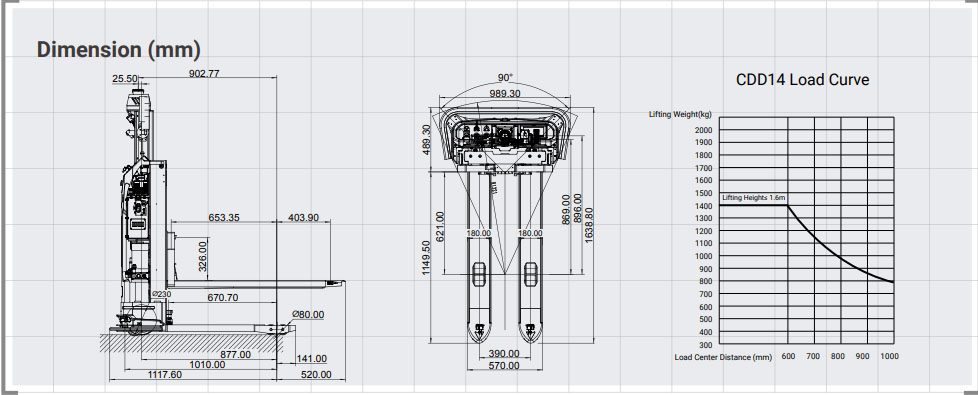
Rated load capacity | 1400kg |
Load centre distance | 600mm |
Wheelbase | 877mm |
Dead weight (with battery) | 680kg |
Navigation position accuracy [1] | ±10mm |
Navigation angle accuracy [1] | ±0.5° |
Fork in-position accuracy [1] | ±10mm |
Standard lifting height | 1600/3000mm |
Gantry height | 2130mm |
Fork surface ground clearance (at the lowest position) | 85±5mm |
Navigation laser scanning height | 2025mm |
Vehicle size: length * width * height | 1640*990*2043mm |
Fork size: length * width * height | 1150*180*55mm |
Fork outer width | 570/680mm |
Right-angle stacking channel width, pallet 1000×1200 (1200 placed across forks) | 1888mm |
Right-angle stacking channel width, pallet 800×1200 (1200 placed along the fork) | 1880mm |
Map area (Single) | ≤ 400000m² |
Minimum turning radius | 1182mm |
Performance parameters | |
Driving speed: full load/no load | 1.2/1.5m/s |
Lifting speed: full load/no load | 115/170mm/s |
Descent speed: full load/no load | 160/125mm/s |
Gantry movement speed: full load/no load | / |
Passability (slope/step/gap)[2] | < 5%/20mm/30mm |
Drive motor power (S2, 60 min) | 1.25kW |
Lifting motor power (S3, 15%) | 3kW |
Steering motor power (S2, 10 min) | 0.165kW |
Service braking mode | Electromagnetic brake |
Drive control mode | Servo control |
Wheel parameters | |
Tyre type: drive wheel/support wheel | Polyurethane/Polyurethane |
Tire size: driving wheel | 230x75mm |
Tire size: bearing wheel | 80x54mm |
Tire size: Balance wheel | 115x55mm |
Wheel number: driving wheel (×= driving wheel)/ bearing wheel | 1X-2/4 |
Wheel base: bearing side | 538mm |
Wheel base: driving side | 380mm |
Battery parameters | |
Battery specifications | 24/180 (Lithium Iron Phosphate)V/Ah |
Battery weight | 58kg |
Comprehensive battery life | 10h |
Charging time (10%-80%) | 2h |
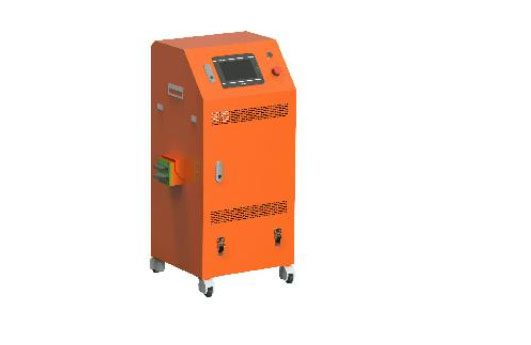
Charging method | Manual/Automatic |
Battery cycle number | > 2000 |
Certifications | |
ISO 3691-4 | × |
EMC/ESD | √ |
UN38.3 | √ |
RoHS | √ |
REACH | √ |
Function configurations | |
Wi-Fi roaming function | √ |
3D obstacle avoidance [3] | 〇 |
Remote emergency stop [4] | 〇 |
Pallet recognition[3] | 〇 |
Cage stack [3] | 〇 |
High shelf pallet recognition[3] | 〇 |
Pallet damage detection [3] | 〇 |
Pallet stacking and unstacking [5] | 〇 |
The HMI screen | √ |
Fork tooth distance sensor | √ |
Cargo weight detection | 〇 |
Safety configurations | |
E-stop button | √ |
Sound and light indicator | √ |
Braking distance: 1m/s / 1.5m/s | ≤30cm / ≤50cm |
Vehicle hardware fault detection | √ |
360° laser protection | √ |
Bumper strip | √ |
High safety protection of fork teeth | √ |
Others | |
Network | 4G / 5G / Wi-Fi 802.11 a/b/g/n/ac |
Ground flatness | ±5mm/m² |
Scenario requirements | Only suitable for indoor, light intensity ≤40 klx (IEC 61496-3), ground without water and oil and other scenes |
Ambient temperature and humidity range | TEMP: 0-50℃ / RH: 10-90%, no compression, no condensation |
IP rating | IP20 |
Noise near driver's ear according to EN12053 | ≤70dB(A) |
Full Technical Data
| Model | TR-CDD14 |
|---|---|
| Lead time | 20 days |
| Category | Mobile Robots & AMR |
Values are nominal at 20 °C. Download the datasheet for cad models, torque curves and controller I/O maps.
Where It Runs
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Sized and commissioned by TROY engineers.
Buyer Questions
What are the key specifications of the TR-CDD14?
Model TR-CDD14. A full datasheet is available on request.
What is the lead time and MOQ for the TR-CDD14?
Lead time is 20 days; MOQ is 1 unit.
How is the TR-CDD14 priced?
Pricing is quoted per configuration, including tooling and freight where applicable.
Get a Priced Proposal for TR-CDD14
Include the part, target rate and destination port. An engineer — not a chatbot — replies within 48 hours.
Same Category
300 kg CTU Mobile Robot for Rack Handling
30 T Heavy-Load AMR Platform
2 T Autonomous Forklift AMR
Reviewed by TROY Engineering · . Specifications are re-checked against the supplier datasheet at every quotation.