


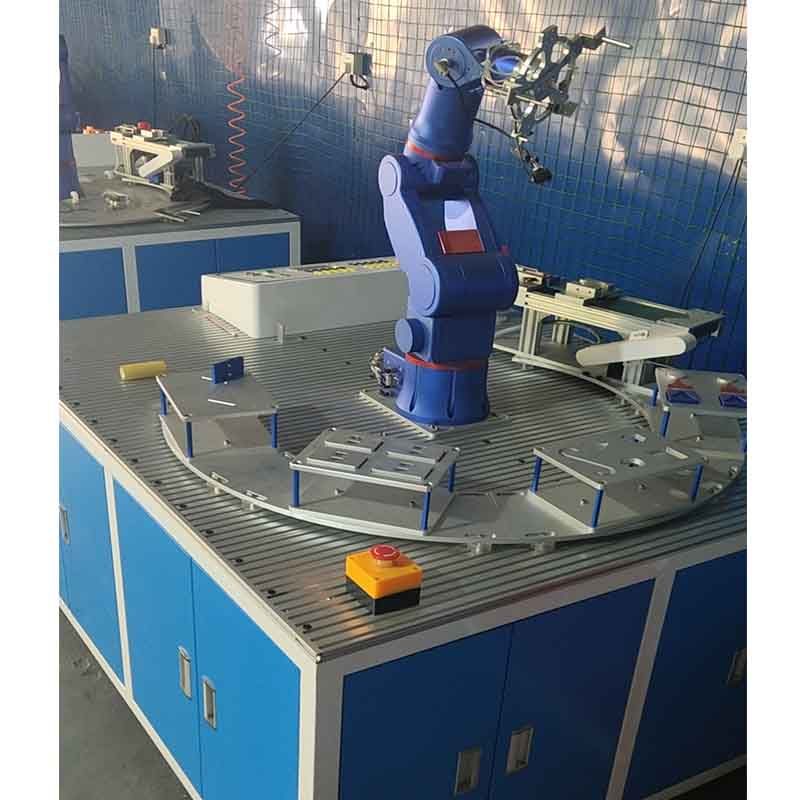
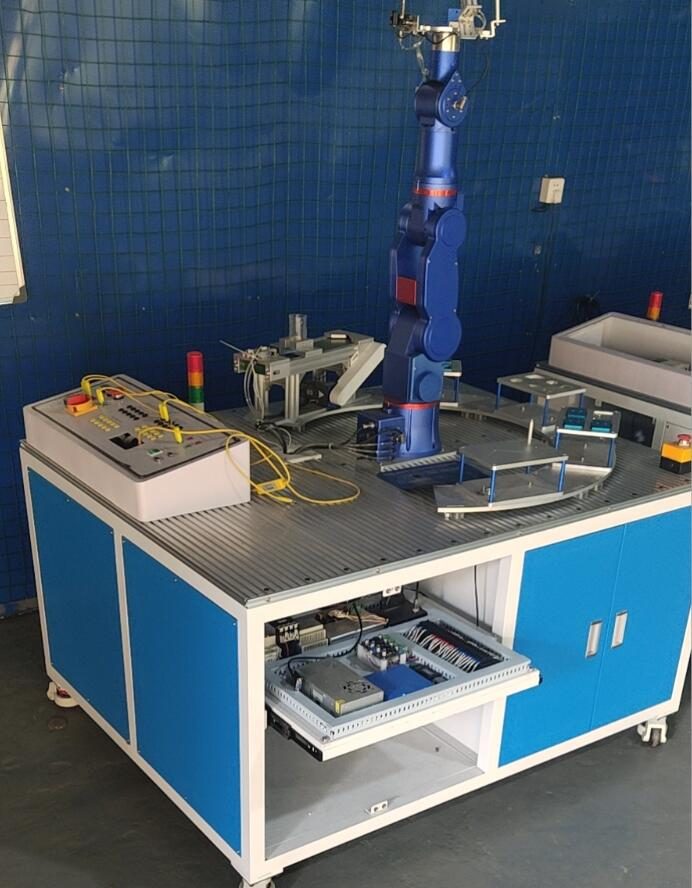
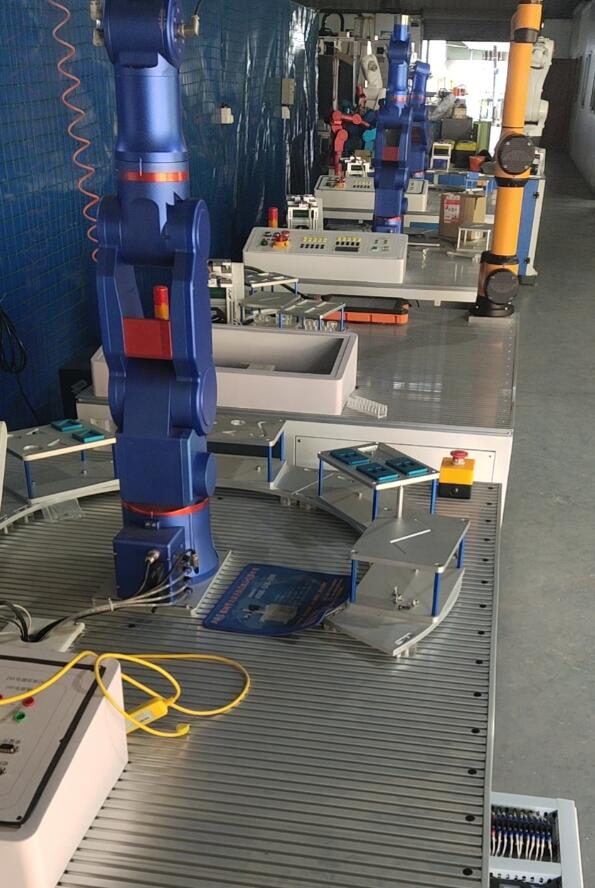
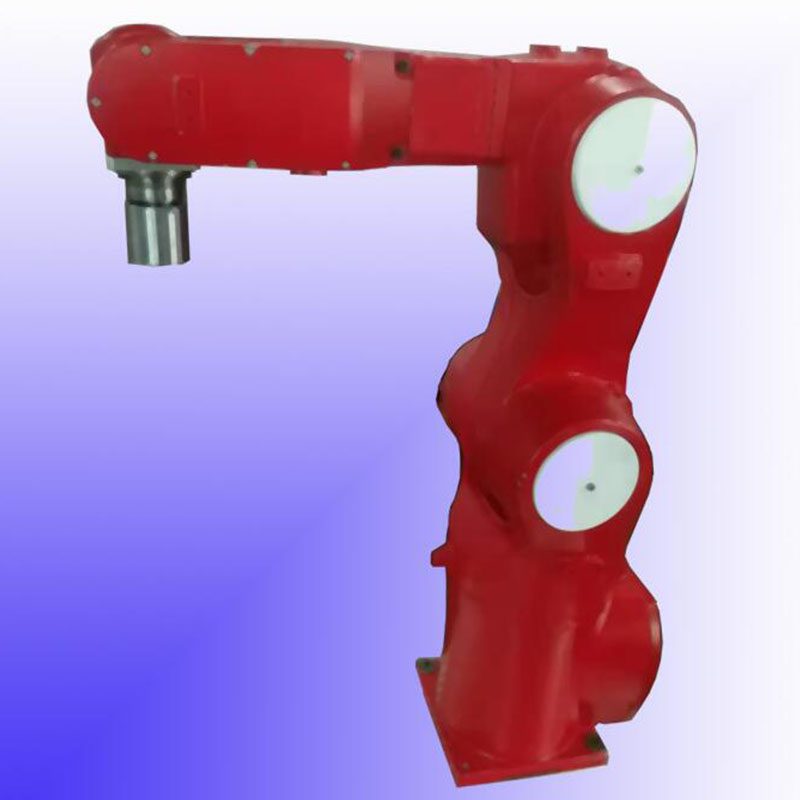
学校およびエンジニアトレーニングセンター向けの産業用6軸ロボットアームトレーニングプラットフォーム
TRE500S-TPは、STEMラボ・職業訓練用ロボットアームです。主な仕様: 軸数 6 軸。リードタイムは15日です。価格は構成ごとに見積もられます。認証: ご要望に応じて CE ドキュメントをご提供します。
- モデル
- TRE500S-TP
- 軸
- 6軸
- カテゴリ
- 教育ロボット
- リードタイム
- 15日
このプラットフォームの目的
産業用6軸ロボットアームトレーニングプラットフォーム トレーニング対象: ・6軸ロボットアームをプログラムで動かすのに便利 ・ロボットグリッパによるI/O制御に便利 ・PLCとの接続に便利 ・日常のメンテナンスに便利
商業条件
| 引用 | 構成ごとの価格 - 48 時間以内にご返信ください |
|---|---|
| リードタイム | 15日 |
| MOQ | 5台 |
| 起源 | 中国 |
| 積地港 | 深セン、中国 |
| インコタームズ | FOB 深セン / CIF (ご要望に応じて) |
| 支払い | 30% のデポジット、出荷前に 70% |
| 保証 | 標準は 24 か月、オプションは 36 か月 |
製品詳細
TROY エンジニアリング ファイルからのアプリケーション ノート、構造図、およびビデオ — 見積書に同梱される同じ文書。
Instruction of six-axis robot training teaching platform
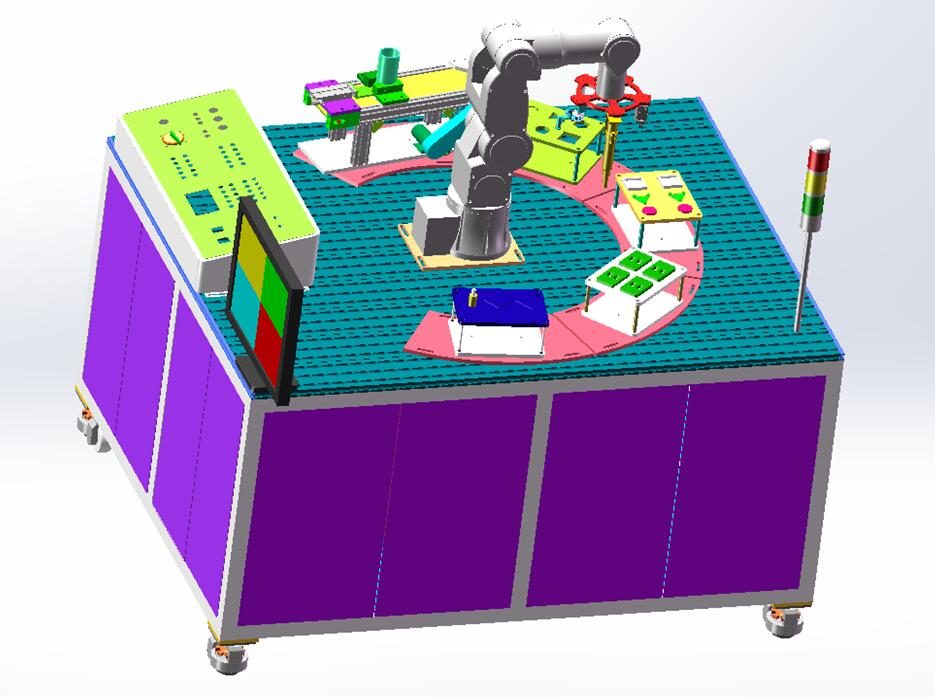
First: Introduction
これ ロボット教育およびトレーニングワークステーションはロボットに基づいており、 対応する周辺モジュール式アクセサリ、主に以下が含まれます: 組立ライン、パレタイジングハンドリング、溶接トラックモジュール、材料クランプ、 位置決めピン、真空吸着、検出。
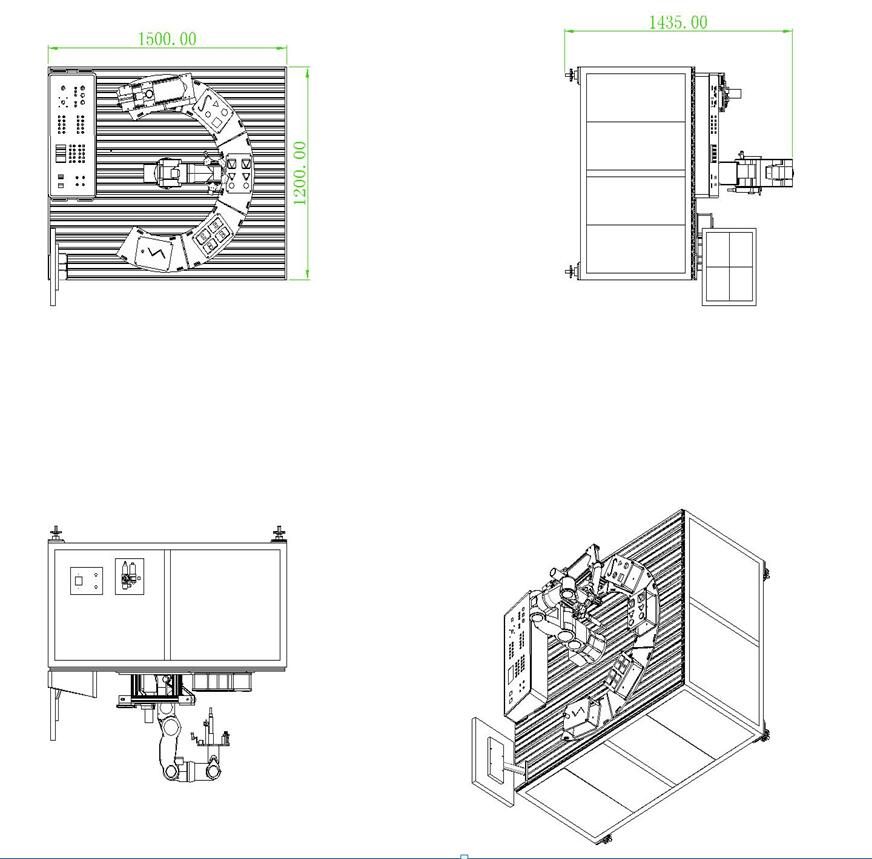
Third: Instructions for each functional module (1)
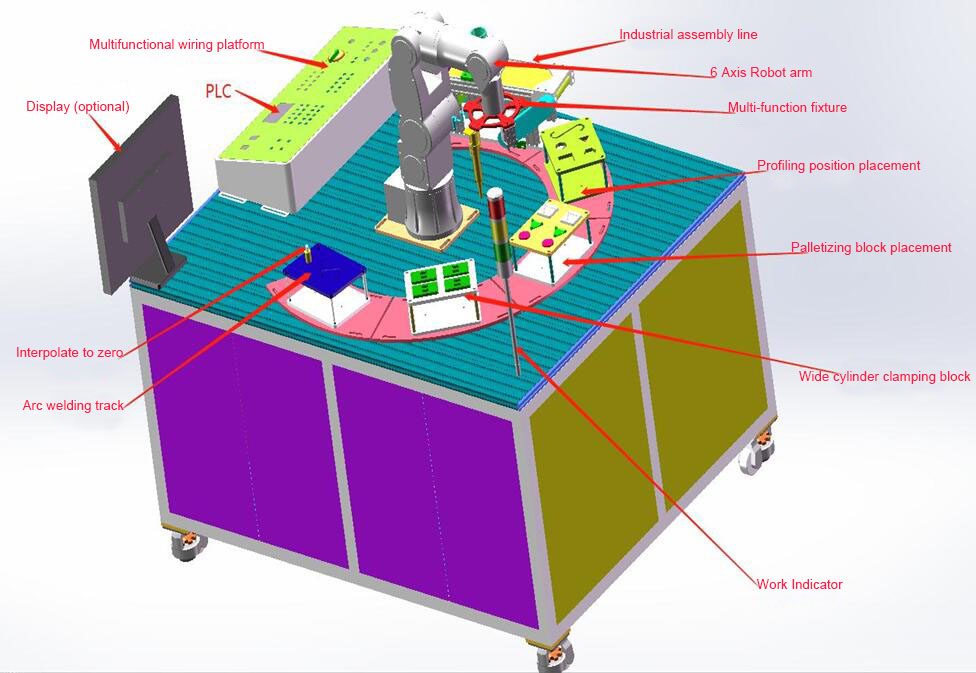
Instructions for each functional module (2)
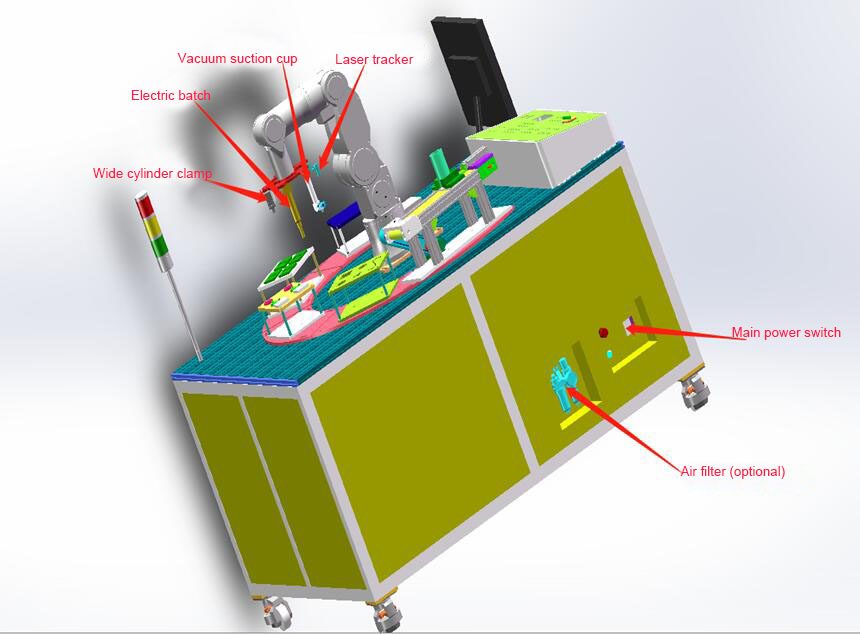
4番目: の動作フローの説明 各機能モジュール
4.1 Multi-function fixture
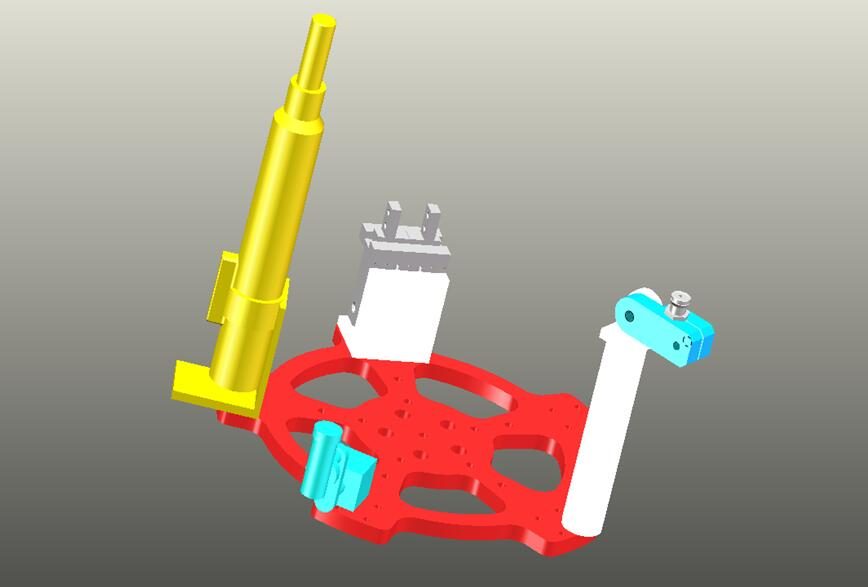
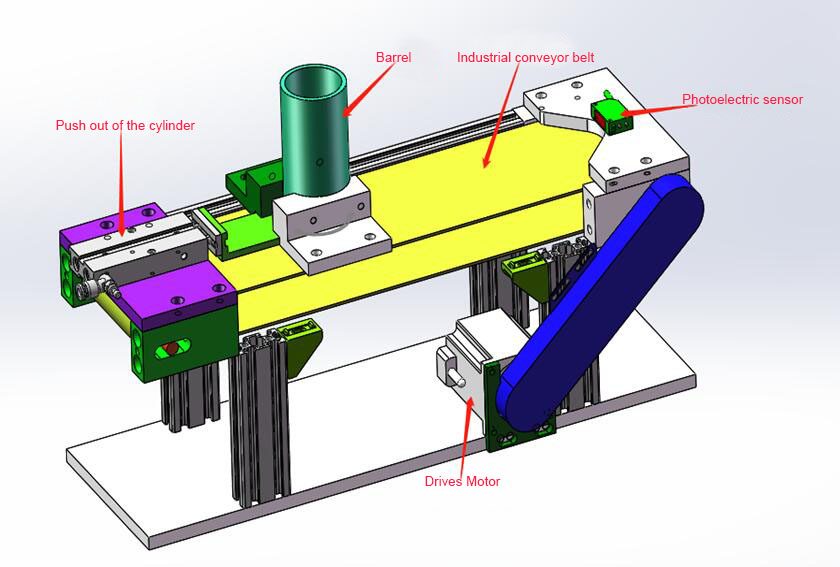
4.2:
Industrial transmission belt
Operation process description: the cylinder pushes the round block and falls
onto the conveyor belt, the belt transfers the round block to the front baffle
position, the sensor senses that the round block is in place and sends a signal
to the PLC, and the PLC controls the belt to stop the transmission movement
Move to the top of the round block and take it.
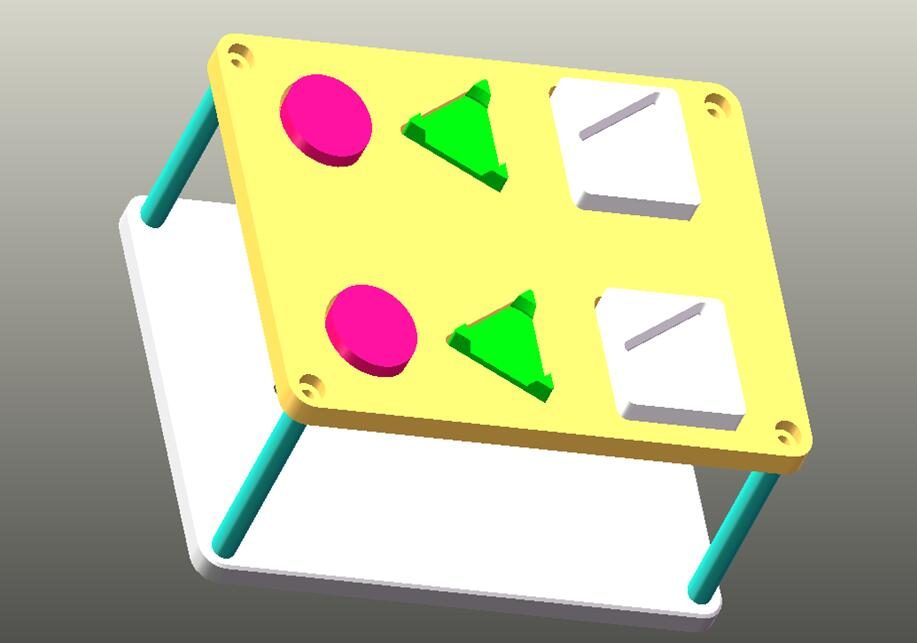
4.3:
Palletizing platform
操作プロセスの説明: 真空吸盤が三角形を吸い込みます。
四角いブロック。次に、円を三角形の中に吸い込み、元の位置に戻します。
元の位置。
4.4:
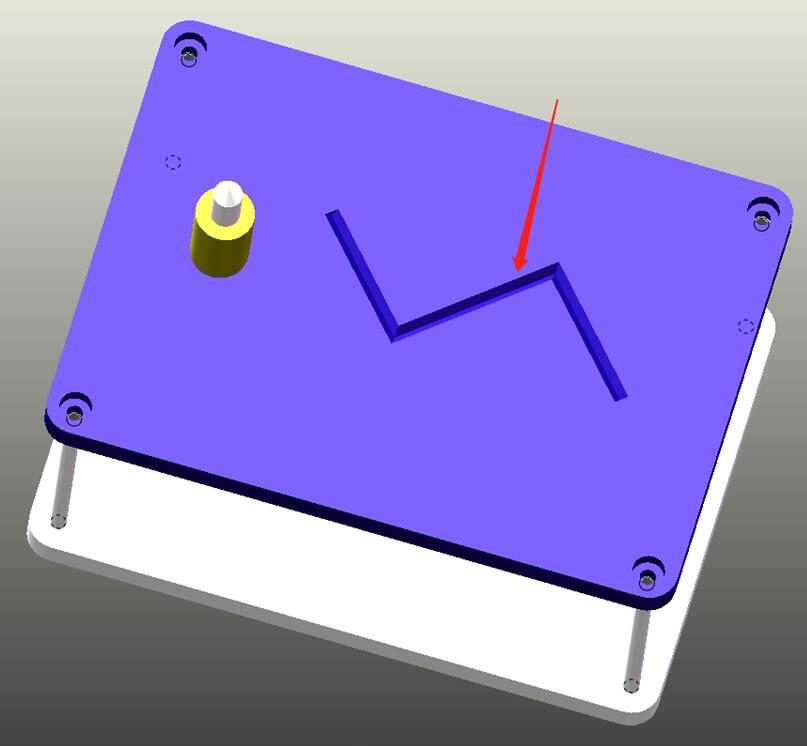
Needle and arc welding track simulation
動作フロー説明: マニピュレータがアーク溶接シミュレーションを移動します。
Z 字型の軌道へのコラム (レーザー ポインター)、およびマニピュレーター コントロール
軌道に沿って歩くコラム。
4.5:
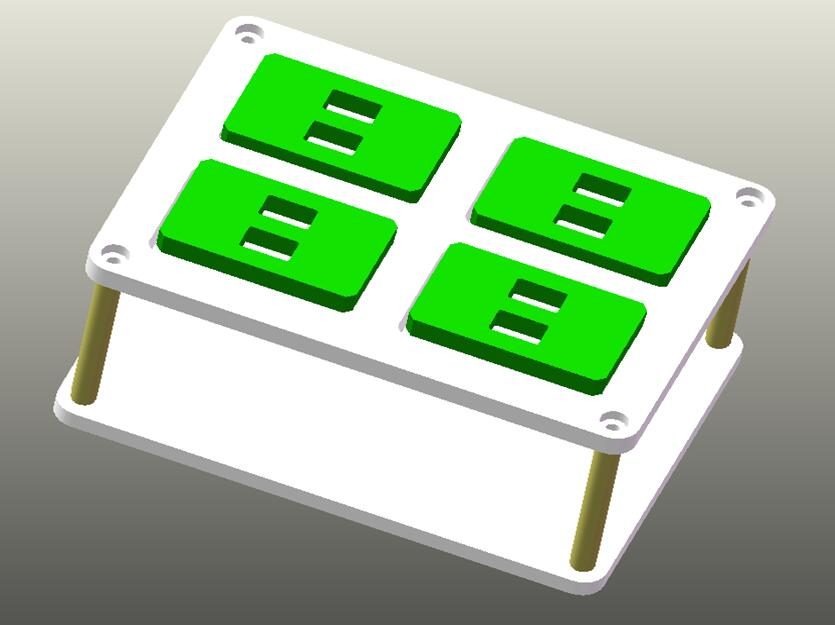
Cube gripping
動作フロー説明: ロボットが幅広シリンダーグリッパーを上部に移動
ブロックを下降させ、指定された位置にブロックをクランプします。
Fifth:
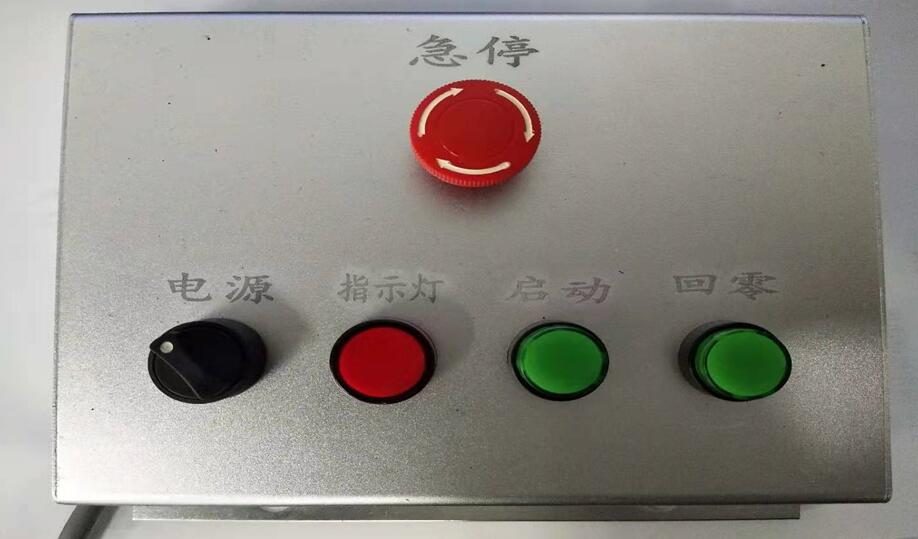
Button description
Emergency stop: Control the robot to stop (press it to stop, turn it on and
press the start button to continue following the program.) Power: Control the
robot power management. Start: Control the robot to move according to the
program. Zero return: control the robot to return to the programmed zero
position.
Sixth:
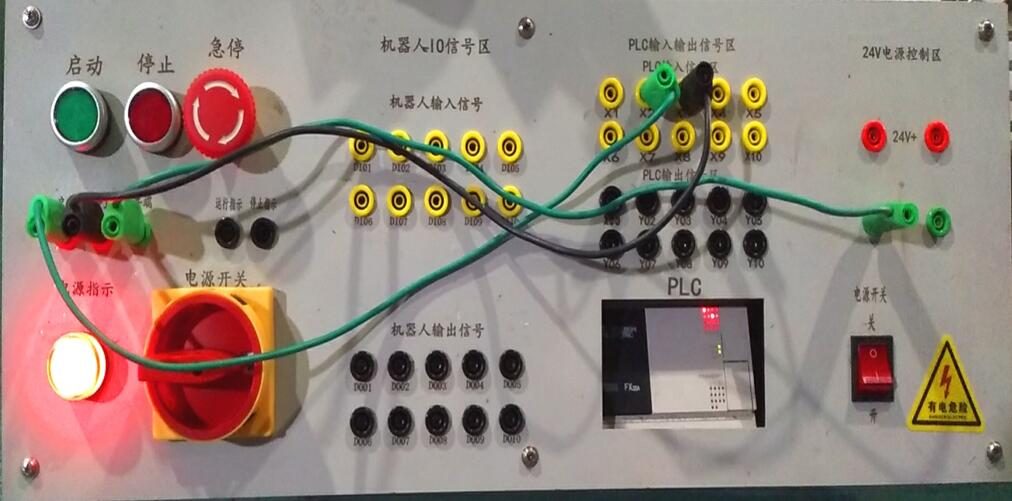
Description of control wiring board
Through this controller, the communication between the robot and the PLC can be
easily realized, and at the same time, the wiring method and skills can be
understood intuitively. Through the connection of various input points, the
construction of various settings can be quickly realized, which is convenient
for learning and safe.
Seventh:
Repair and maintenance
1: 装置を修理する前に、主電源を切ってください。
専門家以外は電源ボックスを開けないでください。
2: 作業面を掃除し、主電源と空気源を切ってください。
毎回の使用後に。
3: 装置を操作する前に、環境に注意してください。
安全上の事故を避けるために、ロボットの移動半径内に移動してください。
完全な技術データ
| モデル | TRE500S-TP |
|---|---|
| 軸 | 6軸 |
| カテゴリ | 教育ロボット |
| リードタイム | 15日 |
値は 20 °C における公称値です。 CAD モデル、トルク曲線、コントローラー I/O マップのデータシートをダウンロードしてください。
どこで実行されるか
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
購入者の質問
TRE500S-TPの主な仕様は何ですか?
軸:6軸。リクエストに応じて完全なデータシートを入手できます。
TRE500S-TPのリードタイムとMOQはどれくらいですか?
リードタイムは15日です。 MOQは5ユニットです。
TRE500S-TPの価格はいくらですか?
価格は構成ごとに見積もられており、該当する場合は工具や輸送費も含まれます。
TRE500S-TP の価格提案を受ける
パート、ターゲット レート、宛先ポートを含めます。チャットボットではなくエンジニアが 48 時間以内に返信します。
同じカテゴリ
TROY エンジニアリングによるレビュー ·。仕様は見積ごとにサプライヤーのデータシートと照合して再チェックされます。