



双腕ヒューマノイドロボット
TR-Mは調査・受付用の人型ロボットです。主な仕様: ペイロード 20 kg。 0.03mmに達します。公差±0.03mm。リードタイムは45日です。価格は構成ごとに見積もられます。認証: ご要望に応じて CE ドキュメントをご提供します。
- モデル
- TR-M
- ペイロード
- 20 kg
- 到着
- 0.03 mm
- 許容範囲
- ±0.03 mm
- カテゴリ
- AIとヒューマノイドロボット
- リードタイム
- 45日
このプラットフォームの目的
TROY 双腕ヒューマノイド ロボット: 14 DOF、MEMS 関節トルク センサーによる完全関節力制御、+/-0.03 mm の再現性、3 ~ 20 kg のペイロード オプション、5 カメラ ビジョン、NVIDIA Jetson Orin AGX 275 TOPS、ROS2。
商業条件
| 引用 | 構成ごとの価格 - 48 時間以内にご返信ください |
|---|---|
| リードタイム | 45日 |
| MOQ | 1台 |
| 起源 | 中国 |
| 積地港 | 深セン、中国 |
| インコタームズ | FOB 深セン / CIF (ご要望に応じて) |
| 支払い | 30% のデポジット、出荷前に 70% |
| 保証 | 標準は 24 か月、オプションは 36 か月 |
製品詳細
TROY エンジニアリング ファイルからのアプリケーション ノート、構造図、およびビデオ — 見積書に同梱される同じ文書。
AI Robot Introduction:
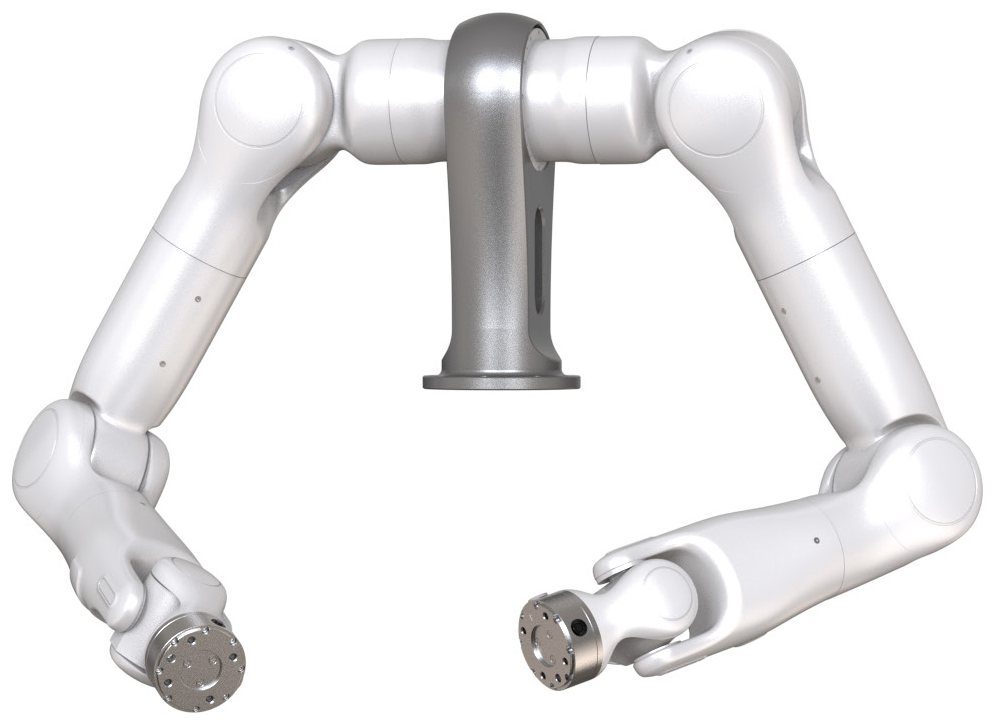
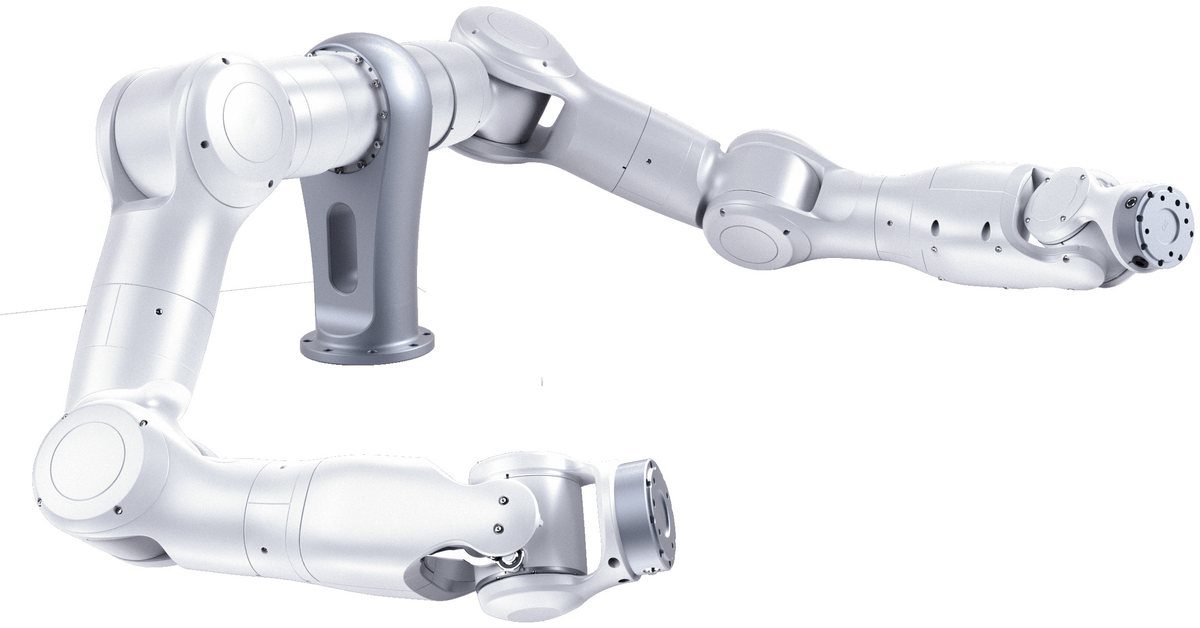
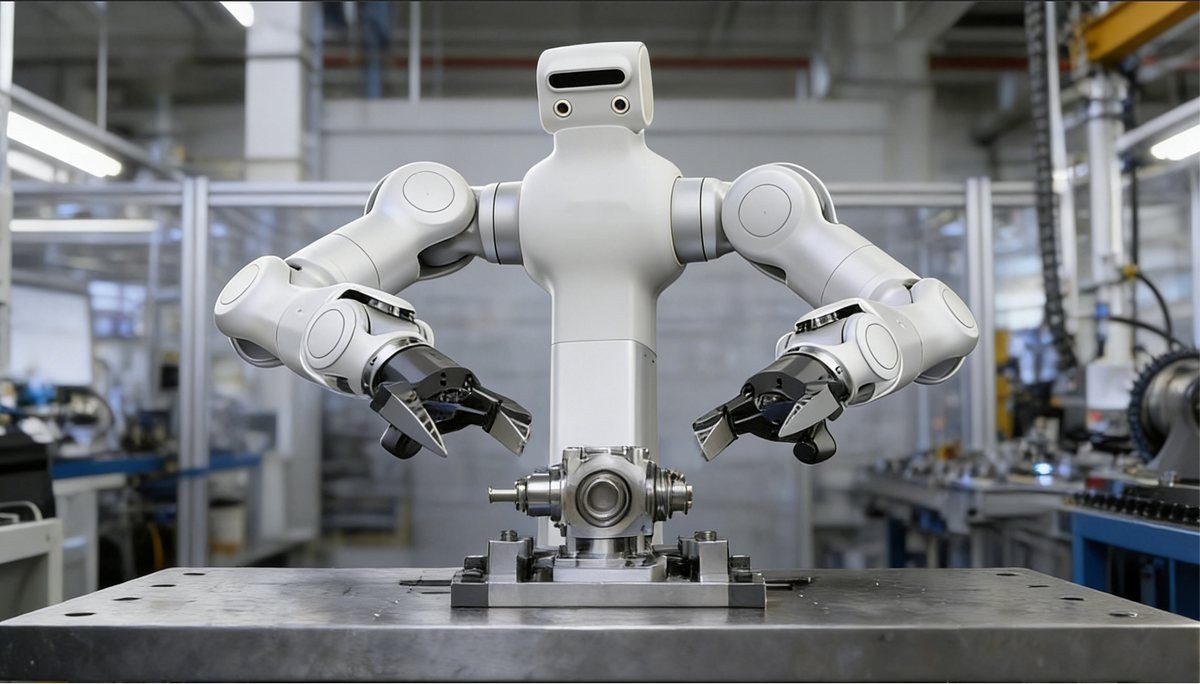
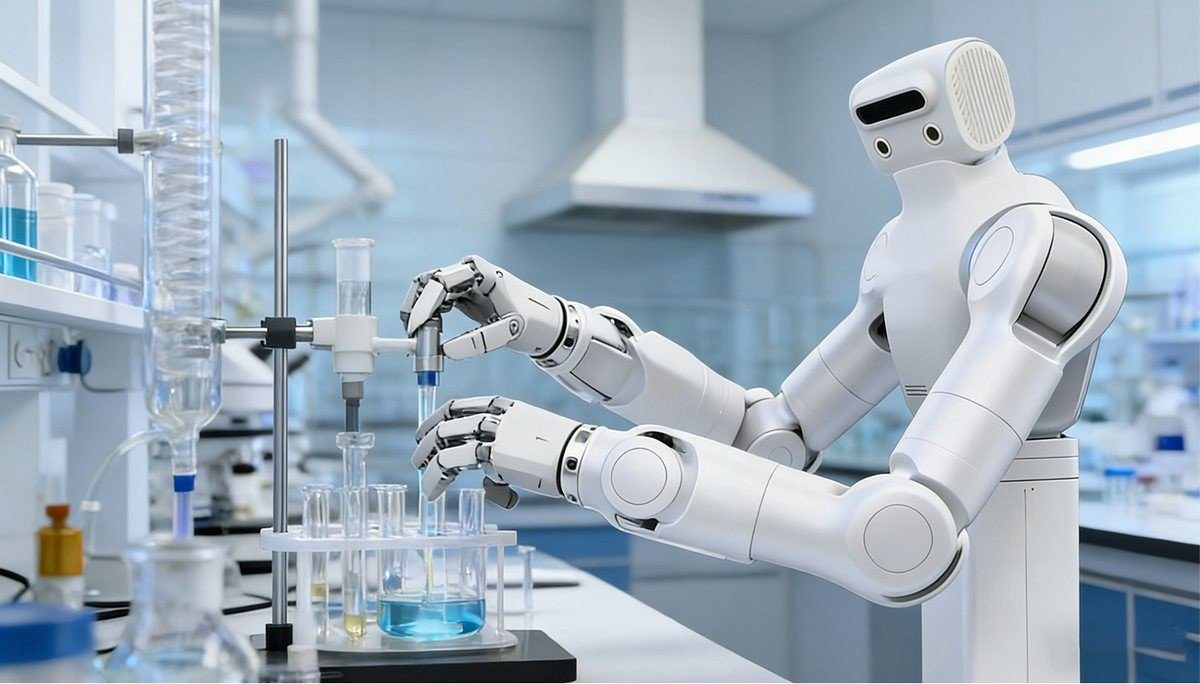
TROY Humanoid Robot is a fully force-controlled dual-arm humanoid robot platform designed for high-precision, fixed-station tasks in industry and research. A rigid stand replaces the conventional mobile chassis, trading mobility for uncompromising stability and accuracy — making the platform ideal for precision flexible assembly, laboratory automation, inspection, and embodied-intelligence research.
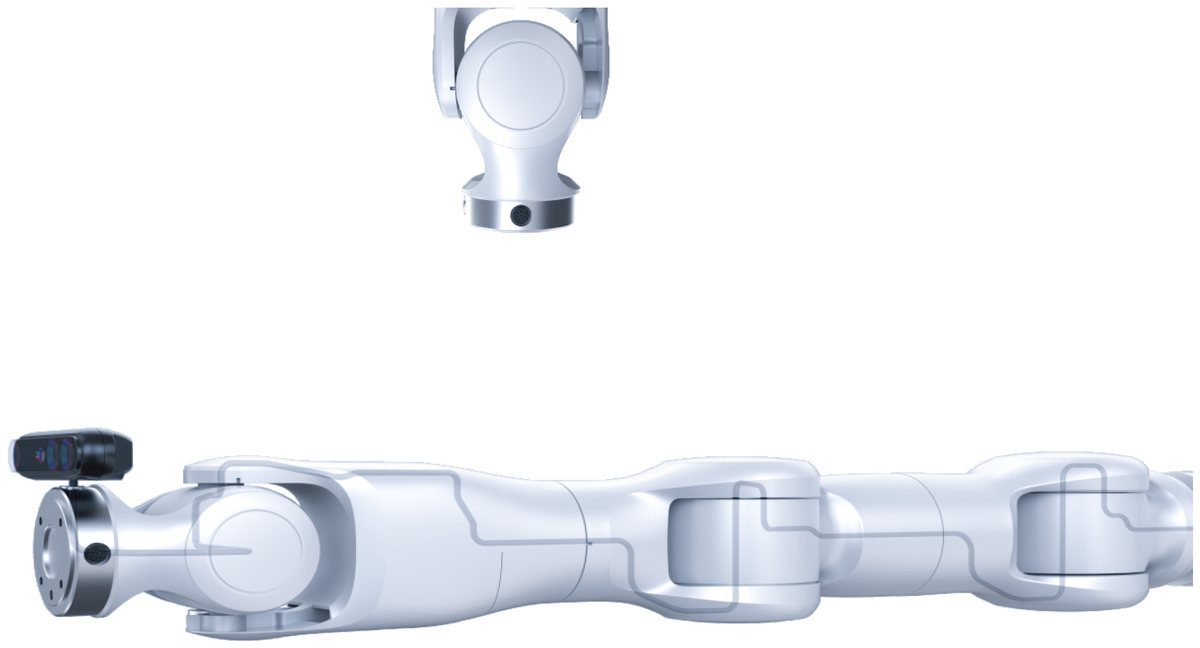
The robot features two 7-DOF arms (14 DOF in total) with joint torque sensors standard on every axis. Repeat positioning accuracy reaches ±0.03 mm and force-control accuracy is up to 0.15 N, with position, impedance and hybrid force-position control modes in the standard controller. Each arm uses an innovative crossed-axis wrist design that eliminates the degree-of-freedom degradation of traditional wrists, achieving biomechanical equivalence to the human wrist for more natural, human-like motion.
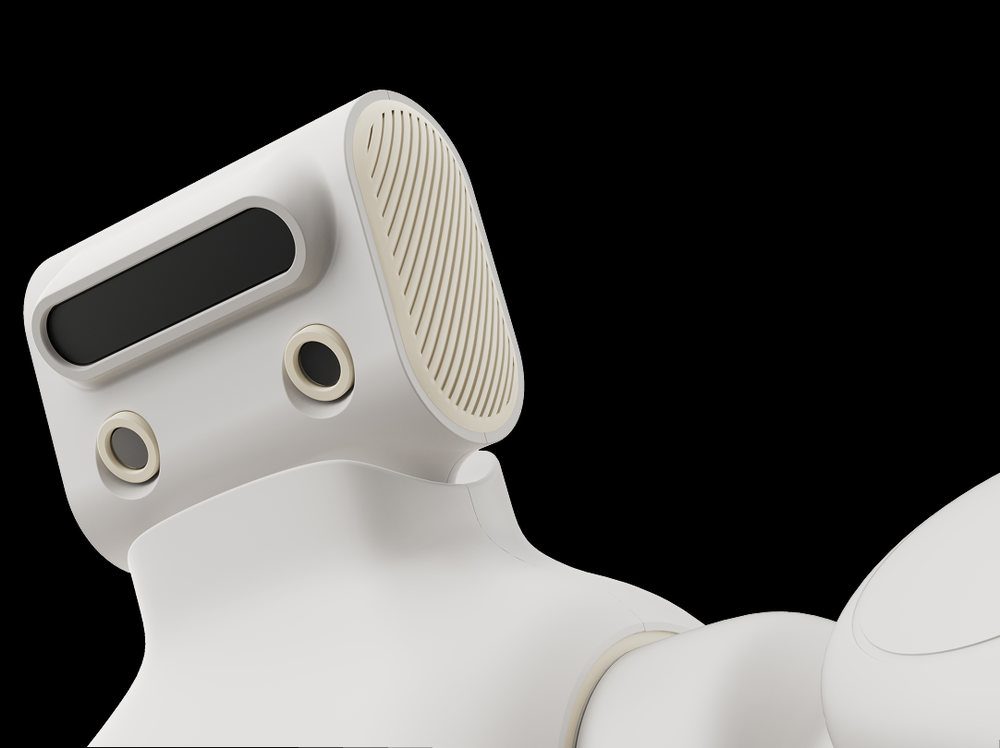
The platform ships fully equipped: a 5-camera panoramic vision system (head: 1× depth camera + 2× RGB cameras; wrists: 2× RGB cameras), an NVIDIA Jetson Orin AGX 64 GB (275 TOPS) computing platform and open ROS2 support — ready for vision-guided operation, data collection and secondary development out of the box. Eight arm models cover rated payloads from 3 kg to 20 kg and working reaches from 615 mm to 1050 mm, so a single controller, SDK and software ecosystem scales across applications.
Core Technology
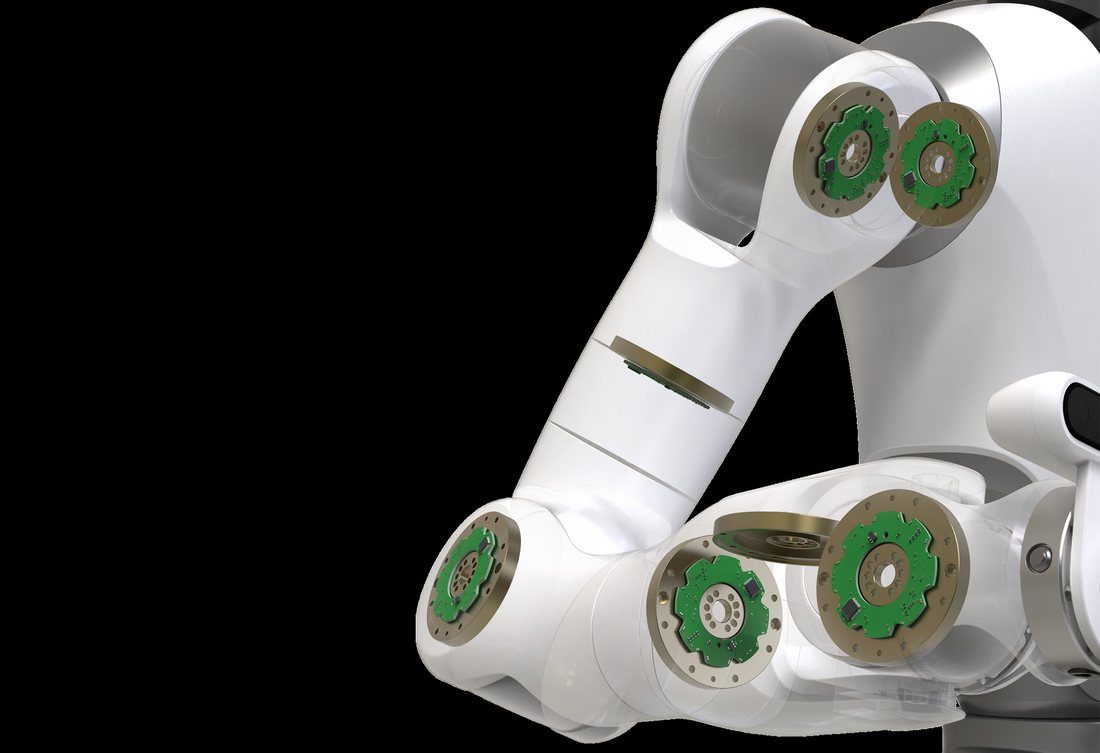
Joint Torque Sensor
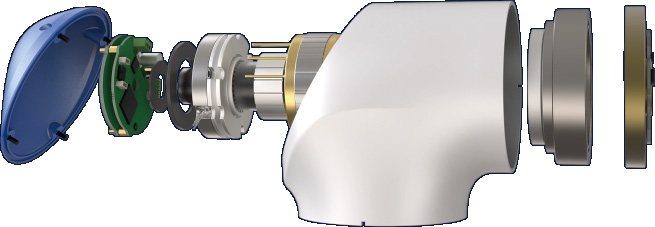
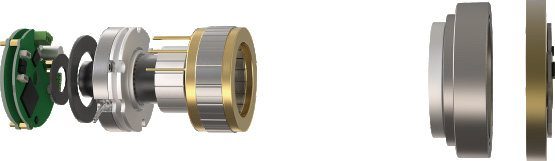
Self-developed joint torque sensors — among the first to integrate MEMS sensing technology into robotic arm joints. MEMS sensors deliver ultra-precise force detection (10× sensitivity); silicon micro-melting technology provides superior stability (4×); and a special steel structure design enhances rigidity and durability (2×).
Lightweight Integrated Joint Module
A modular design enables rapid and efficient arm assembly, and the lightweight structure makes it the lightest force-controlled module in its payload class. The built-in EtherCAT communication driver features four-loop control (position, velocity, torque and current loops) supporting 8 kHz torque closed-loop control directly on the driver. Integrated dual absolute encoders enable full closed-loop control with battery-free zero-point recording, while a built-in friction brake ensures no drift when powered off and no jitter when powered on.
Impedance Control & Dynamic Tracking
With full-body force control and impedance technology, the robot explores the world like a human. In human-robot interaction it exhibits natural compliance, reducing impact forces and enhancing comfort and safety; in unknown environments, impedance control helps the robot adapt to changes and minimizes oscillation and instability caused by external disturbance, improving task efficiency and reliability; in precision flexible assembly, it adjusts flexibly upon contact, preventing damage to the workpiece or to the robot itself.
Product Features
Humanoid Design & Dexterity
The 7-DOF symmetrical arms move as flexibly and naturally as human arms. The innovative crossed-axis wrist achieves biomechanical equivalence to the human wrist with a smaller rotation radius, making grasping and adjustment movements more natural and teleoperation smoother and more adaptable across diverse scenarios.
Safe & Compliant Interaction
すべてのジョイントには内蔵トルクセンサーが装備されており、ユーザーとその周囲を保護するソフトで安全な相互作用を保証します。フルジョイントフォースコントロールと衝突保護機能が両アームに標準装備されています。
Industrial-Grade Performance
革新的なコンプライアンス補償テクノロジーにより、絶対精度が大幅に向上します。産業グレードの精度と剛性を兼ね備えたこのロボットは、商業用途と産業用途の両方で優れたパフォーマンスを発揮します。
Standard 5-Camera Panoramic Vision
すべての構成には 5 台のパノラマ カメラが付属しており、死角はありません。このシステムは、環境認識、グローバルな位置特定、点群の取得、ターゲット認識、エンドエフェクターの精密な位置決め、ワークの検査、および操作の視覚的ガイダンスをカバーします。
Powerful Edge Computing
The robot's brain is built on an NVIDIA Jetson Orin AGX 64 GB platform delivering 275 TOPS, with a 12-core CPU (up to 2.2 GHz) and 1.3 GHz GPU — supporting high-precision vision processing, data collection, deep learning and motion-control algorithms. The open ROS2 framework is supported for plug-and-play, developer-friendly deployment.
Comprehensive SDK & Teleoperation
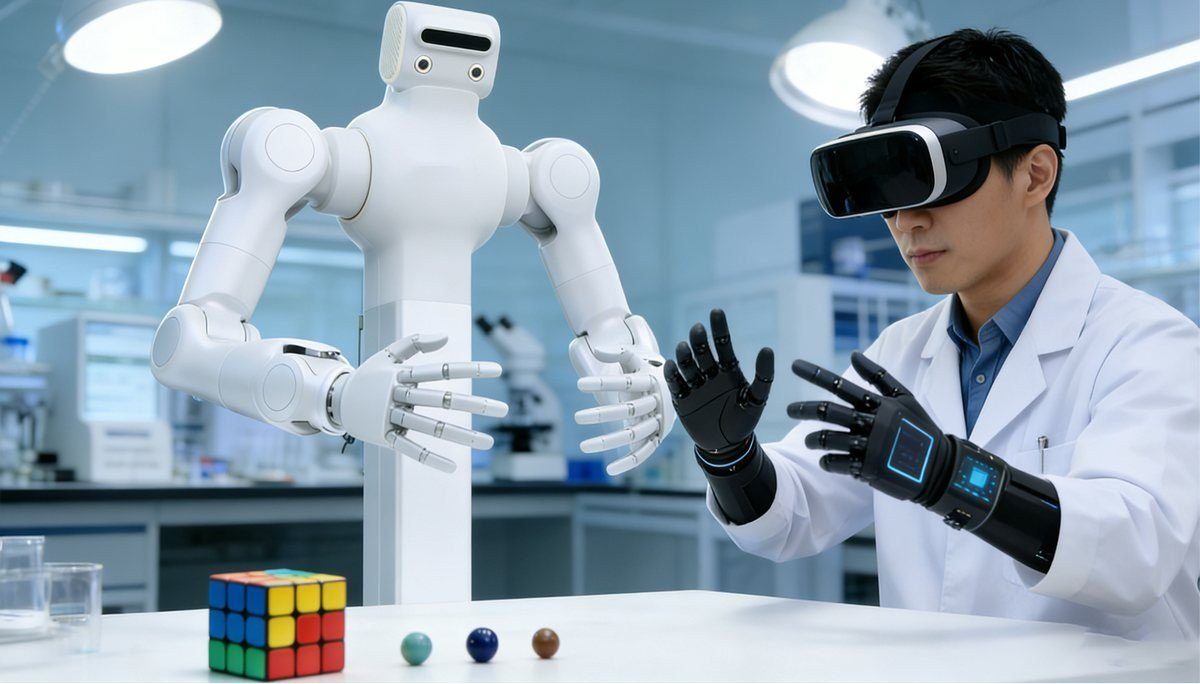
The SDK provides rich functionality, including real-time force-control and position-control interfaces with control frequencies up to 1 kHz, plus advanced algorithms such as dynamics, kinematics, impedance control, payload identification, hybrid force-position control, collision detection, drag-to-teach and dual-arm coordination. Secondary-development interfaces encapsulate complex arm functions into APIs with demo examples for typical applications. The dedicated teleoperation system offers 16 DOF, 500 Hz control and sampling frequency, ≤100 ms end-to-end latency, Ethernet/CAN-FD communication and HDF5/RLDS data formats — ideal for data collection and imitation learning.
Flexible Expansion & Integration
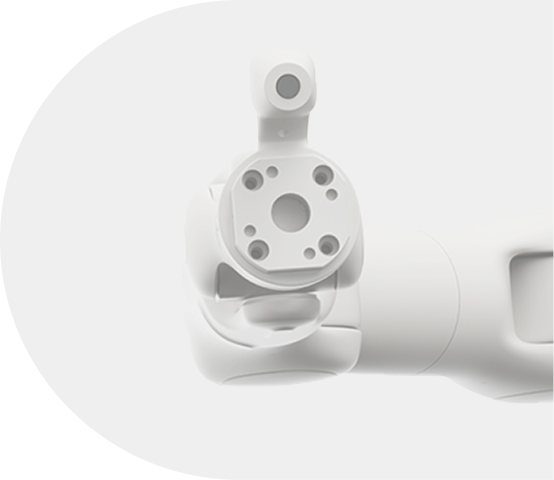
The dual-arm end effectors provide a wide range of communication interfaces (EtherCAT, CAN FD, RS485) plus high-current power output and an 8-pin end connector, making it easy to integrate dexterous hands, 6-axis force/torque sensors and various actuators. A large hollow structure allows internal routing of camera cables and quick integration of stereo-vision systems while avoiding cable damage from environmental contact, and the platform is compatible with various mobility platforms.
Power & Continuous Operation
主電源直接供給 (AC 220 V、海外の電圧に対応したアダプターが利用可能)、バッテリーモジュールなしで 24 時間連続稼働できるように設計されています。ロボットの重量は約 80 kg、垂直作業スペースは 0.6 ~ 1.8 m です。
アプリケーション
Precision flexible assembly, 3C electronics manufacturing, laboratory automation, scientific research and education (embodied intelligence and imitation-learning data collection), quality inspection and human-robot collaboration research.
Technical Specifications
Dual-Arm Robot — Standard Configuration
| モデル | TROY Humanoid Robot (M3 / M6 options) |
| 自由度 | 14 DOF (7 DOF × 2 arms) |
| 力制御 | Full-joint force control, standard; joint torque sensors on all axes |
| Rated payload (per arm) | 3 kg (M3) / 6 kg (M6) |
| Max payload (per arm) | 5 kg (M3) / 10 kg (M6) |
| Working reach (J2 to end flange) | 615 mm (M3) / 695 mm (M6) |
| 繰り返し位置決め精度 | ±0.03 mm |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Max joint speed | 180°/s |
| Control modes | Position control, impedance control, hybrid force-position control |
| Communication | 1 kHz EtherCAT |
| Braking | All joints with brakes |
| End-effector interface | RS485, CAN, EtherCAT |
| End 6-axis force/torque sensor | Optional |
| Dexterous hand | Optional |
| ベース | Fixed-height rigid stand (fixed-station platform, no mobile chassis) |
| Vertical working space | 0.6–1.8 m |
| Robot weight | Approx. 80 kg |
| ビジョンシステム | 5 cameras standard: head 1× D435 RGBD + 2× RGB; wrists 2× RGB (standard on all models) |
| Computing platform | NVIDIA Jetson Orin AGX 64 GB (275 TOPS); 12-core CPU up to 2.2 GHz; GPU 1.3 GHz |
| Framework | ROS2 supported |
| Teleoperation system | 16 DOF; position + impedance modes; 500 Hz control and sampling; ≤100 ms end-to-end latency; Ethernet / CAN-FD; 2560×720 @ 30 fps; HDF5, RLDS data formats |
| 電源 | AC 220 V direct supply (adapters for overseas voltages); no battery module |
| Continuous operation | 24 hours uninterrupted |
| Communication ports | WiFi, Ethernet |
Arm Model Range (per arm)
| Parameter | TR-M6S SRS-686 | TR-M6S CCS-696 | TR-M6S CCS-809 | TR-M3S Long CCS-920 | TR-M6S Lite CCS-615 | TR-M6S Lite CCS-680 | TR-M6S Lite CCS-750 | TR-M20S CCS-105 |
| Number of joints | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Rated payload | 6 kg | 6 kg | 5 kg | 3 kg | 5 kg | 4 kg | 3 kg | 20 kg |
| Wrist configuration | Traditional collaborative wrist | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis |
| Working reach | 686 mm | 696 mm | 809 mm | 920 mm | 615 mm | 680 mm | 751 mm | 1050 mm |
| Weight (per arm) | 11.45 kg | 12.45 kg | 12.7 kg | 13.1 kg | 8.45 kg | 8.65 kg | 8.8 kg | 30 kg |
| Max TCP speed | 2 m/s | 2 m/s | 2 m/s | 2 m/s | 1.5 m/s | 1.5 m/s | 1.5 m/s | 2 m/s |
| 再現性 | ±0.03 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.1 mm |
| IP等級 | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP65 |
| Brake control | All joints | All joints | All joints | All joints | J1–J4 | J1–J4 | J1–J4 | All joints |
| 消費電力 | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 1000 W avg / 3800 W peak |
| Max joint speed | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 120°/s |
Common Parameters & Certifications
| Joint torque sensors | Standard on all axes |
| Camera cable | Embeddable in end-effector |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Communication | EtherCAT, cycle ≤1 ms |
| Debugging software | PC-based setup & visualization software for 7 axes |
| Encoder | Dual absolute encoders |
| On-board interface (end-effector) | Drag-teach enabling button |
| On-board interface (power) | 24 VDC (rated current 3 A) |
| On-board interface (communication) | RS485, CAN FD, EtherCAT |
| 動作電圧 | 48 V (±10%) |
| Certifications | CE marking, ISO/TS 15066, ISO 13849-1 PLd (Cat. 3), EN 60204-1:2018, EN IEC 61000-6-2, EN IEC 61000-6-4, EN ISO 12100:2010 |
仕様は予告なく変更される場合があります。最新のデータシート、図面、構成オプションについては、当社の営業チームにお問い合わせください。
完全な技術データ
| モデル | TR-M |
|---|---|
| ペイロード | 20 kg |
| 到着 | 0.03 mm |
| 許容範囲 | ±0.03 mm |
| カテゴリ | AIとヒューマノイドロボット |
| リードタイム | 45日 |
値は 20 °C における公称値です。 CAD モデル、トルク曲線、コントローラー I/O マップのデータシートをダウンロードしてください。
どこで実行されるか
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
購入者の質問
主な仕様は何ですか?
型式:TR-M、可搬質量:20kg、リーチ:0.03mm。
リードタイムはどれくらいですか?
標準構成の場合は 45 日。引用時に確認されました。
カスタマイズできますか?
はい - OEM/ODM オプション、電圧、ツール、ブランドを適応させることができます。アプリケーションと提案のターゲット出力を送信します。
TR-M の価格提案を入手する
パート、ターゲット レート、宛先ポートを含めます。チャットボットではなくエンジニアが 48 時間以内に返信します。
同じカテゴリ


TROY エンジニアリングによるレビュー ·。仕様は見積ごとにサプライヤーのデータシートと照合して再チェックされます。