



डुअल-आर्म ह्यूमनॉइड रोबोट
टीआर-एम अनुसंधान/रिसेप्शन के लिए एक ह्यूमनॉइड रोबोट है। मुख्य विशिष्टताएँ: पेलोड 20 किग्रा; 0.03 मिमी तक पहुंचें; सहनशीलता ±0.03 मिमी. लीड समय 45 दिन है; मूल्य निर्धारण प्रति कॉन्फ़िगरेशन उद्धृत किया गया है। प्रमाणपत्र: अनुरोध पर सीई दस्तावेज़ीकरण।
- नमूना
- टीआर-एम
- पेलोड
- 20 kg
- पहुँचना
- 0.03 mm
- सहनशीलता
- ±0.03 mm
- वर्ग
- एआई और ह्यूमनॉइड रोबोट
- समय सीमा
- 45 दिन
यह प्लेटफार्म किस लिए है
ट्रॉय डुअल-आर्म ह्यूमनॉइड रोबोट: 14 डीओएफ, एमईएमएस ज्वाइंट टॉर्क सेंसर के साथ फुल-ज्वाइंट फोर्स कंट्रोल, +/-0.03 मिमी रिपीटेबिलिटी, 3-20 किलोग्राम पेलोड विकल्प, 5-कैमरा विजन, एनवीडिया जेटसन ओरिन एजीएक्स 275 टॉप्स, आरओएस2।
वाणिज्यिक शर्तें
| उद्धरण | प्रति कॉन्फ़िगरेशन मूल्य - 48 घंटों के भीतर उत्तर दें |
|---|---|
| समय सीमा | 45 दिन |
| MOQ | 1 इकाई |
| मूल | चीन |
| लोडिंग के बंदरगाह | शेनझेन, चीन |
| इन्कोटर्म | अनुरोध पर एफओबी शेन्ज़ेन/सीआईएफ |
| भुगतान | 30% जमा, 70% शिपमेंट से पहले |
| गारंटी | 24 महीने मानक, 36 महीने वैकल्पिक |
उत्पाद विवरण
TROY इंजीनियरिंग फ़ाइल से एप्लिकेशन नोट्स, निर्माण चित्र और वीडियो - वही दस्तावेज़ जो उद्धरण के साथ भेजा गया है।
AI Robot Introduction:
TROY Humanoid Robot is a fully force-controlled dual-arm humanoid robot platform designed for high-precision, fixed-station tasks in industry and research. A rigid stand replaces the conventional mobile chassis, trading mobility for uncompromising stability and accuracy — making the platform ideal for precision flexible assembly, laboratory automation, inspection, and embodied-intelligence research.
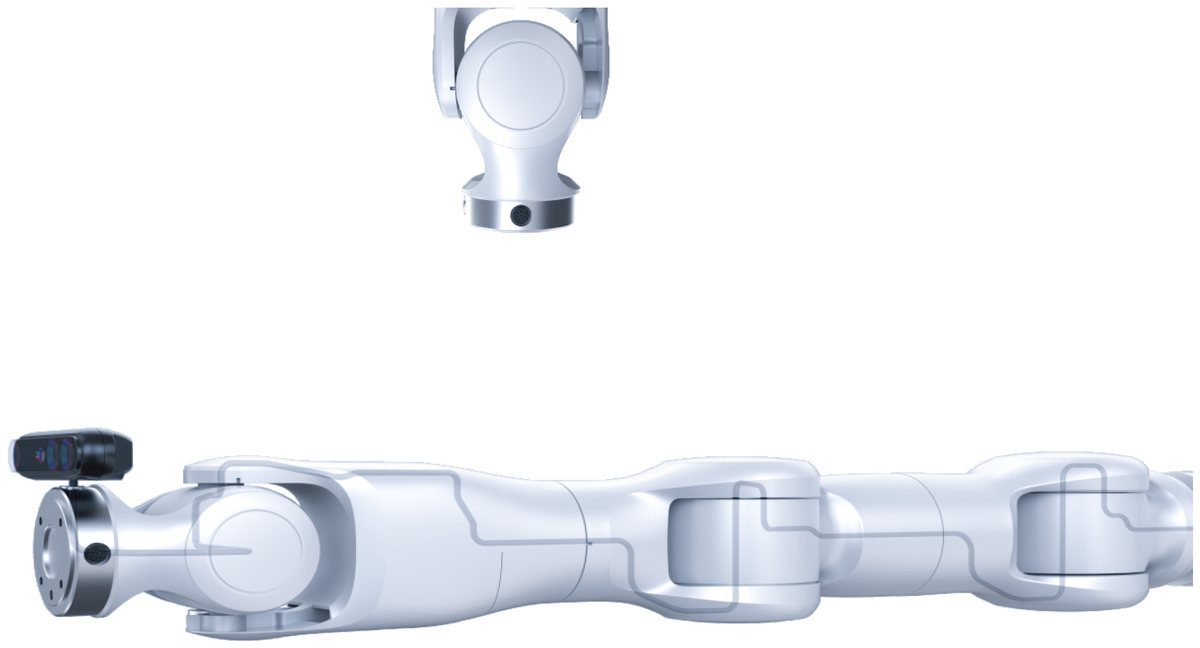
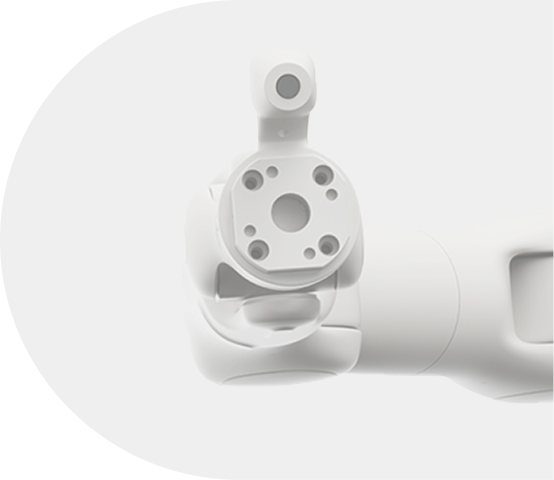
The robot features two 7-DOF arms (14 DOF in total) with joint torque sensors standard on every axis. Repeat positioning accuracy reaches ±0.03 mm and force-control accuracy is up to 0.15 N, with position, impedance and hybrid force-position control modes in the standard controller. Each arm uses an innovative crossed-axis wrist design that eliminates the degree-of-freedom degradation of traditional wrists, achieving biomechanical equivalence to the human wrist for more natural, human-like motion.
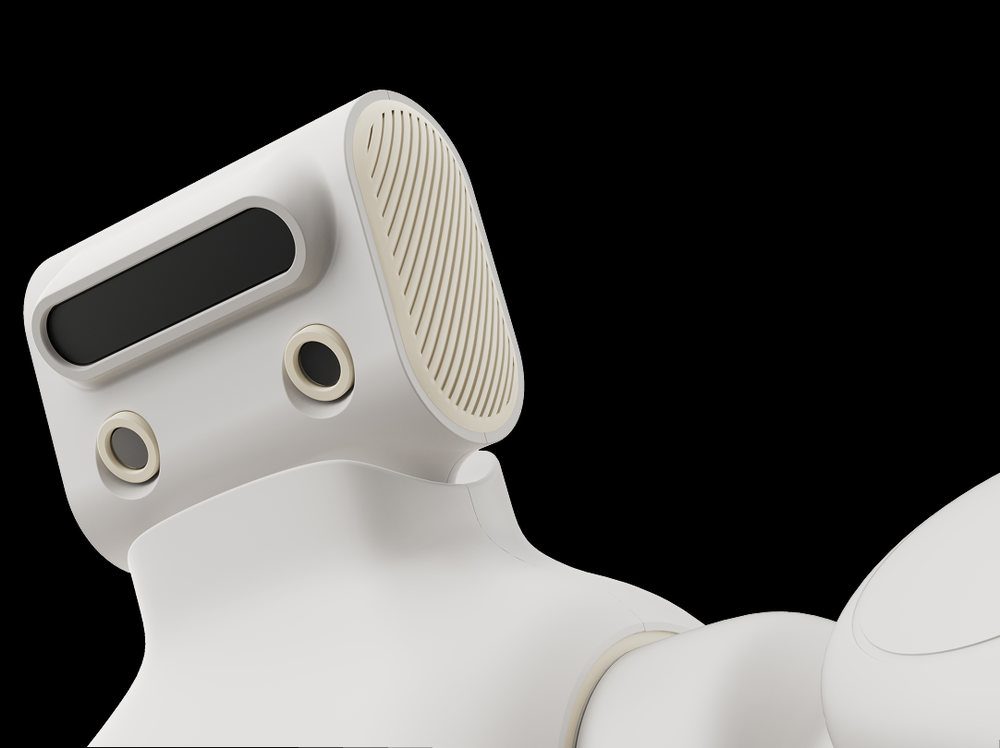
The platform ships fully equipped: a 5-camera panoramic vision system (head: 1× depth camera + 2× RGB cameras; wrists: 2× RGB cameras), an NVIDIA Jetson Orin AGX 64 GB (275 TOPS) computing platform and open ROS2 support — ready for vision-guided operation, data collection and secondary development out of the box. Eight arm models cover rated payloads from 3 kg to 20 kg and working reaches from 615 mm to 1050 mm, so a single controller, SDK and software ecosystem scales across applications.
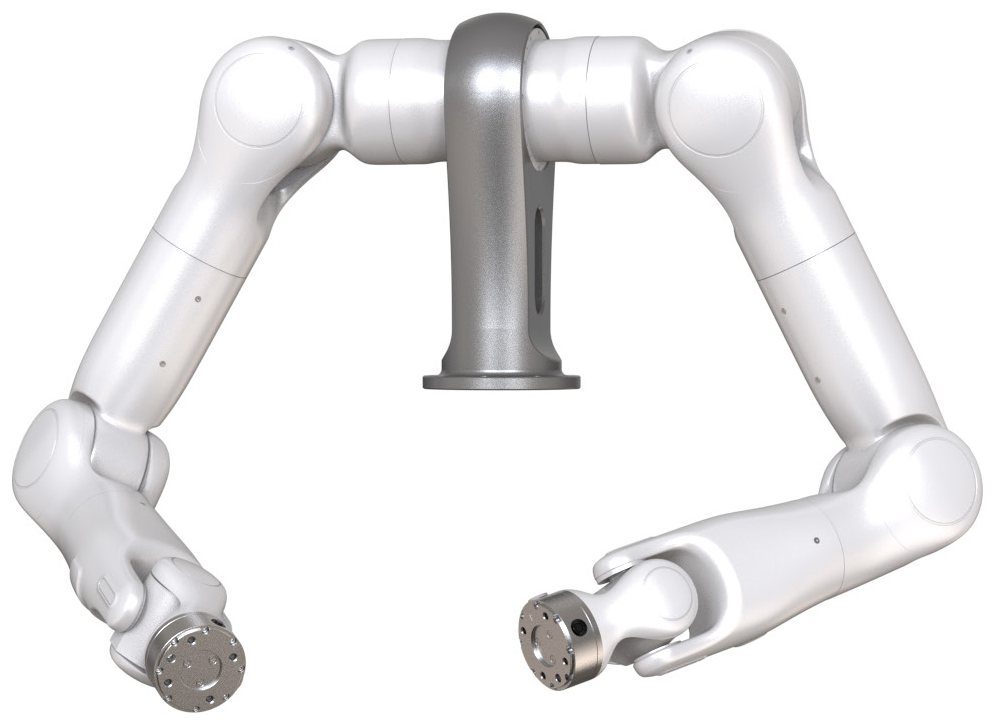
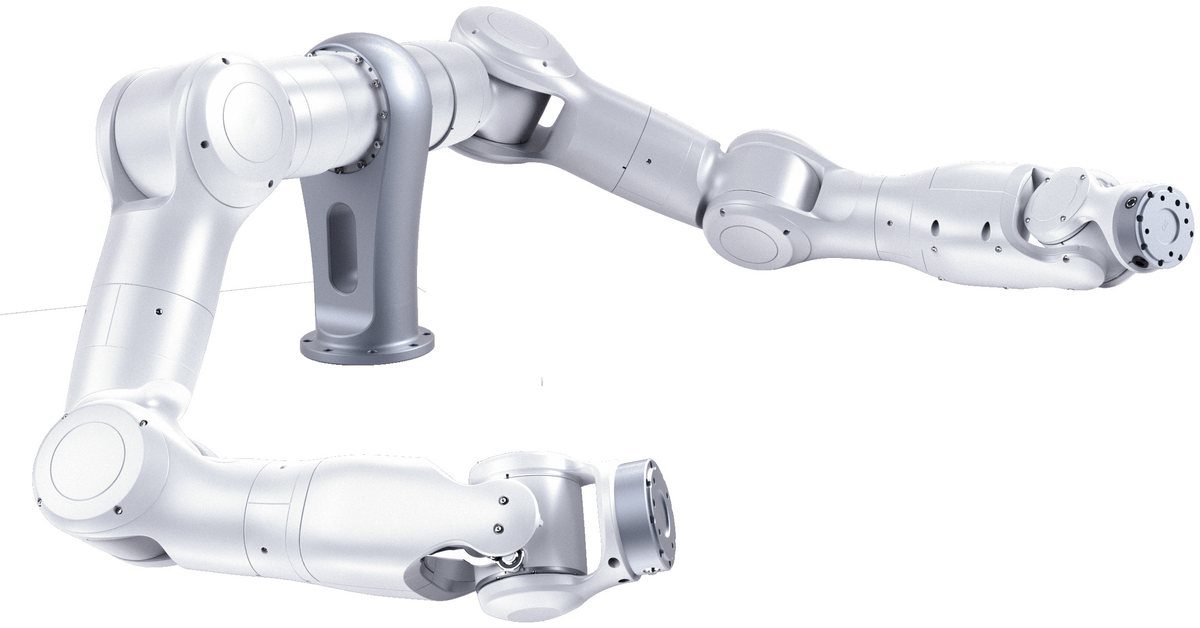
Core Technology
Joint Torque Sensor
Self-developed joint torque sensors — among the first to integrate MEMS sensing technology into robotic arm joints. MEMS sensors deliver ultra-precise force detection (10× sensitivity); silicon micro-melting technology provides superior stability (4×); and a special steel structure design enhances rigidity and durability (2×).
Lightweight Integrated Joint Module
A modular design enables rapid and efficient arm assembly, and the lightweight structure makes it the lightest force-controlled module in its payload class. The built-in EtherCAT communication driver features four-loop control (position, velocity, torque and current loops) supporting 8 kHz torque closed-loop control directly on the driver. Integrated dual absolute encoders enable full closed-loop control with battery-free zero-point recording, while a built-in friction brake ensures no drift when powered off and no jitter when powered on.
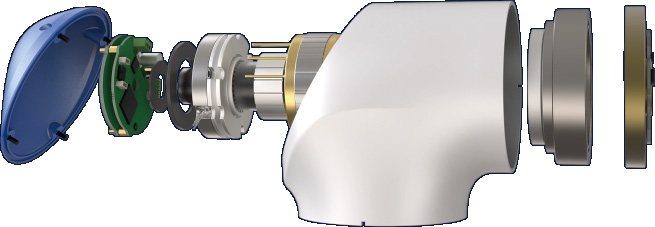
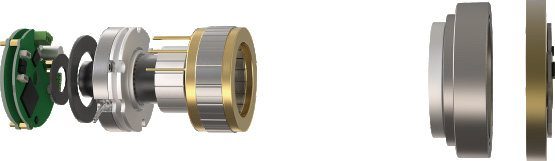
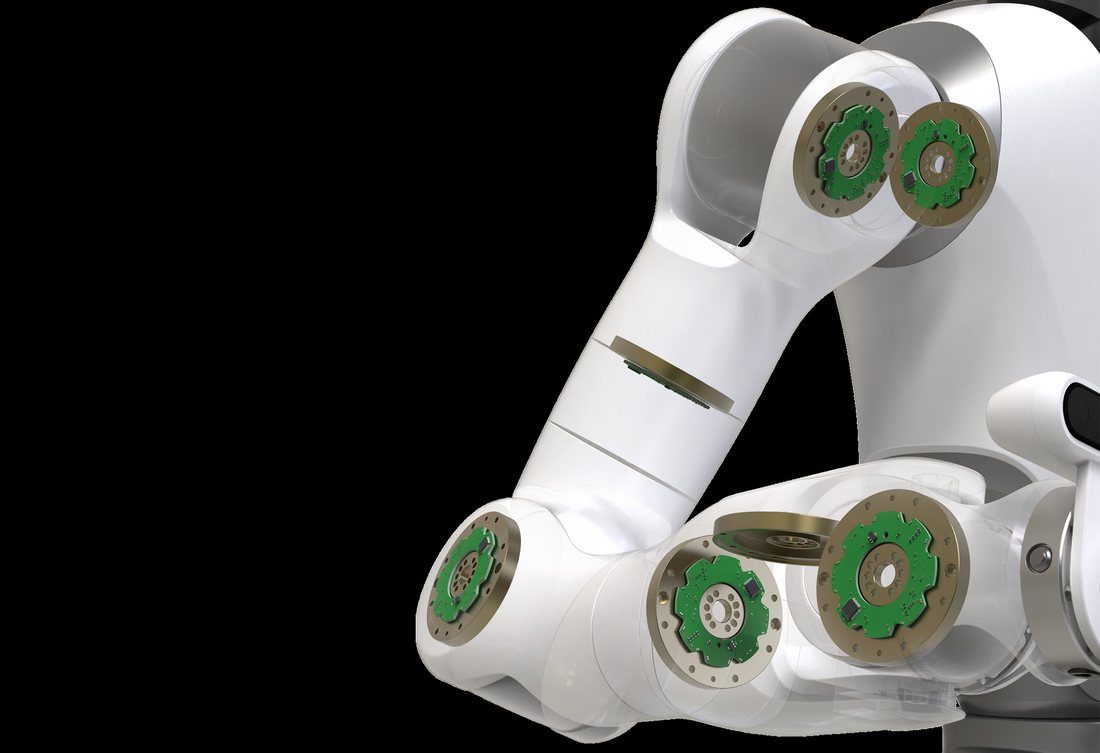
Impedance Control & Dynamic Tracking
With full-body force control and impedance technology, the robot explores the world like a human. In human-robot interaction it exhibits natural compliance, reducing impact forces and enhancing comfort and safety; in unknown environments, impedance control helps the robot adapt to changes and minimizes oscillation and instability caused by external disturbance, improving task efficiency and reliability; in precision flexible assembly, it adjusts flexibly upon contact, preventing damage to the workpiece or to the robot itself.
Product Features
Humanoid Design & Dexterity
The 7-DOF symmetrical arms move as flexibly and naturally as human arms. The innovative crossed-axis wrist achieves biomechanical equivalence to the human wrist with a smaller rotation radius, making grasping and adjustment movements more natural and teleoperation smoother and more adaptable across diverse scenarios.
Safe & Compliant Interaction
प्रत्येक जोड़ एक अंतर्निर्मित टॉर्क सेंसर से सुसज्जित है, जो नरम और सुरक्षित इंटरैक्शन सुनिश्चित करता है जो उपयोगकर्ताओं और उनके आसपास की सुरक्षा करता है। पूर्ण-संयुक्त बल नियंत्रण और टकराव सुरक्षा दोनों भुजाओं पर मानक हैं।
Industrial-Grade Performance
नवोन्मेषी अनुपालन क्षतिपूर्ति तकनीक पूर्ण सटीकता को महत्वपूर्ण रूप से बढ़ाती है। औद्योगिक-ग्रेड परिशुद्धता और कठोरता के साथ, रोबोट वाणिज्यिक और औद्योगिक दोनों अनुप्रयोगों में उत्कृष्ट प्रदर्शन प्रदान करता है।
Standard 5-Camera Panoramic Vision
सभी कॉन्फ़िगरेशन पाँच पैनोरमिक कैमरों के साथ आते हैं - कोई ब्लाइंड स्पॉट नहीं। प्रणाली पर्यावरणीय धारणा, वैश्विक स्थानीयकरण, बिंदु-क्लाउड अधिग्रहण, लक्ष्य पहचान, अंतिम-प्रभावक ठीक स्थिति, वर्कपीस निरीक्षण और संचालन के दृश्य मार्गदर्शन को कवर करती है।
Powerful Edge Computing
The robot's brain is built on an NVIDIA Jetson Orin AGX 64 GB platform delivering 275 TOPS, with a 12-core CPU (up to 2.2 GHz) and 1.3 GHz GPU — supporting high-precision vision processing, data collection, deep learning and motion-control algorithms. The open ROS2 framework is supported for plug-and-play, developer-friendly deployment.
Comprehensive SDK & Teleoperation
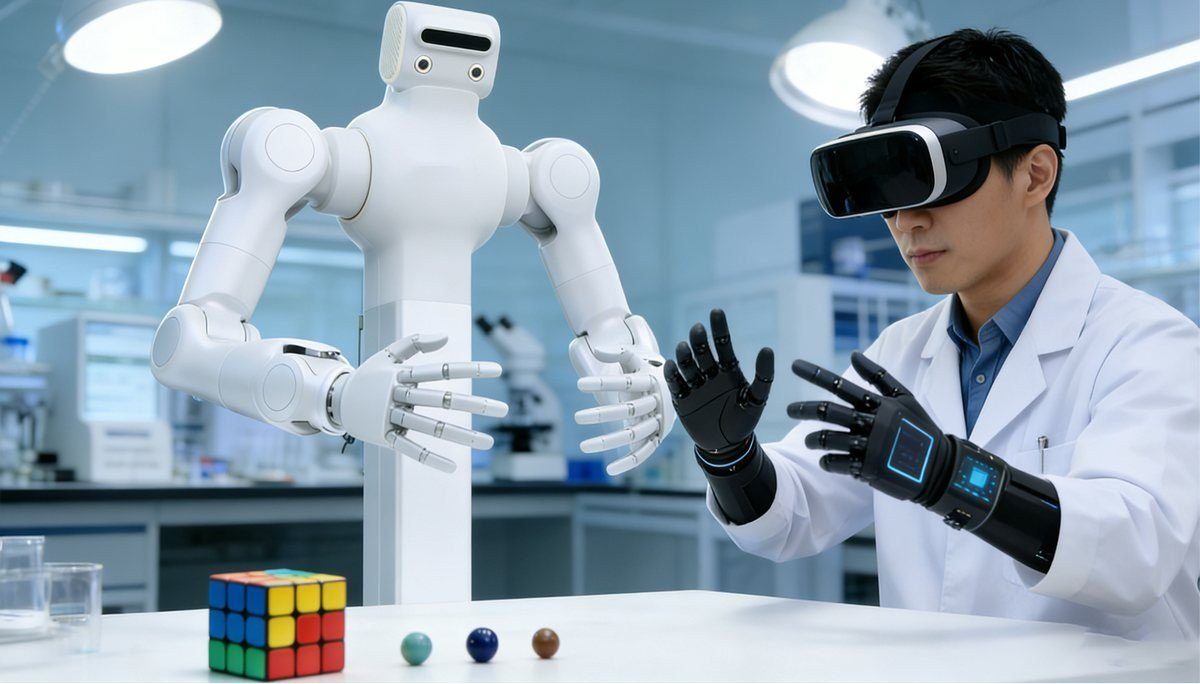
The SDK provides rich functionality, including real-time force-control and position-control interfaces with control frequencies up to 1 kHz, plus advanced algorithms such as dynamics, kinematics, impedance control, payload identification, hybrid force-position control, collision detection, drag-to-teach and dual-arm coordination. Secondary-development interfaces encapsulate complex arm functions into APIs with demo examples for typical applications. The dedicated teleoperation system offers 16 DOF, 500 Hz control and sampling frequency, ≤100 ms end-to-end latency, Ethernet/CAN-FD communication and HDF5/RLDS data formats — ideal for data collection and imitation learning.
Flexible Expansion & Integration
The dual-arm end effectors provide a wide range of communication interfaces (EtherCAT, CAN FD, RS485) plus high-current power output and an 8-pin end connector, making it easy to integrate dexterous hands, 6-axis force/torque sensors and various actuators. A large hollow structure allows internal routing of camera cables and quick integration of stereo-vision systems while avoiding cable damage from environmental contact, and the platform is compatible with various mobility platforms.
Power & Continuous Operation
मेन डायरेक्ट सप्लाई (एसी 220 वी; विदेशी वोल्टेज के लिए एडेप्टर उपलब्ध), बिना बैटरी मॉड्यूल के 24 घंटे निर्बाध संचालन के लिए डिज़ाइन किया गया। 0.6-1.8 मीटर के ऊर्ध्वाधर कार्य स्थान के साथ रोबोट का वजन लगभग 80 किलोग्राम है।
अनुप्रयोग
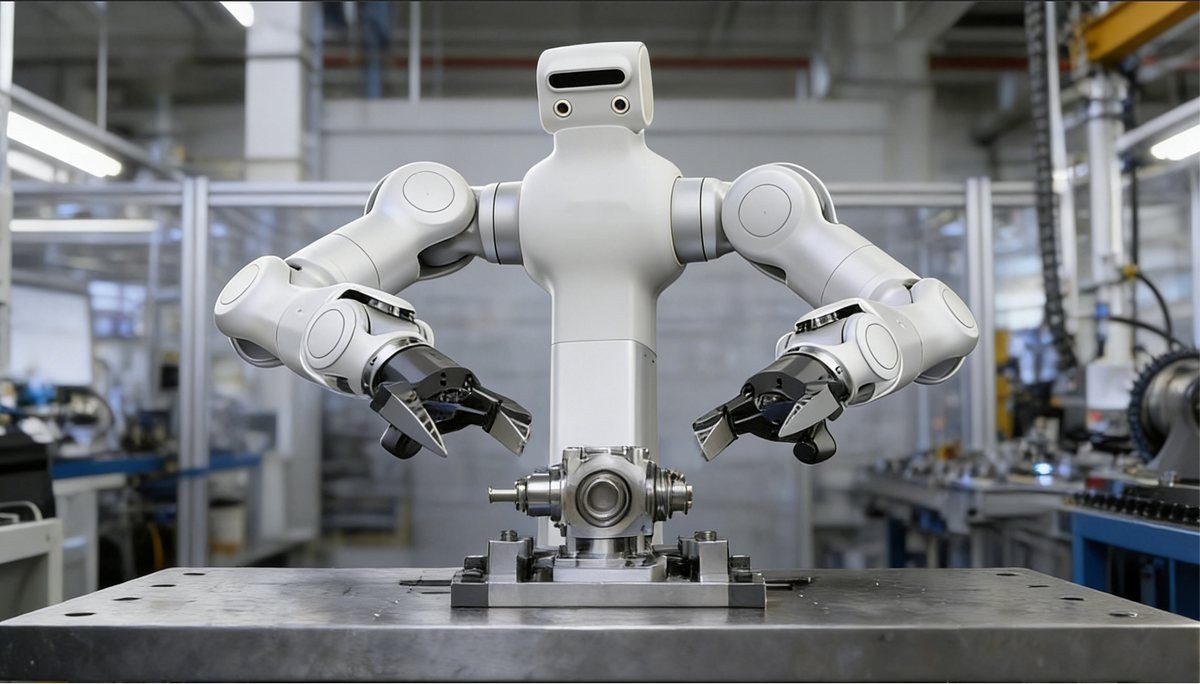
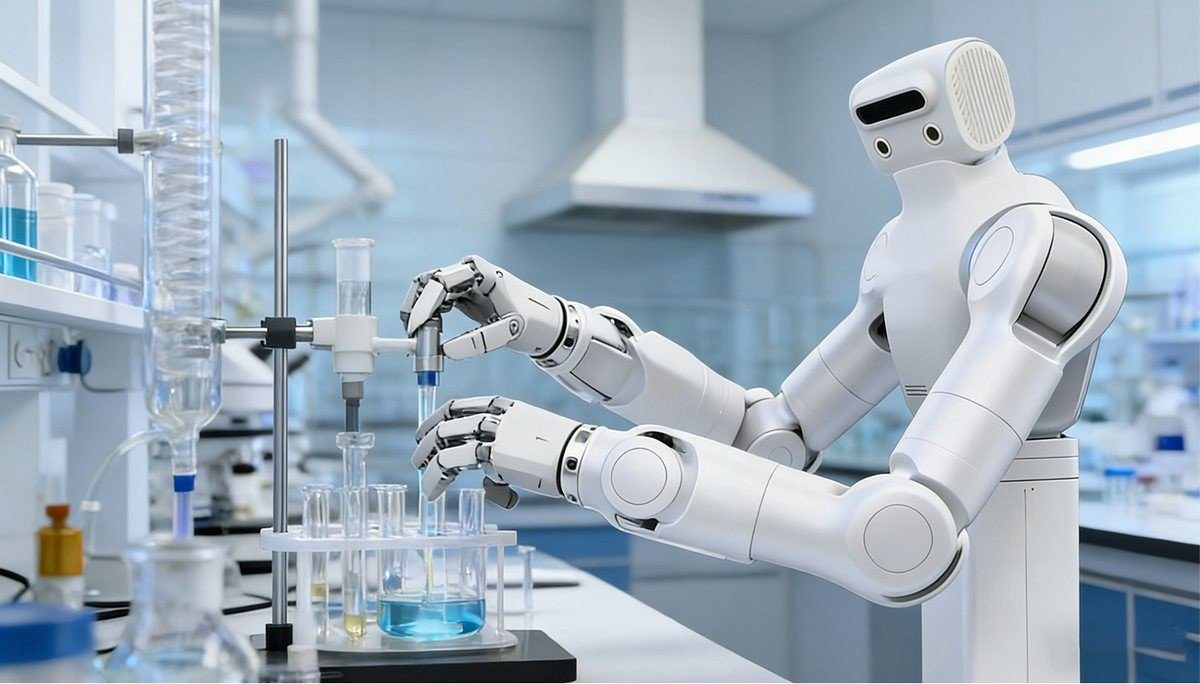
Precision flexible assembly, 3C electronics manufacturing, laboratory automation, scientific research and education (embodied intelligence and imitation-learning data collection), quality inspection and human-robot collaboration research.
Technical Specifications
Dual-Arm Robot — Standard Configuration
| नमूना | TROY Humanoid Robot (M3 / M6 options) |
| स्वतंत्रता की कोटियां | 14 DOF (7 DOF × 2 arms) |
| बलपूर्वक नियंत्रण | Full-joint force control, standard; joint torque sensors on all axes |
| Rated payload (per arm) | 3 kg (M3) / 6 kg (M6) |
| Max payload (per arm) | 5 kg (M3) / 10 kg (M6) |
| Working reach (J2 to end flange) | 615 mm (M3) / 695 mm (M6) |
| स्थिति निर्धारण सटीकता दोहराएँ | ±0.03 mm |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Max joint speed | 180°/s |
| Control modes | Position control, impedance control, hybrid force-position control |
| Communication | 1 kHz EtherCAT |
| Braking | All joints with brakes |
| End-effector interface | RS485, CAN, EtherCAT |
| End 6-axis force/torque sensor | Optional |
| Dexterous hand | Optional |
| आधार | Fixed-height rigid stand (fixed-station platform, no mobile chassis) |
| Vertical working space | 0.6–1.8 m |
| Robot weight | Approx. 80 kg |
| दृष्टि प्रणाली | 5 cameras standard: head 1× D435 RGBD + 2× RGB; wrists 2× RGB (standard on all models) |
| Computing platform | NVIDIA Jetson Orin AGX 64 GB (275 TOPS); 12-core CPU up to 2.2 GHz; GPU 1.3 GHz |
| Framework | ROS2 supported |
| Teleoperation system | 16 DOF; position + impedance modes; 500 Hz control and sampling; ≤100 ms end-to-end latency; Ethernet / CAN-FD; 2560×720 @ 30 fps; HDF5, RLDS data formats |
| बिजली की आपूर्ति | AC 220 V direct supply (adapters for overseas voltages); no battery module |
| Continuous operation | 24 hours uninterrupted |
| Communication ports | WiFi, Ethernet |
Arm Model Range (per arm)
| Parameter | TR-M6S SRS-686 | TR-M6S CCS-696 | TR-M6S CCS-809 | TR-M3S Long CCS-920 | TR-M6S Lite CCS-615 | TR-M6S Lite CCS-680 | TR-M6S Lite CCS-750 | TR-M20S CCS-105 |
| Number of joints | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Rated payload | 6 kg | 6 kg | 5 kg | 3 kg | 5 kg | 4 kg | 3 kg | 20 kg |
| Wrist configuration | Traditional collaborative wrist | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis |
| Working reach | 686 mm | 696 mm | 809 mm | 920 mm | 615 mm | 680 mm | 751 mm | 1050 mm |
| Weight (per arm) | 11.45 kg | 12.45 kg | 12.7 kg | 13.1 kg | 8.45 kg | 8.65 kg | 8.8 kg | 30 kg |
| Max TCP speed | 2 m/s | 2 m/s | 2 m/s | 2 m/s | 1.5 m/s | 1.5 m/s | 1.5 m/s | 2 m/s |
| repeatability | ±0.03 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.1 mm |
| आईपी रेटिंग | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP65 |
| Brake control | All joints | All joints | All joints | All joints | J1–J4 | J1–J4 | J1–J4 | All joints |
| बिजली की खपत | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 1000 W avg / 3800 W peak |
| Max joint speed | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 120°/s |
Common Parameters & Certifications
| Joint torque sensors | Standard on all axes |
| Camera cable | Embeddable in end-effector |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Communication | EtherCAT, cycle ≤1 ms |
| Debugging software | PC-based setup & visualization software for 7 axes |
| Encoder | Dual absolute encoders |
| On-board interface (end-effector) | Drag-teach enabling button |
| On-board interface (power) | 24 VDC (rated current 3 A) |
| On-board interface (communication) | RS485, CAN FD, EtherCAT |
| ऑपरेटिंग वोल्टेज | 48 V (±10%) |
| Certifications | CE marking, ISO/TS 15066, ISO 13849-1 PLd (Cat. 3), EN 60204-1:2018, EN IEC 61000-6-2, EN IEC 61000-6-4, EN ISO 12100:2010 |
विनिर्देश बिना सूचना के परिवर्तित किए जाने की विषय - वस्तु है। नवीनतम डेटाशीट, ड्राइंग और कॉन्फ़िगरेशन विकल्पों के लिए कृपया हमारी बिक्री टीम से संपर्क करें।
पूर्ण तकनीकी डेटा
| नमूना | टीआर-एम |
|---|---|
| पेलोड | 20 kg |
| पहुँचना | 0.03 mm |
| सहनशीलता | ±0.03 mm |
| वर्ग | एआई और ह्यूमनॉइड रोबोट |
| समय सीमा | 45 दिन |
मान 20 डिग्री सेल्सियस पर नाममात्र हैं। कैड मॉडल, टॉर्क कर्व्स और कंट्रोलर I/O मैप्स के लिए डेटाशीट डाउनलोड करें।
यह कहां चलता है
TROY इंजीनियरों द्वारा आकार और कमीशन किया गया।
TROY इंजीनियरों द्वारा आकार और कमीशन किया गया।
TROY इंजीनियरों द्वारा आकार और कमीशन किया गया।
TROY इंजीनियरों द्वारा आकार और कमीशन किया गया।
क्रेता प्रश्न
प्रमुख विशिष्टताएँ क्या हैं?
मॉडल: टीआर-एम, पेलोड: 20 किलो, पहुंच: 0.03 मिमी।
लीड टाइम क्या है?
मानक विन्यास के लिए 45 दिन; उद्धरण पर पुष्टि की गई।
क्या इसे अनुकूलित किया जा सकता है?
हाँ - OEM/ODM विकल्प, वोल्टेज, टूलींग और ब्रांडिंग को अनुकूलित किया जा सकता है। प्रस्ताव के लिए आवेदन और लक्ष्य आउटपुट भेजें।
टीआर-एम के लिए एक मूल्य प्रस्ताव प्राप्त करें
भाग, लक्ष्य दर और गंतव्य पोर्ट शामिल करें। एक इंजीनियर - चैटबॉट नहीं - 48 घंटों के भीतर जवाब देता है।
वही श्रेणी

पहिएदार दोहरे हाथ वाला ह्यूमनॉइड रोबोट

बायोमिमेटिक पांडा सर्विस रोबोट
पहिएदार ह्यूमनॉइड रोबोट
TROY इंजीनियरिंग द्वारा समीक्षित ·. प्रत्येक कोटेशन पर आपूर्तिकर्ता डेटाशीट के विरुद्ध विशिष्टताओं की दोबारा जाँच की जाती है।