



Dvouruký humanoidní robot
TR-M je humanoidní robot pro výzkum / příjem. Klíčové specifikace: Užitečné zatížení 20 kg; dosah 0,03 mm; Tolerance ±0,03 mm. Dodací lhůta je 45 dní; cena je uvedena za konfiguraci. Certifikáty: CE dokumentace na vyžádání.
- Model
- TR-M
- Užitečné zatížení
- 20 kg
- Dosah
- 0.03 mm
- Tolerance
- ±0.03 mm
- Kategorie
- AI a humanoidní roboti
- Dodací lhůta
- 45 dní
K čemu je tato platforma
Dvouramenný humanoidní robot TROY: 14 DOF, plné ovládání síly kloubu se snímači točivého momentu kloubů MEMS, opakovatelnost +/-0,03 mm, možnosti užitečného zatížení 3–20 kg, vidění s 5 kamerami, NVIDIA Jetson Orin AGX 275 TOPS, ROS2.
Obchodní podmínky
| Citát | Cena za konfiguraci – odpověď do 48 hodin |
|---|---|
| Dodací lhůta | 45 dní |
| MOQ | 1 jednotka |
| Původ | Čína |
| Přístav nakládky | Shenzhen, Čína |
| Incoterm | FOB Shenzhen / CIF na vyžádání |
| Platba | 30% záloha, 70% před odesláním |
| Záruka | 24 měsíců standardně, 36 měsíců volitelně |
Podrobnosti o produktu
Poznámky k aplikaci, konstrukční výkresy a video z inženýrského souboru TROY — stejná dokumentace dodávaná s cenovou nabídkou.
AI Robot Introduction:
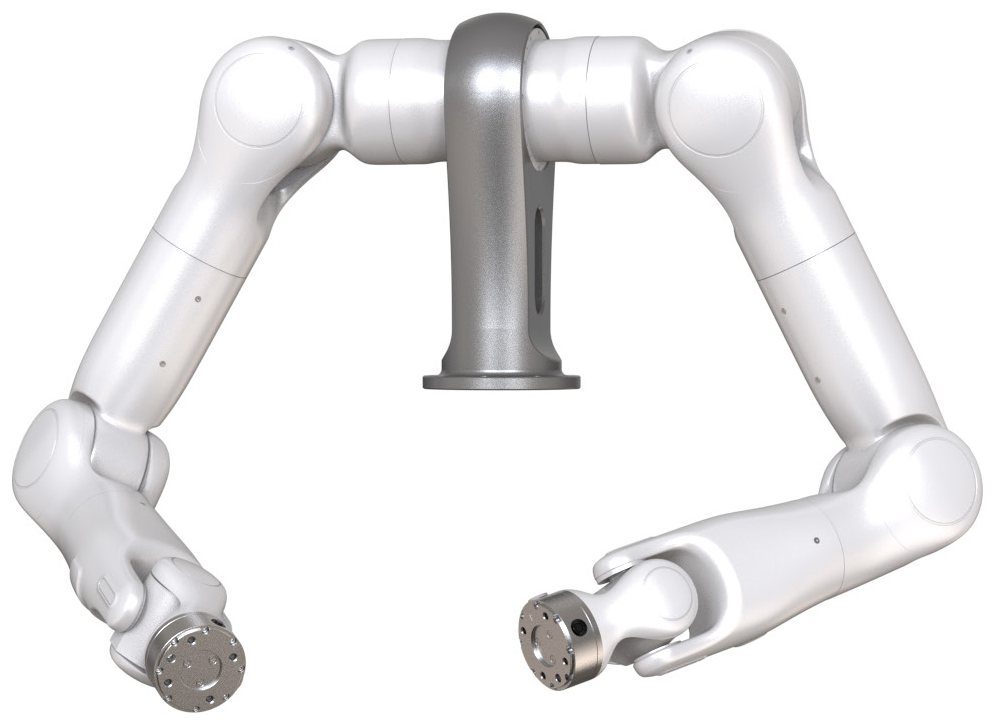
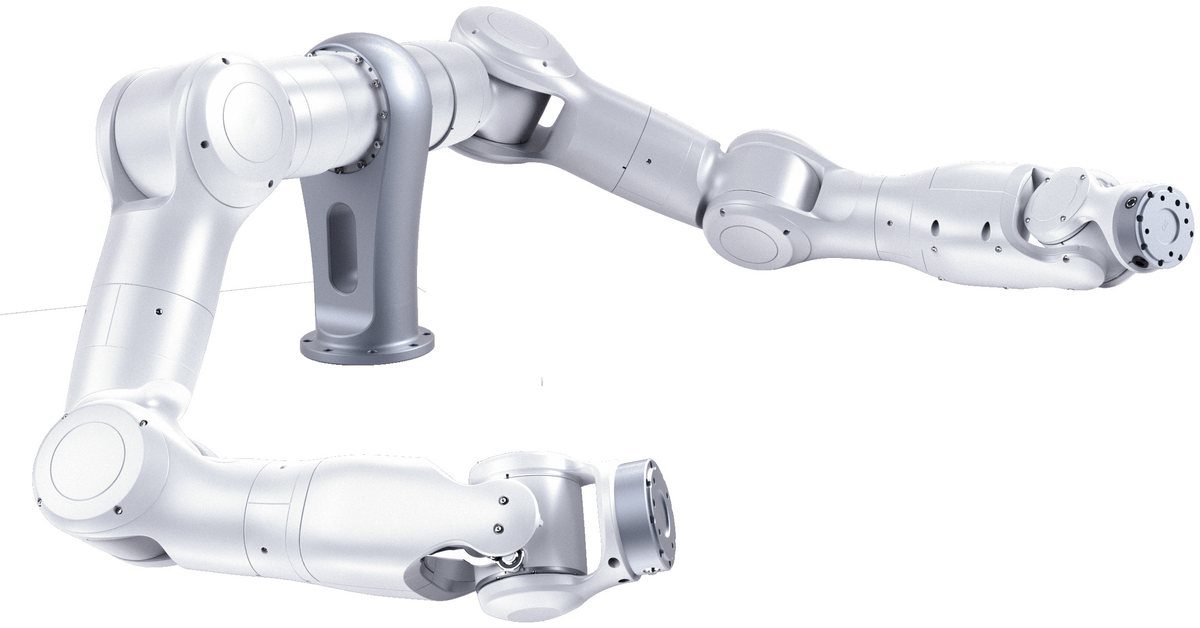
TROY Humanoid Robot is a fully force-controlled dual-arm humanoid robot platform designed for high-precision, fixed-station tasks in industry and research. A rigid stand replaces the conventional mobile chassis, trading mobility for uncompromising stability and accuracy — making the platform ideal for precision flexible assembly, laboratory automation, inspection, and embodied-intelligence research.
The robot features two 7-DOF arms (14 DOF in total) with joint torque sensors standard on every axis. Repeat positioning accuracy reaches ±0.03 mm and force-control accuracy is up to 0.15 N, with position, impedance and hybrid force-position control modes in the standard controller. Each arm uses an innovative crossed-axis wrist design that eliminates the degree-of-freedom degradation of traditional wrists, achieving biomechanical equivalence to the human wrist for more natural, human-like motion.
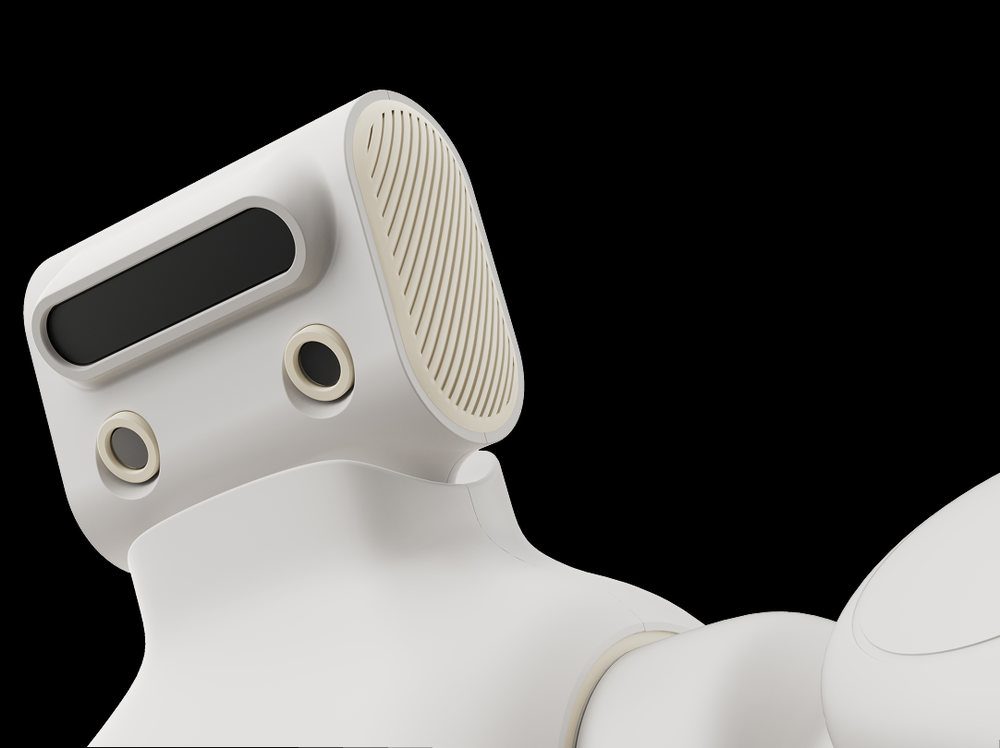
The platform ships fully equipped: a 5-camera panoramic vision system (head: 1× depth camera + 2× RGB cameras; wrists: 2× RGB cameras), an NVIDIA Jetson Orin AGX 64 GB (275 TOPS) computing platform and open ROS2 support — ready for vision-guided operation, data collection and secondary development out of the box. Eight arm models cover rated payloads from 3 kg to 20 kg and working reaches from 615 mm to 1050 mm, so a single controller, SDK and software ecosystem scales across applications.
Core Technology
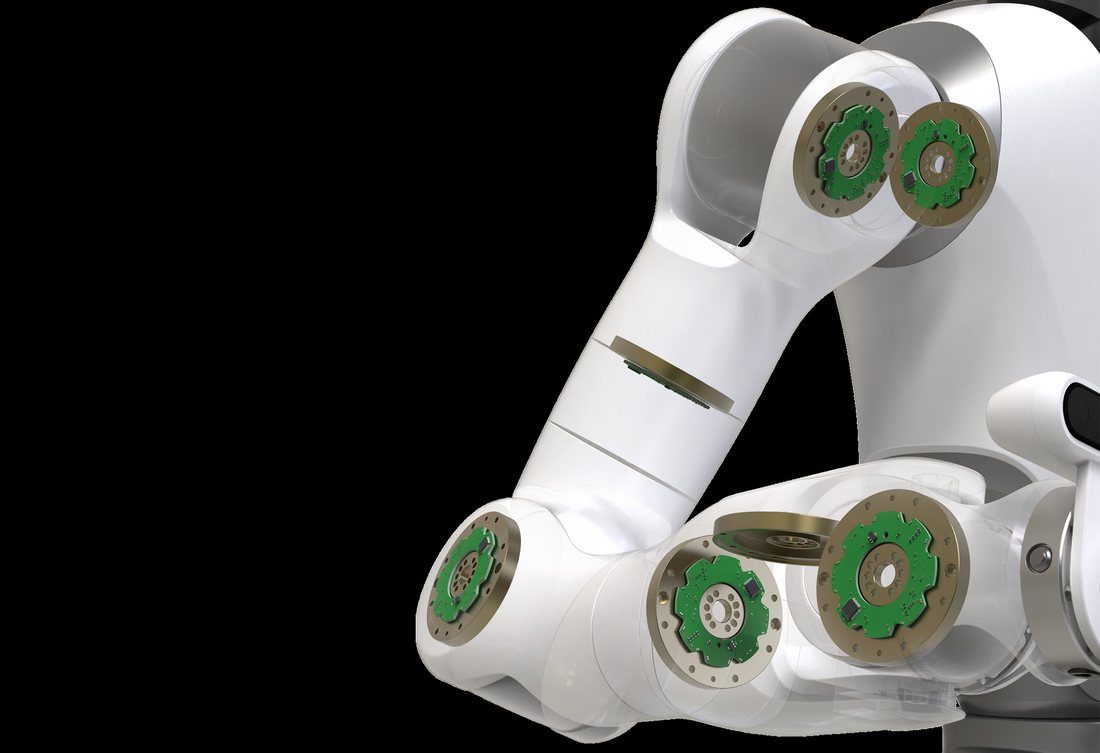
Joint Torque Sensor
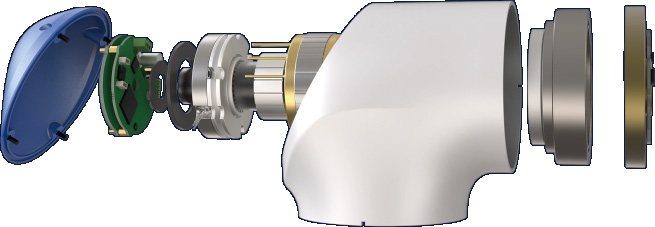
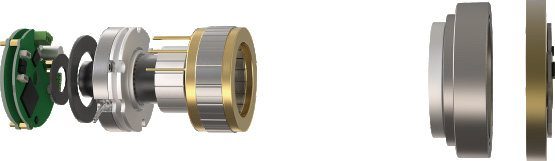
Self-developed joint torque sensors — among the first to integrate MEMS sensing technology into robotic arm joints. MEMS sensors deliver ultra-precise force detection (10× sensitivity); silicon micro-melting technology provides superior stability (4×); and a special steel structure design enhances rigidity and durability (2×).
Lightweight Integrated Joint Module
A modular design enables rapid and efficient arm assembly, and the lightweight structure makes it the lightest force-controlled module in its payload class. The built-in EtherCAT communication driver features four-loop control (position, velocity, torque and current loops) supporting 8 kHz torque closed-loop control directly on the driver. Integrated dual absolute encoders enable full closed-loop control with battery-free zero-point recording, while a built-in friction brake ensures no drift when powered off and no jitter when powered on.
Impedance Control & Dynamic Tracking
With full-body force control and impedance technology, the robot explores the world like a human. In human-robot interaction it exhibits natural compliance, reducing impact forces and enhancing comfort and safety; in unknown environments, impedance control helps the robot adapt to changes and minimizes oscillation and instability caused by external disturbance, improving task efficiency and reliability; in precision flexible assembly, it adjusts flexibly upon contact, preventing damage to the workpiece or to the robot itself.
Product Features
Humanoid Design & Dexterity
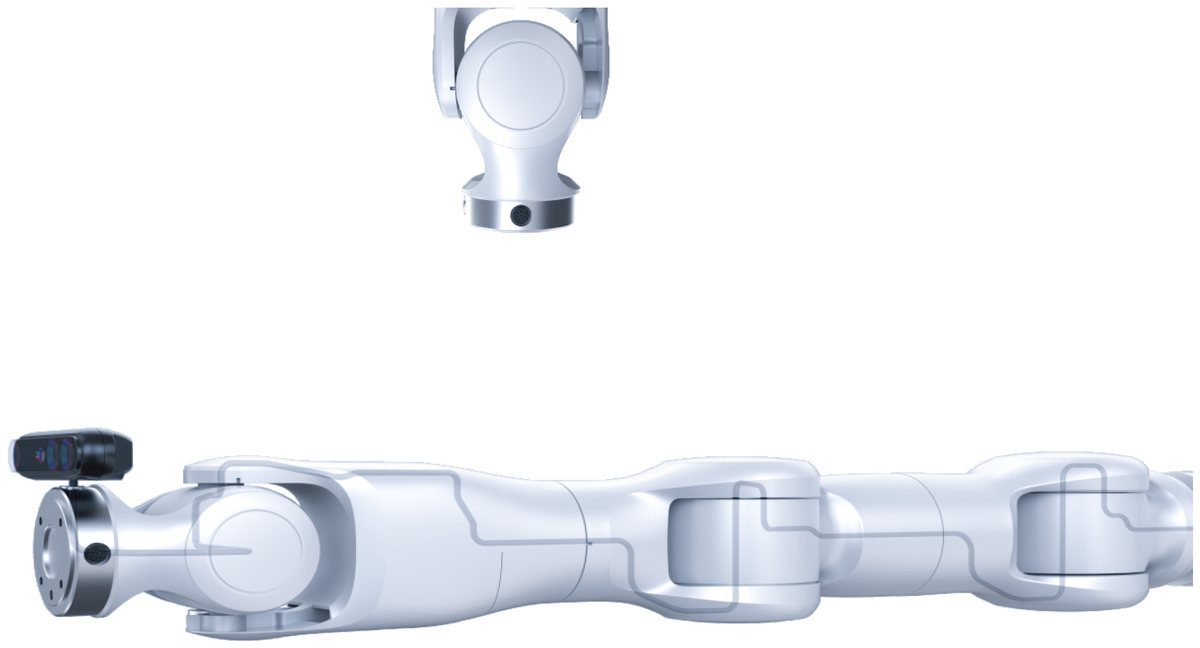
The 7-DOF symmetrical arms move as flexibly and naturally as human arms. The innovative crossed-axis wrist achieves biomechanical equivalence to the human wrist with a smaller rotation radius, making grasping and adjustment movements more natural and teleoperation smoother and more adaptable across diverse scenarios.
Safe & Compliant Interaction
Každý kloub je vybaven vestavěným snímačem točivého momentu, který zajišťuje měkkou a bezpečnou interakci, která chrání uživatele a jejich okolí. Plná kontrola síly kloubu a ochrana proti kolizi jsou standardem na obou pažích.
Industrial-Grade Performance
Inovativní technologie kompenzace shody výrazně zvyšuje absolutní přesnost. V kombinaci s průmyslovou přesností a tuhostí poskytuje robot vynikající výkon v komerčních i průmyslových aplikacích.
Standard 5-Camera Panoramic Vision
Všechny konfigurace se dodávají s pěti panoramatickými kamerami – žádná slepá místa. Systém pokrývá vnímání prostředí, globální lokalizaci, získávání mraků bodů, rozpoznávání cíle, jemné polohování koncového efektoru, kontrolu obrobku a vizuální vedení provozu.
Powerful Edge Computing
The robot's brain is built on an NVIDIA Jetson Orin AGX 64 GB platform delivering 275 TOPS, with a 12-core CPU (up to 2.2 GHz) and 1.3 GHz GPU — supporting high-precision vision processing, data collection, deep learning and motion-control algorithms. The open ROS2 framework is supported for plug-and-play, developer-friendly deployment.
Comprehensive SDK & Teleoperation
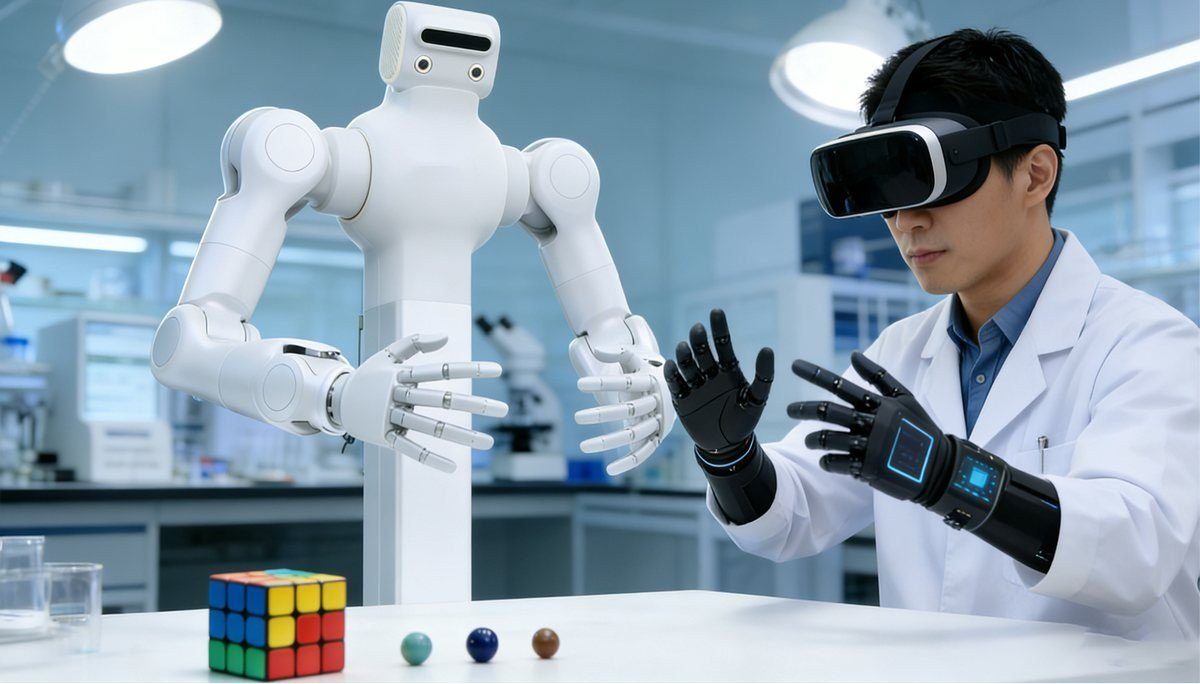
The SDK provides rich functionality, including real-time force-control and position-control interfaces with control frequencies up to 1 kHz, plus advanced algorithms such as dynamics, kinematics, impedance control, payload identification, hybrid force-position control, collision detection, drag-to-teach and dual-arm coordination. Secondary-development interfaces encapsulate complex arm functions into APIs with demo examples for typical applications. The dedicated teleoperation system offers 16 DOF, 500 Hz control and sampling frequency, ≤100 ms end-to-end latency, Ethernet/CAN-FD communication and HDF5/RLDS data formats — ideal for data collection and imitation learning.
Flexible Expansion & Integration
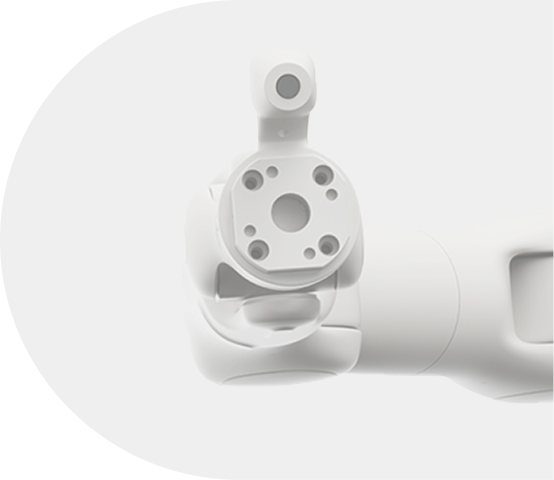
The dual-arm end effectors provide a wide range of communication interfaces (EtherCAT, CAN FD, RS485) plus high-current power output and an 8-pin end connector, making it easy to integrate dexterous hands, 6-axis force/torque sensors and various actuators. A large hollow structure allows internal routing of camera cables and quick integration of stereo-vision systems while avoiding cable damage from environmental contact, and the platform is compatible with various mobility platforms.
Power & Continuous Operation
Přímé síťové napájení (AC 220 V; adaptéry k dispozici pro zámořská napětí), navržené pro nepřetržitý 24hodinový provoz bez bateriového modulu. Hmotnost robota je přibližně 80 kg s vertikálním pracovním prostorem 0,6–1,8 m.
Aplikace
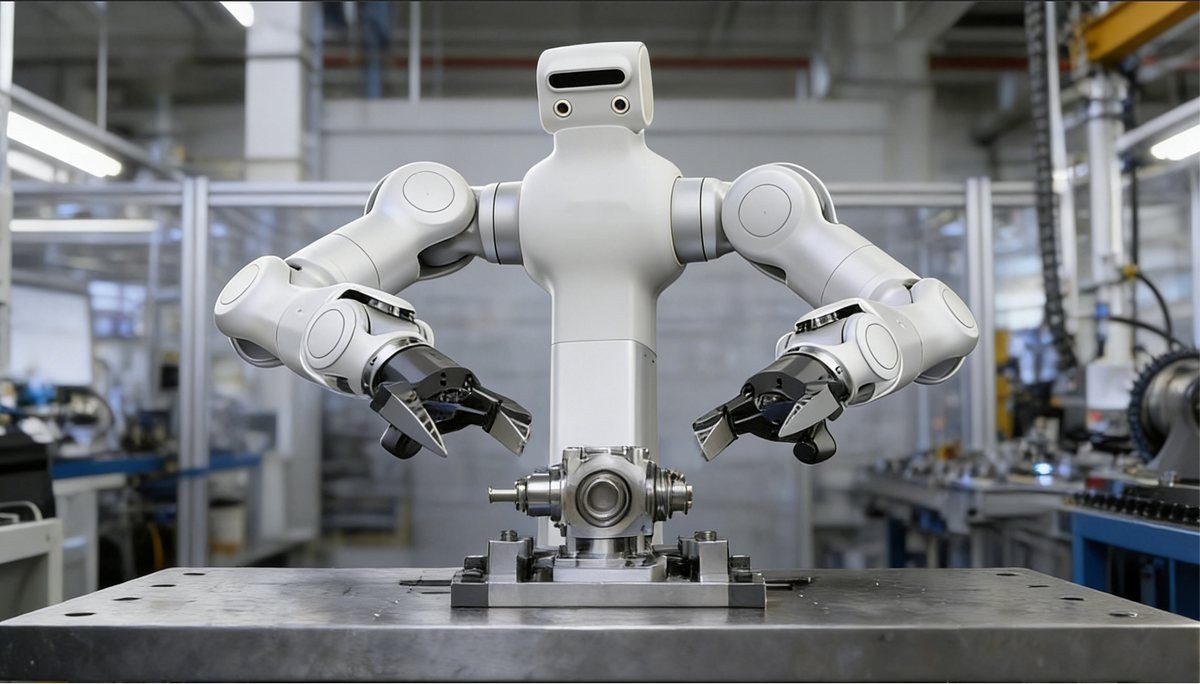
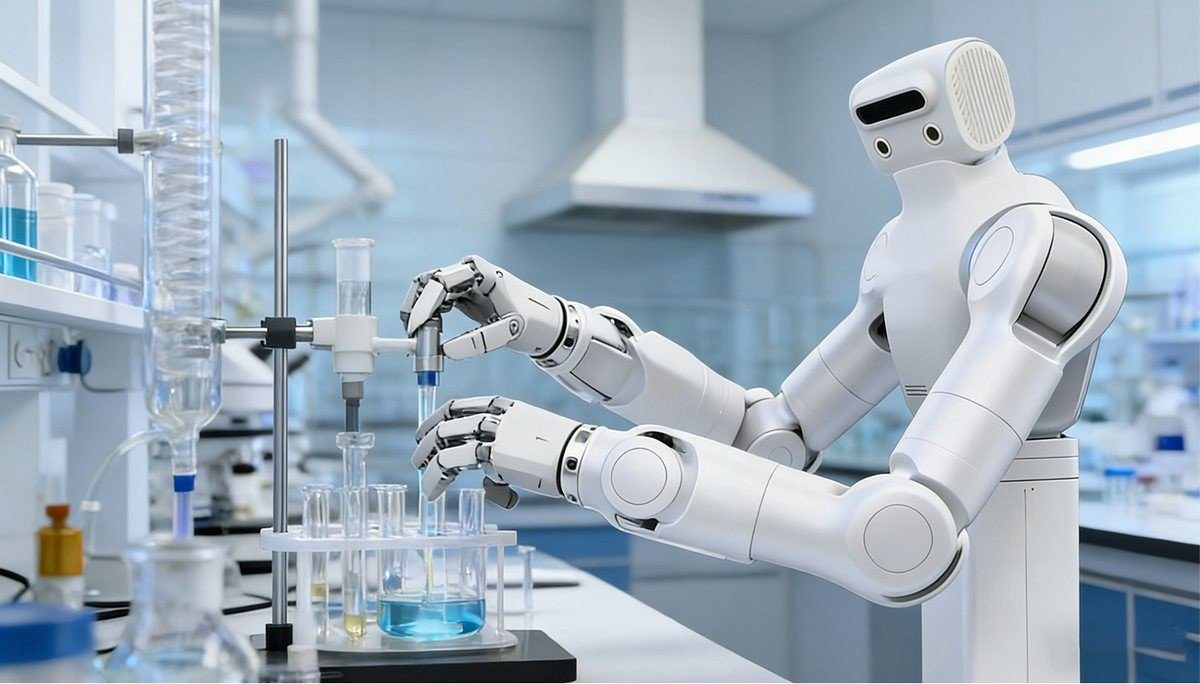
Precision flexible assembly, 3C electronics manufacturing, laboratory automation, scientific research and education (embodied intelligence and imitation-learning data collection), quality inspection and human-robot collaboration research.
Technical Specifications
Dual-Arm Robot — Standard Configuration
| Model | TROY Humanoid Robot (M3 / M6 options) |
| Stupně volnosti | 14 DOF (7 DOF × 2 arms) |
| Ovládání síly | Full-joint force control, standard; joint torque sensors on all axes |
| Rated payload (per arm) | 3 kg (M3) / 6 kg (M6) |
| Max payload (per arm) | 5 kg (M3) / 10 kg (M6) |
| Working reach (J2 to end flange) | 615 mm (M3) / 695 mm (M6) |
| Opakujte přesnost polohování | ±0.03 mm |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Max joint speed | 180°/s |
| Control modes | Position control, impedance control, hybrid force-position control |
| Communication | 1 kHz EtherCAT |
| Braking | All joints with brakes |
| End-effector interface | RS485, CAN, EtherCAT |
| End 6-axis force/torque sensor | Optional |
| Dexterous hand | Optional |
| Báze | Fixed-height rigid stand (fixed-station platform, no mobile chassis) |
| Vertical working space | 0.6–1.8 m |
| Robot weight | Approx. 80 kg |
| Systém vidění | 5 cameras standard: head 1× D435 RGBD + 2× RGB; wrists 2× RGB (standard on all models) |
| Computing platform | NVIDIA Jetson Orin AGX 64 GB (275 TOPS); 12-core CPU up to 2.2 GHz; GPU 1.3 GHz |
| Framework | ROS2 supported |
| Teleoperation system | 16 DOF; position + impedance modes; 500 Hz control and sampling; ≤100 ms end-to-end latency; Ethernet / CAN-FD; 2560×720 @ 30 fps; HDF5, RLDS data formats |
| Napájení | AC 220 V direct supply (adapters for overseas voltages); no battery module |
| Continuous operation | 24 hours uninterrupted |
| Communication ports | WiFi, Ethernet |
Arm Model Range (per arm)
| Parameter | TR-M6S SRS-686 | TR-M6S CCS-696 | TR-M6S CCS-809 | TR-M3S Long CCS-920 | TR-M6S Lite CCS-615 | TR-M6S Lite CCS-680 | TR-M6S Lite CCS-750 | TR-M20S CCS-105 |
| Number of joints | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Rated payload | 6 kg | 6 kg | 5 kg | 3 kg | 5 kg | 4 kg | 3 kg | 20 kg |
| Wrist configuration | Traditional collaborative wrist | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis |
| Working reach | 686 mm | 696 mm | 809 mm | 920 mm | 615 mm | 680 mm | 751 mm | 1050 mm |
| Weight (per arm) | 11.45 kg | 12.45 kg | 12.7 kg | 13.1 kg | 8.45 kg | 8.65 kg | 8.8 kg | 30 kg |
| Max TCP speed | 2 m/s | 2 m/s | 2 m/s | 2 m/s | 1.5 m/s | 1.5 m/s | 1.5 m/s | 2 m/s |
| Opakovatelnost | ±0.03 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.1 mm |
| IP hodnocení | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP65 |
| Brake control | All joints | All joints | All joints | All joints | J1–J4 | J1–J4 | J1–J4 | All joints |
| Spotřeba energie | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 1000 W avg / 3800 W peak |
| Max joint speed | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 120°/s |
Common Parameters & Certifications
| Joint torque sensors | Standard on all axes |
| Camera cable | Embeddable in end-effector |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Communication | EtherCAT, cycle ≤1 ms |
| Debugging software | PC-based setup & visualization software for 7 axes |
| Encoder | Dual absolute encoders |
| On-board interface (end-effector) | Drag-teach enabling button |
| On-board interface (power) | 24 VDC (rated current 3 A) |
| On-board interface (communication) | RS485, CAN FD, EtherCAT |
| Provozní napětí | 48 V (±10%) |
| Certifications | CE marking, ISO/TS 15066, ISO 13849-1 PLd (Cat. 3), EN 60204-1:2018, EN IEC 61000-6-2, EN IEC 61000-6-4, EN ISO 12100:2010 |
Specifikace se mohou bez upozornění změnit. Pro nejnovější datové listy, výkresy a možnosti konfigurace kontaktujte náš prodejní tým.
Úplné technické údaje
| Model | TR-M |
|---|---|
| Užitečné zatížení | 20 kg |
| Dosah | 0.03 mm |
| Tolerance | ±0.03 mm |
| Kategorie | AI a humanoidní roboti |
| Dodací lhůta | 45 dní |
Hodnoty jsou nominální při 20 °C. Stáhněte si datový list pro modely cad, křivky točivého momentu a mapy I/O regulátoru.
Kde to běží
Velikost a objednáno inženýry TROY.
Velikost a objednáno inženýry TROY.
Velikost a objednáno inženýry TROY.
Velikost a objednáno inženýry TROY.
Otázky kupujícího
Jaké jsou klíčové specifikace?
Model: TR-M, Užitečné zatížení: 20 kg, Dosah: 0,03 mm.
Jaká je dodací lhůta?
45 dní pro standardní konfiguraci; potvrzeno v nabídce.
Dá se to přizpůsobit?
Ano – možnosti OEM/ODM, napětí, nástroje a značky lze přizpůsobit. Odešlete žádost a cílový výstup pro návrh.
Získejte cenovou nabídku pro TR-M
Zahrňte součást, cílovou rychlost a cílový port. Technik – ne chatbot – odpoví do 48 hodin.
Stejná kategorie

Dvouramenný humanoidní robot na kolech

Biomimetický servisní robot Panda
Humanoidní robot na kolečkách
Recenzováno TROY Engineering ·. Specifikace jsou při každé nabídce znovu porovnávány s datovým listem dodavatele.