



양팔 휴머노이드 로봇
TR-M은 연구/접수용 휴머노이드 로봇입니다. 주요 사양: 탑재량 20kg; 0.03mm에 도달; 공차 ±0.03mm. 리드타임은 45일입니다. 가격은 구성별로 제시됩니다. 인증: 요청 시 CE 문서.
- 모델
- TR-M
- 유효 탑재량
- 20 kg
- 도달하다
- 0.03 mm
- 용인
- ±0.03 mm
- 범주
- AI 및 휴머노이드 로봇
- 리드타임
- 45일
이 플랫폼의 용도
TROY 이중 팔 휴머노이드 로봇: 14 DOF, MEMS 관절 토크 센서를 통한 완전 관절 힘 제어, +/-0.03mm 반복성, 3~20kg 페이로드 옵션, 5카메라 비전, NVIDIA Jetson Orin AGX 275 TOPS, ROS2.
상업적 용어
| 인용 | 구성당 가격 책정 — 48시간 이내에 답변 |
|---|---|
| 리드타임 | 45일 |
| MOQ | 1개 단위 |
| 기원 | 중국 |
| 선적항 | 중국 선전 |
| 인코텀즈 | 요청 시 FOB 심천/CIF |
| 지불 | 보증금 30%, 배송 전 70% |
| 보증 | 24개월은 기본, 36개월은 선택 가능 |
제품 세부정보
TROY 엔지니어링 파일의 애플리케이션 노트, 시공 도면 및 비디오 — 견적과 함께 제공되는 동일한 문서입니다.
AI Robot Introduction:
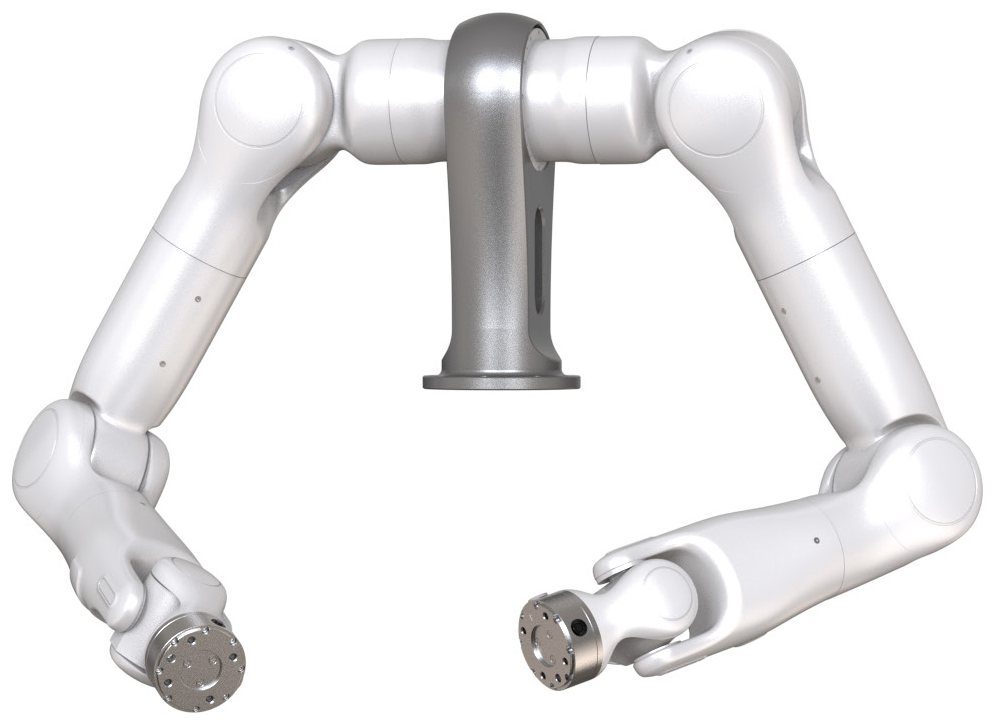
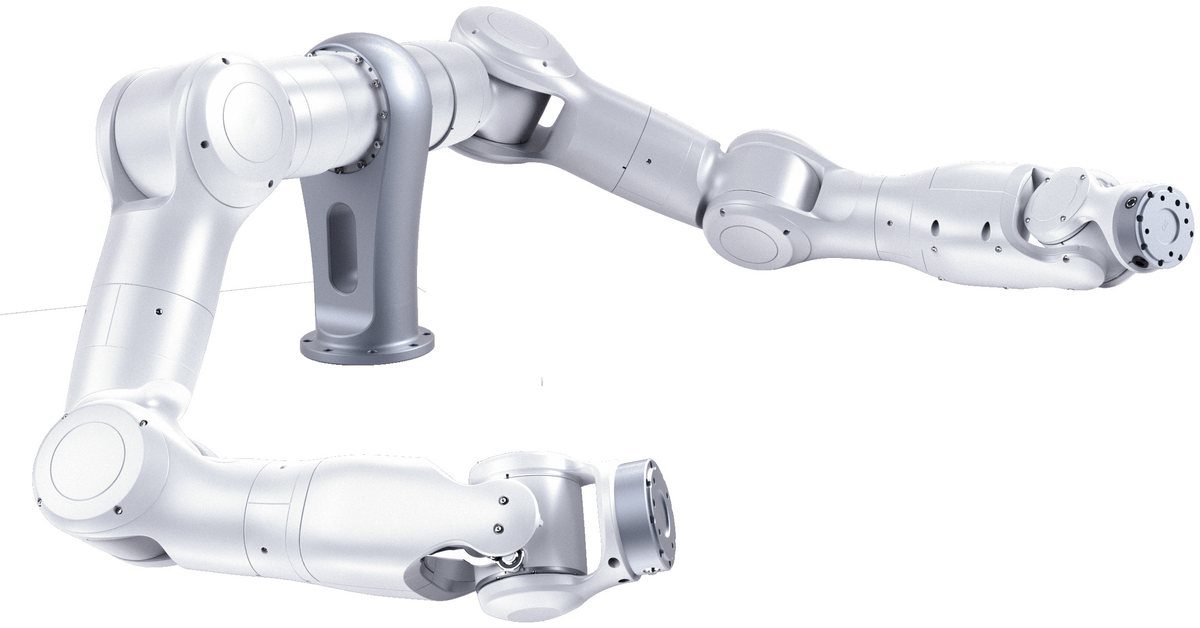
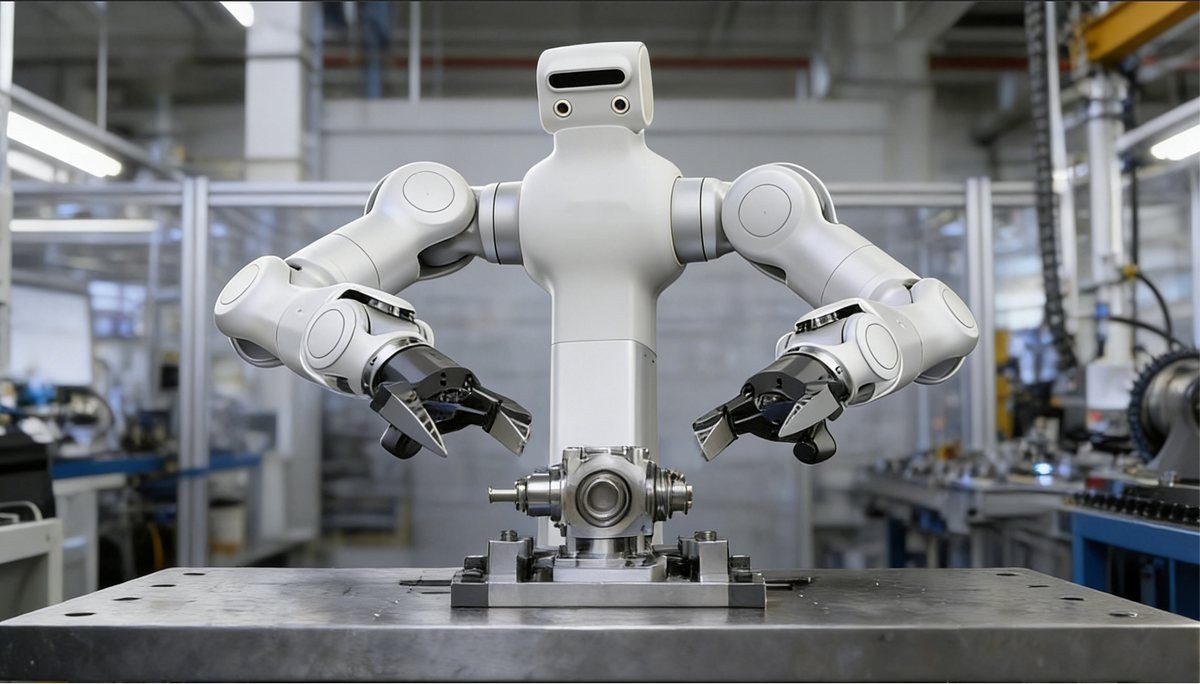
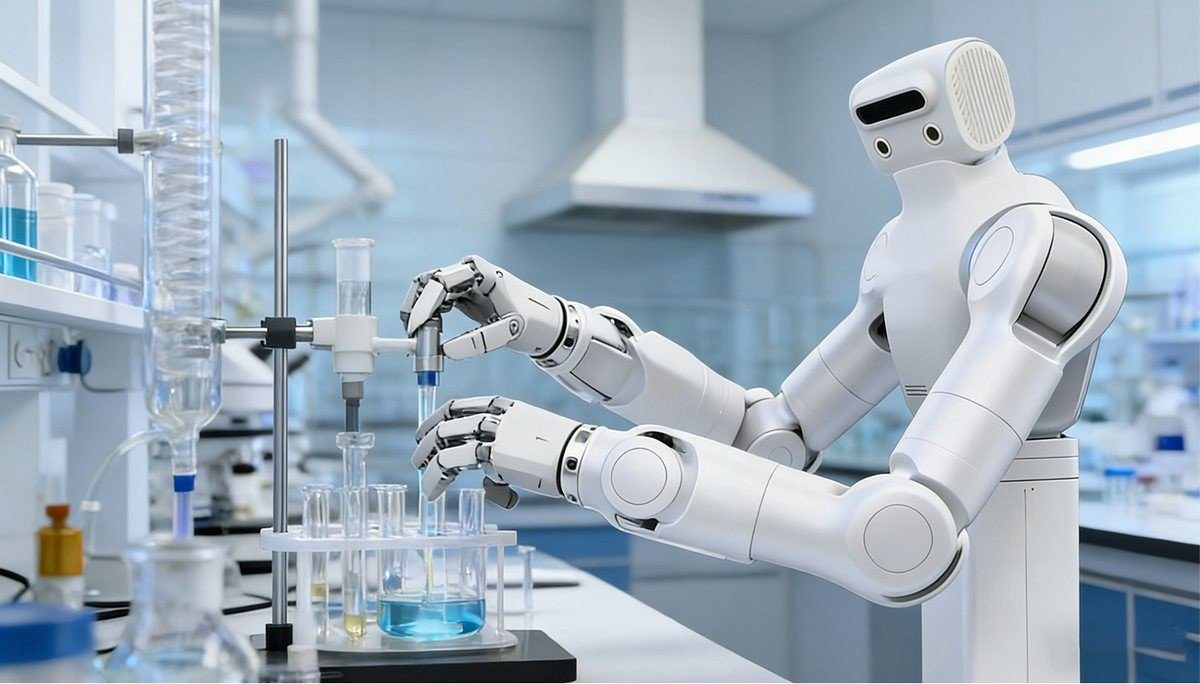
TROY Humanoid Robot is a fully force-controlled dual-arm humanoid robot platform designed for high-precision, fixed-station tasks in industry and research. A rigid stand replaces the conventional mobile chassis, trading mobility for uncompromising stability and accuracy — making the platform ideal for precision flexible assembly, laboratory automation, inspection, and embodied-intelligence research.
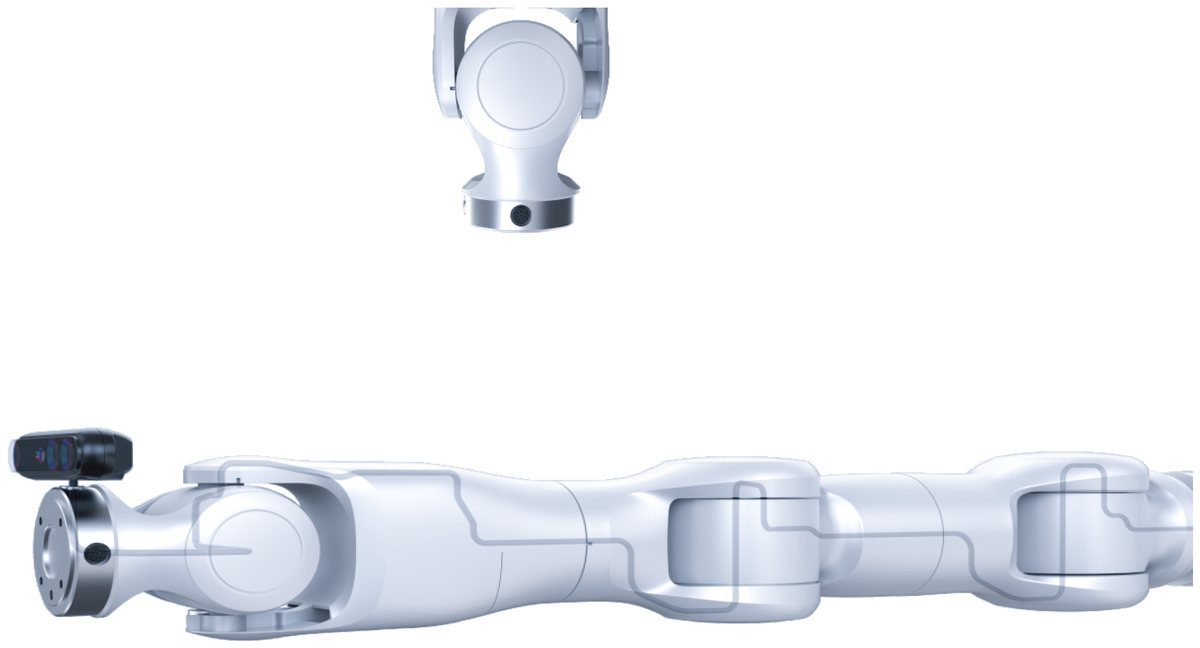
The robot features two 7-DOF arms (14 DOF in total) with joint torque sensors standard on every axis. Repeat positioning accuracy reaches ±0.03 mm and force-control accuracy is up to 0.15 N, with position, impedance and hybrid force-position control modes in the standard controller. Each arm uses an innovative crossed-axis wrist design that eliminates the degree-of-freedom degradation of traditional wrists, achieving biomechanical equivalence to the human wrist for more natural, human-like motion.
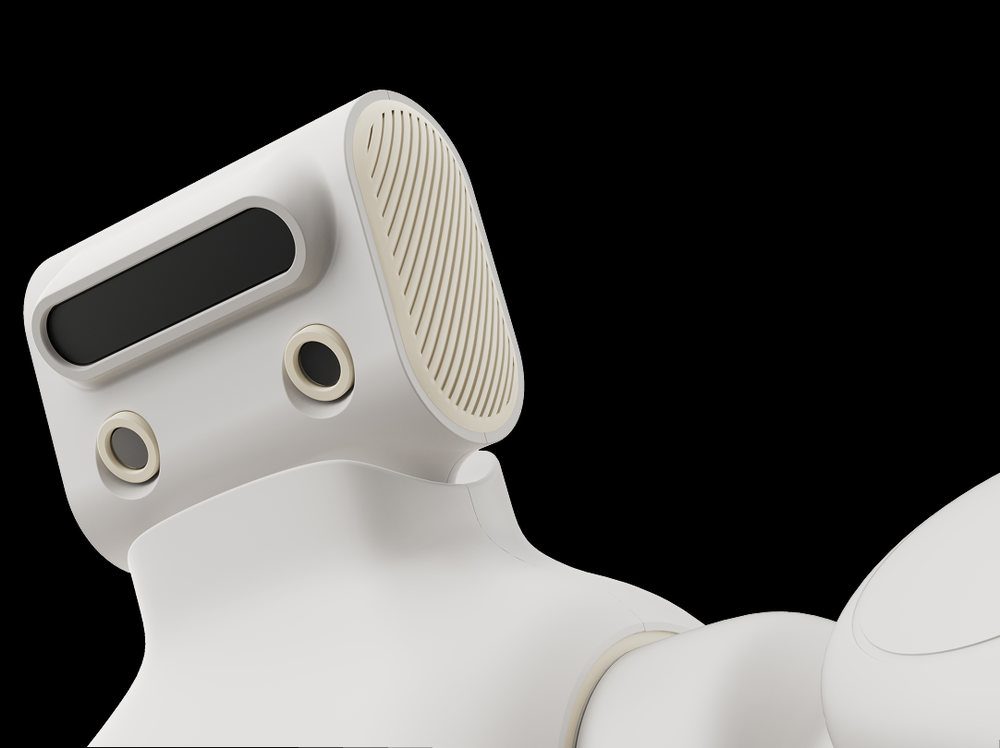
The platform ships fully equipped: a 5-camera panoramic vision system (head: 1× depth camera + 2× RGB cameras; wrists: 2× RGB cameras), an NVIDIA Jetson Orin AGX 64 GB (275 TOPS) computing platform and open ROS2 support — ready for vision-guided operation, data collection and secondary development out of the box. Eight arm models cover rated payloads from 3 kg to 20 kg and working reaches from 615 mm to 1050 mm, so a single controller, SDK and software ecosystem scales across applications.
Core Technology
Joint Torque Sensor
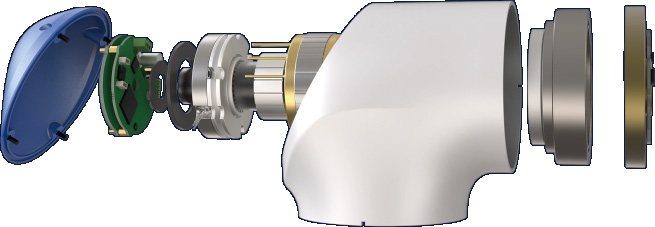
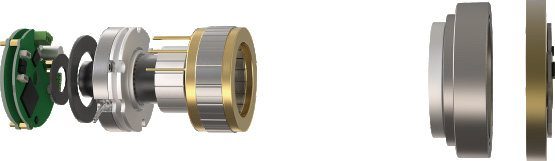
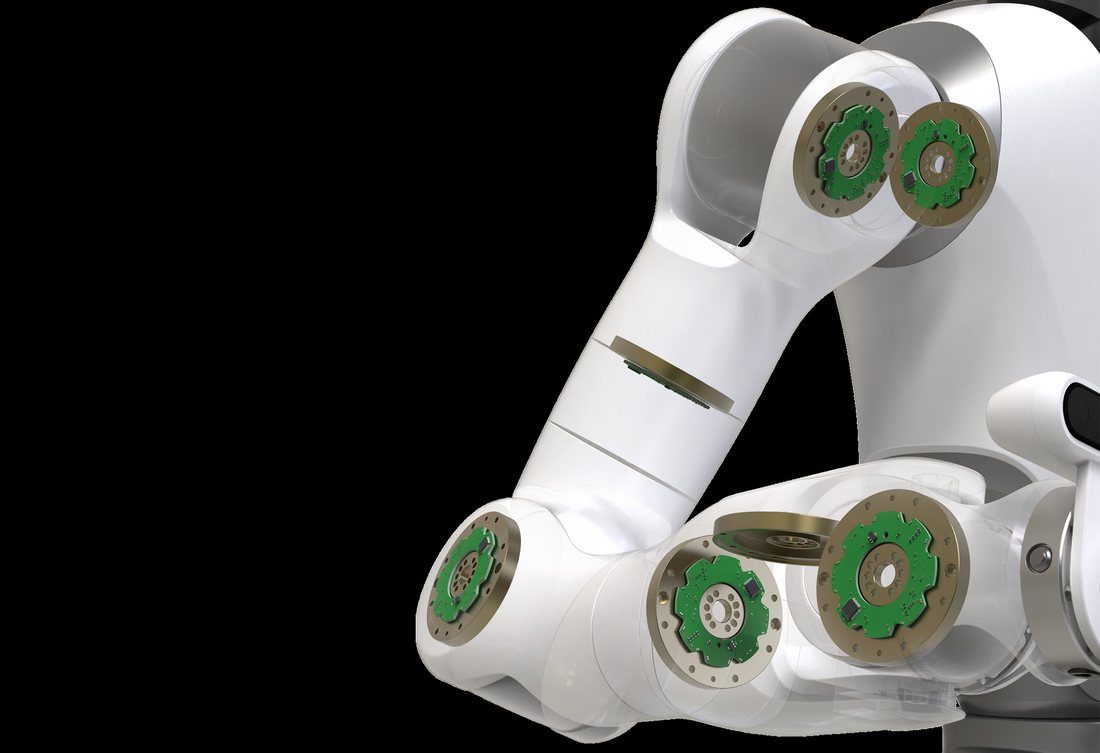
Self-developed joint torque sensors — among the first to integrate MEMS sensing technology into robotic arm joints. MEMS sensors deliver ultra-precise force detection (10× sensitivity); silicon micro-melting technology provides superior stability (4×); and a special steel structure design enhances rigidity and durability (2×).
Lightweight Integrated Joint Module
A modular design enables rapid and efficient arm assembly, and the lightweight structure makes it the lightest force-controlled module in its payload class. The built-in EtherCAT communication driver features four-loop control (position, velocity, torque and current loops) supporting 8 kHz torque closed-loop control directly on the driver. Integrated dual absolute encoders enable full closed-loop control with battery-free zero-point recording, while a built-in friction brake ensures no drift when powered off and no jitter when powered on.
Impedance Control & Dynamic Tracking
With full-body force control and impedance technology, the robot explores the world like a human. In human-robot interaction it exhibits natural compliance, reducing impact forces and enhancing comfort and safety; in unknown environments, impedance control helps the robot adapt to changes and minimizes oscillation and instability caused by external disturbance, improving task efficiency and reliability; in precision flexible assembly, it adjusts flexibly upon contact, preventing damage to the workpiece or to the robot itself.
Product Features
Humanoid Design & Dexterity
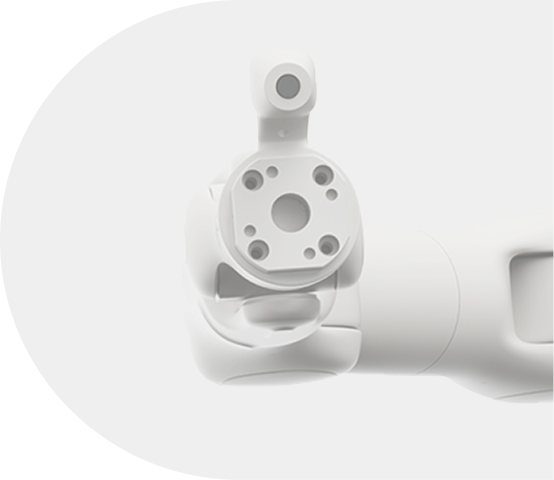
The 7-DOF symmetrical arms move as flexibly and naturally as human arms. The innovative crossed-axis wrist achieves biomechanical equivalence to the human wrist with a smaller rotation radius, making grasping and adjustment movements more natural and teleoperation smoother and more adaptable across diverse scenarios.
Safe & Compliant Interaction
모든 관절에는 토크 센서가 내장되어 있어 사용자와 주변 환경을 보호하는 부드럽고 안전한 상호 작용을 보장합니다. 완전 관절 힘 제어 및 충돌 보호 기능이 양쪽 팔에 표준으로 제공됩니다.
Industrial-Grade Performance
혁신적인 컴플라이언스 보상 기술로 절대 정확도가 대폭 향상됩니다. 산업용 수준의 정밀도와 강성이 결합된 이 로봇은 상업용 및 산업용 응용 분야 모두에서 뛰어난 성능을 제공합니다.
Standard 5-Camera Panoramic Vision
모든 구성에는 사각지대가 없는 5대의 파노라마 카메라가 함께 제공됩니다. 이 시스템은 환경 인식, 전역 위치 파악, 포인트 클라우드 획득, 대상 인식, 엔드 이펙터 미세 위치 지정, 공작물 검사 및 시각적 작업 안내를 다룹니다.
Powerful Edge Computing
The robot's brain is built on an NVIDIA Jetson Orin AGX 64 GB platform delivering 275 TOPS, with a 12-core CPU (up to 2.2 GHz) and 1.3 GHz GPU — supporting high-precision vision processing, data collection, deep learning and motion-control algorithms. The open ROS2 framework is supported for plug-and-play, developer-friendly deployment.
Comprehensive SDK & Teleoperation
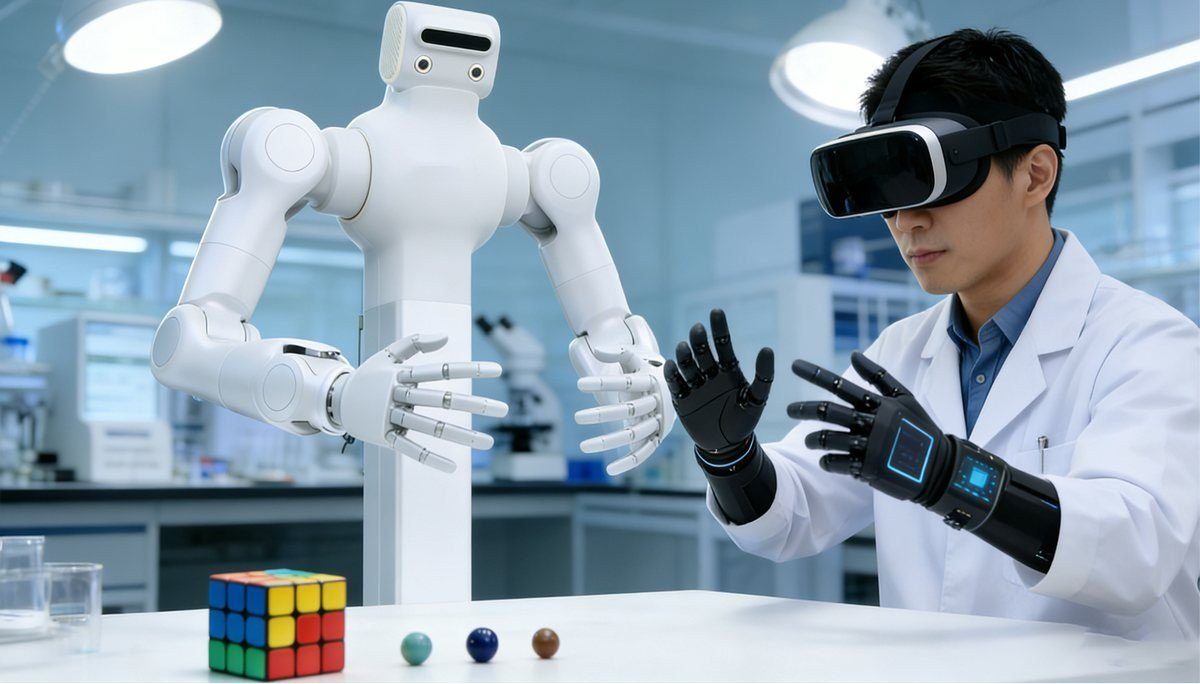
The SDK provides rich functionality, including real-time force-control and position-control interfaces with control frequencies up to 1 kHz, plus advanced algorithms such as dynamics, kinematics, impedance control, payload identification, hybrid force-position control, collision detection, drag-to-teach and dual-arm coordination. Secondary-development interfaces encapsulate complex arm functions into APIs with demo examples for typical applications. The dedicated teleoperation system offers 16 DOF, 500 Hz control and sampling frequency, ≤100 ms end-to-end latency, Ethernet/CAN-FD communication and HDF5/RLDS data formats — ideal for data collection and imitation learning.
Flexible Expansion & Integration
The dual-arm end effectors provide a wide range of communication interfaces (EtherCAT, CAN FD, RS485) plus high-current power output and an 8-pin end connector, making it easy to integrate dexterous hands, 6-axis force/torque sensors and various actuators. A large hollow structure allows internal routing of camera cables and quick integration of stereo-vision systems while avoiding cable damage from environmental contact, and the platform is compatible with various mobility platforms.
Power & Continuous Operation
주전원 직접 공급(AC 220V, 해외 전압용 어댑터 사용 가능), 배터리 모듈 없이 24시간 중단 없이 작동하도록 설계되었습니다. 로봇 무게는 약 80kg이며 수직 작업 공간은 0.6~1.8m입니다.
응용
Precision flexible assembly, 3C electronics manufacturing, laboratory automation, scientific research and education (embodied intelligence and imitation-learning data collection), quality inspection and human-robot collaboration research.
Technical Specifications
Dual-Arm Robot — Standard Configuration
| 모델 | TROY Humanoid Robot (M3 / M6 options) |
| 자유도 | 14 DOF (7 DOF × 2 arms) |
| 힘 제어 | Full-joint force control, standard; joint torque sensors on all axes |
| Rated payload (per arm) | 3 kg (M3) / 6 kg (M6) |
| Max payload (per arm) | 5 kg (M3) / 10 kg (M6) |
| Working reach (J2 to end flange) | 615 mm (M3) / 695 mm (M6) |
| 반복 위치 정확도 | ±0.03 mm |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Max joint speed | 180°/s |
| Control modes | Position control, impedance control, hybrid force-position control |
| Communication | 1 kHz EtherCAT |
| Braking | All joints with brakes |
| End-effector interface | RS485, CAN, EtherCAT |
| End 6-axis force/torque sensor | Optional |
| Dexterous hand | Optional |
| 베이스 | Fixed-height rigid stand (fixed-station platform, no mobile chassis) |
| Vertical working space | 0.6–1.8 m |
| Robot weight | Approx. 80 kg |
| 비전 시스템 | 5 cameras standard: head 1× D435 RGBD + 2× RGB; wrists 2× RGB (standard on all models) |
| Computing platform | NVIDIA Jetson Orin AGX 64 GB (275 TOPS); 12-core CPU up to 2.2 GHz; GPU 1.3 GHz |
| Framework | ROS2 supported |
| Teleoperation system | 16 DOF; position + impedance modes; 500 Hz control and sampling; ≤100 ms end-to-end latency; Ethernet / CAN-FD; 2560×720 @ 30 fps; HDF5, RLDS data formats |
| 전원공급장치 | AC 220 V direct supply (adapters for overseas voltages); no battery module |
| Continuous operation | 24 hours uninterrupted |
| Communication ports | WiFi, Ethernet |
Arm Model Range (per arm)
| Parameter | TR-M6S SRS-686 | TR-M6S CCS-696 | TR-M6S CCS-809 | TR-M3S Long CCS-920 | TR-M6S Lite CCS-615 | TR-M6S Lite CCS-680 | TR-M6S Lite CCS-750 | TR-M20S CCS-105 |
| Number of joints | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Rated payload | 6 kg | 6 kg | 5 kg | 3 kg | 5 kg | 4 kg | 3 kg | 20 kg |
| Wrist configuration | Traditional collaborative wrist | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis |
| Working reach | 686 mm | 696 mm | 809 mm | 920 mm | 615 mm | 680 mm | 751 mm | 1050 mm |
| Weight (per arm) | 11.45 kg | 12.45 kg | 12.7 kg | 13.1 kg | 8.45 kg | 8.65 kg | 8.8 kg | 30 kg |
| Max TCP speed | 2 m/s | 2 m/s | 2 m/s | 2 m/s | 1.5 m/s | 1.5 m/s | 1.5 m/s | 2 m/s |
| 반복성 | ±0.03 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.1 mm |
| IP 등급 | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP65 |
| Brake control | All joints | All joints | All joints | All joints | J1–J4 | J1–J4 | J1–J4 | All joints |
| 소비전력 | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 1000 W avg / 3800 W peak |
| Max joint speed | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 120°/s |
Common Parameters & Certifications
| Joint torque sensors | Standard on all axes |
| Camera cable | Embeddable in end-effector |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Communication | EtherCAT, cycle ≤1 ms |
| Debugging software | PC-based setup & visualization software for 7 axes |
| Encoder | Dual absolute encoders |
| On-board interface (end-effector) | Drag-teach enabling button |
| On-board interface (power) | 24 VDC (rated current 3 A) |
| On-board interface (communication) | RS485, CAN FD, EtherCAT |
| 작동 전압 | 48 V (±10%) |
| Certifications | CE marking, ISO/TS 15066, ISO 13849-1 PLd (Cat. 3), EN 60204-1:2018, EN IEC 61000-6-2, EN IEC 61000-6-4, EN ISO 12100:2010 |
사양은 예고 없이 변경될 수 있습니다. 최신 데이터시트, 도면 및 구성 옵션에 대해서는 영업팀에 문의하세요.
전체 기술 데이터
| 모델 | TR-M |
|---|---|
| 유효 탑재량 | 20 kg |
| 도달하다 | 0.03 mm |
| 용인 | ±0.03 mm |
| 범주 | AI 및 휴머노이드 로봇 |
| 리드타임 | 45일 |
값은 20°C에서의 공칭값입니다. CAD 모델, 토크 곡선 및 컨트롤러 I/O 맵에 대한 데이터시트를 다운로드하세요.
실행되는 곳
TROY 엔지니어가 크기를 조정하고 의뢰했습니다.
TROY 엔지니어가 크기를 조정하고 의뢰했습니다.
TROY 엔지니어가 크기를 조정하고 의뢰했습니다.
TROY 엔지니어가 크기를 조정하고 의뢰했습니다.
구매자 질문
주요 사양은 무엇입니까?
모델: TR-M, 탑재량: 20kg, 도달 거리: 0.03mm.
리드타임은 무엇입니까?
표준 구성의 경우 45일, 견적으로 확인되었습니다.
맞춤 설정할 수 있나요?
예 - OEM/ODM 옵션, 전압, 툴링 및 브랜딩을 조정할 수 있습니다. 제안서에 대한 응용 프로그램 및 대상 출력을 보냅니다.
TR-M에 대한 가격 제안 받기
부품, 목표 속도 및 대상 포트를 포함합니다. 챗봇이 아닌 엔지니어가 48시간 이내에 답변합니다.
같은 카테고리


검토자: TROY 엔지니어링 ·. 사양은 견적이 나올 때마다 공급업체 데이터시트를 기준으로 다시 확인됩니다.