


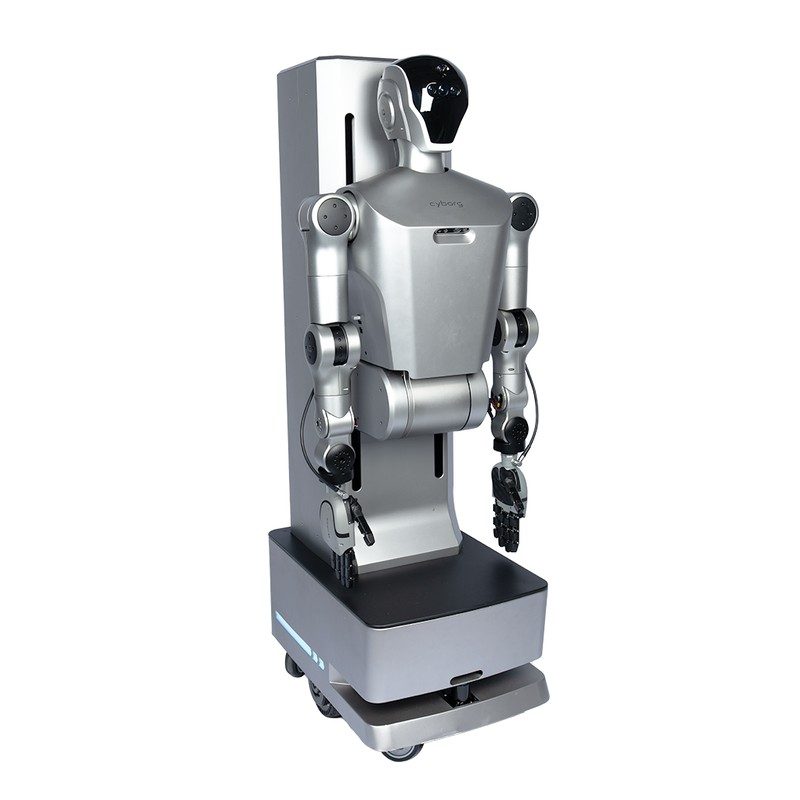
車輪付きヒューマノイドロボット
TR-WH01は調査・受付用の人型ロボットです。リードタイムは60日です。価格は構成ごとに見積もられます。認証: ご要望に応じて CE ドキュメントをご提供します。
- モデル
- TR-WH01
- リードタイム
- 60日
- カテゴリ
- AIとヒューマノイドロボット
このプラットフォームの目的
産業用検査およびハンドリング用の 53 自由度の車輪付きヒューマノイド ロボット。片腕リーチ 835 mm、双腕ペイロード 15 kg、ジョイント トルク 562 N·m、12 コア 275 TOPS 認識プラットフォームを備えています。
商業条件
| 引用 | 構成ごとの価格 - 48 時間以内にご返信ください |
|---|---|
| リードタイム | 60日 |
| MOQ | 1台 |
| 起源 | 中国 |
| 積地港 | 深セン、中国 |
| インコタームズ | FOB 深セン / CIF (ご要望に応じて) |
| 支払い | 30% のデポジット、出荷前に 70% |
| 保証 | 標準は 24 か月、オプションは 36 か月 |
製品詳細
TROY エンジニアリング ファイルからのアプリケーション ノート、構造図、およびビデオ — 見積書に同梱される同じ文書。
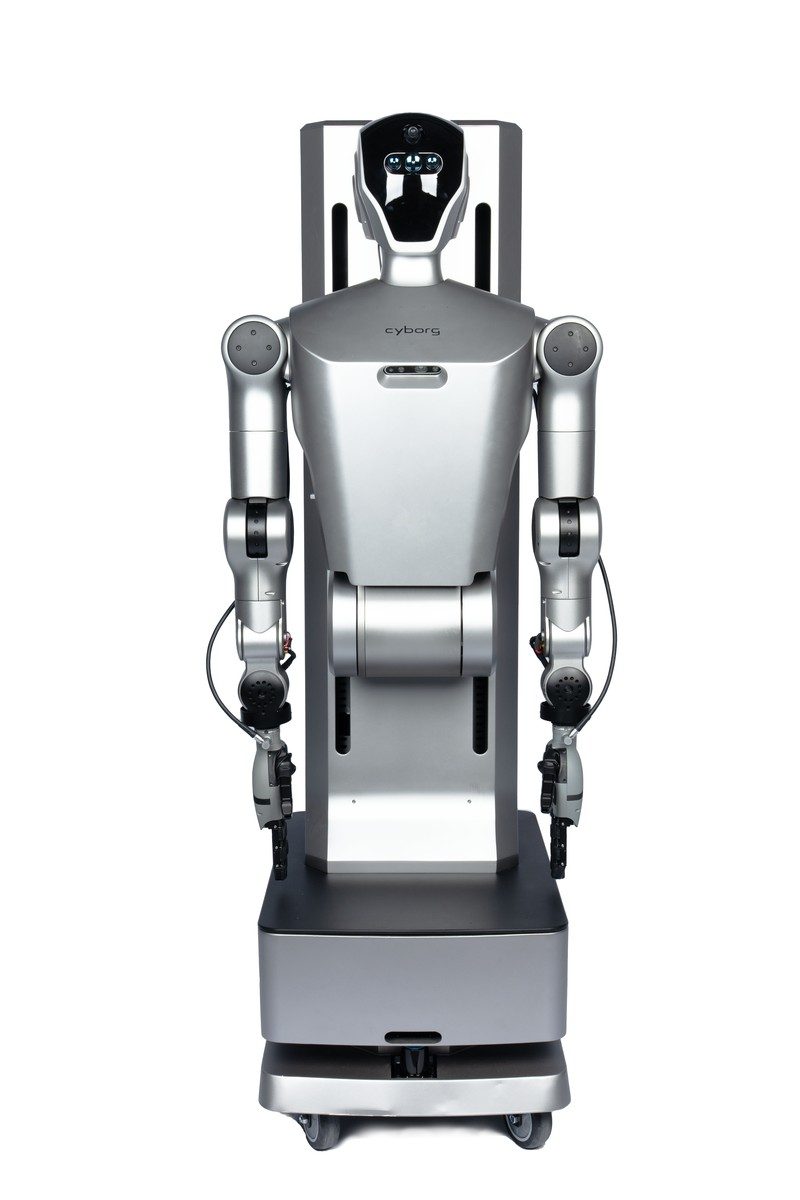
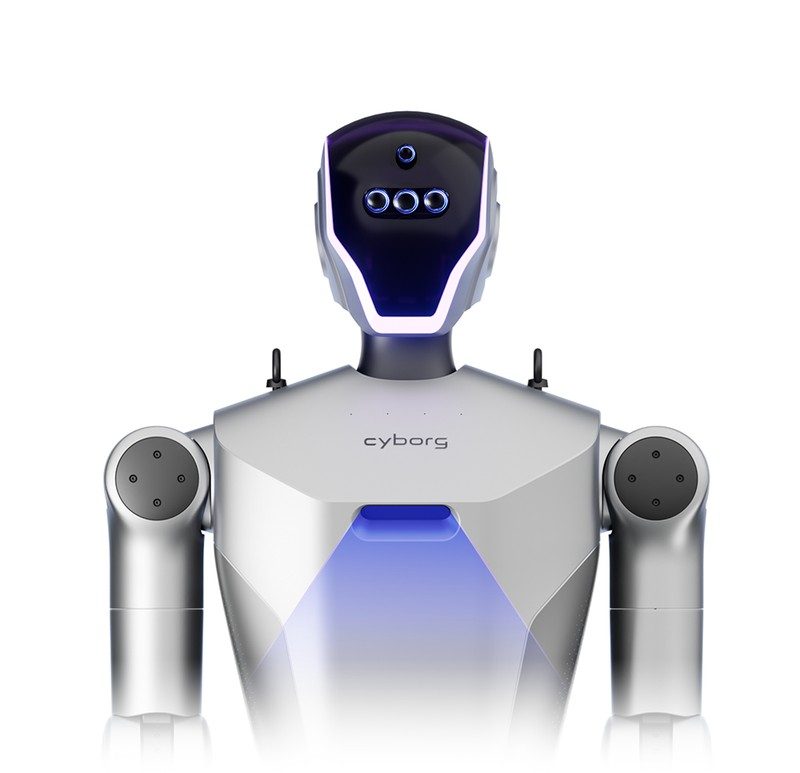
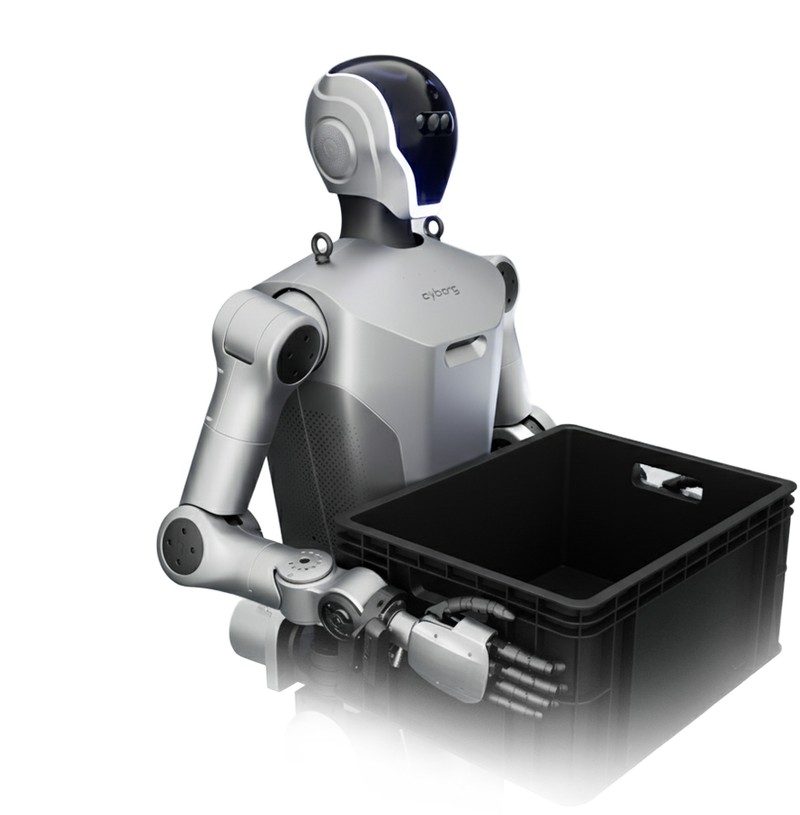
The wheeled humanoid robot delivers an ultra-high degree of freedom, with a total of 53 DOF, an 835mm single-arm reach, a 0–2m working range and a dual-arm payload exceeding 15kg. Equipped with high-density, high-torque joint motor modules (maximum joint torque of 562 N·m), it handles heavy material transport while its bionic dexterous hands enable adaptive grasping and assembly of irregular and precision parts — achieving a refined synergy of strength and dexterity.
Product Features
1. Ultra-High Degrees of Freedom
A total of 53 degrees of freedom, an 835mm single-arm reach, a 0–2m working range and a dual-arm payload over 15kg. High-density, high-torque joint motor modules (maximum joint torque of 562 N·m) support heavy-duty material handling, while the bionic dexterous hands enable adaptive grasping and assembly of irregular and precision parts.
2. Multimodal OMCI Intelligent Hub
A multi-sensor fusion, all-dimensional environmental perception network integrating a monocular camera, RGB-D depth camera, LiDAR, 3D camera and six-axis force sensor. Powered by a 12-core 275 TOPS perception computing platform with WiFi5 / Bluetooth 5.2 / 5G high-speed communication, it realizes a real-time “perception–decision–execution” closed loop, accurately recognizing and planning paths even in low-light and complex terrain.
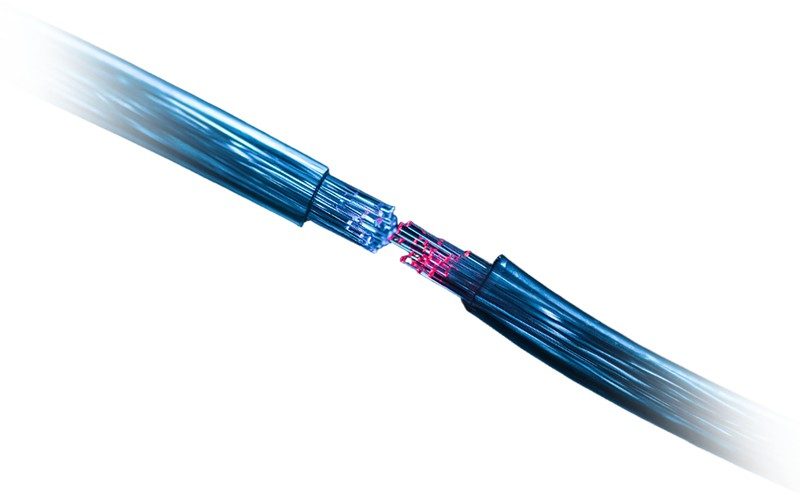
3. Fiber-Optic Sensing Anti-Interference
広い帯域幅と低い遅延により物理的な限界を突破し、消費電力と発熱を削減します。
4. Visual Collaboration System
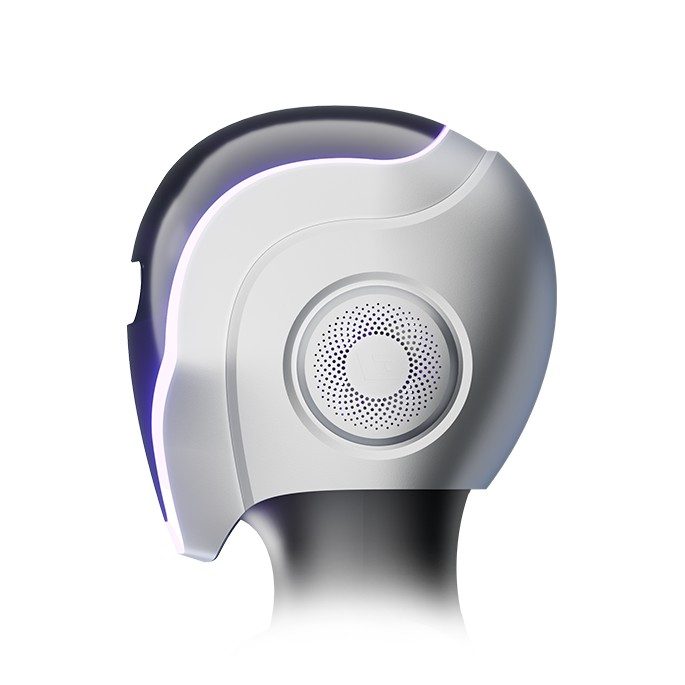
Head-mounted global inspection and chest-mounted detail close-up cameras work together to achieve zero-blind-spot environmental perception.
5. Scenario-Based Operation Pioneer
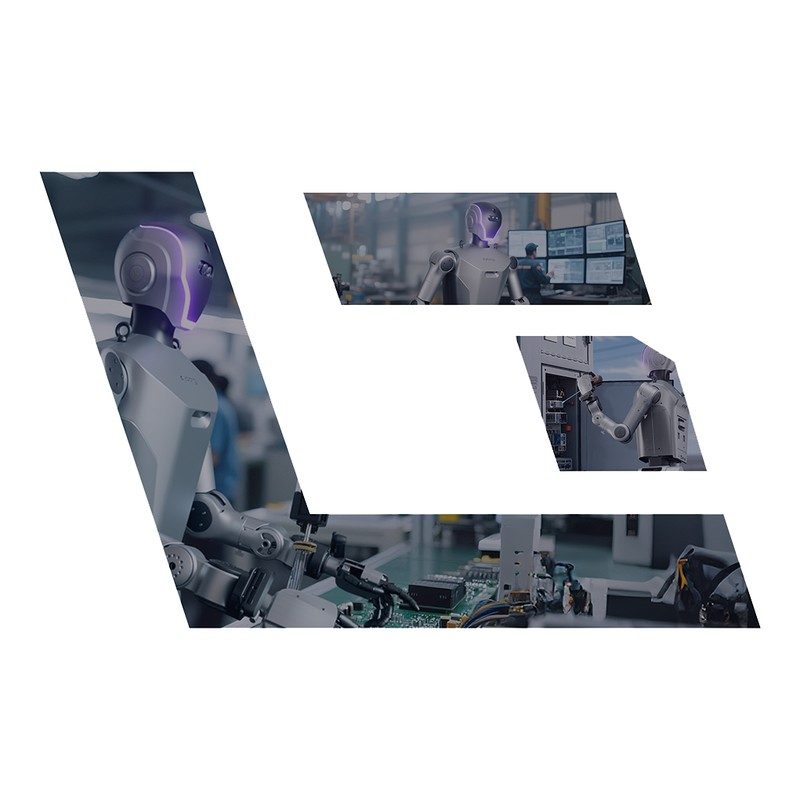
定点での機器検査と自律的な仕分けとハンドリング - 産業シナリオに深く導入され、インテリジェント生産の新時代を到来させます。
6. Large-Payload Handling Capability
最大 15kg までのデュアルアームハンドリングペイロード — 正確かつ効率的なヘビーデューティ操作を簡単にマスターできます。
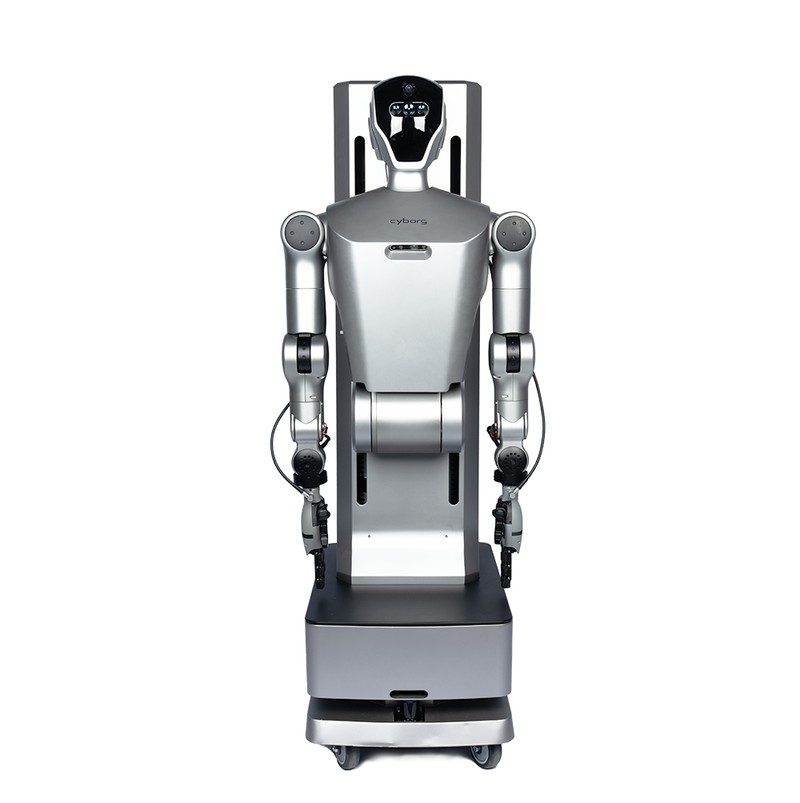
Wheeled Humanoid Robot Technical Specifications:
| Dimensions (L×W×H) | 710×585×1600 mm |
| 重さ | 170 kg |
| Total DOF | 53 |
| Chassis DOF | 3 |
| Waist DOF | 2 |
| Arm DOF | 7 |
| Dexterous Hand DOF | 16 |
| Single-Arm Reach | 835 mm |
| Max Joint Torque | 562 N·m |
| Joint Motor | High-density high-torque joint motor modules |
| Arm Max Payload | 7.5 kg per arm |
| 動作範囲 | 0–2 m |
| Monocular / RGB-D Depth Camera | はい |
| IMU / LiDAR / Infrared / Six-Axis Force Sensor | はい |
| Speaker / Linear 4-Mic / Voice Noise Reduction | はい |
| WiFi5 / Bluetooth 5.2 / 5G | Supported |
| Ultrasonic Radar | はい |
| Perception Computing | 12-core 275 TOPS |
| External Interfaces | USB3.0 / Gigabit Ethernet / DP |
| Battery Life | 5 h |
| Chassis Max Speed | 1 m/s |
| Chassis Navigation Accuracy | ±1 cm |
| Chassis Dimensions | 704×470×397 mm |
完全な技術データ
| モデル | TR-WH01 |
|---|---|
| リードタイム | 60日 |
| カテゴリ | AIとヒューマノイドロボット |
値は 20 °C における公称値です。 CAD モデル、トルク曲線、コントローラー I/O マップのデータシートをダウンロードしてください。
どこで実行されるか
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
購入者の質問
TR-WH01の主な仕様は何ですか?
モデルTR-WH01。リクエストに応じて完全なデータシートを入手できます。
TR-WH01のリードタイムとMOQはどれくらいですか?
リードタイムは60日です。 MOQは1ユニットです。
TR-WH01の価格はいくらですか?
価格は構成ごとに見積もられており、該当する場合は工具や輸送費も含まれます。
TR-WH01 の価格提案を取得する
パート、ターゲット レート、宛先ポートを含めます。チャットボットではなくエンジニアが 48 時間以内に返信します。
同じカテゴリ



TROY エンジニアリングによるレビュー ·。仕様は見積ごとにサプライヤーのデータシートと照合して再チェックされます。