



Robot hình người hai cánh tay
TR-M là một robot hình người dùng để nghiên cứu/tiếp nhận. Thông số kỹ thuật chính: Tải trọng 20 kg; Đạt 0,03 mm; Dung sai ± 0,03 mm. Thời gian thực hiện là 45 ngày; giá được trích dẫn cho mỗi cấu hình. Chứng chỉ: Tài liệu CE theo yêu cầu.
- Người mẫu
- TR-M
- Tải trọng
- 20 kg
- Với tới
- 0.03 mm
- Sức chịu đựng
- ±0.03 mm
- Loại
- Robot AI & hình người
- thời gian dẫn
- 45 ngày
Nền tảng này dùng để làm gì
TROY Robot hình người hai tay: 14 DOF, điều khiển lực toàn khớp với cảm biến mô-men xoắn khớp MEMS, độ lặp lại +/- 0,03 mm, tùy chọn tải trọng 3-20 kg, tầm nhìn 5 camera, NVIDIA Jetson Orin AGX 275 TOPS, ROS2.
Điều kiện thương mại
| Trích dẫn | Định giá theo cấu hình - trả lời trong vòng 48 giờ |
|---|---|
| thời gian dẫn | 45 ngày |
| MOQ | 1 đơn vị |
| Nguồn gốc | Trung Quốc |
| Cảng bốc hàng | Thâm Quyến, Trung Quốc |
| Incoterm | FOB Thâm Quyến / CIF theo yêu cầu |
| Sự chi trả | Đặt cọc 30%, 70% trước khi giao hàng |
| Bảo hành | Tiêu chuẩn 24 tháng, tùy chọn 36 tháng |
Chi tiết sản phẩm
Ghi chú ứng dụng, bản vẽ xây dựng và video từ tệp kỹ thuật TROY - cùng một tài liệu được gửi cùng với báo giá.
AI Robot Introduction:
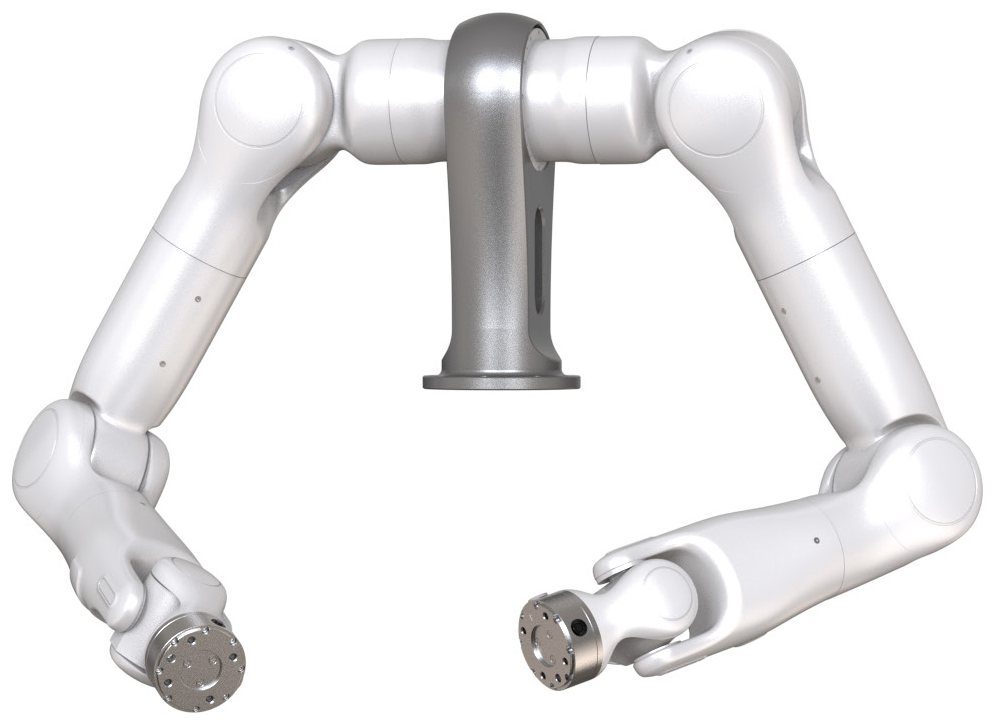
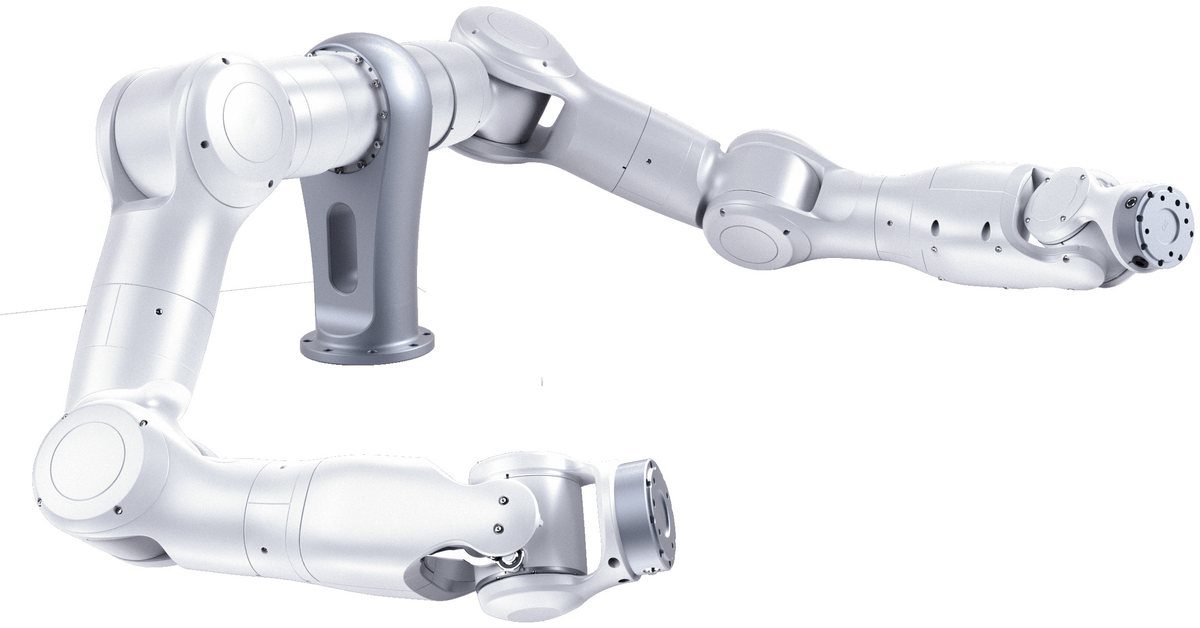
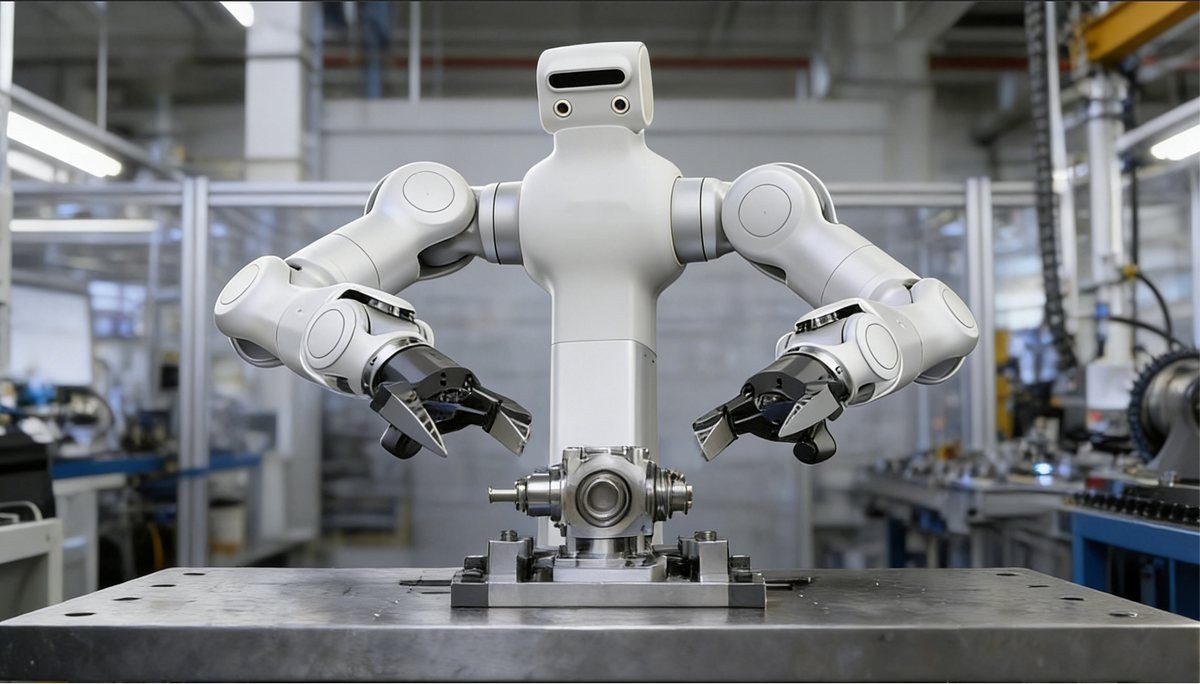
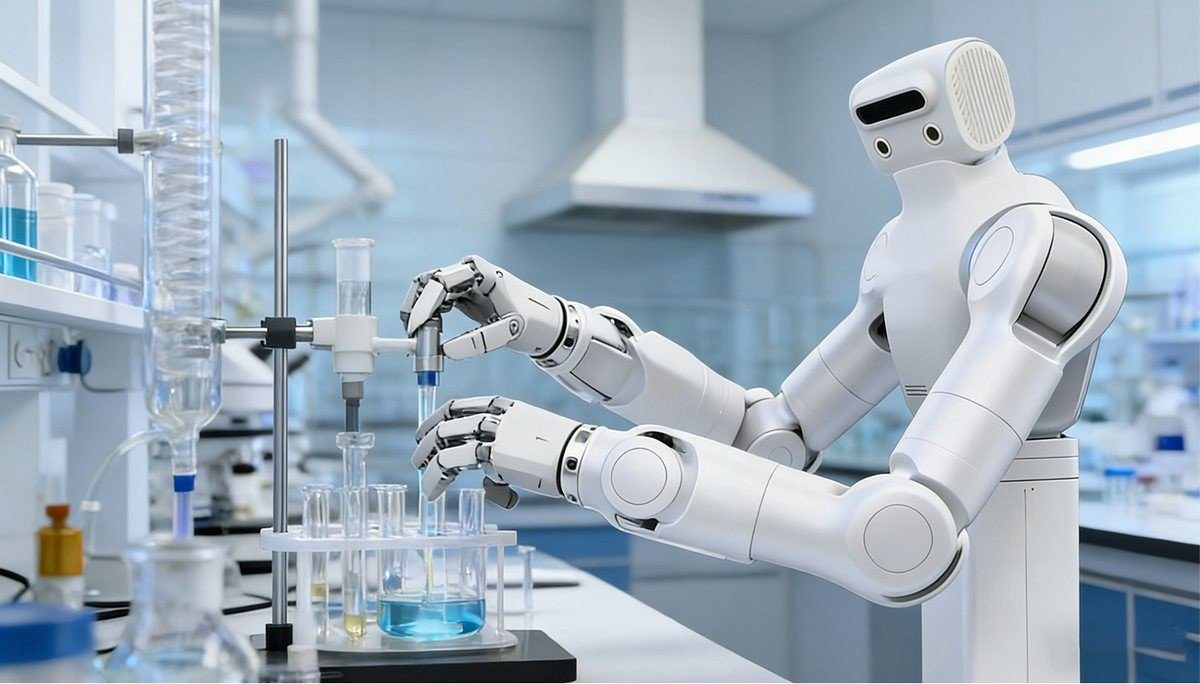
TROY Humanoid Robot is a fully force-controlled dual-arm humanoid robot platform designed for high-precision, fixed-station tasks in industry and research. A rigid stand replaces the conventional mobile chassis, trading mobility for uncompromising stability and accuracy — making the platform ideal for precision flexible assembly, laboratory automation, inspection, and embodied-intelligence research.
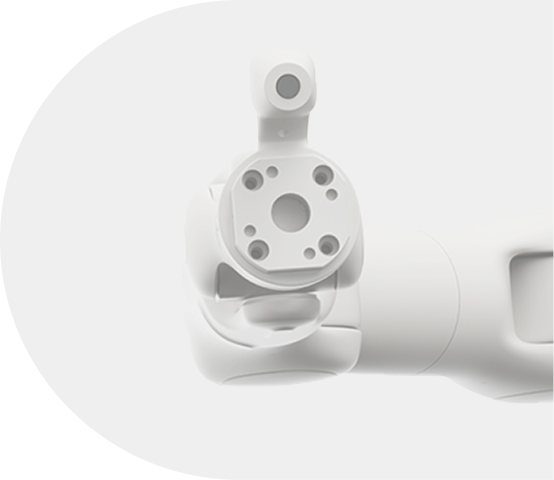
The robot features two 7-DOF arms (14 DOF in total) with joint torque sensors standard on every axis. Repeat positioning accuracy reaches ±0.03 mm and force-control accuracy is up to 0.15 N, with position, impedance and hybrid force-position control modes in the standard controller. Each arm uses an innovative crossed-axis wrist design that eliminates the degree-of-freedom degradation of traditional wrists, achieving biomechanical equivalence to the human wrist for more natural, human-like motion.
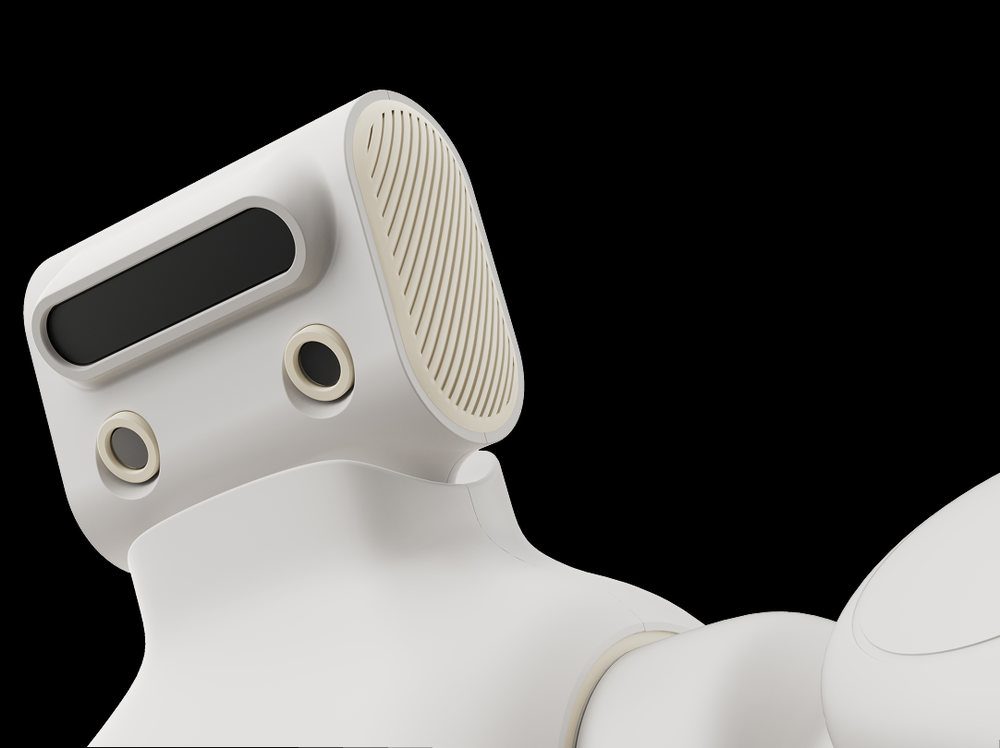
The platform ships fully equipped: a 5-camera panoramic vision system (head: 1× depth camera + 2× RGB cameras; wrists: 2× RGB cameras), an NVIDIA Jetson Orin AGX 64 GB (275 TOPS) computing platform and open ROS2 support — ready for vision-guided operation, data collection and secondary development out of the box. Eight arm models cover rated payloads from 3 kg to 20 kg and working reaches from 615 mm to 1050 mm, so a single controller, SDK and software ecosystem scales across applications.
Core Technology
Joint Torque Sensor
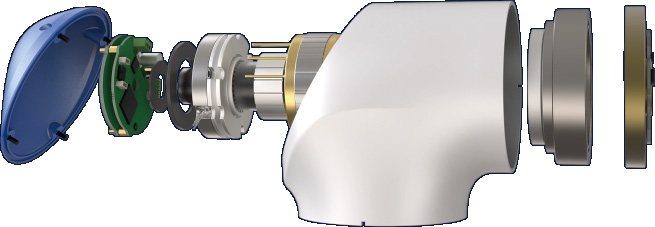
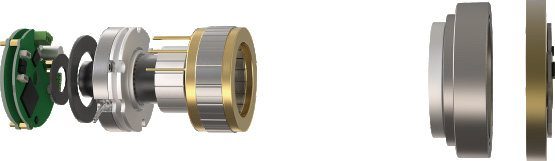
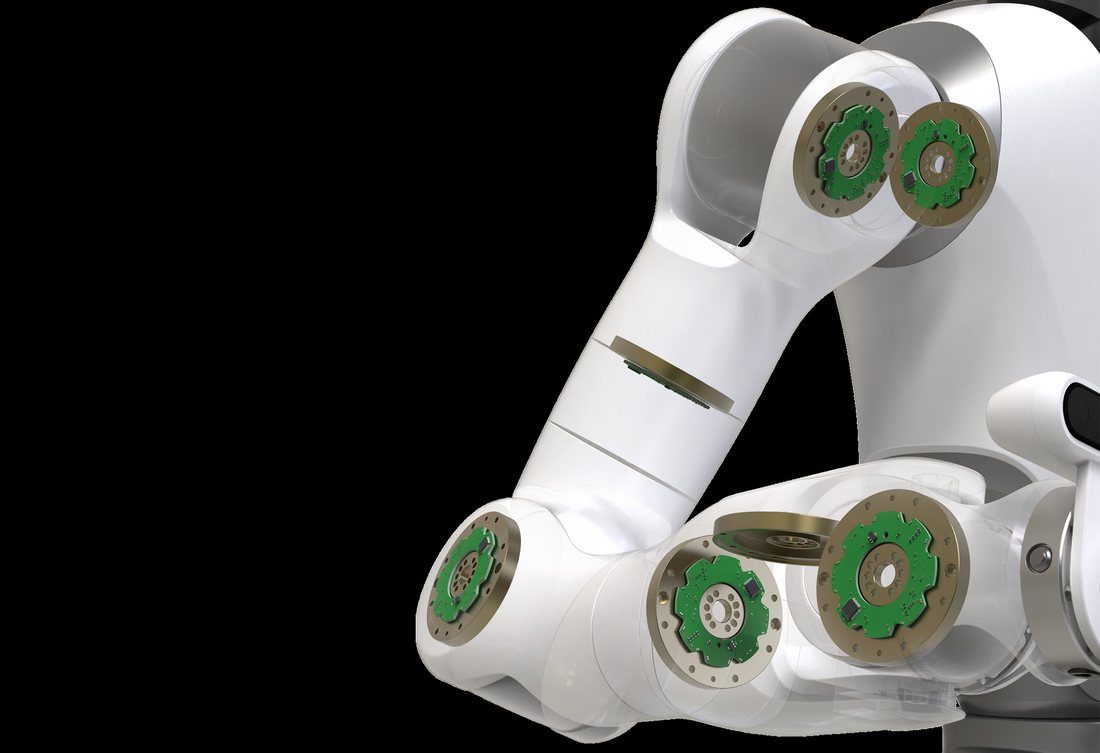
Self-developed joint torque sensors — among the first to integrate MEMS sensing technology into robotic arm joints. MEMS sensors deliver ultra-precise force detection (10× sensitivity); silicon micro-melting technology provides superior stability (4×); and a special steel structure design enhances rigidity and durability (2×).
Lightweight Integrated Joint Module
A modular design enables rapid and efficient arm assembly, and the lightweight structure makes it the lightest force-controlled module in its payload class. The built-in EtherCAT communication driver features four-loop control (position, velocity, torque and current loops) supporting 8 kHz torque closed-loop control directly on the driver. Integrated dual absolute encoders enable full closed-loop control with battery-free zero-point recording, while a built-in friction brake ensures no drift when powered off and no jitter when powered on.
Impedance Control & Dynamic Tracking
With full-body force control and impedance technology, the robot explores the world like a human. In human-robot interaction it exhibits natural compliance, reducing impact forces and enhancing comfort and safety; in unknown environments, impedance control helps the robot adapt to changes and minimizes oscillation and instability caused by external disturbance, improving task efficiency and reliability; in precision flexible assembly, it adjusts flexibly upon contact, preventing damage to the workpiece or to the robot itself.
Product Features
Humanoid Design & Dexterity
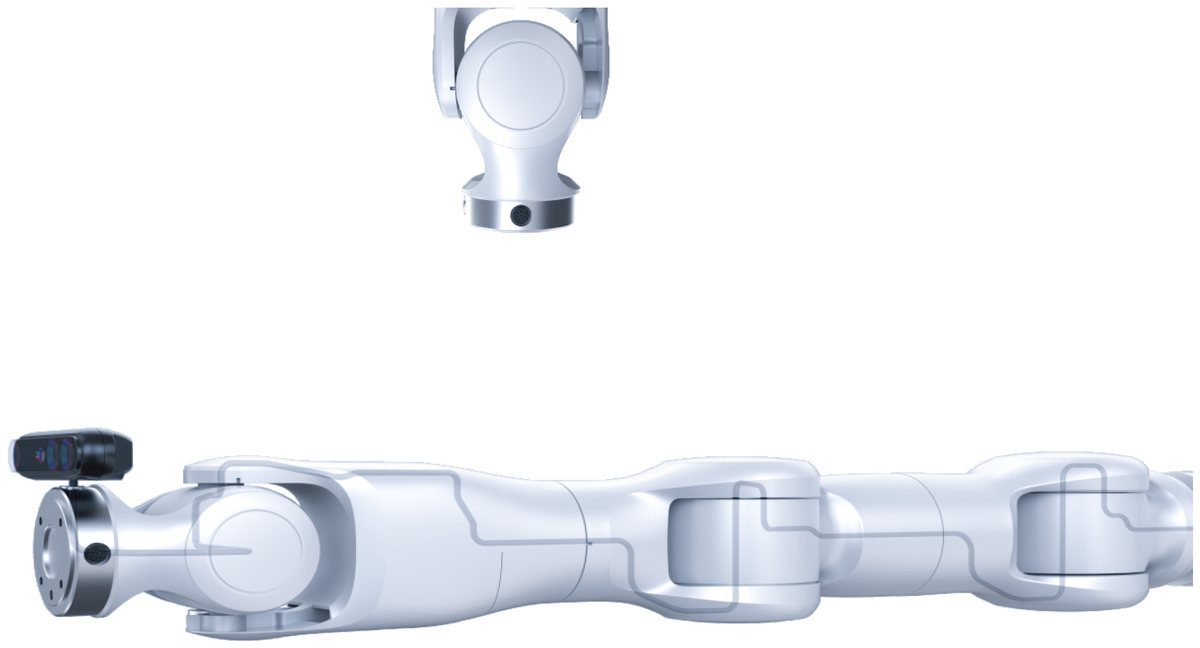
The 7-DOF symmetrical arms move as flexibly and naturally as human arms. The innovative crossed-axis wrist achieves biomechanical equivalence to the human wrist with a smaller rotation radius, making grasping and adjustment movements more natural and teleoperation smoother and more adaptable across diverse scenarios.
Safe & Compliant Interaction
Mỗi khớp nối đều được trang bị cảm biến mô-men xoắn tích hợp, đảm bảo tương tác nhẹ nhàng và an toàn, bảo vệ người dùng và môi trường xung quanh. Kiểm soát toàn bộ lực khớp và bảo vệ va chạm là tiêu chuẩn trên cả hai tay.
Industrial-Grade Performance
Công nghệ bù tuân thủ cải tiến giúp tăng cường đáng kể độ chính xác tuyệt đối. Kết hợp với độ chính xác và độ cứng cấp công nghiệp, robot mang lại hiệu suất vượt trội trong cả ứng dụng thương mại và công nghiệp.
Standard 5-Camera Panoramic Vision
Tất cả các cấu hình đều được trang bị năm camera toàn cảnh — không có điểm mù. Hệ thống này bao gồm nhận thức về môi trường, bản địa hóa toàn cầu, thu thập dữ liệu đám mây điểm, nhận dạng mục tiêu, định vị chính xác bộ phận tác động cuối, kiểm tra phôi và hướng dẫn vận hành bằng trực quan.
Powerful Edge Computing
The robot's brain is built on an NVIDIA Jetson Orin AGX 64 GB platform delivering 275 TOPS, with a 12-core CPU (up to 2.2 GHz) and 1.3 GHz GPU — supporting high-precision vision processing, data collection, deep learning and motion-control algorithms. The open ROS2 framework is supported for plug-and-play, developer-friendly deployment.
Comprehensive SDK & Teleoperation
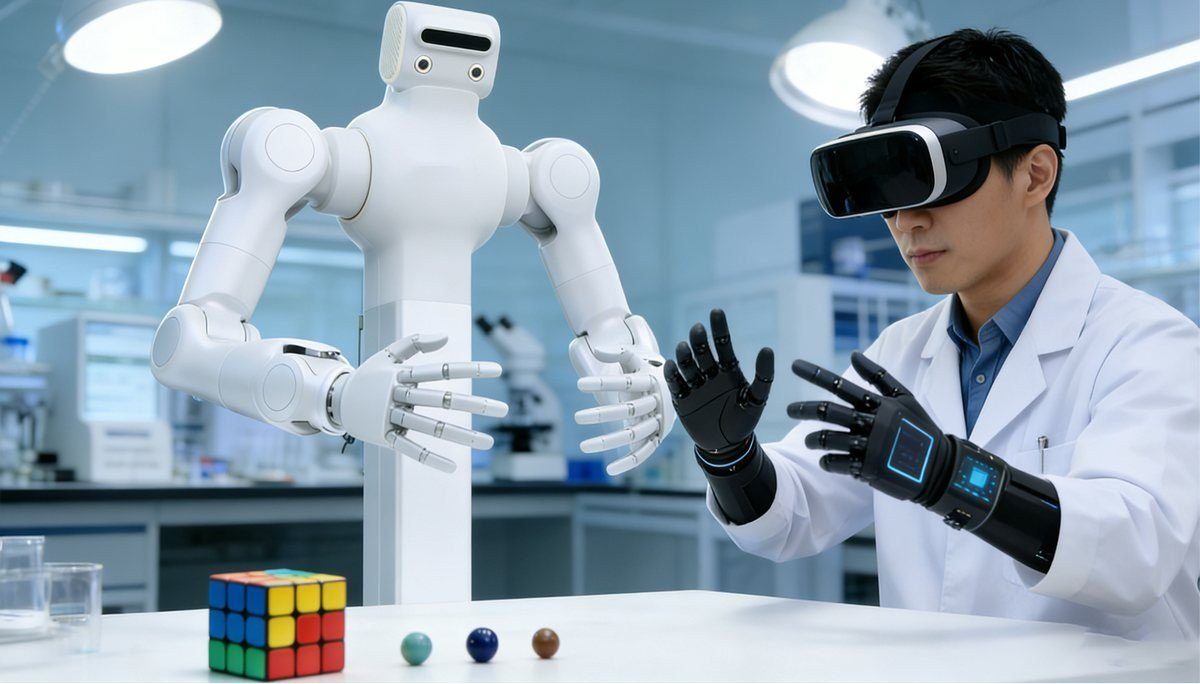
The SDK provides rich functionality, including real-time force-control and position-control interfaces with control frequencies up to 1 kHz, plus advanced algorithms such as dynamics, kinematics, impedance control, payload identification, hybrid force-position control, collision detection, drag-to-teach and dual-arm coordination. Secondary-development interfaces encapsulate complex arm functions into APIs with demo examples for typical applications. The dedicated teleoperation system offers 16 DOF, 500 Hz control and sampling frequency, ≤100 ms end-to-end latency, Ethernet/CAN-FD communication and HDF5/RLDS data formats — ideal for data collection and imitation learning.
Flexible Expansion & Integration
The dual-arm end effectors provide a wide range of communication interfaces (EtherCAT, CAN FD, RS485) plus high-current power output and an 8-pin end connector, making it easy to integrate dexterous hands, 6-axis force/torque sensors and various actuators. A large hollow structure allows internal routing of camera cables and quick integration of stereo-vision systems while avoiding cable damage from environmental contact, and the platform is compatible with various mobility platforms.
Power & Continuous Operation
Nguồn điện trực tiếp (AC 220 V; bộ chuyển đổi có sẵn cho điện áp ở nước ngoài), được thiết kế để hoạt động liên tục 24 giờ mà không cần mô-đun pin. Trọng lượng của robot khoảng 80 kg với không gian làm việc theo chiều dọc là 0,6–1,8 m.
Ứng dụng
Precision flexible assembly, 3C electronics manufacturing, laboratory automation, scientific research and education (embodied intelligence and imitation-learning data collection), quality inspection and human-robot collaboration research.
Technical Specifications
Dual-Arm Robot — Standard Configuration
| Người mẫu | TROY Humanoid Robot (M3 / M6 options) |
| Bậc tự do | 14 DOF (7 DOF × 2 arms) |
| Kiểm soát lực lượng | Full-joint force control, standard; joint torque sensors on all axes |
| Rated payload (per arm) | 3 kg (M3) / 6 kg (M6) |
| Max payload (per arm) | 5 kg (M3) / 10 kg (M6) |
| Working reach (J2 to end flange) | 615 mm (M3) / 695 mm (M6) |
| Lặp lại độ chính xác định vị | ±0.03 mm |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Max joint speed | 180°/s |
| Control modes | Position control, impedance control, hybrid force-position control |
| Communication | 1 kHz EtherCAT |
| Braking | All joints with brakes |
| End-effector interface | RS485, CAN, EtherCAT |
| End 6-axis force/torque sensor | Optional |
| Dexterous hand | Optional |
| Căn cứ | Fixed-height rigid stand (fixed-station platform, no mobile chassis) |
| Vertical working space | 0.6–1.8 m |
| Robot weight | Approx. 80 kg |
| Hệ thống tầm nhìn | 5 cameras standard: head 1× D435 RGBD + 2× RGB; wrists 2× RGB (standard on all models) |
| Computing platform | NVIDIA Jetson Orin AGX 64 GB (275 TOPS); 12-core CPU up to 2.2 GHz; GPU 1.3 GHz |
| Framework | ROS2 supported |
| Teleoperation system | 16 DOF; position + impedance modes; 500 Hz control and sampling; ≤100 ms end-to-end latency; Ethernet / CAN-FD; 2560×720 @ 30 fps; HDF5, RLDS data formats |
| Nguồn điện | AC 220 V direct supply (adapters for overseas voltages); no battery module |
| Continuous operation | 24 hours uninterrupted |
| Communication ports | WiFi, Ethernet |
Arm Model Range (per arm)
| Parameter | TR-M6S SRS-686 | TR-M6S CCS-696 | TR-M6S CCS-809 | TR-M3S Long CCS-920 | TR-M6S Lite CCS-615 | TR-M6S Lite CCS-680 | TR-M6S Lite CCS-750 | TR-M20S CCS-105 |
| Number of joints | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Rated payload | 6 kg | 6 kg | 5 kg | 3 kg | 5 kg | 4 kg | 3 kg | 20 kg |
| Wrist configuration | Traditional collaborative wrist | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis |
| Working reach | 686 mm | 696 mm | 809 mm | 920 mm | 615 mm | 680 mm | 751 mm | 1050 mm |
| Weight (per arm) | 11.45 kg | 12.45 kg | 12.7 kg | 13.1 kg | 8.45 kg | 8.65 kg | 8.8 kg | 30 kg |
| Max TCP speed | 2 m/s | 2 m/s | 2 m/s | 2 m/s | 1.5 m/s | 1.5 m/s | 1.5 m/s | 2 m/s |
| Độ lặp lại | ±0.03 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.1 mm |
| xếp hạng IP | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP65 |
| Brake control | All joints | All joints | All joints | All joints | J1–J4 | J1–J4 | J1–J4 | All joints |
| Tiêu thụ điện năng | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 1000 W avg / 3800 W peak |
| Max joint speed | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 120°/s |
Common Parameters & Certifications
| Joint torque sensors | Standard on all axes |
| Camera cable | Embeddable in end-effector |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Communication | EtherCAT, cycle ≤1 ms |
| Debugging software | PC-based setup & visualization software for 7 axes |
| Encoder | Dual absolute encoders |
| On-board interface (end-effector) | Drag-teach enabling button |
| On-board interface (power) | 24 VDC (rated current 3 A) |
| On-board interface (communication) | RS485, CAN FD, EtherCAT |
| Điện áp hoạt động | 48 V (±10%) |
| Certifications | CE marking, ISO/TS 15066, ISO 13849-1 PLd (Cat. 3), EN 60204-1:2018, EN IEC 61000-6-2, EN IEC 61000-6-4, EN ISO 12100:2010 |
Thông số kỹ thuật có thể thay đổi mà không cần thông báo. Vui lòng liên hệ với nhóm bán hàng của chúng tôi để có bảng dữ liệu, bản vẽ và tùy chọn cấu hình mới nhất.
Dữ liệu kỹ thuật đầy đủ
| Người mẫu | TR-M |
|---|---|
| Tải trọng | 20 kg |
| Với tới | 0.03 mm |
| Sức chịu đựng | ±0.03 mm |
| Loại | Robot AI & hình người |
| thời gian dẫn | 45 ngày |
Các giá trị danh nghĩa ở 20°C. Tải xuống bảng dữ liệu cho các mô hình cad, đường cong mô-men xoắn và bản đồ I/O của bộ điều khiển.
Nó chạy ở đâu
Được xác định kích thước và ủy quyền bởi các kỹ sư TROY.
Được xác định kích thước và ủy quyền bởi các kỹ sư TROY.
Được xác định kích thước và ủy quyền bởi các kỹ sư TROY.
Được xác định kích thước và ủy quyền bởi các kỹ sư TROY.
Câu hỏi của người mua
Các thông số kỹ thuật chính là gì?
Model: TR-M, Tải trọng: 20 kg, Tầm với: 0,03 mm.
Thời gian dẫn đầu là gì?
45 ngày đối với cấu hình tiêu chuẩn; xác nhận tại báo giá.
Nó có thể được tùy chỉnh?
Có - Các tùy chọn OEM/ODM, điện áp, dụng cụ và nhãn hiệu có thể được điều chỉnh. Gửi đơn đăng ký và mục tiêu đầu ra cho một đề xuất.
Nhận đề xuất giá cho TR-M
Bao gồm phần, tỷ lệ mục tiêu và cổng đích. Một kỹ sư – không phải chatbot – sẽ trả lời trong vòng 48 giờ.
Cùng danh mục

Robot hình người hai cánh tay có bánh xe

Robot dịch vụ gấu trúc phỏng sinh học
Robot hình người có bánh xe
Được đánh giá bởi TROY Engineering ·. Các thông số kỹ thuật được kiểm tra lại dựa trên bảng dữ liệu của nhà cung cấp ở mỗi báo giá.