



Двурукий робот-гуманоид
TR-M — робот-гуманоид для исследования/приема. Основные характеристики: Полезная нагрузка 20 кг; Достигают 0,03 мм; Допуск ±0,03 мм. Срок выполнения 45 дней; Цена указана за конфигурацию. Сертификаты: Документация CE по запросу.
- Модель
- ТР-М
- Полезная нагрузка
- 20 kg
- Вылет
- 0.03 mm
- Толерантность
- ±0.03 mm
- Категория
- ИИ и роботы-гуманоиды
- Время выполнения
- 45 дней
Для чего нужна эта платформа
TROY Робот-гуманоид с двумя руками: 14 степеней свободы, полный контроль усилия суставов с помощью датчиков крутящего момента суставов MEMS, повторяемость +/- 0,03 мм, варианты полезной нагрузки 3–20 кг, 5-камерное зрение, NVIDIA Jetson Orin AGX 275 TOPS, ROS2.
Коммерческие условия
| Предложение | Цена указана за конфигурацию — ответ в течение 48 часов. |
|---|---|
| Время выполнения | 45 дней |
| минимальный заказ | 1 единица |
| Источник | Китай |
| Порт погрузки | Шэньчжэнь, Китай |
| Инкотермс | FOB Шэньчжэнь/CIF по запросу |
| Оплата | 30% депозит, 70% перед отправкой |
| Гарантия | 24 месяца стандартно, 36 месяцев опционально |
Подробности о продукте
Рекомендации по применению, строительные чертежи и видео из инженерного файла TROY — та же документация, которая поставляется вместе с предложением.
AI Robot Introduction:
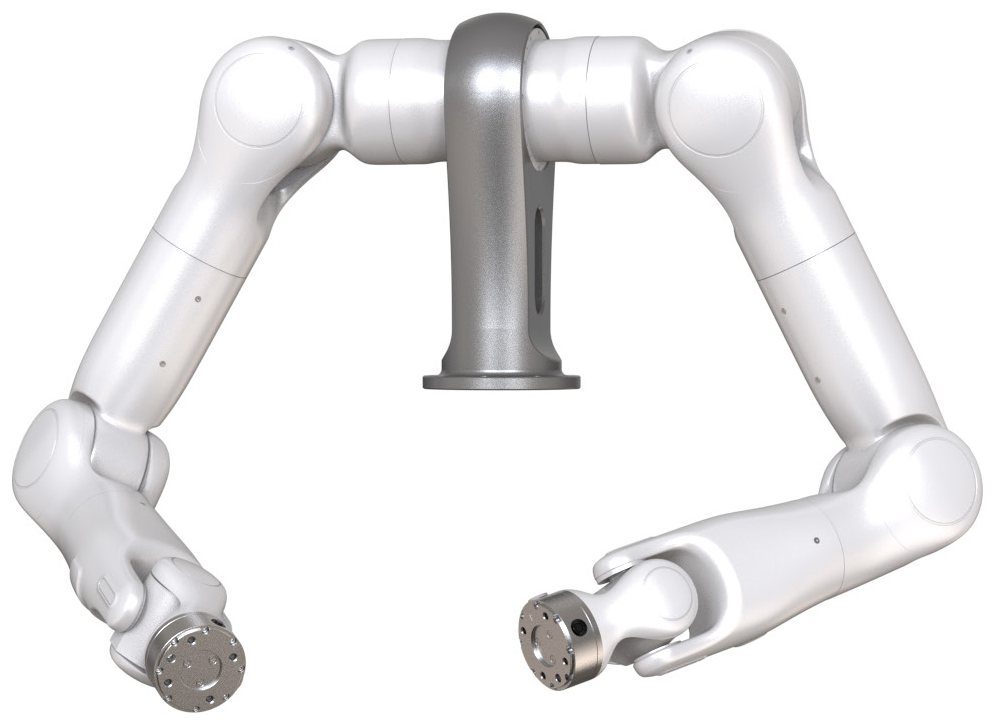
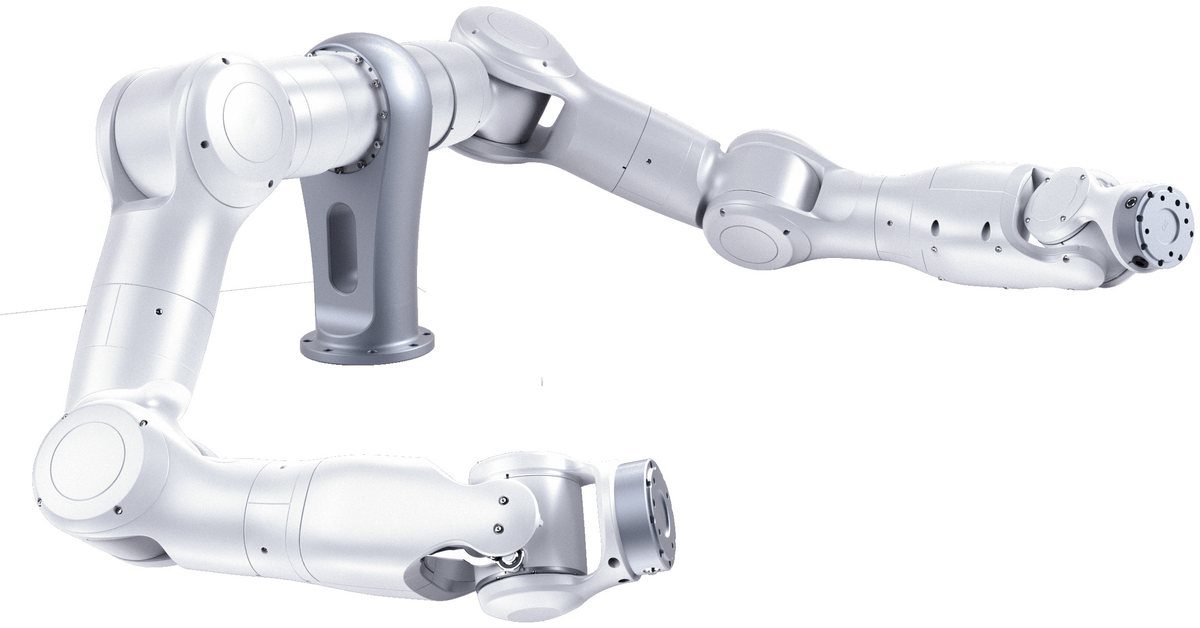
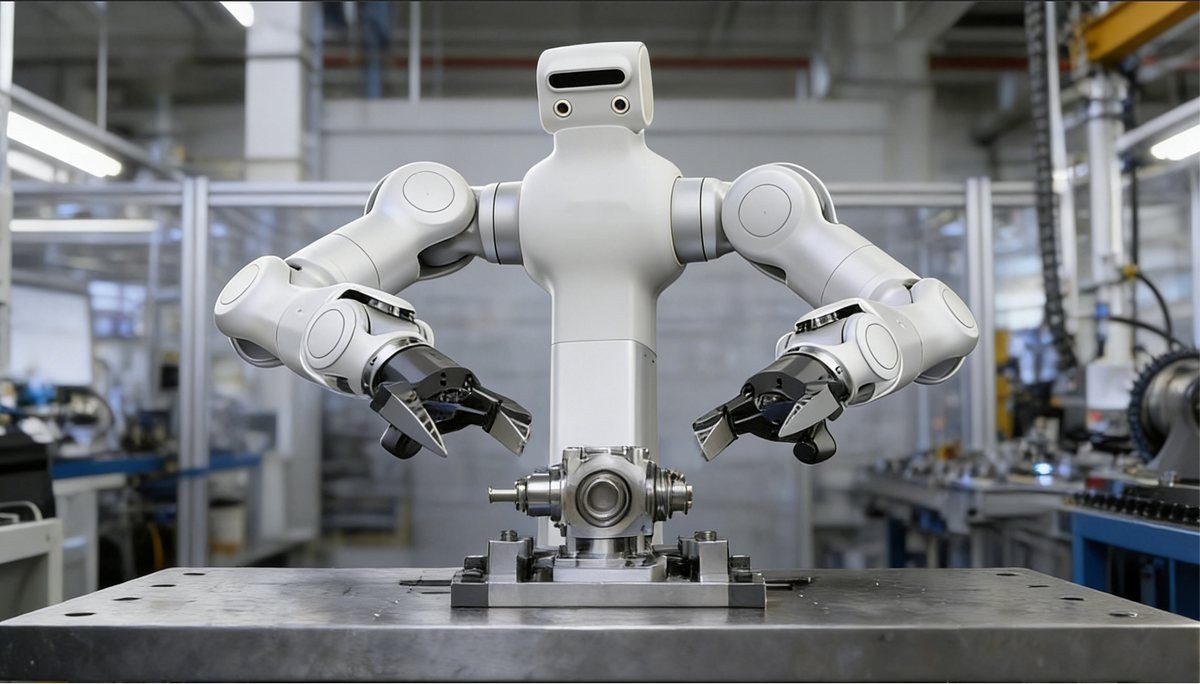
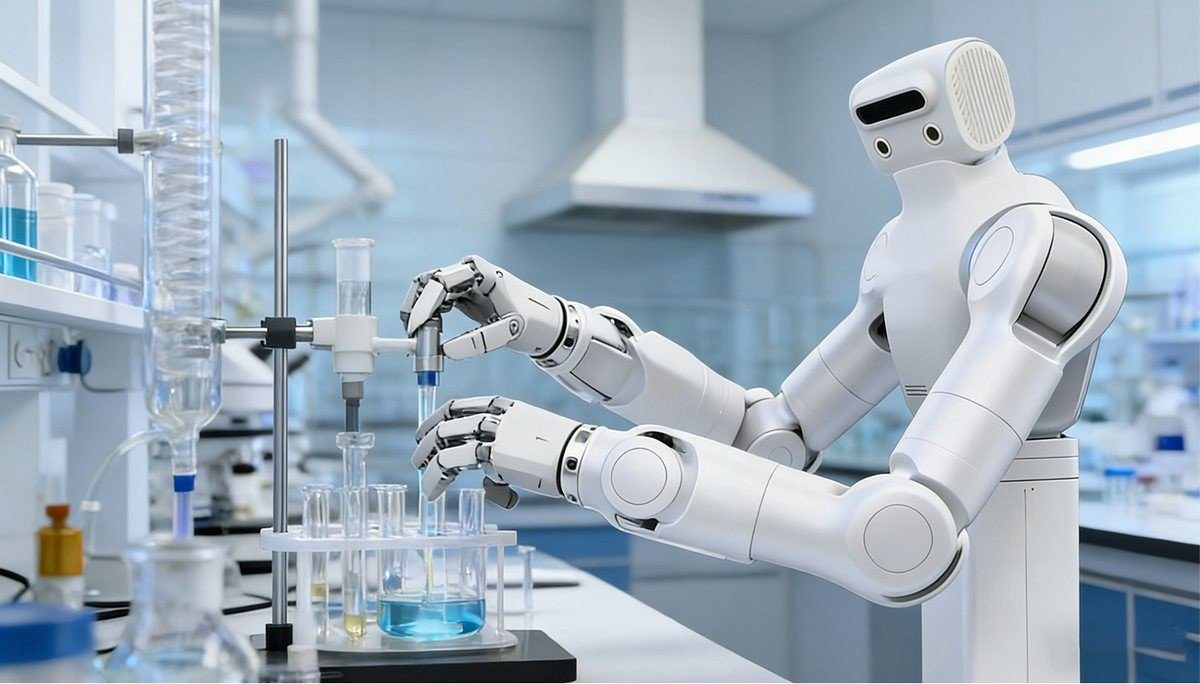
TROY Humanoid Robot is a fully force-controlled dual-arm humanoid robot platform designed for high-precision, fixed-station tasks in industry and research. A rigid stand replaces the conventional mobile chassis, trading mobility for uncompromising stability and accuracy — making the platform ideal for precision flexible assembly, laboratory automation, inspection, and embodied-intelligence research.
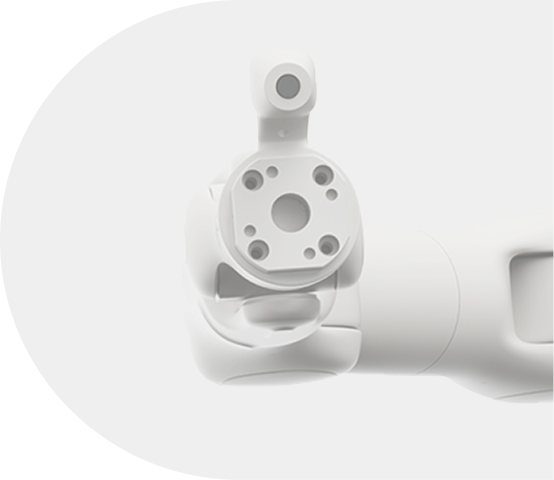
The robot features two 7-DOF arms (14 DOF in total) with joint torque sensors standard on every axis. Repeat positioning accuracy reaches ±0.03 mm and force-control accuracy is up to 0.15 N, with position, impedance and hybrid force-position control modes in the standard controller. Each arm uses an innovative crossed-axis wrist design that eliminates the degree-of-freedom degradation of traditional wrists, achieving biomechanical equivalence to the human wrist for more natural, human-like motion.
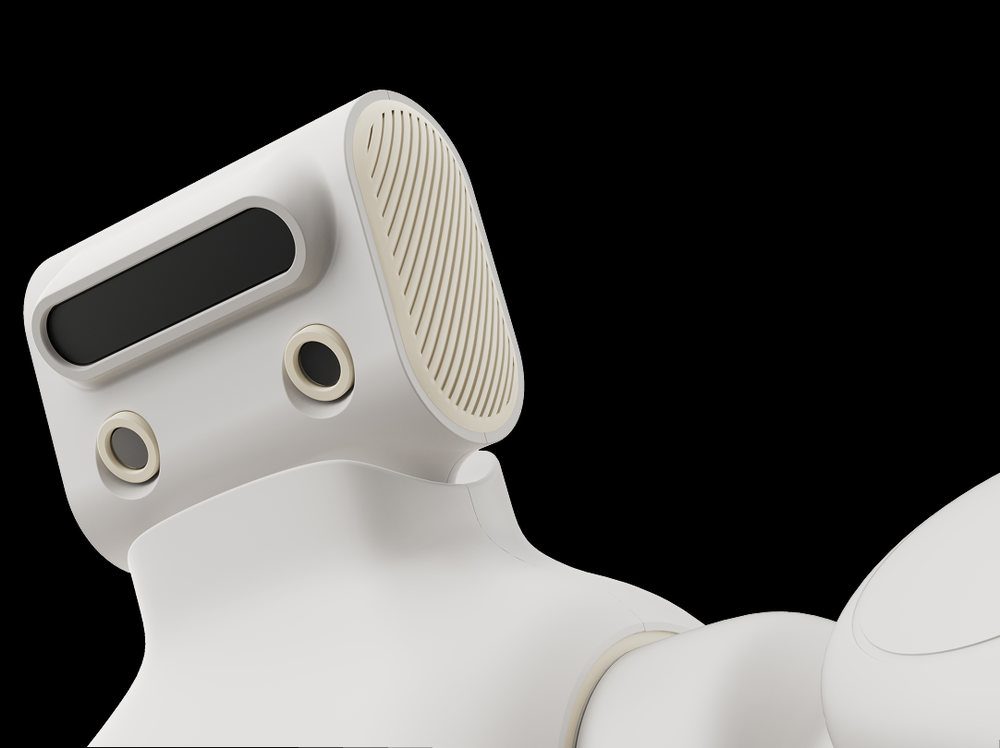
The platform ships fully equipped: a 5-camera panoramic vision system (head: 1× depth camera + 2× RGB cameras; wrists: 2× RGB cameras), an NVIDIA Jetson Orin AGX 64 GB (275 TOPS) computing platform and open ROS2 support — ready for vision-guided operation, data collection and secondary development out of the box. Eight arm models cover rated payloads from 3 kg to 20 kg and working reaches from 615 mm to 1050 mm, so a single controller, SDK and software ecosystem scales across applications.
Core Technology
Joint Torque Sensor
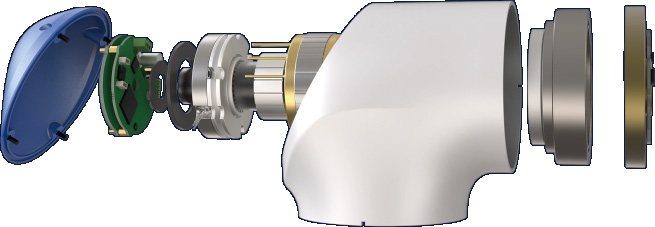
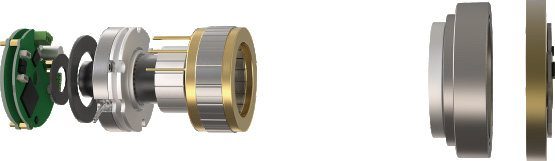
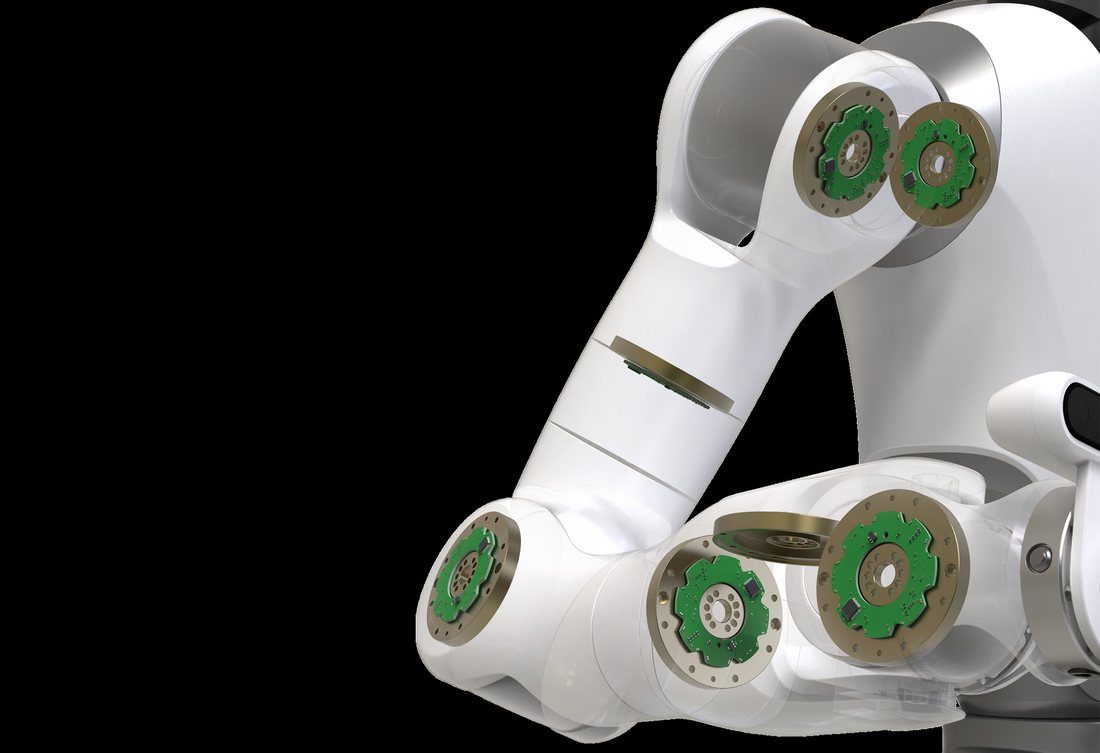
Self-developed joint torque sensors — among the first to integrate MEMS sensing technology into robotic arm joints. MEMS sensors deliver ultra-precise force detection (10× sensitivity); silicon micro-melting technology provides superior stability (4×); and a special steel structure design enhances rigidity and durability (2×).
Lightweight Integrated Joint Module
A modular design enables rapid and efficient arm assembly, and the lightweight structure makes it the lightest force-controlled module in its payload class. The built-in EtherCAT communication driver features four-loop control (position, velocity, torque and current loops) supporting 8 kHz torque closed-loop control directly on the driver. Integrated dual absolute encoders enable full closed-loop control with battery-free zero-point recording, while a built-in friction brake ensures no drift when powered off and no jitter when powered on.
Impedance Control & Dynamic Tracking
With full-body force control and impedance technology, the robot explores the world like a human. In human-robot interaction it exhibits natural compliance, reducing impact forces and enhancing comfort and safety; in unknown environments, impedance control helps the robot adapt to changes and minimizes oscillation and instability caused by external disturbance, improving task efficiency and reliability; in precision flexible assembly, it adjusts flexibly upon contact, preventing damage to the workpiece or to the robot itself.
Product Features
Humanoid Design & Dexterity
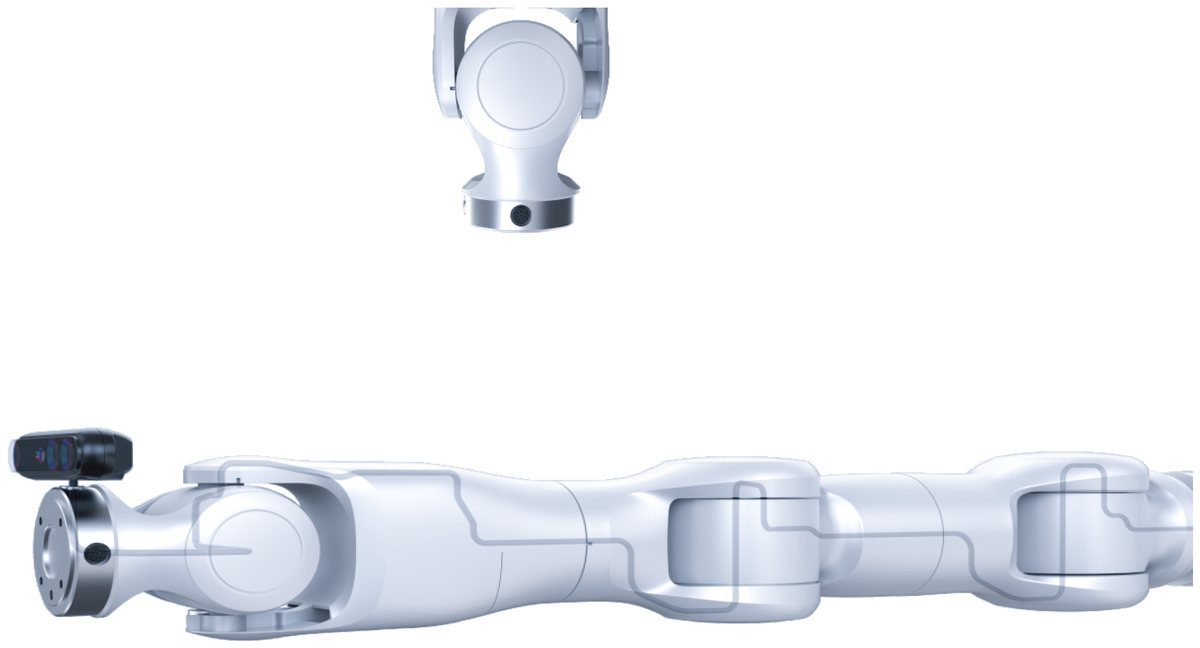
The 7-DOF symmetrical arms move as flexibly and naturally as human arms. The innovative crossed-axis wrist achieves biomechanical equivalence to the human wrist with a smaller rotation radius, making grasping and adjustment movements more natural and teleoperation smoother and more adaptable across diverse scenarios.
Safe & Compliant Interaction
Каждое соединение оснащено встроенным датчиком крутящего момента, обеспечивающим мягкое и безопасное взаимодействие, защищающее пользователей и окружающую среду. Полный контроль силы суставов и защита от столкновений входят в стандартную комплектацию обеих рук.
Industrial-Grade Performance
Инновационная технология компенсации соответствия значительно повышает абсолютную точность. В сочетании с точностью и жесткостью промышленного уровня робот обеспечивает выдающуюся производительность как в коммерческих, так и в промышленных целях.
Standard 5-Camera Panoramic Vision
Все конфигурации поставляются с пятью панорамными камерами — никаких слепых зон. Система охватывает восприятие окружающей среды, глобальную локализацию, сбор облаков точек, распознавание целей, точное позиционирование конечного рабочего органа, проверку заготовки и визуальное руководство работой.
Powerful Edge Computing
The robot's brain is built on an NVIDIA Jetson Orin AGX 64 GB platform delivering 275 TOPS, with a 12-core CPU (up to 2.2 GHz) and 1.3 GHz GPU — supporting high-precision vision processing, data collection, deep learning and motion-control algorithms. The open ROS2 framework is supported for plug-and-play, developer-friendly deployment.
Comprehensive SDK & Teleoperation
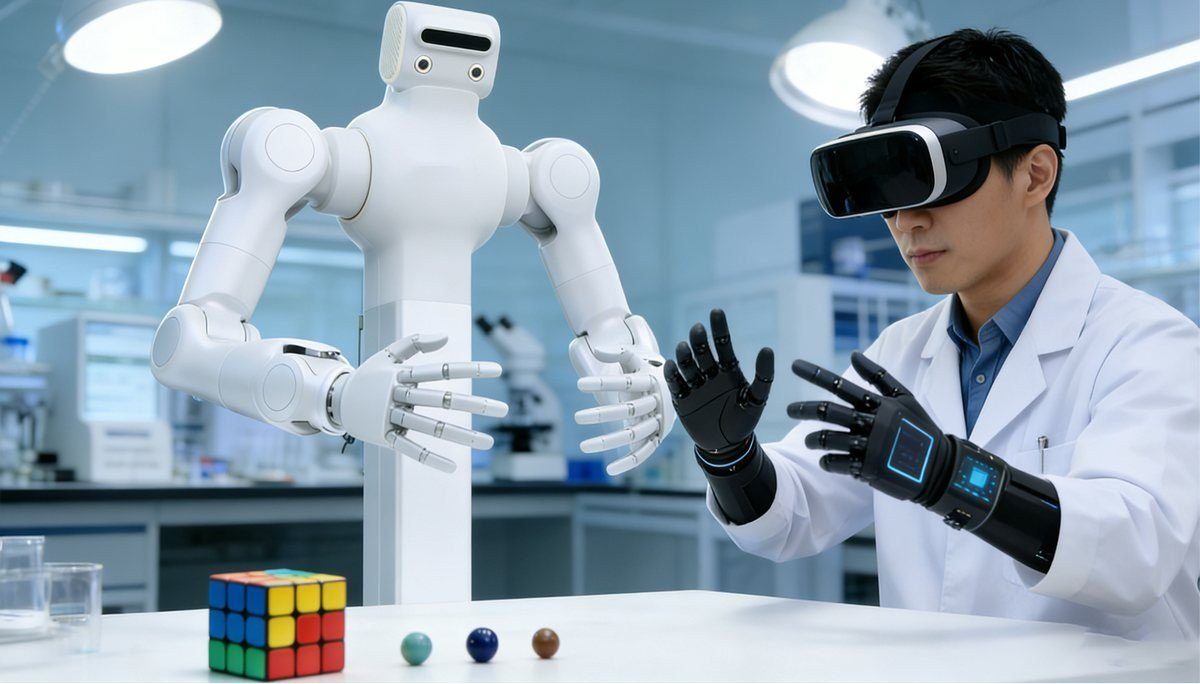
The SDK provides rich functionality, including real-time force-control and position-control interfaces with control frequencies up to 1 kHz, plus advanced algorithms such as dynamics, kinematics, impedance control, payload identification, hybrid force-position control, collision detection, drag-to-teach and dual-arm coordination. Secondary-development interfaces encapsulate complex arm functions into APIs with demo examples for typical applications. The dedicated teleoperation system offers 16 DOF, 500 Hz control and sampling frequency, ≤100 ms end-to-end latency, Ethernet/CAN-FD communication and HDF5/RLDS data formats — ideal for data collection and imitation learning.
Flexible Expansion & Integration
The dual-arm end effectors provide a wide range of communication interfaces (EtherCAT, CAN FD, RS485) plus high-current power output and an 8-pin end connector, making it easy to integrate dexterous hands, 6-axis force/torque sensors and various actuators. A large hollow structure allows internal routing of camera cables and quick integration of stereo-vision systems while avoiding cable damage from environmental contact, and the platform is compatible with various mobility platforms.
Power & Continuous Operation
Прямое питание от сети (220 В переменного тока; доступны адаптеры для зарубежного напряжения), рассчитанное на 24-часовую бесперебойную работу без батарейного модуля. Вес робота составляет около 80 кг при высоте рабочего пространства 0,6–1,8 м.
Применения
Precision flexible assembly, 3C electronics manufacturing, laboratory automation, scientific research and education (embodied intelligence and imitation-learning data collection), quality inspection and human-robot collaboration research.
Technical Specifications
Dual-Arm Robot — Standard Configuration
| Модель | TROY Humanoid Robot (M3 / M6 options) |
| Степени свободы | 14 DOF (7 DOF × 2 arms) |
| Силовое управление | Full-joint force control, standard; joint torque sensors on all axes |
| Rated payload (per arm) | 3 kg (M3) / 6 kg (M6) |
| Max payload (per arm) | 5 kg (M3) / 10 kg (M6) |
| Working reach (J2 to end flange) | 615 mm (M3) / 695 mm (M6) |
| Повторите точность позиционирования | ±0.03 mm |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Max joint speed | 180°/s |
| Control modes | Position control, impedance control, hybrid force-position control |
| Communication | 1 kHz EtherCAT |
| Braking | All joints with brakes |
| End-effector interface | RS485, CAN, EtherCAT |
| End 6-axis force/torque sensor | Optional |
| Dexterous hand | Optional |
| База | Fixed-height rigid stand (fixed-station platform, no mobile chassis) |
| Vertical working space | 0.6–1.8 m |
| Robot weight | Approx. 80 kg |
| Система обзора | 5 cameras standard: head 1× D435 RGBD + 2× RGB; wrists 2× RGB (standard on all models) |
| Computing platform | NVIDIA Jetson Orin AGX 64 GB (275 TOPS); 12-core CPU up to 2.2 GHz; GPU 1.3 GHz |
| Framework | ROS2 supported |
| Teleoperation system | 16 DOF; position + impedance modes; 500 Hz control and sampling; ≤100 ms end-to-end latency; Ethernet / CAN-FD; 2560×720 @ 30 fps; HDF5, RLDS data formats |
| Источник питания | AC 220 V direct supply (adapters for overseas voltages); no battery module |
| Continuous operation | 24 hours uninterrupted |
| Communication ports | WiFi, Ethernet |
Arm Model Range (per arm)
| Parameter | TR-M6S SRS-686 | TR-M6S CCS-696 | TR-M6S CCS-809 | TR-M3S Long CCS-920 | TR-M6S Lite CCS-615 | TR-M6S Lite CCS-680 | TR-M6S Lite CCS-750 | TR-M20S CCS-105 |
| Number of joints | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Rated payload | 6 kg | 6 kg | 5 kg | 3 kg | 5 kg | 4 kg | 3 kg | 20 kg |
| Wrist configuration | Traditional collaborative wrist | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis | Crossed-axis |
| Working reach | 686 mm | 696 mm | 809 mm | 920 mm | 615 mm | 680 mm | 751 mm | 1050 mm |
| Weight (per arm) | 11.45 kg | 12.45 kg | 12.7 kg | 13.1 kg | 8.45 kg | 8.65 kg | 8.8 kg | 30 kg |
| Max TCP speed | 2 m/s | 2 m/s | 2 m/s | 2 m/s | 1.5 m/s | 1.5 m/s | 1.5 m/s | 2 m/s |
| Повторяемость | ±0.03 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.03 mm | ±0.04 mm | ±0.04 mm | ±0.1 mm |
| IP-рейтинг | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP50 | IP65 |
| Brake control | All joints | All joints | All joints | All joints | J1–J4 | J1–J4 | J1–J4 | All joints |
| Потребляемая мощность | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 400 W avg / 600 W peak | 1000 W avg / 3800 W peak |
| Max joint speed | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 180°/s | 120°/s |
Common Parameters & Certifications
| Joint torque sensors | Standard on all axes |
| Camera cable | Embeddable in end-effector |
| Force-control accuracy | ≤0.15 N, ≤0.05 N·m |
| Communication | EtherCAT, cycle ≤1 ms |
| Debugging software | PC-based setup & visualization software for 7 axes |
| Encoder | Dual absolute encoders |
| On-board interface (end-effector) | Drag-teach enabling button |
| On-board interface (power) | 24 VDC (rated current 3 A) |
| On-board interface (communication) | RS485, CAN FD, EtherCAT |
| Рабочее напряжение | 48 V (±10%) |
| Certifications | CE marking, ISO/TS 15066, ISO 13849-1 PLd (Cat. 3), EN 60204-1:2018, EN IEC 61000-6-2, EN IEC 61000-6-4, EN ISO 12100:2010 |
Технические характеристики могут быть изменены без предварительного уведомления. Пожалуйста, свяжитесь с нашим отделом продаж для получения последних технических характеристик, чертежей и вариантов конфигурации.
Полные технические данные
| Модель | ТР-М |
|---|---|
| Полезная нагрузка | 20 kg |
| Вылет | 0.03 mm |
| Толерантность | ±0.03 mm |
| Категория | ИИ и роботы-гуманоиды |
| Время выполнения | 45 дней |
Значения являются номинальными при 20 °C. Загрузите техническое описание моделей CAD, кривых крутящего момента и карт ввода-вывода контроллера.
Где он работает
Размеры и заказ инженеров TROY.
Размеры и заказ инженеров TROY.
Размеры и заказ инженеров TROY.
Размеры и заказ инженеров TROY.
Вопросы покупателя
Каковы ключевые характеристики?
Модель: TR-M, Грузоподъемность: 20 кг, Вылет: 0,03 мм.
Каково время выполнения?
45 дней для стандартной конфигурации; подтверждено по котировке.
Можно ли его настроить?
Да — опции OEM/ODM, напряжение, инструменты и брендинг могут быть адаптированы. Отправьте заявку и укажите целевой результат для предложения.
Получить ценовое предложение на ТР-М
Укажите деталь, целевую скорость и порт назначения. Инженер, а не чат-бот, отвечает в течение 48 часов.
Та же категория

Колесный двурукий робот-гуманоид

Биомиметический сервисный робот-панда
Колесный робот-гуманоид
Отзыв от TROY Engineering ·. Спецификации повторно проверяются по данным поставщика при каждом предложении.