


ล่าสุดหุ่นยนต์ร่วมมือแบบแขนเดียวในซีรีส์ ABBYuMi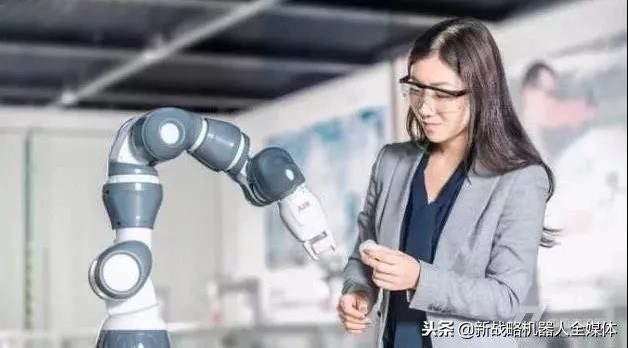 หุ่นยนต์รุ่นใหม่ที่ ABB เปิดตัวนี้มีน้ำหนักบรรทุก 500 กรัม การออกแบบที่กะทัดรัดสูงทำให้สามารถรวมเข้ากับสายการประกอบที่มีอยู่ เพื่อช่วยลูกค้าปรับปรุงประสิทธิภาพการผลิต
The robot also has a guided programming function, so the operator does not need to receive additional professional training. This new YuMi series single-arm collaborative robot will be officially released in 2018, and will work with ABB Ability digital solutions to help customers increase production efficiency and reliability to new heights.หุ่นยนต์น้ำหนักเบา KUKA LBRiiwa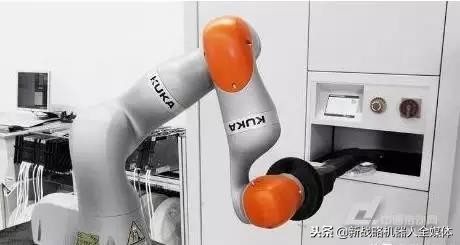 KUKALBRiiwa เป็นหุ่นยนต์ที่มีความละเอียดอ่อนที่ผลิตจำนวนมากตัวแรก และยังเป็นหุ่นยนต์ที่มีความสามารถในการทำงานร่วมกันระหว่างมนุษย์กับเครื่องจักรอีกด้วย
LBR stands for "light robot", iiwa stands for "intelligent industrial work assistant", that is, intelligent industrial work assistant. LBRiiwa has two models to choose from, the load capacity is 7 and 14kg respectively. LBRiiwa can immediately recognize contact through joint torque sensors and immediately reduce force and speed. It handles sensitive workpieces through position and buffer control without any parts that can cause pinching or shearing.ฟานัค CR-35iA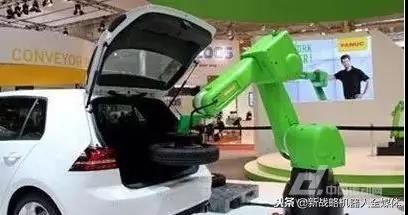 ซีอาร์-35ไอเอหุ่นยนต์ทำงานร่วมกันเป็นหุ่นยนต์ร่วมปฏิบัติงานใหม่ล่าสุดที่ FANUC เปิดตัวในปี 2558 โดยมีน้ำหนักบรรทุก 35 กก. ซึ่งถือเป็นหุ่นยนต์ร่วมปฏิบัติงานที่ใหญ่ที่สุดในโลกในปัจจุบัน
หุ่นยนต์ตัวนี้ไม่จำเป็นต้องมีรั้วนิรภัย และมนุษย์และหุ่นยนต์สามารถใช้พื้นที่ร่วมกันในการทำงานได้
การใช้ CR-35iA และการทำงานแบบแมนนวลร่วมกันสามารถนำไปใช้ในอุตสาหกรรมยานยนต์ บรรจุภัณฑ์ และอุตสาหกรรมอื่นๆ คู่มือนี้ปลอดจากงานหนักแต่เรียบง่ายเพื่อให้คุณสามารถมุ่งเน้นไปที่งานที่ต้องใช้ทักษะและปรับปรุงความปลอดภัยของแรงงาน ปรับปรุงประสิทธิภาพของระบบคาวาซากิ หุ่นยนต์สองแขน duAro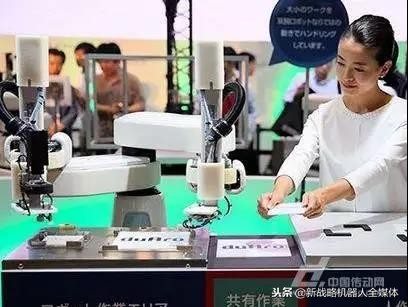 ร่างกายมนุษย์ของเครื่องจักร duAro มีแขนหุ่นยนต์ 2 แขนที่ยื่นออกไปในแนวนอนจากร่างกาย และแขนหุ่นยนต์ 2 แขนทำงานเป็นคู่
It can be installed in the space equivalent to a worker, and can replace the work performed by the worker with both arms. In addition, it can also work with workers. When a worker collides with the robot, the robot can be stopped through the collision detection function. During specific operations, the current flowing through the built-in motor in the robotic arm will be monitored. When an abnormal value is detected, it will be judged as a collision and stop the robotic arm.
นอกจากนี้ ในแง่ของวิธีการสอน นอกเหนือจากการสอนโดยตรงโดยให้ผู้ปฏิบัติงานขยับแขนหุ่นยนต์เพื่อสอนจริงแล้ว ยังสามารถสอนโดยใช้คอมพิวเตอร์แท็บเล็ตหรือสิ่งที่คล้ายกันได้อีกด้วย
MotoMINI หุ่นยนต์ขนาดเล็กตัวใหม่ของ Yaskawa Electric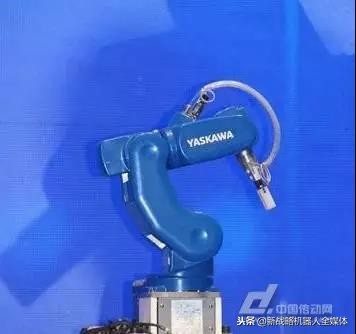 Yaskawa Electric MotoMINI เป็นรถระดับโลกหุ่นยนต์อุตสาหกรรมขนาดเล็ก 6 แกน. MotoMINI สามารถเปลี่ยนตำแหน่งการจัดวางได้ง่ายและตระหนักถึงความเป็นอิสระในระดับสูง เช่น การทำงานร่วมกันระหว่างคนกับเครื่องจักร
It is used for the assembly and operation of small parts, as well as the electronic and electrical parts. And insert etc. MotoMINI has three major characteristics: small and light, high speed and high precision. MotoMINI can carry 500g, the maximum extension distance is 350mm, and the weight is about 7kg. The robot has realized the possibility of producing and processing small products by small portable robots.AURA หุ่นยนต์ร่วมมือมนุษย์-หุ่นยนต์ Comau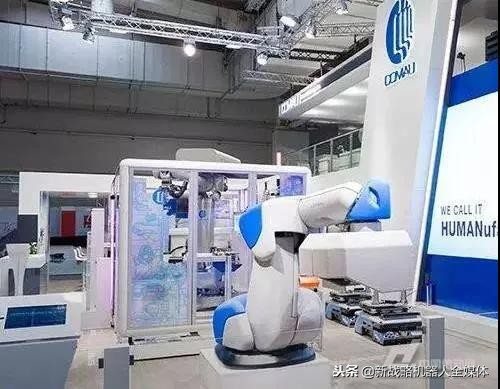 เป็นครั้งแรกที่ AURA หุ่นยนต์ร่วมปฏิบัติงานระหว่างมนุษย์และหุ่นยนต์ของ Comau ผสานรวมการรับรู้ทั่วไปหลายประสาทสัมผัสเกี่ยวกับความใกล้ชิดและการสัมผัสกันของผู้คนหรือส่วนประกอบอัตโนมัติอื่น ๆ และความเข้มข้นของการสัมผัส
เมื่อใช้ร่วมกับการใช้เครื่องสแกนเลเซอร์เพื่อระบุตำแหน่งของบุคคลแบบไดนามิก หุ่นยนต์จะชะลอความเร็วลงเมื่อเข้าใกล้หรือสัมผัสผู้ปฏิบัติงานจริงๆ จนกระทั่งหุ่นยนต์หยุดสนิท เมื่อสัมผัส AURA ก็สามารถตอบสนองความต้องการของผู้ปฏิบัติงานได้เช่นกัน
ตัวควบคุมหุ่นยนต์ยังผสานรวมกับระบบการมองเห็น ซึ่งส่งข้อมูลเกี่ยวกับระยะห่างระหว่างผู้คนไปยังพื้นที่ปฏิบัติการของหุ่นยนต์ และซอฟต์แวร์เฉพาะจะคาดการณ์การกระทำต่อไปของบุคคล จากนั้นจึงเปลี่ยนวิถีการเคลื่อนที่ของหุ่นยนต์ตามนั้น
หุ่นยนต์ข้อต่อ Xinsong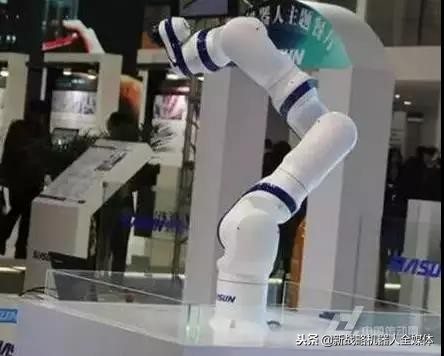 The Sinsong multi-joint robot is the first domestic 7-DOF collaborative robot. It has functions such as rapid configuration, traction teaching, visual guidance, and collision detection. It has the powerful advantages of high load and low cost, and satisfies users' short return on investment cycle and robots.
Product safety, flexibility and human-machine collaboration requirements. It is suitable for flexible production lines with compact layout and high accuracy to meet the needs of industrial operations such as precision assembly, product packaging, grinding, testing, and loading and unloading of machine tools.
หุ่นยนต์ร่วมมือมนุษย์และเครื่องจักร Elfin ของ Han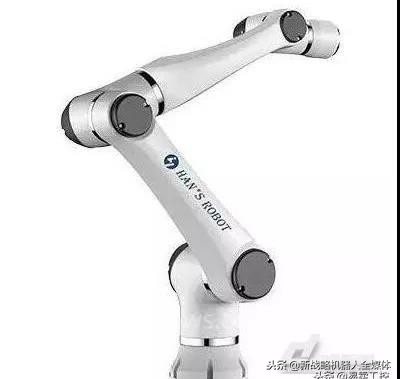 This man-machine collaborative robot named "Elfin" adopts a unique dual-joint modular structure design, which is convenient for assembly and maintenance. The appearance is novel and smooth. The EtherCAT bus is used to communicate between the controller and each shutdown, and it can still have very good anti-interference performance under the control frequency of 10KHz.
การออกแบบที่มีความแข็งแกร่งสูงช่วยให้สามารถทำซ้ำได้ถึง ±0.03 มม. ซึ่งสามารถใช้ในสถานการณ์การทำงาน เช่น สายผลิตภัณฑ์ระบบอัตโนมัติแบบบูรณาการ การเชื่อม การขัดเงา การประกอบ การหยิบ และการทาสีUniversal Robot UR10 หุ่นยนต์ร่วมมือระหว่างมนุษย์และเครื่องจักร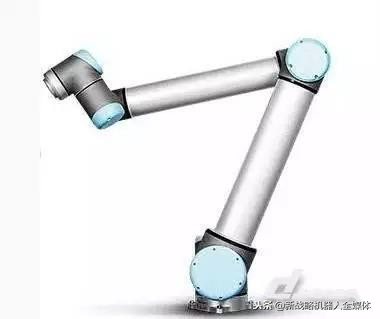 Universal Robots UR10 ได้รับการออกแบบสำหรับงานขนาดใหญ่ที่ยังคงมีความต้องการความแม่นยำและความน่าเชื่อถือสูง
Processes and operations weighing up to 10 kg are processed automatically. Heavier collaborative processes (such as packaging, stacking, assembly, pick and place) are very suitable for UR10. The UR10 has an extension radius of 1300 mm, which makes it more effective to handle operations in larger areas. This can save time for production lines affected by distance. Universal Robots UR10 is easy to program, quick to set up, collaborative and safe.หุ่นยนต์ร่วมมือสองแขนของ NACHI MZ04E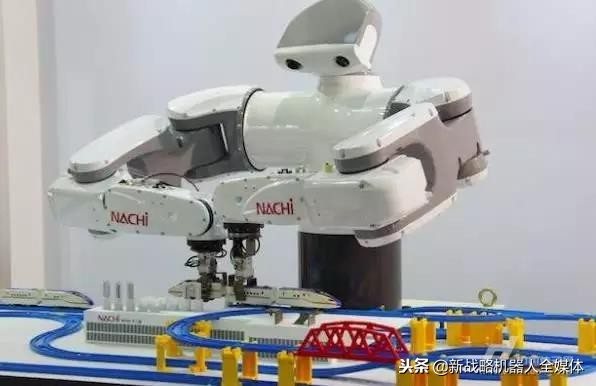 NACHI's dual-arm collaborative robot MZ04E can be used in factory production operations to replace part of the manpower, and use a single CPU to control the dual arms to achieve mutual matching, so as to smoothly and accurately achieve more difficult and more detailed tasks, such as assembling smart phones.
การกำหนดเส้นทางสายเคเบิลอันชาญฉลาดของข้อมือกลวงจะต่อสายเคเบิลของหุ่นยนต์ผ่านโครงสร้างกลวงของข้อมืออย่างชาญฉลาด ป้องกันการรบกวนอุปกรณ์รอบข้างด้วยการเดินสายไฟแบบกระจายสลับกัน ซึ่งช่วยเพิ่มความน่าเชื่อถือของอุปกรณ์ได้อย่างมาก


