


Последнийоднорукий коллаборативный роботв серии АББЮМи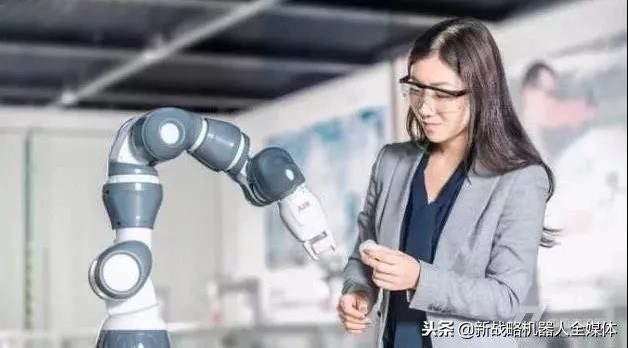 Этот новый робот, выпущенный компанией ABB, имеет нагрузку 500 граммов. Очень компактная конструкция позволяет интегрировать его в существующую сборочную линию, чтобы помочь клиентам повысить эффективность производства.
The robot also has a guided programming function, so the operator does not need to receive additional professional training. This new YuMi series single-arm collaborative robot will be officially released in 2018, and will work with ABB Ability digital solutions to help customers increase production efficiency and reliability to new heights.Легкий робот KUKA LBRiiwa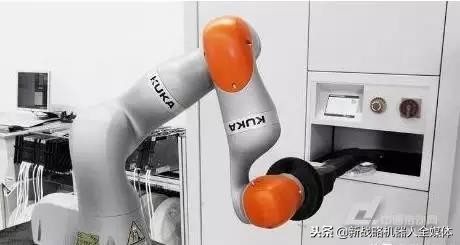 KUKALBRiiwa — первый чувствительный робот массового производства, а также робот с возможностями взаимодействия человека и машины.
LBR stands for "light robot", iiwa stands for "intelligent industrial work assistant", that is, intelligent industrial work assistant. LBRiiwa has two models to choose from, the load capacity is 7 and 14kg respectively. LBRiiwa can immediately recognize contact through joint torque sensors and immediately reduce force and speed. It handles sensitive workpieces through position and buffer control without any parts that can cause pinching or shearing.ФАНУК CR-35iA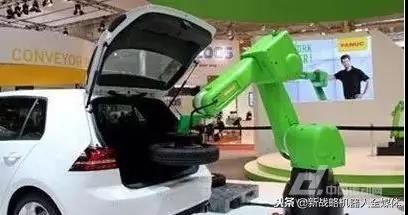 CR-35iAколлаборативный робот— это совершенно новый коллаборативный робот, выпущенный компанией FANUC в 2015 году, грузоподъемностью 35 кг, который на сегодняшний день является крупнейшим коллаборативным роботом в мире.
Этому роботу не требуется защитное ограждение, и люди и роботы могут делить определенную зону для работы.
Совместное использование CR-35iA и ручной работы может применяться в автомобильной промышленности, упаковочной и других отраслях. Руководство освобождено от тяжелых, но простых задач, чтобы вы могли сосредоточиться на работе, требующей навыков, и повысить безопасность труда. Повышайте эффективность системы.Двурукий робот Kawasaki duAro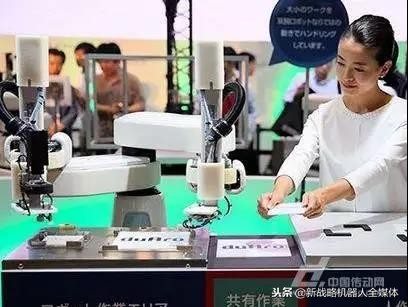 Человеческое тело машины duAro имеет две роботизированные руки, отходящие горизонтально от тела, и эти две роботизированные руки работают парами.
It can be installed in the space equivalent to a worker, and can replace the work performed by the worker with both arms. In addition, it can also work with workers. When a worker collides with the robot, the robot can be stopped through the collision detection function. During specific operations, the current flowing through the built-in motor in the robotic arm will be monitored. When an abnormal value is detected, it will be judged as a collision and stop the robotic arm.
Кроме того, что касается методов обучения, помимо прямого обучения, при котором работник фактически перемещает манипулятор робота для обучения, обучение также может осуществляться с использованием планшетного компьютера или чего-либо подобного.
Новый маленький робот MotoMINI от Yaskawa Electric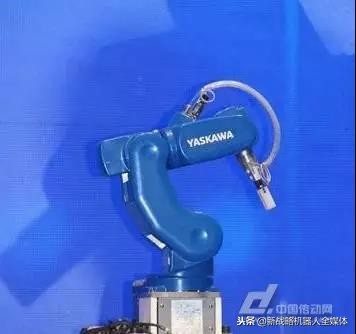 Yaskawa Electric MotoMINI — это автомобиль мирового класса.небольшой промышленный 6-осевой робот. MotoMINI легко меняет положение размещения и обеспечивает высокую степень свободы, например, при совместной работе человека и машины.
It is used for the assembly and operation of small parts, as well as the electronic and electrical parts. And insert etc. MotoMINI has three major characteristics: small and light, high speed and high precision. MotoMINI can carry 500g, the maximum extension distance is 350mm, and the weight is about 7kg. The robot has realized the possibility of producing and processing small products by small portable robots.Совместный робот человек-робот Comau AURA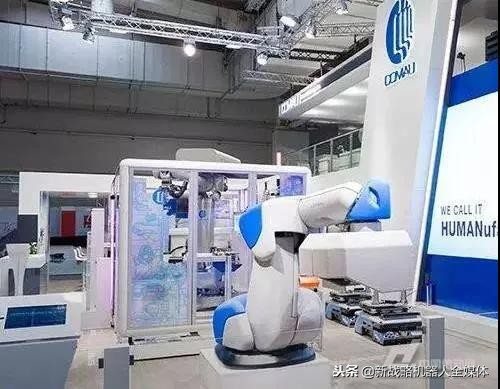 Совместный робот человека и робота AURA компании Comau впервые объединяет мультисенсорное общее восприятие близости и контакта людей или любых других автоматизированных компонентов, а также интенсивность контакта.
В сочетании с использованием лазерного сканера для динамического определения положения человека робот становится возможным замедляться при приближении или фактическом касании оператора до полной остановки. Когда AURA чувствует прикосновение, она также может реагировать на потребности оператора.
Контроллер робота также интегрирован с системой технического зрения, которая передает данные о близости людей к зоне действия робота, а специальное программное обеспечение прогнозирует следующее действие человека, а затем соответствующим образом меняет траекторию движения робота.
Шарнирно-сочлененный робот Xinsong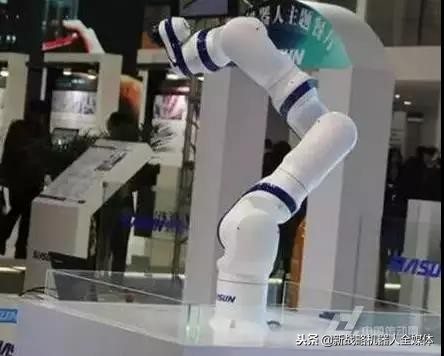 The Sinsong multi-joint robot is the first domestic 7-DOF collaborative robot. It has functions such as rapid configuration, traction teaching, visual guidance, and collision detection. It has the powerful advantages of high load and low cost, and satisfies users' short return on investment cycle and robots.
Product safety, flexibility and human-machine collaboration requirements. It is suitable for flexible production lines with compact layout and high accuracy to meet the needs of industrial operations such as precision assembly, product packaging, grinding, testing, and loading and unloading of machine tools.
Человеко-машинный коллаборативный робот Хана Elfin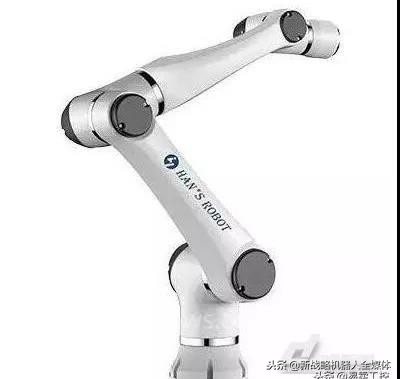 This man-machine collaborative robot named "Elfin" adopts a unique dual-joint modular structure design, which is convenient for assembly and maintenance. The appearance is novel and smooth. The EtherCAT bus is used to communicate between the controller and each shutdown, and it can still have very good anti-interference performance under the control frequency of 10KHz.
Конструкция высокой жесткости обеспечивает повторяемость до ±0,03 мм, что можно использовать в таких рабочих ситуациях, как интегрированные линии автоматизации, сварка, полировка, сборка, комплектация и покраска.Универсальный робот UR10 Совместный человеко-машинный робот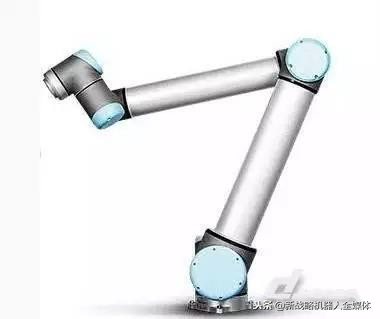 Универсальные роботы UR10 предназначены для более крупных работ, к которым предъявляются высокие требования к точности и надежности.
Processes and operations weighing up to 10 kg are processed automatically. Heavier collaborative processes (such as packaging, stacking, assembly, pick and place) are very suitable for UR10. The UR10 has an extension radius of 1300 mm, which makes it more effective to handle operations in larger areas. This can save time for production lines affected by distance. Universal Robots UR10 is easy to program, quick to set up, collaborative and safe.Коллаборативный робот NACHI с двумя руками MZ04E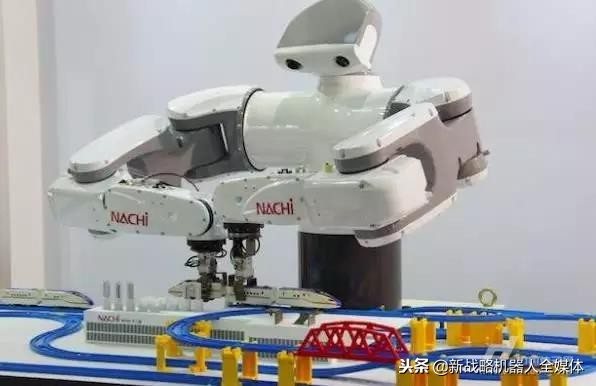 NACHI's dual-arm collaborative robot MZ04E can be used in factory production operations to replace part of the manpower, and use a single CPU to control the dual arms to achieve mutual matching, so as to smoothly and accurately achieve more difficult and more detailed tasks, such as assembling smart phones.
Гениальная прокладка кабеля полого запястья позволяет разумно проложить кабель манипулятора через полую структуру запястья. Предотвратите помехи окружающим устройствам за счет простой перемежающейся проводки, что значительно повышает надежность оборудования.


