


1. 외골격 로봇 소개
안외골격 로봇 refers to a robot that is sheathed outside the human body, also known as a "wearable robot". Its essence is a wearable intelligent structure with human-machine coupling. The principle is to combine human intelligence with the mechanical energy of an external mechanical power device. It can enhance human heavy load capacity and walking ability by providing power assistance and an intelligent platform.
그리고 의료 재활, 산업, 야외 스포츠, 군사 산업 및 기타 분야에서 주로 사용되는 기타 기능.
2. 외골격 로봇의 주요 제품 종류
According to the different organs that provide strength support, the current mainstream exoskeleton robots are divided into three categories in terms of product form: upper limb exoskeleton robot, lower limb exoskeleton robot and waist exoskeleton robot. On this basis, a more "economical" single-joint exoskeleton robot has emerged, and a soft exoskeleton robot with a completely new technological path. Different forms of exoskeleton are used in different scenarios, such as medical field, industrial field, civil field, etc.
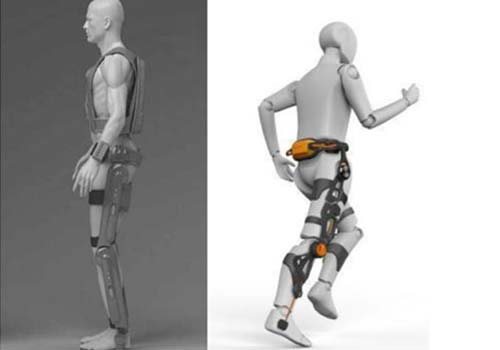
(1) 하지 외골격 로봇
하지 외골격 로봇은 형태에 따라 전체 커버리지형과 하프 커버리지형의 두 가지 유형으로 나눌 수 있습니다.
Full coverage type: including the main box on the waist and back, the metal structure that completely wraps the outside of the two legs, and the metal structure of the sole. Some products will have matching crutches to achieve control and support functions, and some products will be supplemented by brackets or hanging rope. There are hardware modules such as system operating platform and power supply in the main box, and their size and weight vary with each product.
하지 구조에서는 고관절, 무릎관절, 발목관절이 일반적으로 가동관절로 설계되어 있다. 자유롭게 움직일 수 있는 관절의 수를 일반적으로 "자유도"라고 합니다. 자유도는 인간의 형태를 시뮬레이션하는 로봇의 능력과 밀접한 관련이 있습니다.
Semi-covered type: Except for the main box, the lower limbs have only leg fixing structure, joints and connection structure, and the product design is more compact and light. Generally speaking, the heavier the product, the higher the demand of the applicable people for the machine, and the greater the support provided by the machine, such as paralyzed patients and hemiplegic patients; the use scenarios of lightweight products are also relatively more flexible, and the applicable population has a certain degree of support.
보행능력.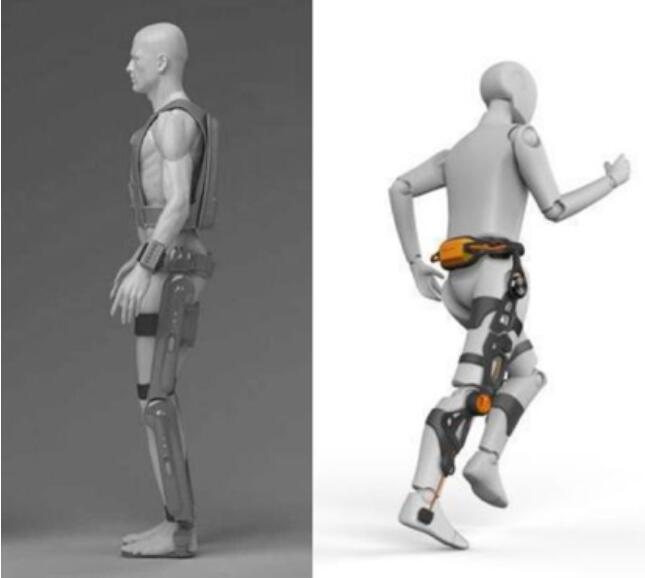 (2) 상지 외골격 로봇
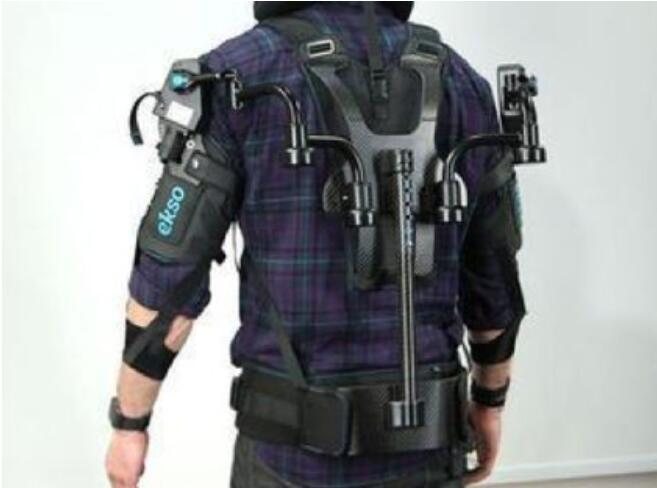
The shape of the upper limb exoskeleton robot is very similar to the semi-covered lower limb product, except that the structure fixed on the lower limb is transferred to the upper limb. From the structural point of view, it mainly assists the movement of the human body through the joints with degrees of freedom.
 (3) 허리 외골격 로봇
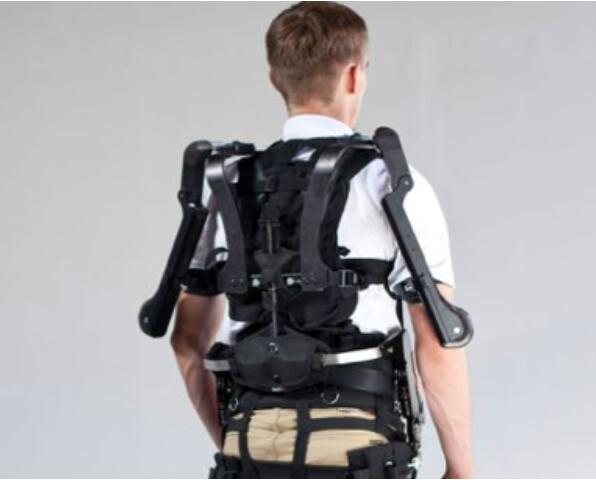
The shape of the waist exoskeleton robot is similar to the once smashing "back and back". The product is fixed on the back through fabric. The main body of the product is the main box on the body, and various functional modules are arranged inside the box. It is mainly used in scenes of frequent bending and transportation, such as logistics and construction sites.
 (4) 소프트 외골격 로봇
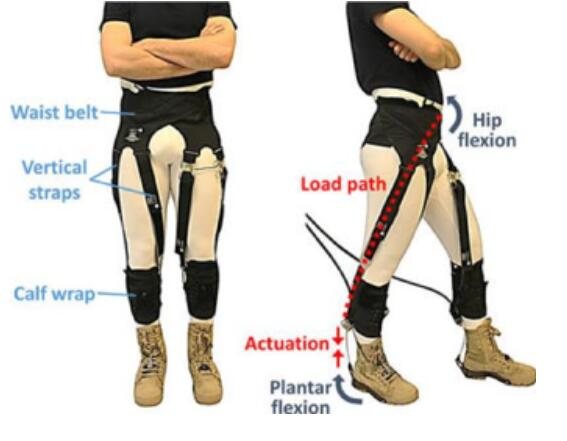
The soft exoskeleton robots currently on the market are actually a kind of lower limb exoskeleton robots. In terms of usage scenarios, they also overlap with lightweight metal structure exoskeleton robots, but their shape and technical path are similar to those of metal structure lower exoskeleton robots. It's totally different. The main box still exists, but the structure is more compact, the lower limbs are fixed to the human body through textiles, and the ropes are used to provide assistance instead of the joint structure.
 셋째, 외골격 로봇의 핵심구성
외골격 로봇은 크게 감지 시스템, 제어 시스템, 구동 시스템의 세 가지 핵심 시스템으로 구성됩니다.
(1) 감지 시스템
The sensor system collects the user's gait information or movement intention through sensors distributed in different positions of the exoskeleton, and then transmits these data to the control system in a certain form. From the type of information collected, it can be divided into physical quantity sensors (position, angle, torque, pressure, etc., which can determine the user's gait cycle) and biomass sensors (electromyogram signals, which can determine the user's movement consciousness).
(2) 제어 시스템
The control system is the central hub of the exoskeleton robot. By analyzing the data fed back from the sensor system and planning the gait mode, closed-loop control of the drive system is achieved. The difficulties involved include a series of software modules such as sensor fusion algorithms and control algorithms. . Generally speaking, the controller is located on the back and implements global control, including the system host, signal acquisition board, motor drive board, power management and other modules.
그러나 외골격의 자유도가 높아지고 모델 알고리즘이 복잡해짐에 따라 분산 제어를 활용하면 중앙 제어 시스템의 부담을 줄이고 시스템의 응답 속도를 향상시킬 수도 있습니다.
(3) 구동 시스템
The drive system is located at the end of the machine's operation and is responsible for driving the mechanical structure and performing specific tasks passed by the control system. According to the different drive forms, there are mainly three drive modes: motor drive, pneumatic drive, and hydraulic drive.
모터 구동: 구조가 간단하고 정밀도가 높으며 자동 제어가 용이하며 현재 가장 많이 사용되는 프로그램입니다.
공압 드라이브: 작은 크기, 저렴한 비용, 편리한 작동; 하지만 정확도가 높지 않고, 제어가 어렵고, 이동 범위가 제한됩니다.
유압 드라이브: 안정적인 변속기, 높은 역동성, 높은 안전성을 제공하지만 구조가 복잡하고 무게가 무겁고 비용이 높습니다.
(4) 외골격 로봇 기술 개발 현황
The exoskeleton robot interacts with the above three systems to realize the coordinated movement of the entire robot, which involves multidisciplinary knowledge such as sensing technology, mechanical control, and human mechanics, which is a complex and comprehensive task. At this stage, there are still many technical bottlenecks that are difficult to break through, which limits the ease of use of the product, such as insufficient response speed under complex motions, unstable center of gravity of lower limb robots, and difficulty in coordinated control under multiple degrees of freedom.
Specifically, the difficulties are mainly concentrated in the control system, including: multi-sensor fusion technology, intention recognition, center of gravity adjustment, joint freedom and the balance of modeling complexity, etc. These are the difficulties at the software level. In addition, in the drive system, due to the slow development of materials science, the performance of the motor is restricted, which in turn limits the applicable scenarios of the robot, which is a difficulty at the hardware level.넷째, 외골격 로봇의 주요 시장 응용 분야와 시장 규모
(1) 의료재활
my country’s rehabilitation medical industry is in the early stages of development. On the one hand, neurodegenerative diseases such as stroke, cerebral palsy, and Parkinson’s mobility are affected by huge and urgent market demands. On the other hand, there is low capital investment, small number of rehabilitation institutions, and small scale. There is a serious imbalance between demand and supply in the current situation of backward equipment research and development.
The wearable exoskeleton robot is designed based on the principle of bionics, combined with ergonomics, and can be worn on the affected limb. Each joint corresponds to a separate driving device. After the patient wears it, it can ensure that the motion mode of the robot is coaxial with the degree of freedom of the human body, which can achieve more effective rehabilitation training.
At present, there are about 4,000 general hospitals in my country with rehabilitation departments. With an average of 1-2 units of equipment purchased by a hospital, the stock demand for rehabilitation exoskeleton robots in my country is 9,000. According to the price of 300,000 to 3 million per unit, the stock market size is about In the billions.
(2) 이동 지원
The goal of mobility assistance exoskeleton robots is to provide users with continuous assistance in their daily lives. The population of assistance needs are mainly: physically disabled, elderly people with mobility impairments and people without walking disabilities (climbing enthusiasts). The market prices of the products range from 100,000 to 300,000 RMB (average price of 150,000 RMB), tens of thousands of RMB (average price of 30,000 RMB), and thousands to tens of thousands of RMB (average price of 8,000 RMB).
The potential market demand for mobility-aided exoskeleton robots is about 15 million units, and the market size is about 120 billion yuan. Compared with the rehabilitation market, the market size of mobility-assisted exoskeleton robots is more promising, and 2C is an incremental market. The market ceiling is high enough and the market space is large enough.
(3) 산업
1. 물류취급
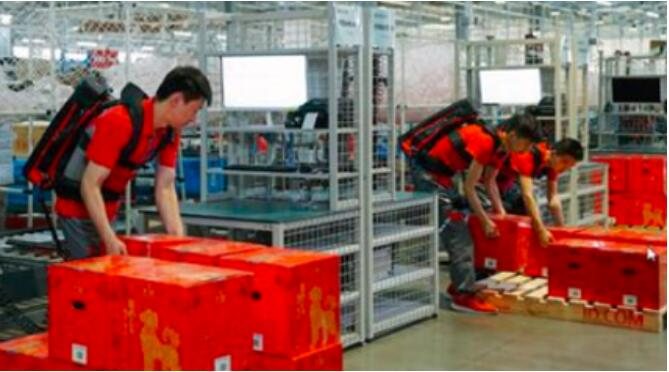
Logistics handling is the largest application scenario in the industrial field. my country's express logistics continues to prosper, with an annual express delivery volume of more than 40 billion pieces, maintaining a rapid growth of more than 50%. The sorting and distribution of express delivery are labor-intensive and high labor costs. After the wearer puts on the exoskeleton robot, it can improve the high-intensity load-bearing capacity of core parts (such as the lower back) and core muscles (such as the lumbar erector spinae) , Effectively slow down the fatigue speed of working muscles and protect the waist muscles of the courier.
사람이 이동하는 동안 에너지 소비를 줄이고 작업 효율성을 향상시킵니다.
외골격 로봇은 물류 효율성을 크게 향상시키고 인건비를 절감할 수 있습니다. 현재 JD.com, Suning 등 거대 기업에서는 핸들링을 보조하는 외골격 로봇을 적극적으로 개발하고 이를 사용하기 시작했습니다.
 2. 자동차 산업:
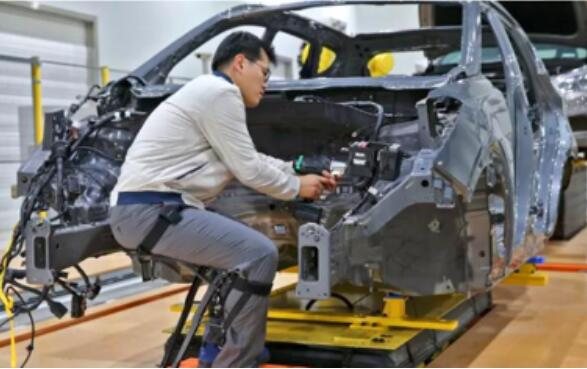
The current front-end manufacturing stations of the automobile assembly line have basically realized automated operations, but the auto assembly line stations at the end still cannot be replaced by automated equipment. These station operations have brought great damage to the workers' shoulder and waist bone joints. Take overhead operations as an example. Workers need to lift about 5-6 kilograms of parts and tools, and repeat them about 3000-4000 times a day.
일년 내내 한 번의 움직임과 중력의 압력으로 인해 어깨와 허리에 쉽게 긴장이 생길 수 있으며 이는 공장에도 영향을 미칩니다. 파이프라인의 효율성.
외골격 로봇은 인간의 상지 근력을 크게 향상시키고 노동 강도를 줄이며 허리 통증 발생률을 줄이고 전반적인 작업 효율성을 향상시킬 수 있습니다.
 (4) 시장 규모
ABI리서치(ABI Research)의 연구 보고서에 따르면, 2018년 기준 전 세계 외골격 로봇 출하량은 7,000대, 전 세계 하드웨어 매출은 1억 9,200만 달러에 이른다. 전체 출하량은 2023년에는 9만1000대, 2028년에는 30만1000대를 넘어설 것으로 예상된다.
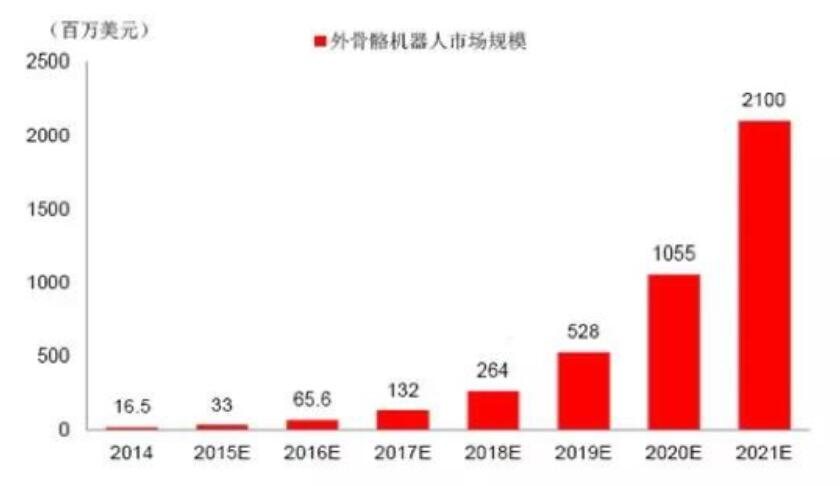
중국 산업 정보 네트워크(China Industry Information Network)의 글로벌 데이터에 따르면 2021년까지 외골격 로봇의 시장 가치는 미화 21억 달러에 달하고 매년 거의 두 배의 속도로 성장할 것으로 나타났습니다.
 다섯번째, 요약
(1) 시장수요
1. 의료재활시장
The number of physically disabled people in my country currently exceeds 20 million, but there are 7,858 rehabilitation institutions for the disabled in the country, and only 1.357 million people with physical disabilities have received basic rehabilitation services. In addition, with the accelerating arrival of an aging society, the population of patients with cerebrovascular disease is also expanding, if more effective measures are not taken.
By 2030, there will be 31.77 million stroke patients in China. At present, the number of rehabilitation physiotherapists in my country is seriously insufficient, and the market gap is huge. The huge gap can be met by exoskeleton robots. Therefore, the demand for exoskeleton robots in the medical rehabilitation market will be huge.
2. 산업시장
With the continuous development of robotics technology, robots have been widely used in industry, medical care, transportation, consumption and other fields. However, with the support of existing technology, industrial automation has developed to a platform period with many refinements. In non-standardized work scenarios, automated machines are difficult to perform, and manpower is still an indispensable source of productivity in industrial production.
According to the data disclosed by the National Bureau of Statistics, in recent years, the number of employees in heavy manual labor industries such as mining, industrial manufacturing, construction, loading and unloading and warehousing has continued to decrease. With the decrease in the number of employees, the number of employees has increased. The phenomenon continues to increase. Most workers are physically unable to adapt to the high-speed production environment and needs.
장기간 반복적인 노동으로 인한 직업병은 근로자의 생산성을 더욱 저하시킨다. 이 부분은 작업자의 힘을 강화하고 부담을 줄일 수 있는 외골격 로봇에 대한 수요 잠재력이 크다.
(2) 시장개발
It has been a hundred years since the development of exoskeleton robots, from R&D to application. From the earliest military field, applications in medical, industrial, logistics and other fields began. Products such as Ekso Labs in the United States, Rewalk in Israel, CyberDyne in Japan, and exoskeleton robots from Panasonic have begun to be gradually applied all over the world. The domestic exoskeleton robot industry application is still in its infancy.
Whether it is in the medical field or the industrial field, it will take a few years to truly realize large-scale commercial use. Although the large-scale implementation of the industry is still far away, related technologies and products have begun to develop. Some manufacturers have trial production lines, as well as small-scale mass production and application.
Xin Guobin, Vice Minister of the Ministry of Industry and Information Technology, said at the 2019 World Robotics Conference, “Since the second half of 2018, China’s industrial robot output has slowed down year-on-year, and the robot industry has entered a stage of in-depth adjustment, expanding new application areas and improving quality. Increased efficiency has become an urgent need for the healthy development of the industry. "After the robotics industry enters in-depth adjustments, the exoskeleton robot market will usher in new development opportunities.
(3) 기술상의 문제점과 향후 발전방향
Although the development prospects of the entire exoskeleton robot market are good, the current technology still has many areas that need to be improved, such as battery life issues; comfort issues, how to make the fuselage lighter; human-computer interaction issues, robots need to know the intentions of people ; And more powerful data acquisition capabilities and driving capabilities.
시스템 통합, 인간-컴퓨터 상호 작용, 구조 설계, 지각 인식 및 인지 학습 능력은 향후 외골격 로봇 개발의 주요 방향이 될 것입니다.


