


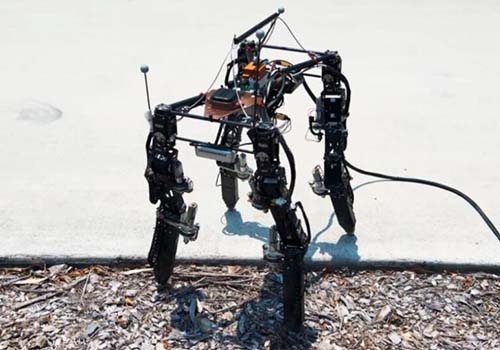
Modern robots are equipped with motion systems, but adapting to the terrain in action has always been a difficult point. Scientists from the University of Oslo in Norway have developed a new type of four-legged robot for this purpose. When it encounters different surfaces, it can adjust its leg length and walking gait. This ability can improve its energy efficiency and unpredictable Performance in the environment.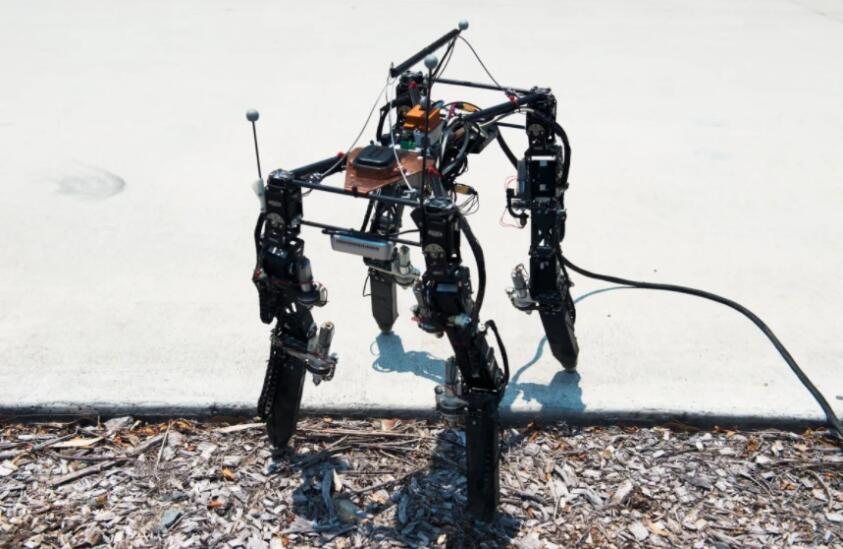 1. Познакомьтесь с DyRET
The robot is called Dyret (meaning "animal" in Norwegian), and is known as the first four-legged robot that can automatically change its shape according to different conditions. Through the mixed use of sensors, cameras and artificial intelligence, the robot can recognize and mechanically adjust the length of the legs when encountering different terrains to adjust the body shape and optimize its gait to adapt to specific surfaces.
Руководитель этого исследования Ниджиаде заявил, что этот робот может постоянно изучать среду, в которой он ходит, а затем комбинировать полученные знания в контролируемой среде, чтобы адаптироваться к ней.
It is understood that the researchers first trained the robot to walk on gravel, sand and concrete, and then let it walk on grass that has never been set foot. Although this does not seem to be the most troublesome terrain, the researchers pointed out that any different shape of the ground is a new real challenge for long-legged robots.
This dog-like deformable robot can dynamically elongate its four legs. Researchers conducted tests in Norway and Australia to help DyRET learn how to lengthen or shorten its limbs to adapt to different types of terrain. Nigard, a computer scientist at the University of Oslo and the Norwegian National Defense Research Institute, said: "At this stage, it is possible to take robots outdoors and learn to adapt to the environment. It can use the intelligence that humans give them."
2. Сложная «эволюция» четвероногих роботов.
Terrestrial animals have no limbs to stretch, because it is biologically impossible in the first place, and it is not necessary. Due to millions of years of evolution, human bodies, cheetahs or wolves have incredible agility. They can constantly scan the obstacles in front of them during the running movement, but the function of joint expansion and contraction is not.
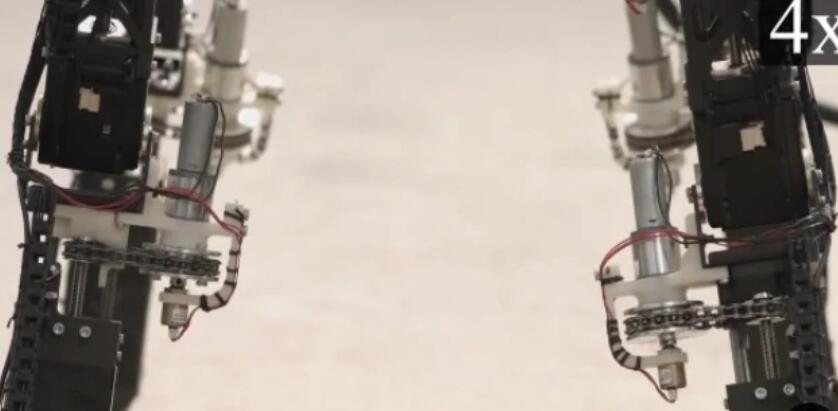 Stretchable limbsOn the other hand, the evolution of robots also requires some adjustments. Even super-complex machines like the Spot Robot Dog from Boston Dynamics cannot navigate the complex terrain. Making the robot telescopic legs can not only improve their stability when moving on different surfaces, but also improve energy efficiency. Walking around consumes a lot of battery power, and the shaking of the robot may hurt itself or people nearby.
"I think having an adjustable body is a particularly good idea," said Francisco Valero Cuevas, an engineer at the University of Southern California, who participated in the development of quadruped robots. "Technology is constantly iterating, and the adjustable body makes future robots more flexible."
Nigard and his colleagues first literally constructed an experimental sandbox to allow DyRET to receive balance training. In the laboratory, they filled long boxes with cement, gravel and sand, representing the various terrains that the robot might find in the real world. The concrete is relatively flat, but the sand is full of uncertainty, because every step the robot’s legs will tilt or sink; gravel is a hard surface substance, but the gravel will move, making DyRET's footsteps staggering.
Ниджад сказал: «Благодаря трем примерам местности с разной твердостью и шероховатостью можно хорошо представить форму робота или общее взаимодействие между телом и окружающей средой».
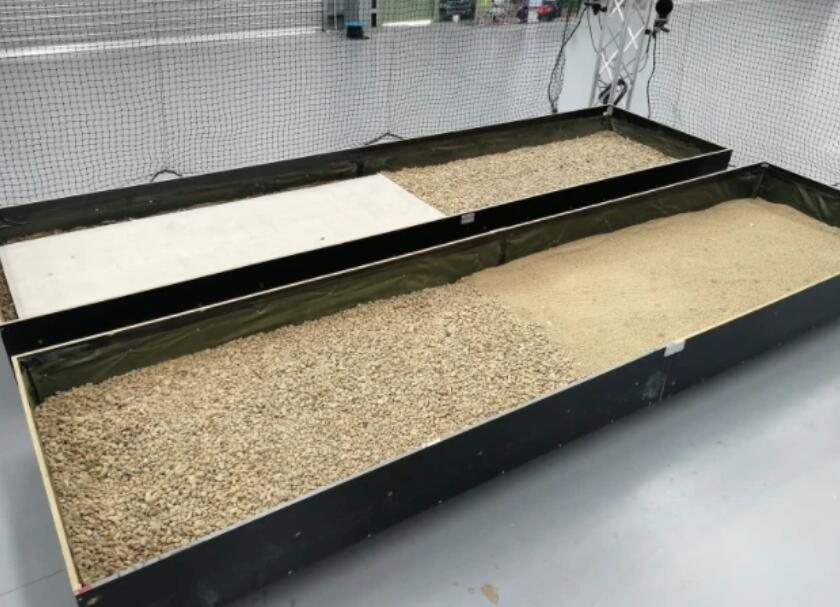 Different ground materials for training robot balance in the laboratoryThe DyRET robot has four legs and a handle on the top for researchers to grasp. The robot’s legs can extend a total of 6 inches, but can extend in two positions: the "femur" above the knee and the "tibia" below the knee. This allows the machine to set its leg sections in different lengths.
Например, он может растягивать конечности, делая бедренную кость длиннее, а голень короче, и наоборот. Исследователи могут настроить эти конфигурации, разместить DyRET на каждом ландшафте, заставить его двигаться, как собака или кошка, а затем рассчитать их эффективность на каждом ландшафте.
More specifically, researchers see "movement cost" as an efficiency, which is the same metric used by biologists when observing animal movements. Basically, this is how much energy a creature or robot consumes to implement the behavior of moving. The workmanship and stability of walking are all coded into the computer, which is very important for expensive robots like DyRET.
The researchers measured the energy consumption in the motors of the robot's joints and used a camera to monitor its movement. The robot also has its own depth-sensing camera to characterize the roughness of the surface. For example, it has been observed that concrete is much smoother than gravel. The machine can even immerse the toes in the water, so to speak: the force sensor on the foot provides it with information that the sand is much softer than concrete; the camera and the force sensor together provide DyRET with complex vision to monitor the process of walking and Operational efficiency.
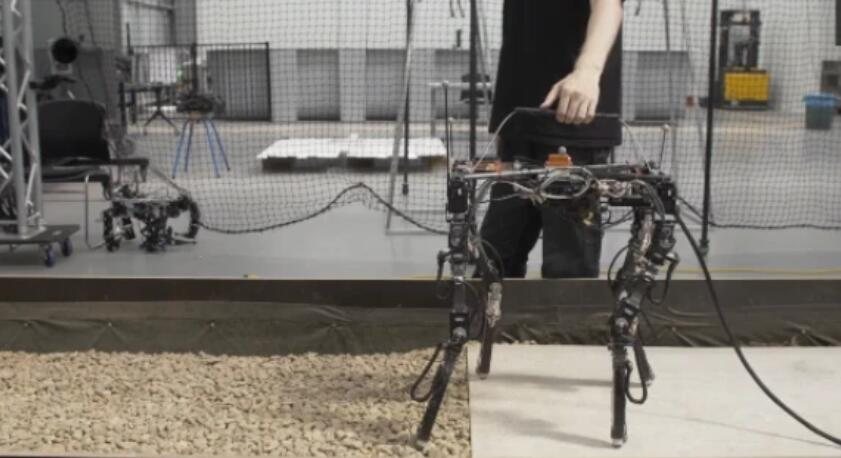 When the robot detects that it is transitioning from concrete to gravel, it can be seen to lower its heightThe researchers found that when walking on concrete, the deformable robot has longer legs and is the most efficient. In the sand, as long as the tibia is short, it can effectively stretch any femur length.
On gravel, DyRET's overall body is shorter and performs very well, which makes sense: a lower center of gravity will make the robot more stable when climbing on small rocks. Generally speaking, shorter legs allow the robot to apply more force to step on looser materials, while longer legs can increase the speed of walking on smoother materials.
All these trainings provide the robot with the experience of how to coordinate the best limb configuration for a specific surface. Therefore, when the researchers subsequently take DyRET to other terrain, the robot can look at the ground with its camera and sense objects under its feet through a force sensor, comparing this data with previous information about how the concrete looks and feels. Then, the robot knows how to walk on the road, adjust the stride length, and achieve higher efficiency.
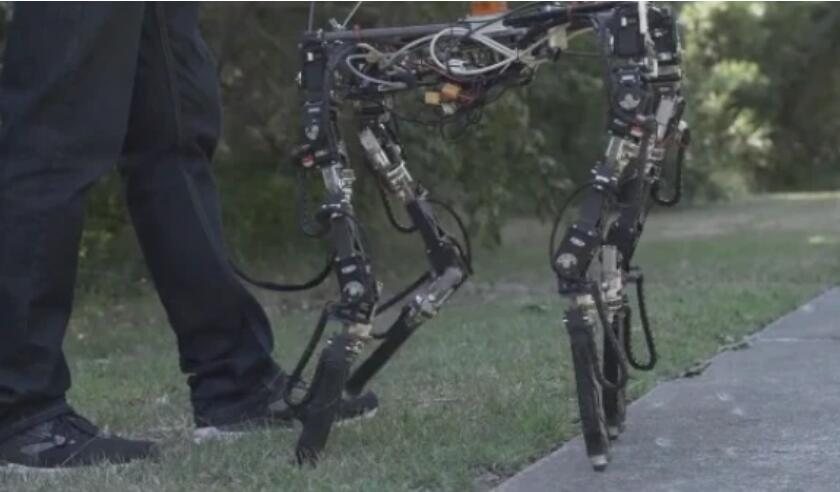 DyRET может даже адаптироваться к газону. Поначалу его производительность была еще очень нестабильной, но вскоре он смог понять, какие формы тела работают лучше, и адаптироваться к новой среде.3. В будущем пусть восприятие робота адаптируется к его собственному телу.
As robot learning technology becomes more and more complex, in the past ten years or so, robotics experts are used to training quadruped robots in simulations. In other words, we must first train the software that controls the robot in the virtual world. In this virtual world, the simulated robot can perform thousands of walking attempts and learn through trial and error. The system punishes errors and rewards successful operations until the virtual robot learns the best behavior.
Это техника, называемая обучением с подкреплением. Эксперты по робототехнике смогут затем перенести эти знания в реальных роботов и шагающие машины.
In addition, the technology has the problem of "simulation to reality" transition: the complexity of the physical world cannot be perfectly simulated in the virtual environment, so the knowledge obtained through simulation does not always match the real world, which means The actual robot may have a vague understanding of the surrounding environment.
In contrast, what these researchers do with DyRET is to train robots in the real world. Of course, this also brings new challenges: the learning speed of deformed robots is much slower, and may often be damaged by falling. Kyle Gretel, a computer scientist at the University of Oslo, said: “Factors such as terrain differences make actual manipulation much harder than it sounds. There is no trajectory to follow, and it is difficult to achieve it through simulation.”
Objectively speaking, the movement of DyRET is still slow, especially when compared with advanced quadruped robots like Spot. For example, it takes 90 seconds to fully extend or contract the robot's legs. But the researchers hope that DyRET's hardware and underlying algorithms can be improved at the same time, and perhaps one day other deforming robots can use this type of system. In fact, in the robotics laboratory, the bigger idea is to make the hardware and software work together so that the robot can better perceive the terrain and adapt to its body and behavior.
Это сделает технологию робототехники окончательно популярной.


