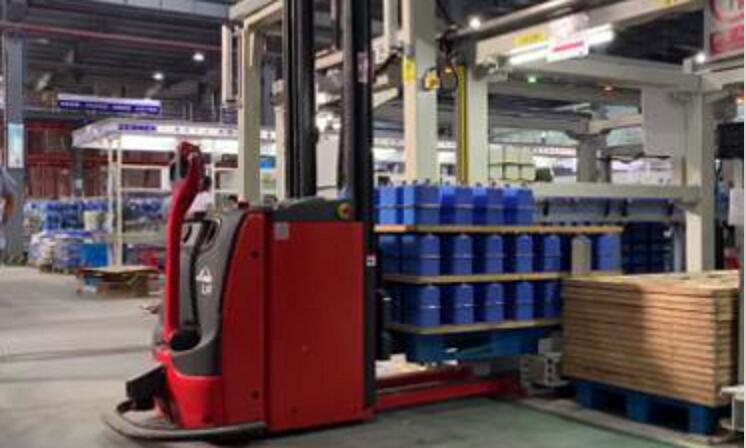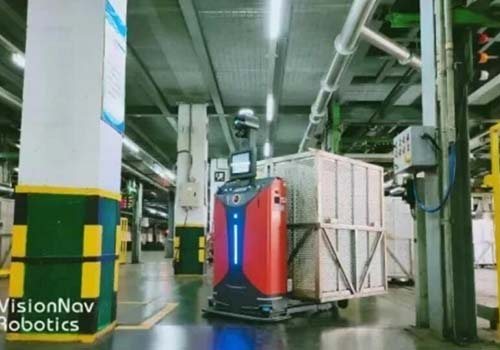
SLIM 시리즈 제품---팔레트 스태커무인지게차, based on VisionNav vision unmanned driving platform, are designed for narrow aisle handling, with a slimmer body, which can realize automatic unmanned handling of goods and 2.0m narrow aisle storage and exit. SLIM series products have a rated load of 1.4T, a full-load maximum operating speed of 1.5m/s, and a maximum lift of 3 meters, which can realize fast storage and fast steering connections.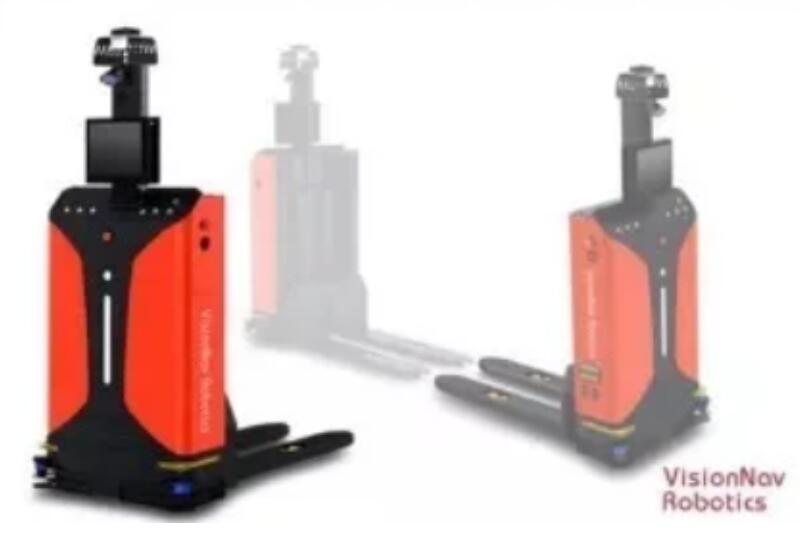 SLIM 시리즈 무인 지게차는 ±10mm의 탐색 정확도로 업계의 첨단 시각적 SLAM 탐색 기술을 채택합니다.
The body is equipped with an advanced 3D vision module, equipped with vehicle detection and shelf detection functions, and can adapt to vehicles and shelves. The unmanned forklift central control system has powerful cloud computing and information storage capabilities, which can complete multi-vehicle scheduling and collaborative operations, flexible docking automation equipment (such as automatic baler, automatic palletizer, automatic elevator, etc.) and WMS/ERP warehouse management System.
이중 시스템 안전 설정, 360도 레이저 장애물 회피로 사람, 차량 및 물품의 안전을 보장합니다. 전자상거래 물류, 제3자 물류, 3C 제조, 식품 및 의약품, 자동차 제조, 신에너지 및 기타 분야에서 널리 사용되었습니다.
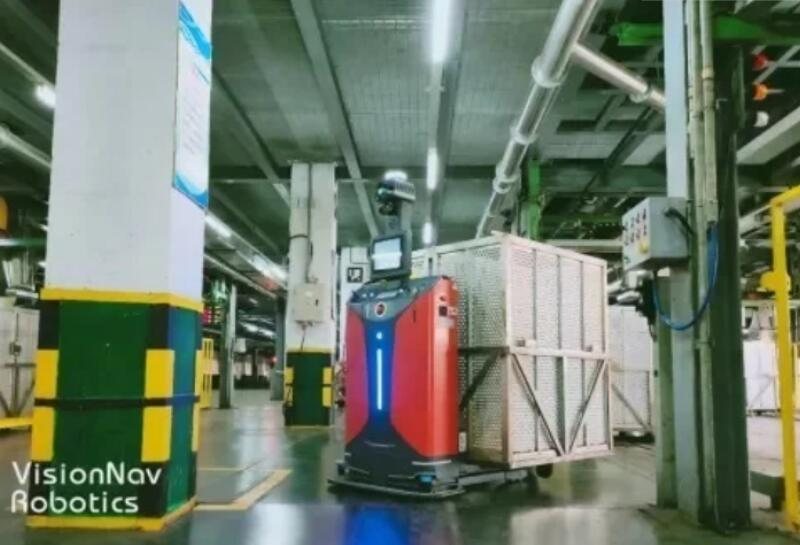
In a textile factory, Future Robot has customized an unmanned logistics solution for the automatic online unloading of acrylic fiber baskets and workshop line body transfer, including nearly 10 SLIM series unmanned forklifts and a future robot central control system , Replacing 2 shifts of forklift workers, running stably and continuously for 24 hours, stably and efficiently replacing manual logistics and transportation operations between production lines. The main innovations of the project are:
1) Material car with rollers. Due to the special attributes of the company's products, the wheeled material truck is used as the carrier, and the position and posture of the material truck will be deviated in the unloading station. The unmanned forklift is required to have the ability to automatically recognize the fork position and adaptive body adjustment;
2) Narrow channel operation. The narrowest position of the project is 1.7 meters through the space, requiring vehicles to adapt to space changes while ensuring safe driving to maintain smooth operations;
3) Human-machine collaboration. This project is mainly for the connection of the end of the production line. The unmanned handling task is manually issued at the end of the production line. The unmanned forklift is required to intelligently sort the tasks according to the priority of the task, generate routes, and flexibly adapt to the handling needs on the spot.