


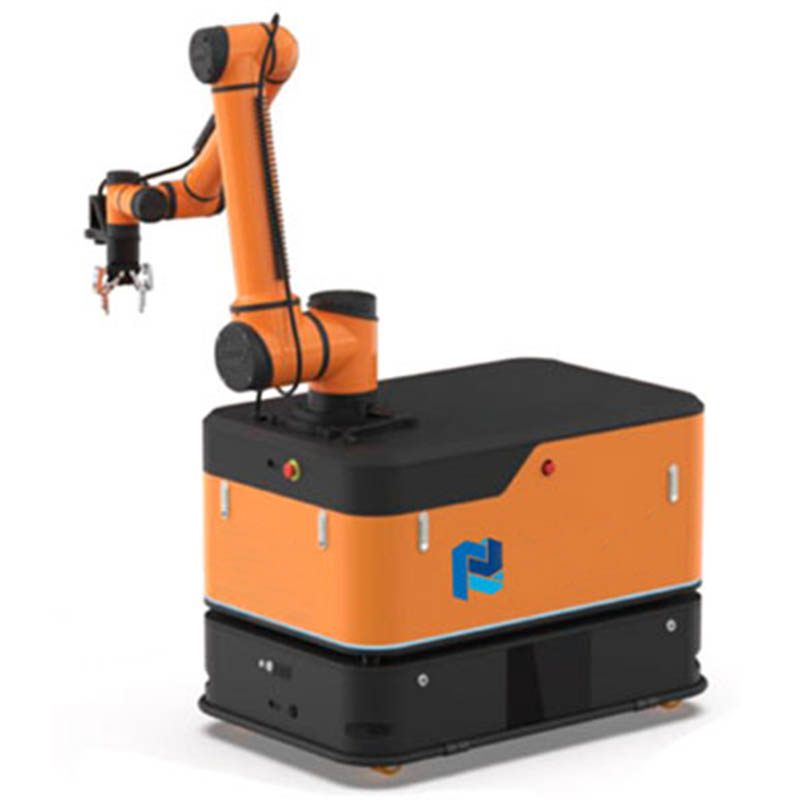
複合AMRロボット
TR-CP300Sは、社内物流・倉庫搬送用の移動ロボットです。リードタイムは45日です。価格は構成ごとに見積もられます。認証: ご要望に応じて CE ドキュメントをご提供します。
- モデル
- TR-CP300S
- リードタイム
- 45日
- カテゴリ
- モバイルロボットとAMR
このプラットフォームの目的
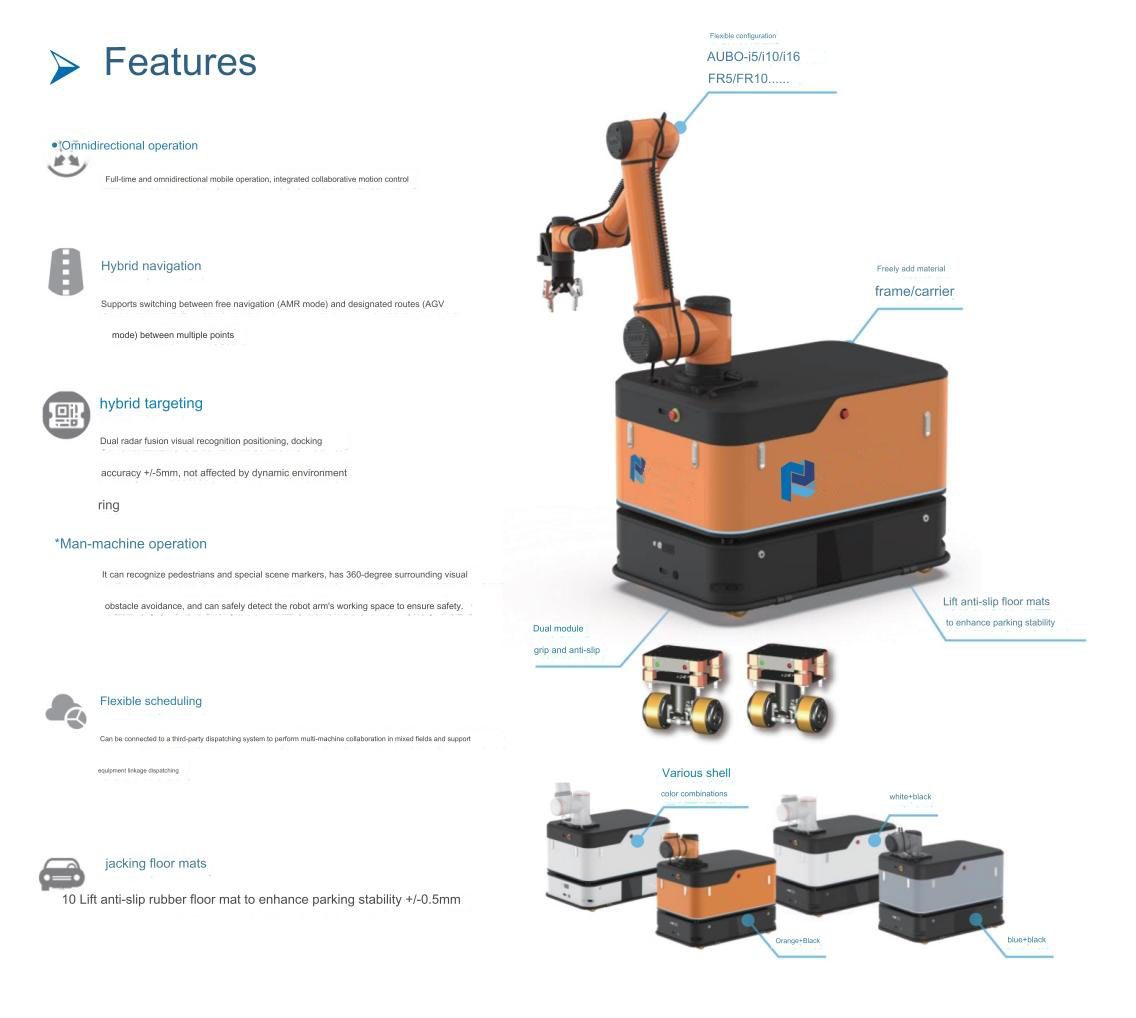
Composite Robot Features: *Omnidirectional operation Full-time and omnidirectional mobile operation, integrated coordinated motion control. *Hybrid navigation Supports switching between free navigation (AMR mode) and designated routes (AGV mode) between multiple points. *Hybrid targeting Dual radar fusion visual recognition positioning, docking accuracy +/-5mm, not affected by.
商業条件
| 引用 | 構成ごとの価格 - 48 時間以内にご返信ください |
|---|---|
| リードタイム | 45日 |
| MOQ | 1台 |
| 起源 | 中国 |
| 積地港 | 深セン、中国 |
| インコタームズ | FOB 深セン / CIF (ご要望に応じて) |
| 支払い | 30% のデポジット、出荷前に 70% |
| 保証 | 標準は 24 か月、オプションは 36 か月 |
製品詳細
TROY エンジニアリング ファイルからのアプリケーション ノート、構造図、およびビデオ — 見積書に同梱される同じ文書。
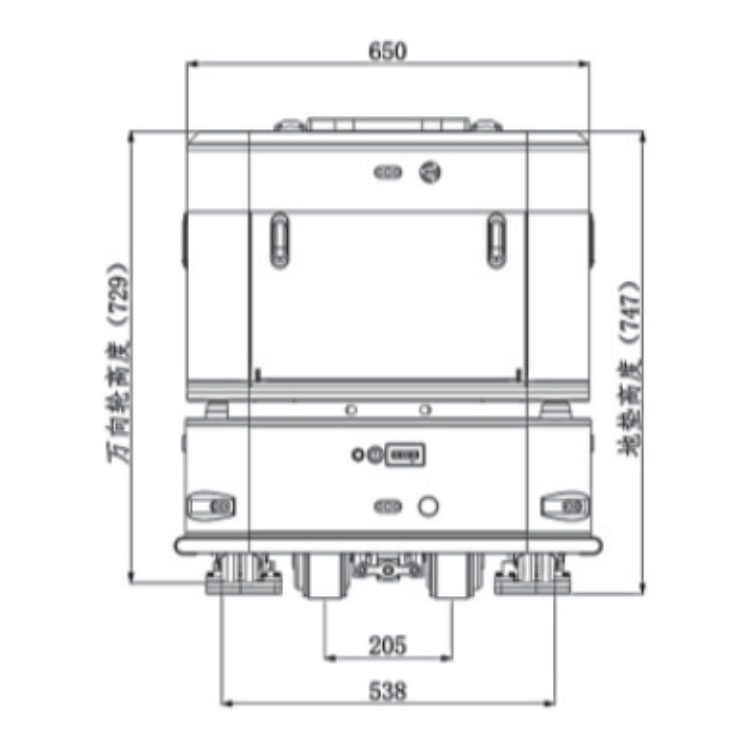
Composite AMR Robot Parameters:
製品番号 | TR-CP300S-(005-020)A |
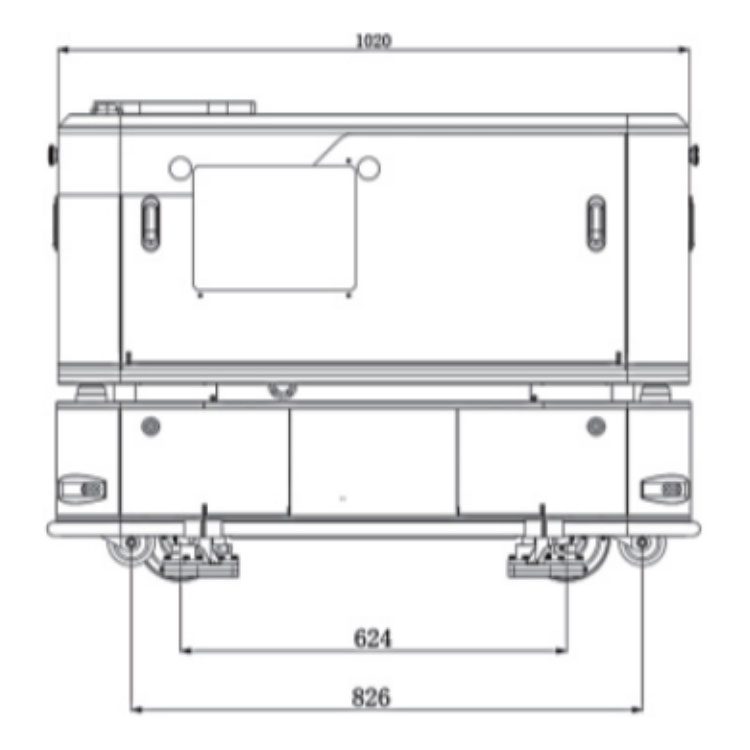
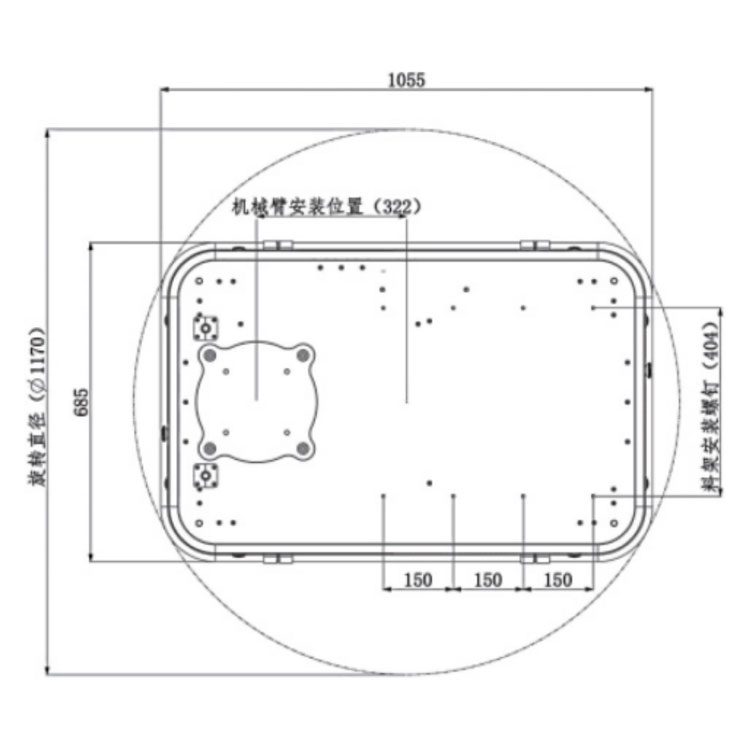
全体の寸法 (length * width * height) mm | 1020 * 650 * 730(+/-2)(excluding robot arm height) |
Loading surface dimensions (length * width * height) mm | 600 * 600 |
Self weight (Kg) | 200 (+/-5), chassis weight only |
Maximum load (Kg) | <=300, robot arm and vehicle weight |
drive | Front and rear dual differential module drive (total 60Nm) |
Laser sensor quantity | Two 40-meter positioning distances before and after |
Number of vision sensors | 前後6個の障害物回避距離2メートル(障害物回避距離2メートルの3個分、ロボットアームの作業スペースを拡大可能) |
Motion Performance:
最高速度(m/s) | Straight line 1.2 |
Working speed (m/s) | AMR mode 0.6, AGV mode 1.2 |
Turning radius (mm) | 0 |
Rotation radius (mm) | 550 |
Climbing ability (degrees) | 10 |
Obstacle clearance height (mm) | 10 |
Seam width (mm) | 20 |
Ground clearance (mm) | 60 |
Walking channel width (mm) | >=850 |
Rotary channel width (mm) | >=1200 |
Site positioning accuracy (mm) | +/-5 |
Battery life:
バッテリー容量 | 48V 80Ah ((main 40Ah + backup 40Ah), iron phosphate |
Battery life (h) | 10 時間 (全負荷)、16 時間 (ロボット アームとシャーシのそれぞれの 50% が動作) |
Battery life (times) | >1500 charge and discharge cycles |
charging method | Optional manual, automatic charging station, manual battery replacement (maximum charging current 20A) |
Charging time (h) | 3 時間 (メイン 1.5 + バックアップ 1.5) (15% ~ 95%)、バックアップ バッテリーは取り外して個別に充電でき、デバイスの電源を切る必要はありません。 |
Optional Accessories:
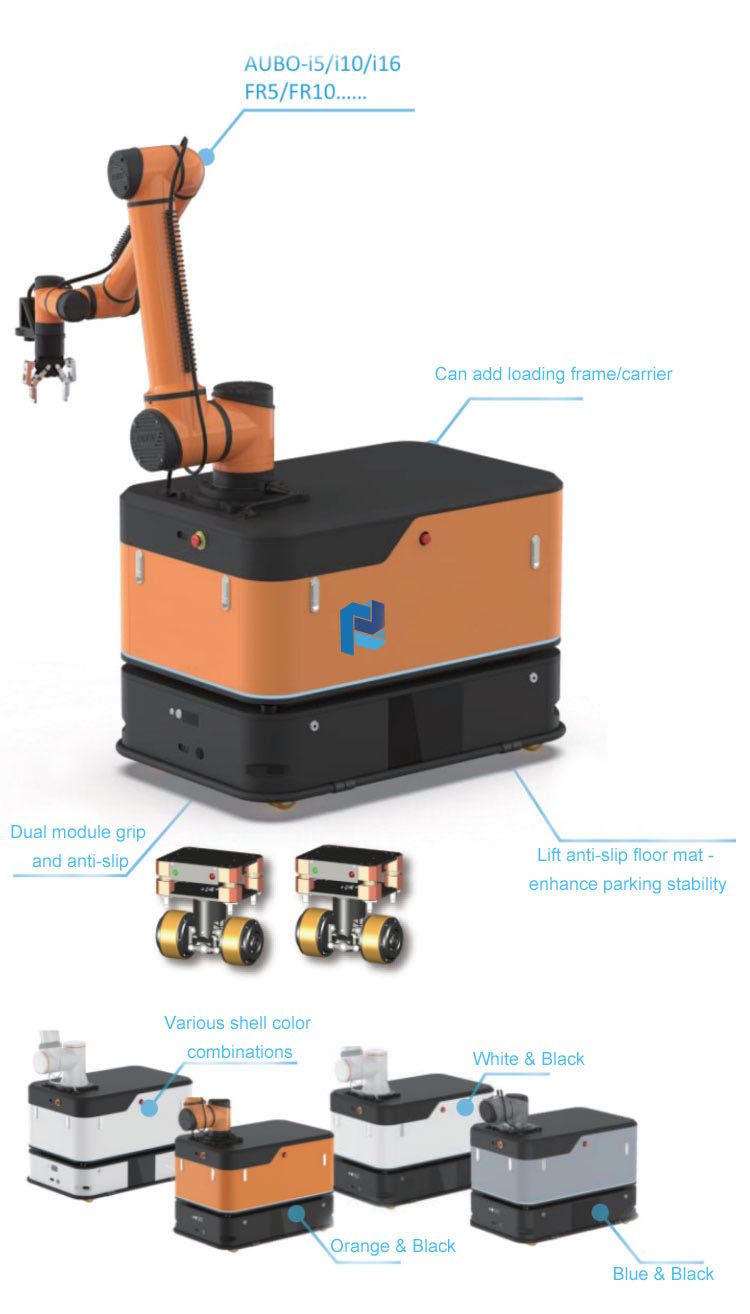
Robotic arm | Configurable AUBO-i5, AUBO-i10, AUBO-i16, FR5, FR10... |
2D camera | 産業用 2D カメラに適合し、ロボット アームの端に取り付けて +/-0.5 mm の精度で 2.5D 位置決めを実現できます。 |
3D camera | ロボットアームの端に取り付けられた構造化光カメラ、双眼3Dカメラに適応可能、精度+/-1mm |
Electric gripper | Can be adapted to two-finger, three-finger adaptive electric claw, two-finger parallel electric claw, vacuum suction cup, etc. |
完全な技術データ
| モデル | TR-CP300S |
|---|---|
| リードタイム | 45日 |
| カテゴリ | モバイルロボットとAMR |
値は 20 °C における公称値です。 CAD モデル、トルク曲線、コントローラー I/O マップのデータシートをダウンロードしてください。
どこで実行されるか
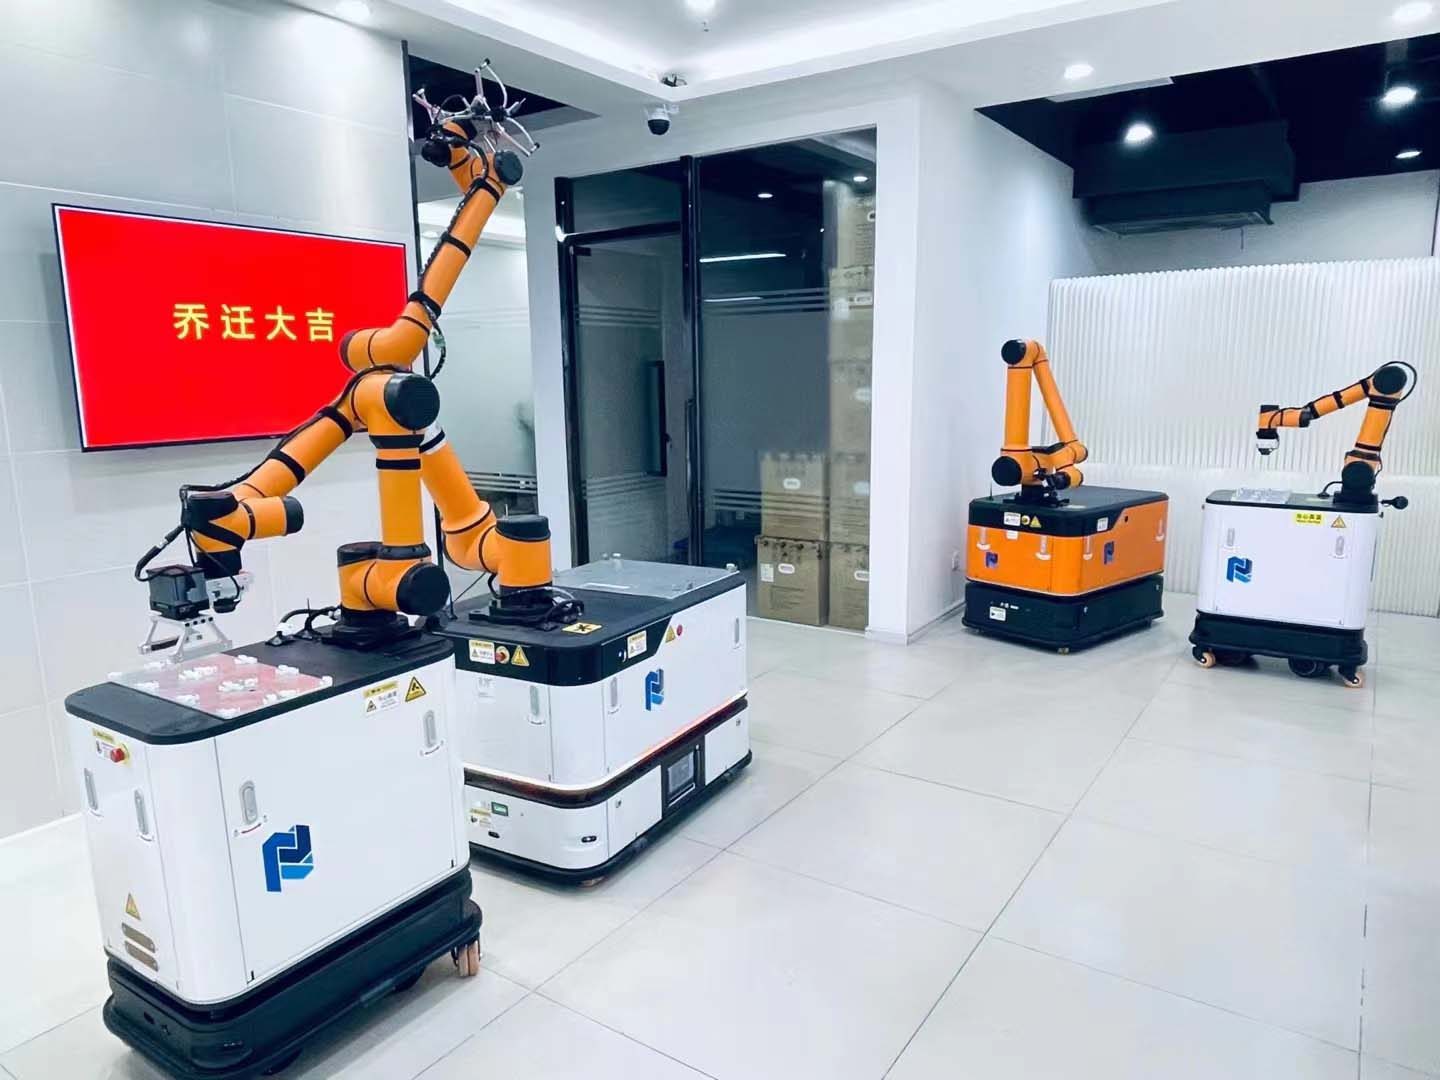
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
購入者の質問
TR-CP300Sの主な仕様は何ですか?
型式TR-CP300S。リクエストに応じて完全なデータシートを入手できます。
TR-CP300SのリードタイムとMOQはどれくらいですか?
リードタイムは45日です。 MOQは1ユニットです。
TR-CP300Sの価格はいくらですか?
価格は構成ごとに見積もられており、該当する場合は工具や輸送費も含まれます。
TR-CP300S の価格提案を取得する
パート、ターゲット レート、宛先ポートを含めます。チャットボットではなくエンジニアが 48 時間以内に返信します。
同じカテゴリ
TROY エンジニアリングによるレビュー ·。仕様は見積ごとにサプライヤーのデータシートと照合して再チェックされます。