


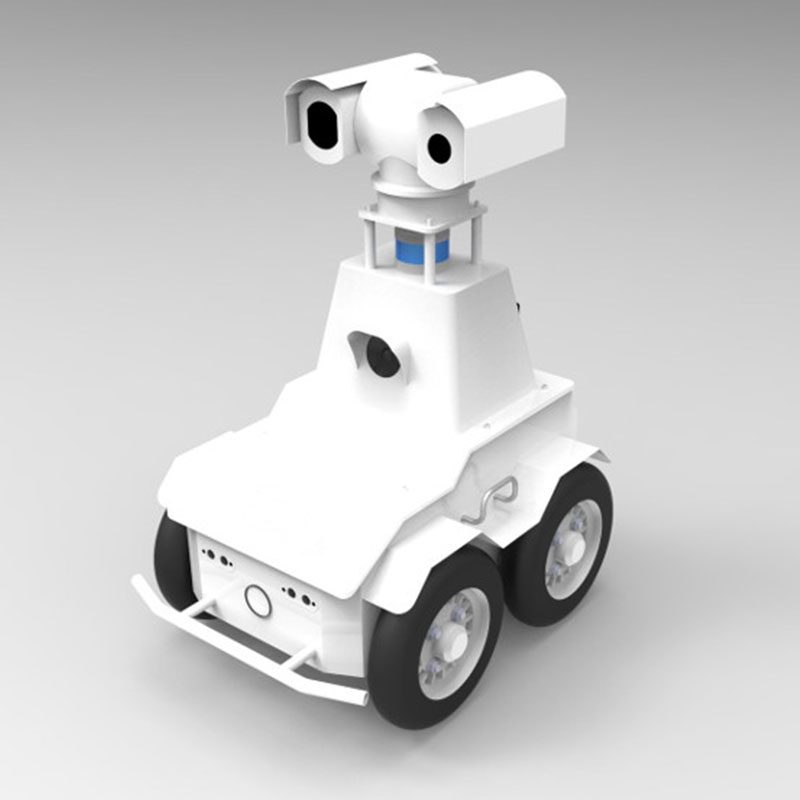
知能検査ロボット TR100M
TR100Mは、接客・清掃用のサービスロボットです。リードタイムは30日です。 pricing is quoted per configuration.認証: ご要望に応じて CE ドキュメントをご提供します。
- モデル
- TR100M
- リードタイム
- 30日
- カテゴリ
- サービスロボット
このプラットフォームの目的
The Inspection Robot uses highly intelligent robot technology and image recognition technology to replace the manual completion of the detection and diagnosis of the equipment operating status in a special environment, realize full coverage inspection of the equipment area, and have multiple functions such as security inspection, environmental monitoring, and smoke sensing. It.
商業条件
| 引用 | 構成ごとの価格 - 48 時間以内にご返信ください |
|---|---|
| リードタイム | 30日 |
| MOQ | 1台 |
| 起源 | 中国 |
| 積地港 | 深セン、中国 |
| インコタームズ | FOB 深セン / CIF (ご要望に応じて) |
| 支払い | 30% のデポジット、出荷前に 70% |
| 保証 | 標準は 24 か月、オプションは 36 か月 |
製品詳細
TROY エンジニアリング ファイルからのアプリケーション ノート、構造図、およびビデオ — 見積書に同梱される同じ文書。
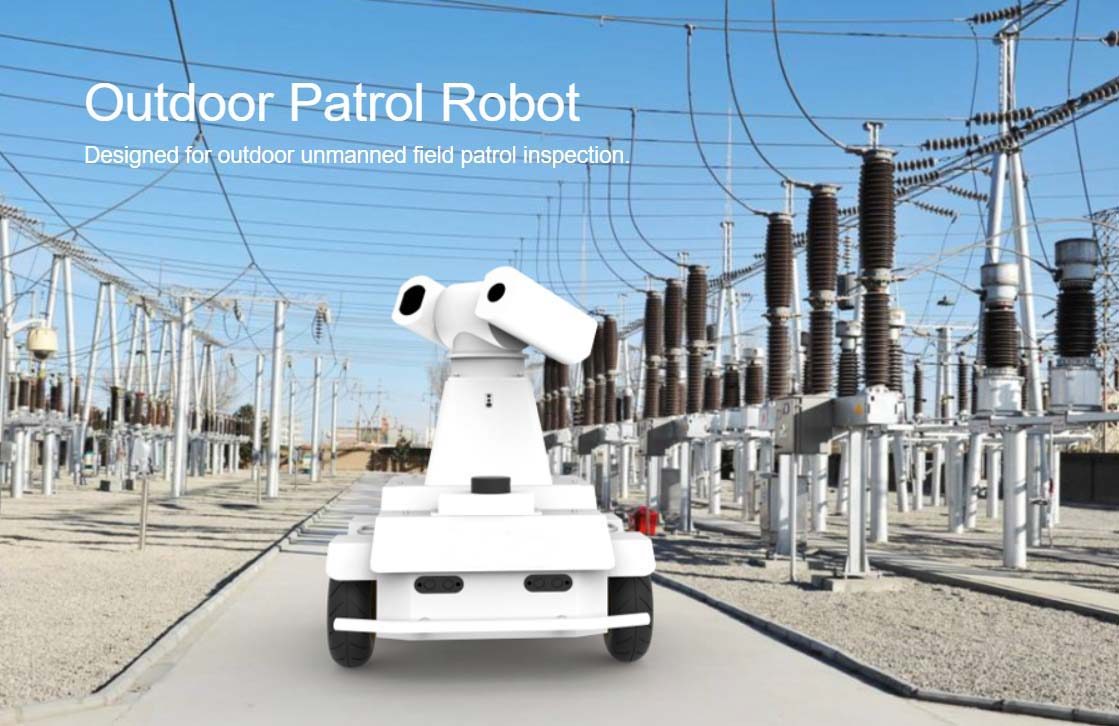
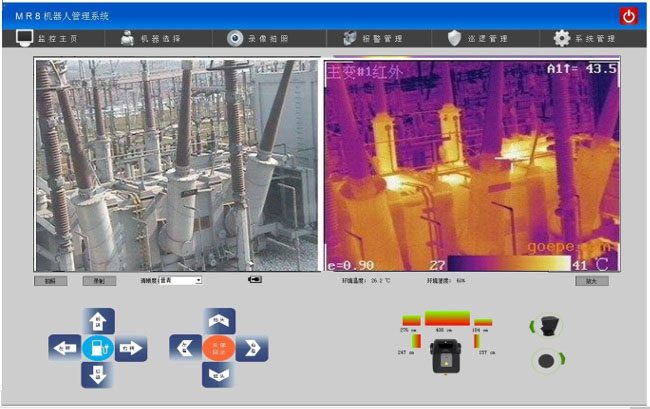
TR100M is an outdoor patrol robot, which was designed for factory field, transformer station, chemical plant and similar applicatin, to perform unmanned field patrol inspection. TR100M uses four driving-wheels chassis, default height is 93 cm and base size is 80cm x 62cm. With waterproof splash design, 50/100 meter outdoor LIDAR do SLAM main job and also perform obstacle avoidance. It can autonomously move the navigation function, automatically walk to the specified position, with build-in vision AI module, TR100M robot can recognize no-authorization human, analyze the operation status of inassigned equipments or objects. According to the alarm conditions set by the user, real-time alarm messages and scene video can be sent to the designated person immediately when found somethings abnormal. With FLIR infrared thermal camera, TR100M inspection patrol robot can no contact measure the view window objects' temperature data and distribution. If the temperature anomaly appears, alarm messages and scene photos will be sent to registed person.
| Basic Functions | Self navigation/ device monitoring/ vision surveillance/ timing patrol/ auto-charging/ report generation |
| Recommended application | IDCデータセンター、自動作業場、電力切替室など。 |
| Size and weight | Height:93CM, Base size:80X62CM,Net weight:58KG(include 20Ah 24V LiFePO4 battery) |
| Localization & Navigation | 2Dレーザーレーダーを使用してロボット周囲の物体の位置情報をスキャンし、SLMAを実現します。 |
| Motors & driving | Two wheel differential drive, Integrated 2X150 hub-wheel motor, high efficiency and low noise. |
| Optical Video Capture | 標準の 2M ピクセル UVC プロトコル HD USB カメラ、画質は 1920X1080 ピクセルに達します。 |
| Infrared thermal image | オプションの FLIR AX8 赤外線熱画像装置。温度範囲は-10~150℃です。 |
| Main hardware | メインボードは産業用 PC、CPU は Core I5 プロセッサ、2G RAM、補助ボードは ARM アーチです。 |
| Robot software system | 主要なO/SはLINUXで、各機能モジュールと通信・連携するためにROS Kineticを搭載しています。 |
| Vision AI algorithm | OPENCVと機械学習アルゴリズムに基づくAI認識アルゴリズム。 |
| Remote Communication | LAN および WAN に適した P2P ピアツーピア通信アーキテクチャに基づいています。 |
| Client Software | クライアント監視ソフトウェアを提供します。PC O/S は WIN7 以降です。顧客開発用のSDKを提供します。 |
| Robot motion features | 巡航速度は0.2~0.8m/秒、最大登坂角度は10度、旋回半径は0.25m。 |
| Camera platform moving | 水平回転角:-180~+180度、ピッチ回転角:-50~+80度。 |
| Obstacle Avoidance | Laser radar scanning, ultrasonic detection and mechanical anti-collision switch three safe. |
| Battery Specification | MR9の内蔵バッテリーは24V20AH LiFePO4タイプです。 |
| Automatic Charging | タスクが完了すると、自動的に充電ステーションに戻り、エネルギーを供給します。 |
| Maximum walking distance | フル充電されたロボットの場合、最大 3000 メートルまで連続歩行できます。 |
完全な技術データ
| モデル | TR100M |
|---|---|
| リードタイム | 30日 |
| カテゴリ | サービスロボット |
値は 20 °C における公称値です。 CAD モデル、トルク曲線、コントローラー I/O マップのデータシートをダウンロードしてください。
どこで実行されるか
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
TROY エンジニアによってサイズ調整と委託が行われました。
購入者の質問
TR100Mの主な仕様は何ですか?
型式TR100M。リクエストに応じて完全なデータシートを入手できます。
TR100MのリードタイムとMOQはどれくらいですか?
リードタイムは30日です。 MOQは1ユニットです。
TR100Mの価格はいくらですか?
価格は構成ごとに見積もられており、該当する場合は工具や輸送費も含まれます。
TR100M の価格提案を取得する
パート、ターゲット レート、宛先ポートを含めます。チャットボットではなくエンジニアが 48 時間以内に返信します。
同じカテゴリ



TROY エンジニアリングによるレビュー ·。仕様は見積ごとにサプライヤーのデータシートと照合して再チェックされます。